
⚙️ How AI Robots Work — The Layered System Behind Every Demo and Every Deployment Failure
Every viral robotics demo you have ever seen was filmed in a controlled environment with people you didn't notice offscreen. Real deployment looks completely different. The people most misled by the gap between what robots do in demos and what they do in the field are the executives, procurement officers, and policymakers making multi-million-dollar decisions based on the wrong mental model. The question this article answers is the one the demos never do: what is actually happening inside the system, where does it break, and why does that gap between the demo and the deployment exist at all?
The logistics manager had watched the demo three times before signing the purchase order. The robotic system picked packages cleanly, sorted them by destination, and handled exceptions smoothly. The vendor's team was professional. The system was genuinely impressive. Six weeks into deployment, she was managing a different situation: the robots were performing at about 70% of their demo rate, struggling with packages that differed slightly from the training distribution, requiring a human supervisor on every shift to handle the edge cases that kept appearing, and generating a maintenance burden nobody had scoped into the budget. The system was not broken. It was doing exactly what it had been designed to do. The problem was that the design had been validated in conditions that did not match her facility.
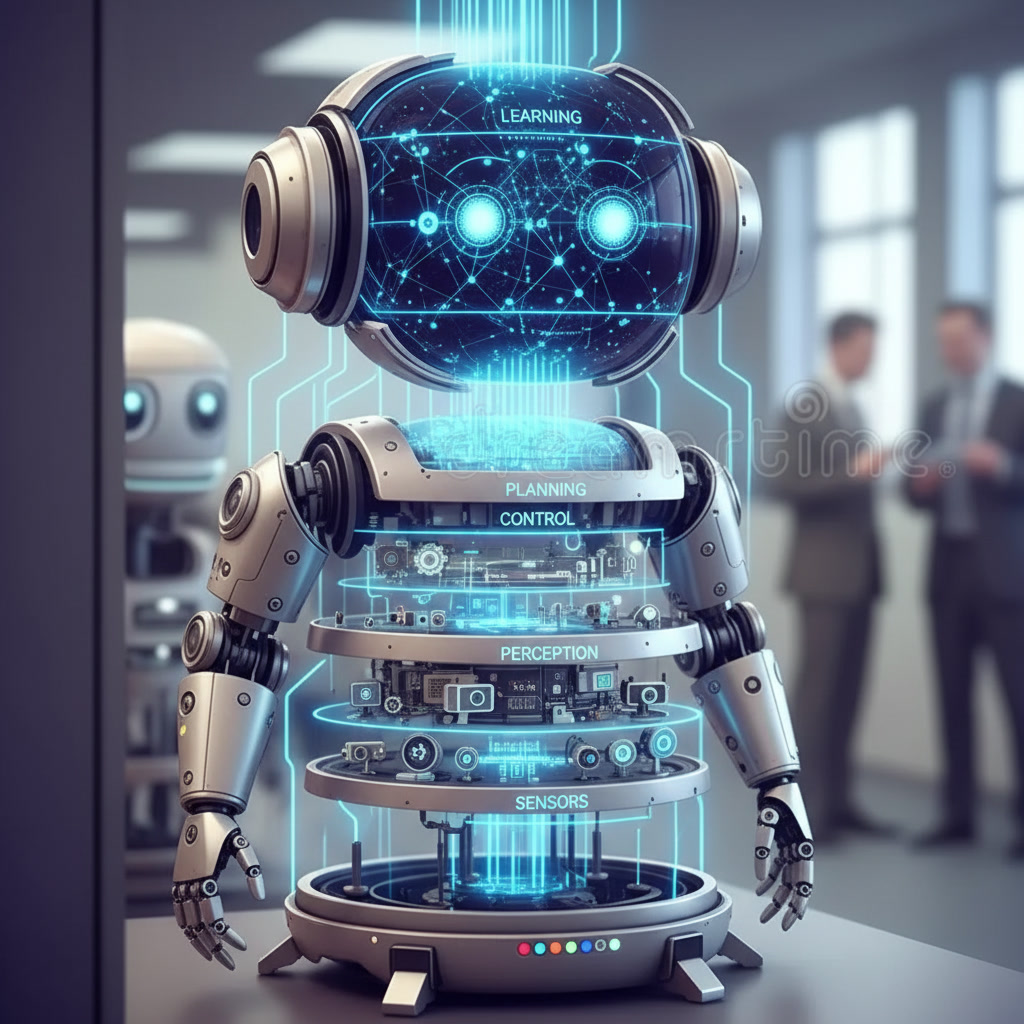
That gap between demo performance and deployment performance is the most consequential misunderstanding in AI robotics right now, and it flows directly from not understanding how these systems actually work. An AI robot is not a single intelligent machine. It is a layered system of coordinated components — sensors that read the environment, perception software that interprets what those sensors detect, planning modules that decide what to do, control systems that execute those decisions physically, and learning mechanisms that improve performance over time. Every layer can fail. Failures at the boundaries between layers are the most common cause of real-world underperformance. And the conditions that expose those failures are precisely the unpredictable, variable, messy conditions that demos are designed to avoid. If you are buying, deploying, managing, or regulating AI robotic systems, the mental model matters as much as the specification sheet.
How Do AI Robots Work?
An AI robot is a layered system in which hardware sensors collect environmental data, AI software interprets that data to build a model of the world, planning algorithms decide what actions to take, and physical control systems execute those decisions — with learning mechanisms updating the system's performance based on what actually happens. Each layer operates on the output of the previous one, which means a small error in perception produces a compounding error in planning, which produces a compounding error in control. For anyone evaluating, purchasing, or deploying AI robotic systems, understanding this layered architecture is the difference between assessing a system accurately and being surprised by the gap between its demonstrated capability and its operational reliability.
How Are Different Markets Putting This System Into Practice?
The deployment of AI robotic systems globally reveals which layers of the autonomy stack are maturing, which remain fragile, and where the gap between capability and reliability still sits.
South Korea and Japan represent the most advanced real-world integration of complete autonomy stacks at industrial scale. South Korea maintains 1,012 robots per 10,000 manufacturing employees — the world's highest density — and Japan has 414,000 industrial robots in active operation, according to IFR World Robotics 2024–2025. Both countries are operating at the frontier of what tight human-robot interaction looks like when systems have been refined through years of real-world exposure rather than lab validation. The high density is not purely about hardware — it reflects decades of investment in the full stack: sensor reliability, perception calibration, planning systems trained on real operational data, and control systems refined through millions of hours of actual use in uncontrolled environments.
Europe is investing specifically in the perception layer, which consistently proves to be the most critical single point of failure in real-world deployment. As of 2025, computer vision algorithms — the primary perception tool in the autonomy stack — were embedded in 79% of service and industrial robots globally, according to SQ Magazine AI Robotics Statistics (2025). Horizon Europe allocated €1.8 billion for robotics and AI research from 2024–2027, with significant funding directed toward the gap between perception performance in controlled environments and perception reliability in the variable conditions of actual deployment. European industry is also leading on the governance dimension of how AI robotic systems operate: the EU AI Act's requirements for interpretability and human oversight in high-risk AI applications create specific demands on the planning and control layers of the stack, pushing manufacturers to build systems whose decisions can be audited and overridden.
The United States is generating the clearest data on how individual stack layers are improving in practice. Adaptive control AI allowed robotic arms to handle 22% more object types with minimal reprogramming in 2025, and AI-powered trajectory planning cut manufacturing motion cycle times by 15%, according to SQ Magazine AI Robotics Statistics (2025). Those numbers describe genuine layer-level progress. The harder measure — sustained, reliable operation across months in unstructured real-world environments, without human supervision for edge cases — remains undemonstrated at scale. Bain & Company's 2025 Technology Report found that most humanoid robot deployments remain early-stage, with heavy reliance on human supervision, and that intelligence and perception are advancing fastest while handling dexterity and battery life remain gating constraints. That distribution of progress across layers is exactly what the stack model predicts: different layers mature at different speeds, and the system is only as reliable as its weakest point.
What Is Actually Happening Inside an AI Robot When It Works — and When It Breaks?
In practice, an AI robot works by continuously running a loop: sensing the environment, building an internal model of what is happening, deciding what to do, acting on that decision, and updating its model based on the result of the action.
Think about how an experienced cook works in a busy kitchen during service. They are constantly reading the environment — the pan temperature, how the sauce is reducing, how much time each table has been waiting, what the other cooks around them are doing. They build a running model of what is happening, decide what action to take next, execute it with practised physical precision, and update their model based on what happens. They are also learning continuously: if the sauce reduces faster than expected tonight because of a different cream, they adjust mid-service and remember the adjustment. Now imagine that cook has never worked in a kitchen that serves more than thirty covers, and you put them in a two-hundred-cover restaurant on a Saturday. Their skills are genuine. Their system is real. But the conditions are outside their operational experience, and the failures appear not in their fundamental technique but at the boundaries of what their experience has prepared them for. That is exactly how an AI robotic system fails in real-world deployment. Its perception, planning, and control work. The boundaries of its training distribution are where it encounters conditions it cannot handle reliably.
"As of 2025, computer vision algorithms were embedded in 79% of service and industrial robots globally — making visual perception the most deployed single layer in the AI robotics stack, and the one whose failure modes most directly explain the gap between demo performance and operational reliability." (Source: SQ Magazine AI Robotics Statistics 2025)
Rules Gave Way to Learning, and Failure Modes Changed
Traditional robots operated on explicit rules: if this condition, then this action. The rules were written in advance, covered every anticipated situation, and failed whenever reality deviated from what the rules anticipated. The shift to AI-enabled robots replaced explicit rules with learned models — systems trained on data rather than programmed on instructions. The organisations and researchers that understood this transition first began investing in data collection as a core robotic capability, recognising that the quality and diversity of training data would determine the quality and reliability of deployed behaviour more than any architectural improvement in the models themselves. The failure modes changed completely: instead of failing predictably when a rule didn't match the situation, AI robots now fail at the boundary of their training distribution — in ways that are often harder to anticipate and harder to diagnose, because the failure is a statistical rarity rather than a logical gap.
The Sim-to-Real Gap Became the Field's Central Challenge
The second development was the discovery of how poorly systems trained in simulation transferred to real environments. The sim-to-real gap — the difference between how a system behaves in its training environment and how it behaves in deployment — proved larger and more stubborn than most researchers had expected. Controlled environments rarely reveal the types of failures that appear during daily operation: lighting variation that degrades perception accuracy, floor surfaces that affect traction and control, objects positioned slightly differently from training examples, and human behaviour that the system was never trained to model. The survival strategy for organisations deploying AI robotic systems in real environments is to treat the first months of deployment as a structured data collection exercise — capturing the real-world conditions that simulation missed, using them to retrain the perception and planning layers, and iterating faster than any lab-based validation process could achieve. As one robotics engineer documented after 13,000 hours of field deployment, real-world operation is where most of the actual engineering work begins — not where it ends.
Integration Quality Became the Real Differentiator
The result is a field where the differentiating capability is no longer the performance of any individual layer but the quality of integration across all of them. In research, perception, planning, control, and hardware reliability are often developed separately by different teams. In deployed systems, those boundaries disappear: a perception model that performs well in isolation but degrades slightly in poor lighting forces the planning module to compensate; if the map drifts, the control system must remain stable; if a sensor temporarily fails, the robot must recover safely. The organisations that win in AI robotics at scale are the ones that treat the integration layer as a first-class engineering investment — not as the final step after all the components are built, but as the primary design constraint that shapes how every component is built. South Korea's decades of investment in this integration discipline — reflected in its world-leading robot density of 1,012 per 10,000 manufacturing workers — is the most compelling evidence that integration quality, sustained over time through real operational learning, is the compound advantage that no amount of component-level progress can substitute for.
Is AI Robotics Overhyped, Underestimated, or Genuinely Somewhere In Between?
Two genuine, well-grounded concerns drive most of the credible scepticism and most of the credible excitement about how AI robots work, and both reflect real evidence rather than uninformed opinion.
The first concern is that the demo-to-deployment gap is being systematically obscured by an industry with strong incentives to present its best conditions as representative conditions. Viral robotics videos are, without exception, filmed in circumstances that have been optimised to show the system at its peak. The failure rates, the edge cases, the hours of human supervision required to manage exceptions, and the environmental constraints that make the system work — none of these appear in the demo footage. Procurement decisions made on the basis of demos rather than deployment data are systematically biased toward overconfidence, and the organisations bearing the cost of that overconfidence are the ones that discover the gap after the system is live.
The second concern runs in the opposite direction: that justified caution about current-generation systems is causing decision-makers to underestimate how fast the relevant layers of the stack are improving, and to miss deployment windows during which early movers will build operational data advantages that late adopters cannot recover. The 22% improvement in object handling and 15% improvement in motion efficiency documented in 2025 alone represent genuine progress at the component level. The perception layer is approaching human capability in structured environments. Learning systems are improving faster than most deployment timelines assume.
The hard structural truth specific to how AI robots work is that both concerns are correct about different parts of the same system, and the resolution requires understanding the stack. A robotics system is only as reliable as its weakest layer, which means the impressive performance of individual components is irrelevant to deployment outcomes unless the integration between those components is equally reliable — and integration reliability is the part of the stack that only real-world operational data can build.
The gap between how AI robots work and how AI robots are represented is itself a governance problem — and how organisations close that gap will determine who captures the coming wave of robotic deployment and who inherits its failures.
This development reinforces:
What is Physical AI: Physical AI and the AI robotics stack are the same problem described at different levels of abstraction — understanding how the sense-decide-act loop works at the system level explains why physical AI is harder to deploy reliably than software AI.
Where Robots are Used: The deployment environments where AI robots succeed or fail are not random — they correspond to the specific conditions that stress different layers of the autonomy stack, and understanding the stack predicts which environments are ready for robots and which are not.
Ethics & Governance: The accountability question in AI robotics — who is responsible when a system fails in deployment — is unanswerable without understanding how the system works, because failures in layered systems often cross the boundaries between developer, deployer, and operator responsibility in ways that require stack-level understanding to assign correctly.
The logistics manager eventually built a deployment protocol that matched the robot's operational envelope to her facility's actual conditions — running a structured mapping phase before full deployment, collecting edge-case data during a supervised parallel operation period, and defining explicit handoff criteria for when the system would require human intervention. The system's performance improved significantly over the following two months. What changed was not the robot. It was the process surrounding the robot, which had been designed with a clear understanding of where the system's layers were reliable and where they were not. That understanding — of the stack, not the demo — is what determined the outcome.
1. How do AI robots work in simple terms? An AI robot works by running a continuous loop: sensors collect data from the environment, AI software interprets that data to understand the situation, planning algorithms decide what action to take, physical control systems execute that action, and learning mechanisms update the system's behaviour based on what happens. Each stage depends on the accuracy of the previous one, which means a small error in perception — misidentifying an object or misreading a position — compounds into a larger error in planning and action. As of 2025, computer vision algorithms were embedded in 79% of service and industrial robots globally, according to SQ Magazine AI Robotics Statistics (2025), making visual perception the most widely deployed single layer in the stack.
2. Why do robots work in demos but fail in real-world deployment? Demos are filmed in controlled environments where variables have been optimised to show the system at its best — consistent lighting, familiar objects, predictable human behaviour, and known environmental conditions. Real deployment introduces variability that falls outside the system's training distribution: different lighting conditions, objects positioned unexpectedly, unfamiliar surfaces, and human behaviour the system was never trained to anticipate. Failures occur not because the individual components are poor but because the system encounters conditions at the boundary of what its training data covered, and the integration between layers breaks down when any single layer produces degraded output.
3. What is the robotics autonomy stack? The robotics autonomy stack is the layered architecture of components that together allow an AI robot to act intelligently in the physical world: sensors that collect raw data, perception software that interprets it, world models that build situational understanding, planning systems that decide what to do, control systems that execute physical movement, and learning mechanisms that improve performance over time. The stack is not a single AI model — it is a system of coordinated components where the reliability of each layer determines the reliability of the whole. South Korea's world-leading robot density of 1,012 per 10,000 manufacturing workers, according to IFR World Robotics 2024–2025, reflects decades of investment in making this full stack work reliably under real industrial conditions.
4. What is the sim-to-real gap in robotics? The sim-to-real gap is the difference between how an AI robotic system behaves in its simulated training environment and how it behaves when deployed in the real world. Systems trained in simulation often encounter conditions in deployment — variable lighting, irregular surfaces, unexpected object positions — that were not present in training, causing the perception and planning layers to produce outputs they were not calibrated for. Closing the sim-to-real gap is one of the central engineering challenges in the field and is why organisations that treat early deployment as a structured data collection exercise, using real operational experience to retrain their systems, consistently outperform those that rely on simulation alone.
5. Which part of an AI robot is most likely to fail? Failures most commonly occur at the integration boundaries between layers — where the output of one component becomes the input of another — rather than within any single component. A perception system that performs at 94% accuracy in controlled conditions may produce subtly different outputs under different lighting; those differences cascade into planning errors, which cascade into control errors. Adaptive control AI has improved robotic handling by 22% in 2025 according to SQ Magazine, and trajectory planning has improved manufacturing cycle times by 15% — but sustained reliability across months of real-world unstructured operation remains the unsolved challenge, precisely because full-system integration under real conditions is harder to engineer and validate than any individual layer's standalone performance.














