

公司简介
US maker of SlipBot and SlipLift robots that autonomously load and unload truck trailers in about five minutes.
机器人媒体与亮点
精选机器人视频
暂无精选机器人视频
暂无视频
该公司尚未关联精选机器人视频。
相关新闻
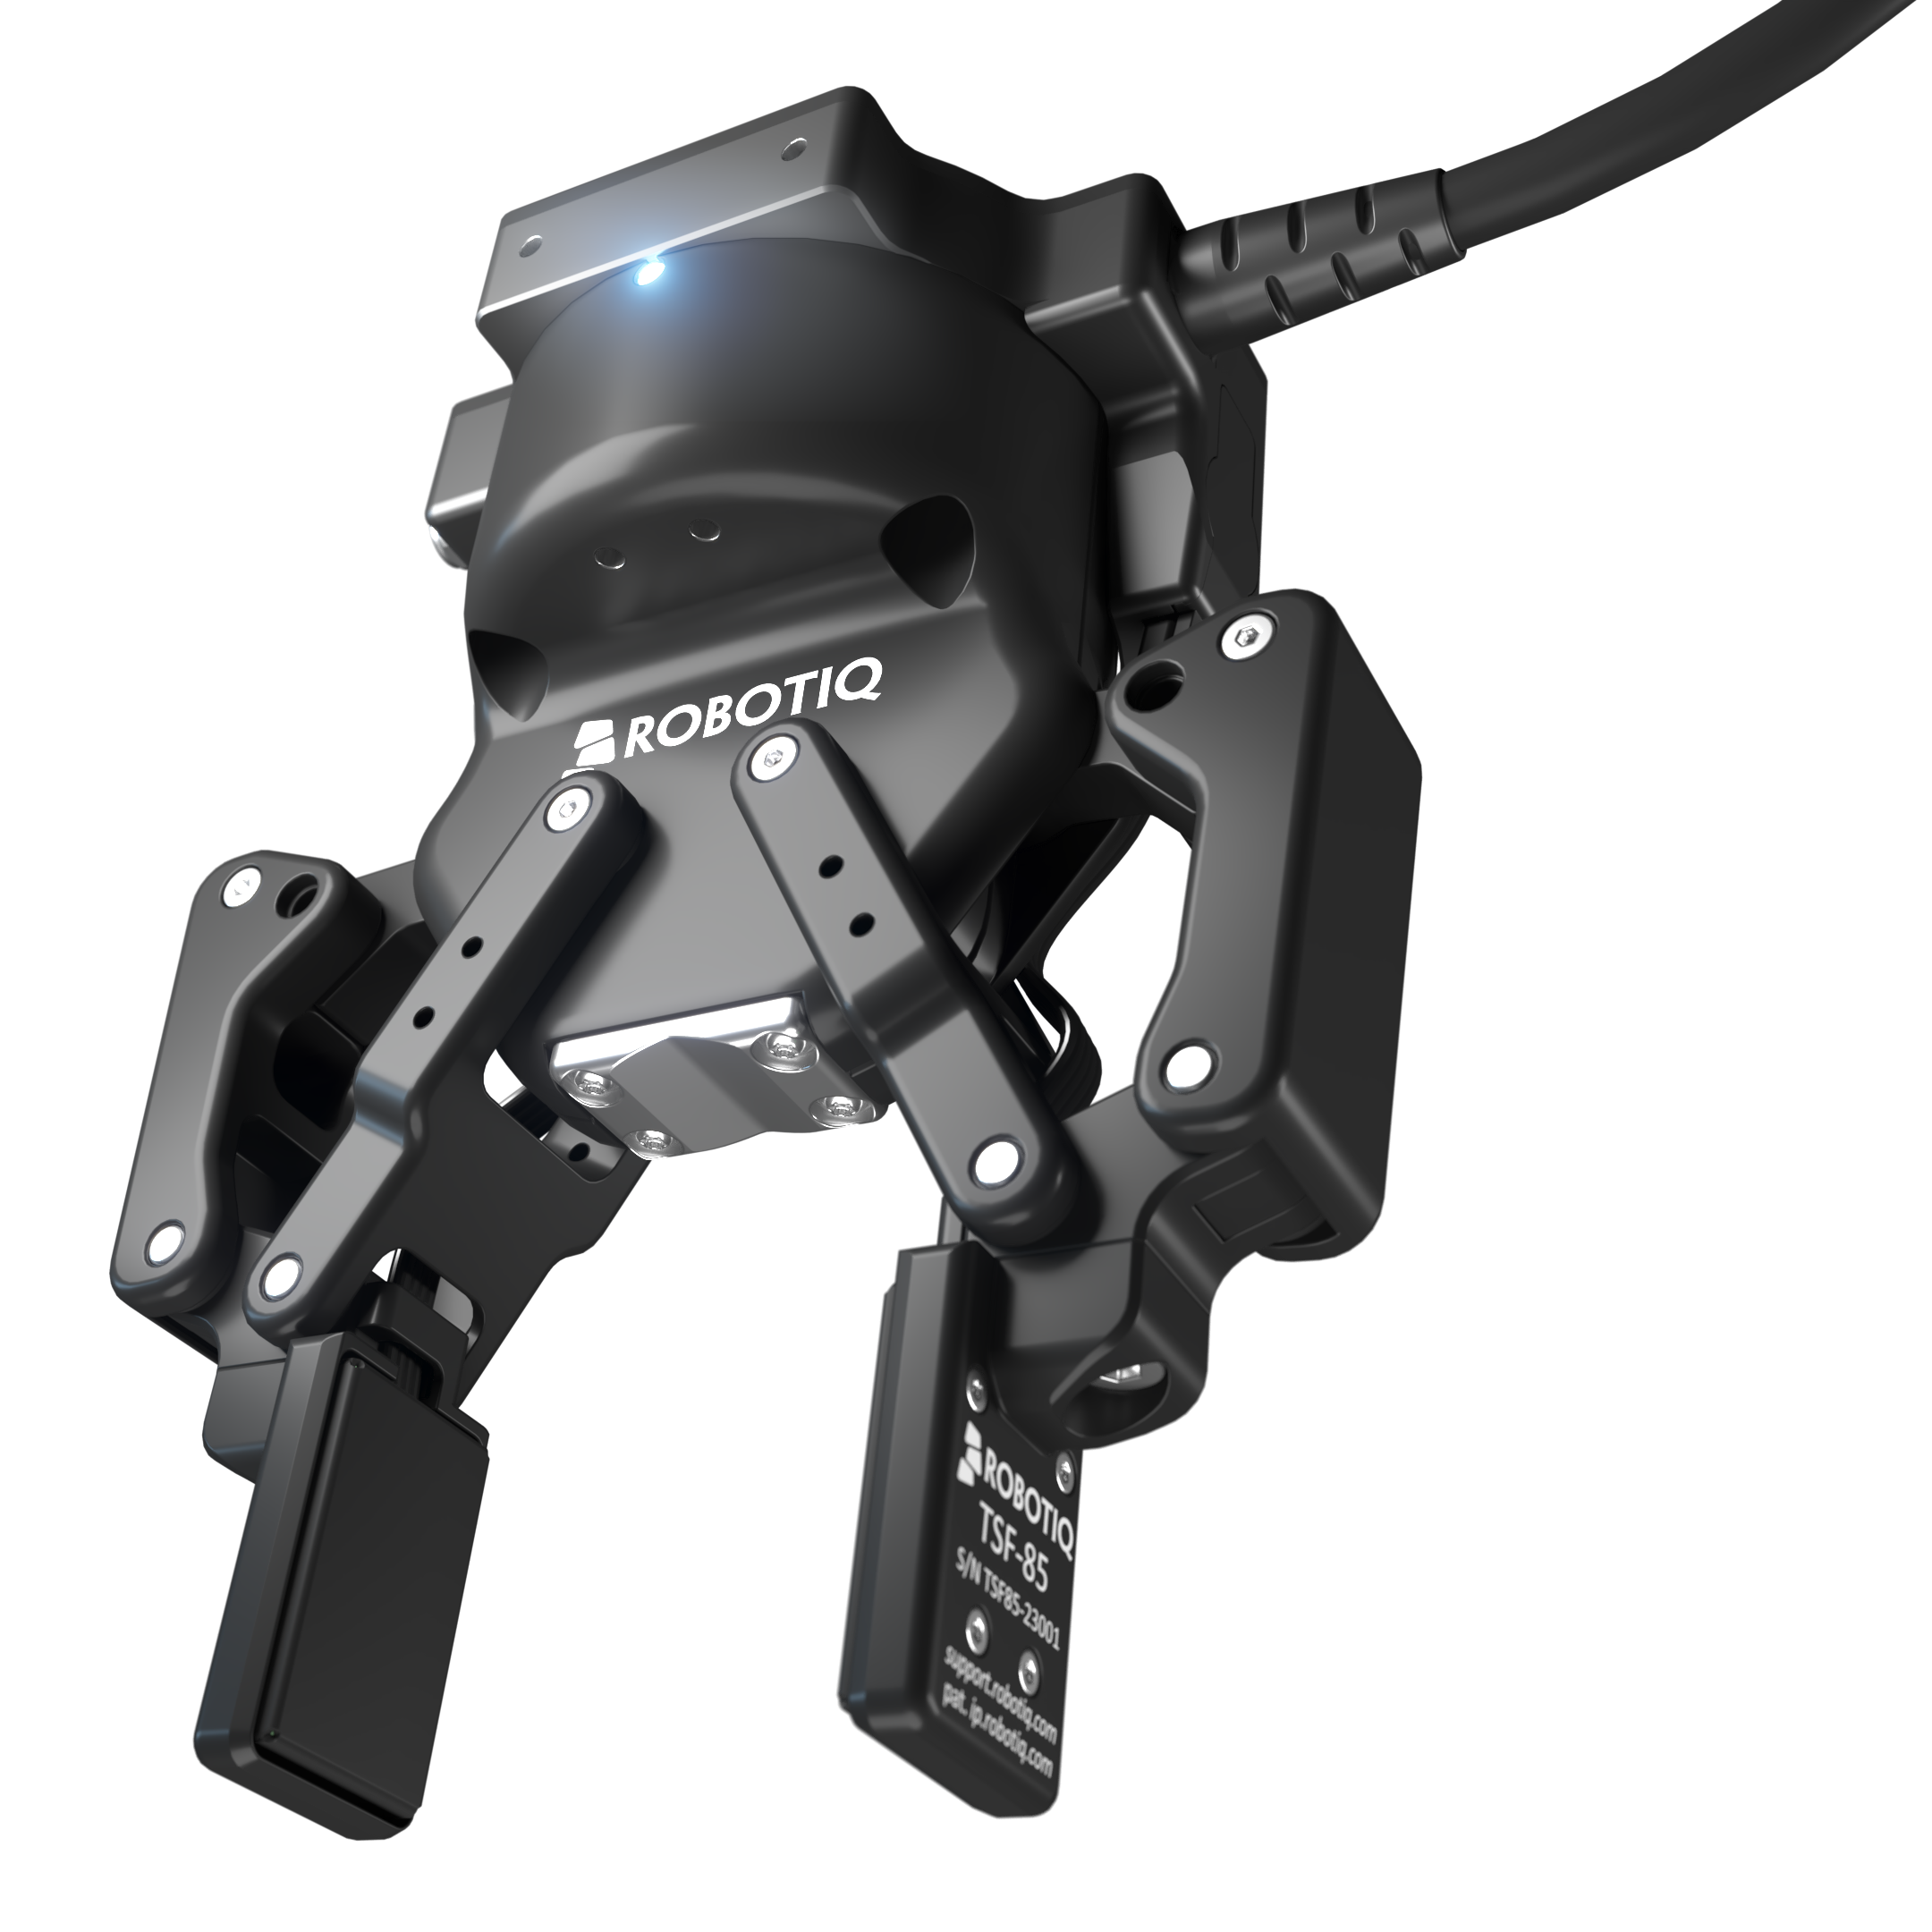
Robotiq's 2FC Gripper Puts Grasp Intelligence Where the Contact Happens
Robotiq has opened pre-orders for the 2FC, an adaptive gripper line (2FC-85 and 2FC-140) that embeds tactile sensors and onboard compute directly into the finger assembly, letting a robot judge grasp quality and detect slip locally instead of relying on a remote model. The gripper ships in two stroke sizes with 2-million-cycle durability, a single-cable Ethernet interface, and an upgrade path for existing 2F-85/2F-140 owners. Shipping begins Q1 2027; pricing is quote-based.
OpenAI Says It Will Build a Humanoid, With a Demo Target of 2027
Sam Altman said OpenAI will build a humanoid and expects a 2027 demonstration, with street-ready robots years further out.
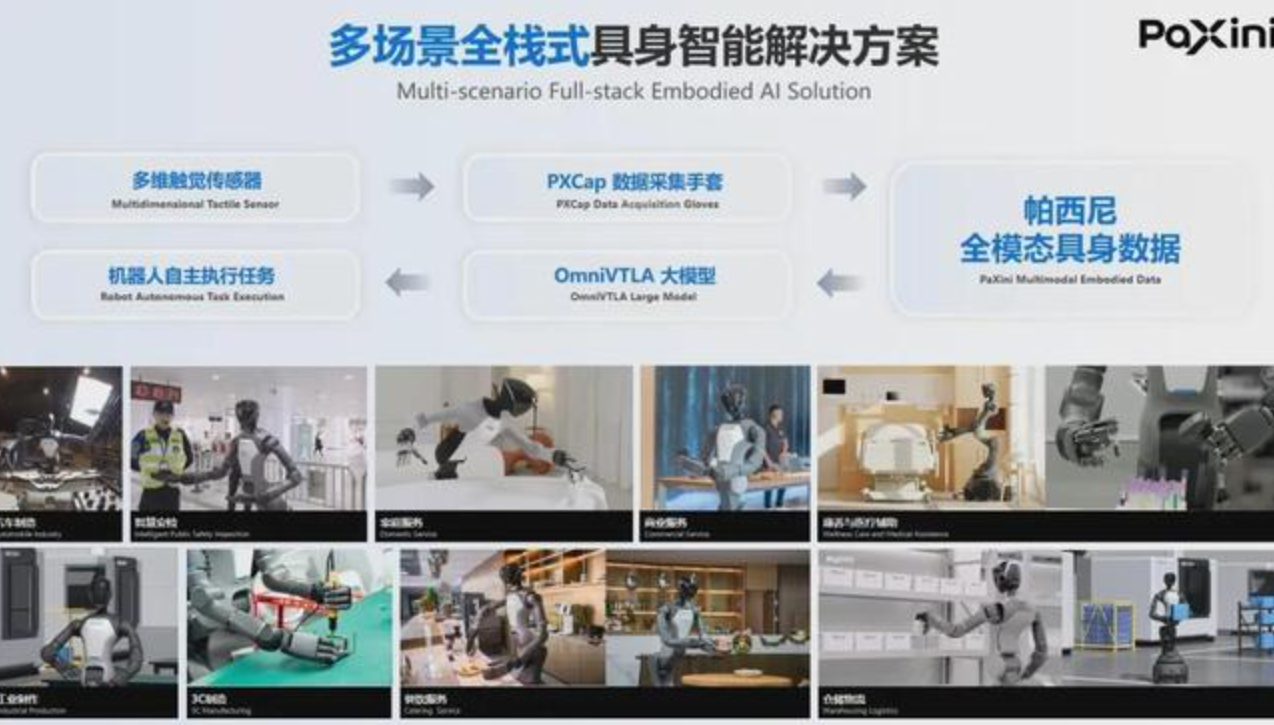
Paxini Raises RMB 1 Billion as Tactile Stacks Draw Capital
Tactile-sensing company Paxini closed a RMB 1 billion strategic round, lifting cumulative funding to nearly RMB 4 billion while moving its headquarters to Beijing.
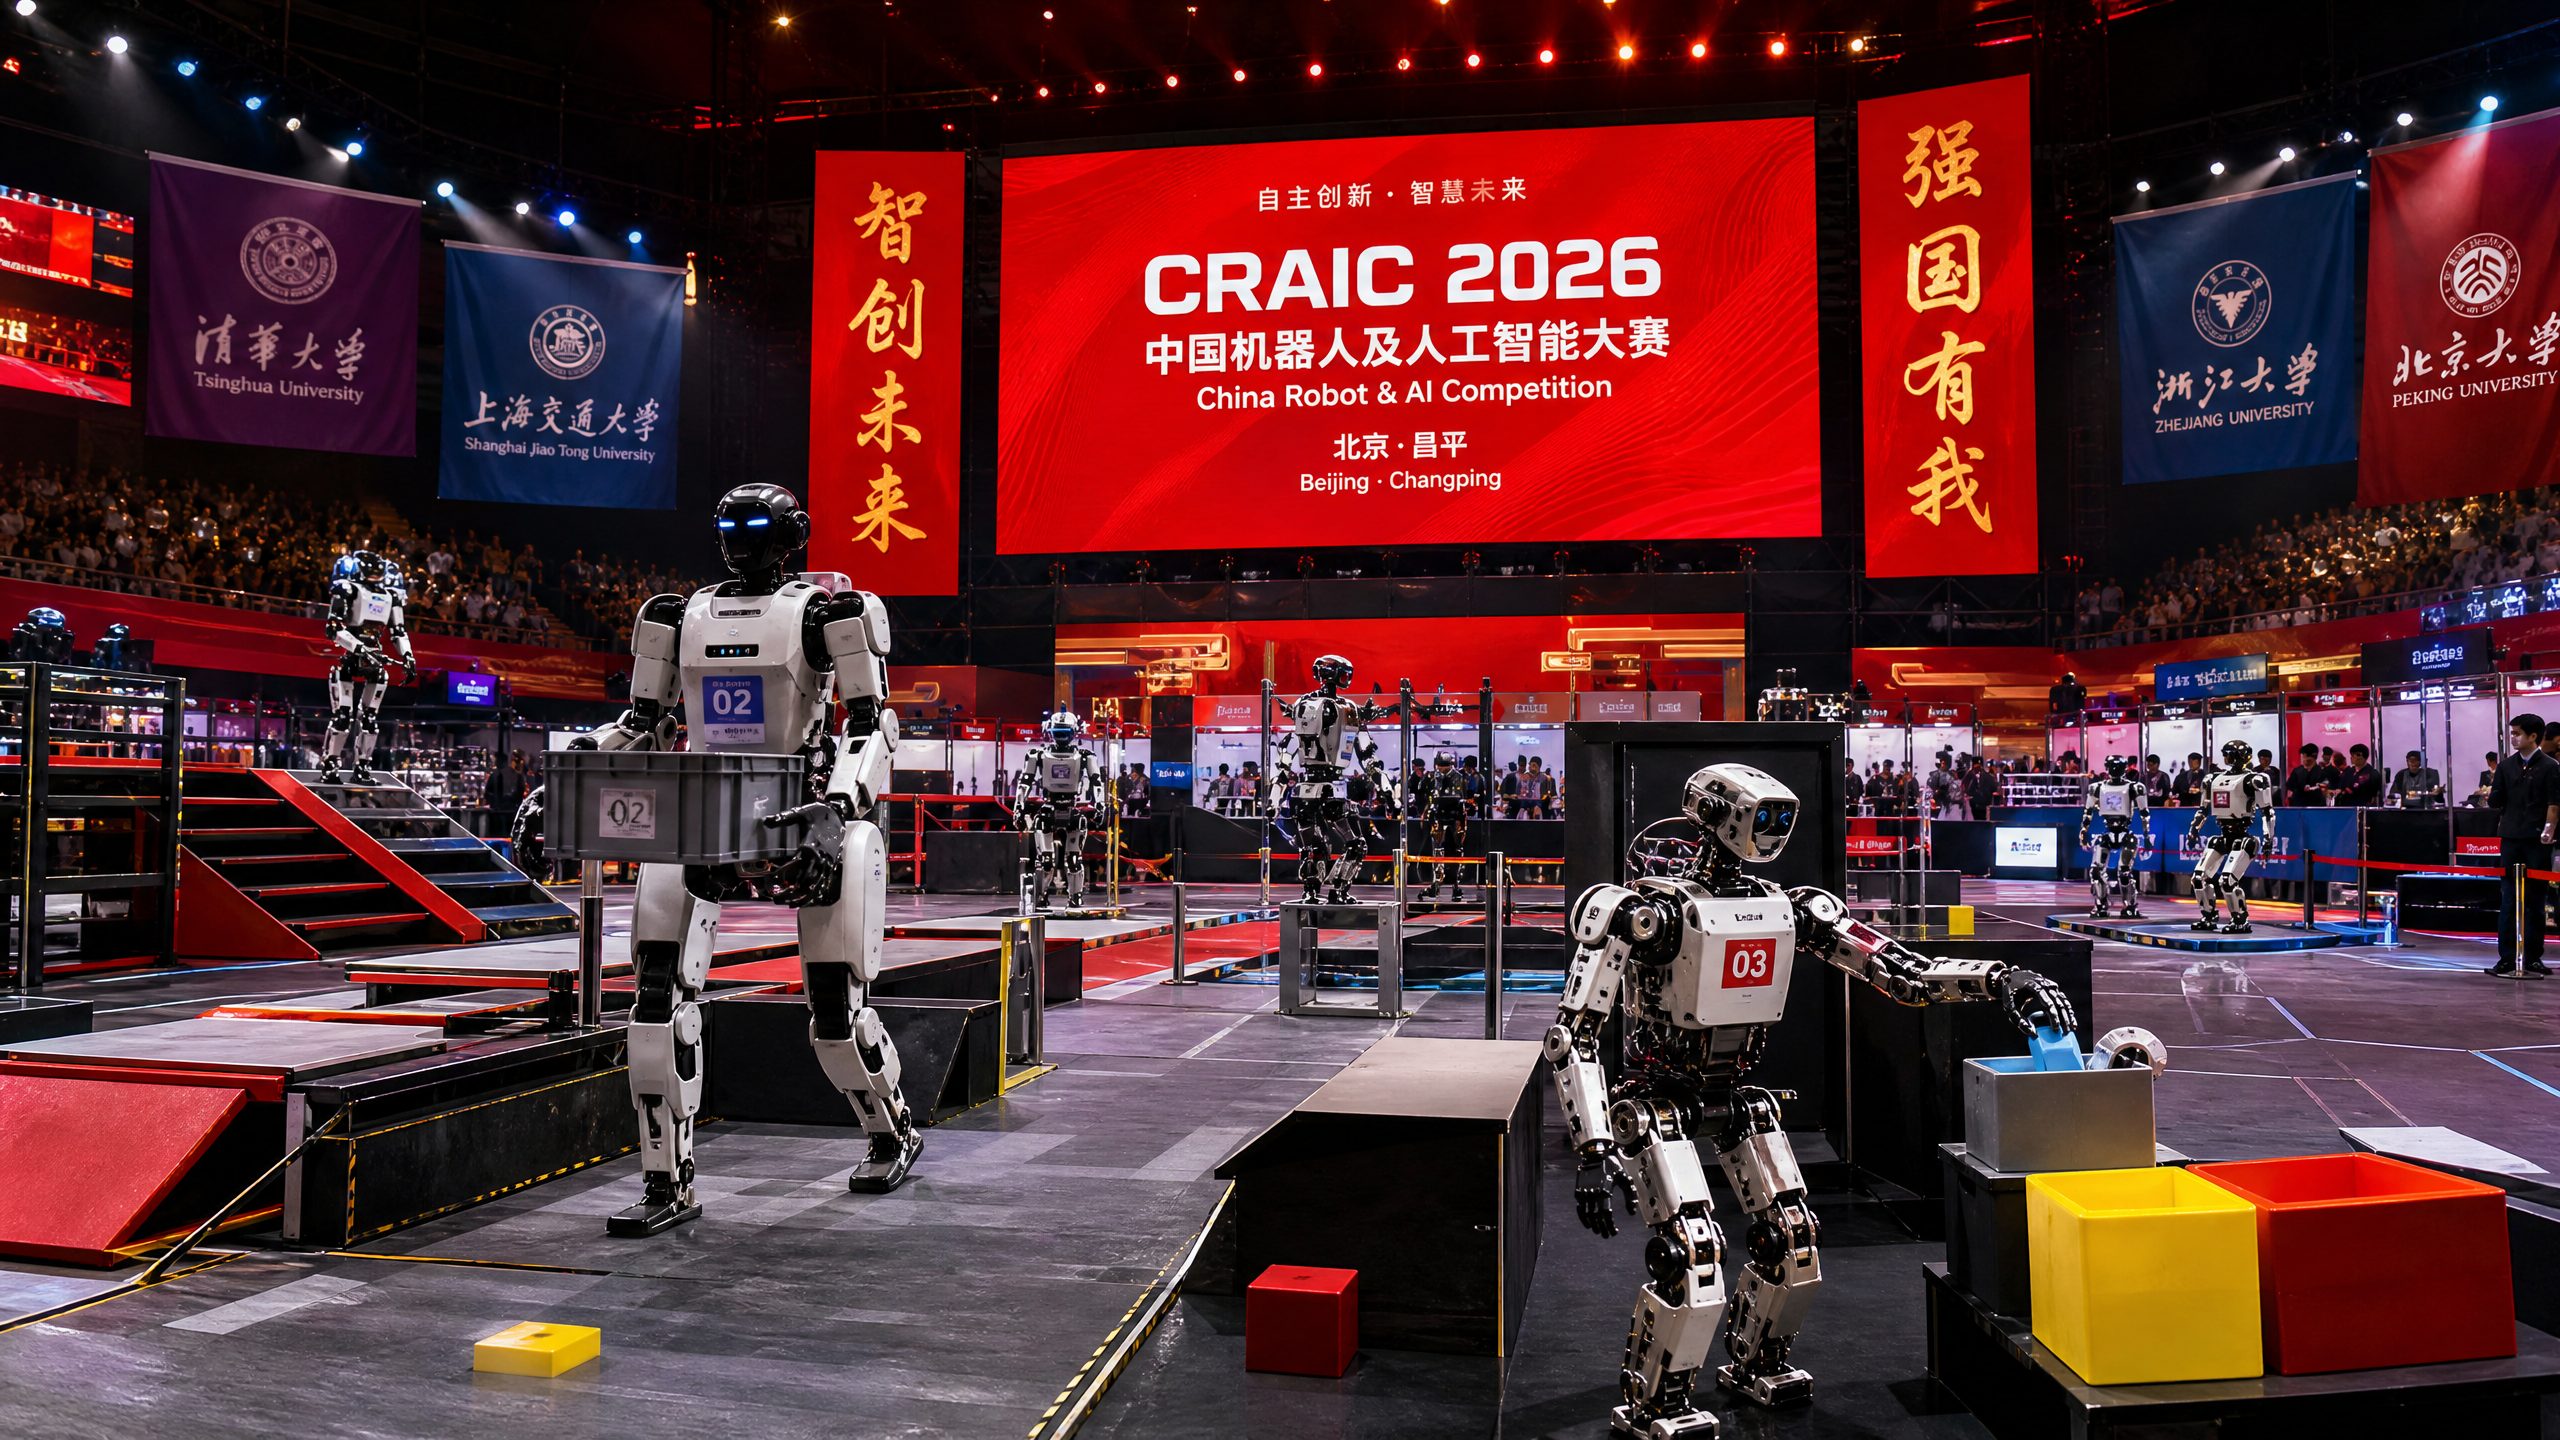
Beijing finals put 350 humanoid robots through first true autonomy test
China’s CRAIC national finals for humanoid robots in Beijing brought 213 university teams and 350 machines into the first full size competition without remote control, stressing industrial tasks and language model driven interaction. The shift signals a push from academic showcase to a national talent pipeline for factory ready embodied AI.
Robots Can See. This Shanghai Lab Just Published 30,000 Hours of Teaching Them to Feel
Shanghai startup NeoteAI (Xinzhi Embodied Intelligence) and Fudan University's Institute of Trustworthy Embodied AI released three technical reports on July 26 built on what they describe as more than 30,000 hours of visual-tactile interaction data, around 1.4 million manipulation clips across 450 real long-horizon tasks. The stack spans a tactile dataset (NeoData), a unified tactile representation model (NeoForce), an anticipatory visuo-tactile-language-action model (VTLA) reporting 85 to 99 percent success on contact-rich tasks, and a tactile world model (TWAM), with data and models pledged as open source. It is the most aggressive public claim yet that touch, not vision, is the next scaling frontier in robot learning.
A Hangzhou Startup Says the Dexterous Hand Race Is Really a Durability Race, and Investors Just Agreed
Shiyue Technology, a Hangzhou dexterous-hand startup founded just five months ago, has raised nearly CN¥100 million (about US$14 million) in angel funding co-led by ZWC Partners and Twenty Venture. The company is unusual in a crowded segment for having revenue before its Series A: its Lumi-Dex hands are already shipping, with claims of 5,000-hour continuous operation and full-palm tactile sensing at a cost-controlled price point. In a market where dexterous hands are widely seen as the bottleneck between humanoid demos and productive work, Shiyue’s operating-hours-first positioning is a bet that reliability, not anatomical fidelity, decides which suppliers survive the coming consolidation.
相关文章
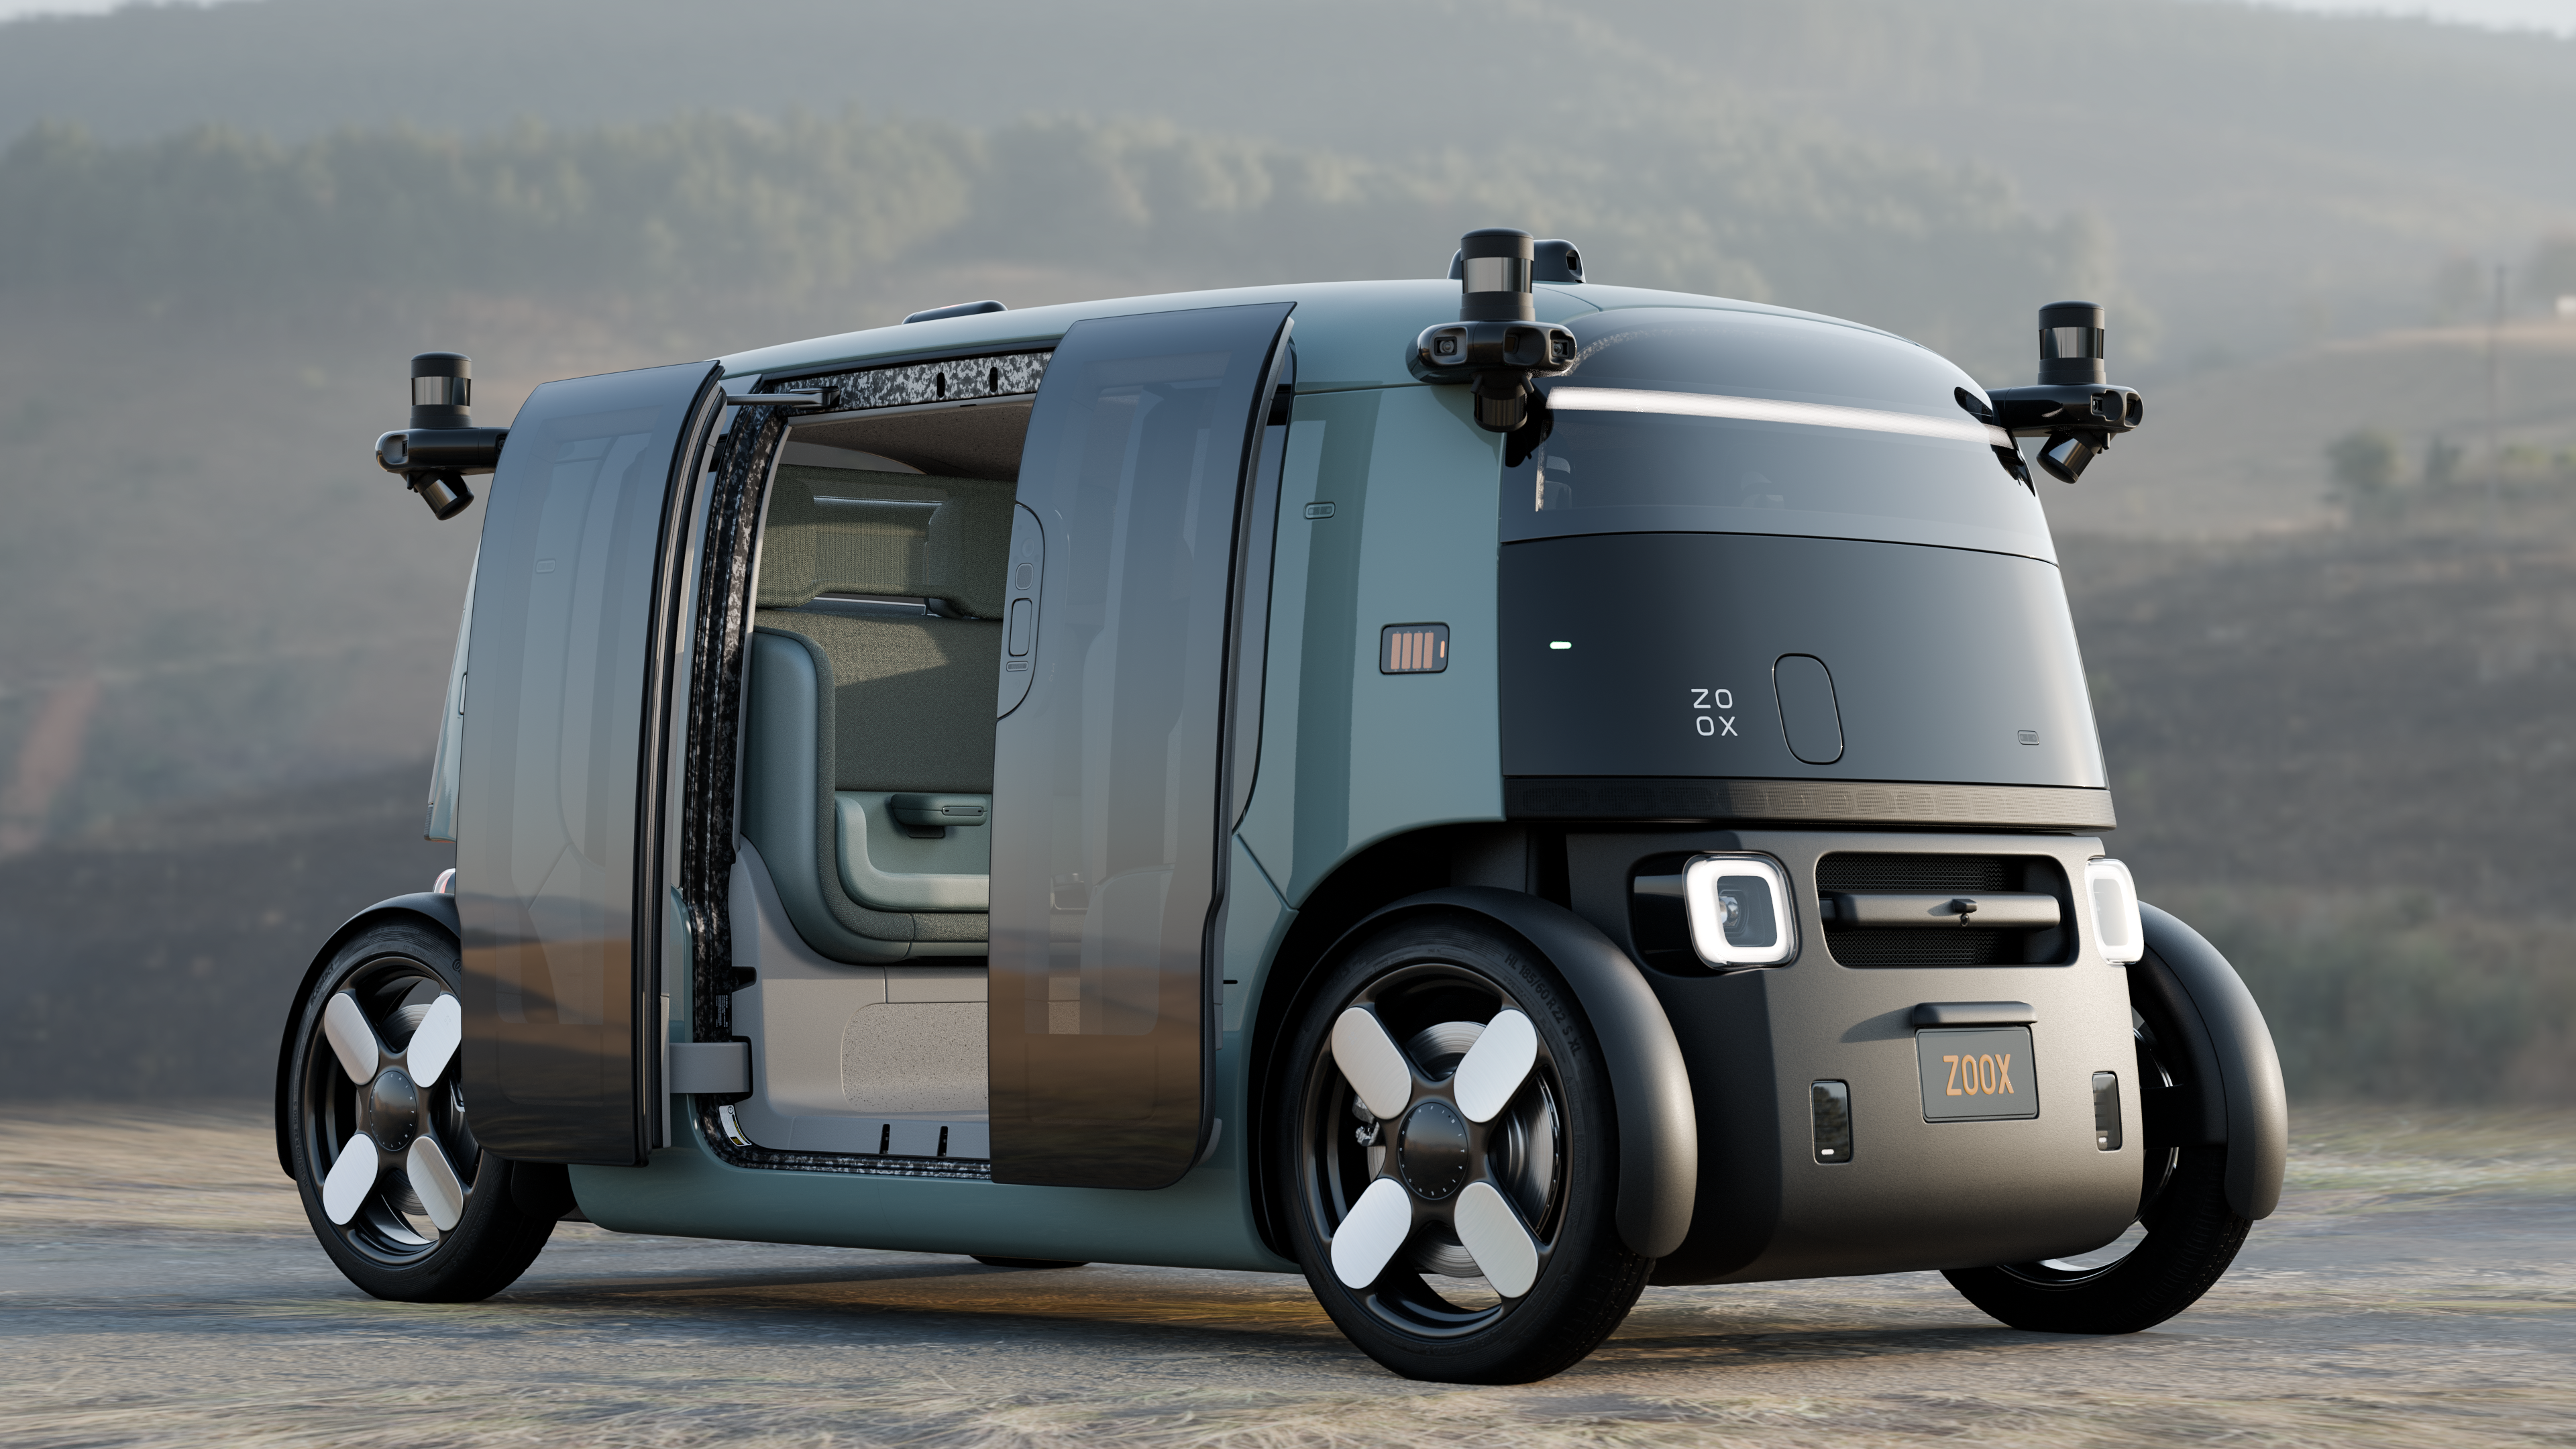
Tesla Skipped NHTSA's Permission Slip for a Wheelless Robotaxi. Zoox Spent Two Years Getting One.
Tesla says its wheelless Cybercab already meets every federal safety standard, no exemption needed. Zoox spent two years and accepted a 2,500-vehicle cap to win permission for the identical design. What that gap in approach actually signals about risk, not price.

Kawasaki Promised Autonomy by 2030. Its Own Roadmap Says 2040.
Kawasaki's own March roadmap puts full humanoid autonomy at 2040, yet October coverage says 2030. The same compression shows up at Tesla and Hyundai; only 1X is honest about how much of its robot is still human-operated.
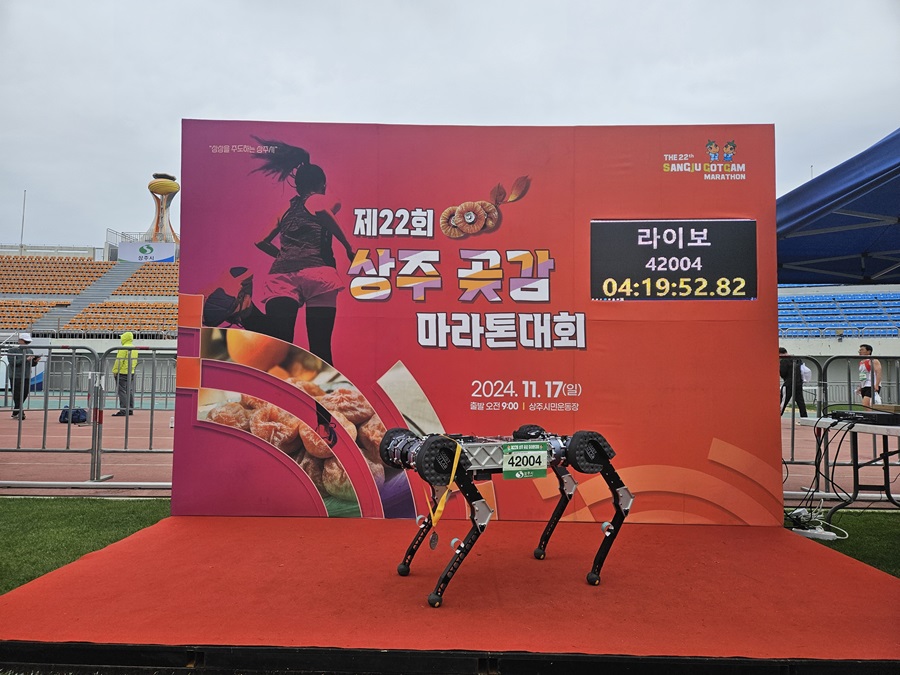
KAIST's RAIBO2 Triples the Endurance Ceiling for Legged Robots
A KAIST-built quadruped named RAIBO2 completed the Sangju Dried Persimmon Marathon on a single battery charge with no recharging or battery swap, and the September 24, 2026 Nature paper behind that run details a system-level co-design method that roughly triples prior quadruped range benchmarks and points to what sustained, energy-efficient legged locomotion means for inspection, patrol, and logistics robot buyers.
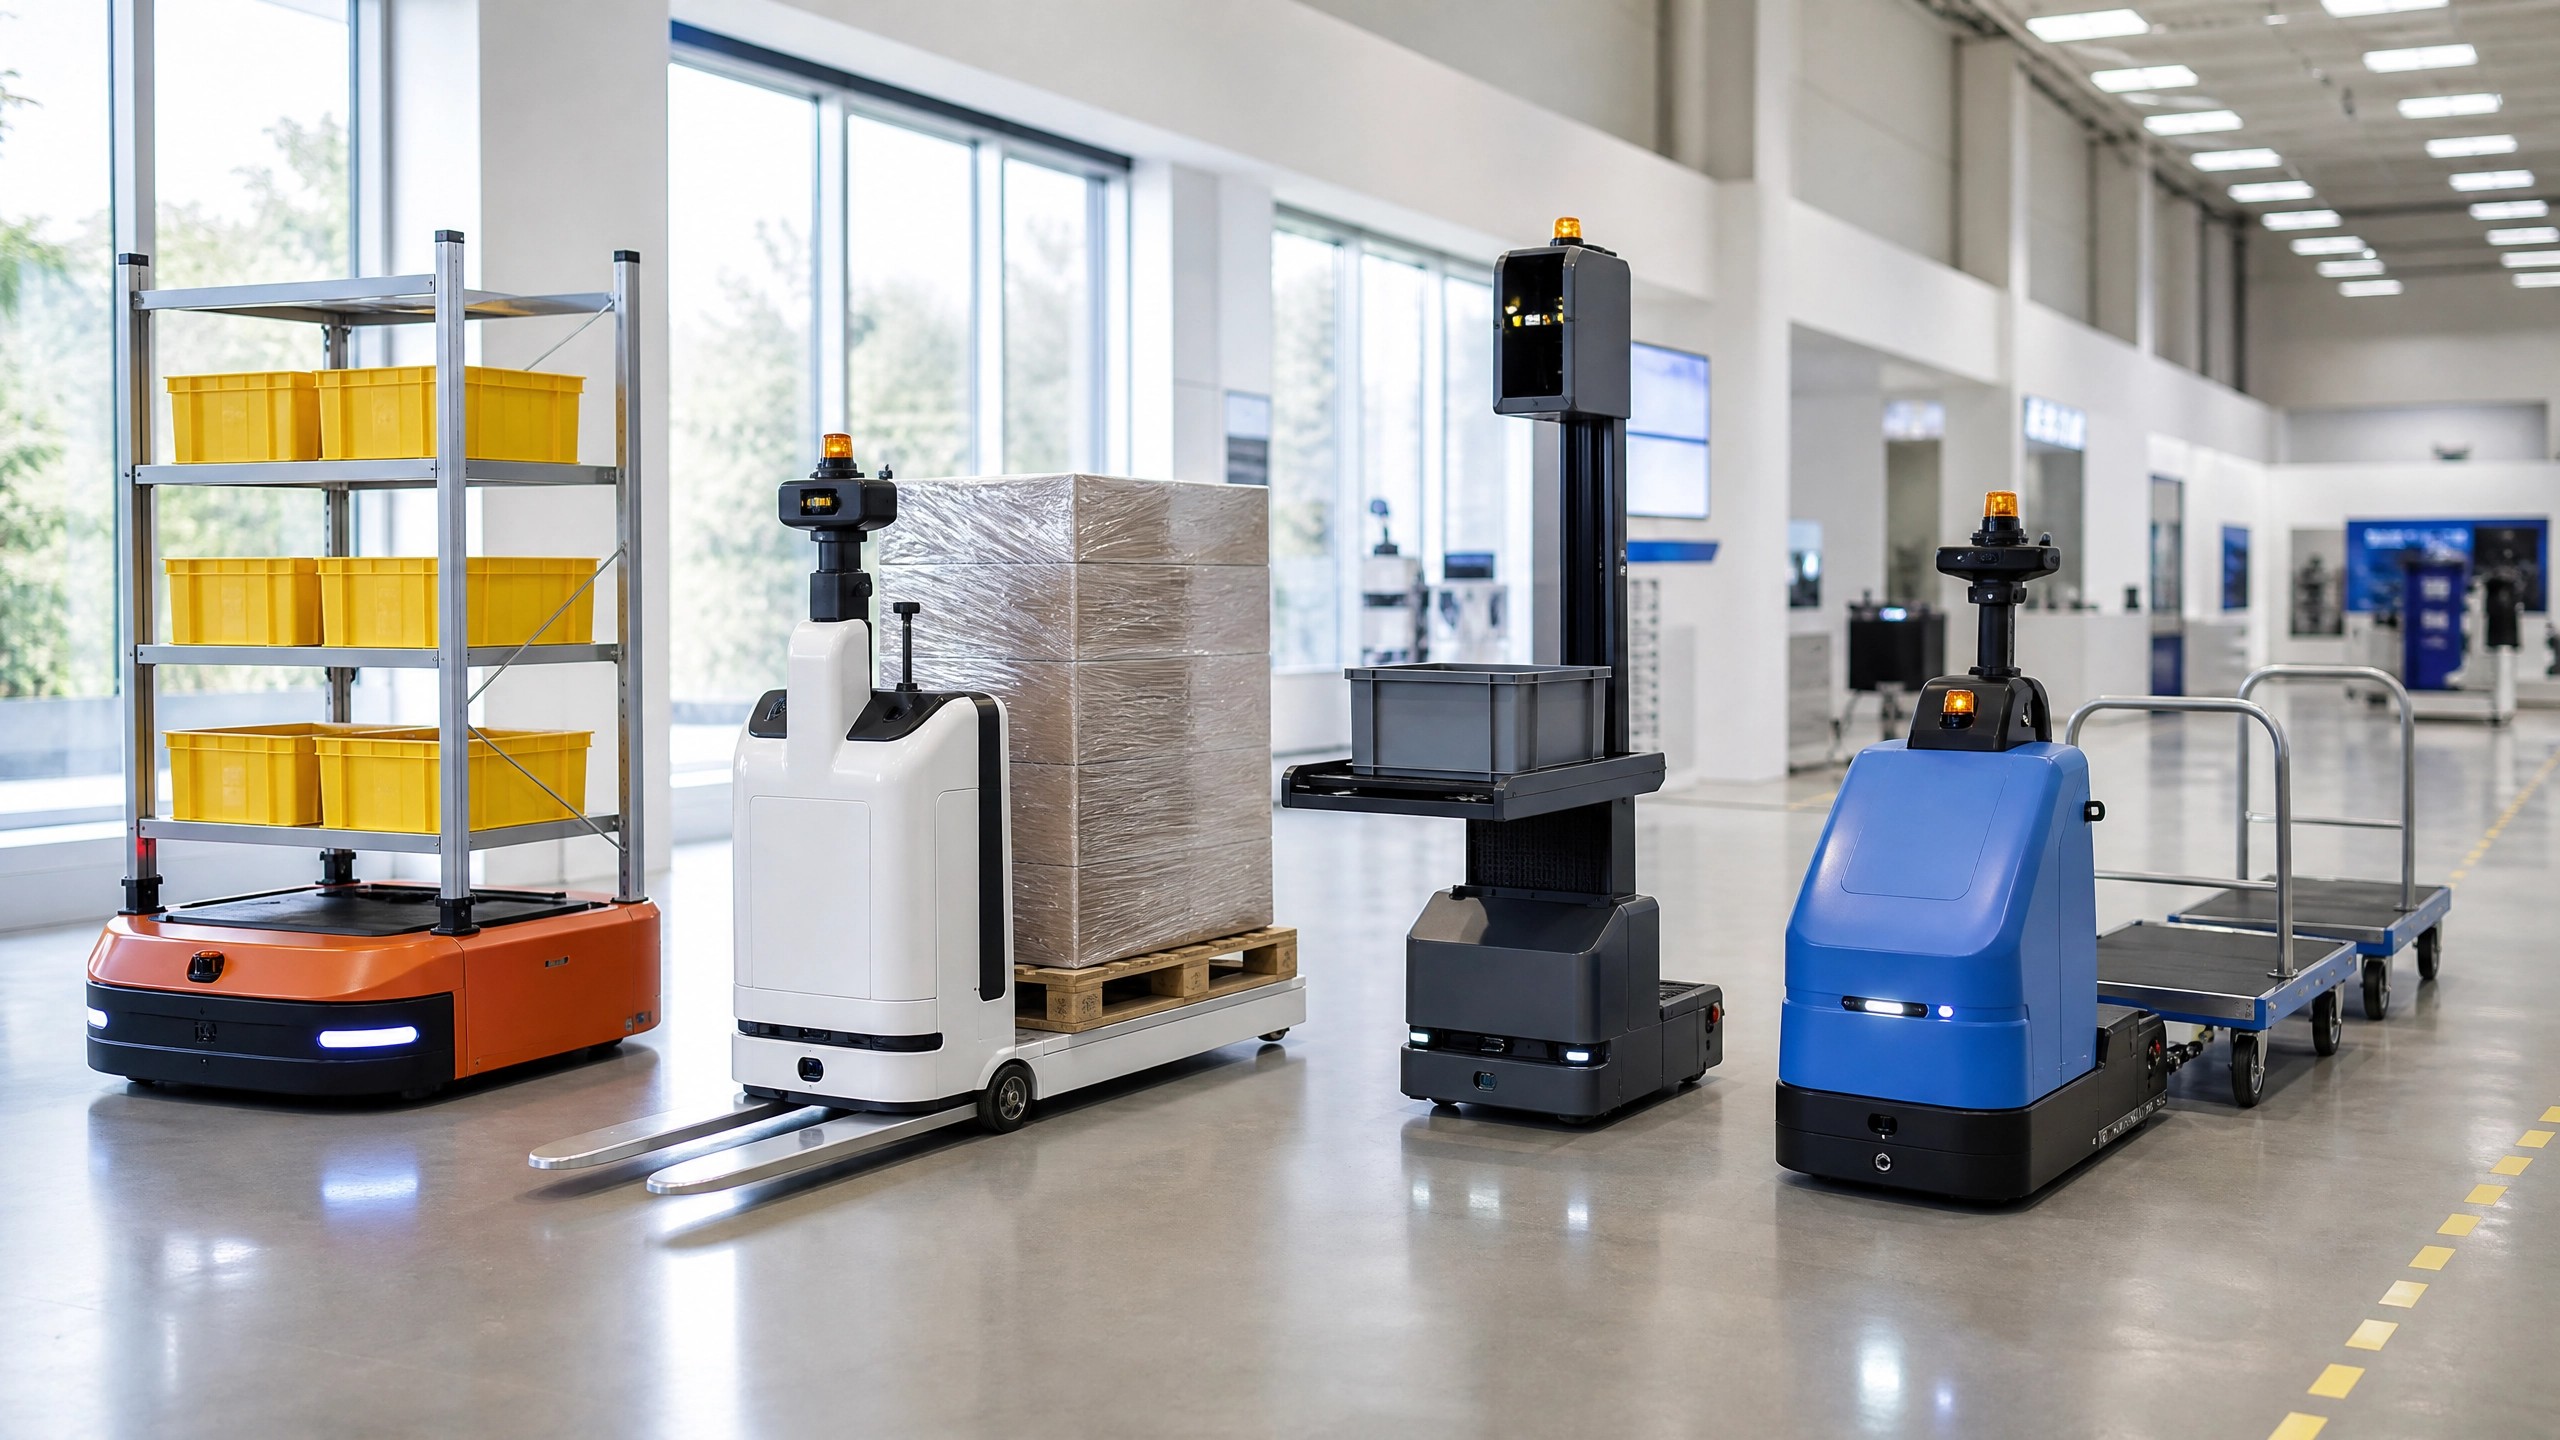
Navigating the Different Classes of AMR and AGVs
Ninety-six new mobile robot products reached the market in the first half of 2026 alone, and they are not interchangeable. This guide maps the six working classes of AGVs and AMRs that matter to buyers, from tuggers and pallet movers to shelf-carriers, tote-handling robots, and the fast-rising mobile manipulator category, explains how each differs in payload, navigation, and facility demands, and provides an original class selector matrix so procurement teams can shortlist the right vehicle type before talking to a single vendor.
由以下公司打造的机器人 SLIP ROBOTICS
暂无机器人
该公司已关联机器人,但仍在审核中,因此暂不对外展示。论坛、图片和视频会在机器人发布后出现。
里程碑
| 年份 | 事件 | 来源 |
|---|---|---|
| 2019 | Slip Robotics 成立 | — |
领导层
领导层信息暂不可用。