

DESCRIPTION
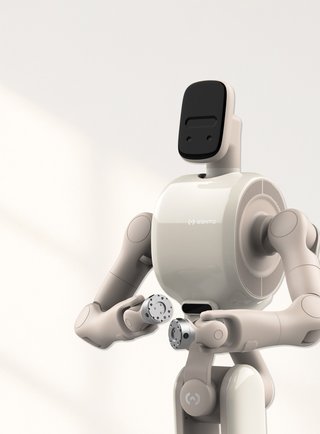
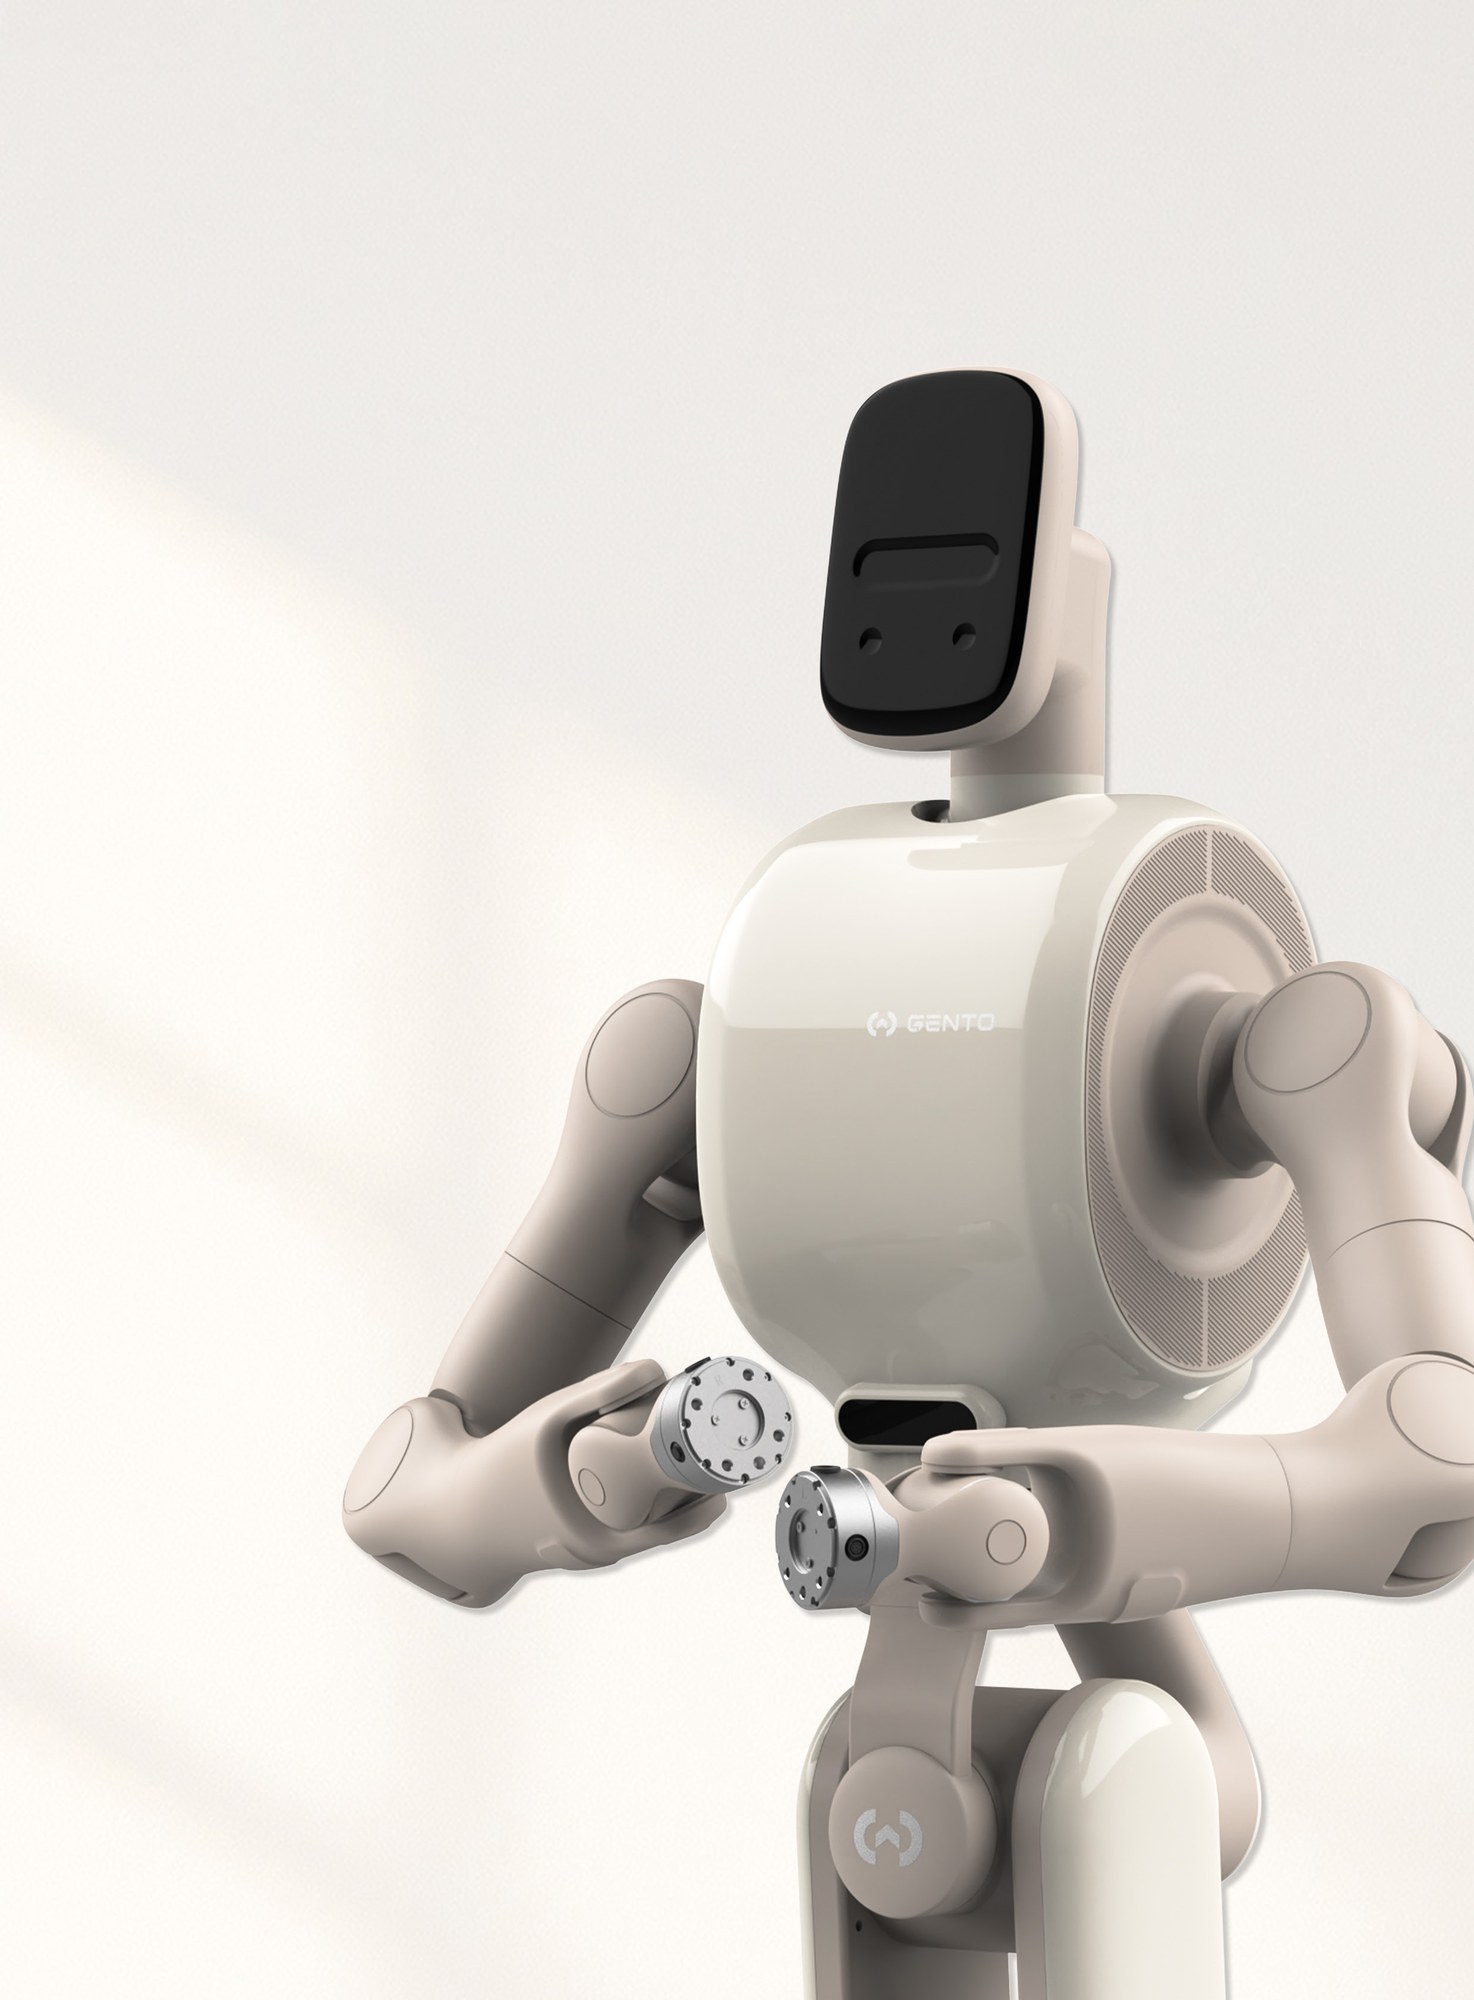
Gento Luna is a wheeled folding humanoid whose defining trick is its collapsing body: 1,700 mm tall standing, it folds to 790 mm so it fits in a lift or a storage cupboard. It carries 26 degrees of freedom excluding hands on a four-wheel-drive, four-wheel-steered omnidirectional chassis that rotates in place, and the whole machine ships with force control as standard — 7-DoF arms rated at 5 kg each with ±0.03 mm repeatability and ≤0.15 N force repeatability, plus six force-controlled joints across waist and legs for whole-body compliant impedance control. That matters in practice: on an unexpected collision the robot yields, dropping joint stiffness instantly to keep impact within a safe range. A 48 V 34.4 Ah lithium-iron-phosphate pack gives four to six hours with manual, automatic or swap charging in under 90 minutes, 3D LiDAR fused with ultrasonic radar builds centimetre-accurate maps, and compute is an NVIDIA Jetson Orin AGX 64 GB at 275 TOPS or an optional Jetson Thor T5000 at 2,070 TFLOPS.
FEATURES
- Folding body: 1,700 mm standing, 790 mm folded for lift transport and tight storage
- 26 DoF excluding dexterous hands
- four-wheel-drive four-wheel-steered omnidirectional chassis with in-place rotation
- whole-machine force control with 7-DoF Luna M6 Lite arms (5 kg rated, ±0.03 mm repeatability, ≤0.15 N force repeatability) and six force-controlled waist and leg joints
- compliant yielding on collision
- 0-2.1 m vertical workspace
- 3D SLAM with 3D LiDAR and eight ultrasonic sensors, ±20 mm / ±1° stopping accuracy
- NVIDIA Jetson Orin AGX 64 GB (275 TOPS) or optional Jetson Thor T5000 (2,070 TFLOPS)
- ROS 2 with full SDK and secondary-development APIs
- expressive lighting system with visual recognition
- active anti-tipping with real-time stability-margin calculation.
TECHNICAL SPECIFICATIONS
| Physical | |
| Weight | 144 kg |
|---|---|
| Dimensions | L 670 mm × W 548 mm × H 1.7 m |
| Payload | 5 kg |
| Reach | 615 mm |
| Repeatability | ±0.03 mm |
| Mobility | |
| Movement Type | Wheeled |
| Degrees of Freedom | 26 |
| Speed | 5.4 km/h |
| Manipulation | High |
| Environment | Indoor; climbing angle >=10°; ±20 mm position and ±1° angle stopping accuracy |
| Actuators | 2x 7-DoF Luna M6 Lite force-controlled arms with brakes on J1-J4; 2-DoF pan/tilt head; force-controlled waist and leg joints; four-wheel-drive four-wheel-steered omnidirectional chassis rated at 100 kg |
| Power | |
| Battery Life | 4-6 h |
| Charging Type | Manual, automatic or battery swap |
| Charging Time | <=1.5 h |
| Sensing & Compute | |
| Sensors | 3D LiDAR (diagonally mounted), 8x ultrasonic sensors, RGBD camera, binocular camera, 4-mic array, optional thoracic RGB-D camera, optional 6D force sensor at the end effector |
| Connectivity | 1 kHz EtherCAT; Wi-Fi and Ethernet; arm-end RS485, CAN FD, EtherCAT, CAN, 24 V (3 A) and 48 V |
| Software / AI | ROS 2 with complete SDK and secondary-development APIs; position control, impedance control, load auto-identification and force-position hybrid control |
Images
 martti
Image Contributions
Videos
ROBOT FORUMS
Loading forums...
RATINGS
FREQUENTLY ASKED QUESTIONS
What is the Gento Luna?
Gento Luna is a wheeled folding humanoid whose defining trick is its collapsing body: 1,700 mm tall standing, it folds to 790 mm so it fits in a lift or a storage cupboard.
Who makes the Gento Luna?
The Gento Luna is made by Tianji Gento, a robotics company based in China.
How much does the Gento Luna cost?
Tianji Gento has not publicly announced pricing for the Gento Luna. You can enquire through RobotAIGeek for current pricing.
What is the Gento Luna used for?
The Gento Luna is designed for pick-and-place, scientific research and education, industrial and production-line inspection, and equipment maintenance. It is used in research, homes, manufacturing, and retail settings.
What is the payload capacity of the Gento Luna?
The Gento Luna has a payload capacity of 5 kg and a reach of 615 mm.
How much does the Gento Luna weigh?
The Gento Luna weighs 144 kg.
How fast is the Gento Luna?
The Gento Luna can move at speeds of up to 5.4 km/h.
What is the battery life of the Gento Luna?
The Gento Luna runs for 4-6 h on a charge. It takes <=1.5 h to charge.
COMPARE WITH SIMILAR ROBOTS
See how this robot stacks up against its closest alternatives
- Gento Luna vs CASBOT W1
- Gento Luna vs Corenetic Monte 02
- Gento Luna vs KUAVO 5-W MAX
- Gento Luna vs Muks Robotics SPACEO PRO
- Gento Luna vs AlphaBot 2