描述
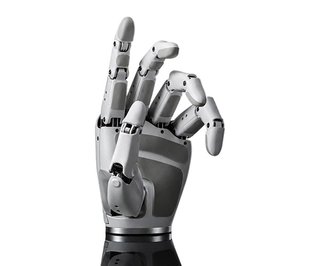
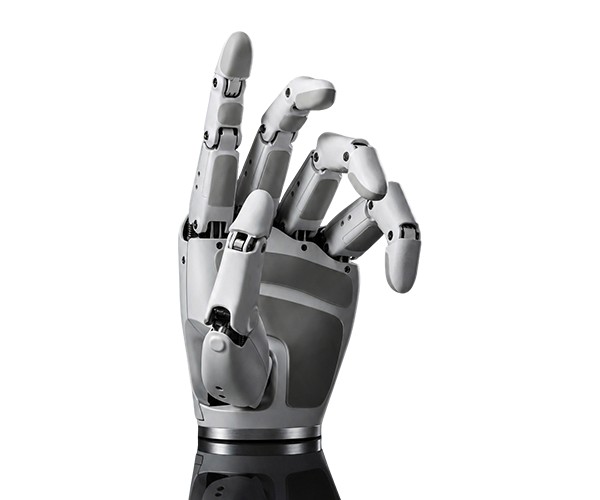
KAI Hand是Kinetix AI 超维动力的End-Effectors。 面向发展、物料搬运、研究设计。 关键数据:0.8 kg、37 自由度。
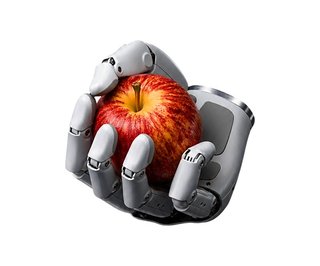
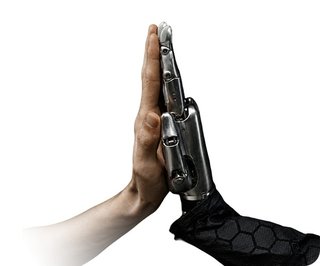
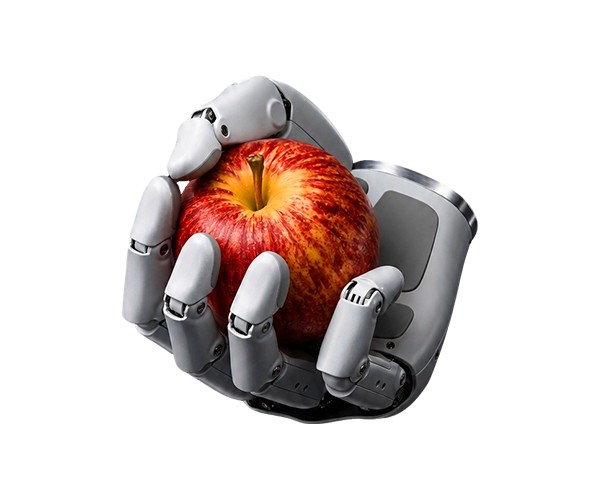
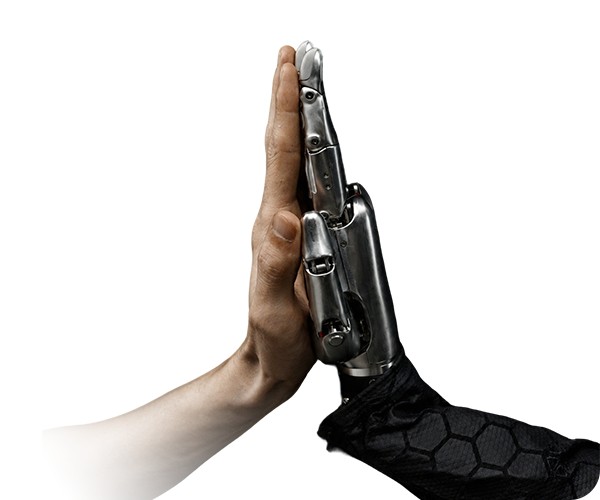
KAI Hand is Kinetix AI's human-scale dexterous hand for embodied-AI robots. Built 1:1 to an adult hand at 185 x 90 x 40 mm and 750 g, it has 37 degrees of freedom - 20 active, 1 passive and 16 compliant - so it can be a natural target for retargeting human demonstrations and transferring manipulation data to robots. A hybrid direct and tendon drive with unidirectional self-locking keeps heat down during sustained grasps, field-oriented control drives each joint, and passive compliance lets the fingers give on contact. It delivers 30 N of fingertip grip and 2 kg of dynamic load per finger with +/-1 mm repeatability, and quick-swap fingers cut maintenance time. Fingertip tactile sensing comes as standard and a wrist-mounted stereo camera is optional, feeding joint, touch and vision data for teleoperation and policy learning at up to 500 Hz over CAN, CAN FD, RS-485 or EtherCAT on a 12 V supply.
功能特点
- 37 DoF: 20 active, 1 passive, 16 compliant
- 1:1 adult human-hand scale
- 185 x 90 x 40 mm
- 750 g
- Hybrid direct + tendon actuation with unidirectional self-locking
- field-oriented control
- Fingertip grip force 30 N
- dynamic load 2 kg per finger
- positioning repeatability +/-1 mm
- Fingertip tactile sensing standard
- optional wrist-mounted stereo camera
- Communication up to 500 Hz over CAN, CAN FD, RS-485 or EtherCAT
- 12 V (wide input)
- Passive compliance
- thermally balanced design
- modular quick-swap fingers
- Developer docs and SDK for teleoperation and policy learning
技术规格
已验证| 物理参数 | |
| 重量 | 0.75 kg |
|---|---|
| 外形尺寸 | L 185 mm × W 90 mm × H 40 mm |
| 移动能力 | |
| 运动类型 | 文具 |
| 自由度 | 37 |
| 作业环境 | Mounted on humanoid or robot arms |
| 执行器 | Hybrid direct and tendon actuation with unidirectional self-locking |
| 感知与计算 | |
| 传感器 | fingertip tactile sensors, optional wrist stereo camera |
| 连接方式 | CAN, CAN FD, RS-485, EtherCAT (up to 500 Hz) |
机器人论坛
正在加载论坛...
技术规格
已验证| 物理参数 | |
| 重量 | 0.75 kg |
|---|---|
| 外形尺寸 | L 185 mm × W 90 mm × H 40 mm |
| 移动能力 | |
| 运动类型 | 文具 |
| 自由度 | 37 |
| 作业环境 | Mounted on humanoid or robot arms |
| 执行器 | Hybrid direct and tendon actuation with unidirectional self-locking |
| 感知与计算 | |
| 传感器 | fingertip tactile sensors, optional wrist stereo camera |
| 连接方式 | CAN, CAN FD, RS-485, EtherCAT (up to 500 Hz) |
图片
 martti
 martti
 martti
图片贡献
视频
机器人论坛
正在加载论坛...
评分
常见问题
What is the KAI Hand?
KAI Hand is Kinetix AI's human-scale dexterous hand for embodied-AI robots. Built 1:1 to an adult hand at 185 x 90 x 40 mm and 750 g, it has 37 degrees of freedom - 20 active, 1 passive and 16 compliant - so it can be a natural target for retargeting human demonstrations and transferring manipulation data to robots.
Who makes the KAI Hand?
The KAI Hand is made by Kinetix AI 超维动力, a robotics company based in China.
How much does the KAI Hand cost?
Kinetix AI 超维动力 has not publicly announced pricing for the KAI Hand. You can enquire through RobotAIGeek for current pricing.
What is the KAI Hand used for?
The KAI Hand is designed for 发展, 物料搬运, 研究, and humanoid manipulation, teleoperation, manipulation-policy learning. It is used in 研究 and 制造业 settings.
How much does the KAI Hand weigh?
The KAI Hand weighs 0.75 kg.
How many degrees of freedom does the KAI Hand have?
The KAI Hand has 37 degrees of freedom.
与同类机器人对比
看看这款机器人与最接近的同类产品相比表现如何
- KAI Hand vs Xynova Prima 1
- KAI Hand vs Xynova Flex 2
- KAI Hand vs TRI Punyo
- KAI Hand vs Tokyo Robotics Torobo
- KAI Hand vs WIRobotics ALLEX