DESCRIPTION
KAI Hand is an End-Effectors from Kinetix AI 超维动力. It is built for Development, Material-Handling, Research. Key figures: 0.8 kg, 37 degrees of freedom.
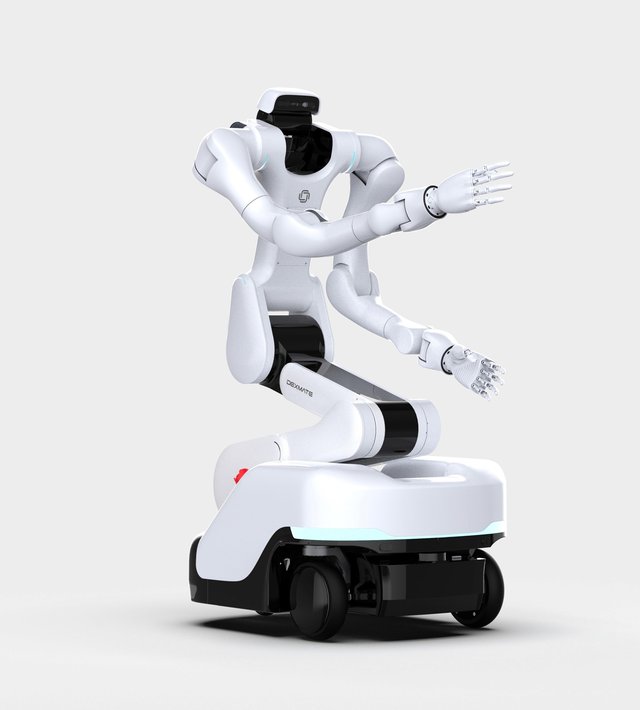
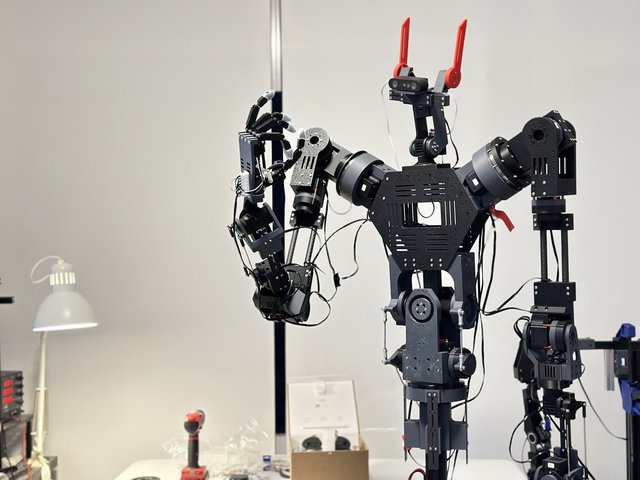
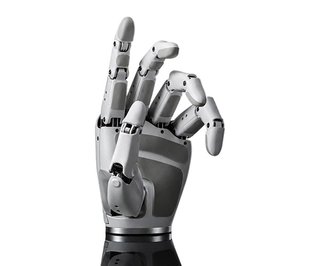
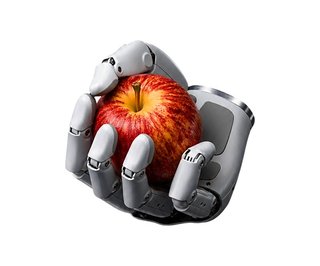
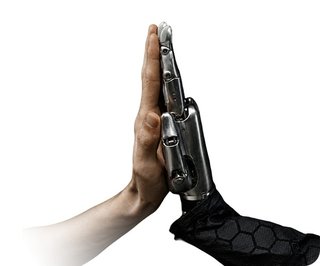
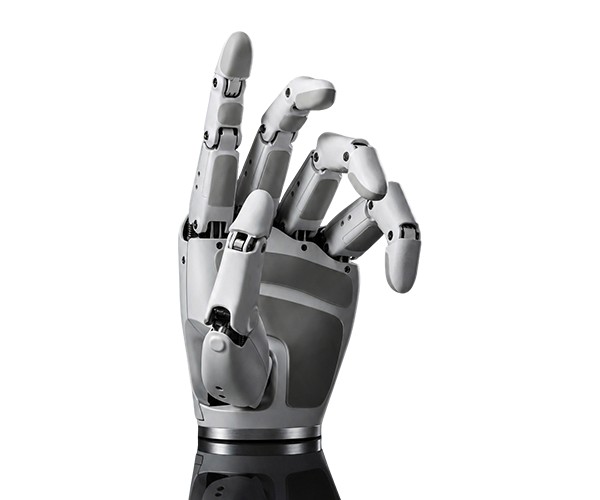
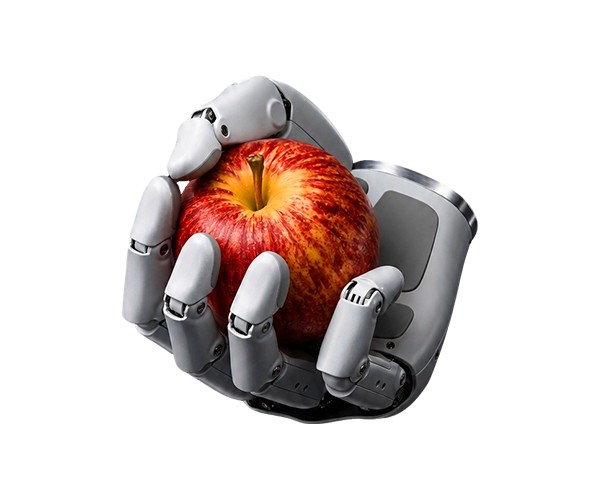
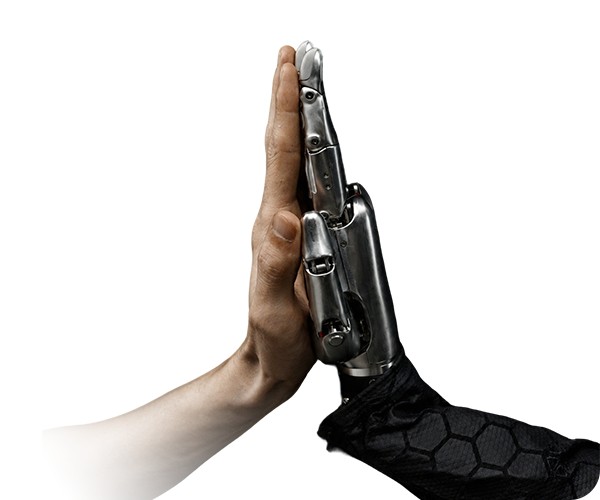
KAI Hand is Kinetix AI's human-scale dexterous hand for embodied-AI robots. Built 1:1 to an adult hand at 185 x 90 x 40 mm and 750 g, it has 37 degrees of freedom - 20 active, 1 passive and 16 compliant - so it can be a natural target for retargeting human demonstrations and transferring manipulation data to robots. A hybrid direct and tendon drive with unidirectional self-locking keeps heat down during sustained grasps, field-oriented control drives each joint, and passive compliance lets the fingers give on contact. It delivers 30 N of fingertip grip and 2 kg of dynamic load per finger with +/-1 mm repeatability, and quick-swap fingers cut maintenance time. Fingertip tactile sensing comes as standard and a wrist-mounted stereo camera is optional, feeding joint, touch and vision data for teleoperation and policy learning at up to 500 Hz over CAN, CAN FD, RS-485 or EtherCAT on a 12 V supply.
FEATURES
- 37 DoF: 20 active, 1 passive, 16 compliant
- 1:1 adult human-hand scale
- 185 x 90 x 40 mm
- 750 g
- Hybrid direct + tendon actuation with unidirectional self-locking
- field-oriented control
- Fingertip grip force 30 N
- dynamic load 2 kg per finger
- positioning repeatability +/-1 mm
- Fingertip tactile sensing standard
- optional wrist-mounted stereo camera
- Communication up to 500 Hz over CAN, CAN FD, RS-485 or EtherCAT
- 12 V (wide input)
- Passive compliance
- thermally balanced design
- modular quick-swap fingers
- Developer docs and SDK for teleoperation and policy learning
TECHNICAL SPECIFICATIONS
Verified| Physical | |
| Weight | 0.75 kg |
|---|---|
| Dimensions | L 185 mm × W 90 mm × H 40 mm |
| Mobility | |
| Movement Type | Stationary |
| Degrees of Freedom | 37 |
| Environment | Mounted on humanoid or robot arms |
| Actuators | Hybrid direct and tendon actuation with unidirectional self-locking |
| Sensing & Compute | |
| Sensors | fingertip tactile sensors, optional wrist stereo camera |
| Connectivity | CAN, CAN FD, RS-485, EtherCAT (up to 500 Hz) |
Images
 martti
 martti
 martti
Image Contributions
Videos
ROBOT FORUMS
Loading forums...
RATINGS
FREQUENTLY ASKED QUESTIONS
What is the KAI Hand?
KAI Hand is Kinetix AI's human-scale dexterous hand for embodied-AI robots. Built 1:1 to an adult hand at 185 x 90 x 40 mm and 750 g, it has 37 degrees of freedom - 20 active, 1 passive and 16 compliant - so it can be a natural target for retargeting human demonstrations and transferring manipulation data to robots.
Who makes the KAI Hand?
The KAI Hand is made by Kinetix AI 超维动力, a robotics company based in China.
How much does the KAI Hand cost?
Kinetix AI 超维动力 has not publicly announced pricing for the KAI Hand. You can enquire through RobotAIGeek for current pricing.
What is the KAI Hand used for?
The KAI Hand is designed for development, material-handling, research, and humanoid manipulation, teleoperation, manipulation-policy learning. It is used in research and manufacturing settings.
How much does the KAI Hand weigh?
The KAI Hand weighs 0.75 kg.
How many degrees of freedom does the KAI Hand have?
The KAI Hand has 37 degrees of freedom.
COMPARE WITH SIMILAR ROBOTS
See how this robot stacks up against its closest alternatives
- KAI Hand vs Xynova Prima 1
- KAI Hand vs Xynova Flex 2
- KAI Hand vs TRI Punyo
- KAI Hand vs Tokyo Robotics Torobo
- KAI Hand vs WIRobotics ALLEX