描述
Red Rabbit Robotics RX1是Red Rabbit Robotics的Educational-Robots。 面向发展、物料搬运、研究设计。
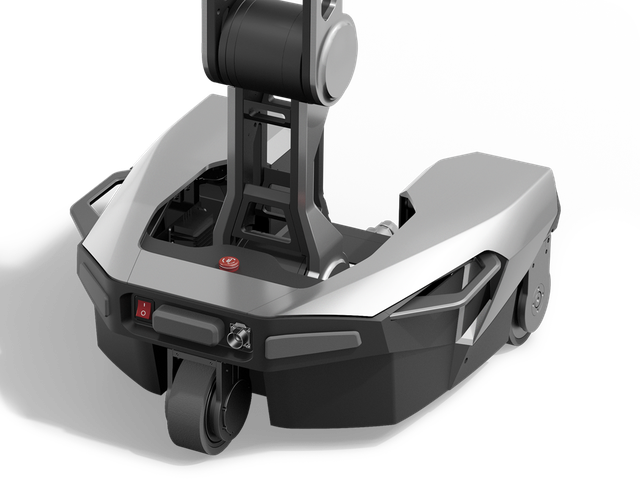
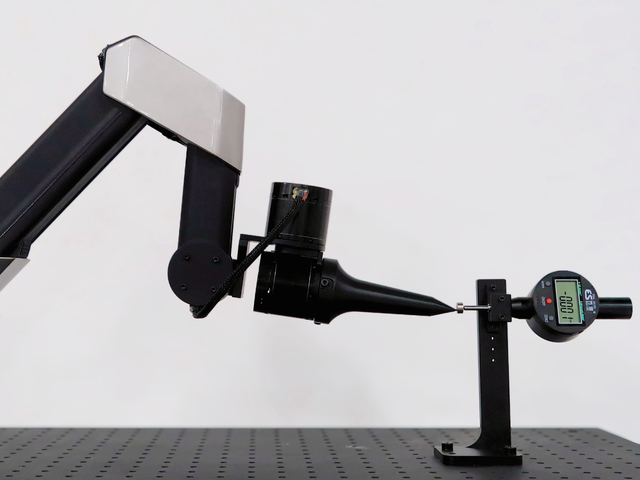
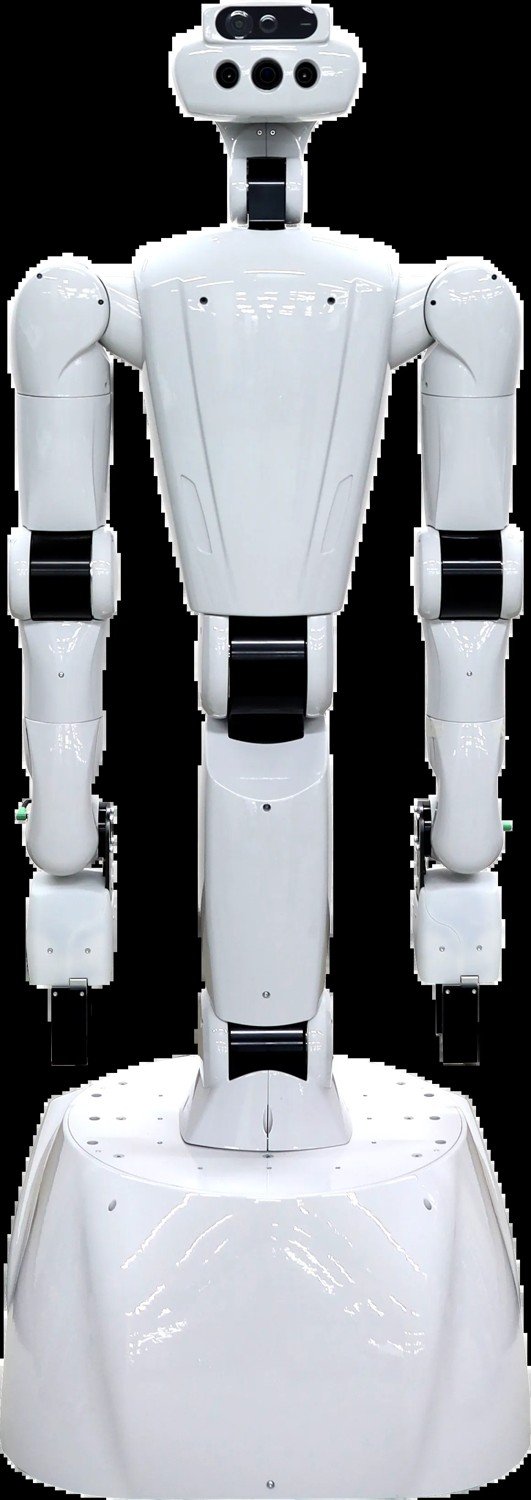
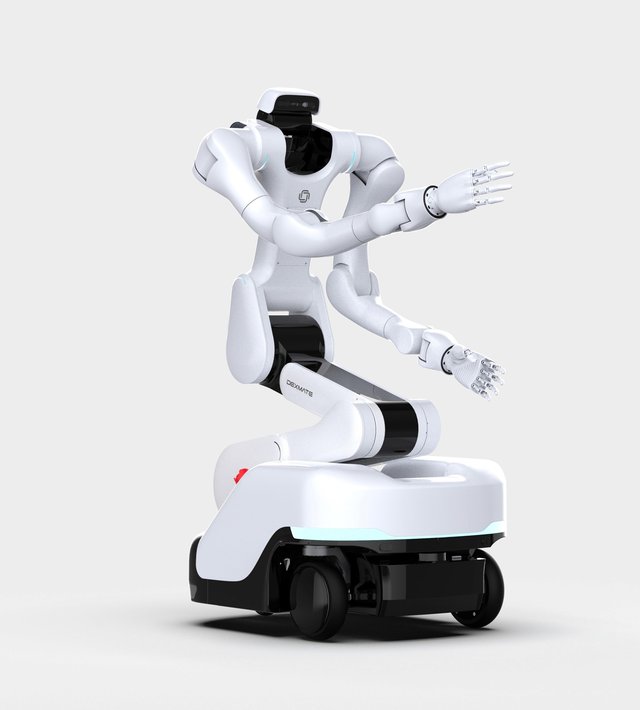
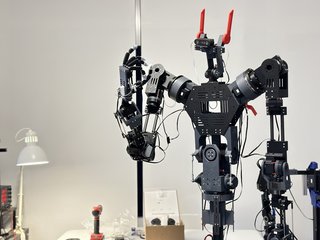
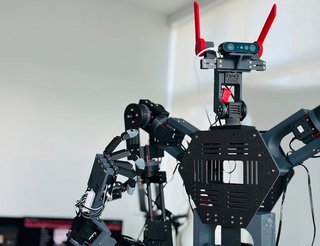
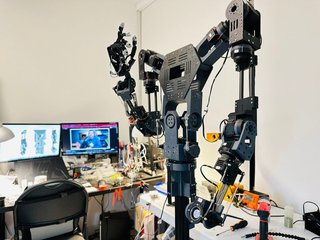
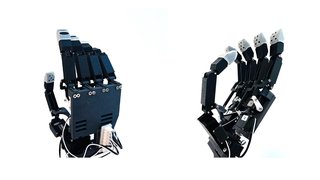
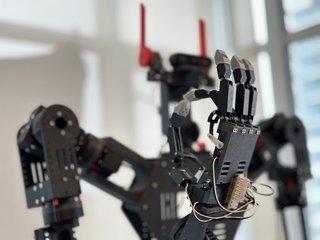
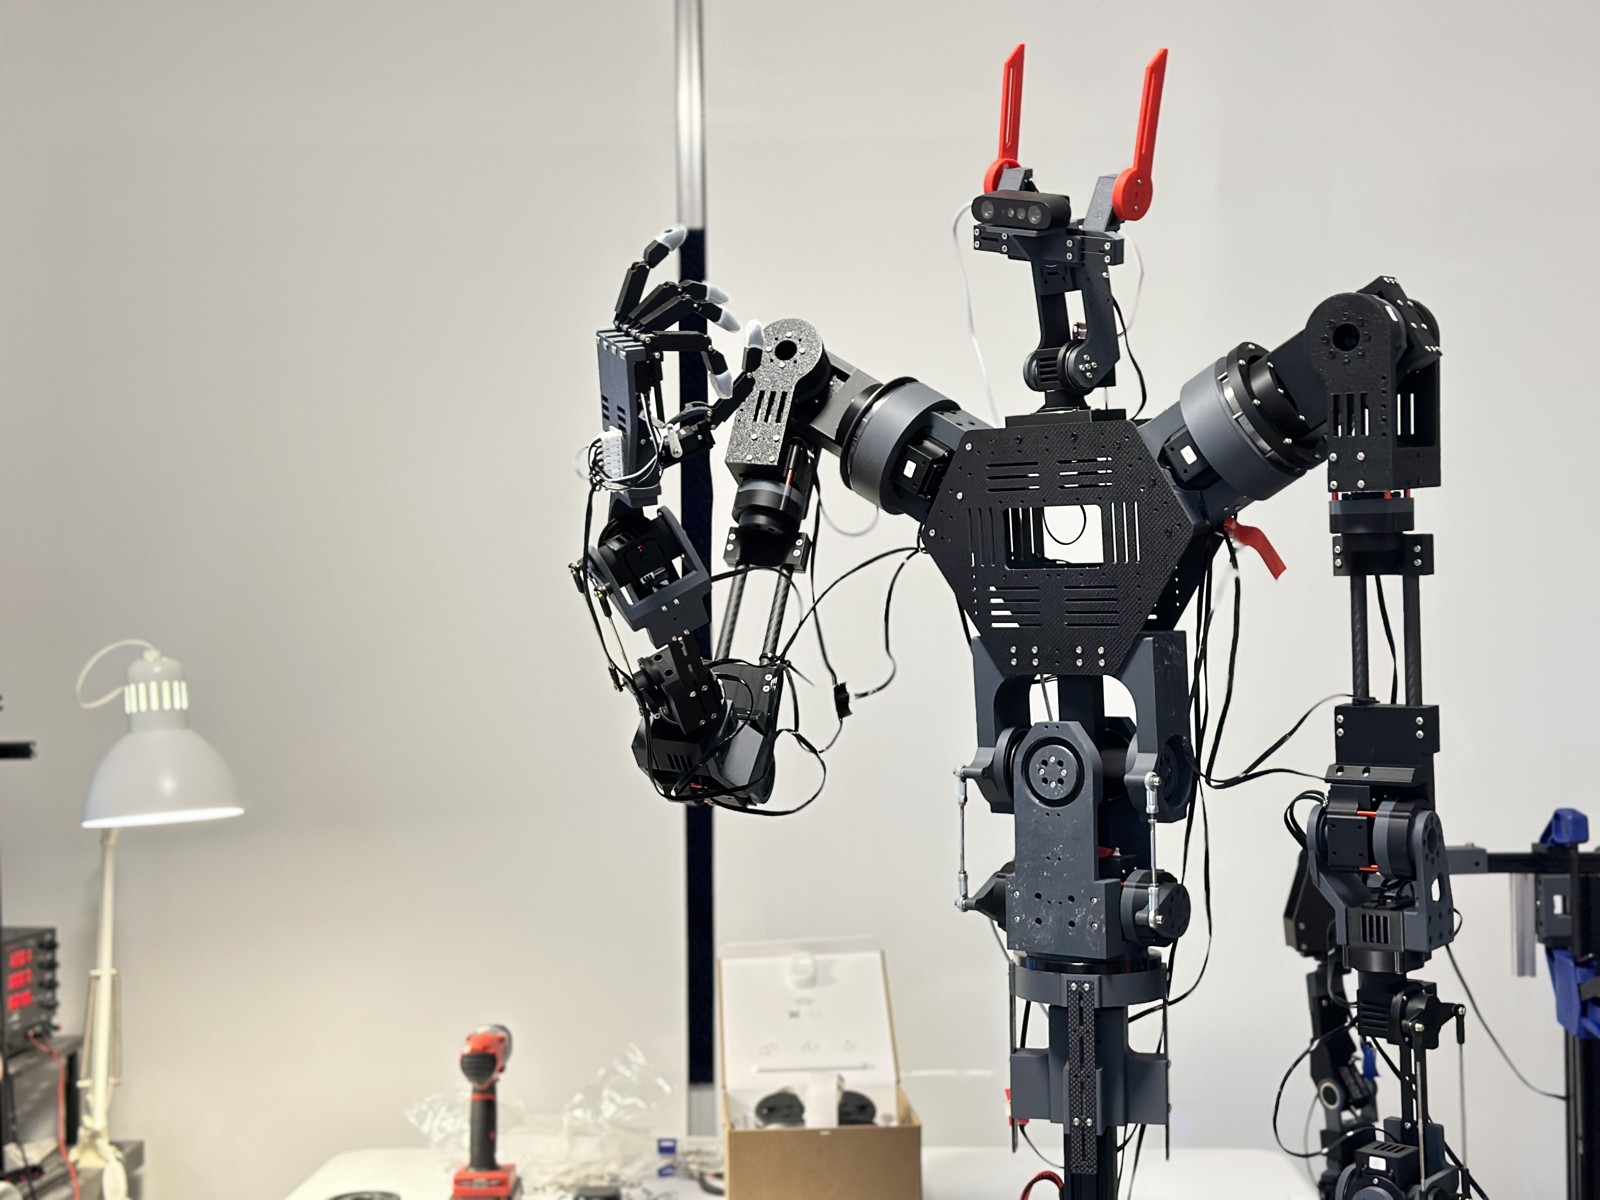
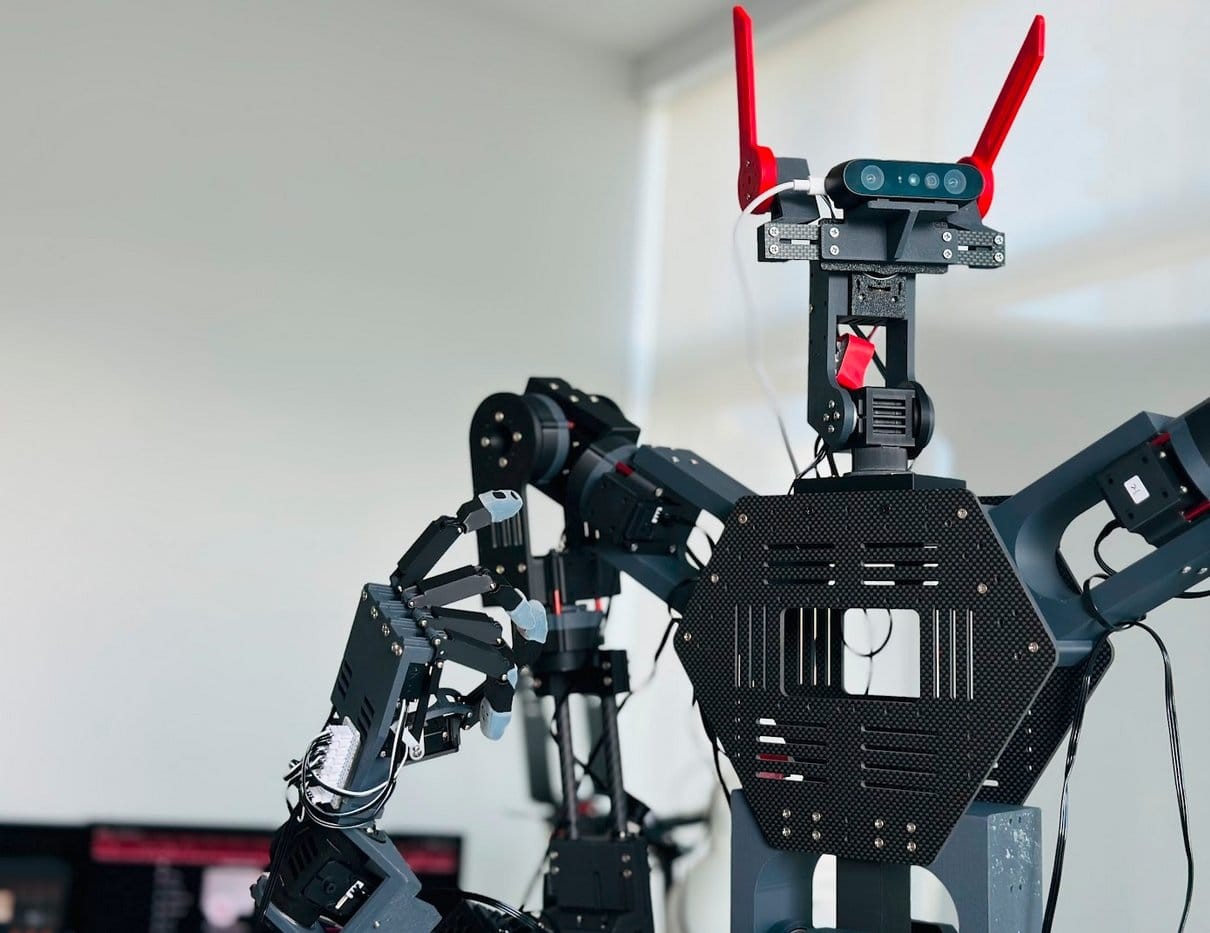
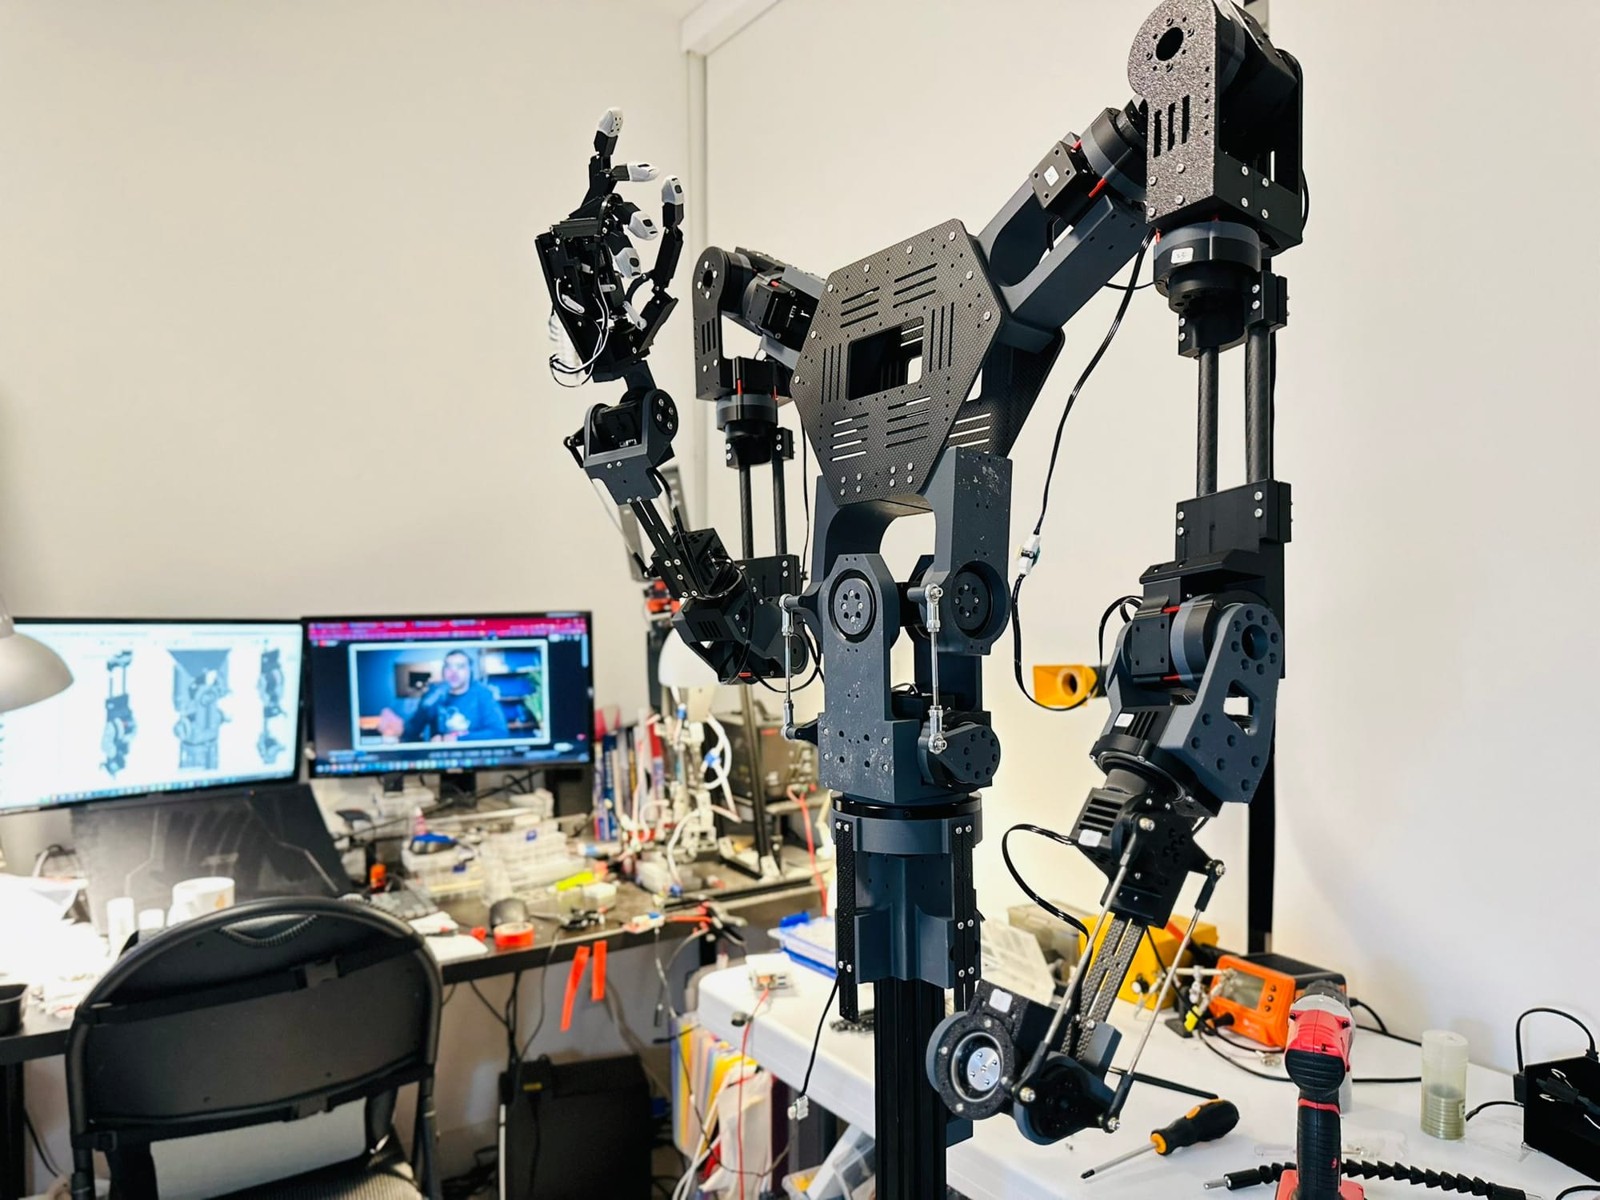
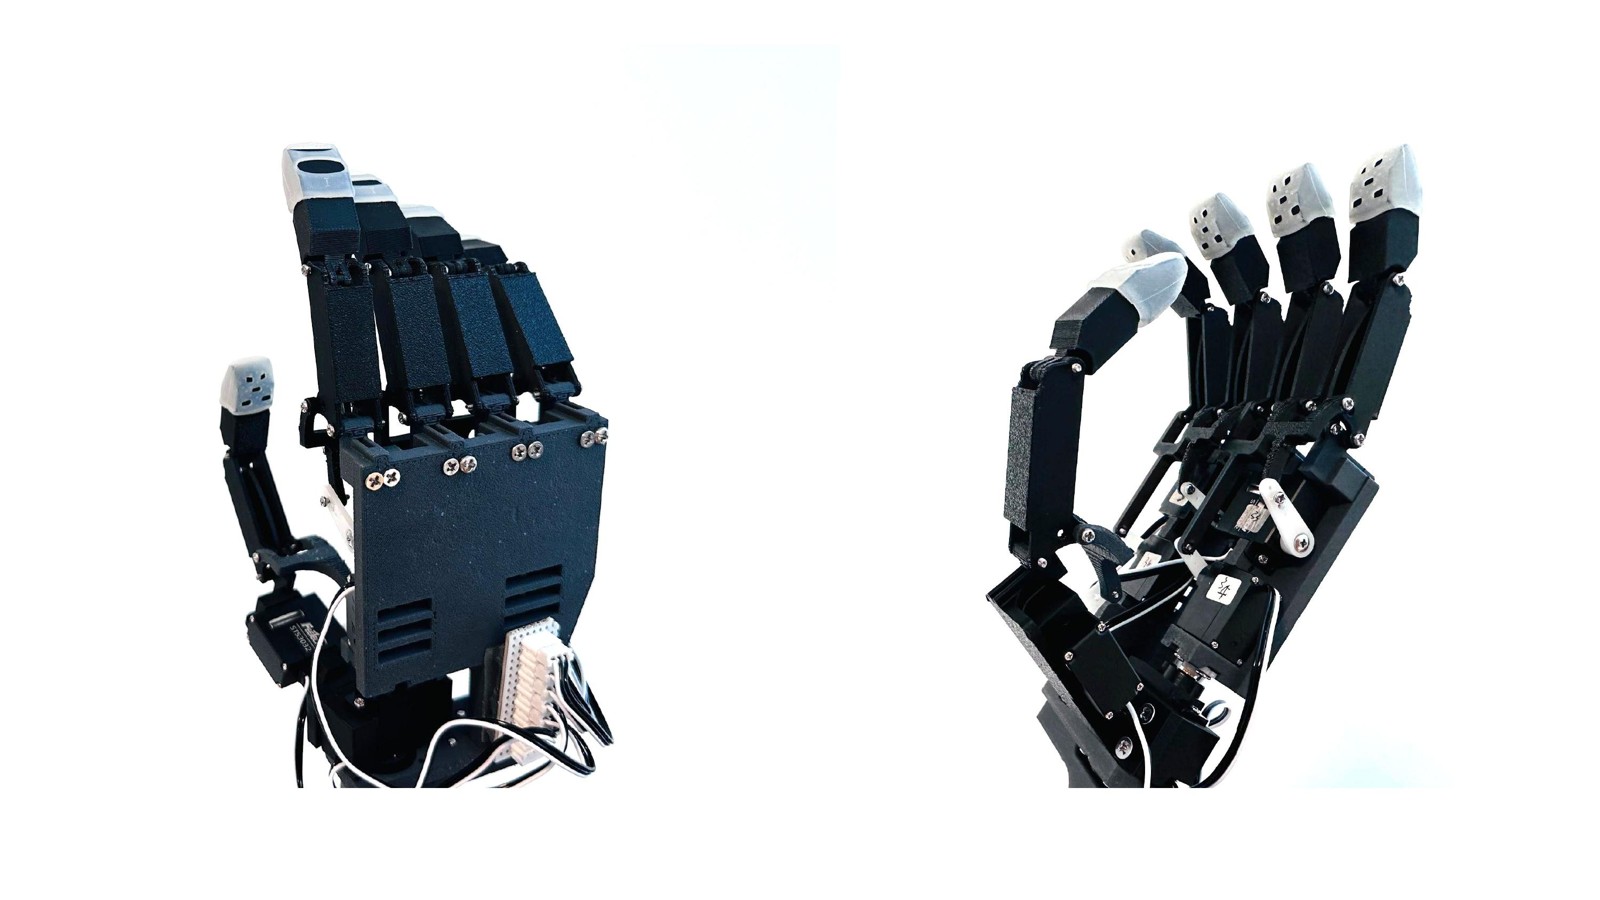
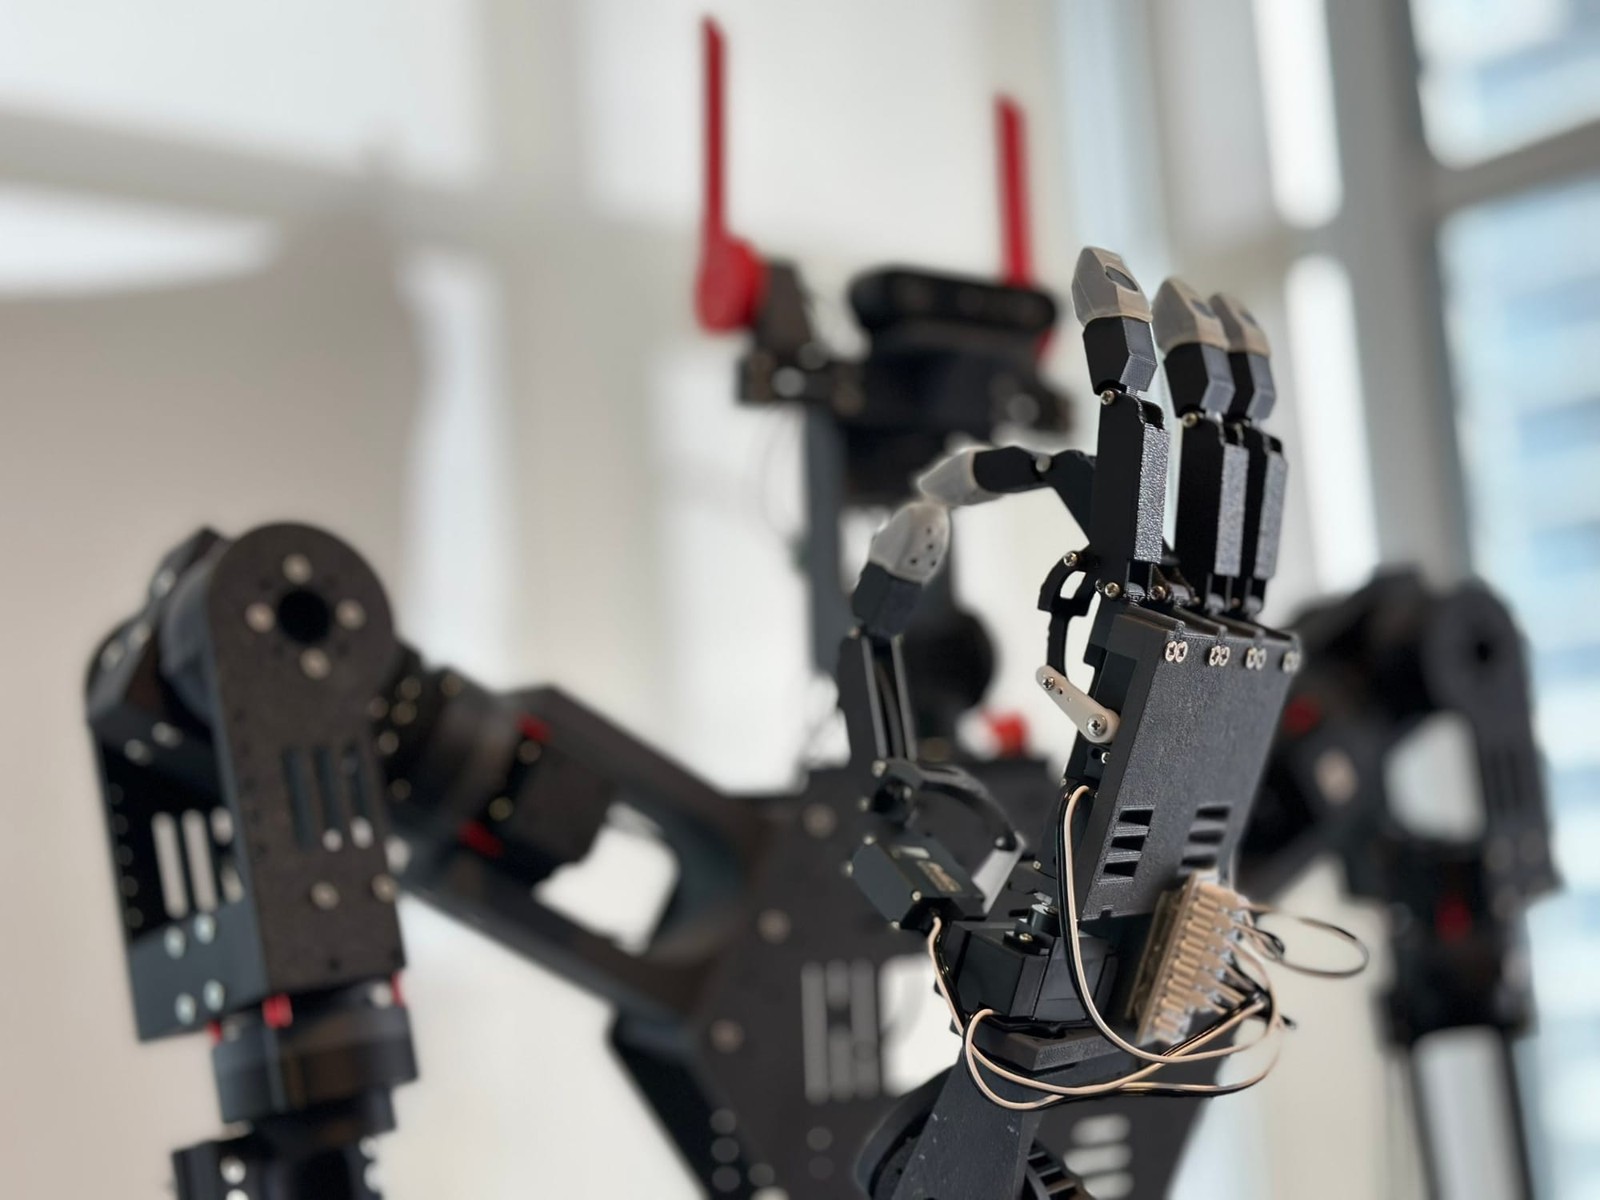
RX1 is a human-scale dual-arm humanoid that Red Rabbit Robotics gave away. Rather than keep the design in-house, the company published the CAD, the bill of materials, the servo, arm, hand, head and torso hardware files and a ROS 1 driver — its own claim is that you can build one for under a thousand dollars from 3D-printed parts and off-the-shelf components. The robot is a torso on a stand rather than a walker: two arms of seven joints each, a three-joint torso and a two-joint neck, counted from Red Rabbit's own URDF. The hands are separate open hardware, as are the gripper and the teleoperation arm. Motion runs on Feetech servos through the company's own driver; perception uses an Orbbec depth camera on the head. The software side is a ROS 1 meta-package: URDF description, servo control, an inverse kinematics demo with a drag-the-end-effector marker, a Gazebo simulation and a single launch file that brings everything up. It can be driven from a computer through machine learning or from a VR headset, and a matching teleoperation arm maps an operator's movement onto the robot. For Red Rabbit the open robot is the shop window: the commercial offer is a pilot of robot workers, initially remote-operated and eventually autonomous.
功能特点
- Open-source human-scale dual-arm humanoid: CAD, BOM, hardware files and ROS 1 driver all public
- Maker's claim: buildable for under 1,000 US dollars
- 7 joints per arm, 3-joint torso, 2-joint neck (counted from the maker's own URDF)
- 3D-printed parts with off-the-shelf components
- Feetech servos driven by the company's own open ROS 1 driver
- Orbbec depth camera on the head
- Separate open hardware for the hands, gripper and teleoperation arm
- ROS 1 meta-package: URDF description, servo control, inverse-kinematics demo, Gazebo simulation
- Controllable from a computer through machine learning or from a VR headset
- Teleoperation arm maps operator movement onto the robot
- Torso-and-arms platform on a stand
- no legs and no mobile base
技术规格
| 移动能力 | |
| 运动类型 | 文具 |
|---|---|
| 作业环境 | Benchtop and lab use; torso-and-arms platform on a stand |
| 执行器 | Feetech servos |
| 感知与计算 | |
| 传感器 | Orbbec depth camera (head), servo position feedback |
| 软件 / AI | ROS 1 (Noetic/Melodic) meta-package: URDF description, Feetech servo control, inverse kinematics, Gazebo simulation; VR and machine-learning control |
机器人论坛
正在加载论坛...
技术规格
| 移动能力 | |
| 运动类型 | 文具 |
|---|---|
| 作业环境 | Benchtop and lab use; torso-and-arms platform on a stand |
| 执行器 | Feetech servos |
| 感知与计算 | |
| 传感器 | Orbbec depth camera (head), servo position feedback |
| 软件 / AI | ROS 1 (Noetic/Melodic) meta-package: URDF description, Feetech servo control, inverse kinematics, Gazebo simulation; VR and machine-learning control |
图片
 martti
 martti
 martti
 martti
 martti
图片贡献
视频
机器人论坛
正在加载论坛...
评分
常见问题
What is the Red Rabbit Robotics RX1?
RX1 is a human-scale dual-arm humanoid that Red Rabbit Robotics gave away. Rather than keep the design in-house, the company published the CAD, the bill of materials, the servo, arm, hand, head and torso hardware files and a ROS 1 driver — its own claim is that you can build one for under a thousand dollars from 3D-pri…
Who makes the Red Rabbit Robotics RX1?
The Red Rabbit Robotics RX1 is made by Red Rabbit Robotics, a robotics company based in United States.
How much does the Red Rabbit Robotics RX1 cost?
Red Rabbit Robotics has not publicly announced pricing for the Red Rabbit Robotics RX1. You can enquire through RobotAIGeek for current pricing.
What is the Red Rabbit Robotics RX1 used for?
The Red Rabbit Robotics RX1 is designed for 发展, 物料搬运, 研究, and 教育. It is used in 研究, 教育, 物流, and 制造业 settings.
与同类机器人对比
看看这款机器人与最接近的同类产品相比表现如何
- Red Rabbit Robotics RX1 vs InMoov
- Red Rabbit Robotics RX1 vs Nino
- Red Rabbit Robotics RX1 vs Robovie-Z
- Red Rabbit Robotics RX1 vs Lanxin H6 Standard
- Red Rabbit Robotics RX1 vs HOPEJr