설명
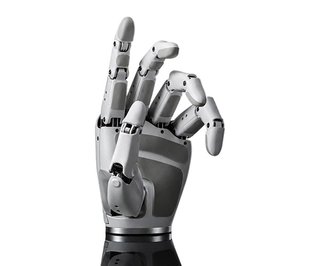
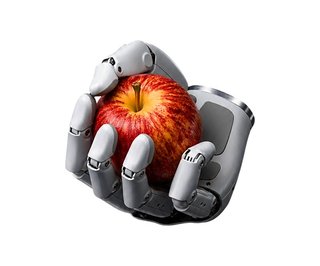
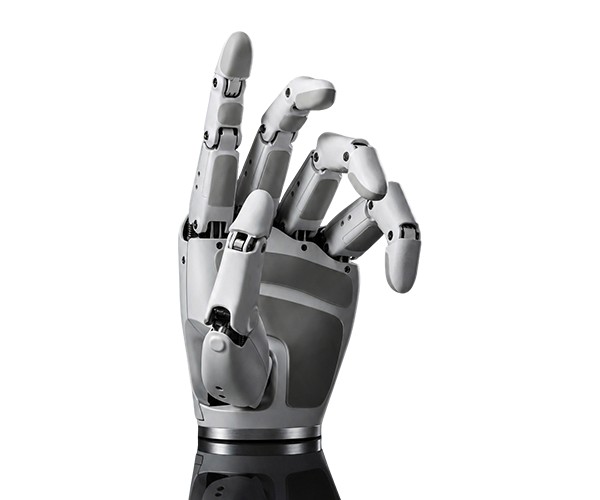
KAI Hand은(는) Kinetix AI 超维动力의 End-Effectors입니다. 개발, 자재 취급, 연구 용도로 설계되었습니다. 주요 수치: 0.8 kg, 37 자유도.
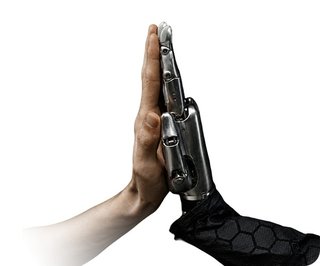
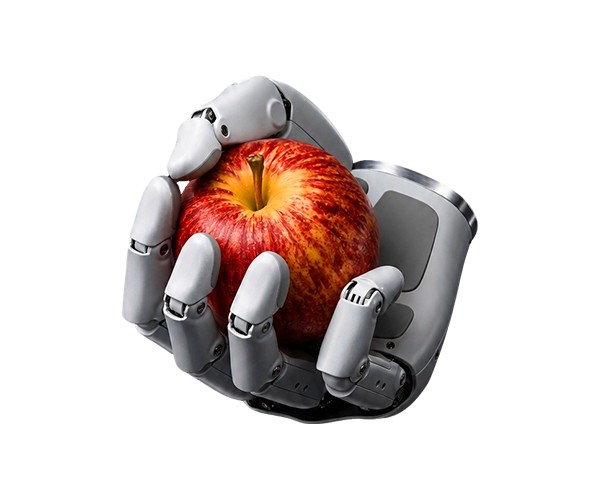
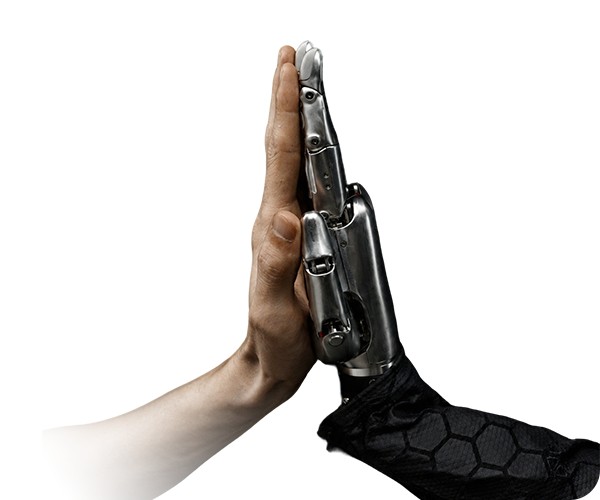
KAI Hand is Kinetix AI's human-scale dexterous hand for embodied-AI robots. Built 1:1 to an adult hand at 185 x 90 x 40 mm and 750 g, it has 37 degrees of freedom - 20 active, 1 passive and 16 compliant - so it can be a natural target for retargeting human demonstrations and transferring manipulation data to robots. A hybrid direct and tendon drive with unidirectional self-locking keeps heat down during sustained grasps, field-oriented control drives each joint, and passive compliance lets the fingers give on contact. It delivers 30 N of fingertip grip and 2 kg of dynamic load per finger with +/-1 mm repeatability, and quick-swap fingers cut maintenance time. Fingertip tactile sensing comes as standard and a wrist-mounted stereo camera is optional, feeding joint, touch and vision data for teleoperation and policy learning at up to 500 Hz over CAN, CAN FD, RS-485 or EtherCAT on a 12 V supply.
주요 기능
- 37 DoF: 20 active, 1 passive, 16 compliant
- 1:1 adult human-hand scale
- 185 x 90 x 40 mm
- 750 g
- Hybrid direct + tendon actuation with unidirectional self-locking
- field-oriented control
- Fingertip grip force 30 N
- dynamic load 2 kg per finger
- positioning repeatability +/-1 mm
- Fingertip tactile sensing standard
- optional wrist-mounted stereo camera
- Communication up to 500 Hz over CAN, CAN FD, RS-485 or EtherCAT
- 12 V (wide input)
- Passive compliance
- thermally balanced design
- modular quick-swap fingers
- Developer docs and SDK for teleoperation and policy learning
기술 사양
검증됨| 물리 사양 | |
| 무게 | 0.75 kg |
|---|---|
| 크기 | L 185 mm × W 90 mm × H 40 mm |
| 이동성 | |
| 이동 방식 | 고정형 |
| 자유도 | 37 |
| 작동 환경 | Mounted on humanoid or robot arms |
| 액추에이터 | Hybrid direct and tendon actuation with unidirectional self-locking |
| 센싱 & 컴퓨팅 | |
| 센서 | fingertip tactile sensors, optional wrist stereo camera |
| 연결성 | CAN, CAN FD, RS-485, EtherCAT (up to 500 Hz) |
로봇 포럼
포럼 불러오는 중...
기술 사양
검증됨| 물리 사양 | |
| 무게 | 0.75 kg |
|---|---|
| 크기 | L 185 mm × W 90 mm × H 40 mm |
| 이동성 | |
| 이동 방식 | 고정형 |
| 자유도 | 37 |
| 작동 환경 | Mounted on humanoid or robot arms |
| 액추에이터 | Hybrid direct and tendon actuation with unidirectional self-locking |
| 센싱 & 컴퓨팅 | |
| 센서 | fingertip tactile sensors, optional wrist stereo camera |
| 연결성 | CAN, CAN FD, RS-485, EtherCAT (up to 500 Hz) |
이미지
 martti
 martti
 martti
이미지 기여
동영상
로봇 포럼
포럼 불러오는 중...
평가
자주 묻는 질문
What is the KAI Hand?
KAI Hand is Kinetix AI's human-scale dexterous hand for embodied-AI robots. Built 1:1 to an adult hand at 185 x 90 x 40 mm and 750 g, it has 37 degrees of freedom - 20 active, 1 passive and 16 compliant - so it can be a natural target for retargeting human demonstrations and transferring manipulation data to robots.
Who makes the KAI Hand?
The KAI Hand is made by Kinetix AI 超维动力, a robotics company based in China.
How much does the KAI Hand cost?
Kinetix AI 超维动力 has not publicly announced pricing for the KAI Hand. You can enquire through RobotAIGeek for current pricing.
What is the KAI Hand used for?
The KAI Hand is designed for 개발, 자재 취급, 연구, and humanoid manipulation, teleoperation, manipulation-policy learning. It is used in 연구 and 제조 settings.
How much does the KAI Hand weigh?
The KAI Hand weighs 0.75 kg.
How many degrees of freedom does the KAI Hand have?
The KAI Hand has 37 degrees of freedom.
유사 로봇과 비교
이 로봇이 가장 가까운 대안들과 어떻게 비교되는지 확인하세요
- KAI Hand vs Xynova Prima 1
- KAI Hand vs Xynova Flex 2
- KAI Hand vs TRI Punyo
- KAI Hand vs Tokyo Robotics Torobo
- KAI Hand vs WIRobotics ALLEX