説明
KAI HandはKinetix AI 超维动力のEnd-Effectorsです。 開発、マテリアルハンドリング、研究向けに設計されています。 主な数値:0.8 kg、37 自由度。
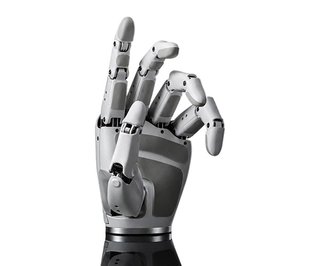
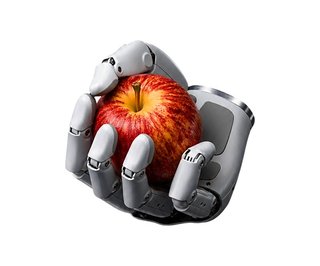
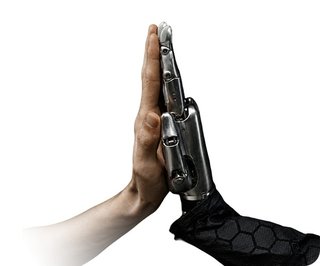
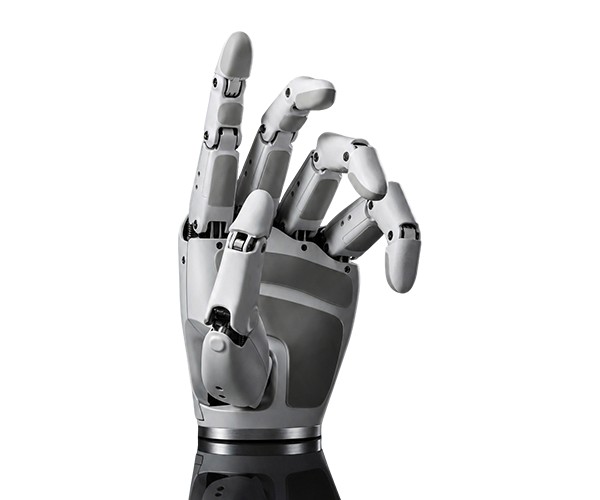
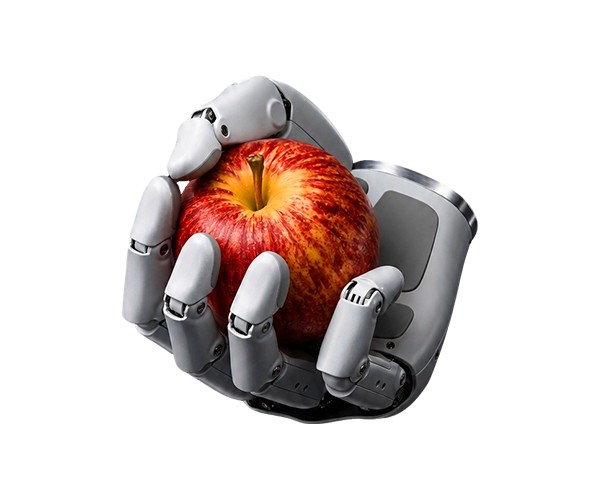
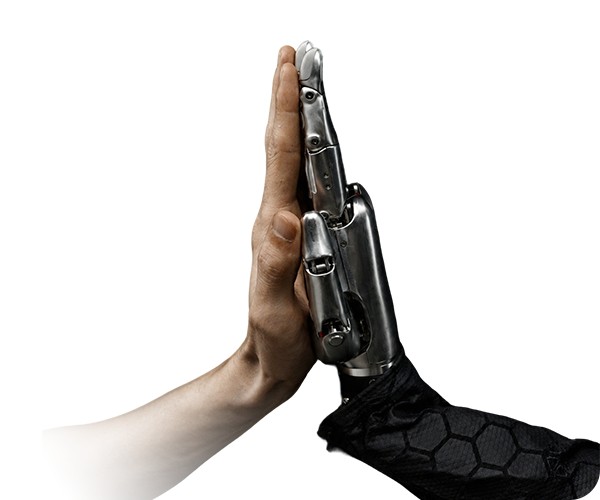
KAI Hand is Kinetix AI's human-scale dexterous hand for embodied-AI robots. Built 1:1 to an adult hand at 185 x 90 x 40 mm and 750 g, it has 37 degrees of freedom - 20 active, 1 passive and 16 compliant - so it can be a natural target for retargeting human demonstrations and transferring manipulation data to robots. A hybrid direct and tendon drive with unidirectional self-locking keeps heat down during sustained grasps, field-oriented control drives each joint, and passive compliance lets the fingers give on contact. It delivers 30 N of fingertip grip and 2 kg of dynamic load per finger with +/-1 mm repeatability, and quick-swap fingers cut maintenance time. Fingertip tactile sensing comes as standard and a wrist-mounted stereo camera is optional, feeding joint, touch and vision data for teleoperation and policy learning at up to 500 Hz over CAN, CAN FD, RS-485 or EtherCAT on a 12 V supply.
特長
- 37 DoF: 20 active, 1 passive, 16 compliant
- 1:1 adult human-hand scale
- 185 x 90 x 40 mm
- 750 g
- Hybrid direct + tendon actuation with unidirectional self-locking
- field-oriented control
- Fingertip grip force 30 N
- dynamic load 2 kg per finger
- positioning repeatability +/-1 mm
- Fingertip tactile sensing standard
- optional wrist-mounted stereo camera
- Communication up to 500 Hz over CAN, CAN FD, RS-485 or EtherCAT
- 12 V (wide input)
- Passive compliance
- thermally balanced design
- modular quick-swap fingers
- Developer docs and SDK for teleoperation and policy learning
技術仕様
検証済み| 本体 | |
| 重量 | 0.75 kg |
|---|---|
| 寸法 | L 185 mm × W 90 mm × H 40 mm |
| 移動性能 | |
| 移動方式 | 固定型 |
| 自由度 | 37 |
| 使用環境 | Mounted on humanoid or robot arms |
| アクチュエーター | Hybrid direct and tendon actuation with unidirectional self-locking |
| センシング・演算 | |
| センサー | fingertip tactile sensors, optional wrist stereo camera |
| 接続性 | CAN, CAN FD, RS-485, EtherCAT (up to 500 Hz) |
ロボットフォーラム
フォーラムを読み込み中...
技術仕様
検証済み| 本体 | |
| 重量 | 0.75 kg |
|---|---|
| 寸法 | L 185 mm × W 90 mm × H 40 mm |
| 移動性能 | |
| 移動方式 | 固定型 |
| 自由度 | 37 |
| 使用環境 | Mounted on humanoid or robot arms |
| アクチュエーター | Hybrid direct and tendon actuation with unidirectional self-locking |
| センシング・演算 | |
| センサー | fingertip tactile sensors, optional wrist stereo camera |
| 接続性 | CAN, CAN FD, RS-485, EtherCAT (up to 500 Hz) |
画像
 martti
 martti
 martti
投稿画像
動画
ロボットフォーラム
フォーラムを読み込み中...
評価
よくある質問
What is the KAI Hand?
KAI Hand is Kinetix AI's human-scale dexterous hand for embodied-AI robots. Built 1:1 to an adult hand at 185 x 90 x 40 mm and 750 g, it has 37 degrees of freedom - 20 active, 1 passive and 16 compliant - so it can be a natural target for retargeting human demonstrations and transferring manipulation data to robots.
Who makes the KAI Hand?
The KAI Hand is made by Kinetix AI 超维动力, a robotics company based in China.
How much does the KAI Hand cost?
Kinetix AI 超维动力 has not publicly announced pricing for the KAI Hand. You can enquire through RobotAIGeek for current pricing.
What is the KAI Hand used for?
The KAI Hand is designed for 開発, マテリアルハンドリング, 研究, and humanoid manipulation, teleoperation, manipulation-policy learning. It is used in 研究 and 製造 settings.
How much does the KAI Hand weigh?
The KAI Hand weighs 0.75 kg.
How many degrees of freedom does the KAI Hand have?
The KAI Hand has 37 degrees of freedom.
類似ロボットと比較
このロボットが最も近い代替候補とどう比べられるかをご覧ください
- KAI Hand vs Xynova Prima 1
- KAI Hand vs Xynova Flex 2
- KAI Hand vs TRI Punyo
- KAI Hand vs Tokyo Robotics Torobo
- KAI Hand vs WIRobotics ALLEX