


DESCRIPTION
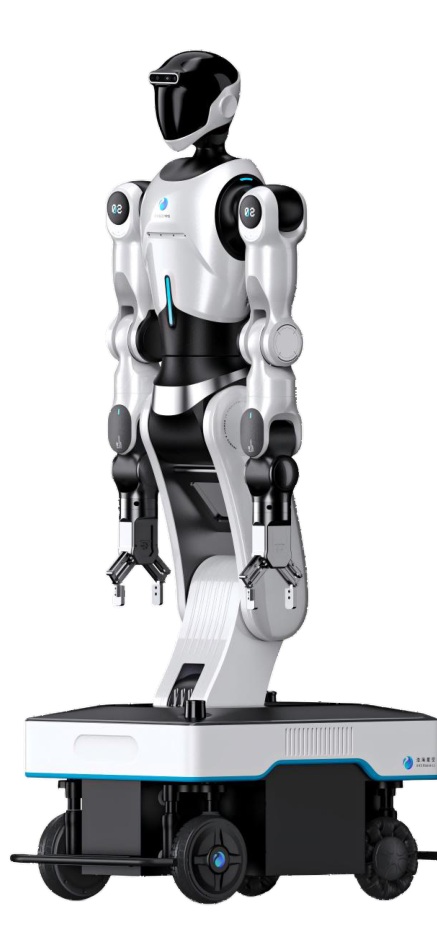
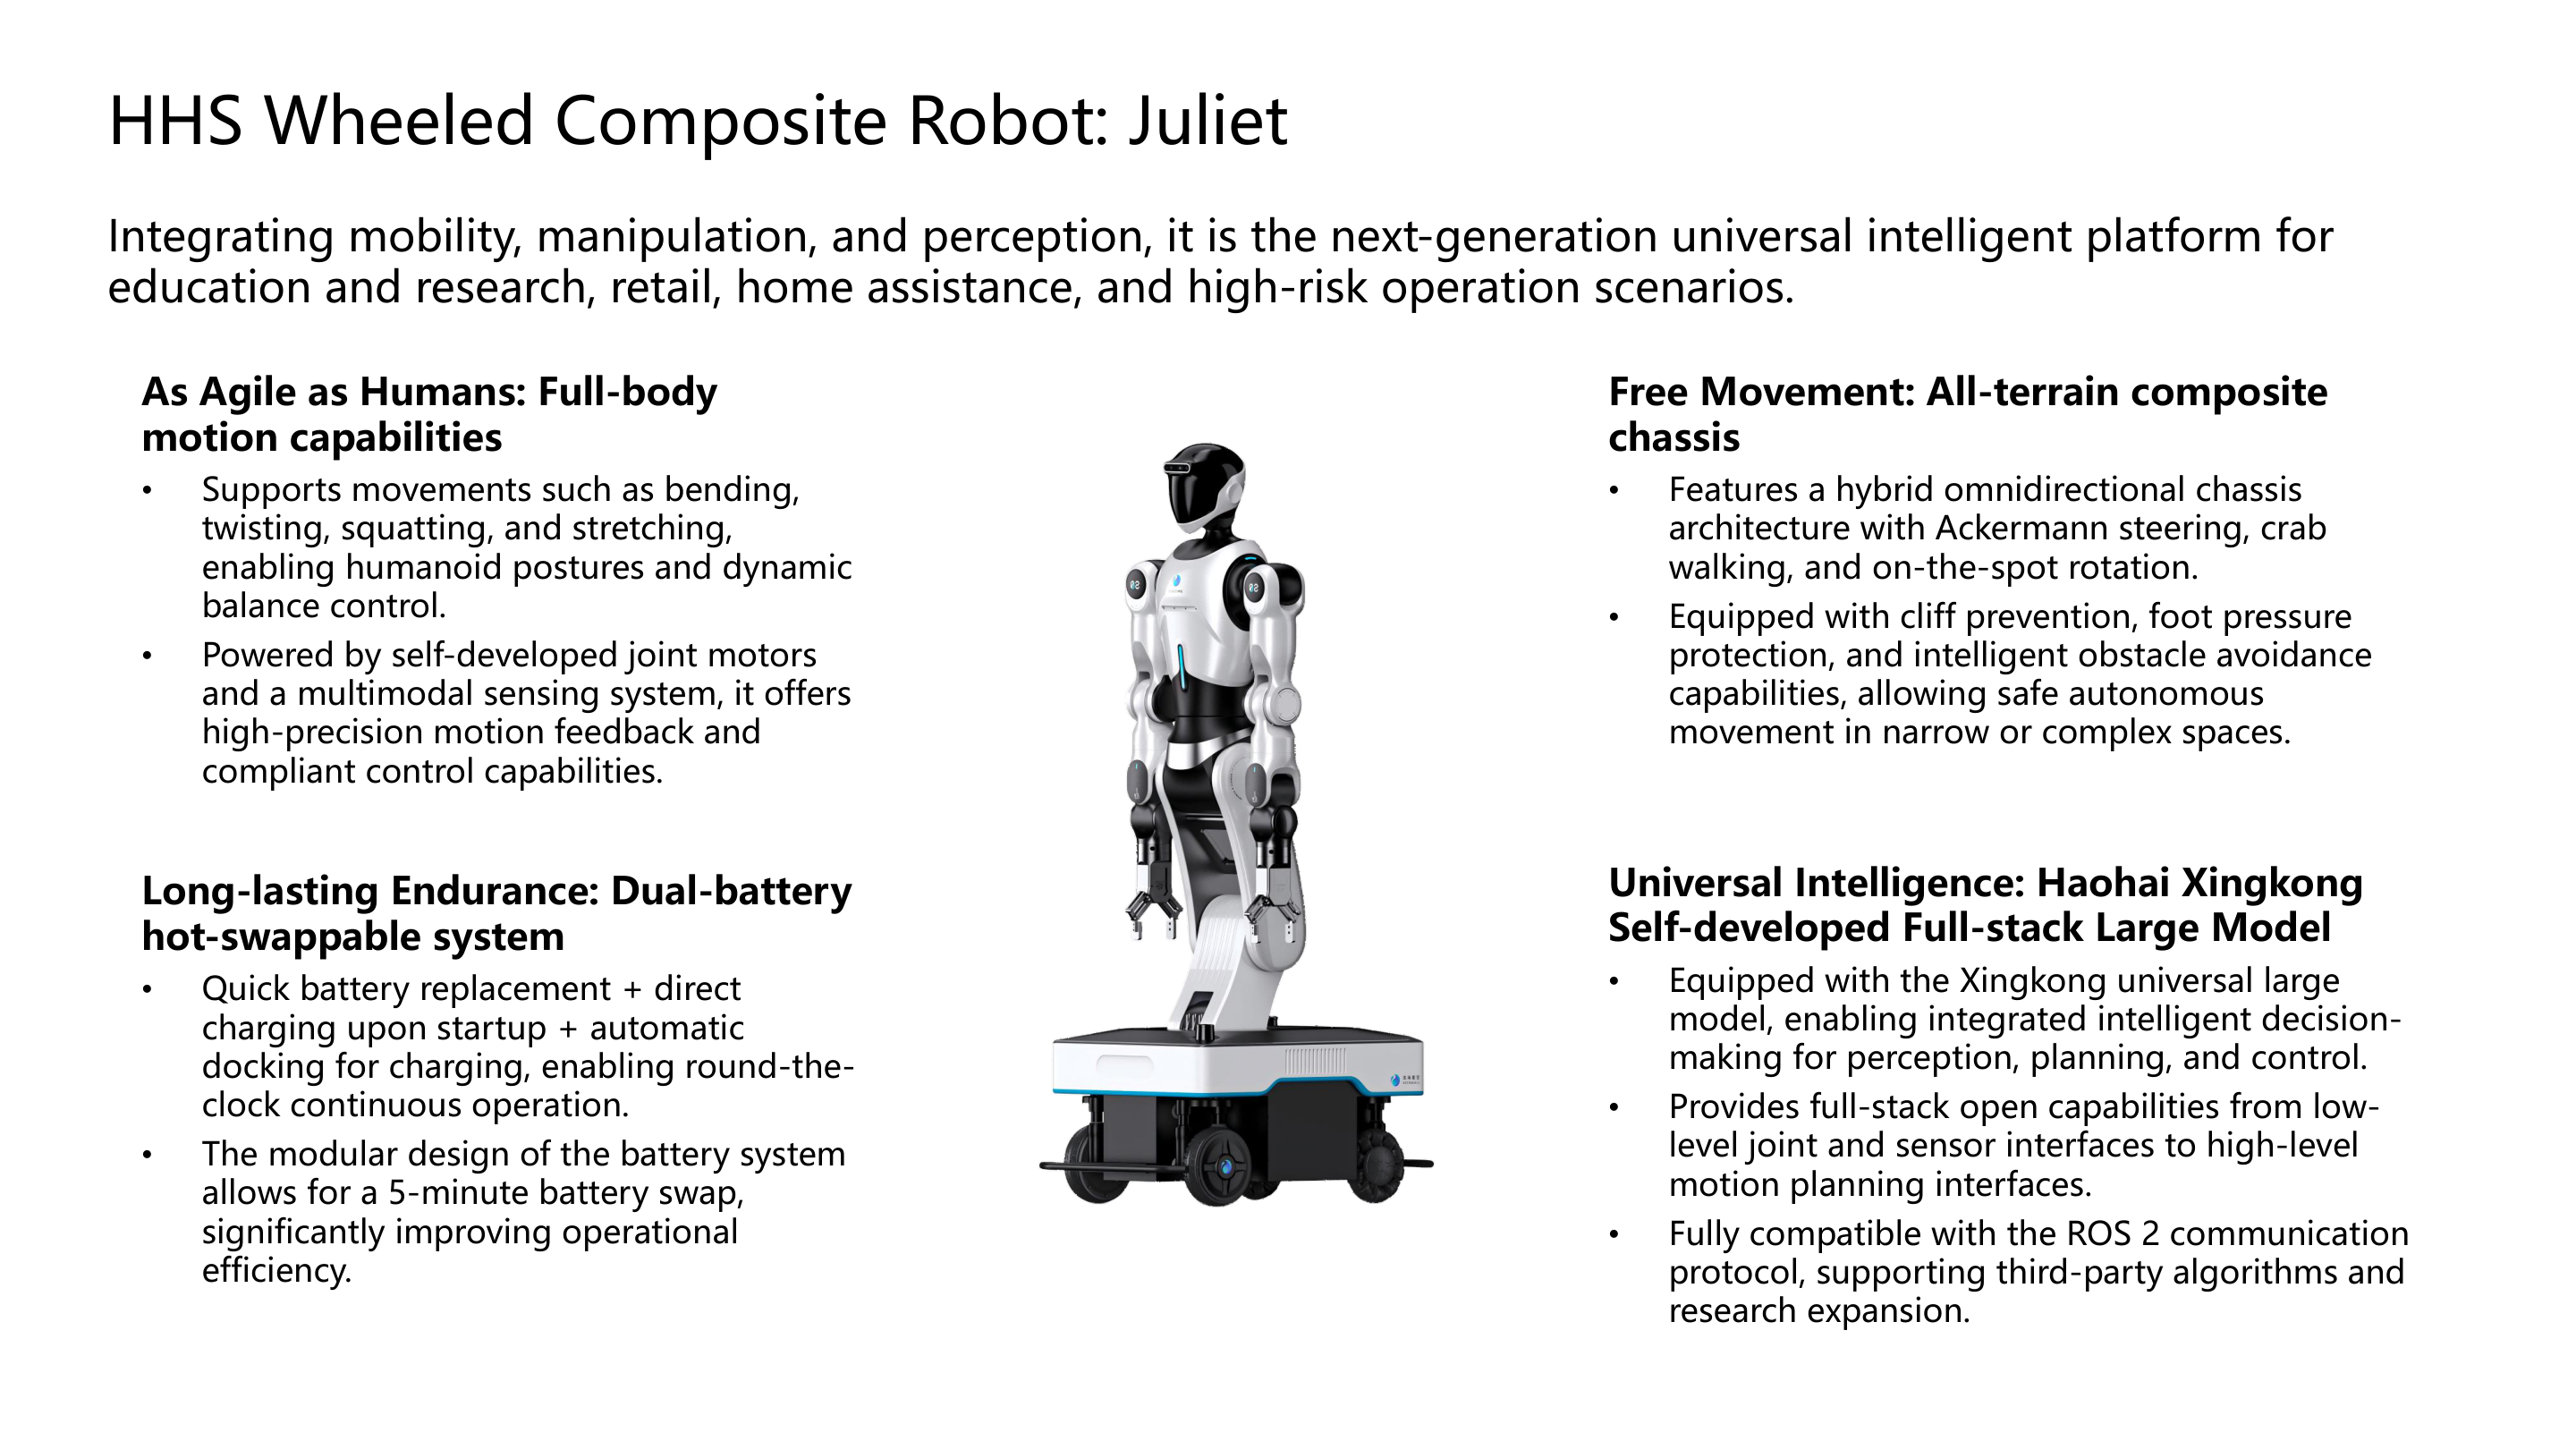
Juliet is HHS Robotics' wheeled composite robot — a humanoid upper body with full-body articulation mounted on an all-terrain composite chassis, pitched as a universal platform across education and research, retail, home assistance and high-risk work. The chassis is the interesting half: a hybrid omnidirectional architecture combining Ackermann steering with crab walking and on-the-spot rotation, with cliff prevention, foot pressure protection and obstacle avoidance so it can move autonomously through narrow or cluttered space. The torso is genuinely articulated rather than a fixed mast, supporting bending, twisting, squatting and stretching under dynamic balance control, driven by HHS's own joint motors with compliant control and high-precision motion feedback. In its retail deployment HHS quotes an end payload of up to 10 kg with ±0.1 mm grasping accuracy across more than 300 SKUs, plus two linear four-microphone arrays for natural-language interaction in noisy outdoor settings and eight hours of endurance with intelligent charging scheduling. Dual hot-swappable batteries allow a five-minute swap with automatic docking for round-the-clock operation. Intelligence comes from HHS's own Xingkong full-stack large model handling perception, planning and control, exposed from low-level joint and sensor interfaces up to motion planning, and fully ROS 2 compatible for third-party algorithms.
FEATURES
- Humanoid upper body with full-body motion — bending, twisting, squatting and stretching under dynamic balance control — on self-developed joint motors with compliant control and high-precision motion feedback
- hybrid omnidirectional chassis combining Ackermann steering, crab walking and on-the-spot rotation, with cliff prevention, foot pressure protection and intelligent obstacle avoidance
- end payload up to 10 kg with ±0.1 mm grasping accuracy across more than 300 SKUs
- two linear four-microphone arrays for natural-language interaction in noisy outdoor environments
- 8-hour endurance with intelligent charging scheduling
- dual hot-swappable battery system allowing a 5-minute swap plus direct charging on startup and automatic docking for round-the-clock operation
- Xingkong self-developed full-stack large model integrating perception, planning and control, with open interfaces from low-level joints and sensors up to motion planning
- fully ROS 2 compatible for third-party algorithms and research extension
- certified under the robot CR system.
TECHNICAL SPECIFICATIONS
| Physical | |
| Payload | 10 kg |
|---|---|
| Repeatability | ±0.1 mm |
| Mobility | |
| Movement Type | Wheeled |
| Manipulation | High |
| Actuators | Articulated humanoid torso on self-developed joint motors with compliant control, over a hybrid omnidirectional composite chassis with Ackermann steering, crab walking and on-the-spot rotation |
| Power | |
| Battery Life | 8 h |
| Charging Type | Dual hot-swappable batteries with 5-minute swap, direct charging on startup and automatic docking |
| Sensing & Compute | |
| Sensors | multimodal sensing system with high-precision motion feedback, 2x linear 4-microphone arrays, cliff prevention sensing, foot pressure protection, obstacle avoidance sensing |
| Software / AI | Xingkong self-developed full-stack large model for integrated perception, planning and control; open interfaces from low-level joint and sensor level to high-level motion planning; ROS 2 compatible |
Images
 martti
 martti
Image Contributions
Videos
ROBOT FORUMS
Loading forums...
RATINGS
FREQUENTLY ASKED QUESTIONS
What is the HHS Juliet?
Juliet is HHS Robotics' wheeled composite robot — a humanoid upper body with full-body articulation mounted on an all-terrain composite chassis, pitched as a universal platform across education and research, retail, home assistance and high-risk work.
Who makes the HHS Juliet?
The HHS Juliet is made by HHS Robotics (浩海星空机器人有限公司), a robotics company based in China.
How much does the HHS Juliet cost?
HHS Robotics (浩海星空机器人有限公司) has not publicly announced pricing for the HHS Juliet. You can enquire through RobotAIGeek for current pricing.
What is the HHS Juliet used for?
The HHS Juliet is designed for pick-and-place, unattended retail and vending, education and research platforms, and home assistance. It is used in education, homes, retail, and security & patrol settings.
What is the payload capacity of the HHS Juliet?
The HHS Juliet has a payload capacity of 10 kg.
What is the battery life of the HHS Juliet?
The HHS Juliet runs for 8 h on a charge.
COMPARE WITH SIMILAR ROBOTS
See how this robot stacks up against its closest alternatives
- HHS Juliet vs Noetix M1
- HHS Juliet vs Gento Luna
- HHS Juliet vs Noetix M1-Pro
- HHS Juliet vs QiO O1
- HHS Juliet vs sudo R1