描述
MagCrawler是TSC Subsea的Industrial-Robot。 面向檢查、監測設計。
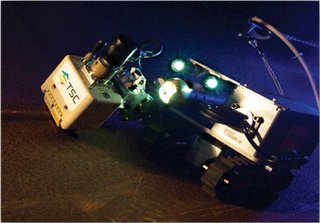
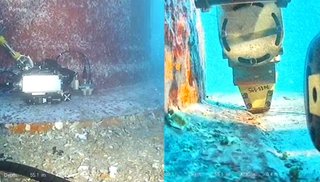
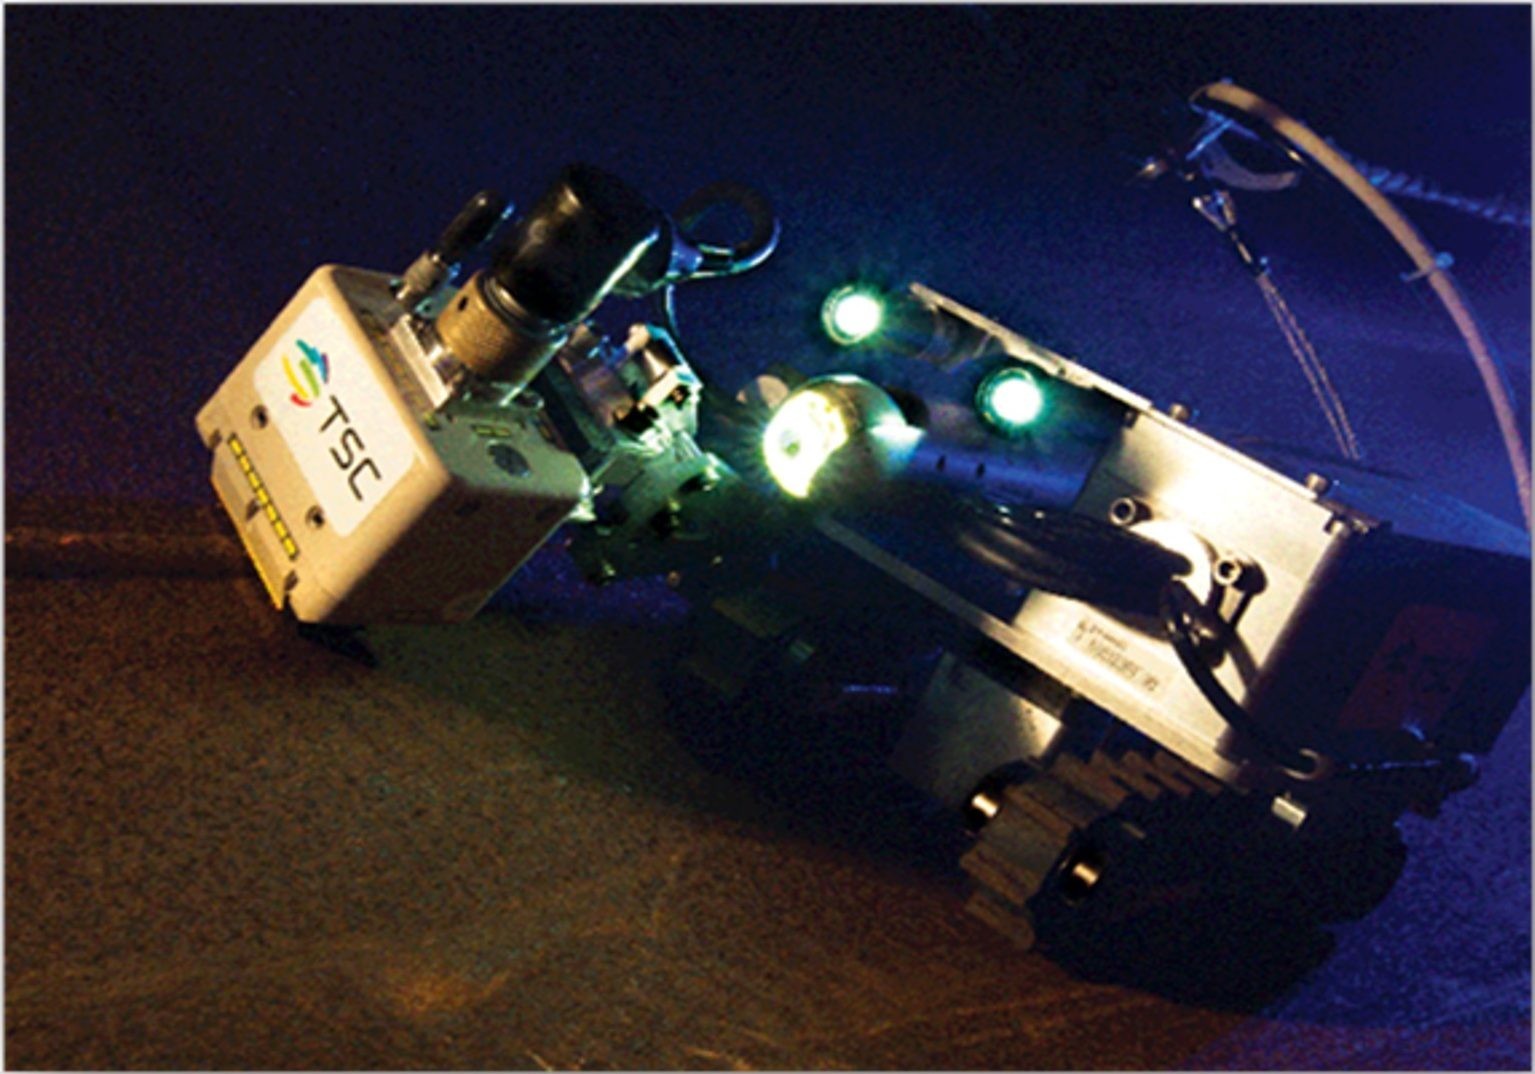
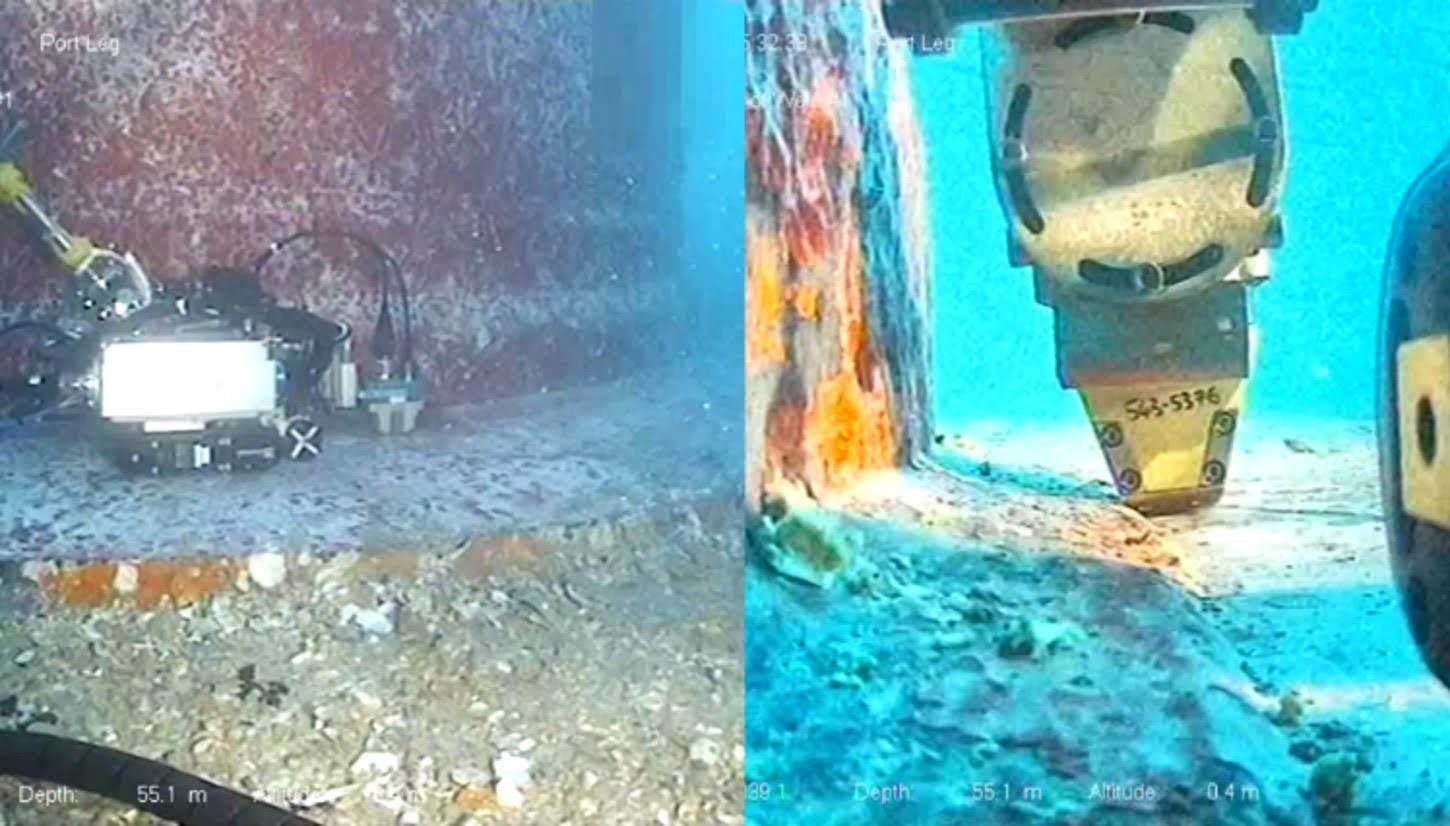
MagCrawler is TSC Subsea's remotely operated magnetic crawler for subsea and splash-zone weld inspection, developed so that an ROV can deploy TSC Subsea's exclusive ACFM (Alternating Current Field Measurement) array probes onto circumferential welds in pipes and tubulars and onto fillet and full-penetration welds in plates. It reaches areas that are restricted, dangerous or expensive to reach with divers, such as splash zones and confined compartments. The ROV carries the crawler to the structure and releases it once it has attached magnetically to the surface. Two rubber caterpillar tracks drive and steer it, motorised mechanisms place the probe precisely over the weld, a 360-degree rotating head gives full coverage of flange welds and the heat-affected zone, and passive compliance keeps the probe aligned on the surface. Dedicated control software follows simple weld paths with closed-loop motor control for accurate weld tracking at a uniform scan speed, while on-board backlit cameras give the operator real-time visual feedback. It can also be launched from deck, inspects through paint and coatings and tolerates residual marine growth.
功能特色
- Magnetic attachment
- ROV-deployed or deck-launched
- Two rubber caterpillar tracks for traction and steering
- Deploys ACFM array probes on welds
- Motorised probe positioning, longitudinal and transverse adjustment
- 360-degree rotating head for flange welds
- Closed-loop motor control for weld tracking
- On-board backlit cameras
- Rated to 150 m water depth
- Works on diameters above 760 mm
- Inspects through paint and coatings
技術規格
已驗證| 移動能力 | |
| 移動類型 | 帶輪的 |
|---|---|
| 作業環境 | Subsea structures and splash zones of offshore oil and gas and wind assets, water depths up to 150 m |
| 致動器 | Two rubber caterpillar tracks with magnetic attachment; motorised probe deployment and 360-degree rotating head |
| 感知與計算 | |
| 感測器 | ACFM array probes; on-board backlit cameras |
| 軟體 / AI | Dedicated control software for weld-path following with closed-loop motor control |
機器人論壇
正在載入論壇...
技術規格
已驗證| 移動能力 | |
| 移動類型 | 帶輪的 |
|---|---|
| 作業環境 | Subsea structures and splash zones of offshore oil and gas and wind assets, water depths up to 150 m |
| 致動器 | Two rubber caterpillar tracks with magnetic attachment; motorised probe deployment and 360-degree rotating head |
| 感知與計算 | |
| 感測器 | ACFM array probes; on-board backlit cameras |
| 軟體 / AI | Dedicated control software for weld-path following with closed-loop motor control |
圖片
 martti
 martti
圖片貢獻
影片
機器人論壇
正在載入論壇...
評分
常見問題
What is the MagCrawler?
MagCrawler is TSC Subsea's remotely operated magnetic crawler for subsea and splash-zone weld inspection, developed so that an ROV can deploy TSC Subsea's exclusive ACFM (Alternating Current Field Measurement) array probes onto circumferential welds in pipes and tubulars and onto fillet and full-penetration welds in pl…
Who makes the MagCrawler?
The MagCrawler is made by TSC Subsea, a robotics company based in United Kingdom.
How much does the MagCrawler cost?
TSC Subsea has not publicly announced pricing for the MagCrawler. You can enquire through RobotAIGeek for current pricing.
What is the MagCrawler used for?
The MagCrawler is designed for 檢查 and 監測. It is used in 能源 settings.
與同類機器人對比
看看這款機器人與最接近的同類產品相比表現如何
- MagCrawler vs ORCA Hull Inspection Crawler
- MagCrawler vs MAG Crawler
- MagCrawler vs A-UT Machine
- MagCrawler vs TRI Coal Conveyor Corridor Inspection Robot
- MagCrawler vs TRI Wind Turbine Nacelle Inspection Robot