DESCRIPTION
Xynova Prima 1 is an End-Effectors from Xynova. It is built for Development, Material-Handling, Research. Key figures: 22 degrees of freedom.
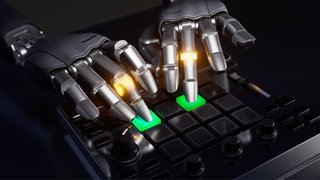
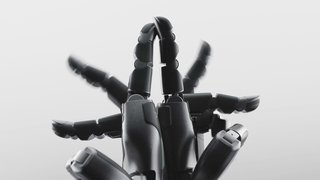
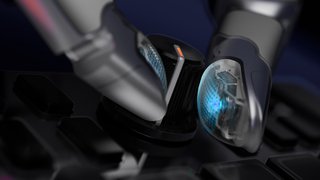
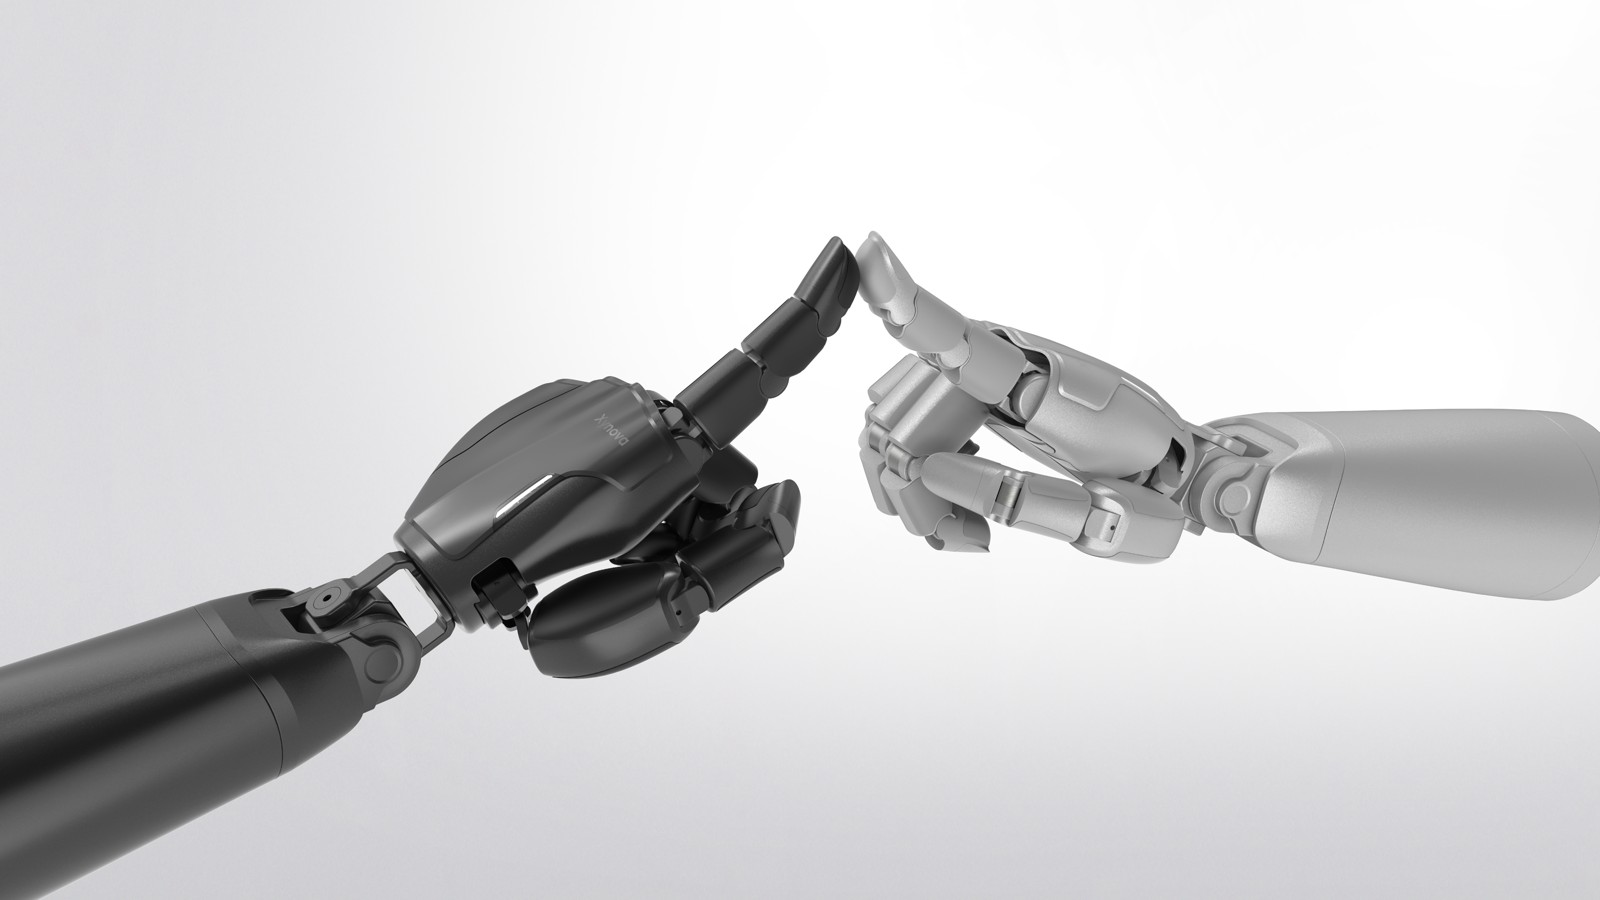
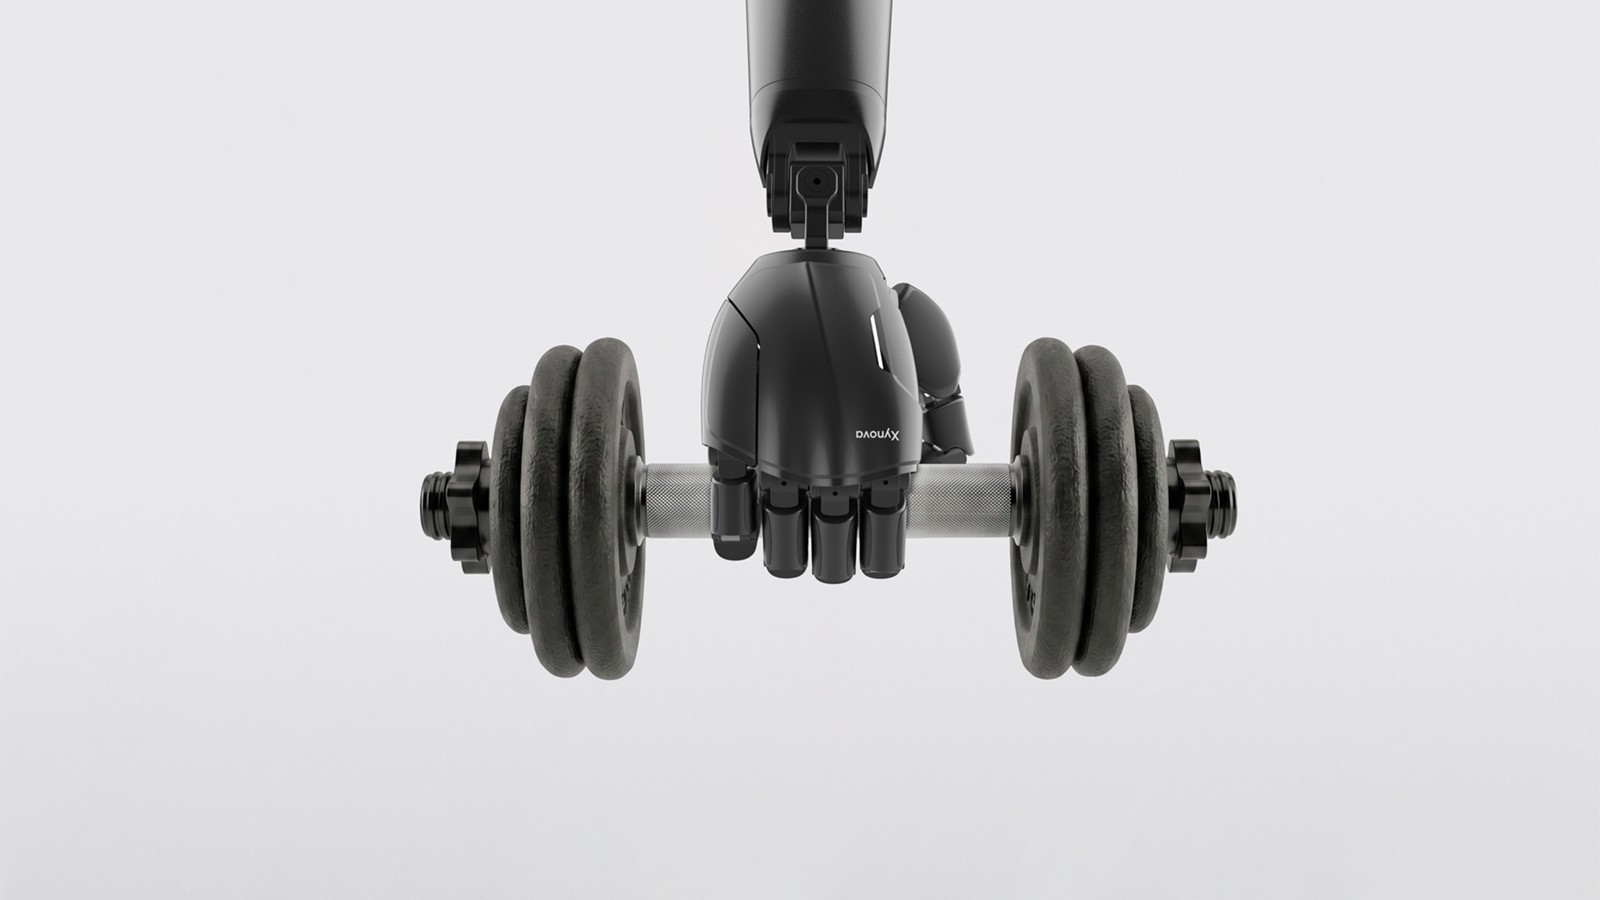
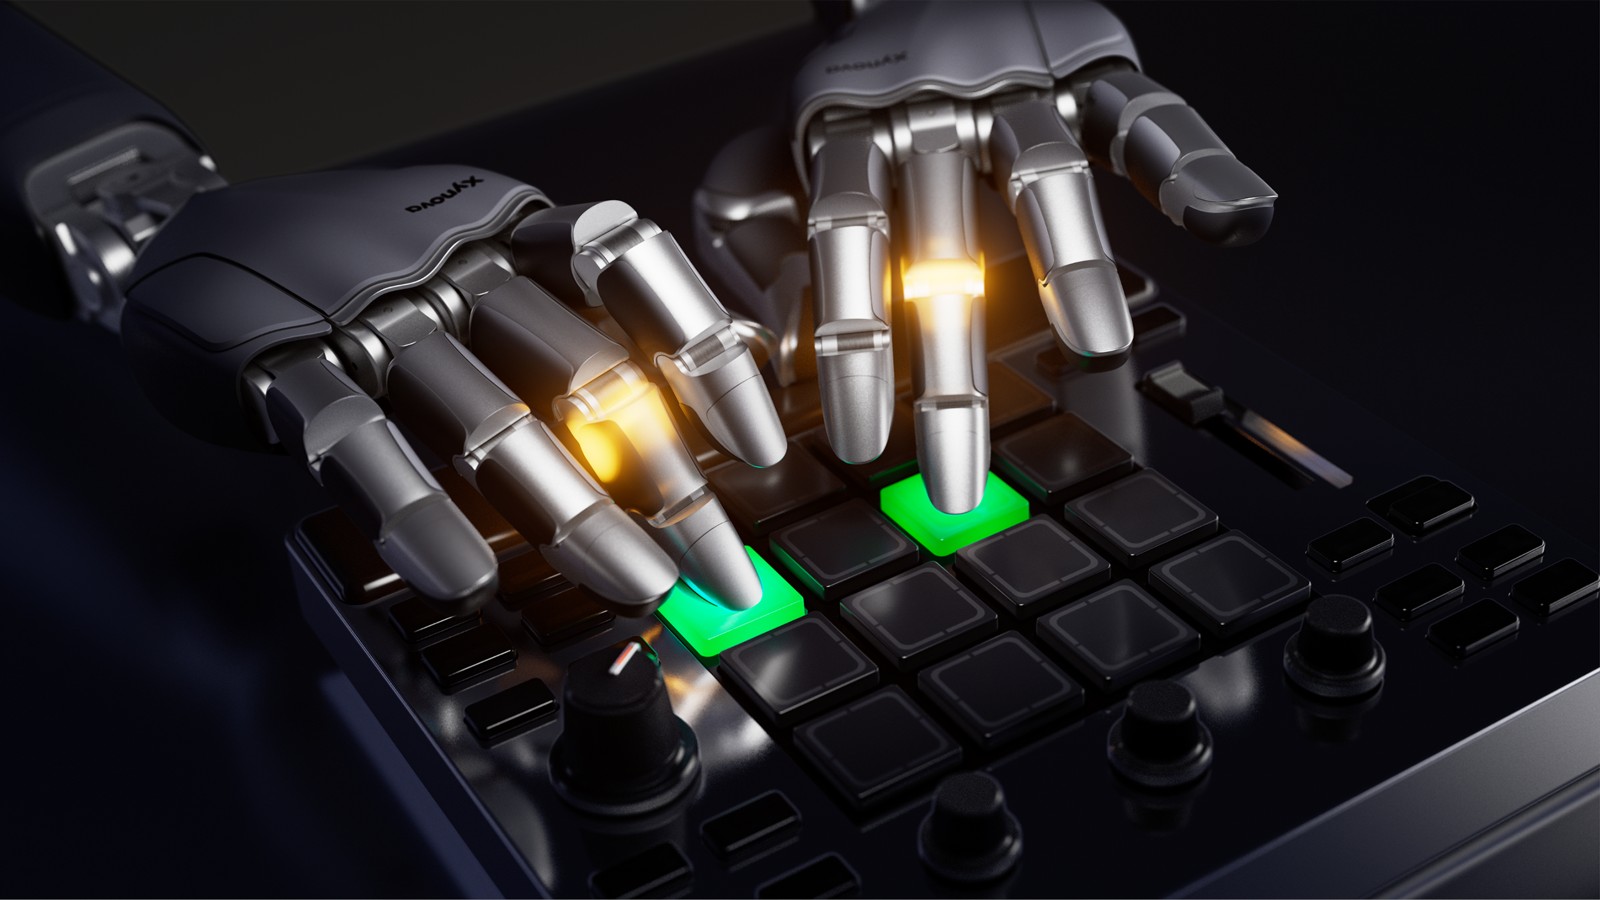
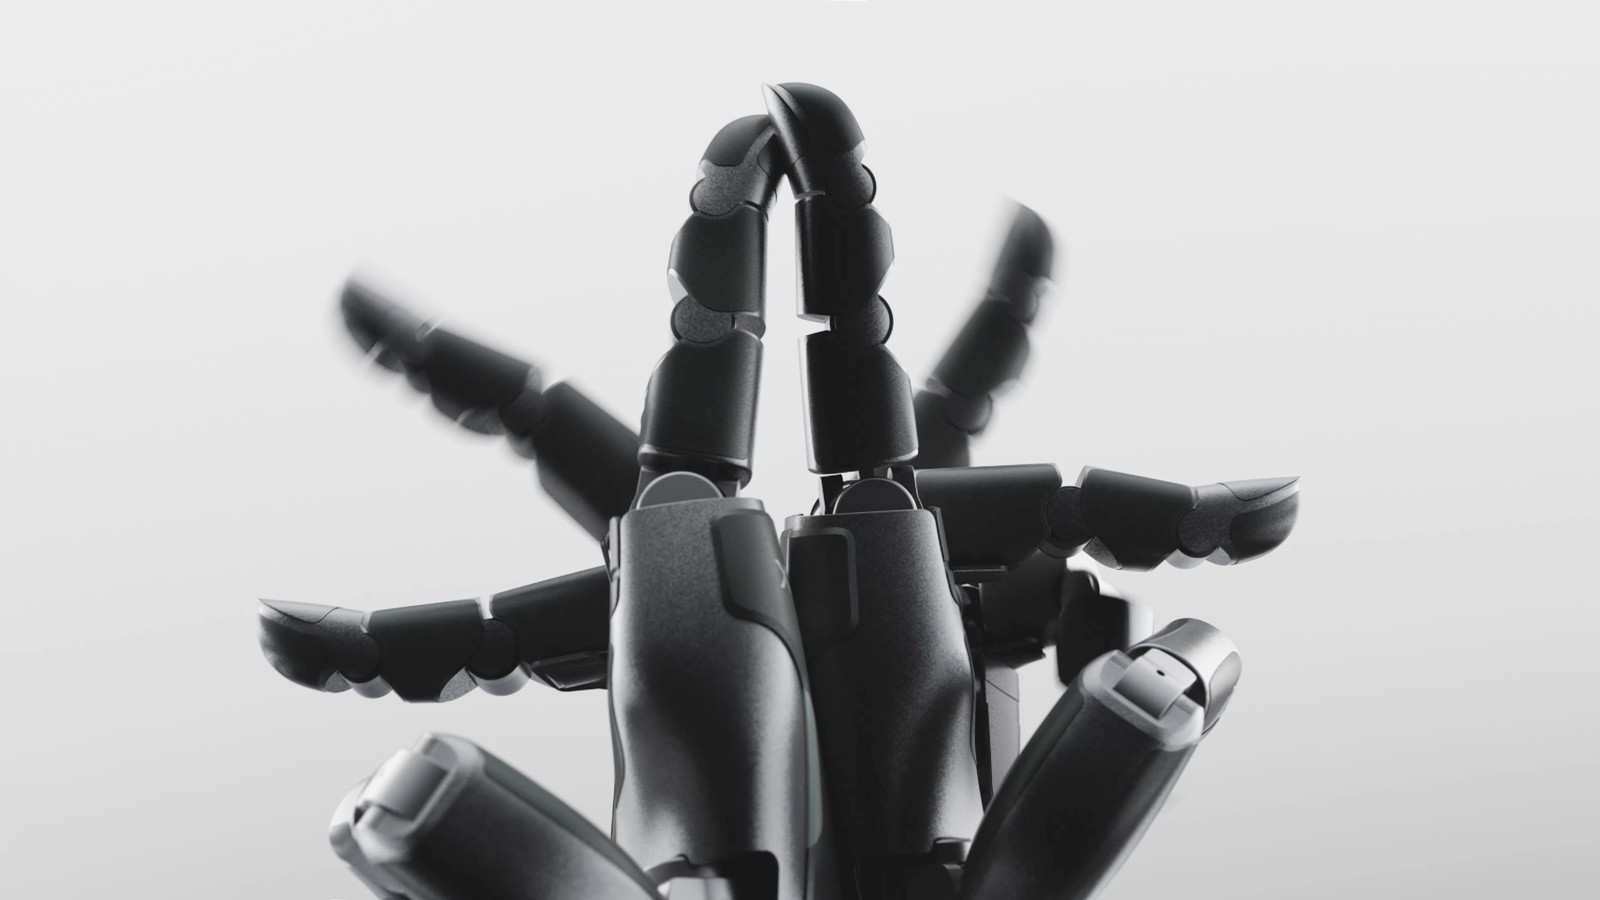
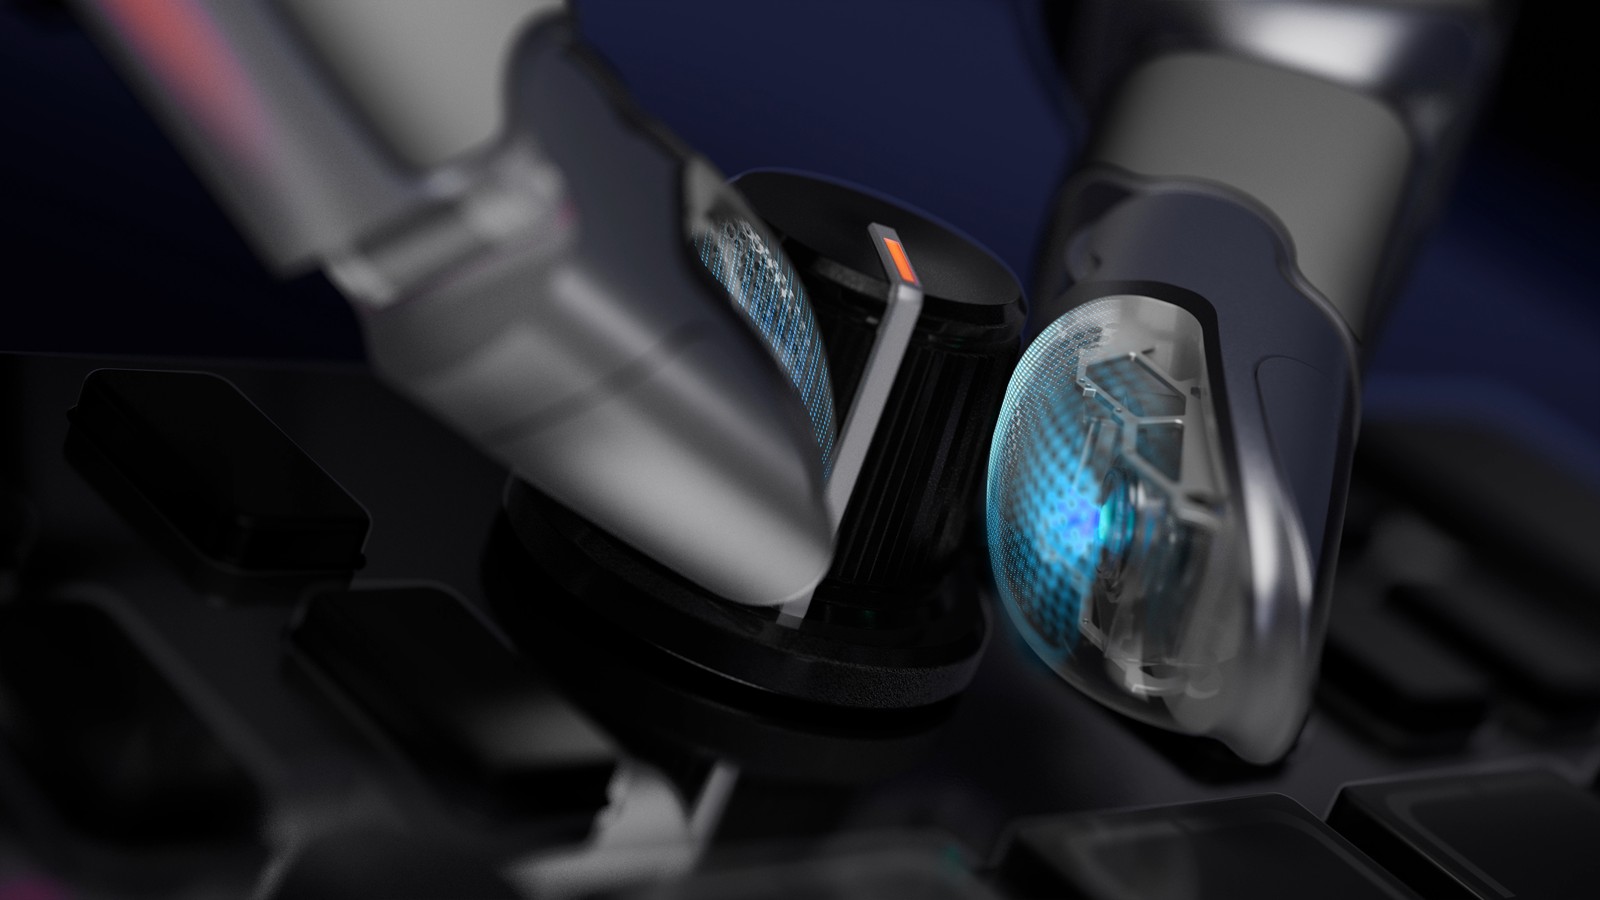
Xynova Prima 1 is a direct-drive dexterous robot hand from Hangzhou component maker Xynova, built 1:1 to human-hand scale (190 mm) for humanoid robots. Fully direct-drive joints with zero backlash give it millisecond response, a 1 kHz control bandwidth and a 0.08-second open/close cycle, and very low back-drive torque (0.04 Nm) makes it compliant and safe to touch. Its 22-DoF biomimetic configuration delivers 15 N of fingertip force across four fingers and lifts up to 20 kg, with 0.5 N force-control accuracy and 0.5 mm repeatability for native hybrid force-position control. All five fingers carry visuo-tactile sensing that captures fine contact changes at the fingertips as high-density feedback for manipulation learning.
FEATURES
- 22-DoF biomimetic dexterous hand, 1:1 human scale (190 mm)
- Fully direct-drive, zero backlash
- 1 kHz response bandwidth
- 0.08 s open/close cycle
- Fingertip force 15 N across four fingers
- lifting payload up to 20 kg
- Force-control accuracy 0.5 N
- repeatability 0.5 mm
- native hybrid force-position control
- Five-finger visuo-tactile sensing with high-density fingertip feedback
- Minimum back-drive torque 0.04 Nm for compliant, safe interaction
TECHNICAL SPECIFICATIONS
Verified| Mobility | |
| Movement Type | Stationary |
|---|---|
| Degrees of Freedom | 22 |
| Environment | Mounted on humanoid or robot arms |
| Actuators | Fully direct-drive finger joints |
| Sensing & Compute | |
| Sensors | five-finger visuo-tactile sensors |
TECHNICAL SPECIFICATIONS
Verified| Mobility | |
| Movement Type | Stationary |
|---|---|
| Degrees of Freedom | 22 |
| Environment | Mounted on humanoid or robot arms |
| Actuators | Fully direct-drive finger joints |
| Sensing & Compute | |
| Sensors | five-finger visuo-tactile sensors |
Images
 martti
 martti
 martti
 martti
 martti
Image Contributions
Videos
ROBOT FORUMS
Loading forums...
RATINGS
FREQUENTLY ASKED QUESTIONS
What is the Xynova Prima 1?
Xynova Prima 1 is a direct-drive dexterous robot hand from Hangzhou component maker Xynova, built 1:1 to human-hand scale (190 mm) for humanoid robots.
Who makes the Xynova Prima 1?
The Xynova Prima 1 is made by Xynova, a robotics company based in China.
How much does the Xynova Prima 1 cost?
Xynova has not publicly announced pricing for the Xynova Prima 1. You can enquire through RobotAIGeek for current pricing.
What is the Xynova Prima 1 used for?
The Xynova Prima 1 is designed for development, material-handling, research, and humanoid robot manipulation, teleoperation and manipulation-learning research. It is used in research and manufacturing settings.
How many degrees of freedom does the Xynova Prima 1 have?
The Xynova Prima 1 has 22 degrees of freedom.
COMPARE WITH SIMILAR ROBOTS
See how this robot stacks up against its closest alternatives
- Xynova Prima 1 vs KAI Hand
- Xynova Prima 1 vs Xynova Flex 2
- Xynova Prima 1 vs TRI Punyo
- Xynova Prima 1 vs Tokyo Robotics Torobo
- Xynova Prima 1 vs WIRobotics ALLEX