


DESCRIPTION
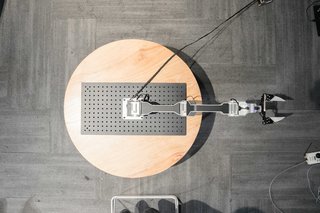
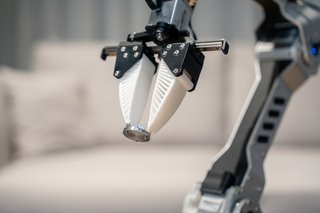
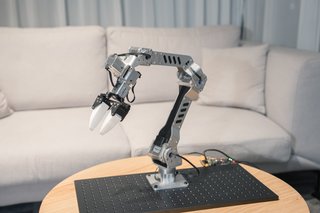
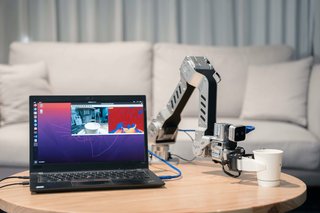
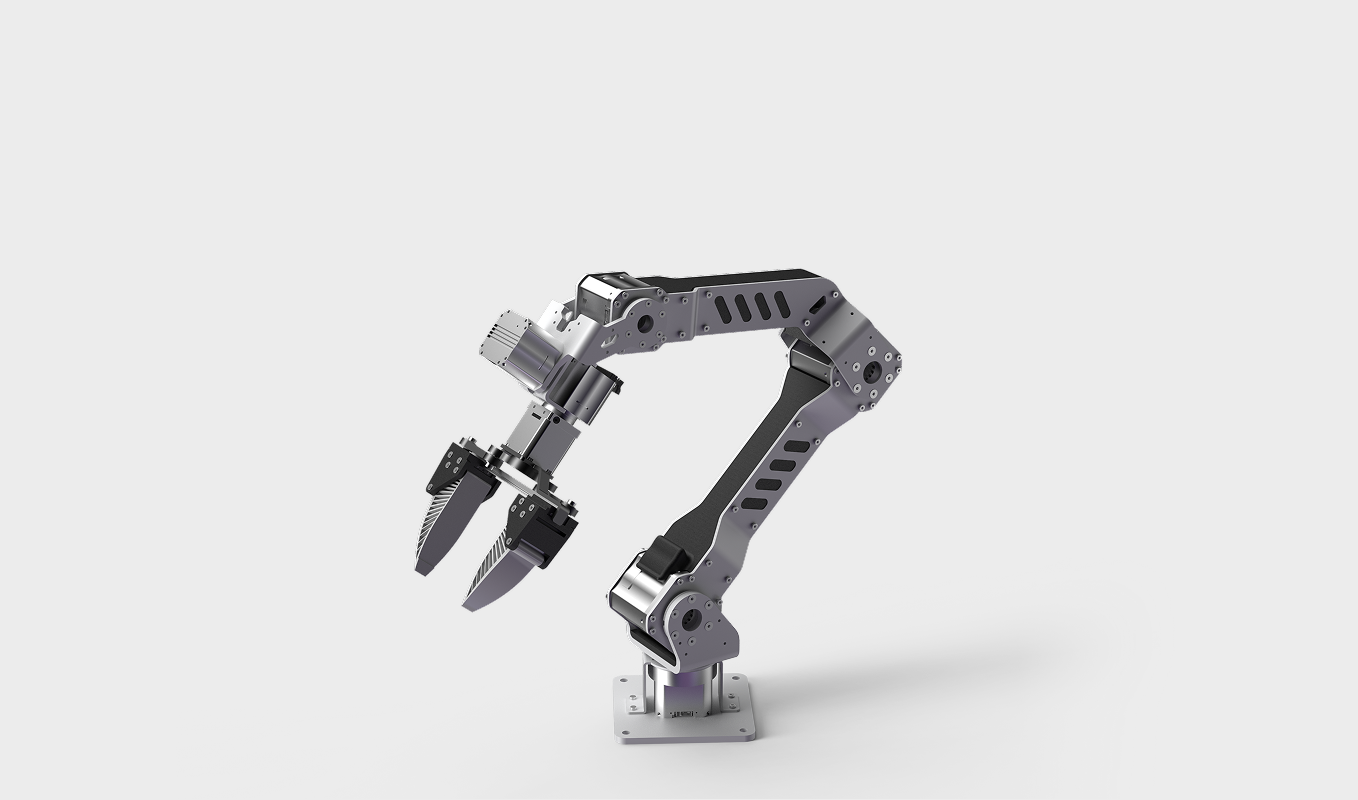
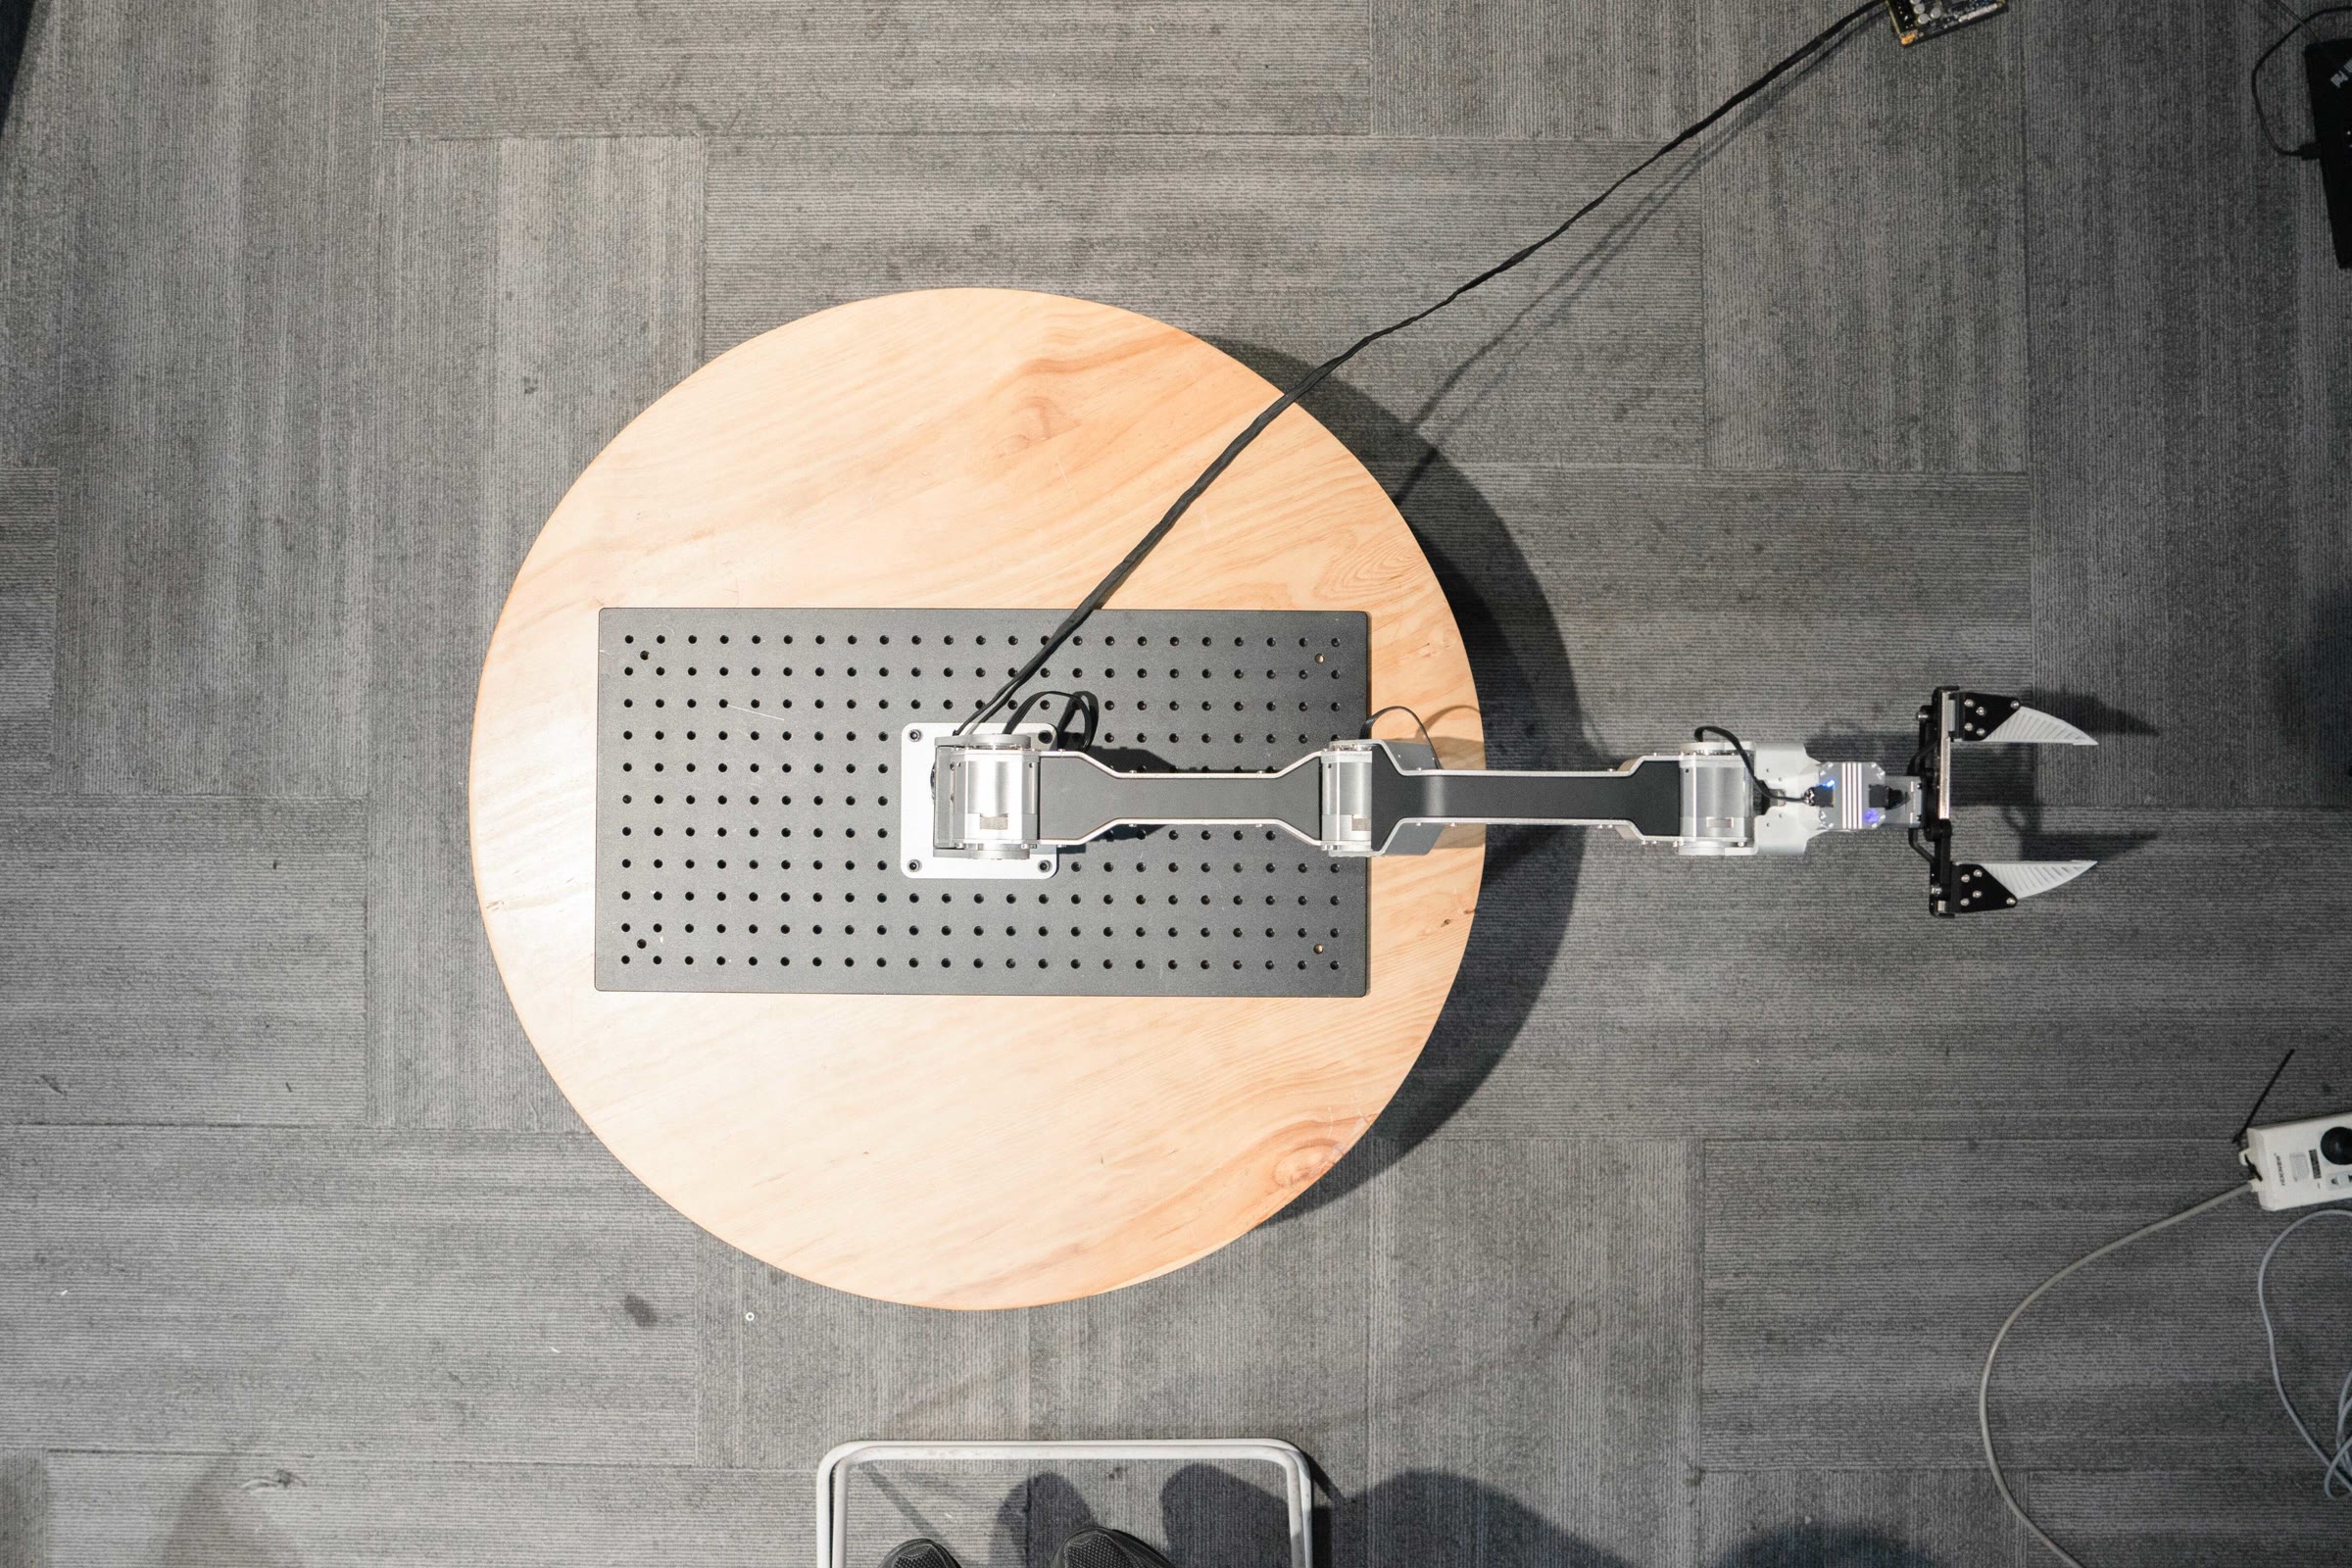
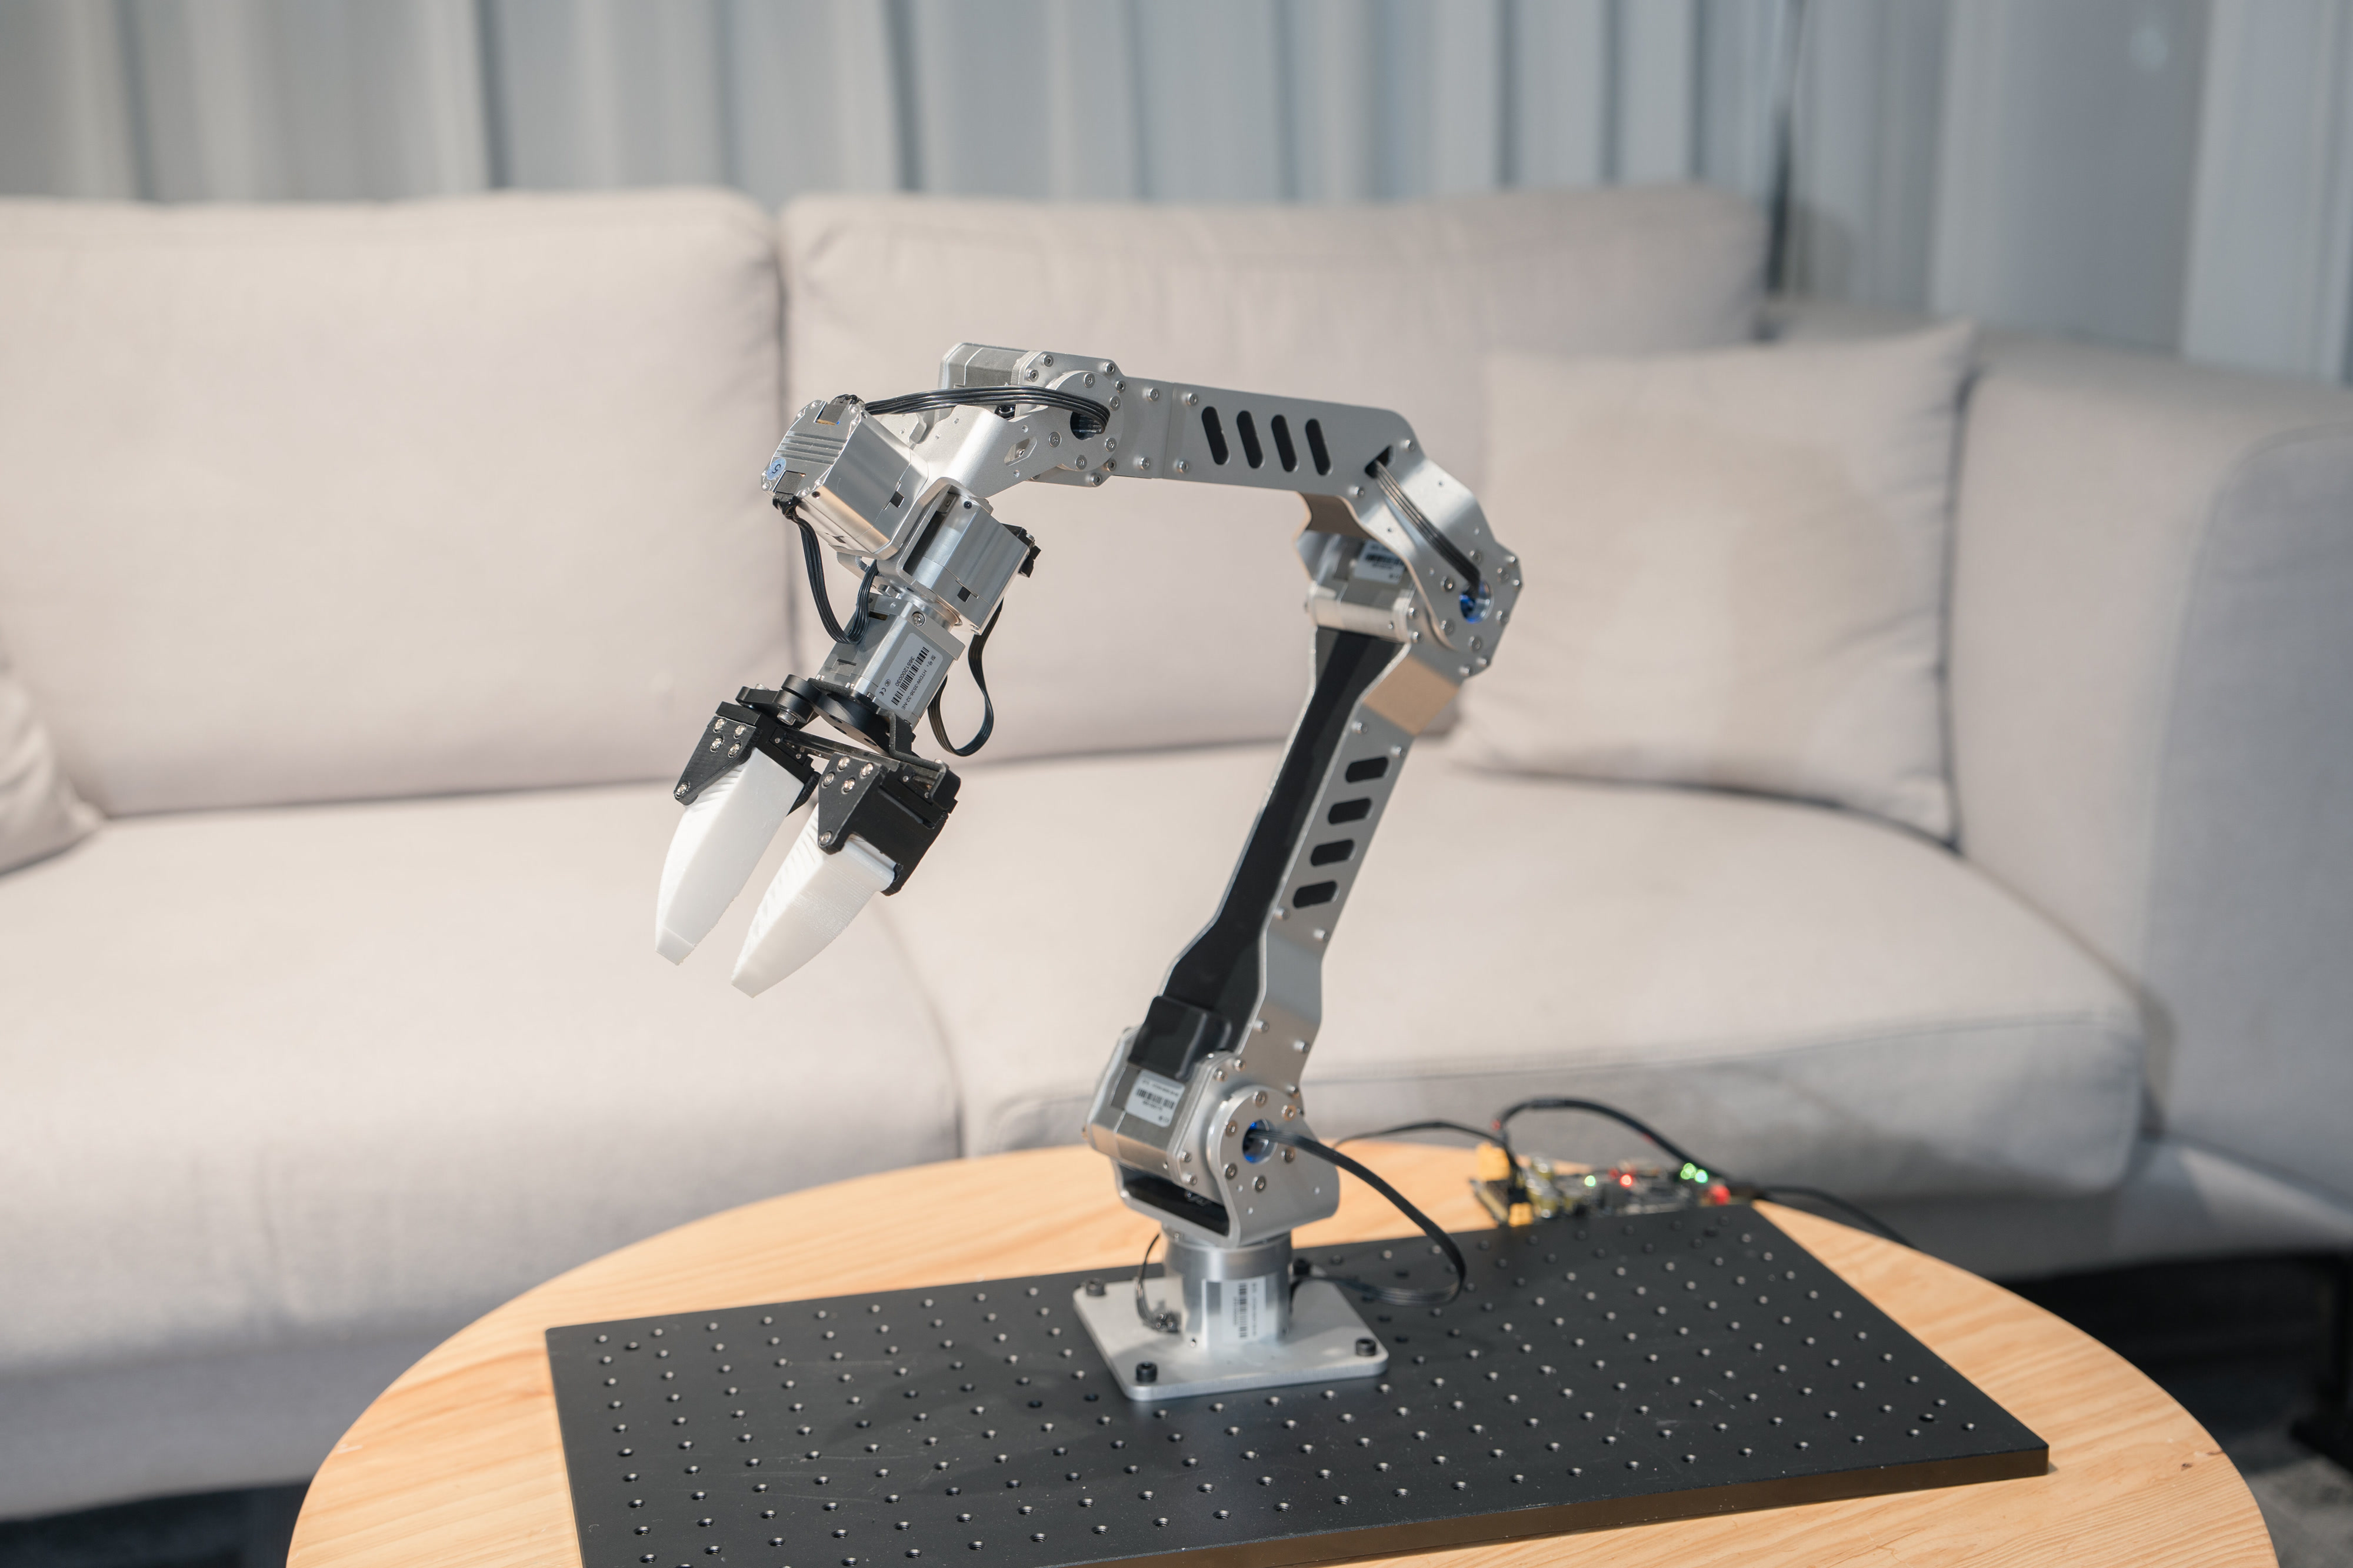
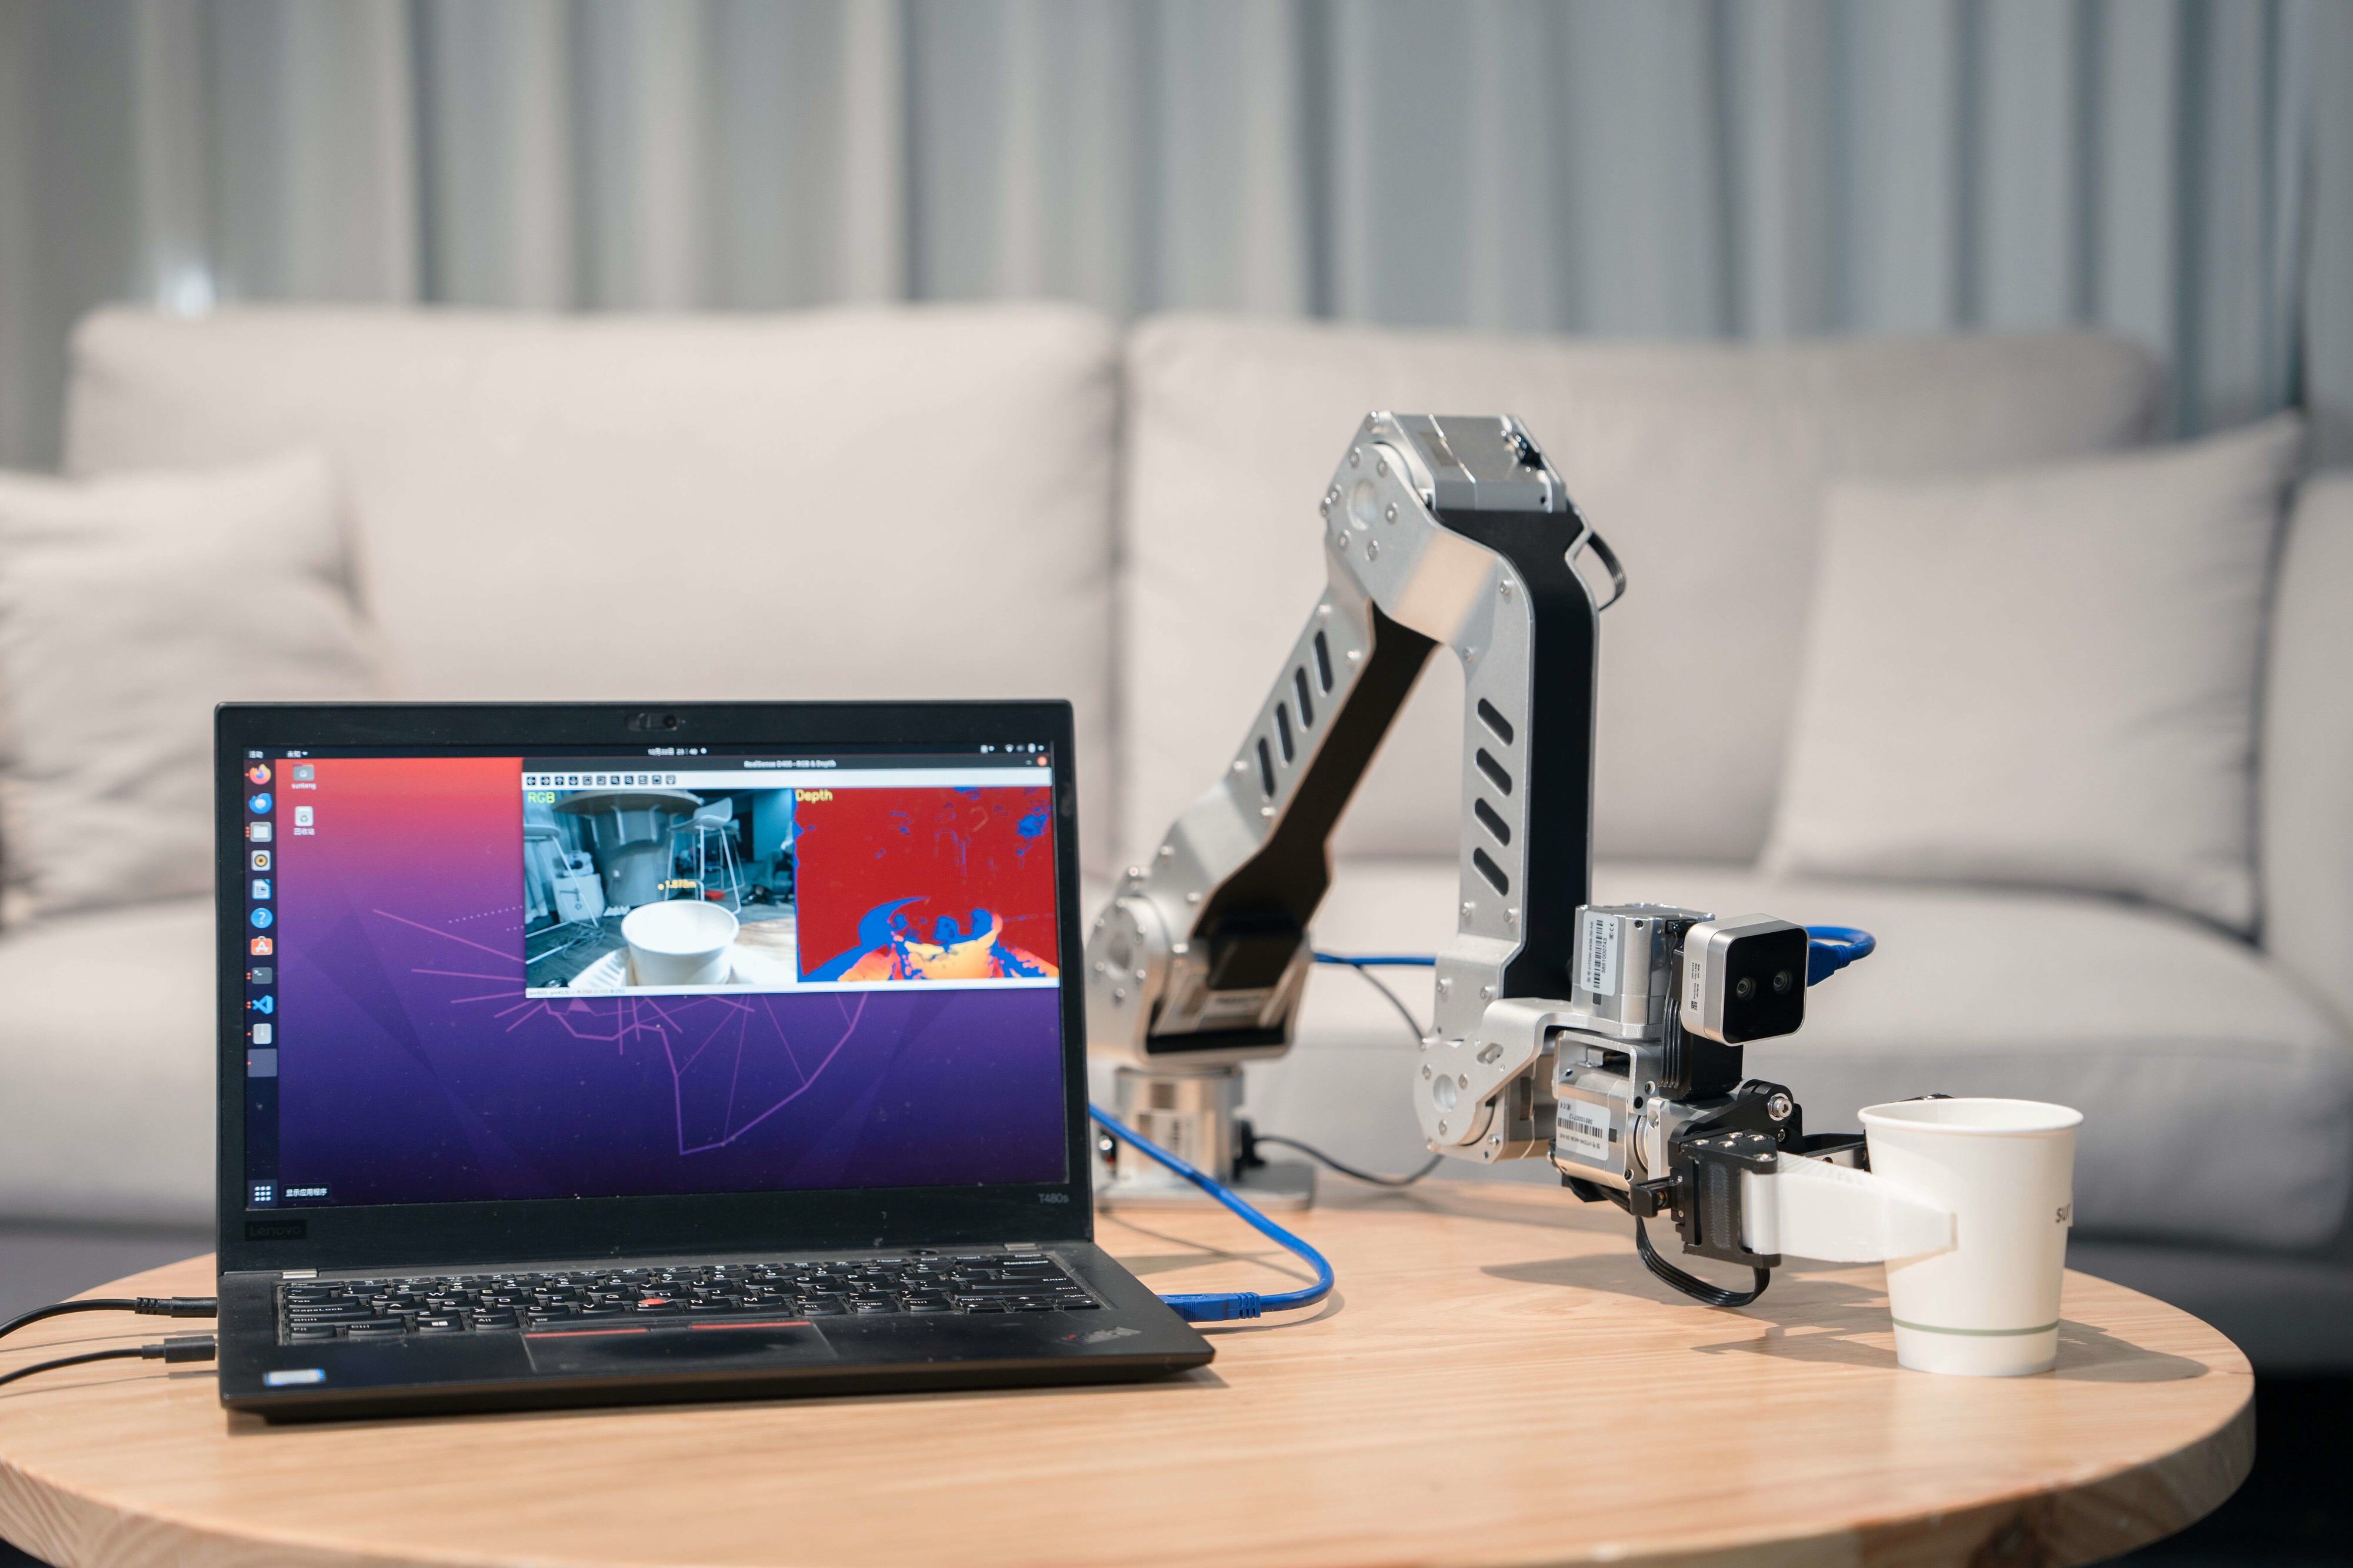
Panthera-HT is an open-source six-axis robotic arm that started as a community project and ended up a product. Its predecessor, the Panthera arm, was designed around DM actuators by wEch1ng and KelvinLauMiau and released openly; the original authors then joined High Torque, which refined it into a commercial maker product while keeping the open-source commitment intact — no restrictions on the project. The engineering goal was to put high-performance joint-motor arms within a student's budget. What that buys is 0.1 mm repeatability, an 860 mm reach that folds to 460 mm, 3.5 kg of static load on a 4.35 kg aluminium-alloy body, and 36 Nm of peak joint torque over CAN-FD. The end effector moves at up to 0.8 m/s. It is built for developers rather than integrators: ROS 2 and LeRobot compatible, C++ and Python, URDF models and simulation support included, and a browser-based model viewer for posing the joints.
FEATURES
- 0.1 mm repeatability from motion-control algorithms and high-precision sensing
- 860 mm extended reach folding to 460 mm
- 3.5 kg maximum static load on a 4.35 kg aluminium-alloy body
- 36 Nm peak joint torque over CAN-FD
- 0.8 m/s maximum end-effector speed
- fully open source with no project restrictions, continuing the community Panthera arm
- ROS 2 and LeRobot compatible with C++ and Python support
- URDF models and simulation support included
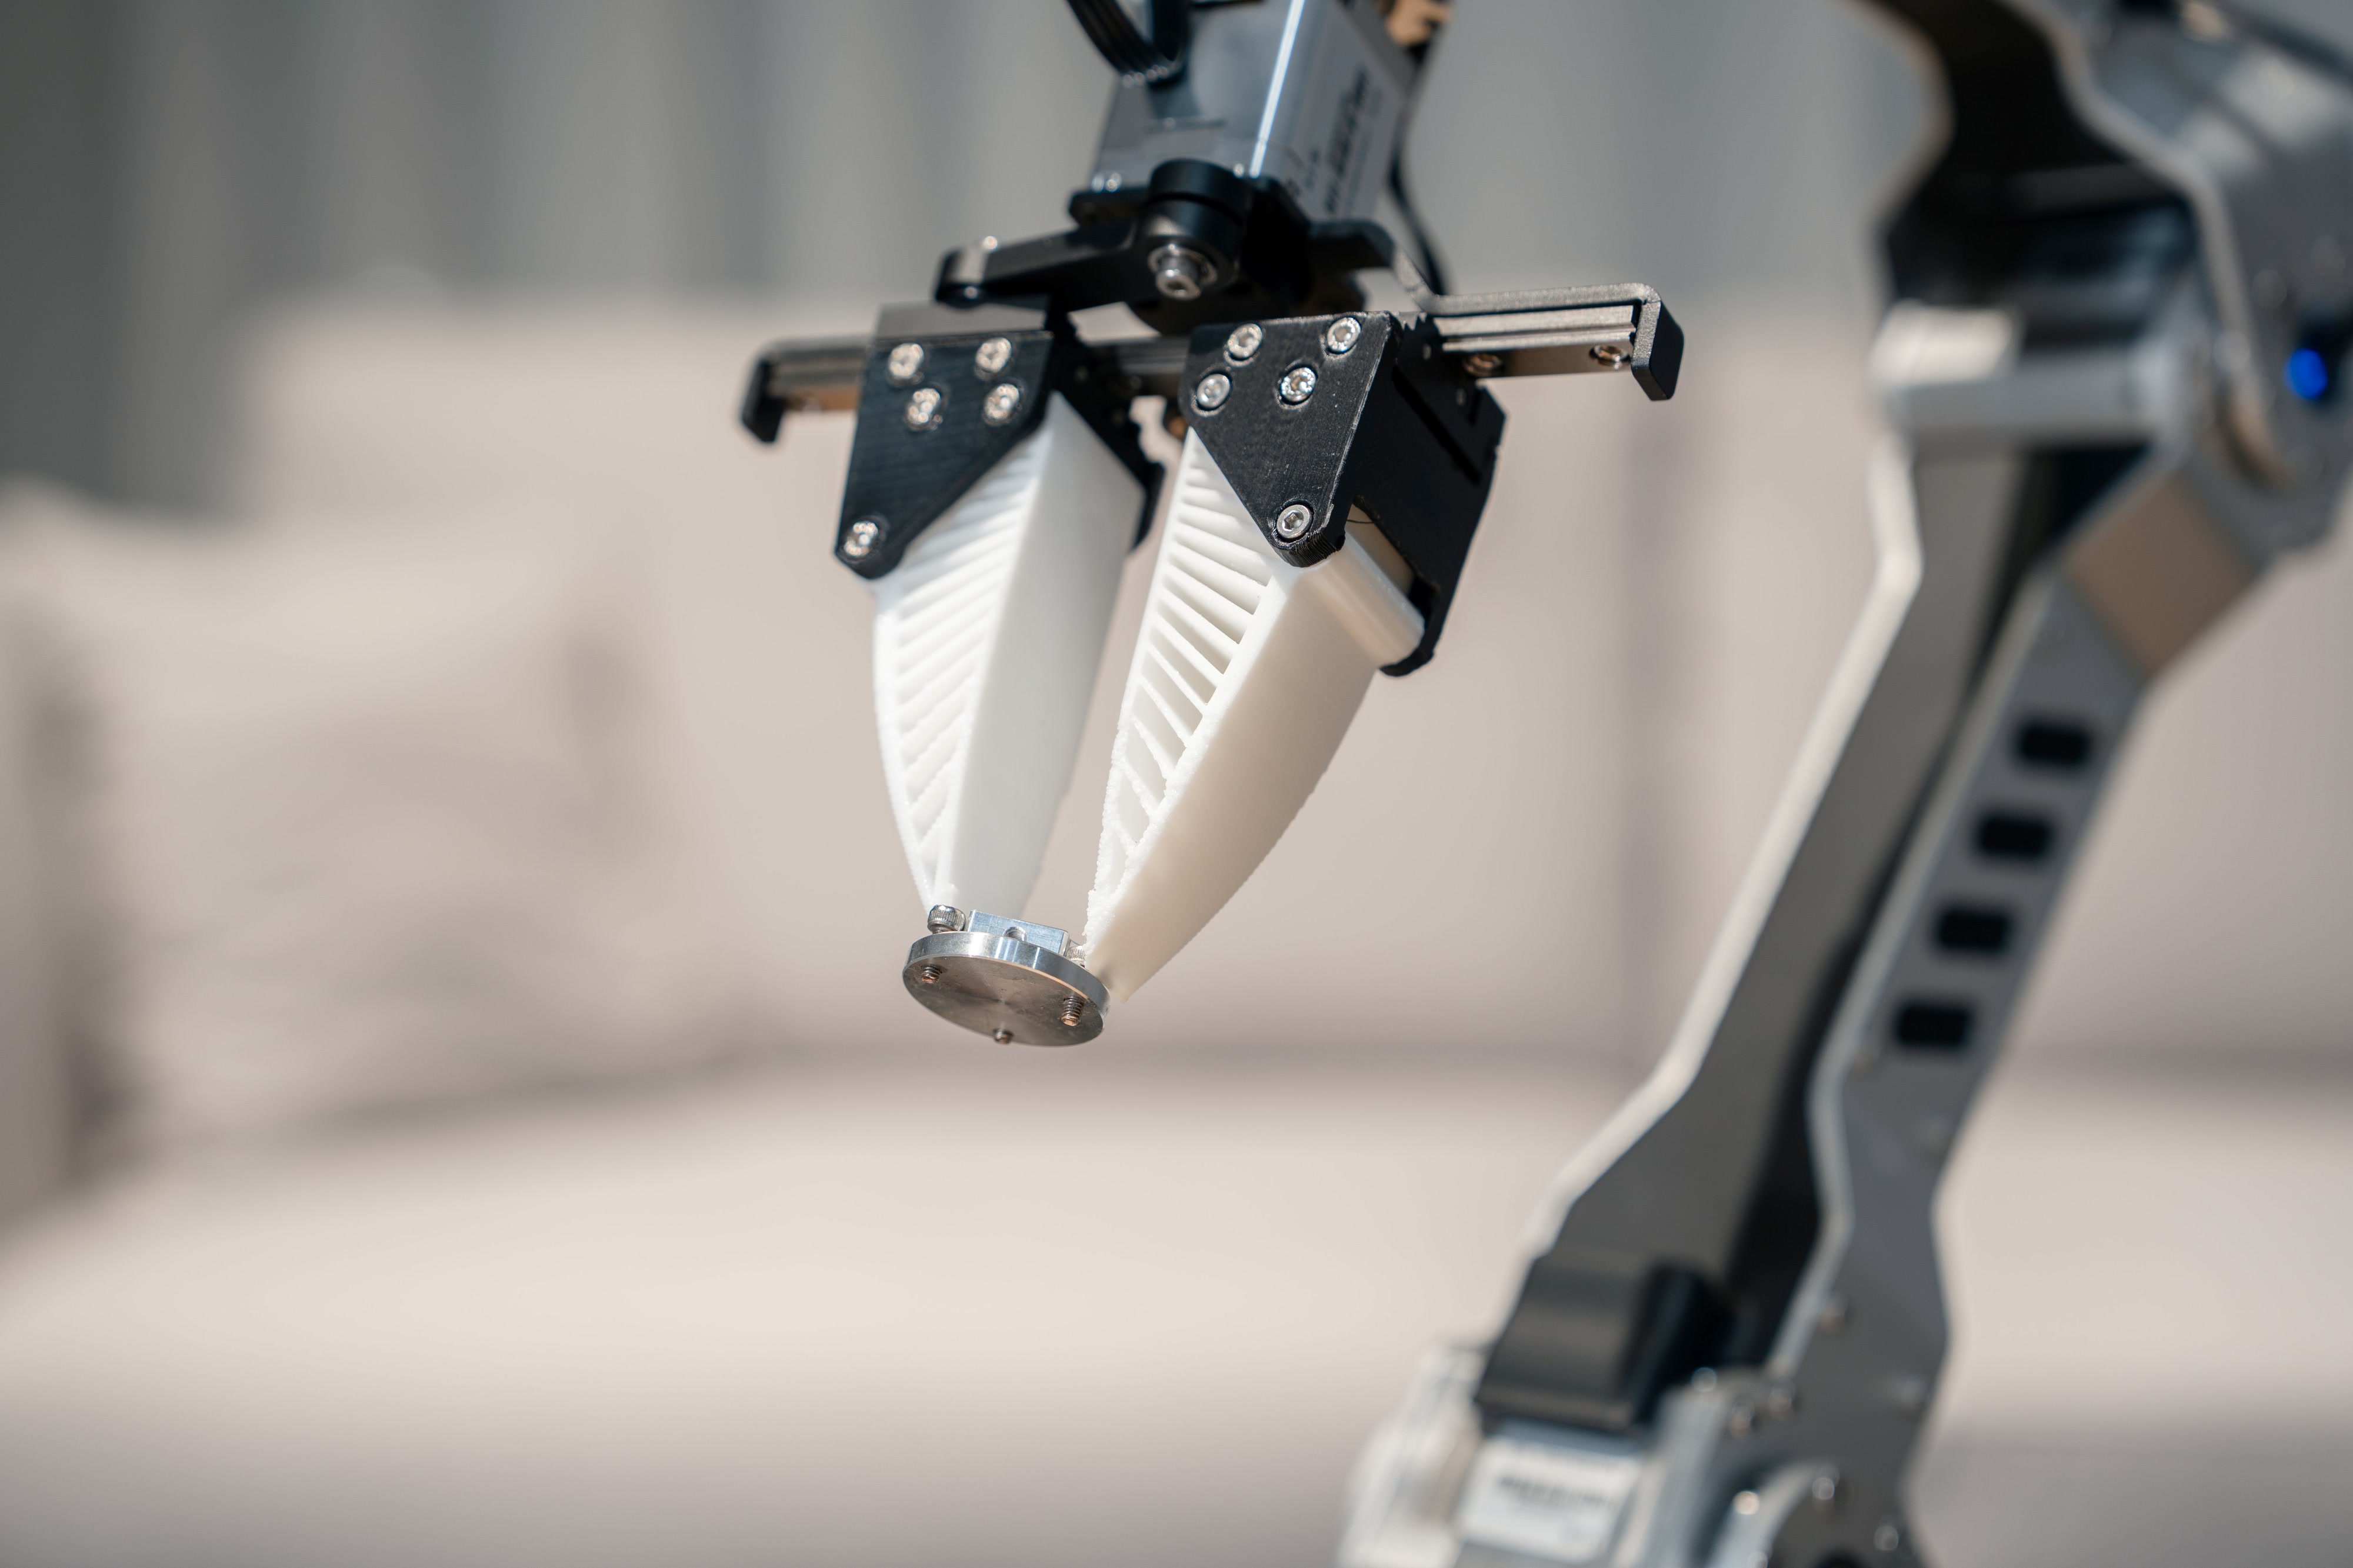
- 1-DoF gripper and high-performance low-level controller
- low-level control SDK with open-source motion-control algorithms
- built from HTDW-3532, 4438, 5036 and 6036 joint modules.
TECHNICAL SPECIFICATIONS
Verified| Physical | |
| Weight | 4.35 kg |
|---|---|
| Dimensions | H 860 mm |
| Payload | 3.5 kg |
| Reach | 860 mm |
| Repeatability | ±0.1 mm |
| Mobility | |
| Movement Type | Stationary |
| Degrees of Freedom | 6 |
| Speed | 2.88 km/h |
| Manipulation | High |
| Actuators | 6 joints using HTDW-6036-02-DNE, HTDW-5036-02-CNE, HTDW-5036-02-DNE, HTDW-4438-30-NE and HTDW-3532-02-DNE modules; joint ranges ±180°, 0-200°, 0-230°, ±90°, ±90° and ±180°; 1-DoF gripper; 860 mm standing height folding to 460 mm |
| Sensing & Compute | |
| Sensors | joint position sensing on all six axes |
| Connectivity | CAN FD |
| Software / AI | Low-level control SDK with open-source motion-control algorithms; ROS 2 and LeRobot compatible; C++ and Python; URDF models and simulation support |
Images
 martti
 martti
 martti
 martti
 martti
Image Contributions
Videos
ROBOT FORUMS
Loading forums...
RATINGS
FREQUENTLY ASKED QUESTIONS
What is the Panthera-HT?
Panthera-HT is an open-source six-axis robotic arm that started as a community project and ended up a product. Its predecessor, the Panthera arm, was designed around DM actuators by wEch1ng and KelvinLauMiau and released openly; the original authors then joined High Torque, which refined it into a commercial maker prod…
Who makes the Panthera-HT?
The Panthera-HT is made by High Torque Technology, a robotics company based in China.
How much does the Panthera-HT cost?
The Panthera-HT is priced at around $1,799.
What is the Panthera-HT used for?
The Panthera-HT is designed for pick-and-place, research, robotics education, and embodied-ai research. It is used in research and education settings.
What is the payload capacity of the Panthera-HT?
The Panthera-HT has a payload capacity of 3.5 kg and a reach of 860 mm.
How much does the Panthera-HT weigh?
The Panthera-HT weighs 4.35 kg.
How fast is the Panthera-HT?
The Panthera-HT can move at speeds of up to 2.88 km/h.
How many degrees of freedom does the Panthera-HT have?
The Panthera-HT has 6 degrees of freedom.
COMPARE WITH SIMILAR ROBOTS
See how this robot stacks up against its closest alternatives
- Panthera-HT vs AUBO-i5
- Panthera-HT vs AUBO-i5L
- Panthera-HT vs CRB 15000-5/0.95
- Panthera-HT vs Yu 5 Industrial
- Panthera-HT vs AUBO-i3