DESCRIPTION
GEFIER R1 is an Educational-Robots from AutoMind Dynamics. It is built for Development, Mapping, Navigation. Key figures: 240 min runtime, 5 kg payload.
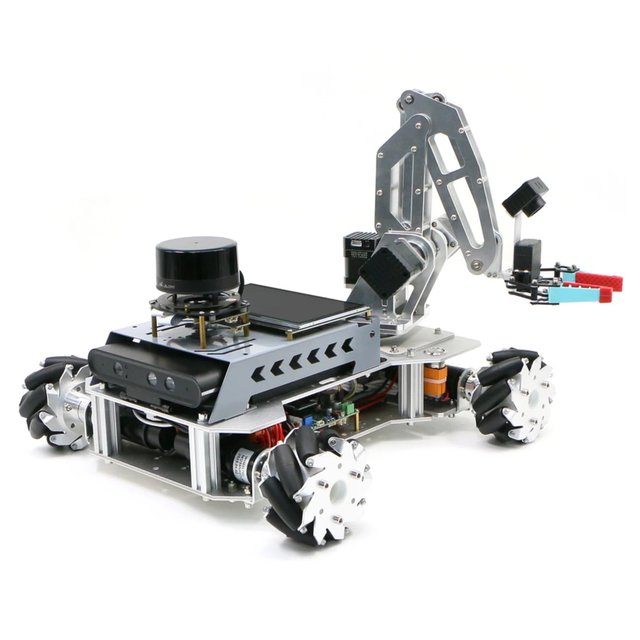
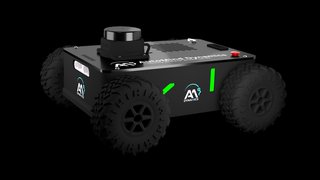
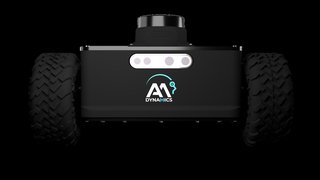
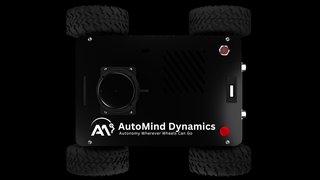
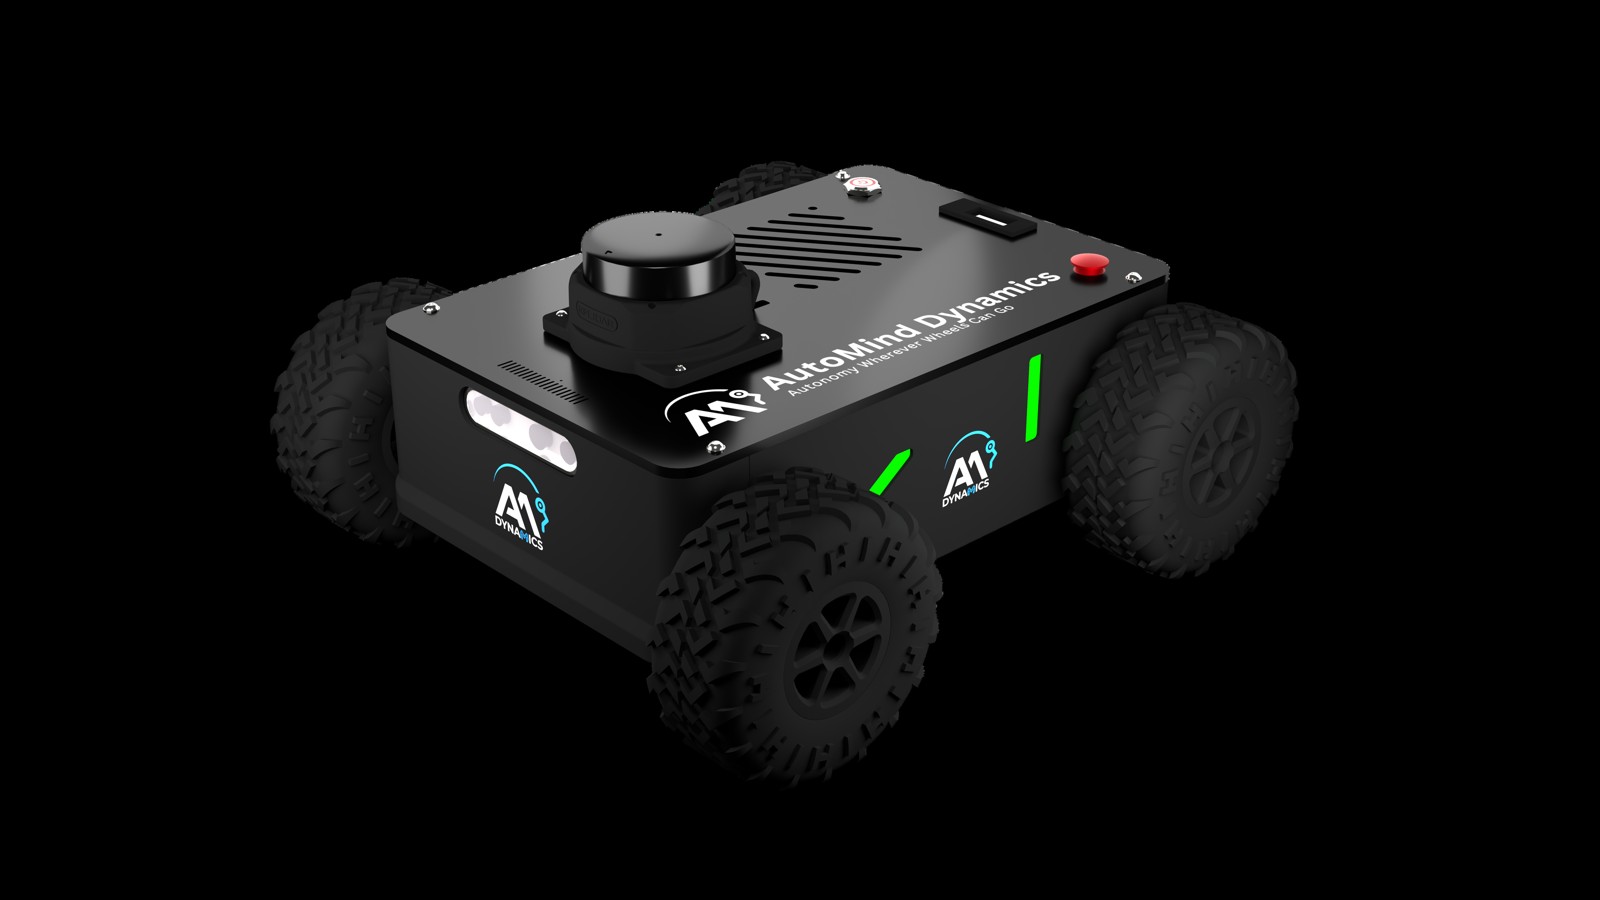
GEFIER R1 is a compact four-wheeled autonomous ground robot that AutoMind Dynamics sells as a ready-to-use platform for robotics research and teaching. It is meant to let students and research teams skip hardware bring-up and start work on mapping, perception, navigation and control from the first day. The rover ships with ROS 2 (Humble or Jazzy) and a fully configured Nav2 stack covering mapping, localisation, path planning, trajectory tracking and obstacle avoidance. It runs on an NVIDIA Jetson Orin Nano or Orin NX module and supports stereo, depth and monocular cameras, 2D and 3D LiDAR, radar and RTK-GNSS add-ons, with standard extrusion and M4/M5 mounting points and 72 W of power for custom sensors. Simulation support covers Isaac Sim, Gazebo, Webots, PyBullet and MATLAB. The brochure gives a 5 kg payload, a top speed of 1.36 m/s (4.9 km/h) and a 3S 15 Ah lithium-ion battery that lasts about 4 hours in performance mode and 6 hours in basic use. The body measures about 390 x 348 x 190 mm and the robot can also carry an SO-ARM100/101 manipulator.
FEATURES
- Compact four-wheel autonomous ground robot for research and academia
- Maximum payload 5 kg (11 lb)
- Maximum speed 1.36 m/s (4.9 km/h)
- Runtime about 4 h (performance) / 6 h (basic use)
- Battery 3S 15 Ah Li-ion with integrated BMS (cell balancing, state of charge, thermal limits)
- Dimensions 390 x 348 x 190 mm (brochure)
- spec sheet gives 385 x 344 x 188 mm
- Compute: NVIDIA Jetson Orin Nano / Orin NX (brochure also lists Orin Nano Super, Orin NX 8/16 GB)
- ROS 2 Humble / Jazzy pre-installed with a fully configured Nav2 stack
- Packages for obstacle avoidance, mapping, localisation, trajectory tracking and path planning
- Odometry accuracy 95-97%
- odometry frequency 30-50 Hz
- Feedback topics: state of charge, current, voltage, wheel odometry, IMU, fused odometry, wheel ticks
- Integrated 6/9-axis IMU
- supports external GNSS / RTK-GNSS
- Supports 2D/3D LiDAR (Livox, Ouster, Velodyne, RPLIDAR, YDLIDAR) and stereo/depth cameras (ZED, Intel RealSense, OAK-D)
- mmWave radar support
- Wi-Fi 5, Bluetooth LE, 1x Ethernet, 3x USB 3.0, USB-C debug port, HDMI
- 12 V / 72 W power port for custom sensors and equipment
- Standard extrusion and M4/M5 mounting points
- motion-capture marker ready
- Manipulator option: SO-ARM100/101
- Simulation support: Isaac Sim, Gazebo, Webots, PyBullet, MATLAB
- Teleoperation via push-button
- optional dashboard UI for live telemetry
- Surge, over-voltage and over-charge protection
- motor over-current monitoring and lock-out
- Physical emergency stop
- multi-state status LEDs
TECHNICAL SPECIFICATIONS
Verified| Physical | |
| Dimensions | L 390 mm × W 348 mm × H 190 mm |
|---|---|
| Payload | 5 kg |
| Mobility | |
| Movement Type | Wheeled |
| Speed | 4.9 km/h |
| Environment | Indoor labs; the spec sheet labels it an indoor UGV, while the product page also cites all-terrain and GPS-denied outdoor use |
| Power | |
| Battery Life | 240 min |
| Sensing & Compute | |
| Sensors | 6/9-axis IMU, Wheel encoders, Supports 2D/3D LiDAR, Supports stereo and depth cameras, Supports mmWave radar, Supports RTK-GNSS |
| Connectivity | Wi-Fi 5, Bluetooth LE, Ethernet, USB 3.0, USB-C, HDMI |
| Software / AI | ROS 2 Humble / Jazzy with pre-configured Nav2 stack |
ROBOT FORUMS
Loading forums...
TECHNICAL SPECIFICATIONS
Verified| Physical | |
| Dimensions | L 390 mm × W 348 mm × H 190 mm |
|---|---|
| Payload | 5 kg |
| Mobility | |
| Movement Type | Wheeled |
| Speed | 4.9 km/h |
| Environment | Indoor labs; the spec sheet labels it an indoor UGV, while the product page also cites all-terrain and GPS-denied outdoor use |
| Power | |
| Battery Life | 240 min |
| Sensing & Compute | |
| Sensors | 6/9-axis IMU, Wheel encoders, Supports 2D/3D LiDAR, Supports stereo and depth cameras, Supports mmWave radar, Supports RTK-GNSS |
| Connectivity | Wi-Fi 5, Bluetooth LE, Ethernet, USB 3.0, USB-C, HDMI |
| Software / AI | ROS 2 Humble / Jazzy with pre-configured Nav2 stack |
Images
 martti
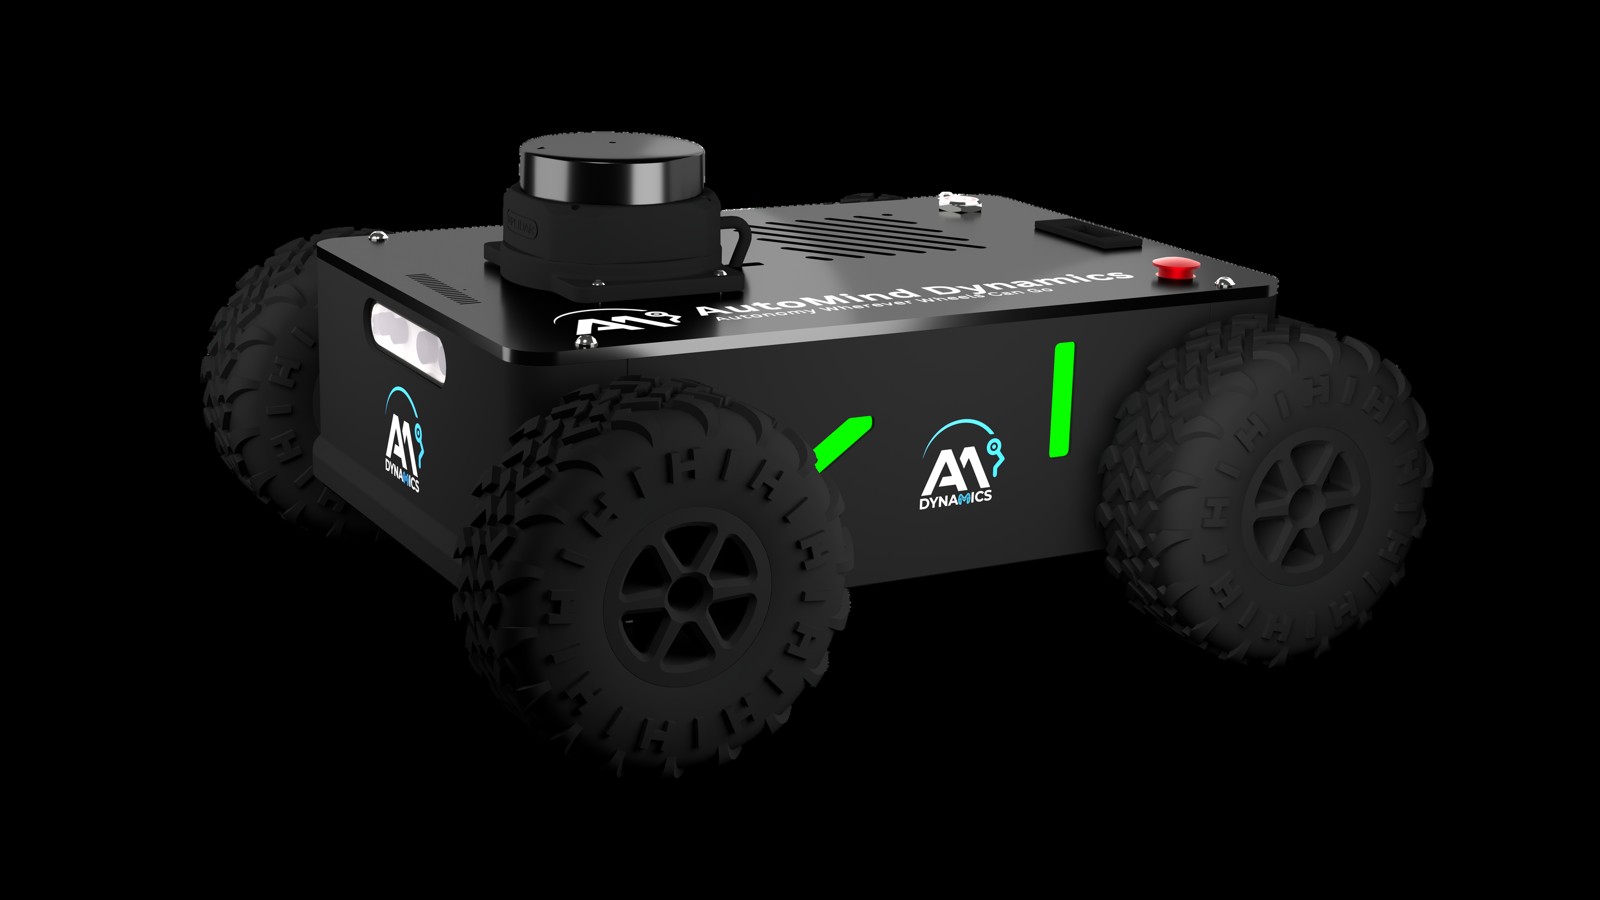 martti
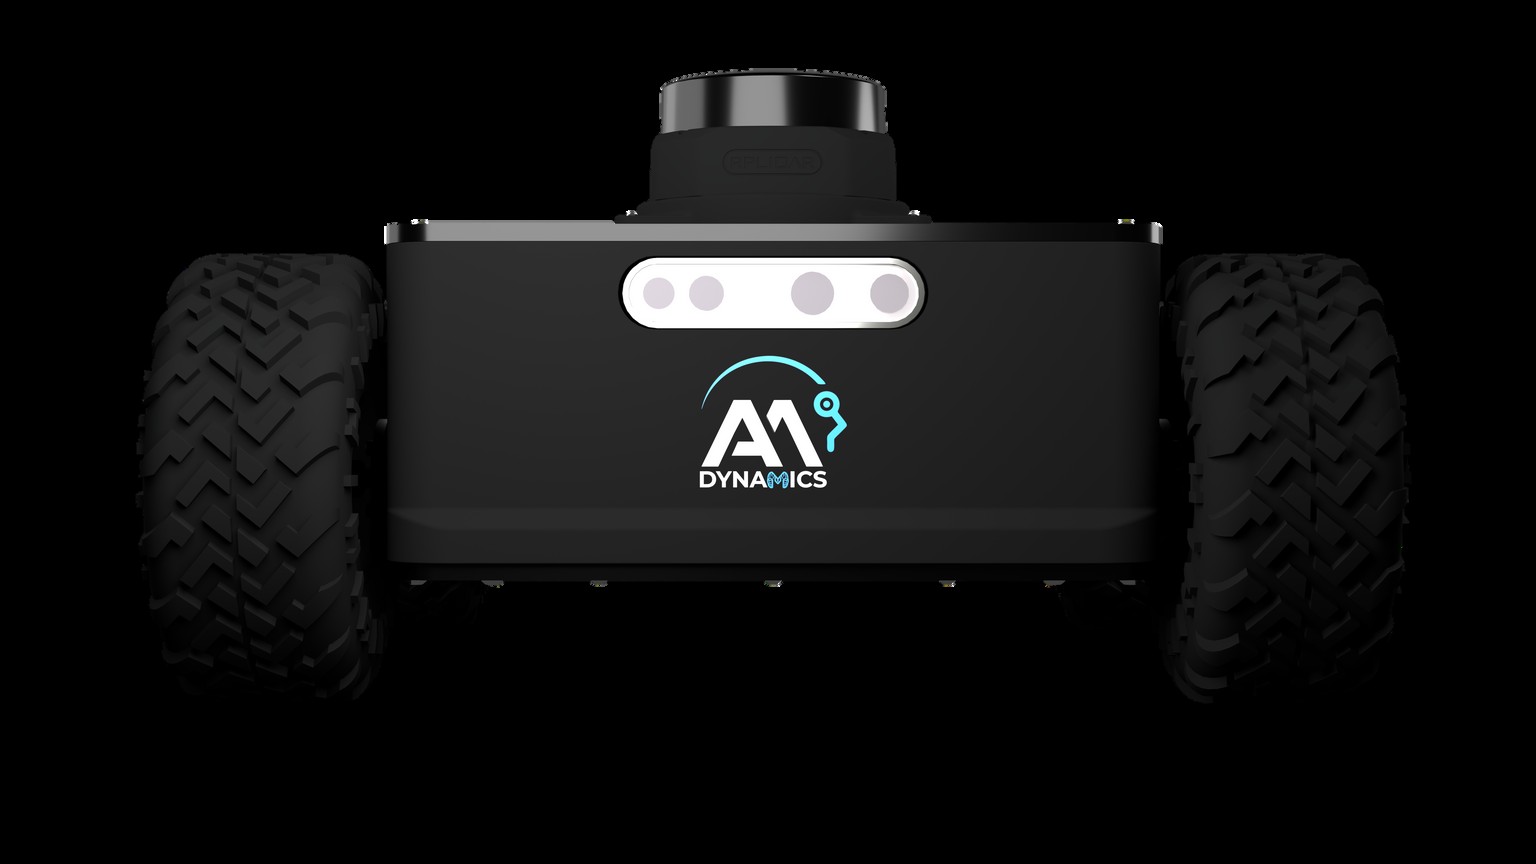 martti
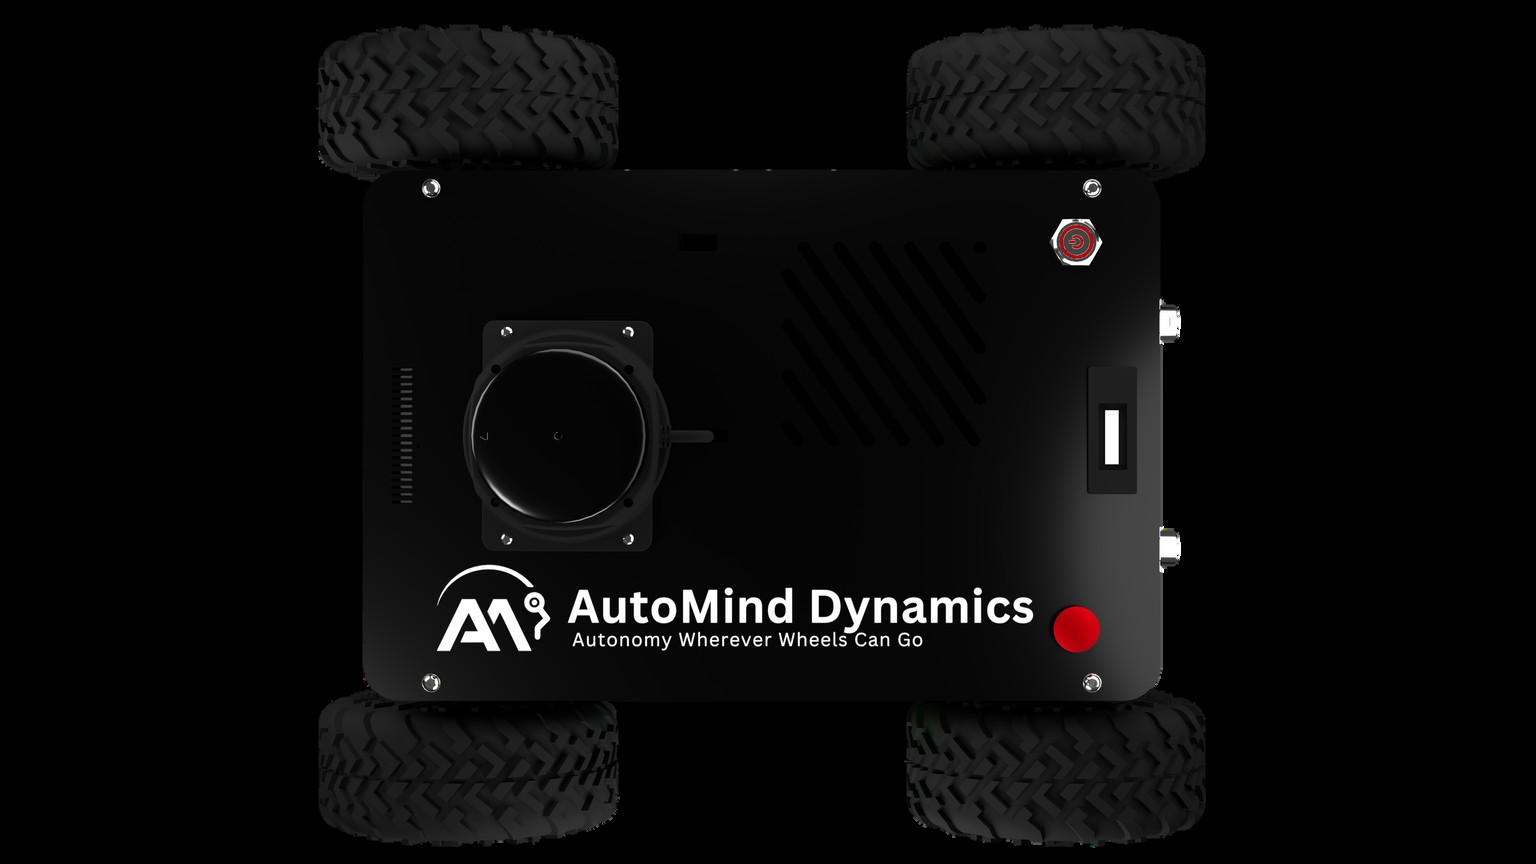 martti
Image Contributions
Videos
ROBOT FORUMS
Loading forums...
RATINGS
FREQUENTLY ASKED QUESTIONS
What is the GEFIER R1?
GEFIER R1 is a compact four-wheeled autonomous ground robot that AutoMind Dynamics sells as a ready-to-use platform for robotics research and teaching. It is meant to let students and research teams skip hardware bring-up and start work on mapping, perception, navigation and control from the first day.
Who makes the GEFIER R1?
The GEFIER R1 is made by AutoMind Dynamics, a robotics company based in India.
How much does the GEFIER R1 cost?
AutoMind Dynamics has not publicly announced pricing for the GEFIER R1. You can enquire through RobotAIGeek for current pricing.
What is the GEFIER R1 used for?
The GEFIER R1 is designed for development, mapping, navigation, and research. It is used in research and education settings.
What is the payload capacity of the GEFIER R1?
The GEFIER R1 has a payload capacity of 5 kg.
How fast is the GEFIER R1?
The GEFIER R1 can move at speeds of up to 4.9 km/h.
What is the battery life of the GEFIER R1?
The GEFIER R1 runs for about 240 minutes on a charge.
COMPARE WITH SIMILAR ROBOTS
See how this robot stacks up against its closest alternatives
- GEFIER R1 vs Mecabot 2
- GEFIER R1 vs Mecabot Pro
- GEFIER R1 vs Mecabot Plus
- GEFIER R1 vs Mecabot X
- GEFIER R1 vs Rosbot Pro