
Shanghai's RoboParty Raises Nearly RMB 500 Million for Open-Source Humanoid Robots
Shanghai humanoid robotics startup RoboParty has closed nearly RMB 500 million (about US$69 million) across two funding rounds, with battery giant CATL leading the latest tranche, as the company pushes its open-source bipedal robot design toward mass production.

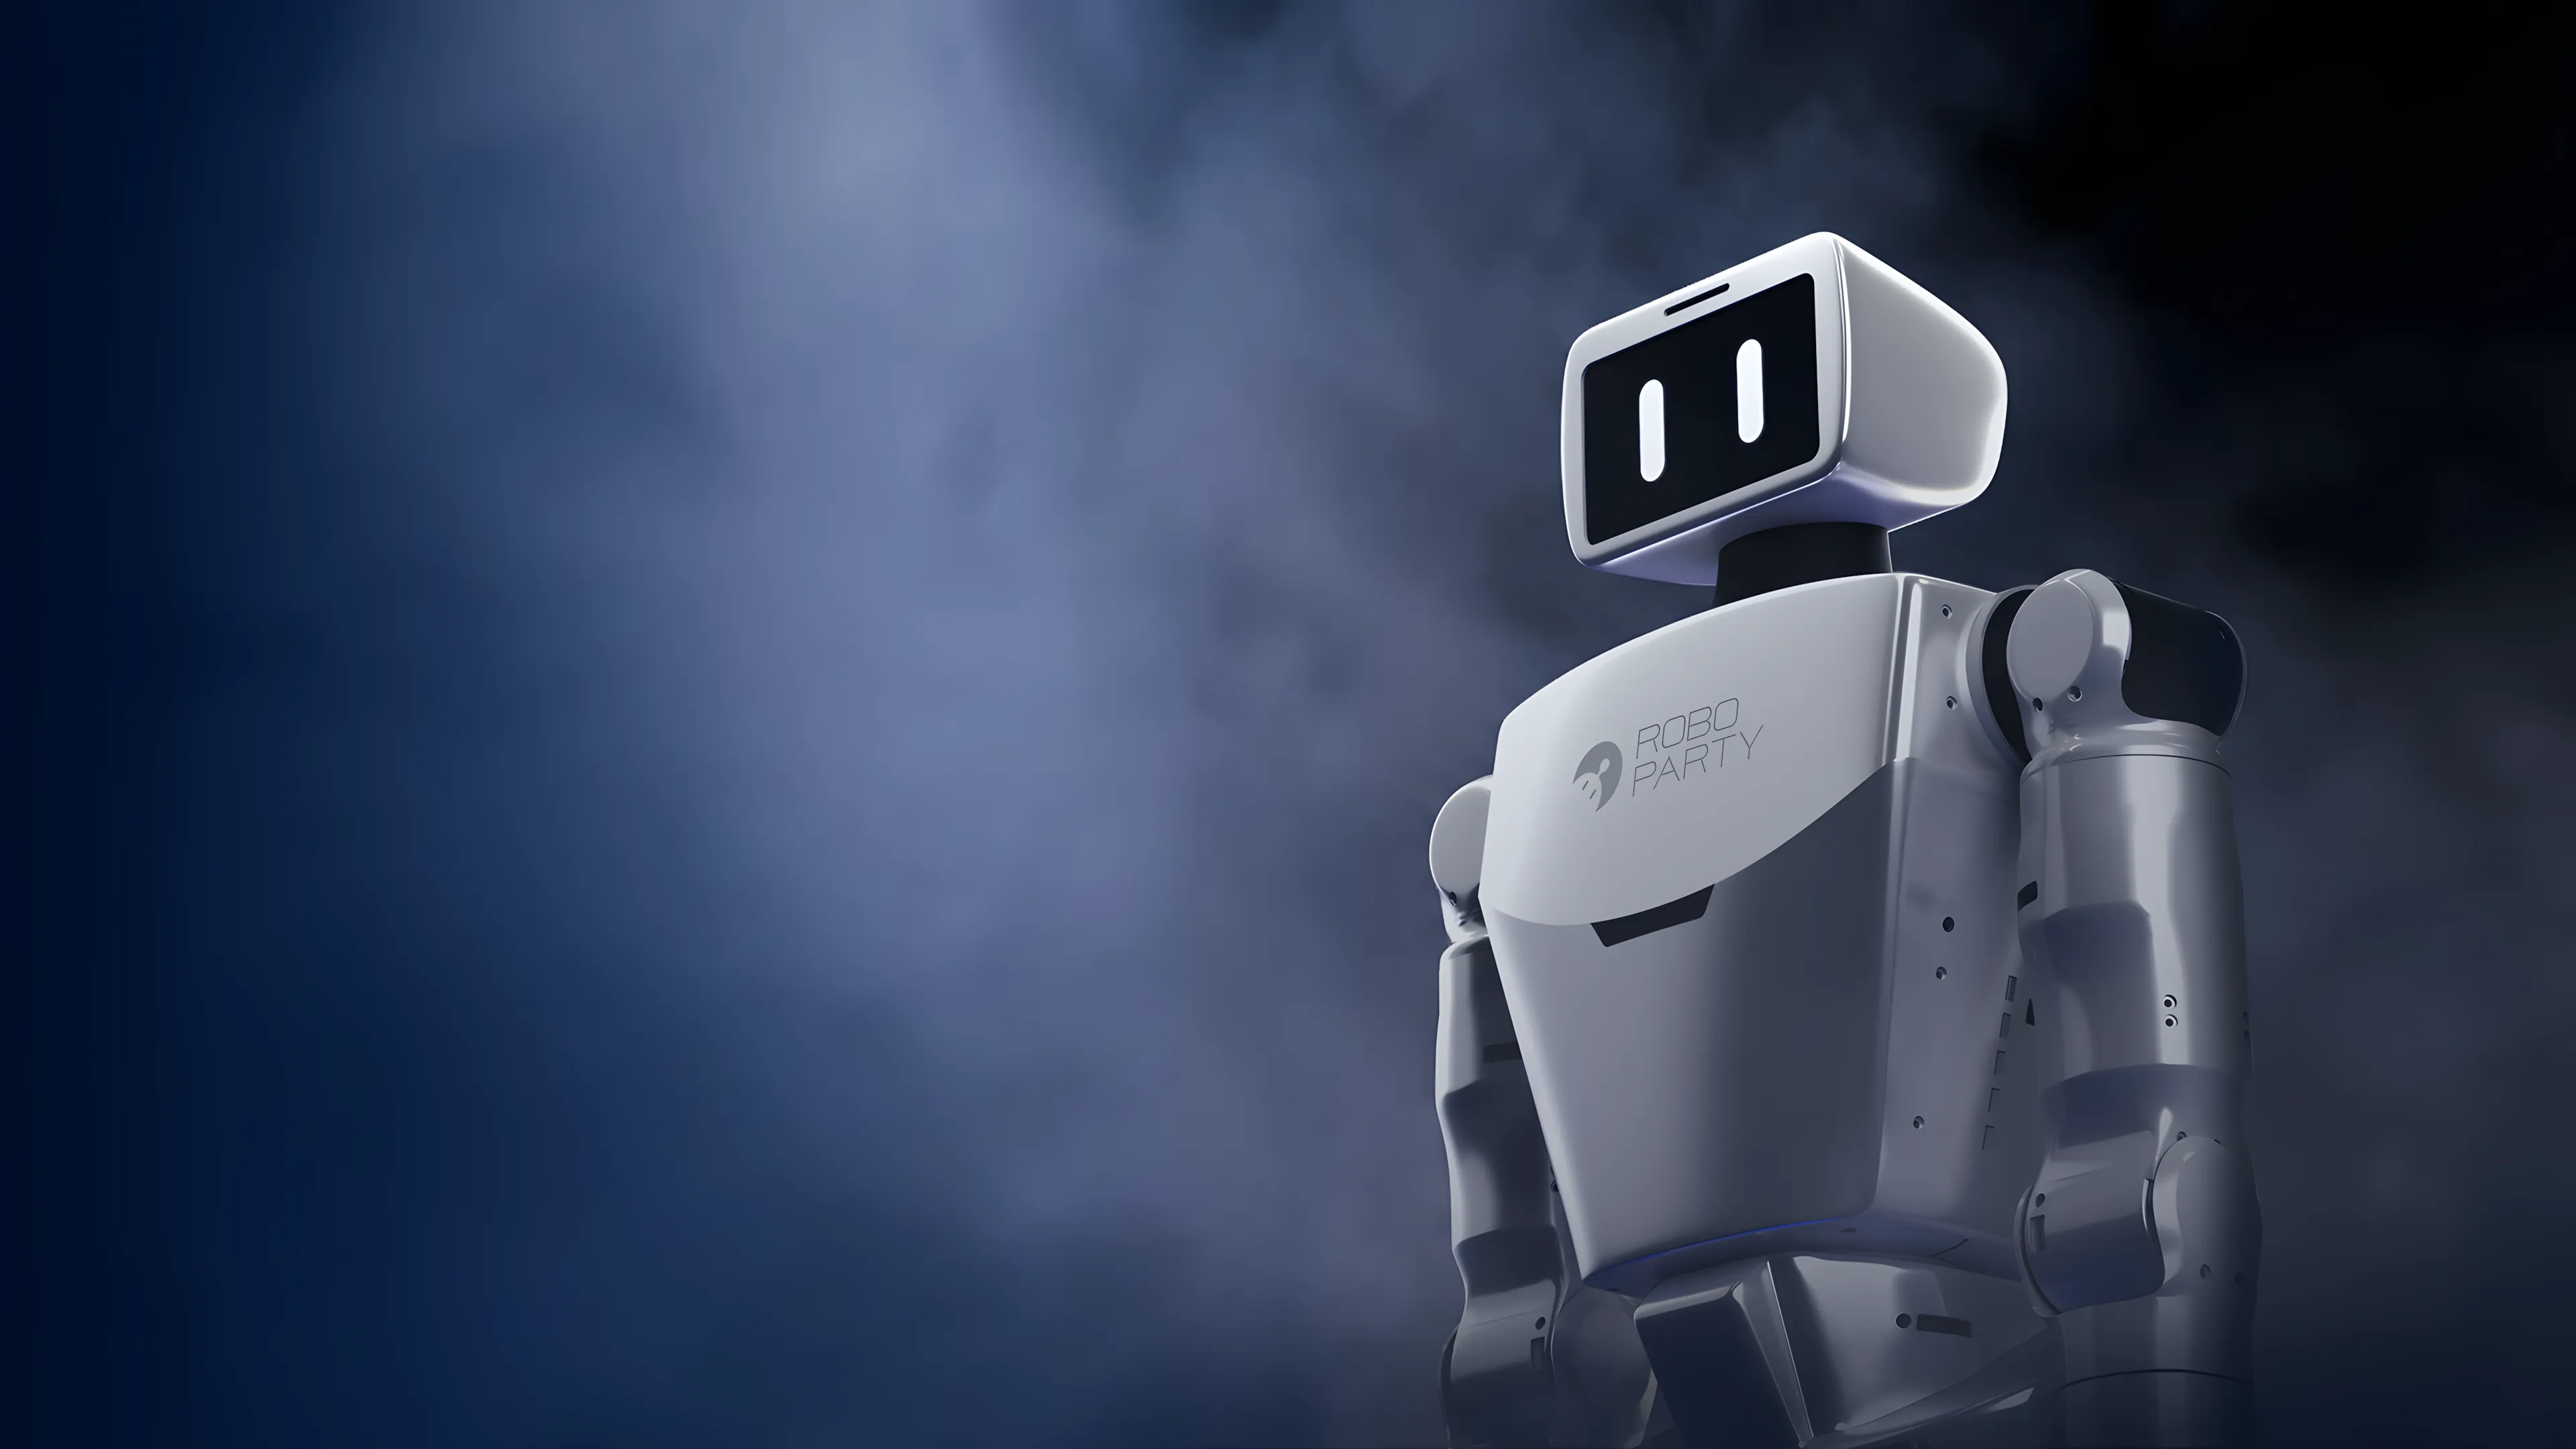
Shanghai-based humanoid robotics startup RoboParty has raised nearly RMB 500 million (approximately US$69 million) across two financing rounds, with Contemporary Amperex Technology Co., Limited, the world's largest electric vehicle battery maker known by its acronym CATL, stepping in as the sole investor in the newer round. The financing marks one of the clearest signs yet that China's industrial supply chain giants are placing direct bets on open-source humanoid hardware rather than waiting to buy finished robots from established players.
That strategy, publishing hardware and software rather than guarding it as most robotics companies do, has become the core of RoboParty's pitch to investors and to the wider robotics developer community, and it is what convinced CATL to back a company several steps removed from its own core battery business.
From Harbin Classrooms to a Growing Cap Table
Founded in 2025 and headquartered in Shanghai, RoboParty's market niche is supplying the open hardware and software reference layer that other manufacturers, research labs, and component suppliers can build on, rather than competing head-on for finished-robot sales. Its core engineering team comes from Harbin Institute of Technology, supplemented by researchers from Tsinghua University's Yao Class and Peking University's AI program, a talent pool it is now expanding through a dedicated RoboParty Lab.
A Funding Sprint Built on Two Rounds
The nearly RMB 500 million total is split between an Angel++ round and a Pre-A round, completed within roughly six months of each other. Existing backers Shunwei Capital, Matrix Partners China, Xiaomi's strategic investment arm and SenseTime's Guoxiang Fund increased their positions in the Angel++ round, while CATL entered as the exclusive investor in the Pre-A round. GP Capital served as the exclusive financial advisor on the deal. The Pre-A round alone followed roughly six months after RoboParty's first institutional check, a fast follow-on that is unusual for a hardware startup still short of shipping robots at meaningful volume.
The involvement of repeat investors matters here. When the same backers add money in consecutive rounds rather than new names replacing them, it typically signals that a startup is hitting internal milestones investors set during earlier due diligence, rather than simply riding sector-wide enthusiasm. CATL's arrival adds a different kind of signal. The battery maker's core business sits far from humanoid robotics, but it has been expanding into energy storage systems, industrial automation and now, with this investment, direct exposure to the humanoid supply chain. For a company whose products depend on manufacturing scale and component standardization, backing an open-source hardware platform is a way to influence and benefit from how that standardization unfolds.
Open Hardware as a Business Model, Not Just a Slogan
Most humanoid robotics companies treat their mechanical designs, actuator specifications and control software as trade secrets. RoboParty has taken the opposite approach with its Roboto_Original bipedal humanoid blueprint, publishing the hardware files, bill of materials and manufacturing documentation openly. The project has drawn close to 2,000 stars on its code repository and built a developer community the company puts at more than 5,000 people, along with several awards from embodied AI industry bodies.
The commercial logic behind giving away a design is straightforward once the ecosystem effect kicks in. A wider base of developers building on the same hardware reference creates a larger pool of contributors improving the platform for free, a faster path to industry-standard components, and a sales funnel for RoboParty's own finished units and modules. The company says it has already delivered its first batch of several hundred robots to customers, moving the project from a research curiosity into what it describes as a genuine commercial closed loop, meaning revenue now flows back from real deliveries rather than only from grants or investor cash.
With the new funding, RoboParty plans to expand beyond the humanoid frame itself into the software and data layer. The company is building out an internal research effort it calls the BFM Off-policy Tracker, a system aimed at improving how the robot's behavior models are trained and evaluated, alongside a Humanoid Foundation Model (HFM) intended to give its robots more general-purpose skills rather than task-specific programming. Reinforcement learning (RL), the machine learning approach in which a robot improves its behavior through repeated trial and reward feedback, sits at the center of both efforts.
Betting on Standardization Before the Market Consolidates
China's humanoid robotics sector has expanded quickly over the past year, with dozens of companies now building bipedal platforms for factories, logistics and consumer settings. Most of that competition has focused on which company can build the most capable finished robot. RoboParty is making a different wager: that whoever controls the reference design other companies build on top of will hold more durable leverage than whoever ships the single best robot in any given quarter.
That bet only pays off if the open-source ecosystem keeps growing faster than closed alternatives. Software development kits (SDKs), reinforcement learning training pipelines and deployment frameworks published under the Roboto_Original umbrella are designed to lower the cost of entry for smaller teams and university labs that cannot afford to build a humanoid platform from scratch. If enough of those teams standardize on RoboParty's components, module suppliers, actuator makers and component-level manufacturers, including ones like CATL with adjacent manufacturing expertise, gain an incentive to support the same standard, reinforcing the platform's position rather than any single robot model.
The risk is that a well-funded competitor could ship a closed but higher-performing platform quickly enough to pull developers away before the open ecosystem reaches critical mass, or that a larger firm could build a rival open standard with more resources behind it.
On the technical side, RoboParty's public repositories give a concrete look at what "open source" means in practice for a humanoid robot rather than just a marketing label. The company publishes a Robot Operating System 2 (ROS 2) deployment framework so outside developers can install and run its control software without building it from scratch, alongside a simulation workspace built on NVIDIA's Isaac Lab platform for training walking and manipulation behavior in simulation before transferring it to physical hardware, a process known in robotics as sim-to-real transfer. The mechanical files, printed circuit board layouts, and full bill of materials for its hardware are published alongside the software, which is what allows university labs and smaller robotics teams to manufacture compatible units rather than only running the code on RoboParty's own robots.
What Standardized Hardware Could Do to Humanoid Economics
Component costs remain the single biggest obstacle to making humanoid robots affordable at scale. Industry estimates commonly cited across the sector put actuators, the motorized joints that let a robot walk and move its arms, at somewhere between 40 percent and 60 percent of a humanoid robot's total bill of materials. When every company designs its own proprietary actuator, joint housing and control board, component suppliers cannot achieve the manufacturing volume needed to bring unit costs down quickly. An open reference design changes that math. If a meaningful share of China's humanoid startups and university labs converge on the same joint specifications and mounting standards that RoboParty publishes, actuator manufacturers can produce larger batches of interchangeable parts rather than small custom runs for each customer, pushing per-unit costs down for the entire ecosystem rather than for one company alone.
This is also where CATL's interest becomes easier to read commercially rather than only strategically. Battery packs and power management are a meaningful share of a humanoid's weight and cost budget, and a company that already manufactures at the gigawatt-hour scale for electric vehicles has an obvious interest in shaping how power delivery is standardized inside a fast-growing robotics category before that standard is set by someone else.
A Crowded Field With Different Playbooks
China now has dozens of companies building bipedal humanoid robots, and RoboParty's open approach sets it apart from most of them rather than putting it in direct head-to-head competition on a single product. Several well-funded Chinese humanoid makers have pursued the opposite path, keeping their mechanical designs, control software and training data closed while competing primarily on the finished robot's specifications, price and deployment speed. RoboParty is instead trying to become the layer underneath those companies, the reference platform that smaller manufacturers, research labs and component suppliers build around, similar in spirit to how open instruction sets and reference boards shaped earlier waves of computing and mobile hardware.
Whether that model works depends less on RoboParty's own robot performance and more on adoption. A reference design only becomes a durable standard if enough independent teams choose to build on it instead of starting their own proprietary stack, and if enough component suppliers find it profitable to manufacture parts that fit it. The first several hundred unit deliveries the company has already made suggest early commercial traction beyond the open-source community alone, and the new funding is explicitly earmarked for turning that early traction into manufacturing scale.
This analysis synthesizes public company statements, financing disclosures, and publicly available market activity as of the publication date.
Disclaimer: This analysis is for informational purposes only and does not constitute investment, financial, or procurement advice. The views expressed are based on public information and industry trends as of the publication date. No vendor is endorsed, and no technology performance is guaranteed.













