설명
Tesollo Delto DG-4F은(는) Tesollo의 End-Effectors입니다. 피킹 용도로 설계되었습니다. 주요 수치: 1.5 kg, 가반 하중 10 kg, 18 자유도.
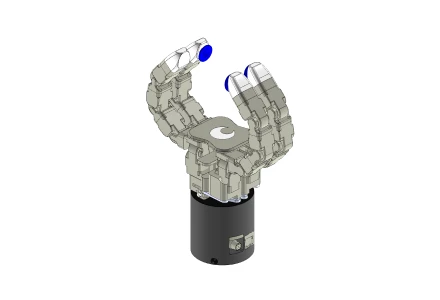
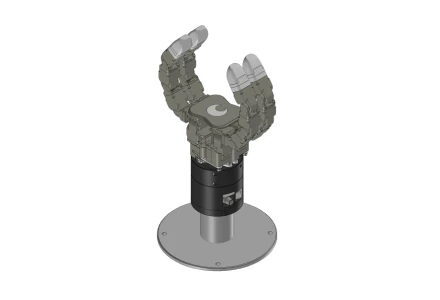
The DG-4F is an 18-DoF four-finger gripper that sits deliberately between a dexterous hand and a conventional industrial gripper. Its four independently controlled multi-joint fingers support a wide range of grasp configurations, and a flexible base-joint structure lets the fingers be arranged left-hand-like, right-hand-like, or squared off into a conventional parallel-gripper stance. That means one end-effector covers grasping strategies that would normally require swapping tools, which is the practical argument for it on a mixed production line. It holds 10 kg rated in an enveloping grasp and 3 kg rated in a pinch, weighs 1,494 g, and runs at 333 Hz over Modbus or Ethernet. Optional fingertip sensing covers 6-axis force/torque, 3-axis force and tactile, with suction-type fingertips available.
주요 기능
- 18 DoF across four independently controlled multi-joint fingers
- Flexible base-joint structure for left-hand, right-hand or gripper-style layouts
- Combines hand-like dexterity with conventional gripper security
- Enveloping payload 10 kg rated, 20 kg maximum
- Pinching payload 3 kg rated, 5 kg maximum
- 1,494 g weight
- 333 Hz control frequency
- Absolute encoders on all joints
- 24 V input, max 10 A
- Modbus (RTU, TCP) and Ethernet (TCP/IP)
- Optional 6-axis F/T, 3-axis force or tactile fingertip sensors
- Optional suction-type fingertip
기술 사양
검증됨| 물리 사양 | |
| 무게 | 1.494 kg |
|---|---|
| 가반하중 | 10 kg |
| 이동성 | |
| 이동 방식 | 고정형 |
| 자유도 | 18 |
| 액추에이터 | Integrated actuator per joint, absolute encoders |
| 센싱 & 컴퓨팅 | |
| 연결성 | Modbus (RTU, TCP), Ethernet (TCP/IP) |
| 소프트웨어 / AI | Delto Gripper Manager and SDK |
로봇 포럼
포럼 불러오는 중...
기술 사양
검증됨| 물리 사양 | |
| 무게 | 1.494 kg |
|---|---|
| 가반하중 | 10 kg |
| 이동성 | |
| 이동 방식 | 고정형 |
| 자유도 | 18 |
| 액추에이터 | Integrated actuator per joint, absolute encoders |
| 센싱 & 컴퓨팅 | |
| 연결성 | Modbus (RTU, TCP), Ethernet (TCP/IP) |
| 소프트웨어 / AI | Delto Gripper Manager and SDK |
이미지
 martti
 martti
 martti
이미지 기여
동영상
로봇 포럼
포럼 불러오는 중...
평가
자주 묻는 질문
What is the Tesollo Delto DG-4F?
The DG-4F is an 18-DoF four-finger gripper that sits deliberately between a dexterous hand and a conventional industrial gripper. Its four independently controlled multi-joint fingers support a wide range of grasp configurations, and a flexible base-joint structure lets the fingers be arranged left-hand-like, right-han…
Who makes the Tesollo Delto DG-4F?
The Tesollo Delto DG-4F is made by Tesollo, a robotics company based in South Korea.
How much does the Tesollo Delto DG-4F cost?
Tesollo has not publicly announced pricing for the Tesollo Delto DG-4F. You can enquire through RobotAIGeek for current pricing.
What is the Tesollo Delto DG-4F used for?
The Tesollo Delto DG-4F is designed for 피킹. It is used in 제조 and robotics research settings.
What is the payload capacity of the Tesollo Delto DG-4F?
The Tesollo Delto DG-4F has a payload capacity of 10 kg.
How much does the Tesollo Delto DG-4F weigh?
The Tesollo Delto DG-4F weighs 1.49 kg.
How many degrees of freedom does the Tesollo Delto DG-4F have?
The Tesollo Delto DG-4F has 18 degrees of freedom.
유사 로봇과 비교
이 로봇이 가장 가까운 대안들과 어떻게 비교되는지 확인하세요
- Tesollo Delto DG-4F vs Tesollo Delto DG-5F-M
- Tesollo Delto DG-4F vs Tesollo Delto DG-5F-S
- Tesollo Delto DG-4F vs Tesollo Delto DG-3F-M
- Tesollo Delto DG-4F vs Tesollo Delto DG-3F-B
- Tesollo Delto DG-4F vs Barrett BarrettHand BH8-282