

説明
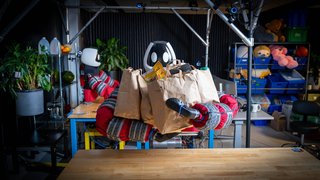
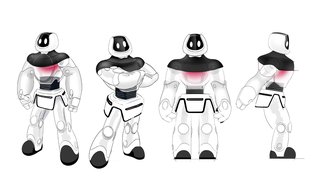
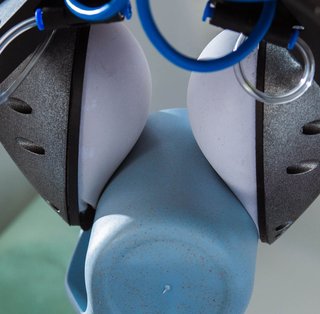
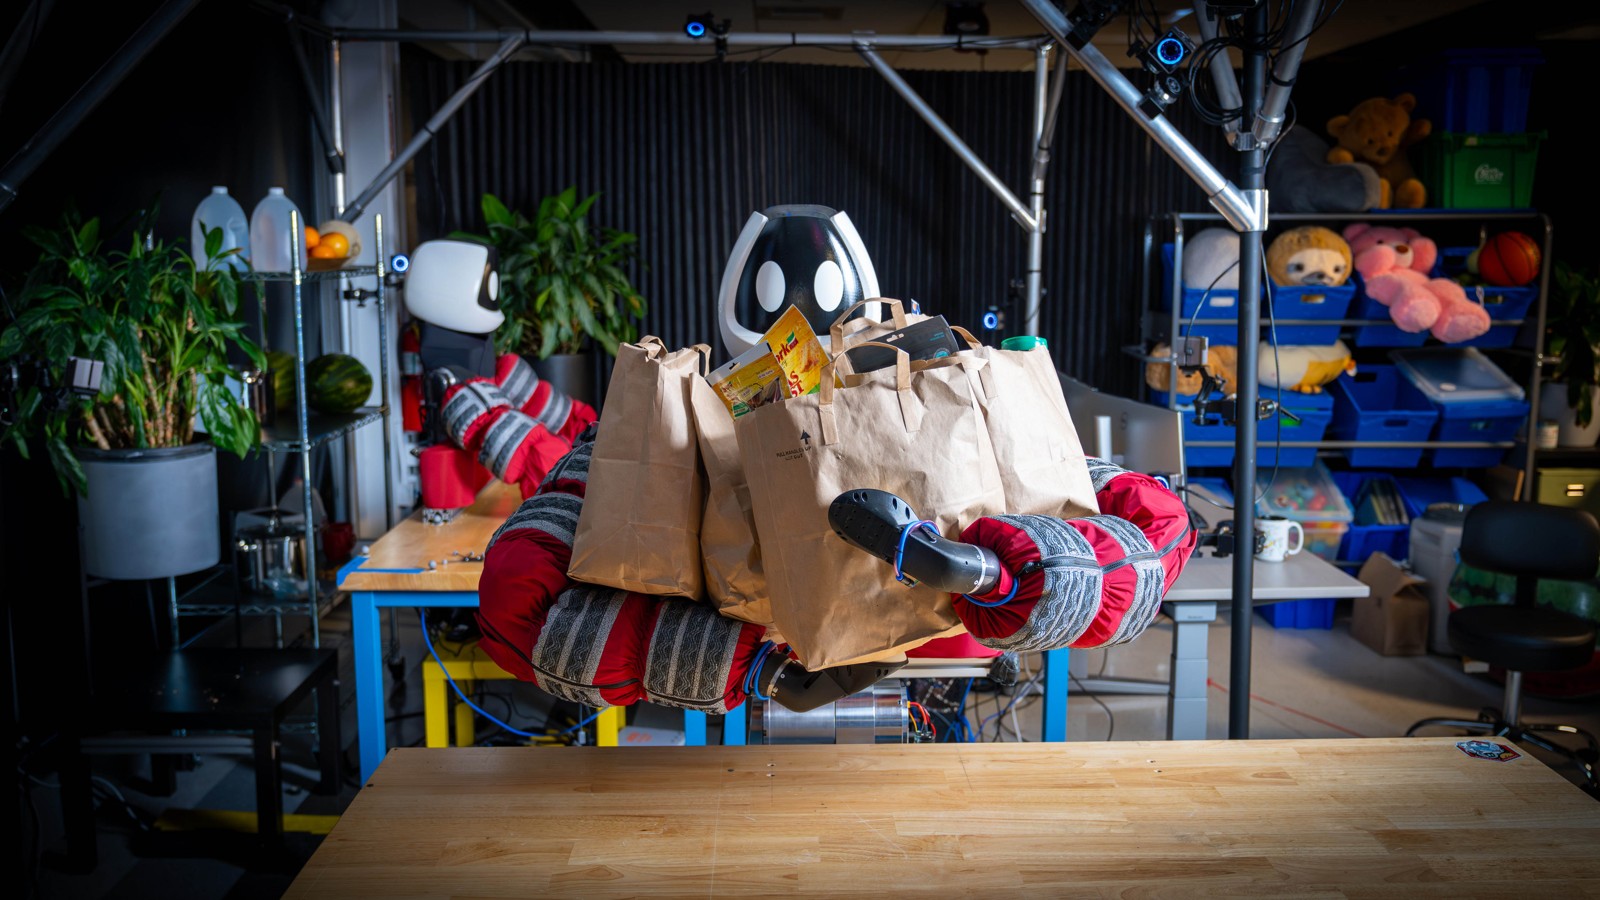
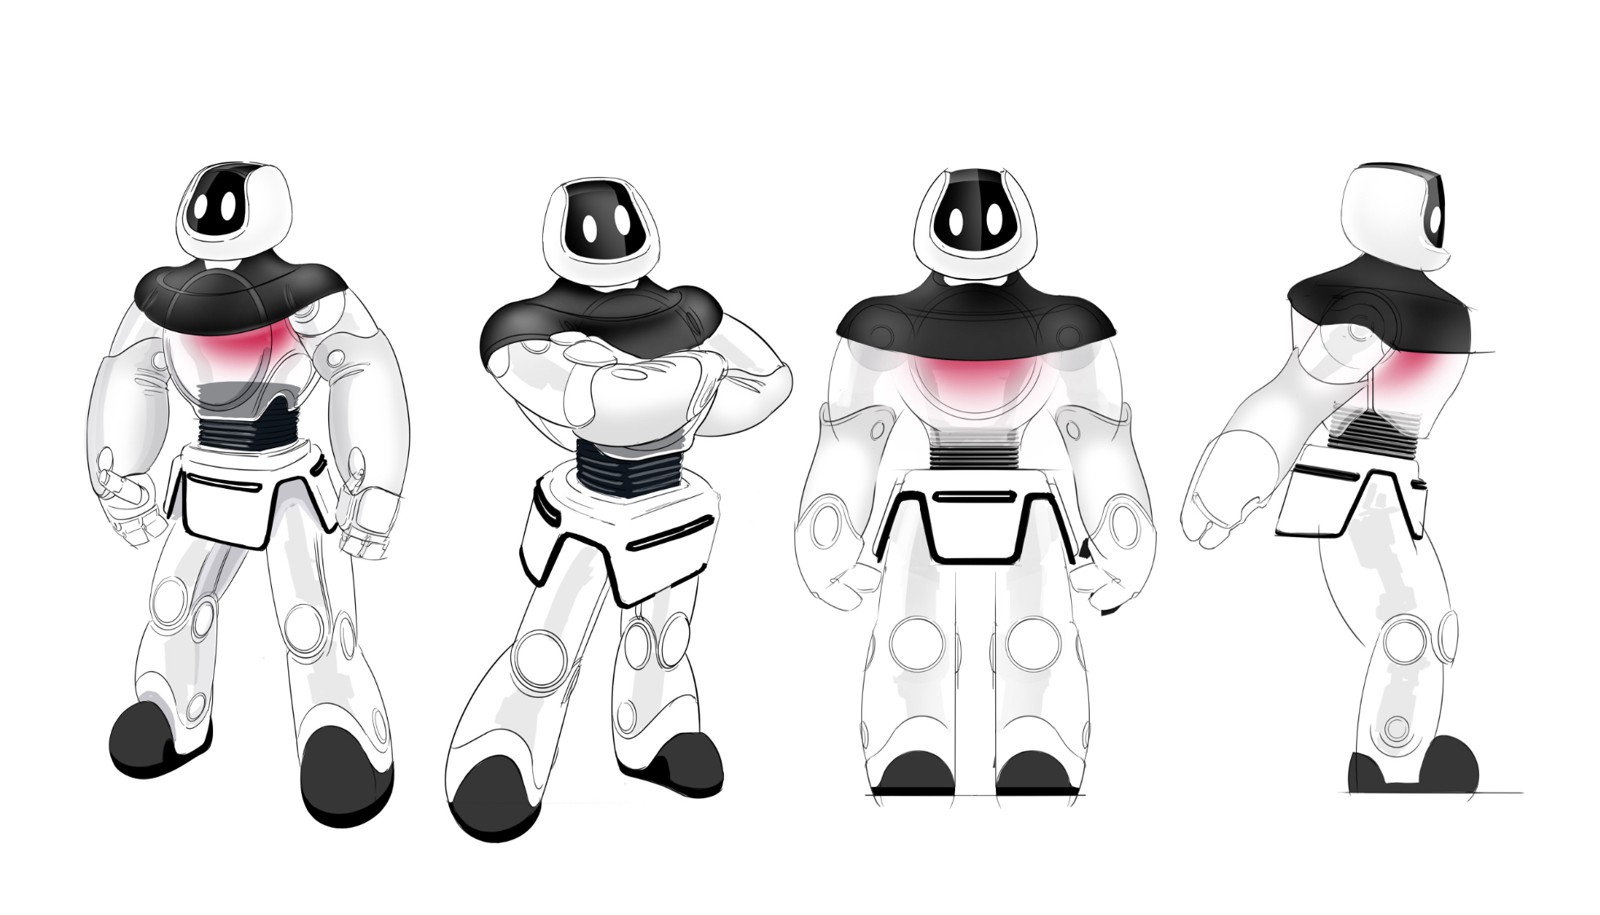
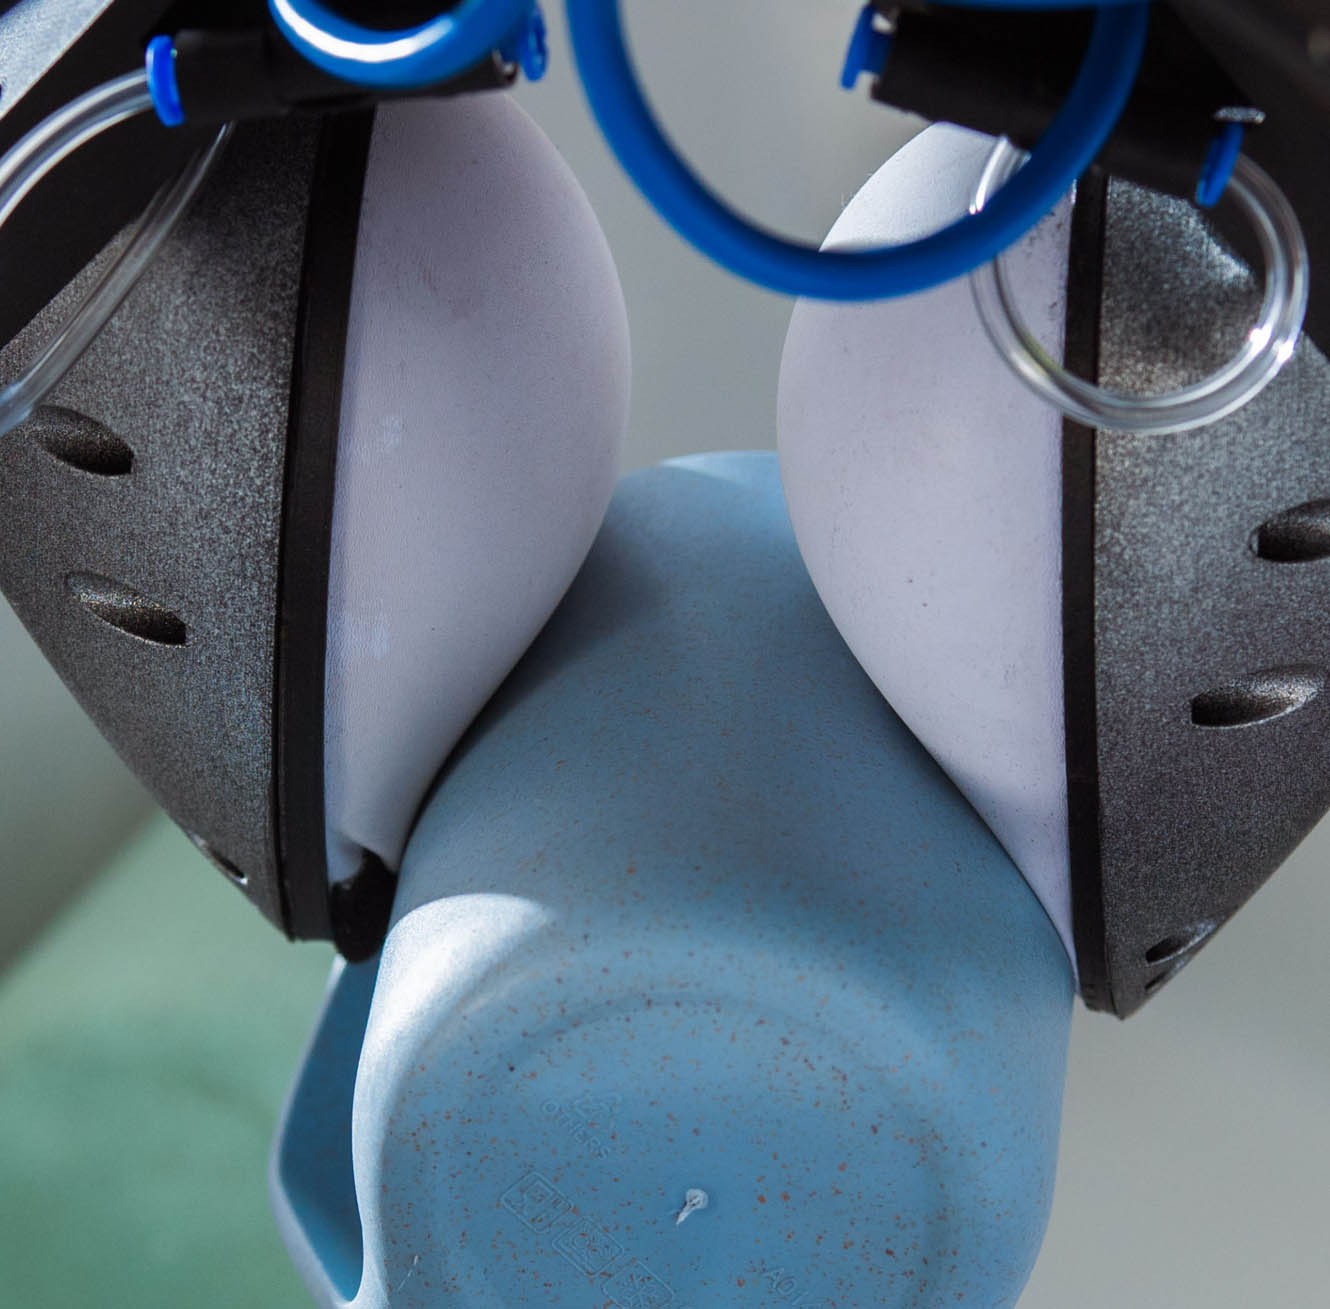
Punyo is Toyota Research Institute's answer to a problem most robots dodge: how to pick up things that are big, heavy and awkward. The usual approach is fingertips and careful grasps. Punyo does the opposite — it hugs. Arms, forearms and chest are covered in soft, air-filled 'bubble' surfaces that sense contact, so the robot can lean into an object, take its weight across its whole body and carry it the way a person carries a full laundry basket. The name is a Japanese word for a soft, chubby, resilient sort of cuteness, and TRI's Tactile team describes the machine as an artistic rendering of their dream domestic robot: soft, interactive, affordable, safe, durable and capable. The design intent is unusual — most robots are engineered to avoid contact, while Punyo is built to make a great deal of it safely. Underneath is the team's sensing work. The bubbles are compliant tactile sensors that turn a rigid arm into a soft one, giving the robot readings from deformation rather than from force at a wrist. TRI has published build instructions and design files for the Punyo Bubble Gripper v2.0, which is built around an Intel RealSense D405 depth camera and released under a Creative Commons Attribution-NonCommercial licence, so other labs can reproduce it. Punyo is a research platform, not a product. It exists to test whole-body manipulation and contact-rich control, feeding TRI's wider work on mobile manipulation and large behaviour models.
特長
- Whole-body manipulation: carries large, heavy and unwieldy items by hugging them, not just gripping
- Soft air-filled 'bubble' surfaces on arms, forearms and chest
- Bubble surfaces are compliant tactile sensors — they sense contact by deforming
- Designed to make frequent, deliberate contact with the world and with people, safely
- Punyo Bubble Gripper v2.0 build instructions and design files published openly
- Bubble Gripper v2.0 built around an Intel RealSense D405 depth camera
- Project material released under a Creative Commons Attribution-NonCommercial licence
- Research platform for contact-rich control, feeding TRI's mobile-manipulation programme
- Developed by TRI's Tactile team, spanning soft robotics, humanoid systems and physical human-robot interaction
技術仕様
| 移動性能 | |
| 移動方式 | ヒューマノイド |
|---|---|
| 使用環境 | Laboratory and domestic research settings |
| センシング・演算 | |
| センサー | soft air-filled bubble tactile sensors on arms, forearms and chest, Intel RealSense D405 depth camera in the Bubble Gripper v2.0 |
技術仕様
| 移動性能 | |
| 移動方式 | ヒューマノイド |
|---|---|
| 使用環境 | Laboratory and domestic research settings |
| センシング・演算 | |
| センサー | soft air-filled bubble tactile sensors on arms, forearms and chest, Intel RealSense D405 depth camera in the Bubble Gripper v2.0 |
画像
 martti
 martti
 martti
投稿画像
動画
ロボットフォーラム
フォーラムを読み込み中...
評価
よくある質問
What is the TRI Punyo?
Punyo is Toyota Research Institute's answer to a problem most robots dodge: how to pick up things that are big, heavy and awkward. The usual approach is fingertips and careful grasps. Punyo does the opposite — it hugs.
Who makes the TRI Punyo?
The TRI Punyo is made by Toyota, a robotics company based in United States.
How much does the TRI Punyo cost?
Toyota has not publicly announced pricing for the TRI Punyo. You can enquire through RobotAIGeek for current pricing.
What is the TRI Punyo used for?
The TRI Punyo is designed for 開発, マテリアルハンドリング, and 研究. It is used in 研究, 家庭, and 製造 settings.
類似ロボットと比較
このロボットが最も近い代替候補とどう比べられるかをご覧ください
- TRI Punyo vs Tokyo Robotics Torobo
- TRI Punyo vs WIRobotics ALLEX
- TRI Punyo vs Dexmate Vega
- TRI Punyo vs Red Rabbit Robotics RX1
- TRI Punyo vs Tokyo Robotics Torobo-kun