

説明
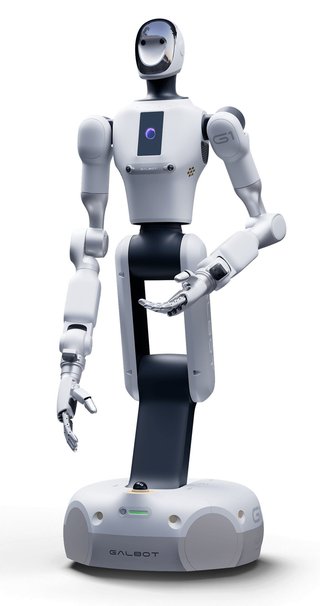
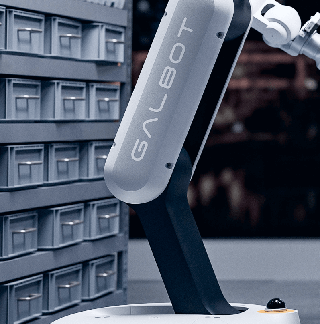
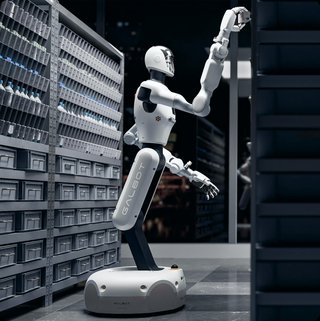
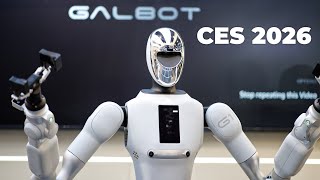
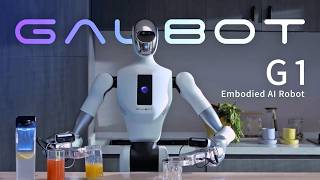
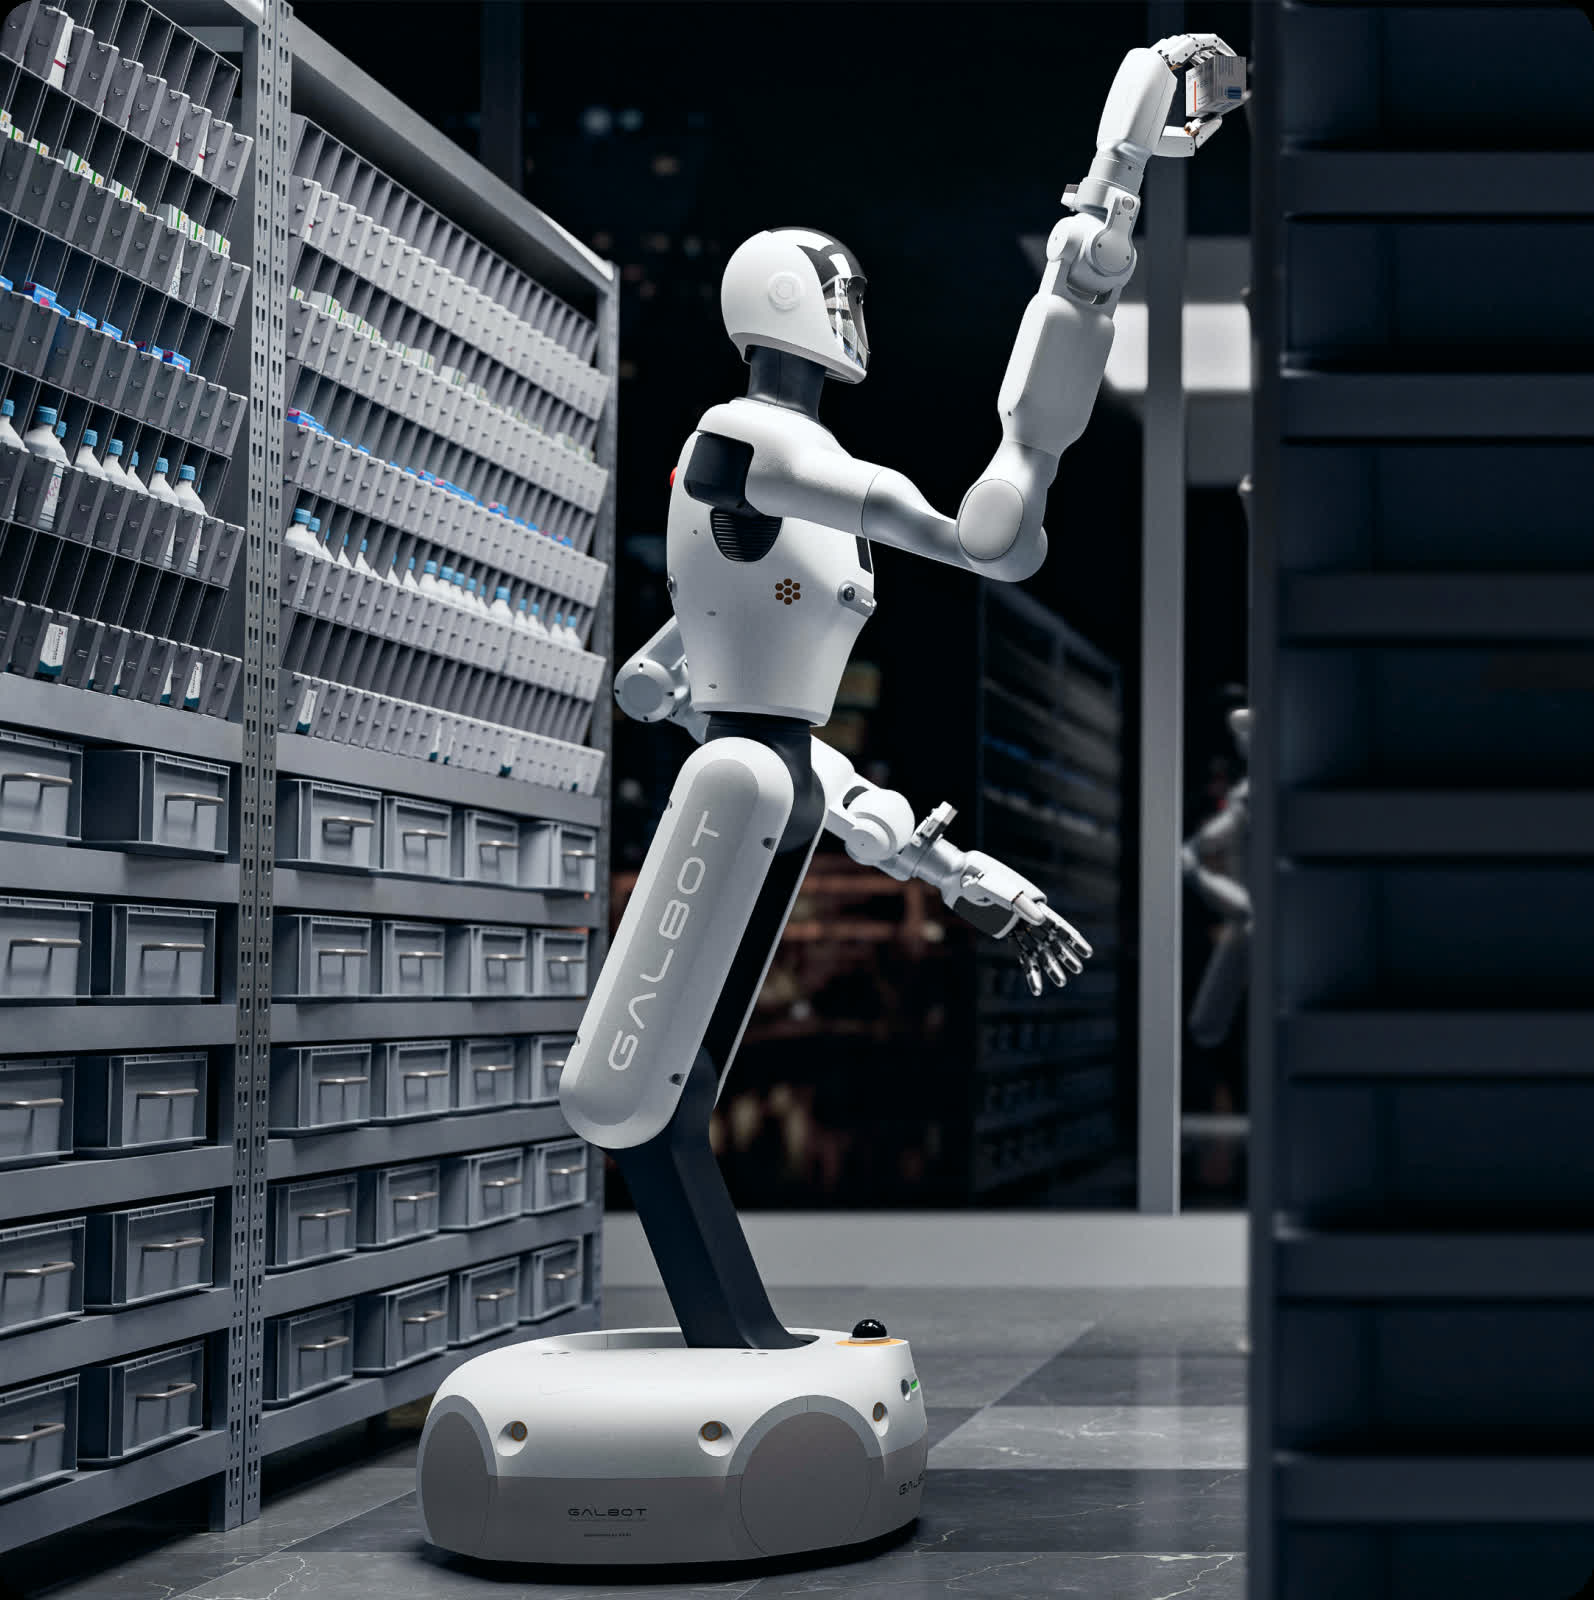
Galbot G1 runs on a 360° omnidirectional-wheel chassis and extends its mechanical arm up to 1.9m with a 10kg payload, operating across heights from 0 to 2.4m.
特長
- 360° omnidirectional-wheel chassis, adaptive height operation (0-2.4m), 1.9m mechanical arm reach, 10kg payload, dexterous hand with modular design, multimodal perception (visual, auditory, 3D), embodied intelligence, Embosar in-house embodied intelligence system architecture, industrial protection (IP54), 6.25-inch smart interactive display, 8 hours operating time.
技術仕様
検証済み| 本体 | |
| 重量 | 92.5 kg |
|---|---|
| 寸法 | H 1.73 m |
| 可搬重量 | 10 kg |
| リーチ | 1.9 m |
| 移動性能 | |
| 移動方式 | 車輪型 |
| 自由度 | 24 |
| マニピュレーション | 高 |
| 使用環境 | IP54 |
| アクチュエーター | Legs 2 + waist 3 + neck 2 = 7 DoF, dual arms 7x2 = 14 DoF, four chassis drive wheels = 24 total; 650 mm torso lift; 710 mm arm length shoulder to wrist |
| 電源 | |
| バッテリー駆動時間 | 8 h |
| センシング・演算 | |
| センサー | head binocular camera, 2x wrist depth cameras, 2x wrist six-axis force sensors, 4x torso RGB cameras, torso IMU, chassis 3D LiDAR, 8x chassis ultrasonic sensors, chassis IMU, 2x linear 4-mic arrays, 5.5-inch 1920x1080 touchscreen |
| 接続性 | Wi-Fi 2.4/5 GHz; Bluetooth |
| ソフトウェア / AI | Embosar in-house embodied-intelligence system architecture; multimodal visual and auditory perception with intent understanding and voice interaction |
画像
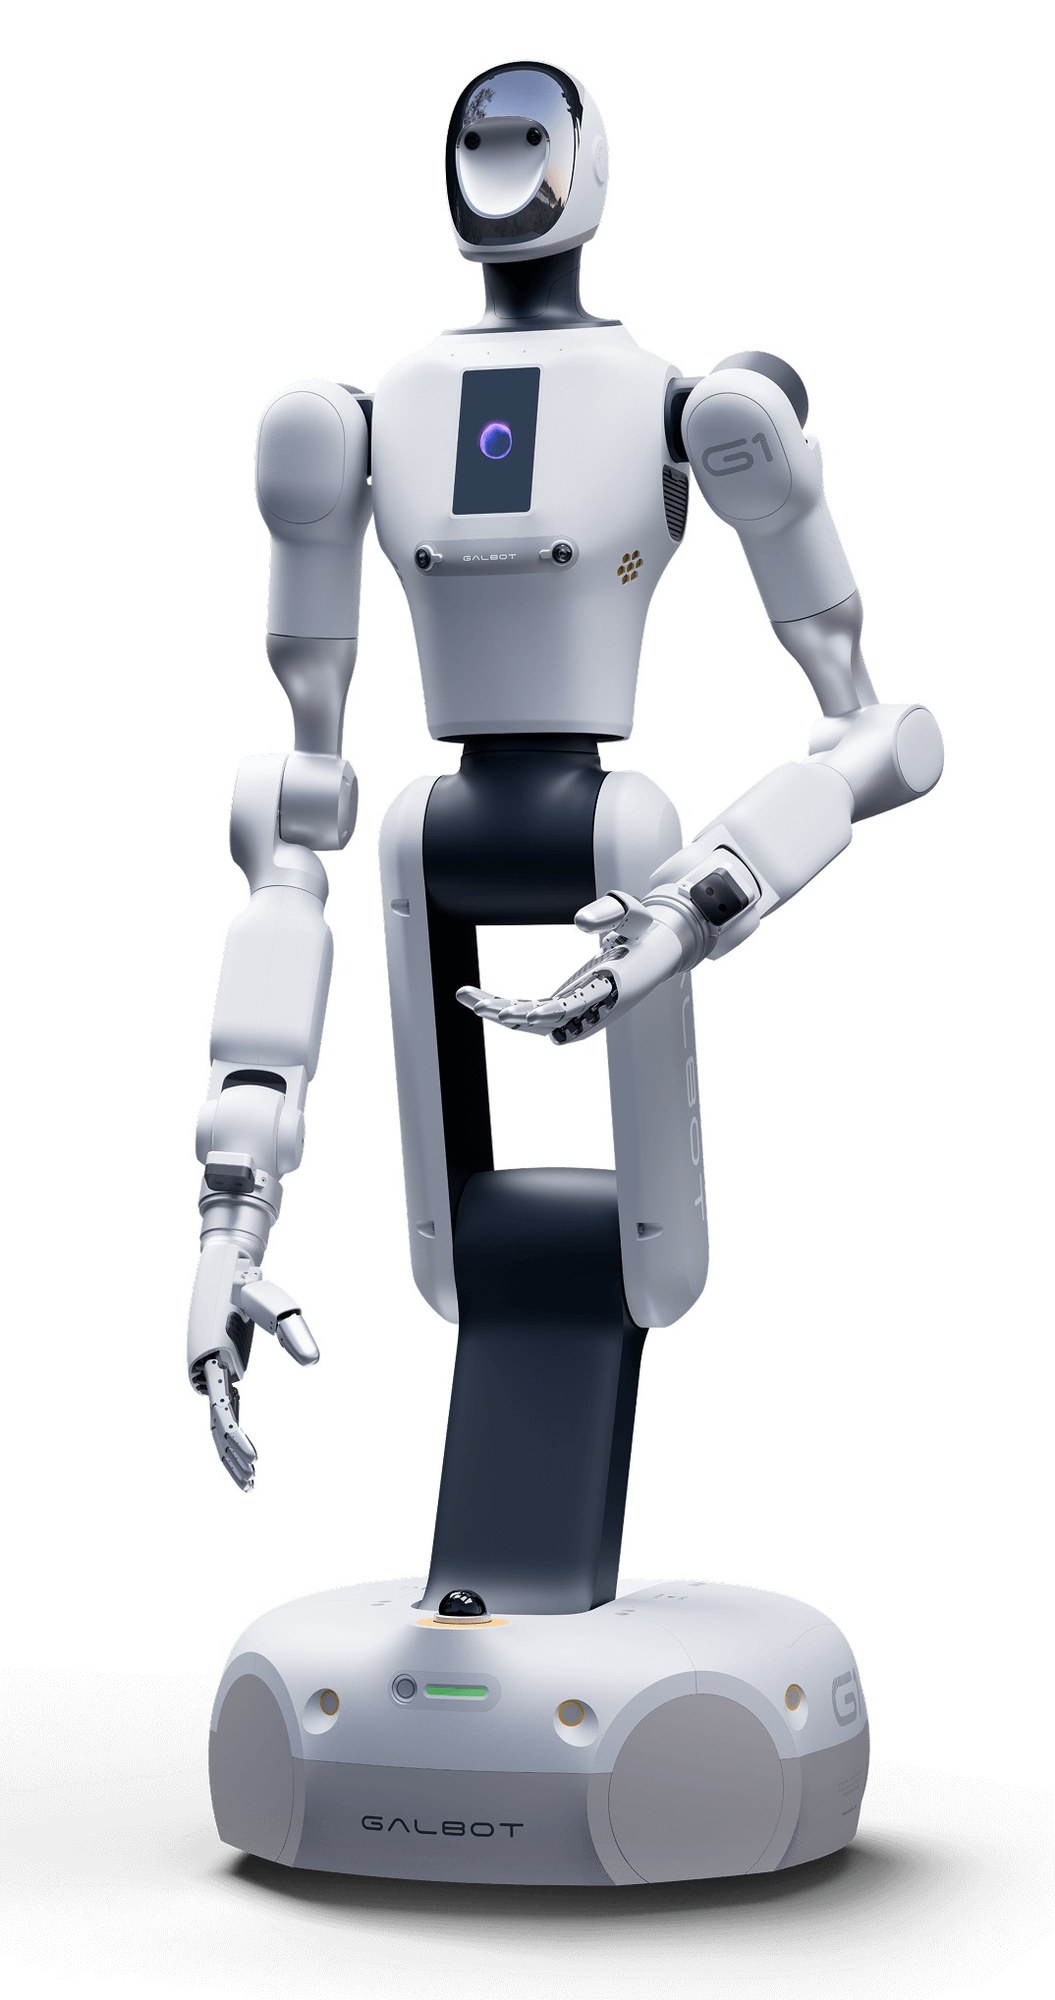
 martti
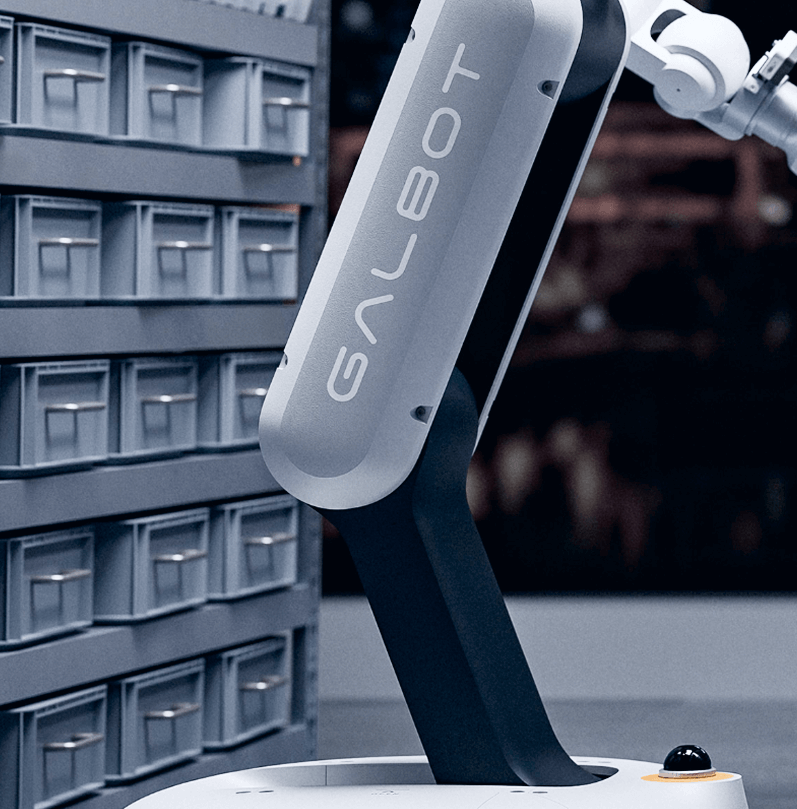 martti
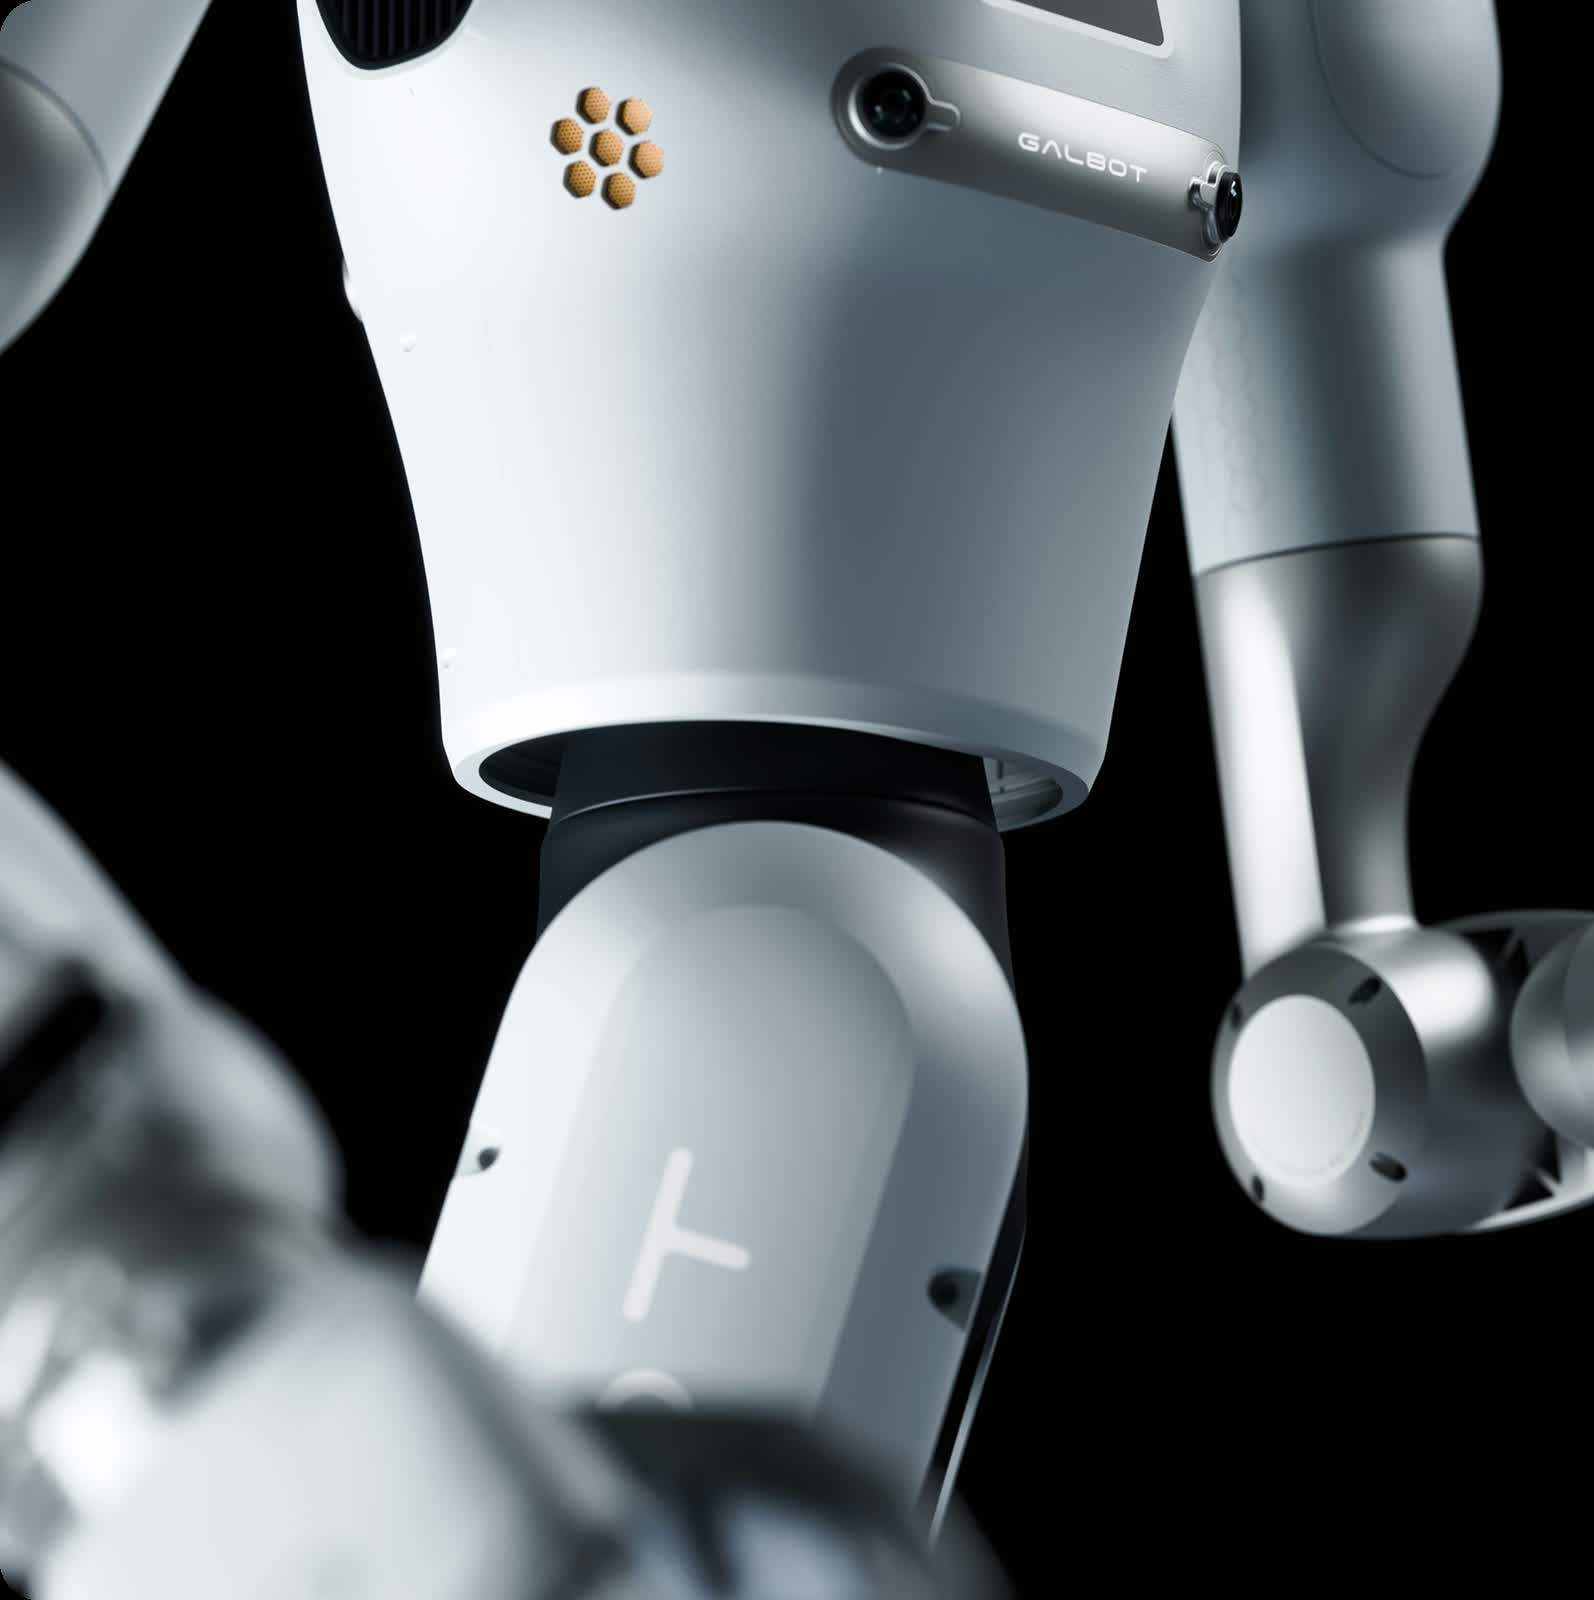 martti
 martti
 martti
投稿画像
ロボットフォーラム
フォーラムを読み込み中...
評価
よくある質問
What is the Galbot G1?
Galbot G1 runs on a 360° omnidirectional-wheel chassis and extends its mechanical arm up to 1.9m with a 10kg payload, operating across heights from 0 to 2.4m.
Who makes the Galbot G1?
The Galbot G1 is made by Galbot (Beijing Galaxy General Robot Co., Ltd.), a robotics company based in China.
How much does the Galbot G1 cost?
Galbot (Beijing Galaxy General Robot Co., Ltd.) has not publicly announced pricing for the Galbot G1. You can enquire through RobotAIGeek for current pricing.
What is the Galbot G1 used for?
The Galbot G1 is designed for 組立, 清掃, ピック&プレース, and 配送. It is used in 医療, 家庭, 倉庫・物流, and 製造 settings.
What is the payload capacity of the Galbot G1?
The Galbot G1 has a payload capacity of 10 kg and a reach of 1.9 m.
How much does the Galbot G1 weigh?
The Galbot G1 weighs 92.5 kg.
What is the battery life of the Galbot G1?
The Galbot G1 runs for 8 h on a charge.
How many degrees of freedom does the Galbot G1 have?
The Galbot G1 has 24 degrees of freedom.
類似ロボットと比較
このロボットが最も近い代替候補とどう比べられるかをご覧ください
- Galbot G1 vs Embodied Tien Kung 3.0
- Galbot G1 vs Embodied Tian Yi 2.0
- Galbot G1 vs Vizum Xiaowei AGV Version
- Galbot G1 vs W-Bot
- Galbot G1 vs MATRIX-1