

BESCHREIBUNG
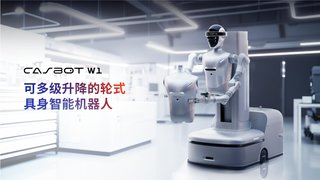
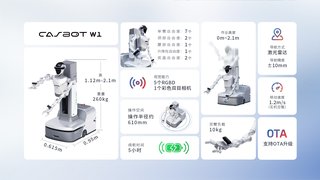
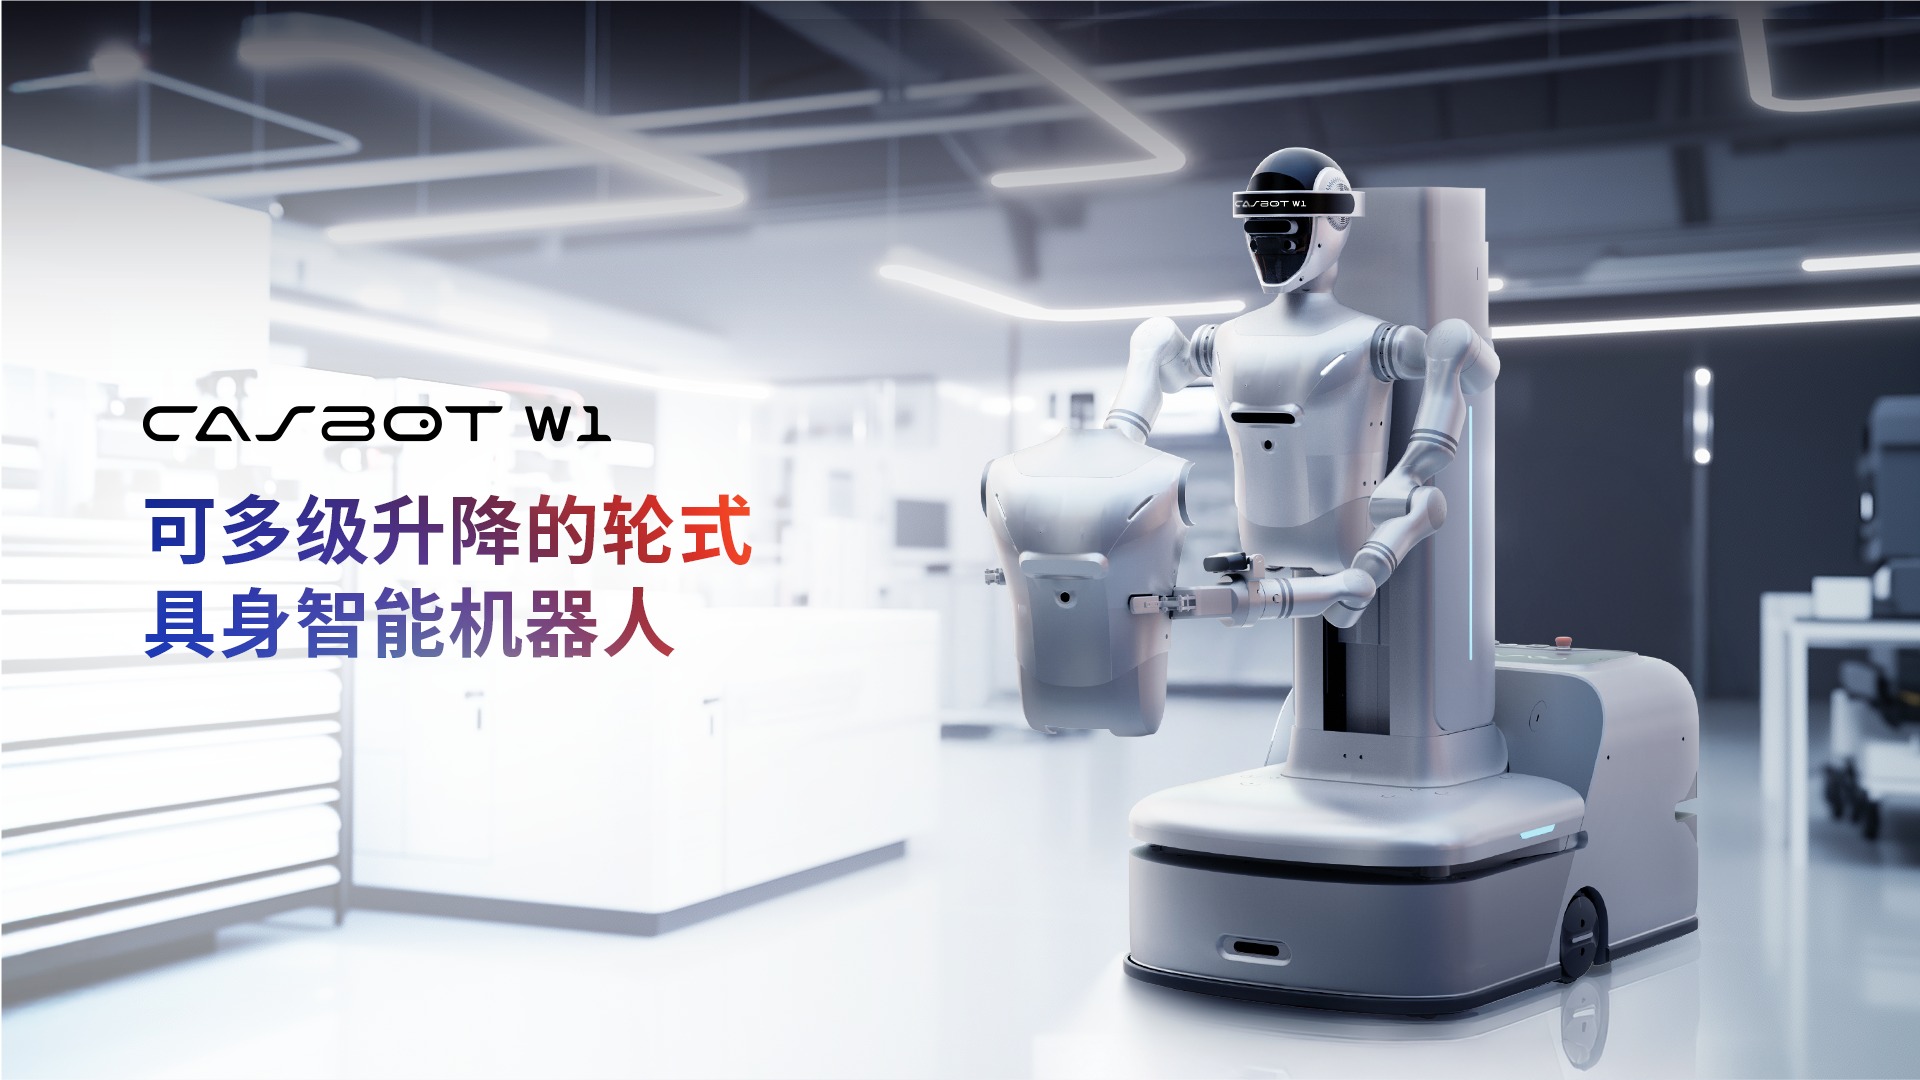
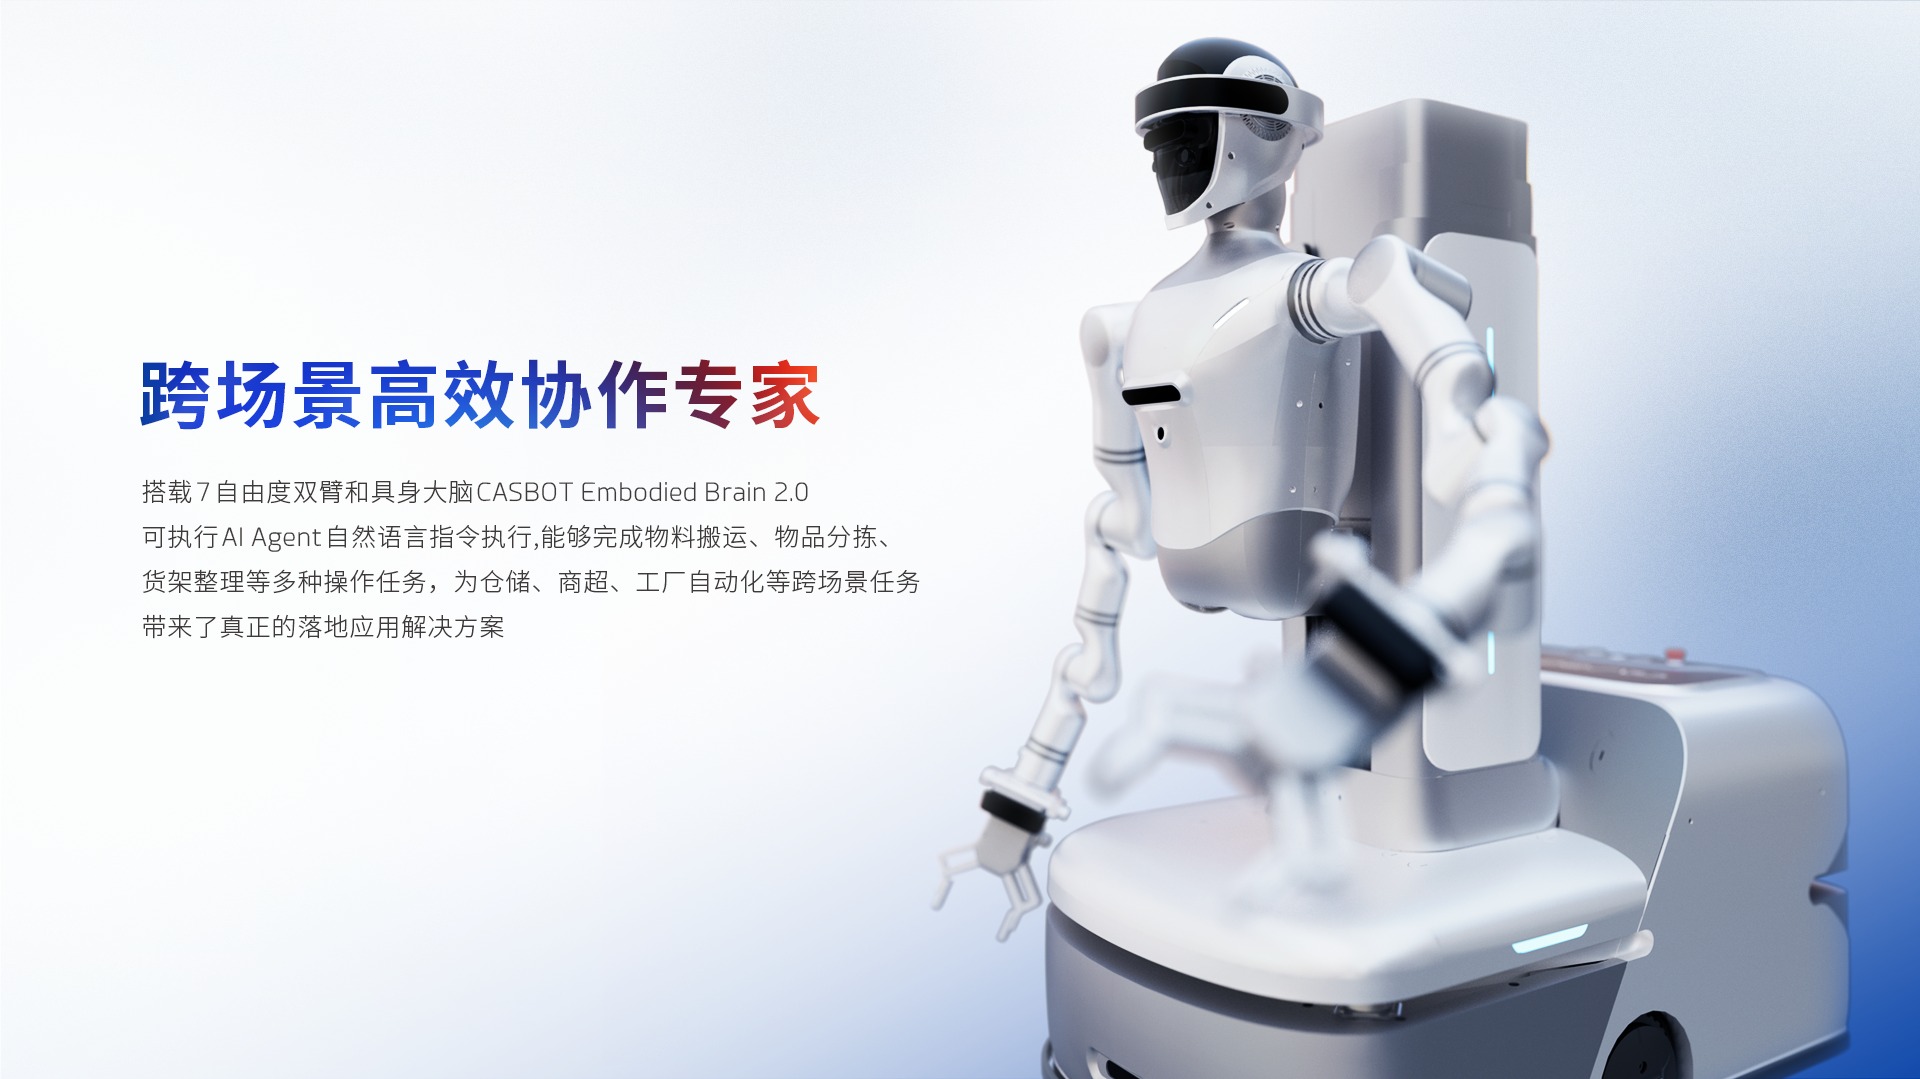
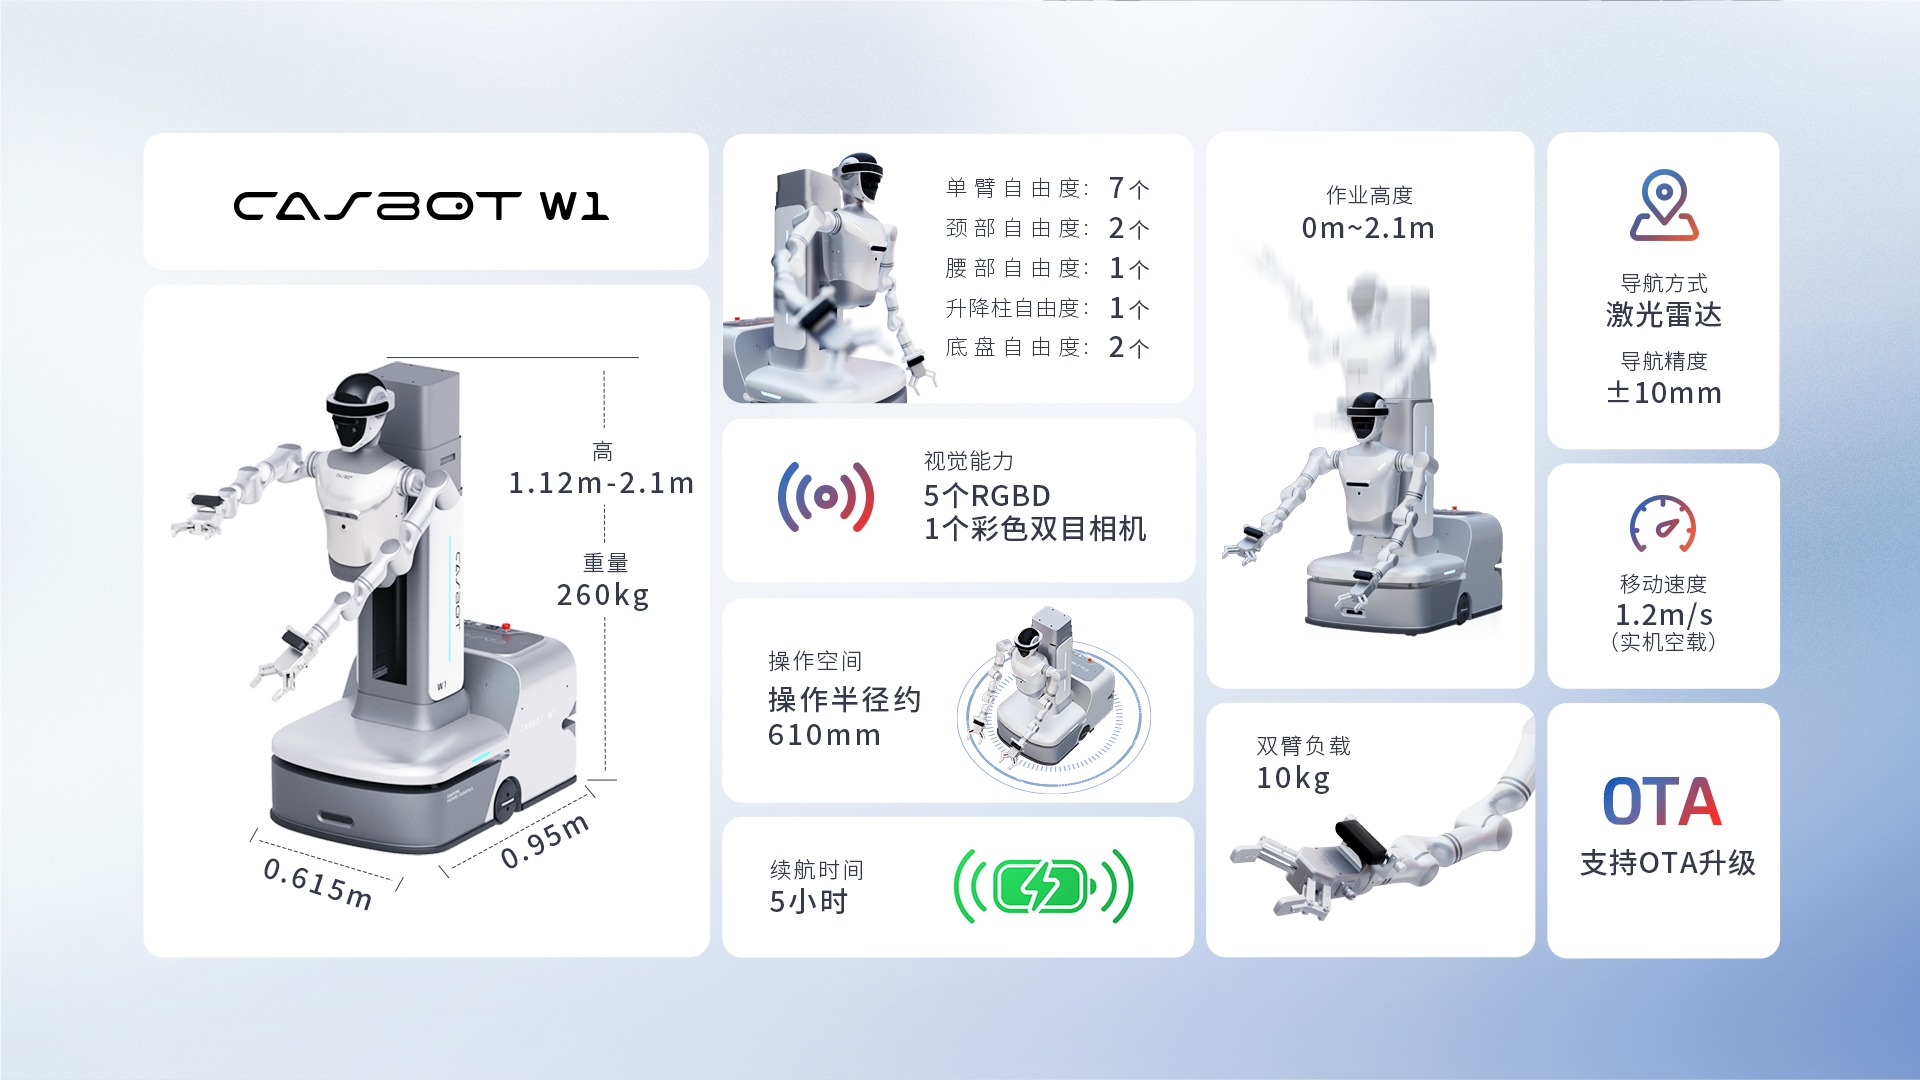
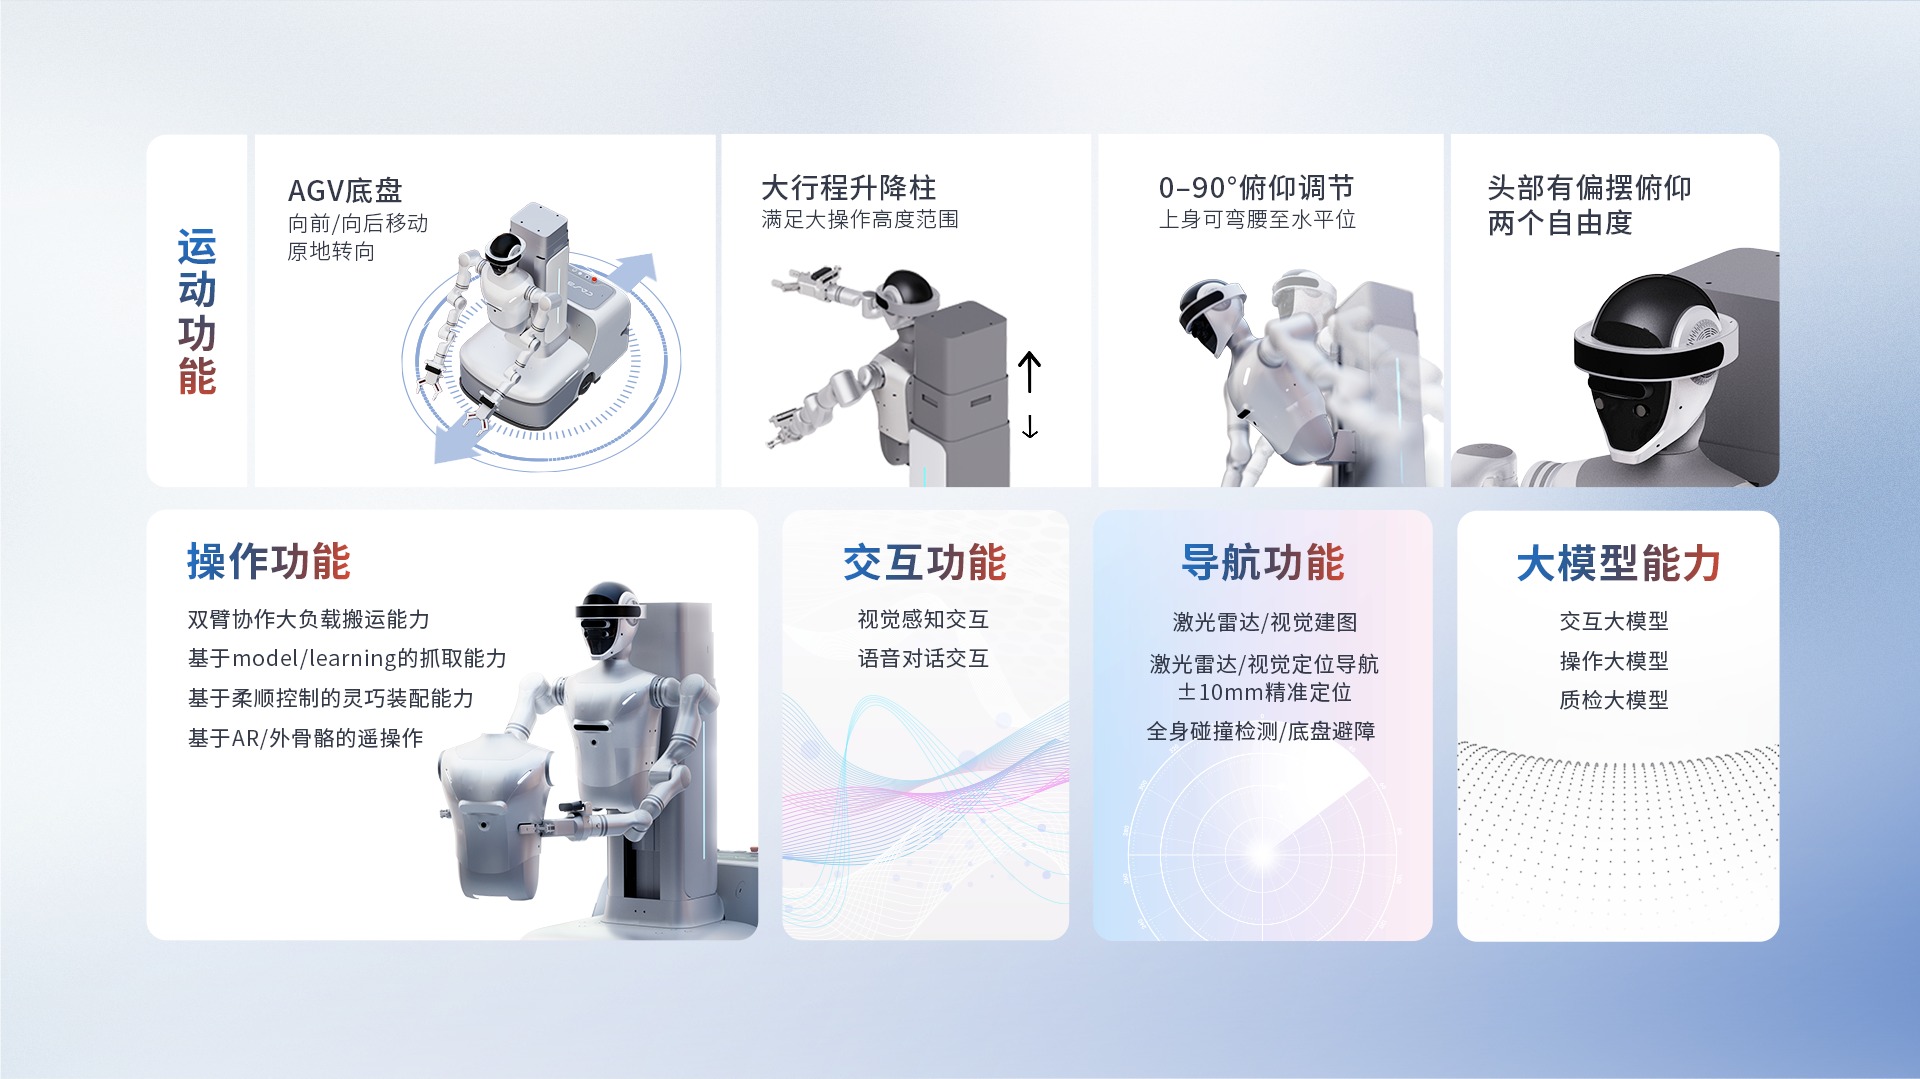
The CASBOT W1 is the company's wheeled embodied humanoid, and its defining feature is a lifting column that takes it from 1.12 m to 2.1 m. That range is the point: a fixed-height wheeled manipulator can only work at one bench height, whereas the W1 covers a 0 to 2.1 m working envelope, reaching floor-level bins and high shelving from the same chassis. Its dual 7-degree-of-freedom arms span 2,040 mm including grippers and carry 5 kg each over a 610 mm working radius, with RGBD cameras at both wrists as well as in the head and chest. Twenty degrees of freedom in total spread across head, waist, chassis, lift column and arms. The end effectors are swappable — the standard 2-DoF gripper can be exchanged for a dexterous hand or suction cups through a standard structural and communications interface. It runs on an industrial PC with an i9 processor and a 4060 GPU, navigates on a two-wheel differential chassis at up to 1.2 m/s, charges itself autonomously, and carries an IP68 rating with 4 to 5 hours of endurance from a 48 V 25 Ah lithium iron phosphate pack.
FUNKTIONEN
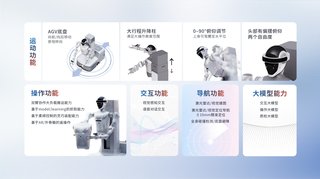
- Multi-stage lifting column taking overall height from 1.12 m retracted to 2.1 m extended, giving a 0 to 2.1 m working height from one chassis
- 0.95 x 0.615 m footprint
- approximately 260 kg
- 20 total degrees of freedom: 2 in the head (yaw and pitch), 1 at the waist (pitch), 2 in the chassis, 1 in the lift column and 7 per arm
- Dual 7-degree-of-freedom arms with a 2,040 mm span including grippers, 5 kg payload each and a 610 mm working radius
- Swappable end effectors through a standard structural and communications interface, supporting grippers, dexterous hands and suction cups
- standard 2-DoF gripper weighs 500 g with 15 N grip force
- RGBD structured-light cameras at both wrists plus one in the head and one in the chest, with a head binocular camera and a head display
- Expandable 360-degree spherical LiDAR at the abdomen
- 820 x 620 x 290 mm chassis on a 2+4 wheel two-wheel differential drive reaching 1.2 m/s unloaded
- Industrial PC with i9 processor and 4060 graphics for main and motion control, plus an RK3588 interaction unit
- 48 V 25 Ah lithium iron phosphate battery, 2 hour charge, 4 to 5 hours endurance, with autonomous charging
- IP68 protection
- 5 to 40 degrees Celsius, 25-85% non-condensing humidity
- WiFi, 4G, Bluetooth and 100 Mbit Ethernet
- Powered by CASBOT Embodied Brain 2.0, a three-layer brain-cerebellum-body architecture, with CASBOT reporting adaptation to new tasks in 45 to 90 minutes
- Alloy and engineering plastic construction
- chest microphone line array, twin head speakers and chest and column lighting
TECHNISCHE DATEN
Verifiziert| Physisch | |
| Gewicht | 260 kg |
|---|---|
| Abmessungen | L 615 mm × W 950 mm × H 2.1 m |
| Traglast | 5 kg |
| Reichweite | 610 mm |
| Mobilität | |
| Bewegungsart | Radbasiert |
| Freiheitsgrade | 20 |
| Geschwindigkeit | 4.32 km/h |
| Manipulation | Hoch |
| Einsatzumgebung | 5 to 40 degrees Celsius, 25-85% relative humidity non-condensing; IP68 |
| Aktoren | Dual 7-degree-of-freedom arms on a single-axis lifting column over a two-wheel differential wheeled chassis; swappable 2-DoF gripper, dexterous hand or suction end effector |
| Energie | |
| Akkulaufzeit | 4-5 h |
| Ladezeit | 2 h |
| Sensorik & Rechenleistung | |
| Sensoren | RGBD structured-light cameras x2 at wrists, RGBD camera in head, RGBD camera in chest, binocular camera in head, expandable 360-degree spherical LiDAR, chest microphone line array |
| Konnektivität | WiFi, 4G, Bluetooth, 100 Mbit Ethernet |
| Software / KI | CASBOT Embodied Brain 2.0 with a three-layer brain-cerebellum-body architecture; autonomous operation with auto-recharging |
Bilder
 martti
 martti
 martti
 martti
Bildbeiträge
Videos
ROBOTER-FOREN
Foren werden geladen...
BEWERTUNGEN
HÄUFIG GESTELLTE FRAGEN
What is the CASBOT W1?
The CASBOT W1 is the company's wheeled embodied humanoid, and its defining feature is a lifting column that takes it from 1.12 m to 2.1 m.
Who makes the CASBOT W1?
The CASBOT W1 is made by CASBOT, a robotics company based in China.
How much does the CASBOT W1 cost?
CASBOT has not publicly announced pricing for the CASBOT W1. You can enquire through RobotAIGeek for current pricing.
What is the CASBOT W1 used for?
The CASBOT W1 is designed for pick-and-place, inspektion, industrial manufacturing, and intelligent warehousing. It is used in forschung, lager & logistik, fertigung, and einzelhandel settings.
What is the payload capacity of the CASBOT W1?
The CASBOT W1 has a payload capacity of 5 kg and a reach of 610 mm.
How much does the CASBOT W1 weigh?
The CASBOT W1 weighs 260 kg.
How fast is the CASBOT W1?
The CASBOT W1 can move at speeds of up to 4.32 km/h.
What is the battery life of the CASBOT W1?
The CASBOT W1 runs for 4-5 h on a charge. It takes 2 h to charge.
MIT ÄHNLICHEN ROBOTERN VERGLEICHEN
Sehen Sie, wie sich dieser Roboter gegenüber seinen nächsten Alternativen schlägt
Alternativen zu CASBOT W1 →