

描述
yobot R2V2是Openmind Intelligent Robot的Humanoid。 面向拾放、Retail shelf replenishment、pharmacy order picking设计。 关键数据:55 kg、续航 120 分钟、负载 3 kg、30 自由度。
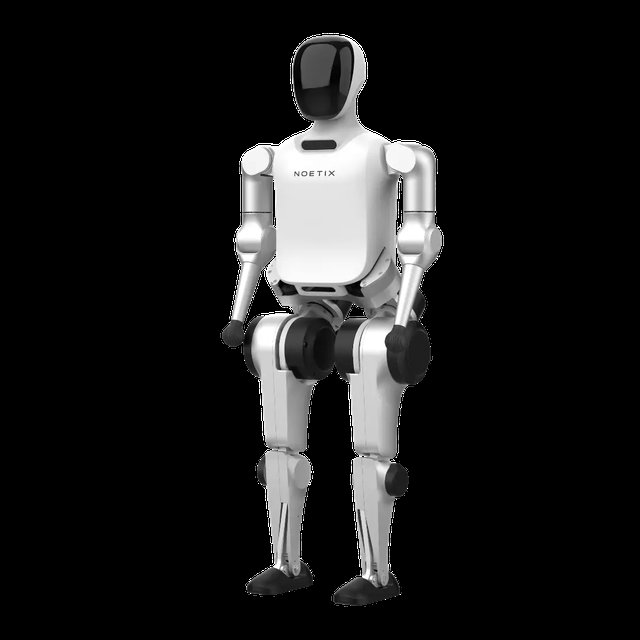
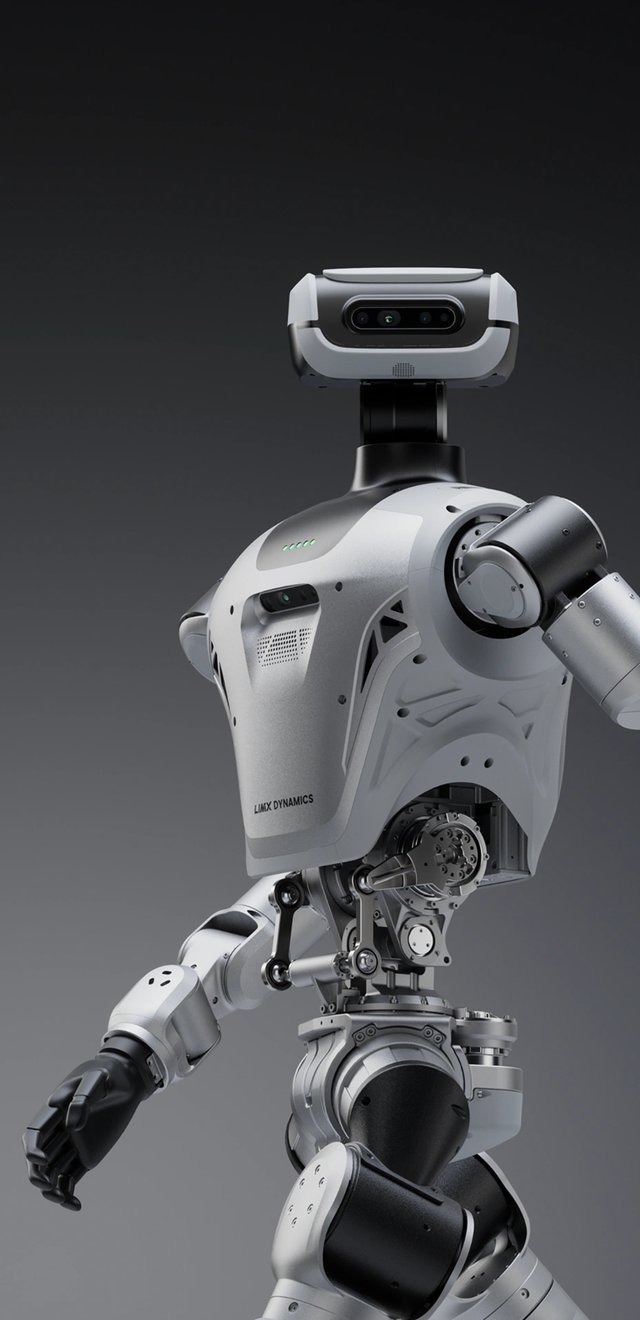
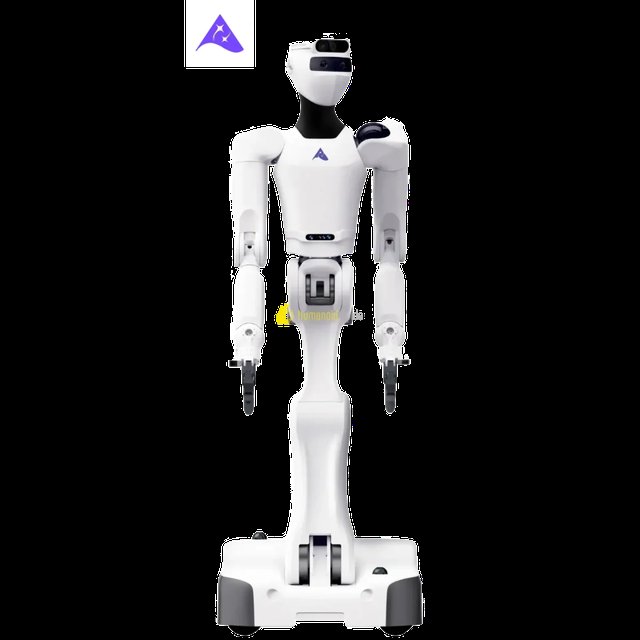
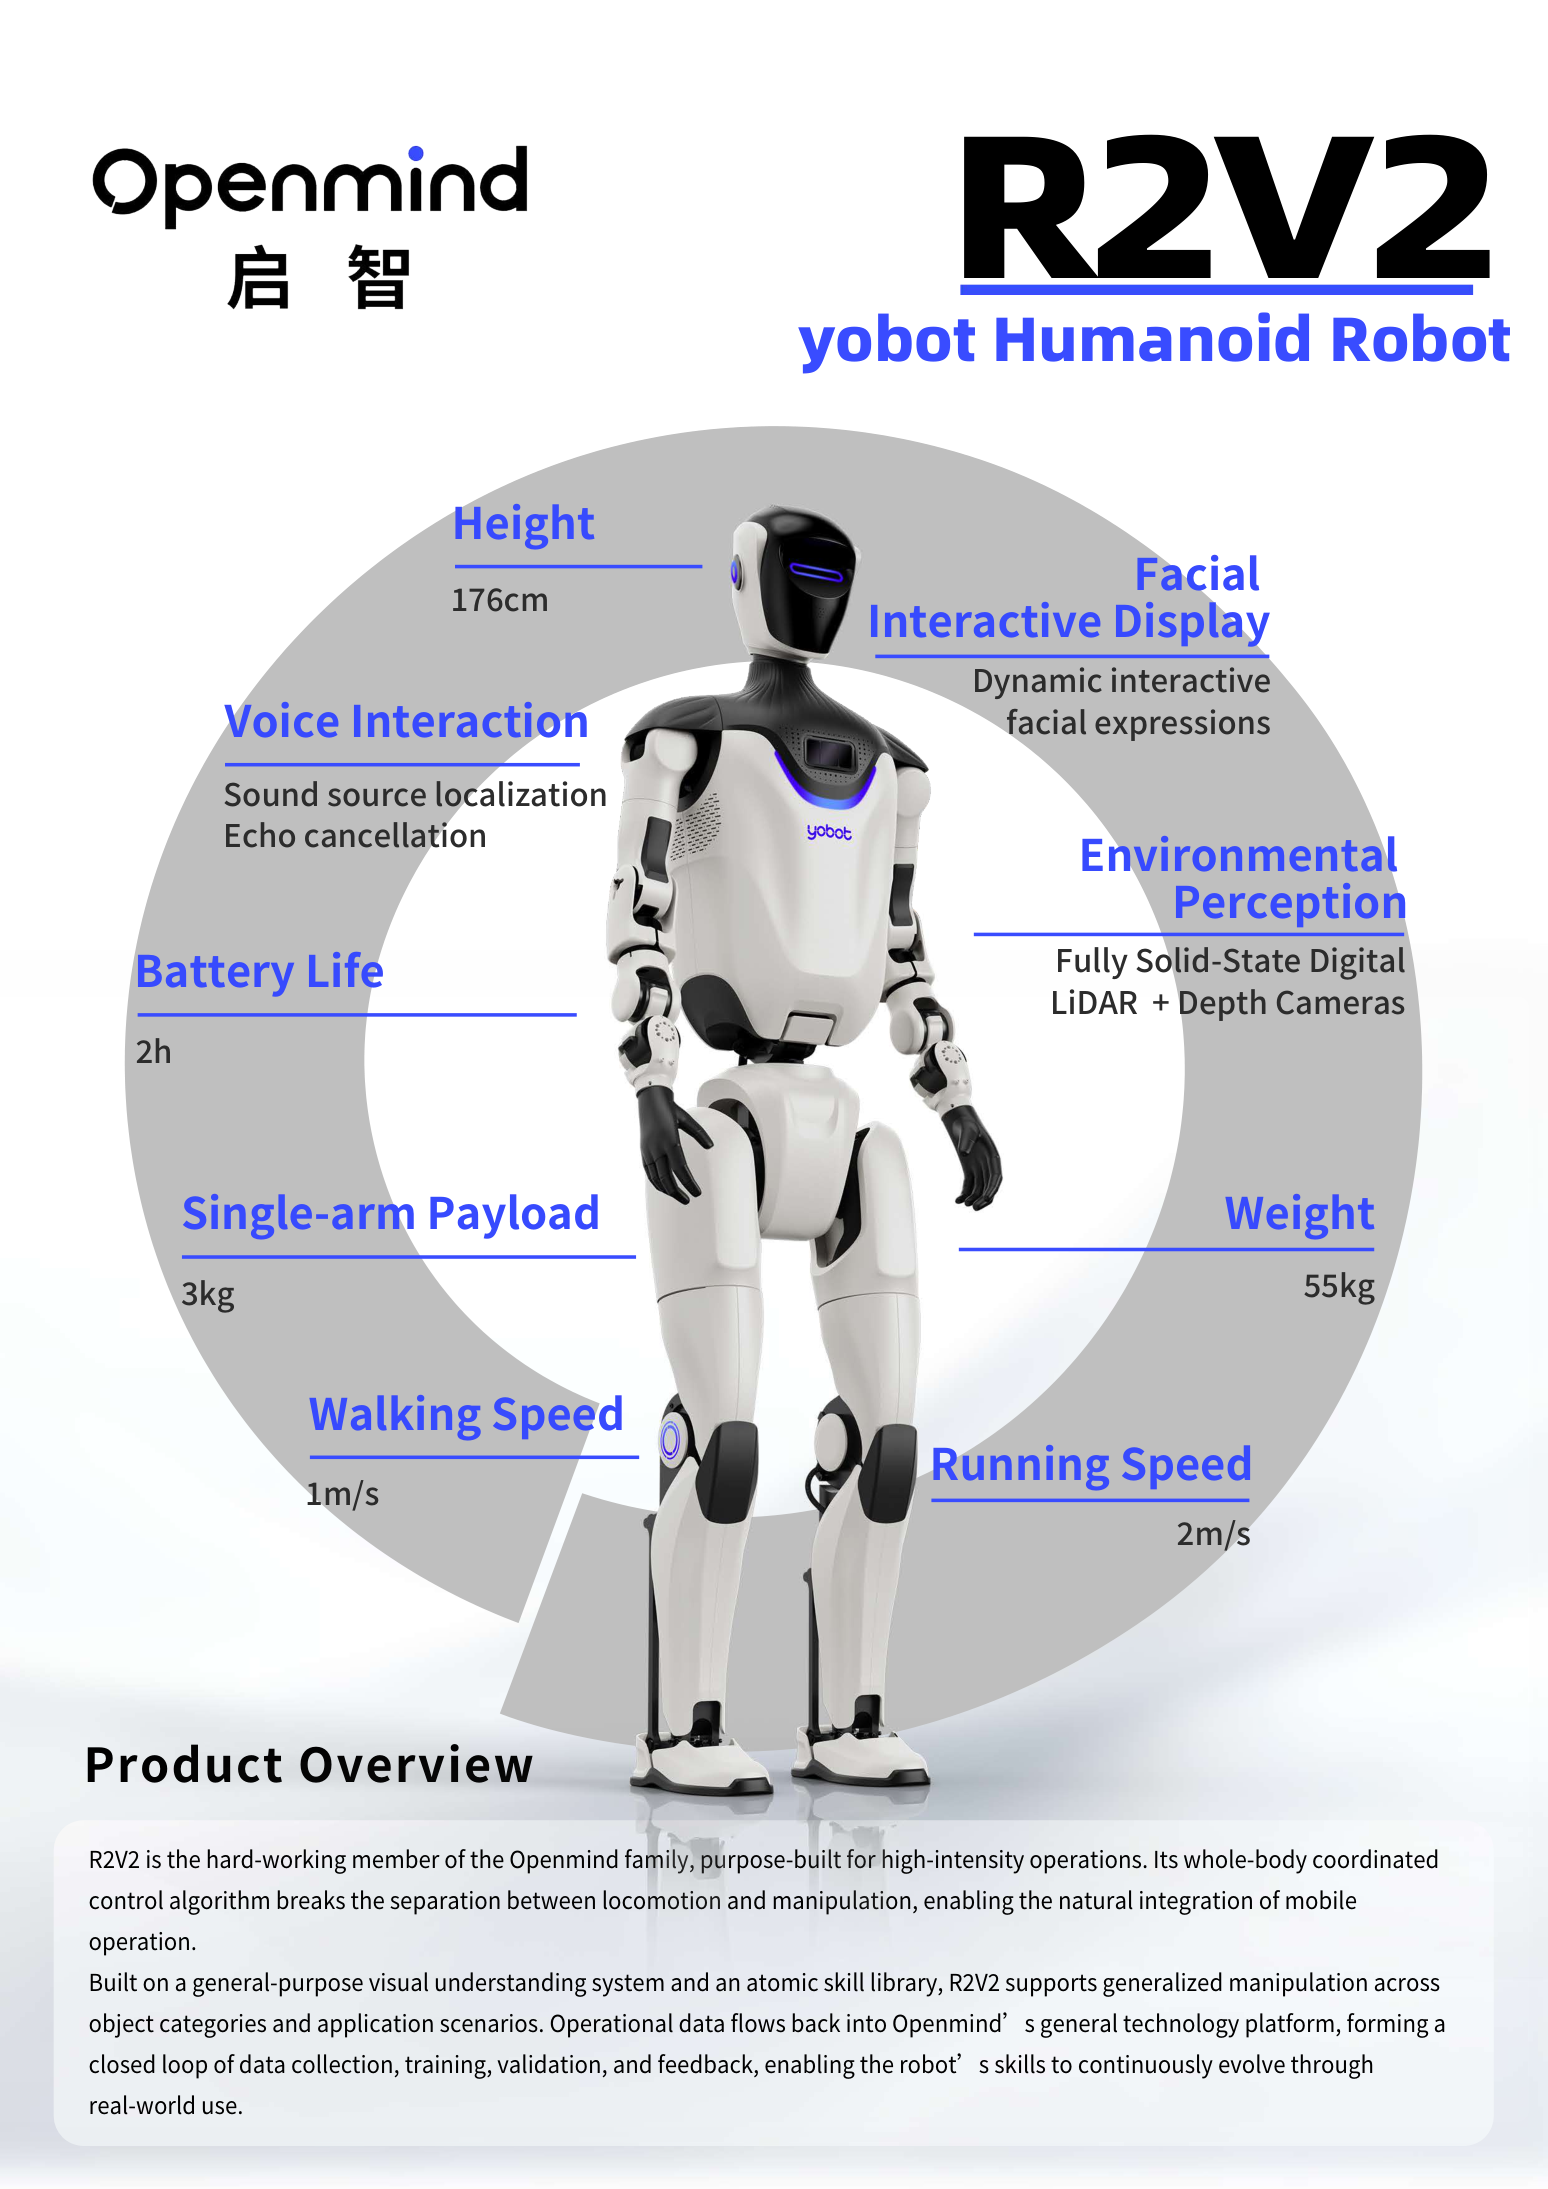
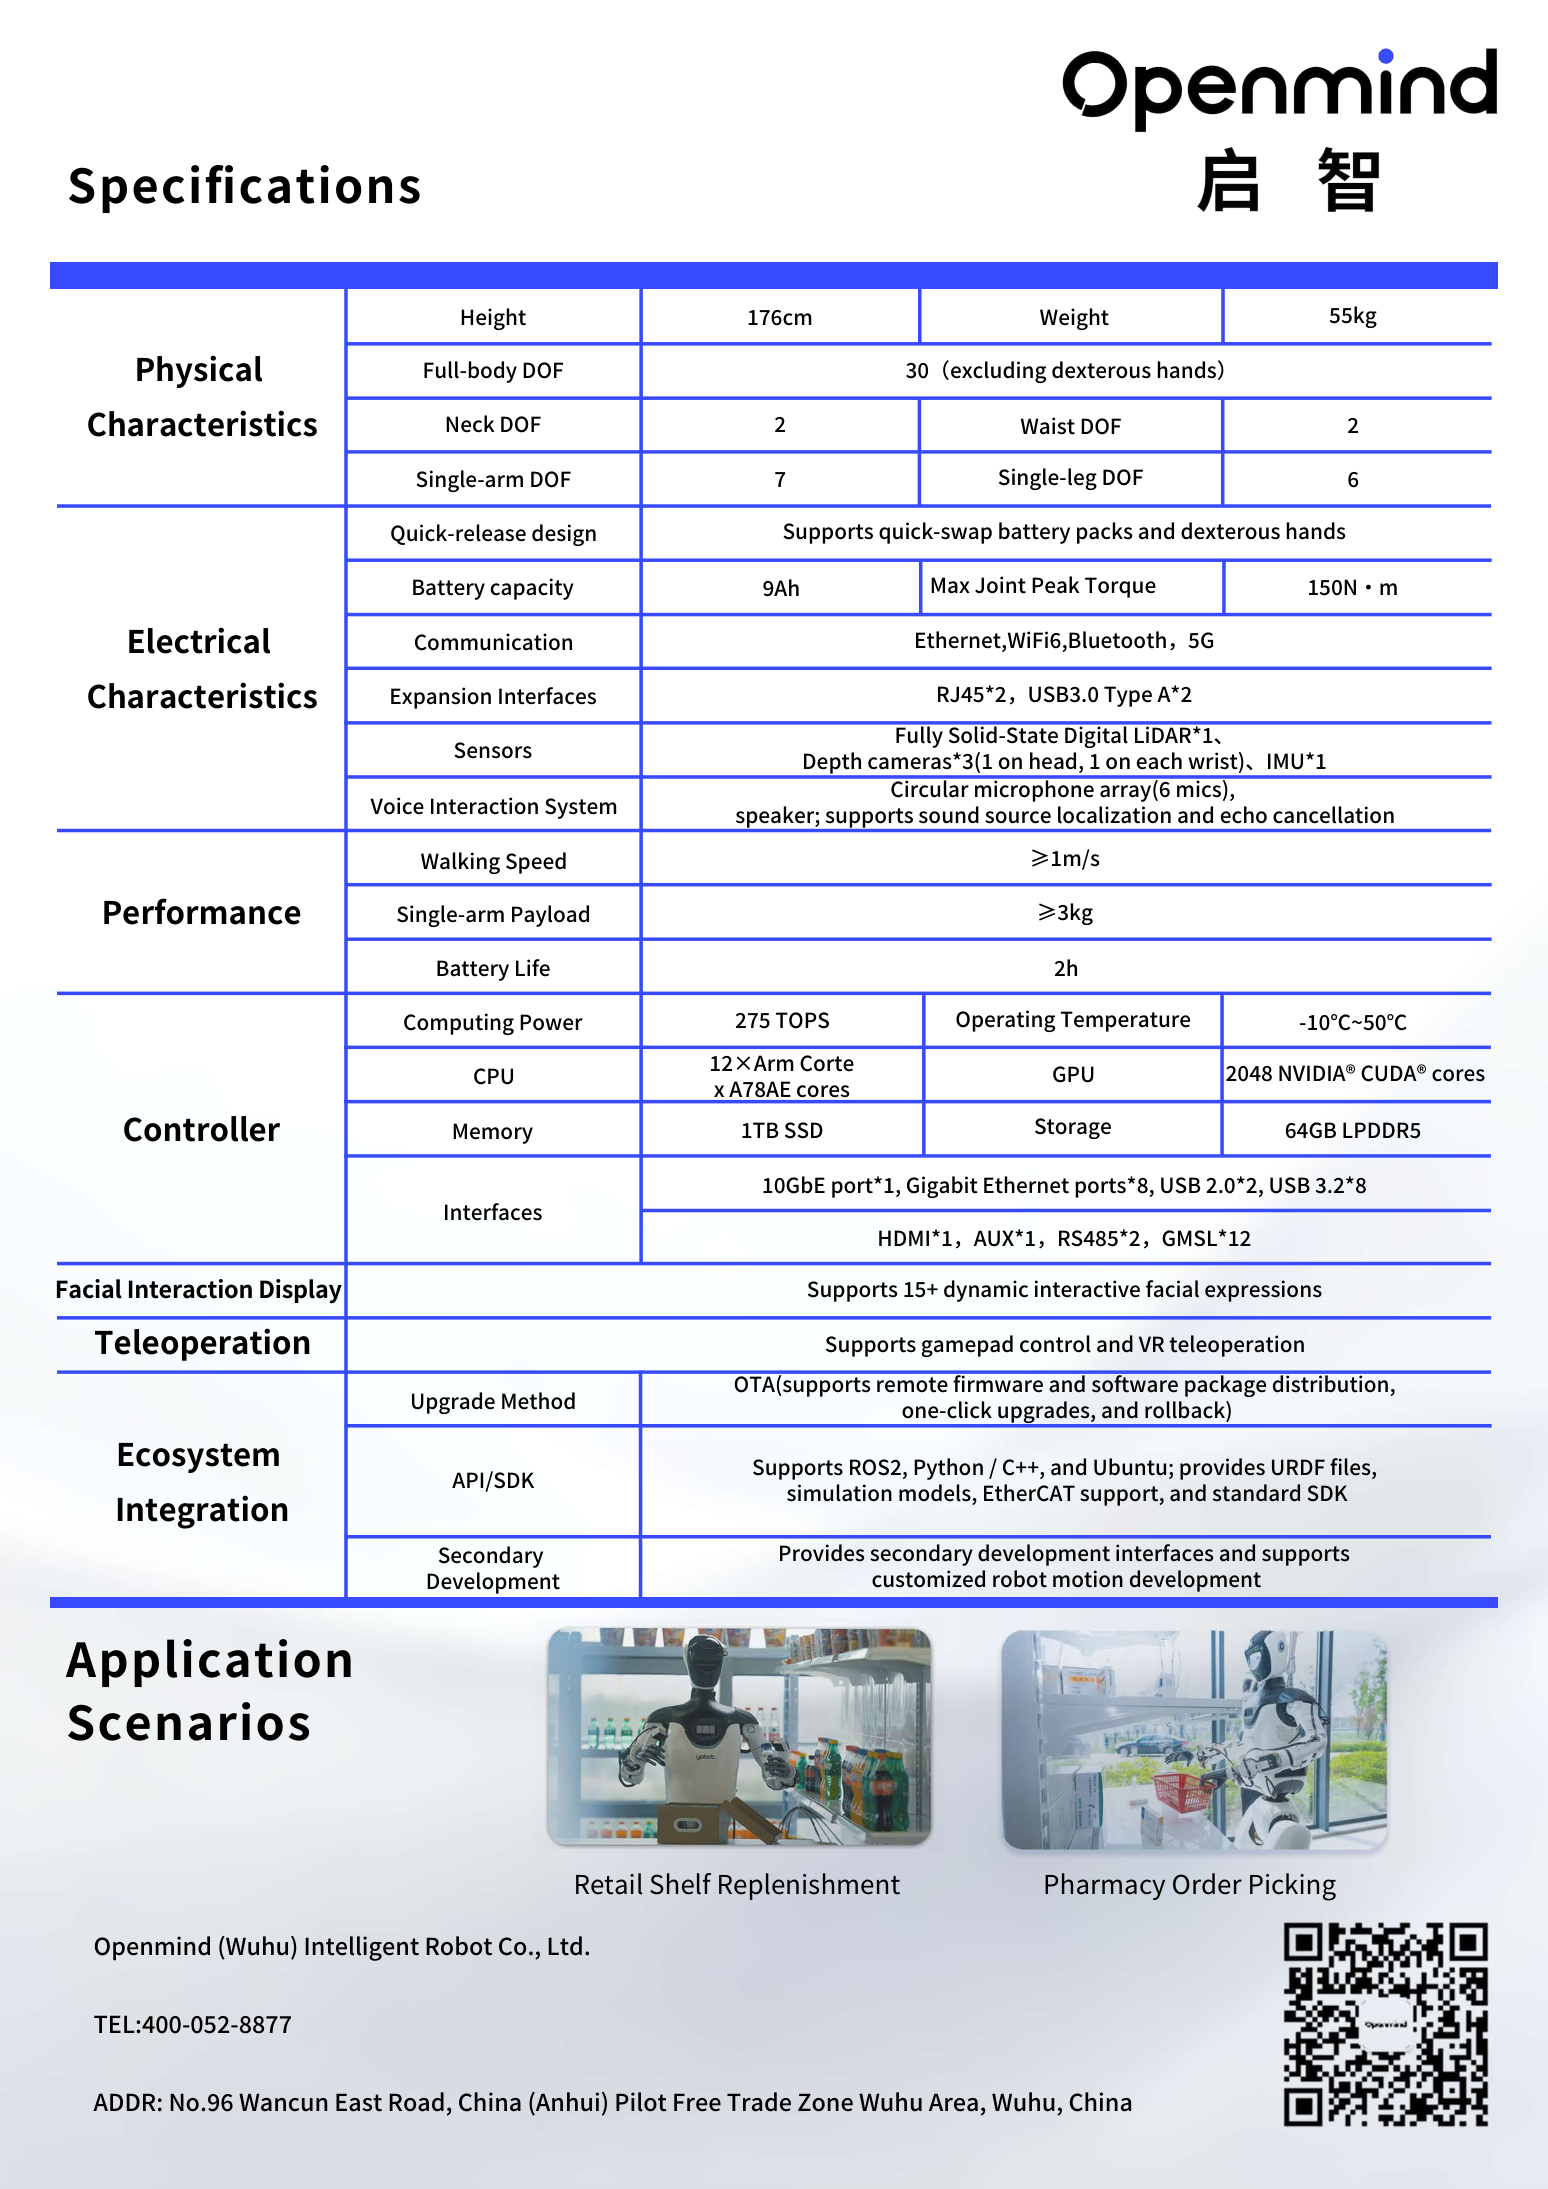
The R2V2 is the hard-working member of the yobot family, built for high-intensity operations rather than demonstrations. Its whole-body coordinated control algorithm deliberately breaks the usual separation between locomotion and manipulation, so walking and working become one motion instead of two modes — the robot can move and manipulate at the same time. On top of that sits a general-purpose visual understanding system and an atomic skill library, which is what lets it generalise across object categories and scenarios instead of being programmed per task. At 176 cm and 55 kg it carries thirty degrees of freedom excluding the hands: two in the neck, two at the waist, seven per arm and six per leg, with joints peaking at 150 N·m and each arm rated for 3 kg. Perception runs on a fully solid-state digital LiDAR and three depth cameras — one in the head, one on each wrist — feeding 275 TOPS of compute across twelve Arm Cortex-A78AE cores and 2,048 CUDA cores. A six-microphone circular array with sound-source localisation and echo cancellation handles voice, and a facial display carries more than fifteen dynamic expressions.
功能特点
- 30 degrees of freedom excluding dexterous hands — neck 2, waist 2, arms 7 each, legs 6 each
- whole-body coordinated control that merges locomotion and manipulation
- general-purpose visual understanding system with an atomic skill library for generalised manipulation
- 150 N·m maximum joint peak torque and 3 kg or more per arm
- 1 m/s walking and 2 m/s running
- 275 TOPS from 12 Arm Cortex-A78AE cores and 2,048 NVIDIA CUDA cores with 64 GB LPDDR5 and 1 TB SSD
- fully solid-state digital LiDAR plus three depth cameras (head and both wrists) and an IMU
- six-microphone circular array with sound-source localisation and echo cancellation
- facial interactive display with 15+ dynamic expressions
- quick-swap battery packs and dexterous hands
- gamepad and VR teleoperation
- ROS 2, Python and C++ on Ubuntu with URDF files, simulation models, EtherCAT support and a standard SDK
- OTA updates with one-click upgrade and rollback
- secondary-development interfaces for custom motion.
技术规格
| 物理参数 | |
| 重量 | 55 kg |
|---|---|
| 外形尺寸 | H 1.76 m |
| 负载 | 3 kg |
| 移动能力 | |
| 运动类型 | 两足行走 |
| 自由度 | 30 |
| 速度 | 3.6 km/h |
| 操作能力 | 高 |
| 作业环境 | -10°C to 50°C |
| 执行器 | 30 DoF excluding dexterous hands — neck 2, waist 2, single arm 7, single leg 6; maximum joint peak torque 150 N·m; quick-release design for battery packs and dexterous hands |
| 电源与续航 | |
| 续航时间 | 2 h |
| 感知与计算 | |
| 传感器 | fully solid-state digital LiDAR, 3x depth cameras (head, both wrists), IMU, 6-mic circular microphone array with sound-source localisation and echo cancellation, facial interactive display |
| 连接方式 | Ethernet, Wi-Fi 6, Bluetooth and 5G; RJ45 x2 and USB 3.0 Type A x2 expansion; 10 GbE x1, gigabit Ethernet x8, USB 2.0 x2, USB 3.2 x8; HDMI x1, AUX x1, RS485 x2, GMSL x12 |
| 软件 / AI | Whole-body coordinated control merging locomotion and manipulation; general-purpose visual understanding system with atomic skill library; GOPS embodied-intelligence training framework developed with Tsinghua University; ROS 2, Python and C++ on Ubuntu with URDF, simulation models, EtherCAT and standard SDK; OTA with one-click upgrade and rollback; secondary-development interfaces |
图片
 martti
 martti
 martti
图片贡献
视频
机器人论坛
正在加载论坛...
评分
常见问题
What is the yobot R2V2?
The R2V2 is the hard-working member of the yobot family, built for high-intensity operations rather than demonstrations. Its whole-body coordinated control algorithm deliberately breaks the usual separation between locomotion and manipulation, so walking and working become one motion instead of two modes — the robot ca…
Who makes the yobot R2V2?
The yobot R2V2 is made by Openmind Intelligent Robot, a robotics company based in China.
How much does the yobot R2V2 cost?
Openmind Intelligent Robot has not publicly announced pricing for the yobot R2V2. You can enquire through RobotAIGeek for current pricing.
What is the yobot R2V2 used for?
The yobot R2V2 is designed for 拾放, retail shelf replenishment, pharmacy order picking, and generalised mobile manipulation. It is used in 研究, 医疗保健, 物流, and 零售 settings.
What is the payload capacity of the yobot R2V2?
The yobot R2V2 has a payload capacity of 3 kg.
How much does the yobot R2V2 weigh?
The yobot R2V2 weighs 55 kg.
How fast is the yobot R2V2?
The yobot R2V2 can move at speeds of up to 3.6 km/h.
What is the battery life of the yobot R2V2?
The yobot R2V2 runs for 2 h on a charge.
与同类机器人对比
看看这款机器人与最接近的同类产品相比表现如何
- yobot R2V2 vs KUAVO 5 / 5-W
- yobot R2V2 vs RoBee
- yobot R2V2 vs RAISE A1
- yobot R2V2 vs AELOS SMART
- yobot R2V2 vs Unitree G1