

描述
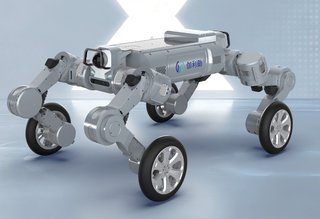
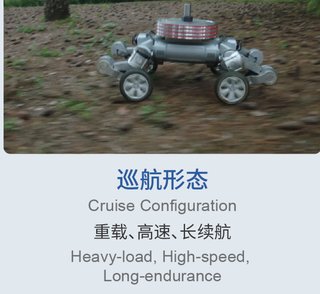
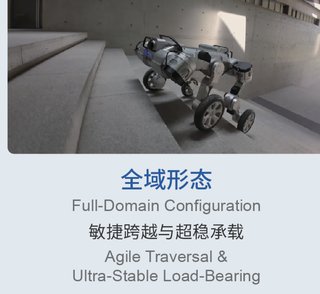
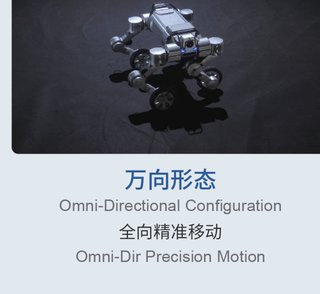
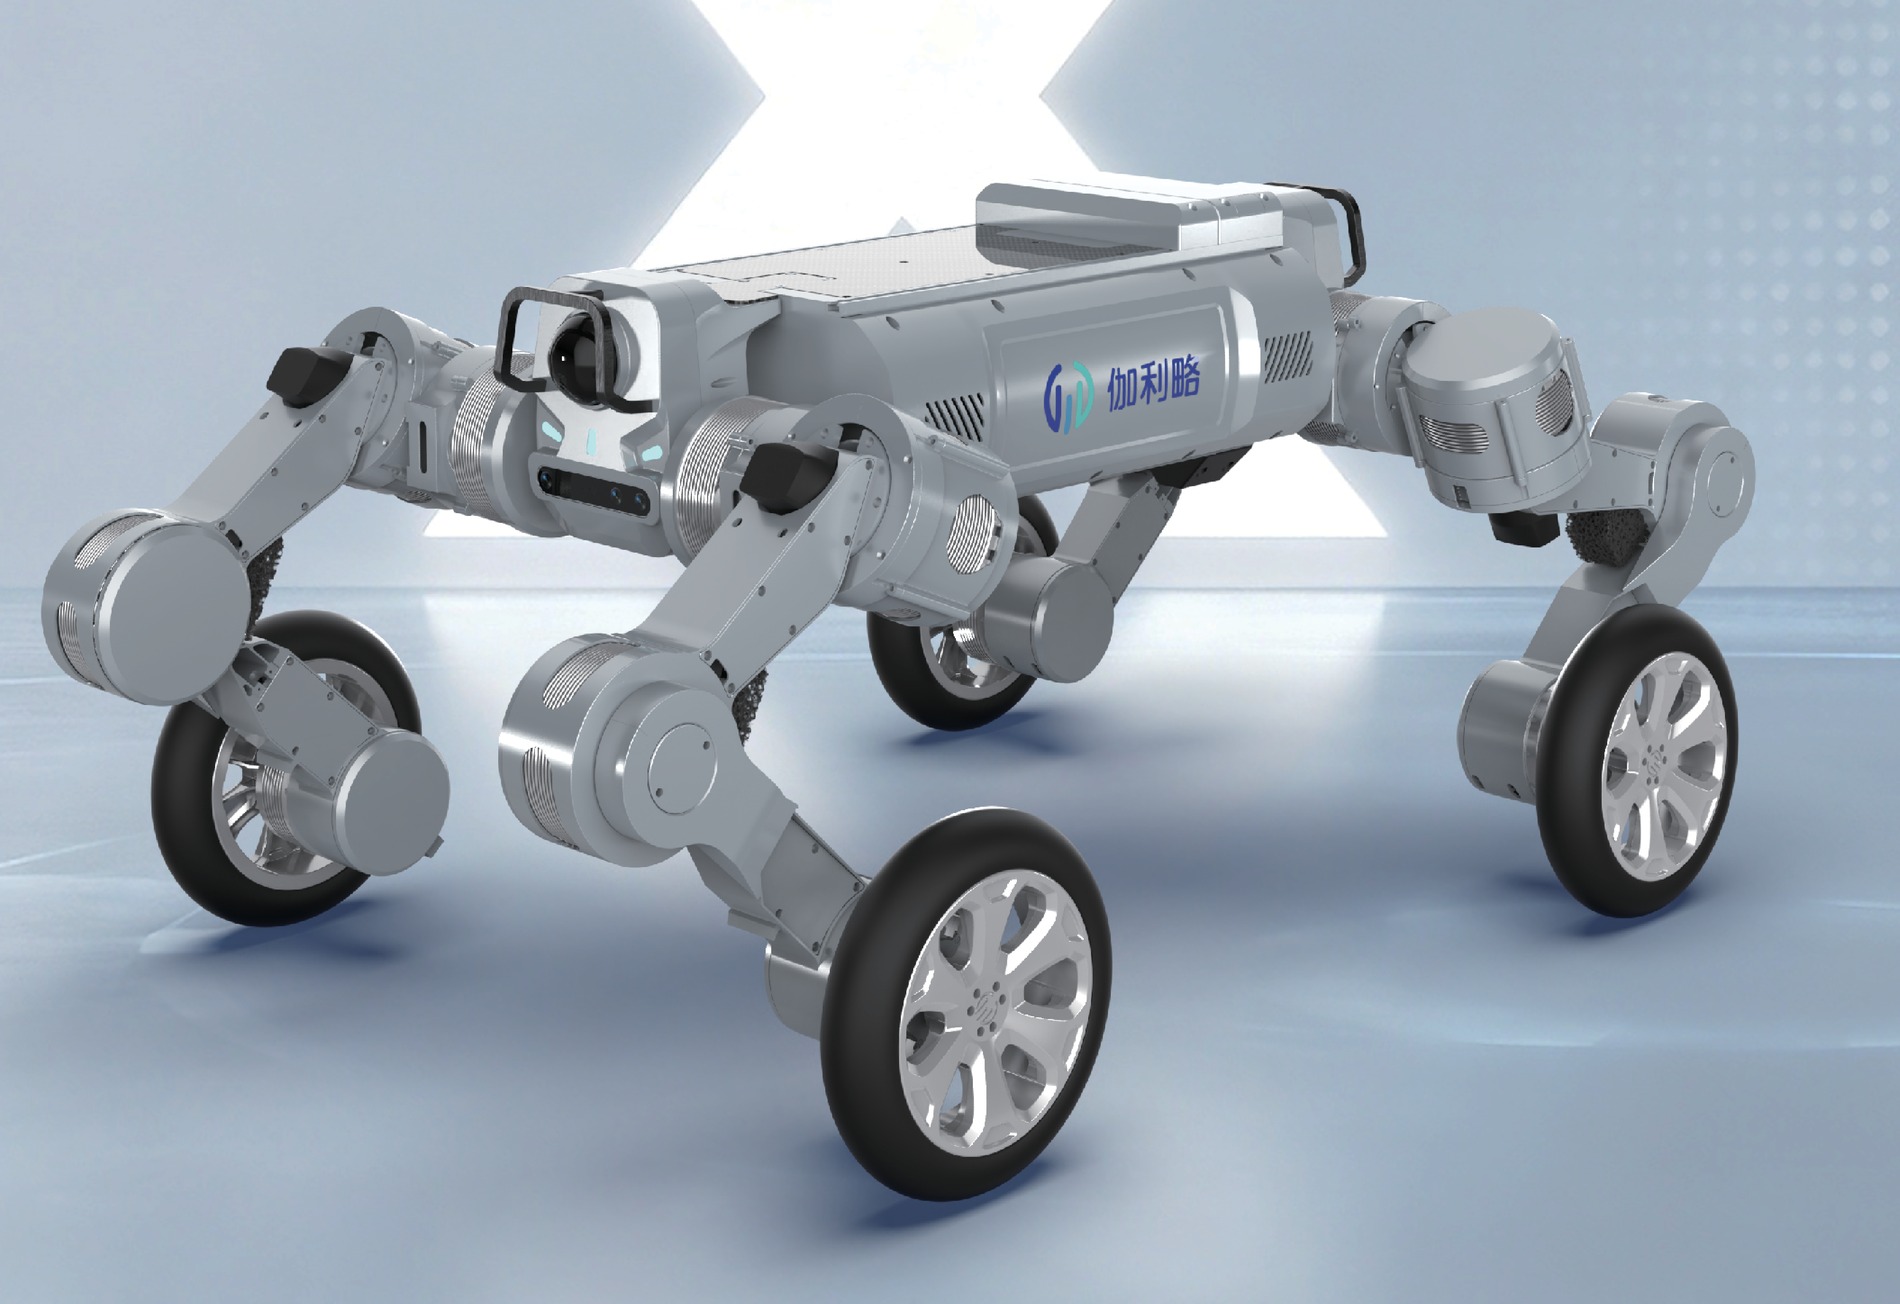
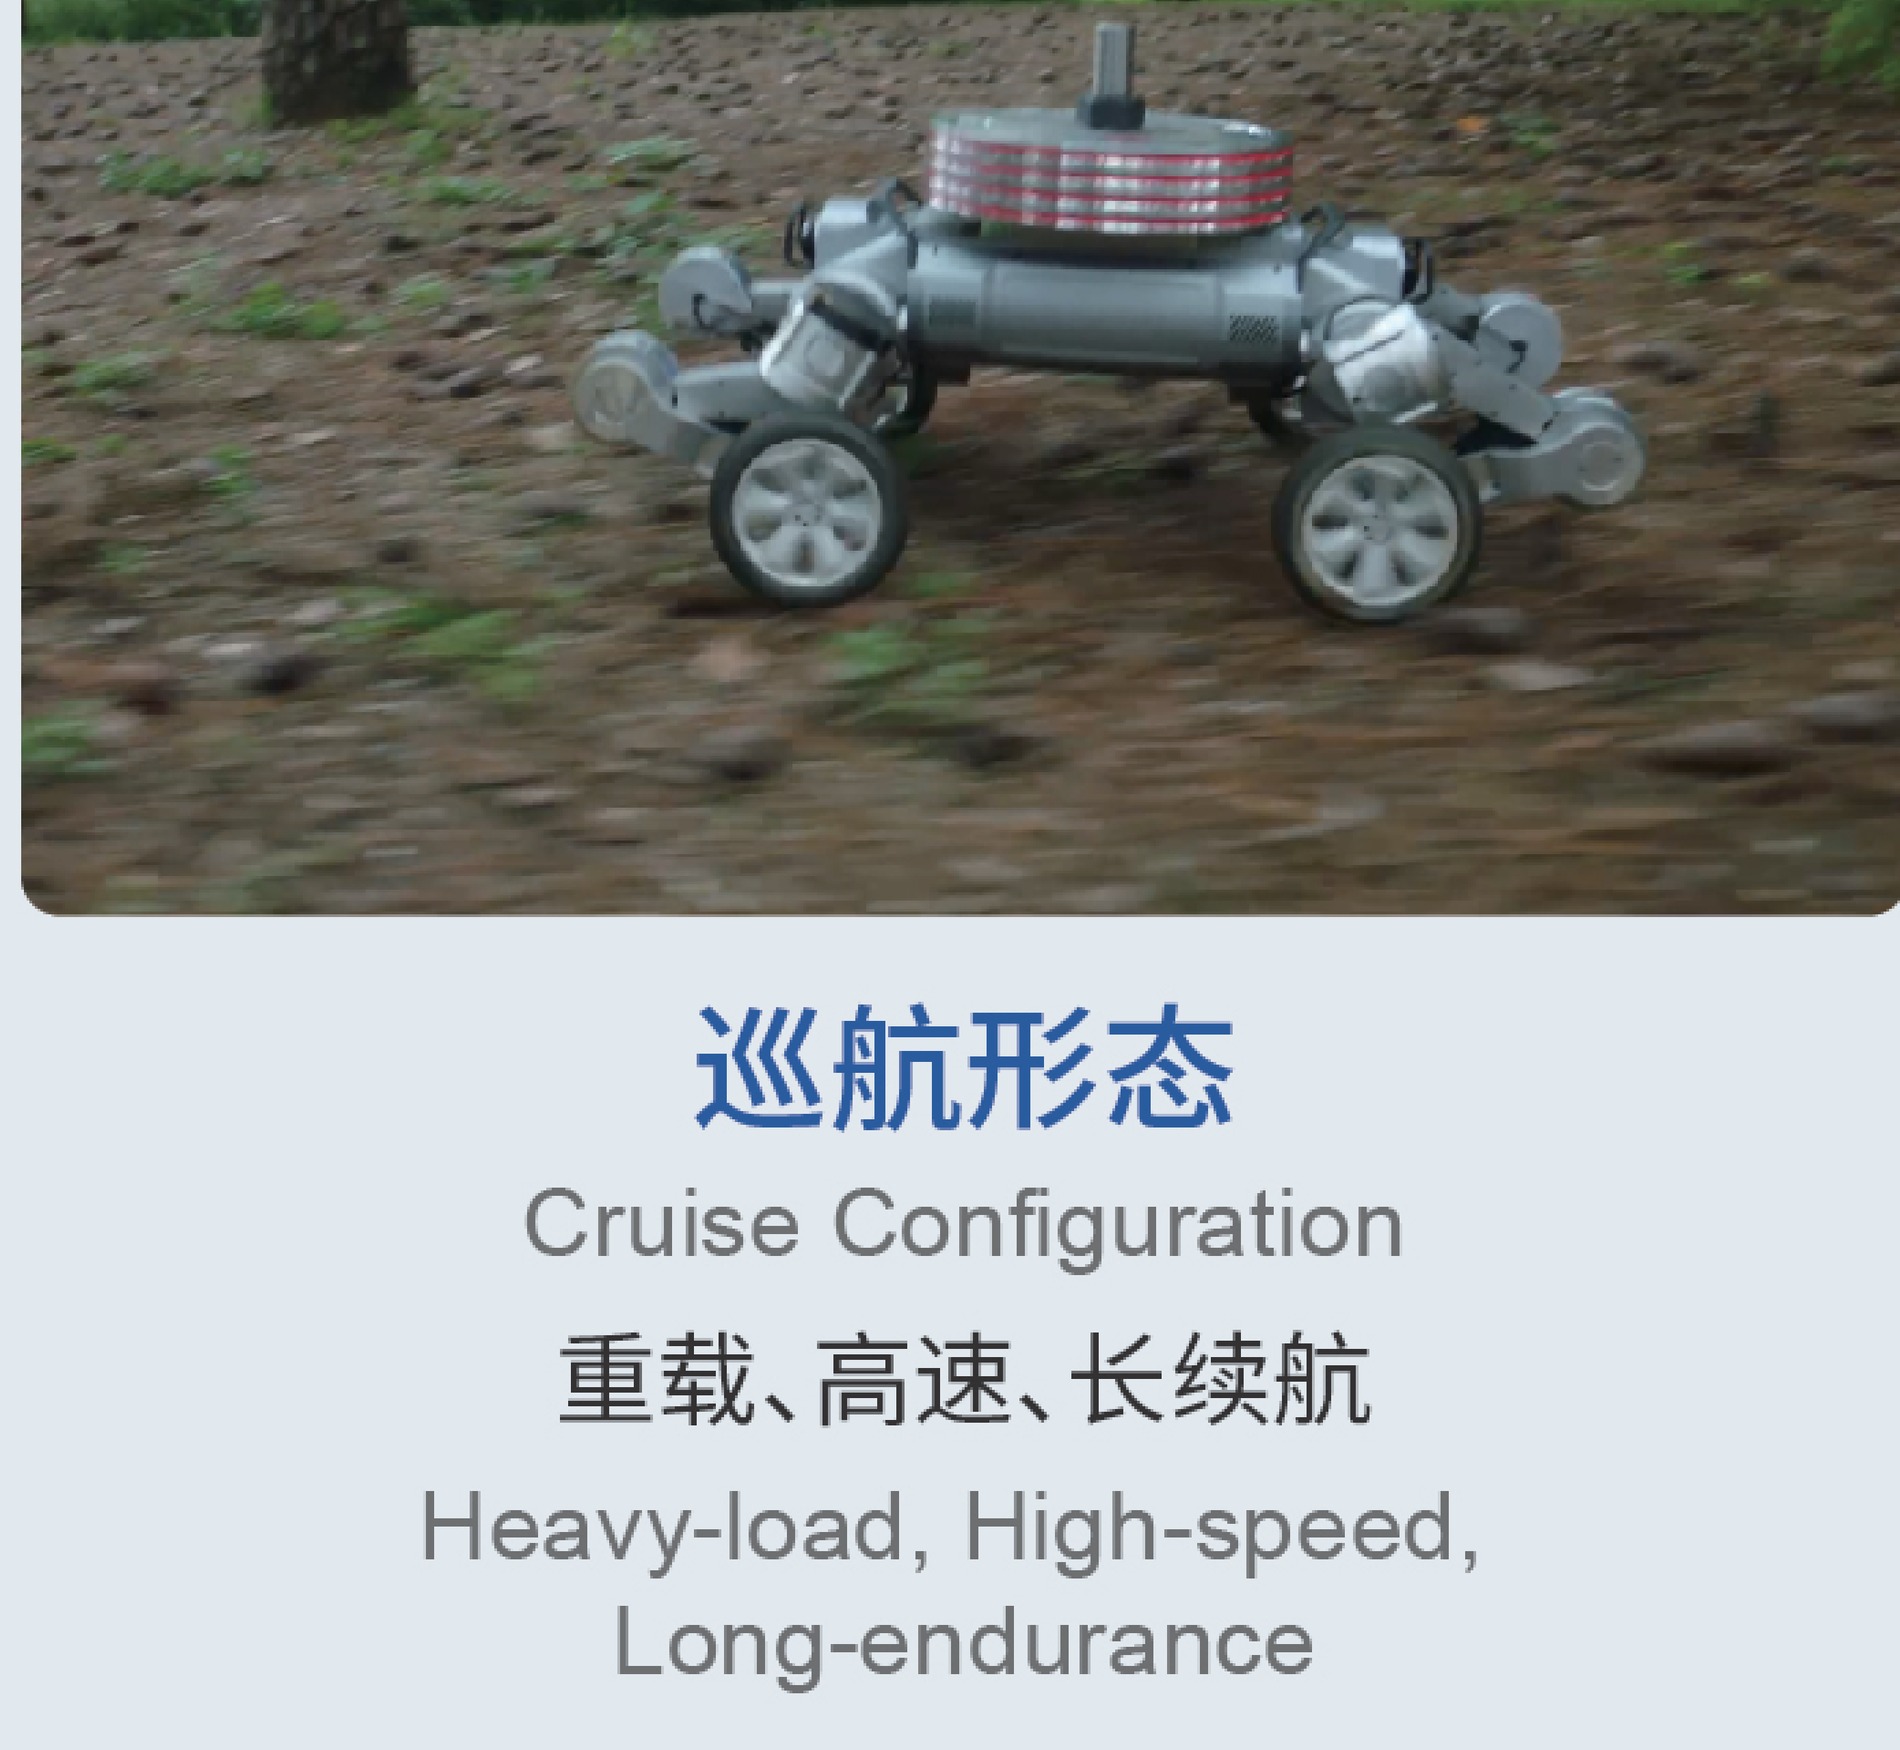
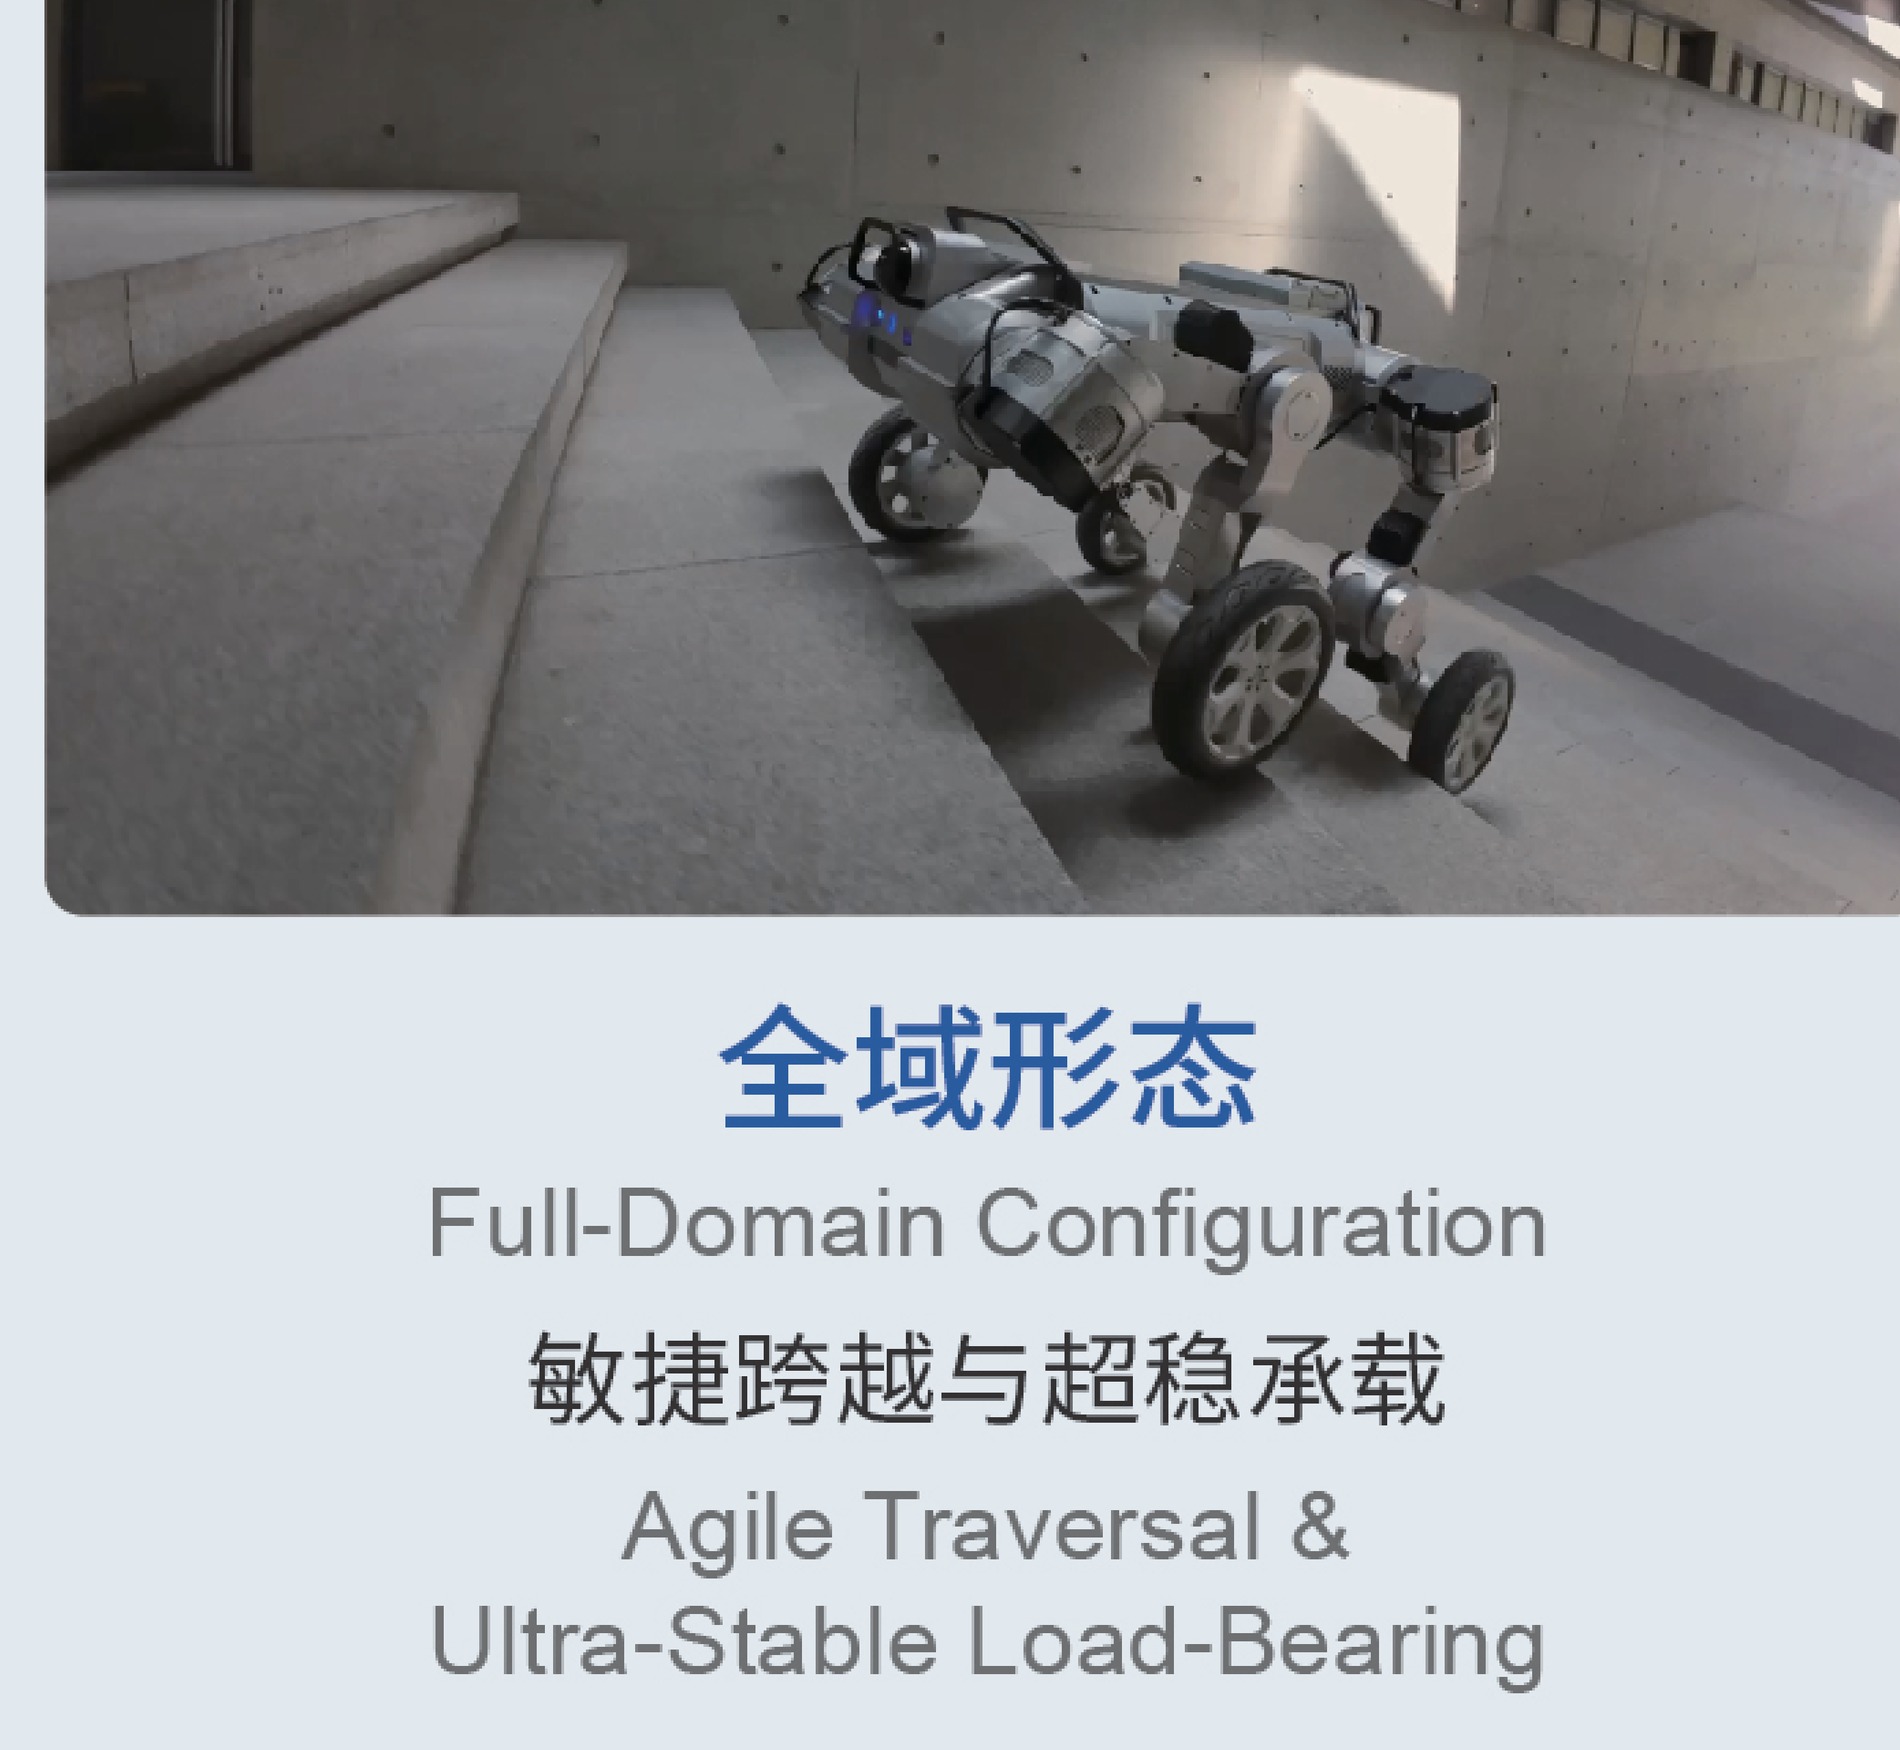
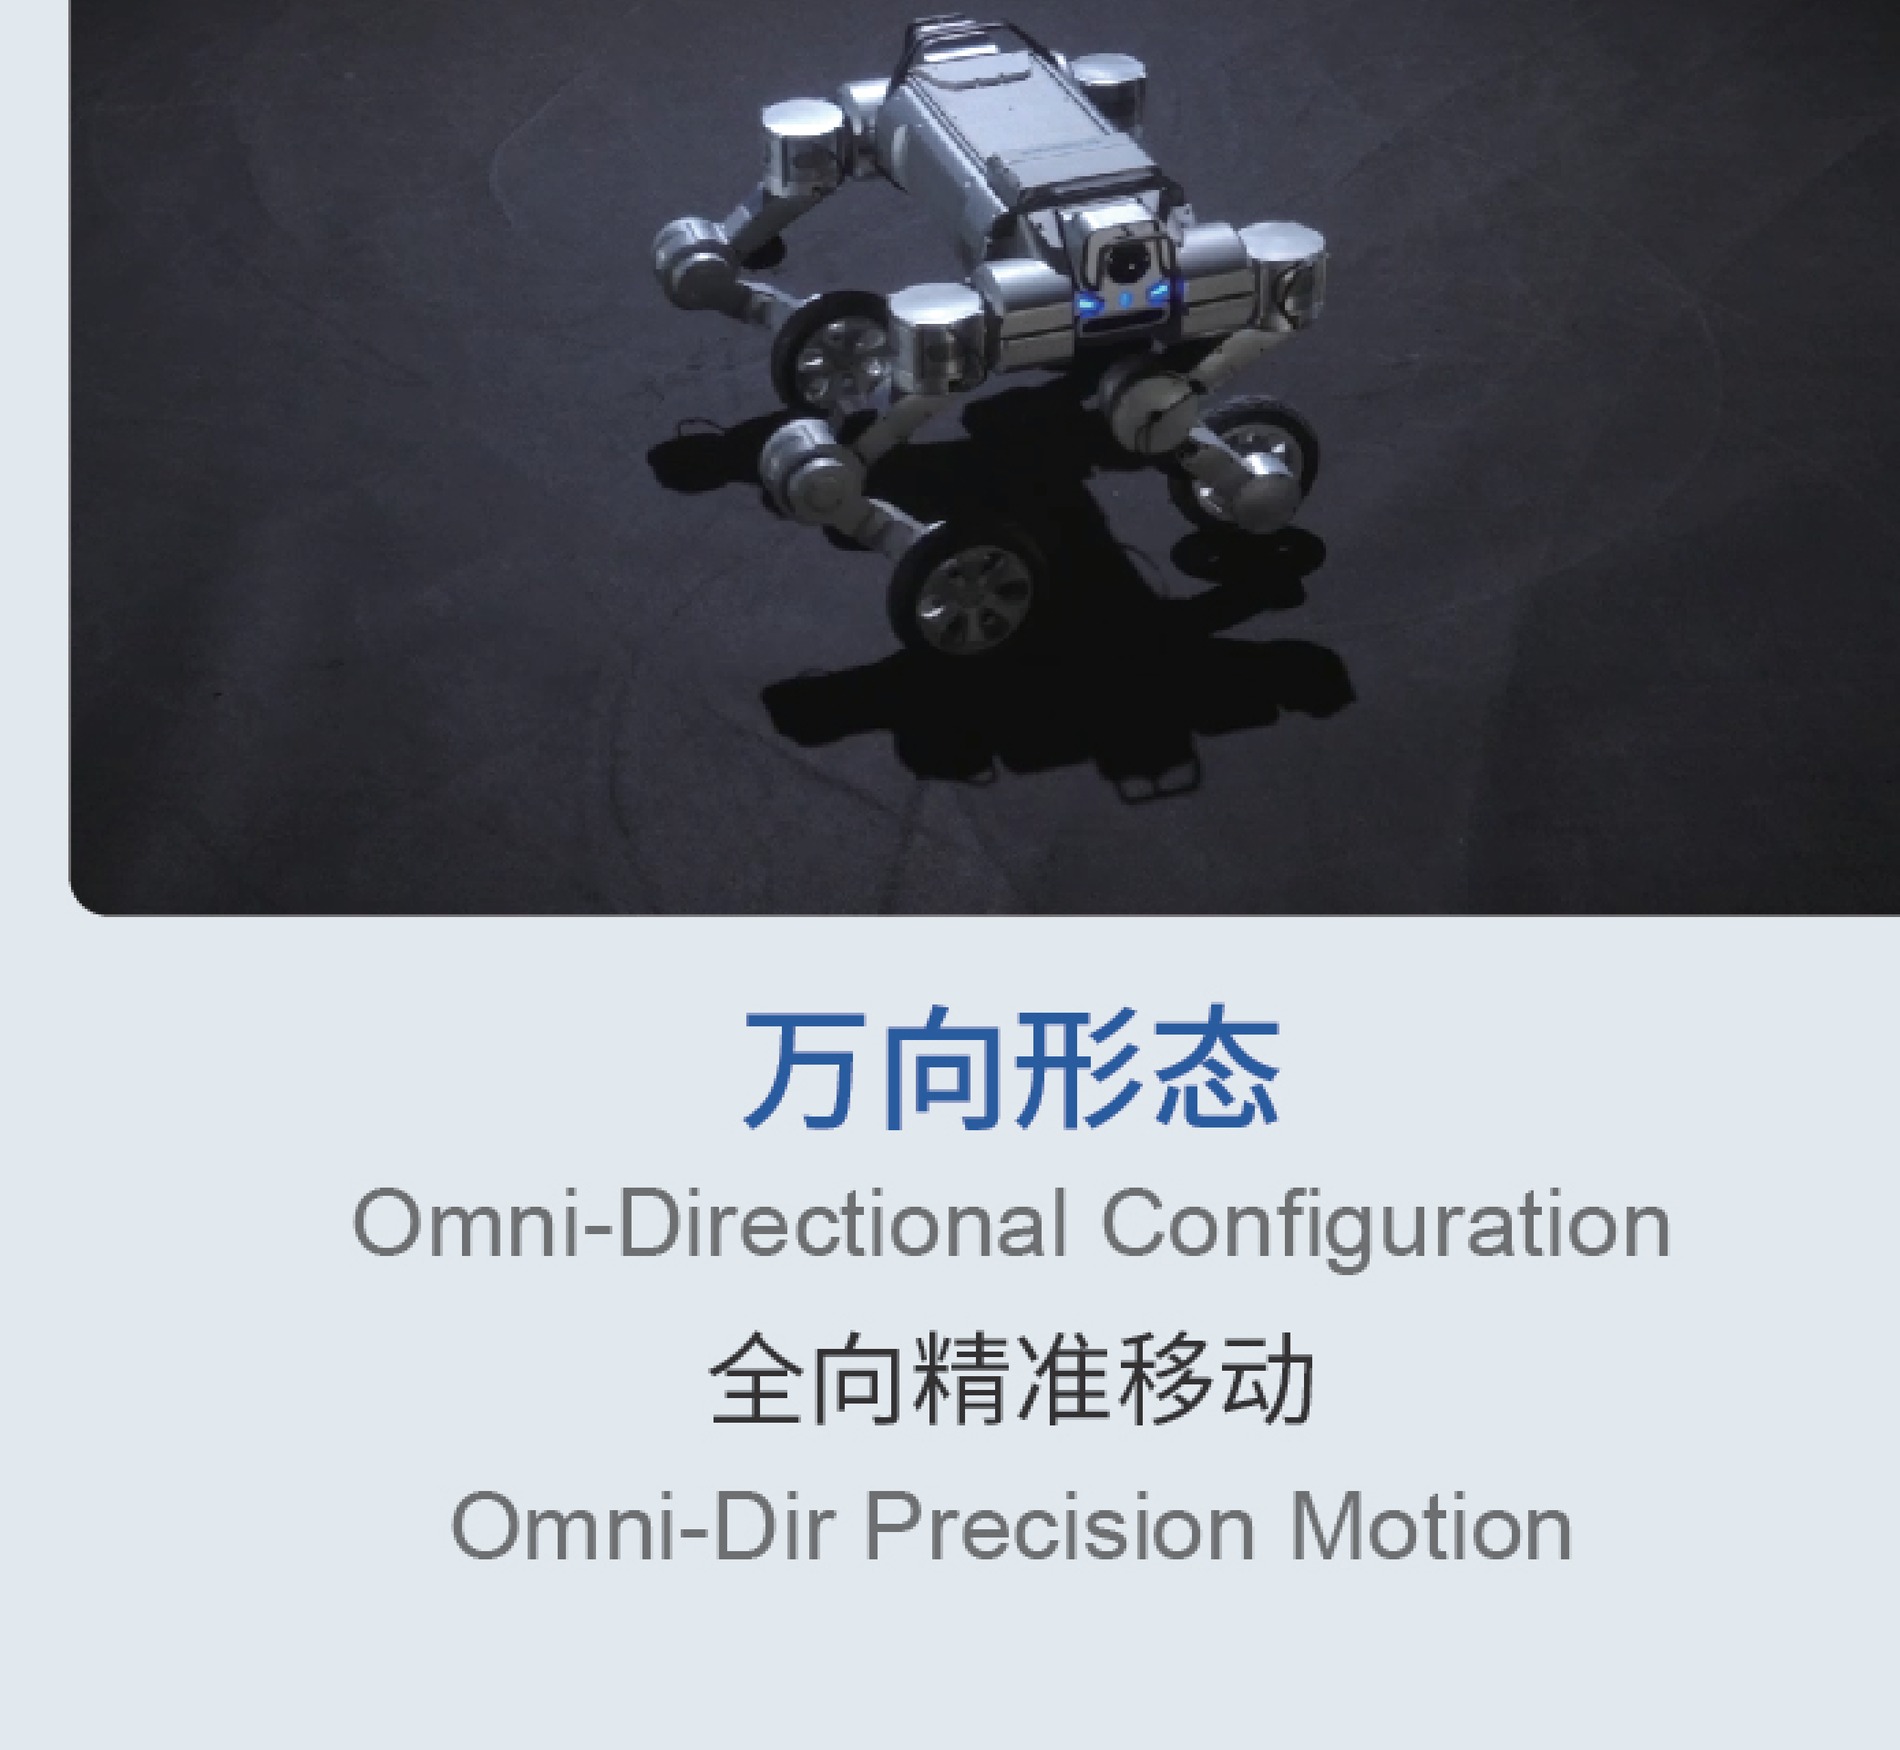
Galileo X is the company's variable-configuration terrestrial platform, and its premise is that a robot should not have to commit to one body plan. The same machine switches between three basic configurations: a cruise form for heavy loads, high speed and long endurance; a full-domain form for agile traversal and ultra-stable load-bearing; and an omni-directional form for precise movement in any direction. Two pieces of engineering make that practical. The first is a composite active suspension built from meta-structural elastic units working with the joint motors, which lets the chassis absorb terrain rather than fight it. The second is more unusual: every system joint rotates a full 360 degrees continuously, with no conventional mechanical end stops, so a limb can roll through a change of configuration instead of unwinding first. A unified base model orchestrates vision, environment, terrain, posture, motion, load and mission objectives together. Galileo aims it at ground transport, warehouse transfer, complex-terrain traversal, stair negotiation, heavy-load cruising and stable load-bearing.
功能特点
- Variable-configuration platform switching between three basic forms according to environment, mission and load
- Cruise configuration for heavy load, high speed and long endurance
- Full-domain configuration for agile traversal and ultra-stable load-bearing
- Omni-directional configuration for omni-directional precision motion
- Composite active suspension built from meta-structural elastic units working together with the joint motors
- Endless-rotation joints giving 360 degrees of continuous rotation with no conventional mechanical limits
- Unified base model orchestrating vision, environment, terrain, posture, motion, load and mission objectives
- Multi-modal embodied intelligence algorithms
- Targeted at ground transportation, warehouse transfer, complex-terrain traversal, stair negotiation, heavy-load cruising and stable load-bearing
技术规格
| 移动能力 | |
| 运动类型 | 带轮的, 混合型 |
|---|---|
| 执行器 | Variable-configuration wheel-legged chassis with composite active suspension from meta-structural elastic units and joint motors; endless-rotation joints with 360 degrees of continuous travel |
| 感知与计算 | |
| 软件 / AI | Multi-modal embodied intelligence algorithms with a unified base model orchestrating vision, environment, terrain, posture, motion, load and mission objectives |
图片
 martti
 martti
 martti
 martti
图片贡献
视频
机器人论坛
正在加载论坛...
评分
常见问题
What is the Galileo X?
Galileo X is the company's variable-configuration terrestrial platform, and its premise is that a robot should not have to commit to one body plan.
Who makes the Galileo X?
The Galileo X is made by Galileo Technology, a robotics company based in China.
How much does the Galileo X cost?
Galileo Technology has not publicly announced pricing for the Galileo X. You can enquire through RobotAIGeek for current pricing.
What is the Galileo X used for?
The Galileo X is designed for 研究, 运输, ground transportation, and warehouse transfer. It is used in 研究, 物流, and 制造业 settings.
与同类机器人对比
看看这款机器人与最接近的同类产品相比表现如何
- Galileo X vs Vision 60
- Galileo X vs Honey Badger 5.0
- Galileo X vs TRACER 2.0
- Galileo X vs BUNKER MINI 2.0
- Galileo X vs SCOUT 2.0