

BESCHREIBUNG
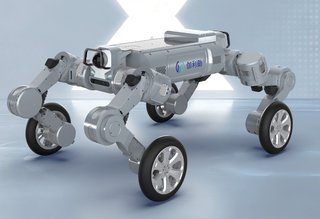
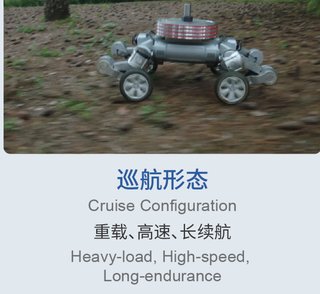
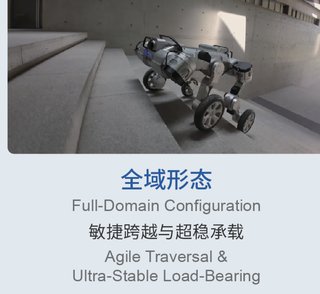
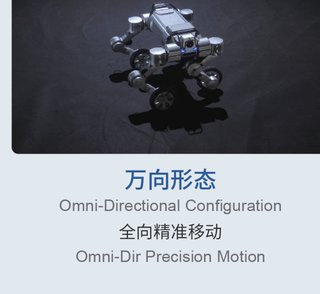
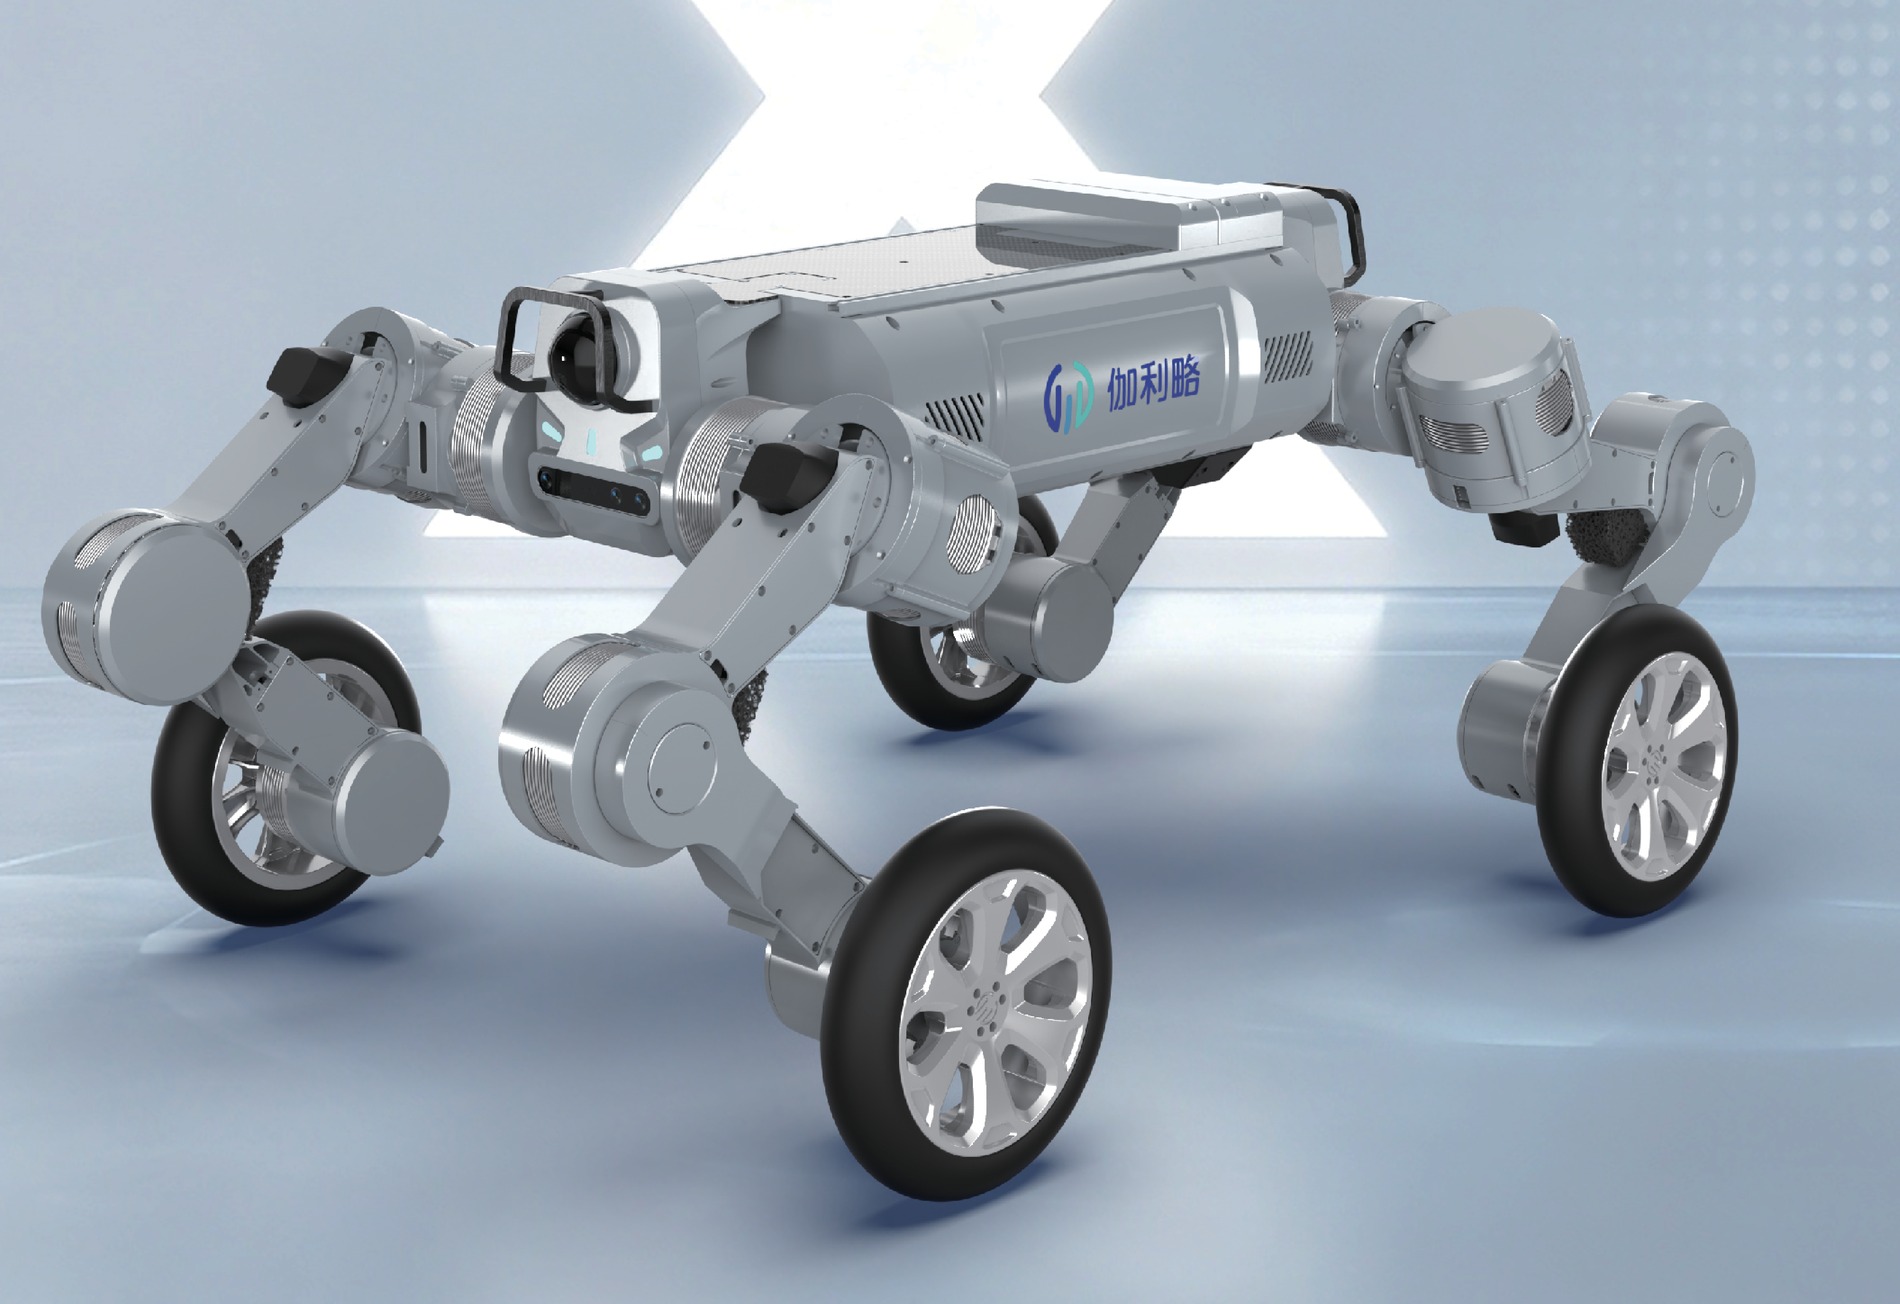
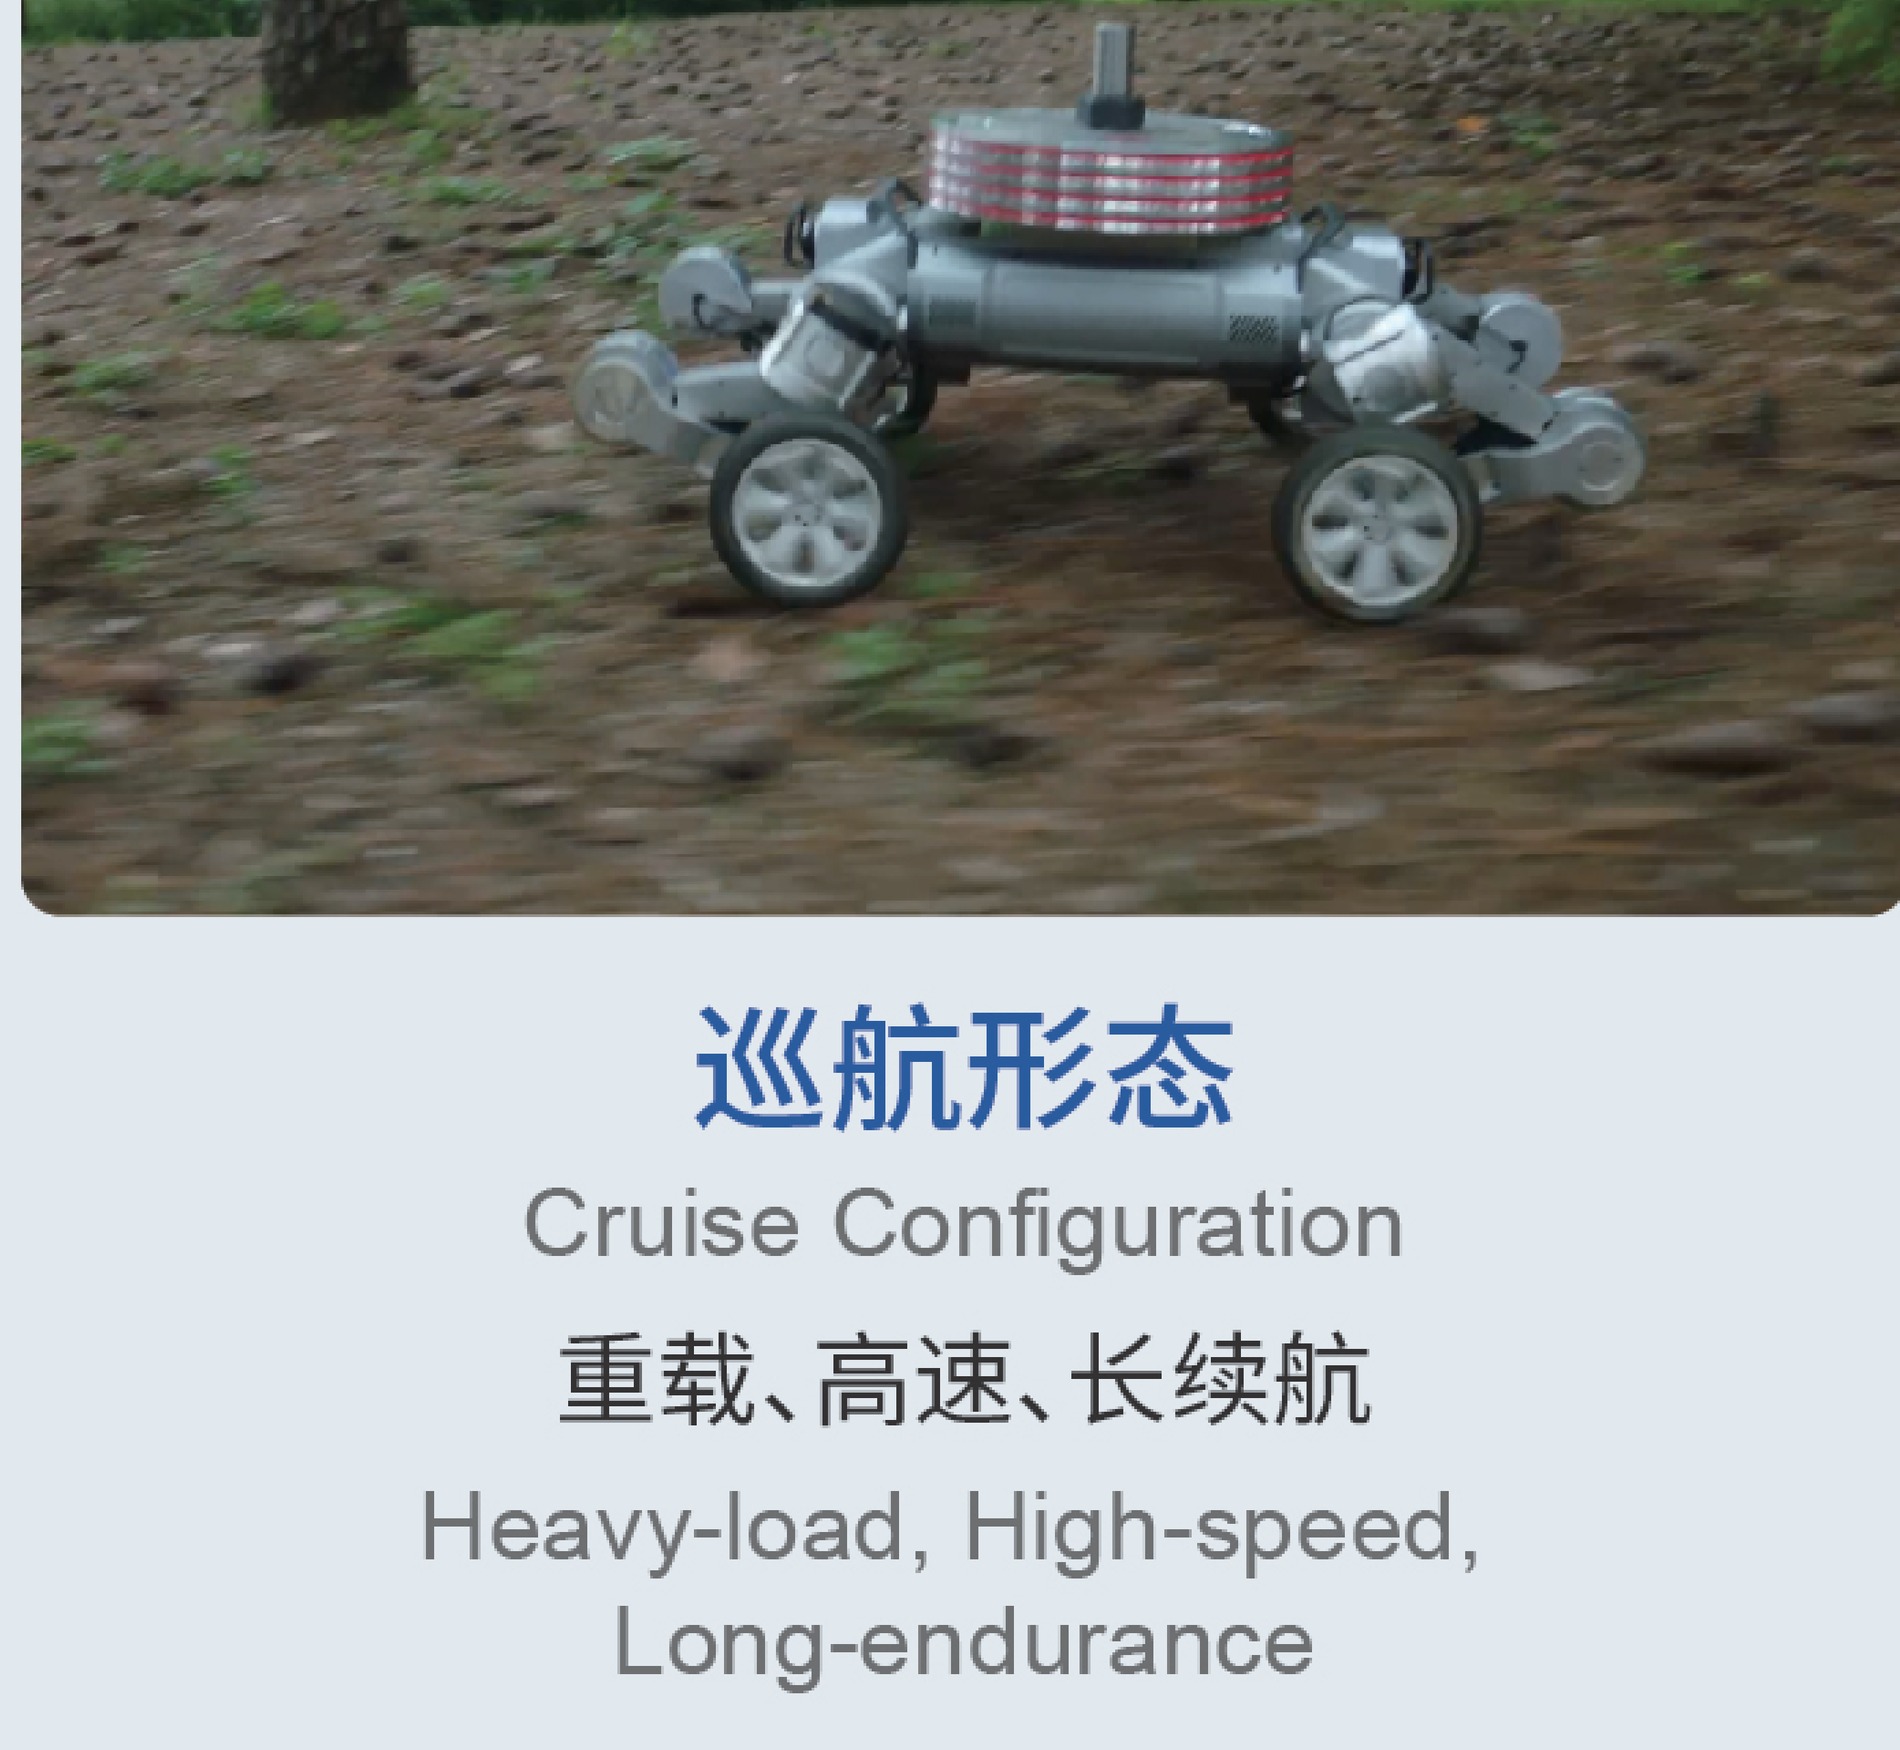
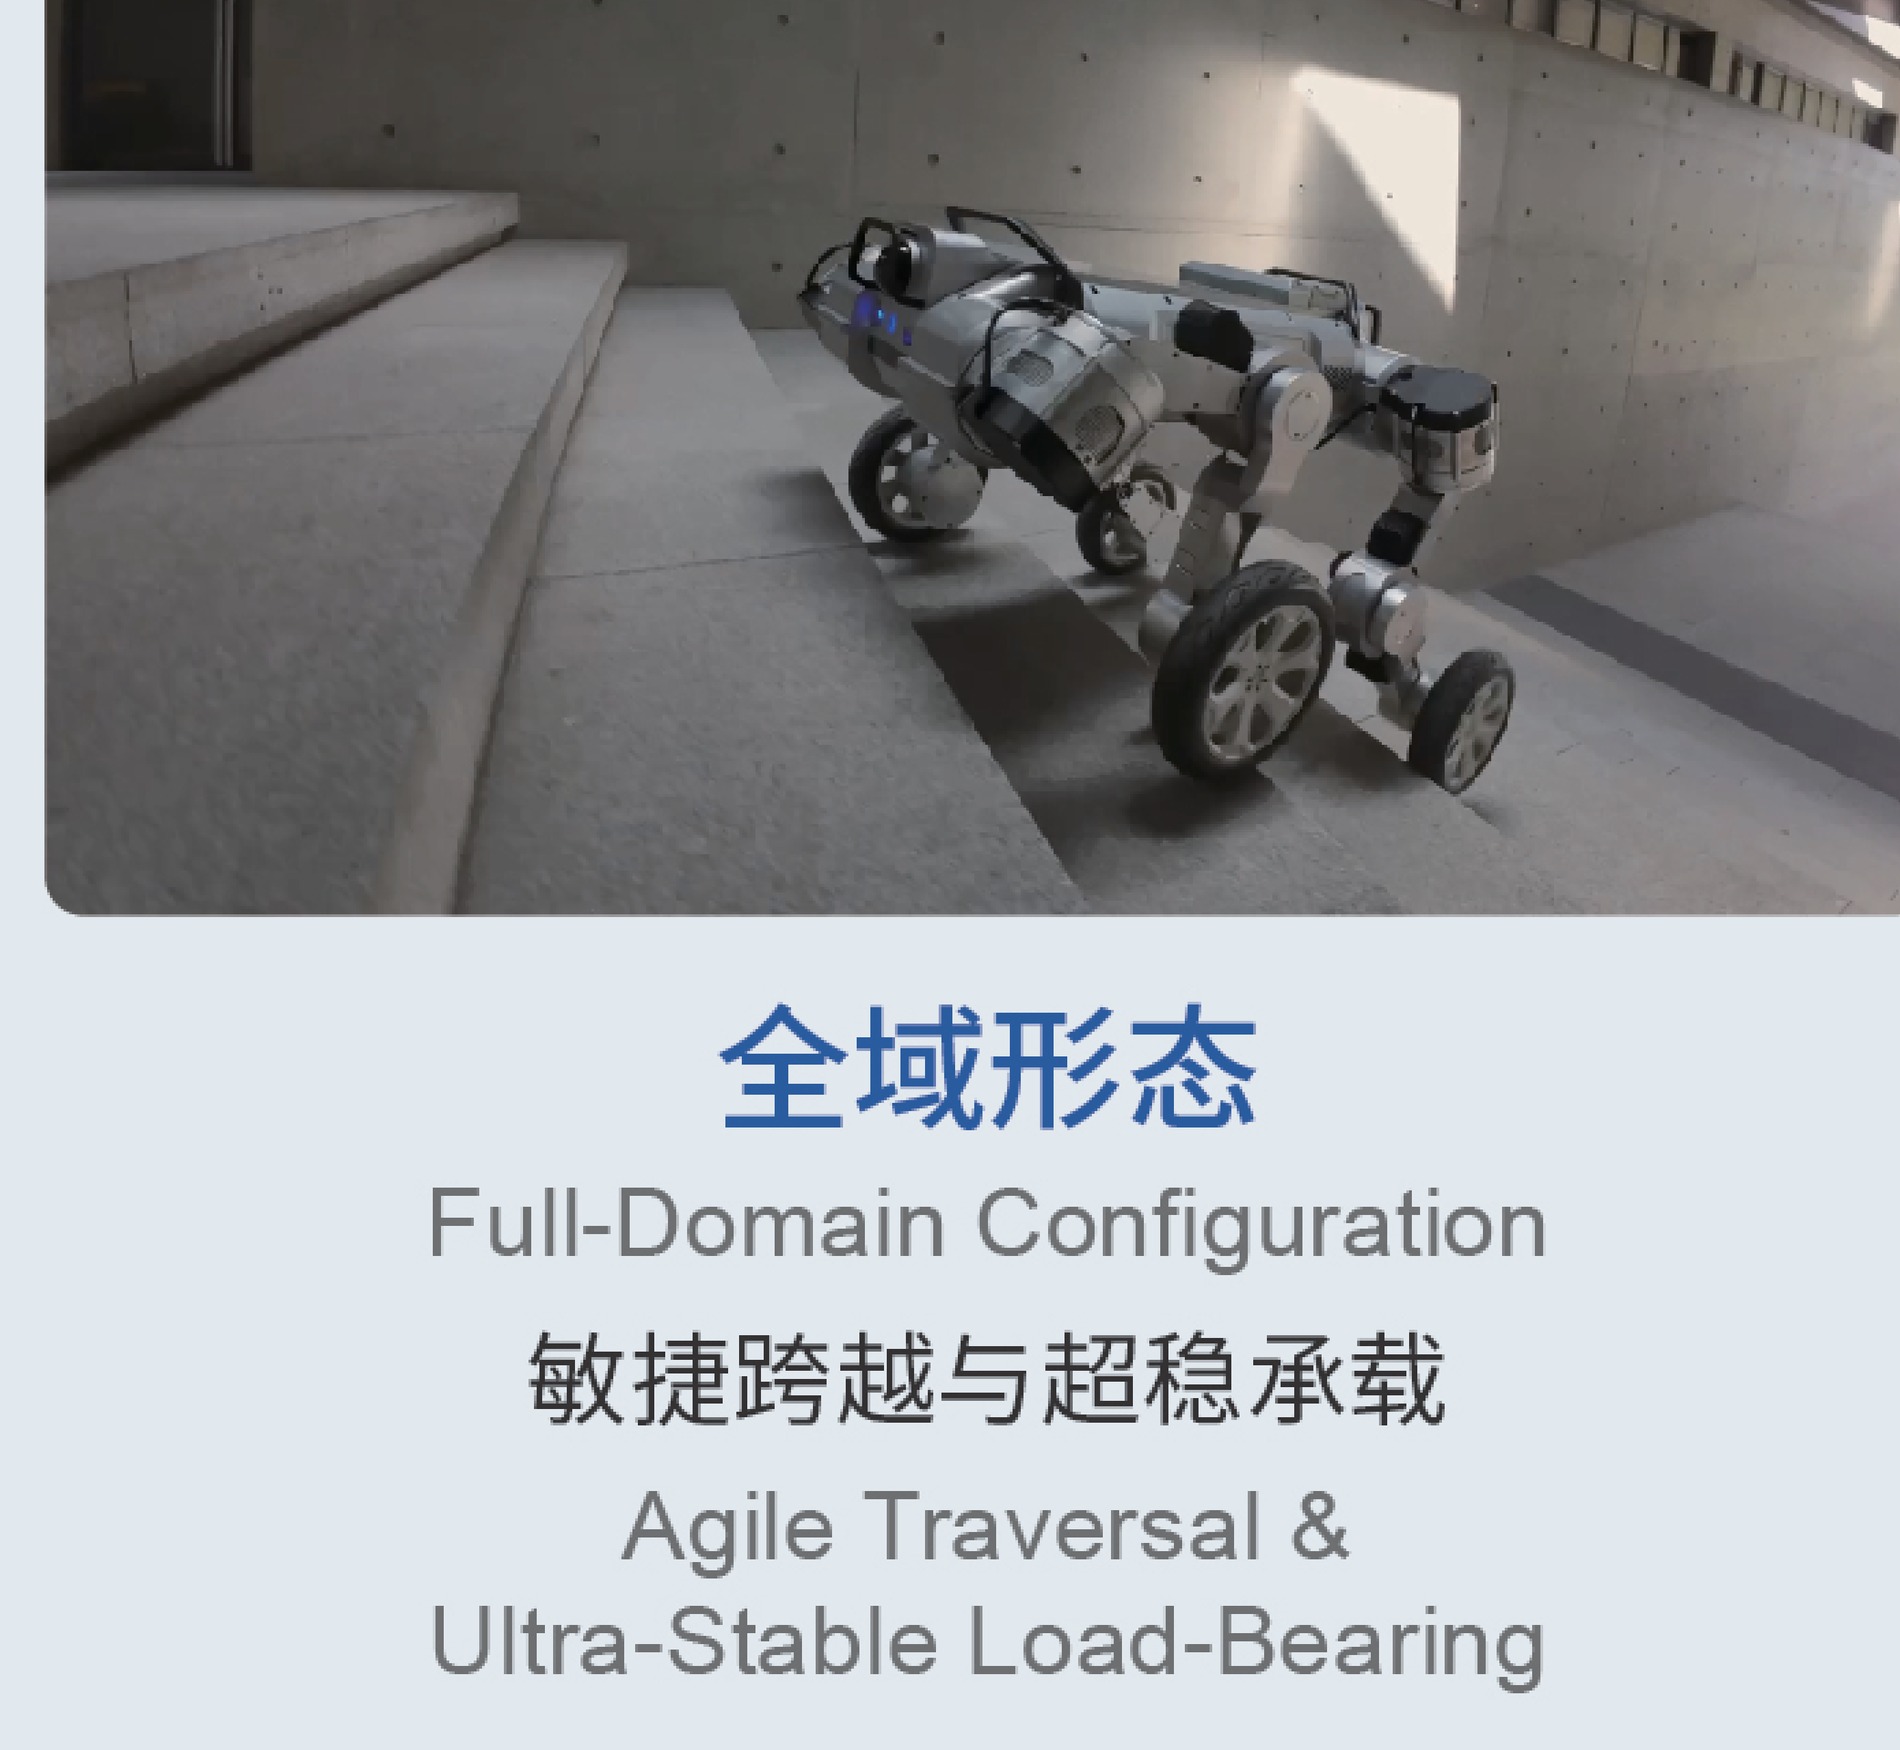
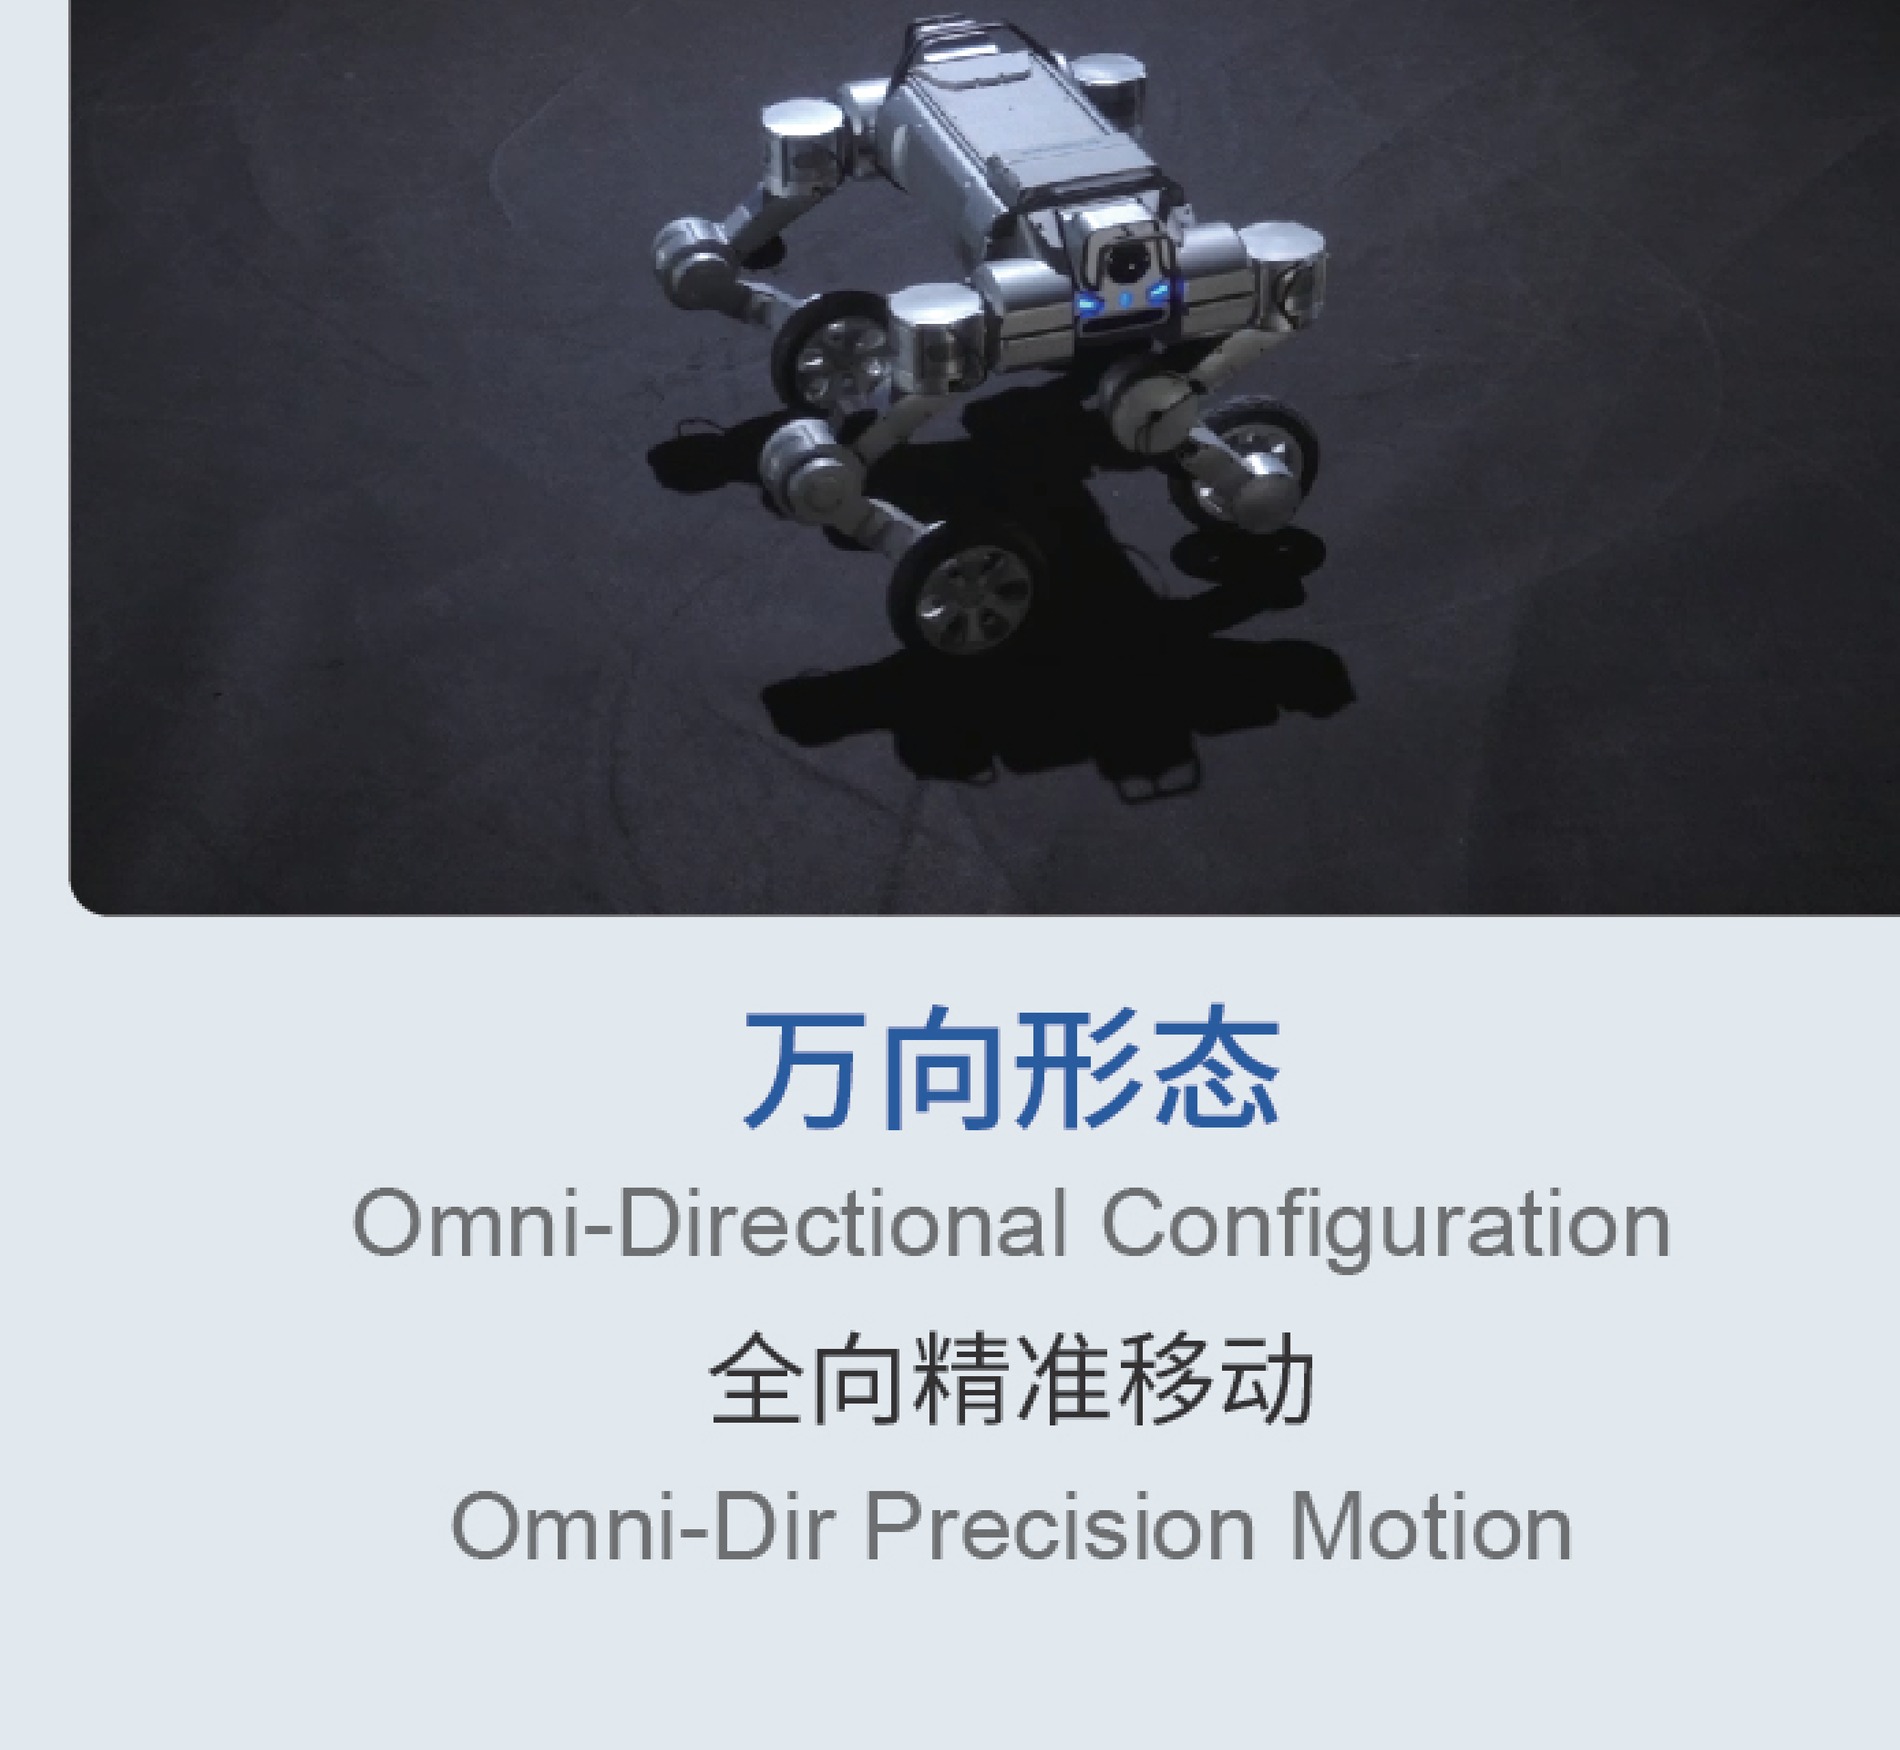
Galileo X is the company's variable-configuration terrestrial platform, and its premise is that a robot should not have to commit to one body plan. The same machine switches between three basic configurations: a cruise form for heavy loads, high speed and long endurance; a full-domain form for agile traversal and ultra-stable load-bearing; and an omni-directional form for precise movement in any direction. Two pieces of engineering make that practical. The first is a composite active suspension built from meta-structural elastic units working with the joint motors, which lets the chassis absorb terrain rather than fight it. The second is more unusual: every system joint rotates a full 360 degrees continuously, with no conventional mechanical end stops, so a limb can roll through a change of configuration instead of unwinding first. A unified base model orchestrates vision, environment, terrain, posture, motion, load and mission objectives together. Galileo aims it at ground transport, warehouse transfer, complex-terrain traversal, stair negotiation, heavy-load cruising and stable load-bearing.
FUNKTIONEN
- Variable-configuration platform switching between three basic forms according to environment, mission and load
- Cruise configuration for heavy load, high speed and long endurance
- Full-domain configuration for agile traversal and ultra-stable load-bearing
- Omni-directional configuration for omni-directional precision motion
- Composite active suspension built from meta-structural elastic units working together with the joint motors
- Endless-rotation joints giving 360 degrees of continuous rotation with no conventional mechanical limits
- Unified base model orchestrating vision, environment, terrain, posture, motion, load and mission objectives
- Multi-modal embodied intelligence algorithms
- Targeted at ground transportation, warehouse transfer, complex-terrain traversal, stair negotiation, heavy-load cruising and stable load-bearing
TECHNISCHE DATEN
| Mobilität | |
| Bewegungsart | Radbasiert, Hybrid |
|---|---|
| Aktoren | Variable-configuration wheel-legged chassis with composite active suspension from meta-structural elastic units and joint motors; endless-rotation joints with 360 degrees of continuous travel |
| Sensorik & Rechenleistung | |
| Software / KI | Multi-modal embodied intelligence algorithms with a unified base model orchestrating vision, environment, terrain, posture, motion, load and mission objectives |
Bilder
 martti
 martti
 martti
 martti
Bildbeiträge
Videos
ROBOTER-FOREN
Foren werden geladen...
BEWERTUNGEN
HÄUFIG GESTELLTE FRAGEN
What is the Galileo X?
Galileo X is the company's variable-configuration terrestrial platform, and its premise is that a robot should not have to commit to one body plan.
Who makes the Galileo X?
The Galileo X is made by Galileo Technology, a robotics company based in China.
How much does the Galileo X cost?
Galileo Technology has not publicly announced pricing for the Galileo X. You can enquire through RobotAIGeek for current pricing.
What is the Galileo X used for?
The Galileo X is designed for forschung, transport, ground transportation, and warehouse transfer. It is used in forschung, lager & logistik, and fertigung settings.
MIT ÄHNLICHEN ROBOTERN VERGLEICHEN
Sehen Sie, wie sich dieser Roboter gegenüber seinen nächsten Alternativen schlägt
- Galileo X vs Vision 60
- Galileo X vs Honey Badger 5.0
- Galileo X vs TRACER 2.0
- Galileo X vs BUNKER MINI 2.0
- Galileo X vs SCOUT 2.0