

説明
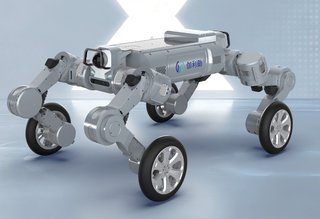
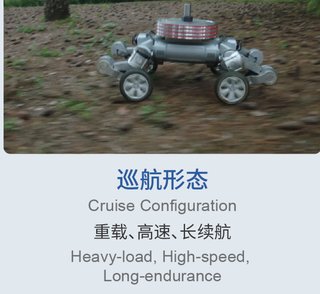
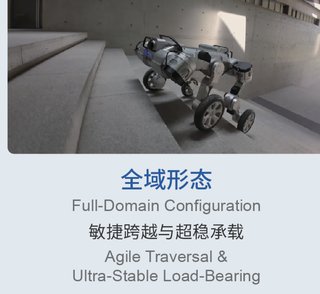
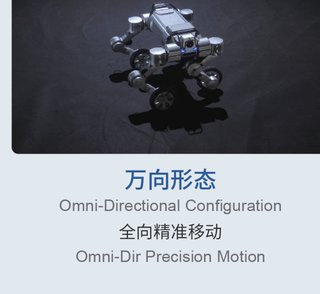
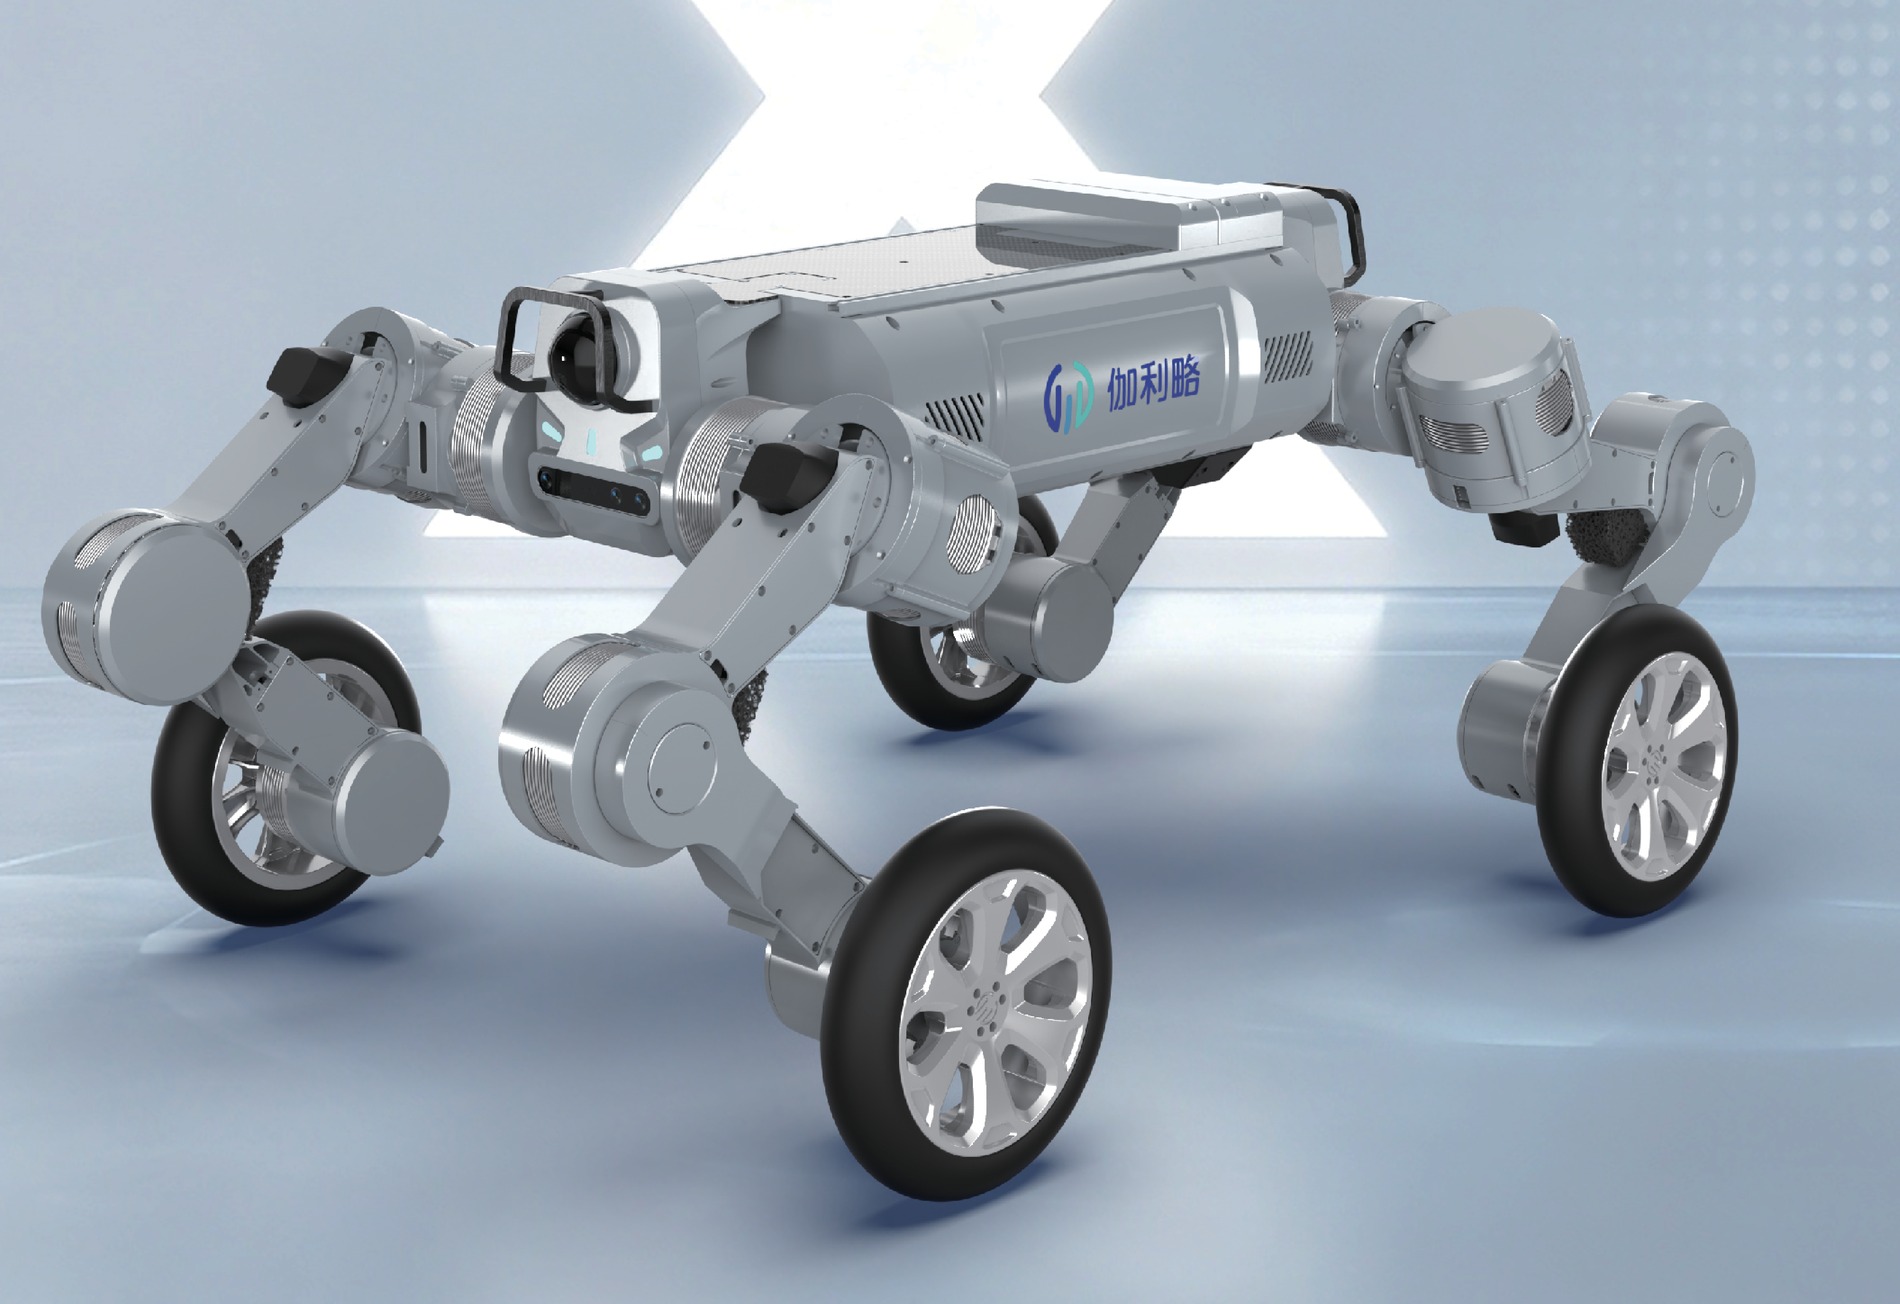
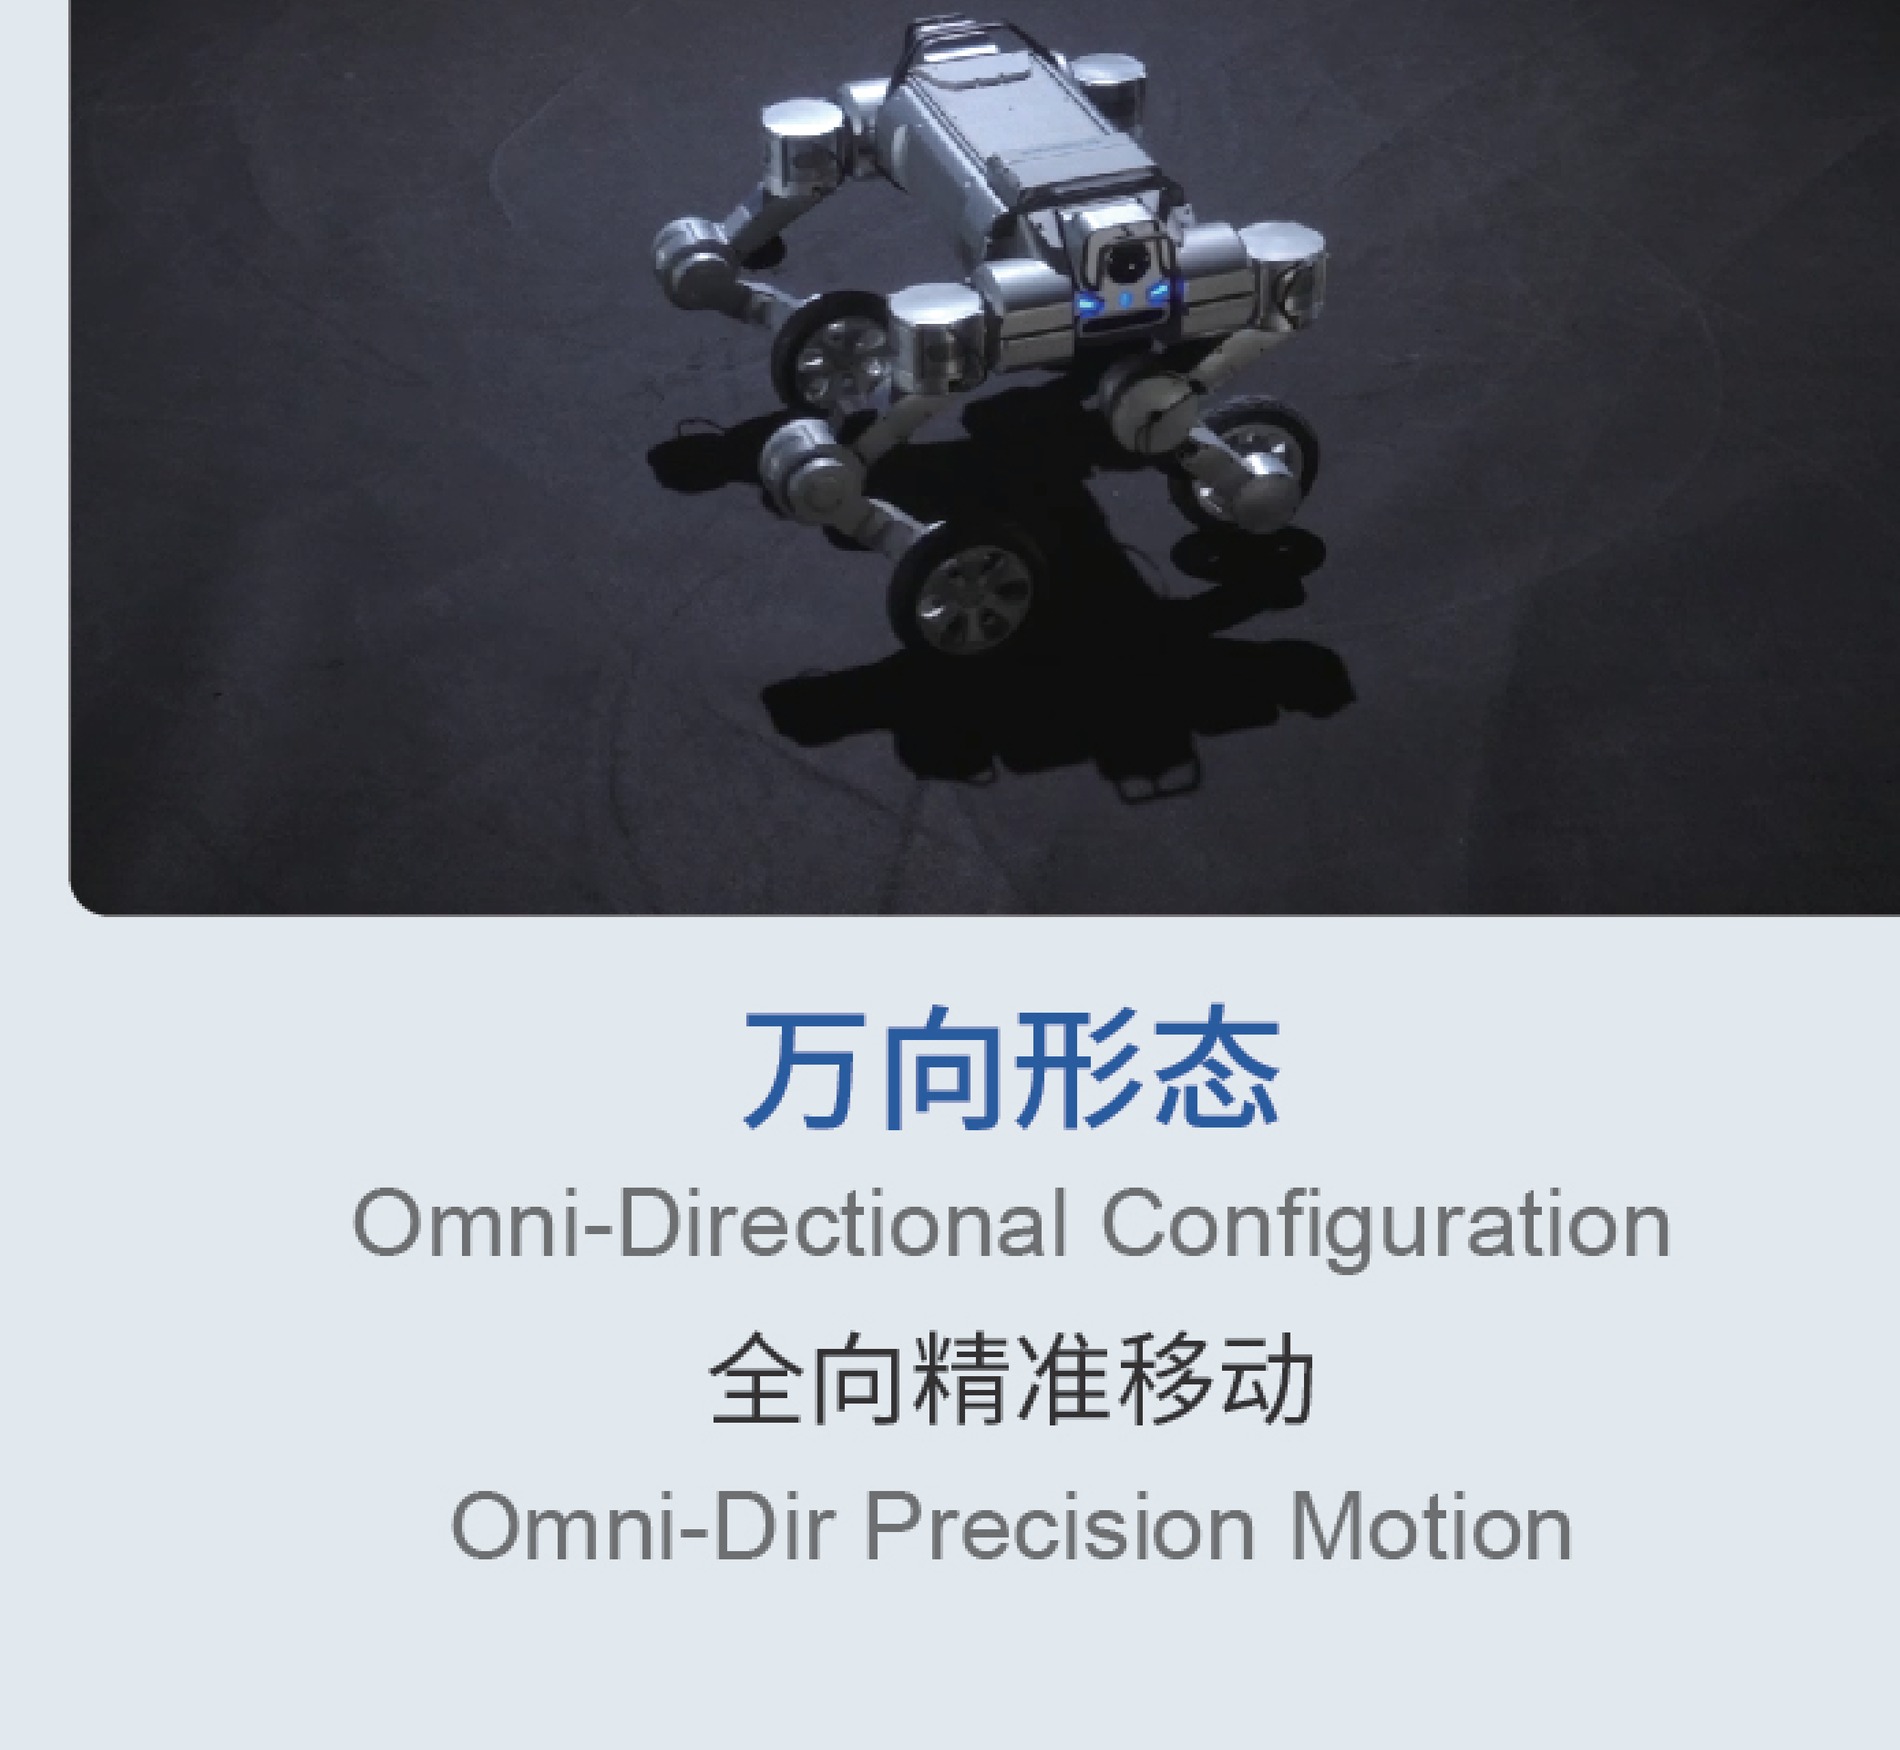
Galileo X is the company's variable-configuration terrestrial platform, and its premise is that a robot should not have to commit to one body plan. The same machine switches between three basic configurations: a cruise form for heavy loads, high speed and long endurance; a full-domain form for agile traversal and ultra-stable load-bearing; and an omni-directional form for precise movement in any direction. Two pieces of engineering make that practical. The first is a composite active suspension built from meta-structural elastic units working with the joint motors, which lets the chassis absorb terrain rather than fight it. The second is more unusual: every system joint rotates a full 360 degrees continuously, with no conventional mechanical end stops, so a limb can roll through a change of configuration instead of unwinding first. A unified base model orchestrates vision, environment, terrain, posture, motion, load and mission objectives together. Galileo aims it at ground transport, warehouse transfer, complex-terrain traversal, stair negotiation, heavy-load cruising and stable load-bearing.
特長
- Variable-configuration platform switching between three basic forms according to environment, mission and load
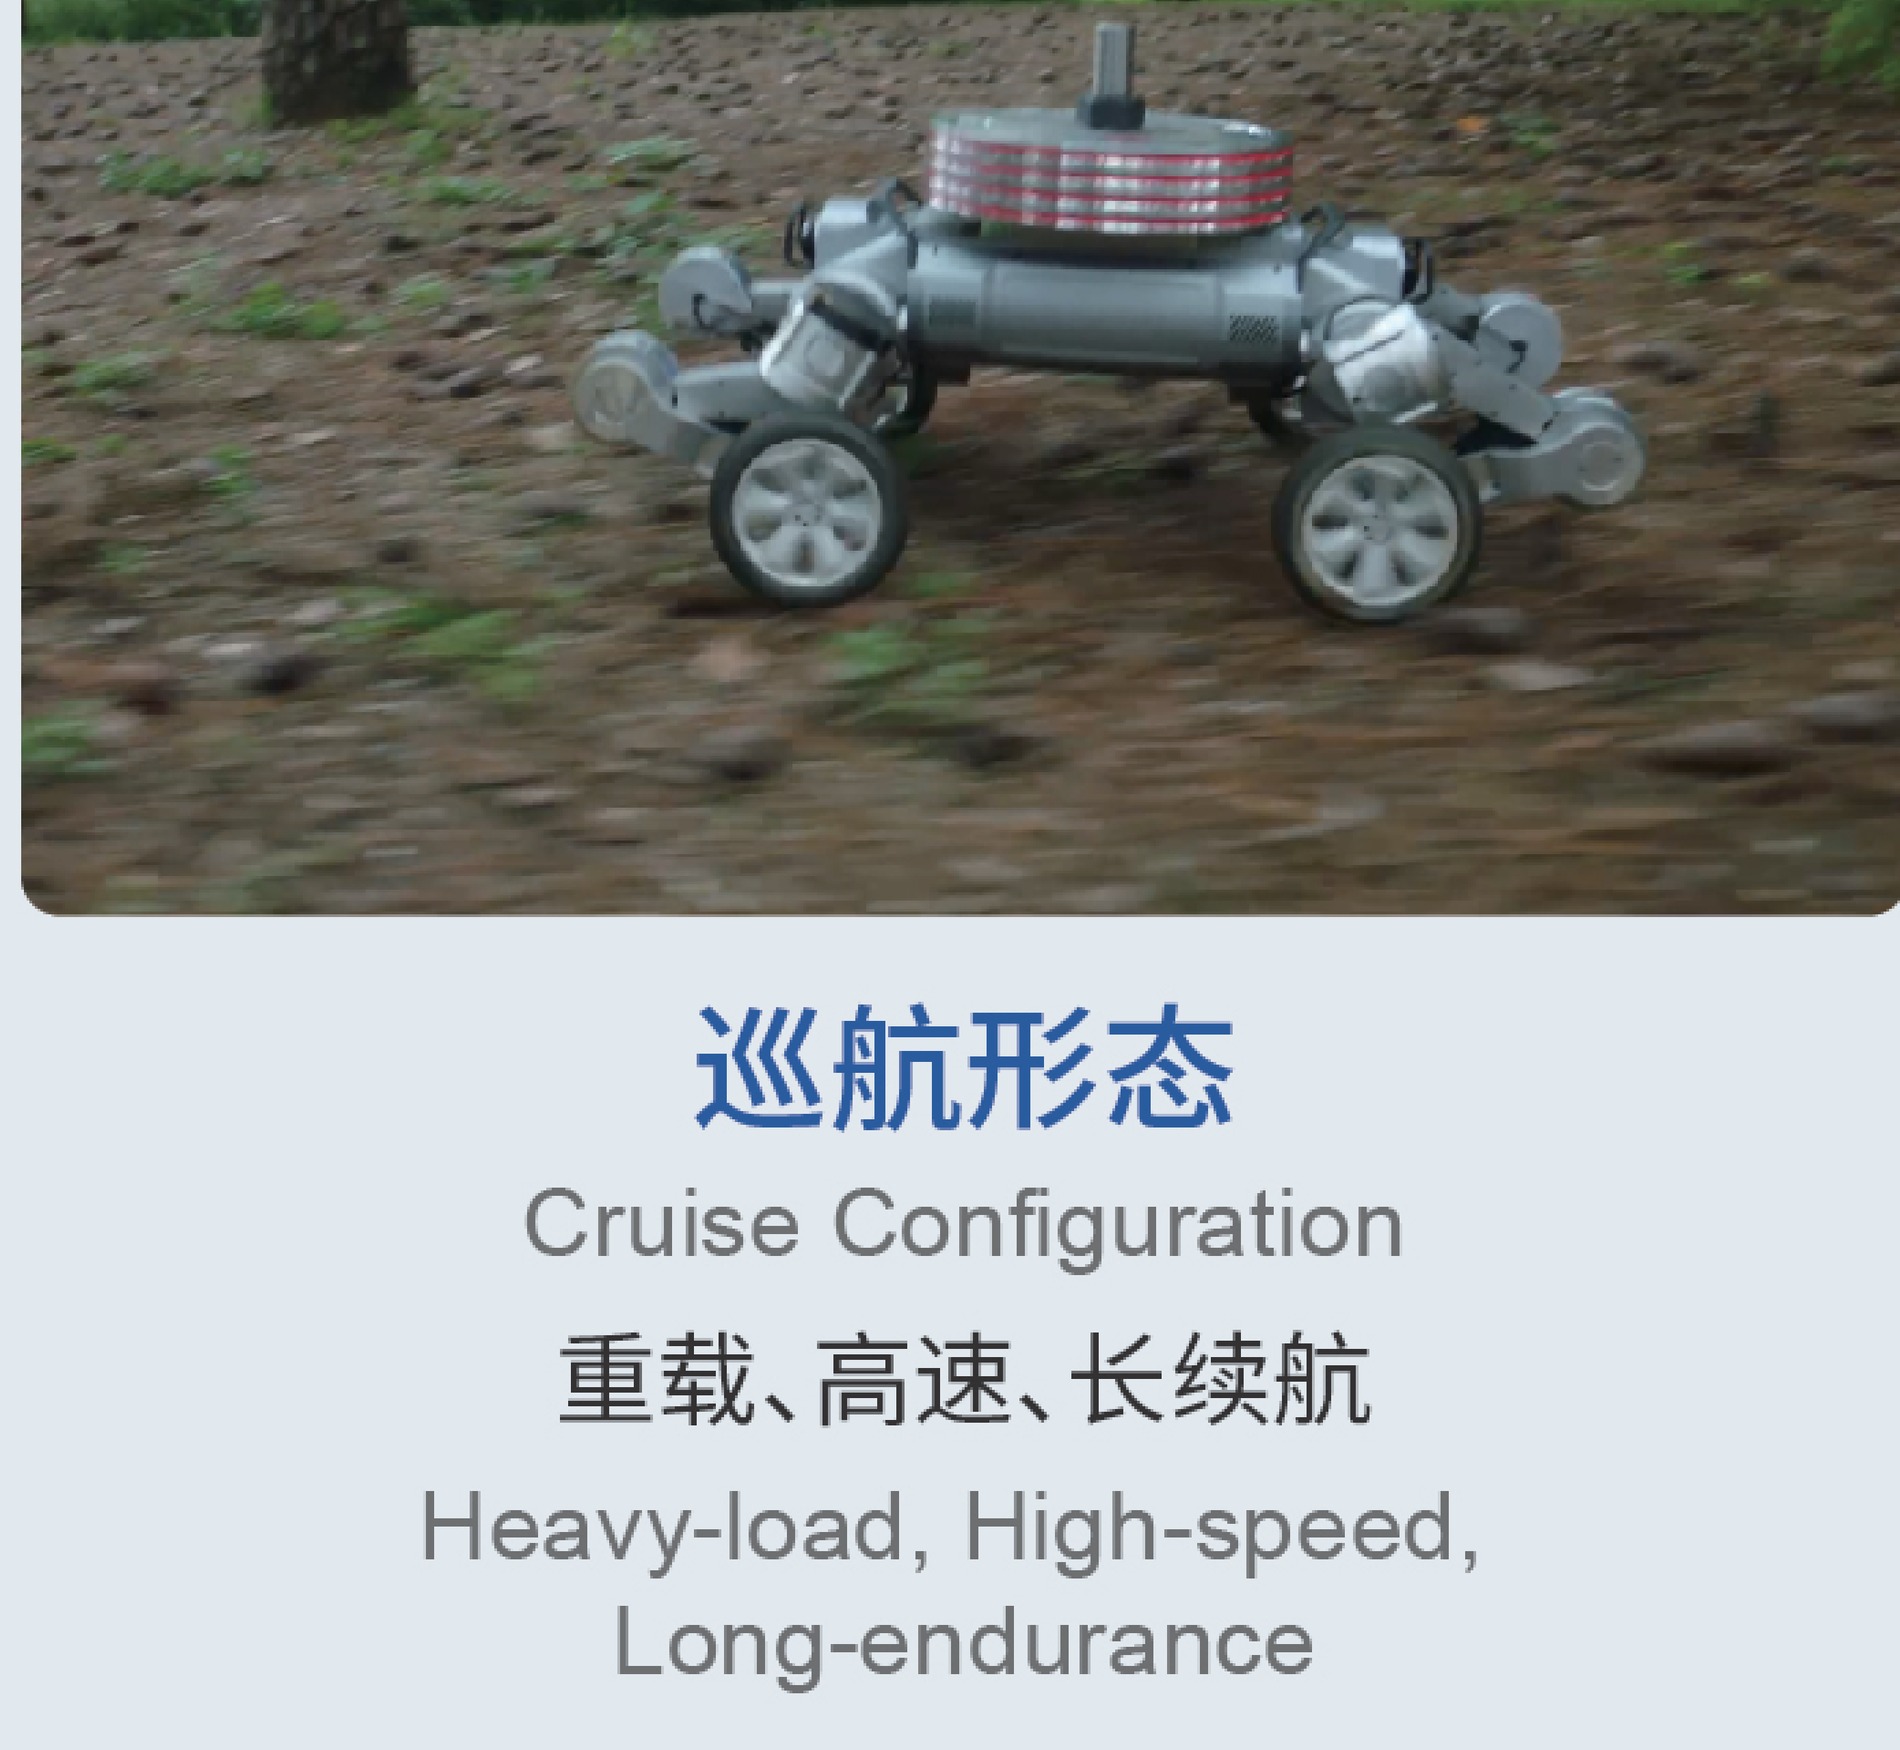
- Cruise configuration for heavy load, high speed and long endurance
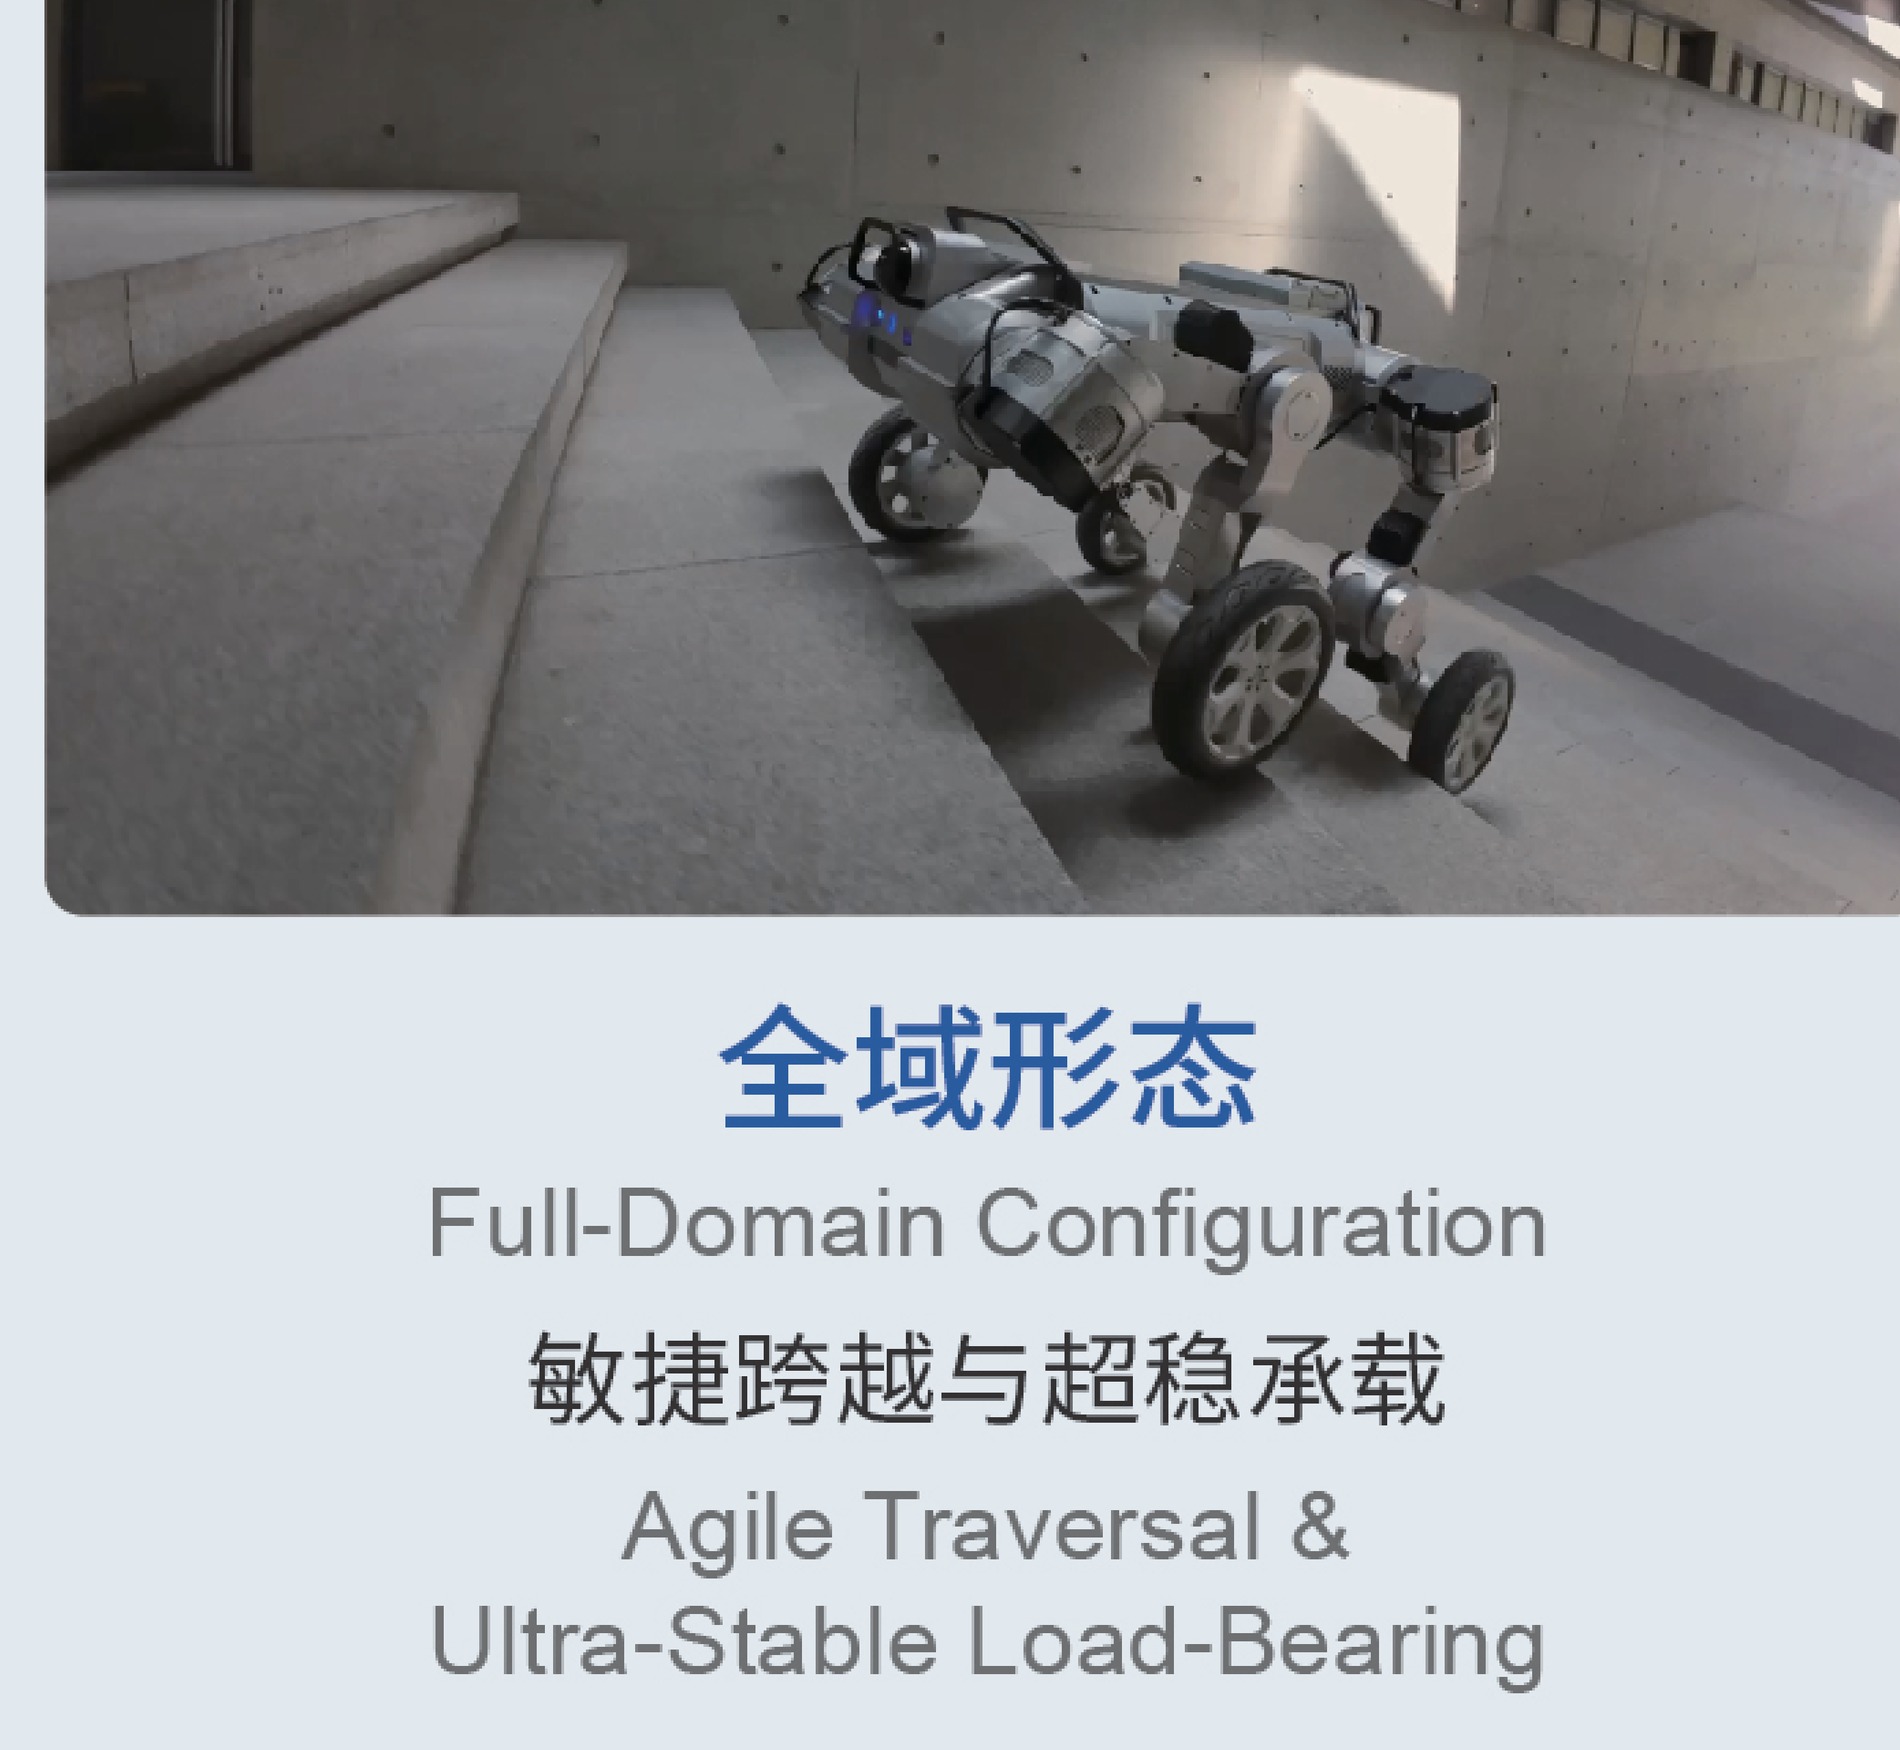
- Full-domain configuration for agile traversal and ultra-stable load-bearing
- Omni-directional configuration for omni-directional precision motion
- Composite active suspension built from meta-structural elastic units working together with the joint motors
- Endless-rotation joints giving 360 degrees of continuous rotation with no conventional mechanical limits
- Unified base model orchestrating vision, environment, terrain, posture, motion, load and mission objectives
- Multi-modal embodied intelligence algorithms
- Targeted at ground transportation, warehouse transfer, complex-terrain traversal, stair negotiation, heavy-load cruising and stable load-bearing
技術仕様
| 移動性能 | |
| 移動方式 | 車輪型, ハイブリッド |
|---|---|
| アクチュエーター | Variable-configuration wheel-legged chassis with composite active suspension from meta-structural elastic units and joint motors; endless-rotation joints with 360 degrees of continuous travel |
| センシング・演算 | |
| ソフトウェア / AI | Multi-modal embodied intelligence algorithms with a unified base model orchestrating vision, environment, terrain, posture, motion, load and mission objectives |
画像
 martti
 martti
 martti
 martti
投稿画像
動画
ロボットフォーラム
フォーラムを読み込み中...
評価
よくある質問
What is the Galileo X?
Galileo X is the company's variable-configuration terrestrial platform, and its premise is that a robot should not have to commit to one body plan.
Who makes the Galileo X?
The Galileo X is made by Galileo Technology, a robotics company based in China.
How much does the Galileo X cost?
Galileo Technology has not publicly announced pricing for the Galileo X. You can enquire through RobotAIGeek for current pricing.
What is the Galileo X used for?
The Galileo X is designed for 研究, 搬送, ground transportation, and warehouse transfer. It is used in 研究, 倉庫・物流, and 製造 settings.
類似ロボットと比較
このロボットが最も近い代替候補とどう比べられるかをご覧ください
- Galileo X vs Vision 60
- Galileo X vs Honey Badger 5.0
- Galileo X vs TRACER 2.0
- Galileo X vs BUNKER MINI 2.0
- Galileo X vs SCOUT 2.0