DESCRIPTION
NEXOR is a Research-Robots from AquaAirX. It is built for Data Collection, Mapping, Surveying.
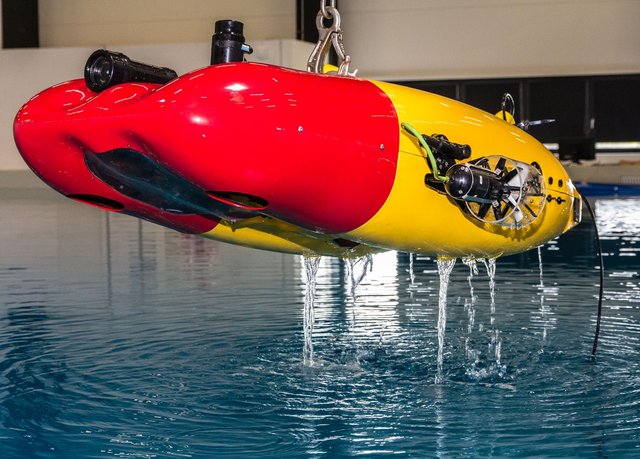
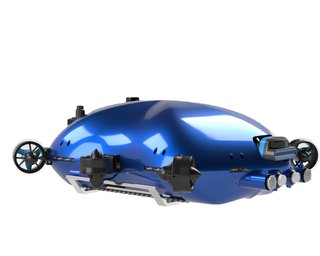
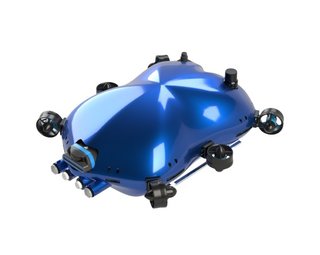
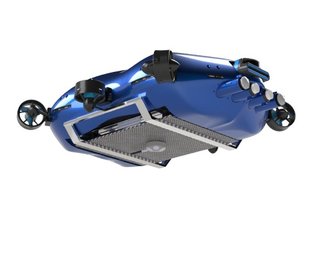
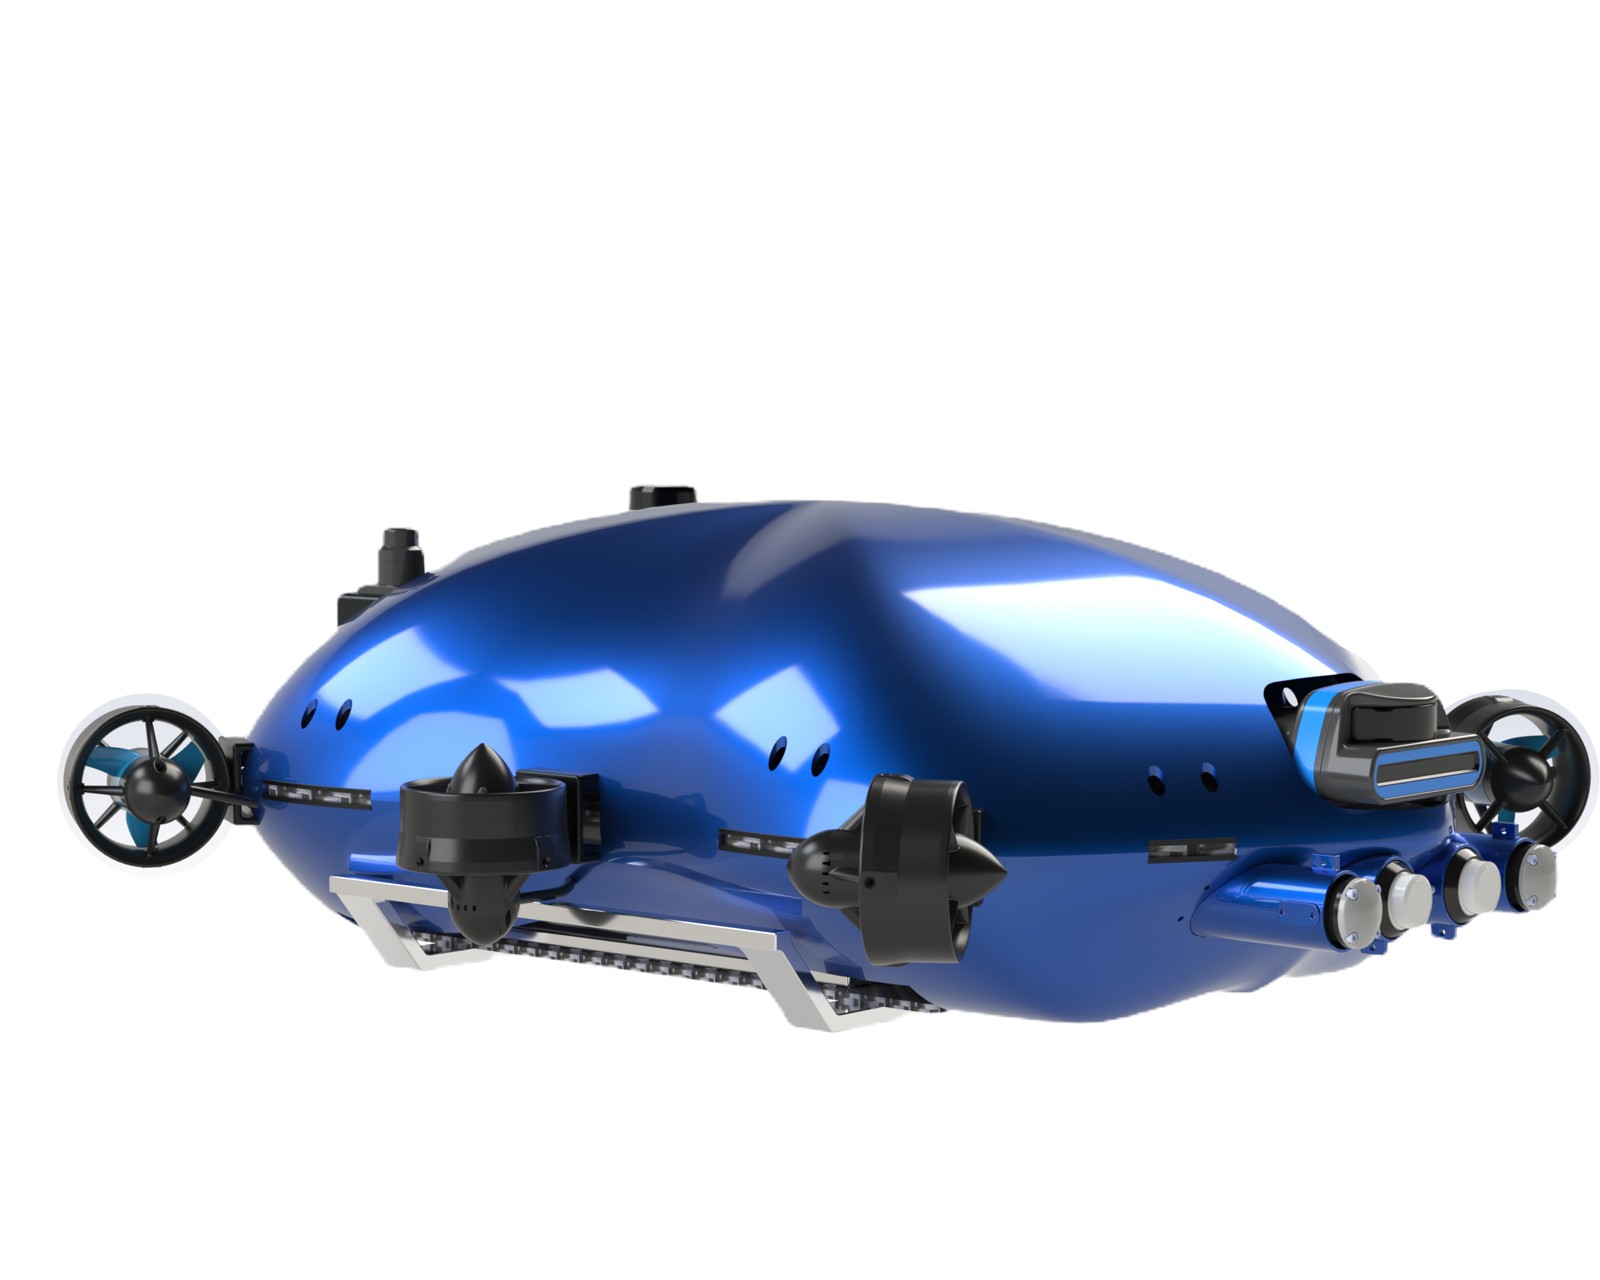
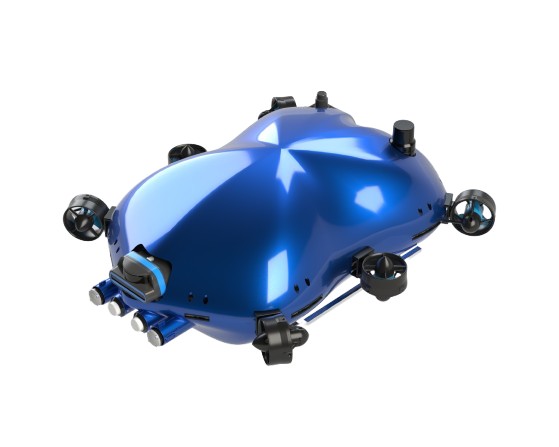
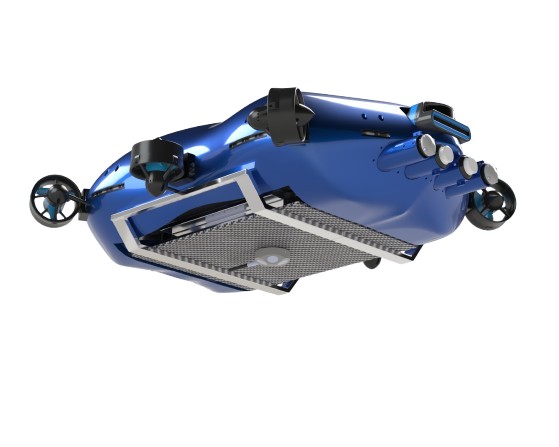
NEXOR is an inspection-class hovering autonomous underwater vehicle (HAUV) from AquaAirX. It is designed to hold position close to subsea structures, even in currents, and capture detailed imaging and sonar data for inspection and survey. The maker's renders show a rounded blue hull with several vectored thrusters, a front camera and lighting cluster and an underside skid frame. The standard sensor stack combines a Doppler velocity log, an inertial measurement unit, USBL acoustic positioning, an acoustic modem, a multibeam imaging sonar, HD and stereo cameras and an LED array. Mission payloads can add an ultrasonic thickness gauge, a robotic manipulator arm, water-quality probes (pH, dissolved oxygen, turbidity), forward-looking sonar, side-scan sonar and a laser scanner. AquaAirX also applies AI enhancement to low-visibility footage, and data feeds its DeepNimbus analytics platform. Target uses are offshore wind foundation and mooring inspection, oil and gas risers, manifolds and cables, pipeline and cable surveys, tunnel, intake and reservoir inspection, naval mine countermeasures and seabed surveillance, and deep-ocean research.
FEATURES
- Inspection-class hovering autonomous underwater vehicle (HAUV)
- Holds position close to assets in dynamic currents
- Multi-sensor data fusion and adaptive navigation
- Standard sensors: Doppler velocity log (DVL), inertial measurement unit (IMU), USBL acoustic positioning, acoustic communication modem, multi-beam imaging sonar, HD visual cameras, LED lighting array
- Flight controller and stereo camera system
- Optional ultrasonic thickness (UT) gauge
- Optional robotic manipulator arm
- Optional environmental probes (pH, DO, turbidity)
- Optional imaging forward-looking sonar
- Optional side-scan sonar and laser scanning module
- AI-powered enhancement of low-visibility underwater footage
- Data analytics via DeepNimbus
- mission control via AquaAirX GCS
- Datasheet on request
TECHNICAL SPECIFICATIONS
Verified| Mobility | |
| Movement Type | Aquatic |
|---|---|
| Environment | Subsea, including strong currents and low visibility |
| Sensing & Compute | |
| Sensors | Doppler velocity log (DVL), IMU, USBL positioning, Acoustic modem, Multi-beam imaging sonar, HD cameras, Stereo camera, LED array |
| Software / AI | AI enhancement of low-visibility footage; DeepNimbus analytics; AquaAirX GCS |
ROBOT FORUMS
Loading forums...
TECHNICAL SPECIFICATIONS
Verified| Mobility | |
| Movement Type | Aquatic |
|---|---|
| Environment | Subsea, including strong currents and low visibility |
| Sensing & Compute | |
| Sensors | Doppler velocity log (DVL), IMU, USBL positioning, Acoustic modem, Multi-beam imaging sonar, HD cameras, Stereo camera, LED array |
| Software / AI | AI enhancement of low-visibility footage; DeepNimbus analytics; AquaAirX GCS |
Images
 martti
 martti
 martti
Image Contributions
Videos
ROBOT FORUMS
Loading forums...
RATINGS
FREQUENTLY ASKED QUESTIONS
What is the NEXOR?
NEXOR is an inspection-class hovering autonomous underwater vehicle (HAUV) from AquaAirX. It is designed to hold position close to subsea structures, even in currents, and capture detailed imaging and sonar data for inspection and survey.
Who makes the NEXOR?
The NEXOR is made by AquaAirX, a robotics company based in India.
How much does the NEXOR cost?
AquaAirX has not publicly announced pricing for the NEXOR. You can enquire through RobotAIGeek for current pricing.
What is the NEXOR used for?
The NEXOR is designed for data collection, mapping, surveying, and inspection. It is used in defence, energy, research, and telecoms settings.
COMPARE WITH SIMILAR ROBOTS
See how this robot stacks up against its closest alternatives
- NEXOR vs NETRA AUV
- NEXOR vs UUR
- NEXOR vs AQUA-SCANNER
- NEXOR vs VideoRay Mission Specialist Wraith
- NEXOR vs Leidos Sea Dart