DESCRIPTION
Corenetic Monte S1 is a Mobile-Robots from Corenetic. It is built for Pick-and-place, Research, Transport. Key figures: 120 kg, 480 min runtime, 3 kg payload, 919 mm reach.
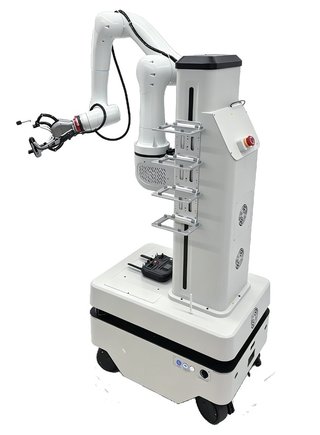
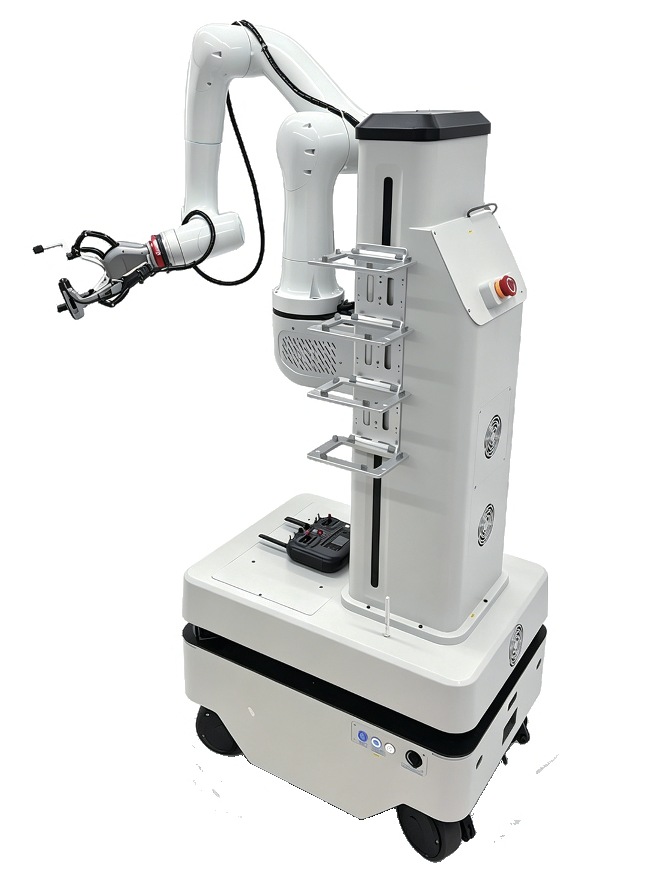
The Monte S1 is Corenetic's mobile manipulation system, and it trades the Monte 02's height and arm dexterity for reach, speed and chassis capability. It is shorter at 1,407 mm but heavier at 120 kg, and it runs a four-wheel four-steer chassis rather than three omnidirectional wheels — good for 1.5 m/s and 15-degree slopes, half again the speed and grade of its sibling. Its arms are simpler at 6 degrees of freedom each but longer, spanning 919 mm against 702 mm, still carrying 3 kg per arm and still swapping automatically between adaptive dual grippers and multi-finger dexterous hands. Corenetic builds it on the same physics-native model, combining spatial understanding, multimodal interaction and fine manipulation so it can adapt to different environments, objects and tasks and complete long sequences such as item delivery, button operation and precise grasping on its own. It carries the same compute pairing — a 200+ TOPS embedded AI processor with an x86 industrial real-time control board — and a larger 48 V 42 Ah pack for eight hours of typical operation. It is aimed at life science, biopharmaceuticals, advanced manufacturing and commercial spaces.
FEATURES
- 699 x 503 x 1407 mm and 120 kg
- High-strength aluminium alloy frame with a sheet metal shell
- Four-wheel four-steer chassis, maximum speed 1.5 m/s, gradeability up to 15 degrees
- Mapping, real-time localisation, obstacle-avoidance navigation and autonomous recharging
- Indoor floor surfaces including tile, wood flooring and rubber
- 6 degrees of freedom per arm with a 919 mm working span per arm
- 3 kg maximum payload per arm
- Adaptive dual grippers or multi-finger dexterous hands with automatic quick-change
- Sub-millimetre precision operation combining multimodal perception, compliant grasping and arm control
- Long-task autonomous execution with multi-step continuous execution and cross-device coordination
- 7 days a week, 24 hours a day continuous stable operation for long-term deployment
- Lithium battery pack, 48 V / 42 Ah, 8 hours typical operation, 2.5 hours fast charge
- Main control unit 1: embedded AI processor with 200+ TOPS
- main control unit 2: x86 industrial real-time control board
- Application tasks include item delivery, button operation and precise grasping
- Manufacturer states the published figures come from laboratory testing and are for reference
TECHNICAL SPECIFICATIONS
| Physical | |
| Weight | 120 kg |
|---|---|
| Dimensions | L 699 mm × W 503 mm × H 1.41 m |
| Payload | 3 kg |
| Reach | 919 mm |
| Mobility | |
| Movement Type | Wheeled |
| Speed | 5.4 km/h |
| Manipulation | High |
| Environment | Indoor floors including tile, wood flooring and rubber; laboratories, production areas and commercial spaces |
| Actuators | Dual 6-degree-of-freedom arms with automatic end-effector quick-change on a four-wheel four-steer chassis |
| Power | |
| Battery Life | 8 h typical |
| Sensing & Compute | |
| Sensors | cameras, multimodal perception suite |
| Software / AI | Physics-native model providing spatial understanding, multimodal interaction and fine manipulation, with long-task planning, multi-step continuous execution and cross-device coordination; mapping, localisation, obstacle avoidance and auto-recharge |
ROBOT FORUMS
Loading forums...
TECHNICAL SPECIFICATIONS
| Physical | |
| Weight | 120 kg |
|---|---|
| Dimensions | L 699 mm × W 503 mm × H 1.41 m |
| Payload | 3 kg |
| Reach | 919 mm |
| Mobility | |
| Movement Type | Wheeled |
| Speed | 5.4 km/h |
| Manipulation | High |
| Environment | Indoor floors including tile, wood flooring and rubber; laboratories, production areas and commercial spaces |
| Actuators | Dual 6-degree-of-freedom arms with automatic end-effector quick-change on a four-wheel four-steer chassis |
| Power | |
| Battery Life | 8 h typical |
| Sensing & Compute | |
| Sensors | cameras, multimodal perception suite |
| Software / AI | Physics-native model providing spatial understanding, multimodal interaction and fine manipulation, with long-task planning, multi-step continuous execution and cross-device coordination; mapping, localisation, obstacle avoidance and auto-recharge |
Images
 martti
Image Contributions
Videos
ROBOT FORUMS
Loading forums...
RATINGS
FREQUENTLY ASKED QUESTIONS
What is the Corenetic Monte S1?
The Monte S1 is Corenetic's mobile manipulation system, and it trades the Monte 02's height and arm dexterity for reach, speed and chassis capability.
Who makes the Corenetic Monte S1?
The Corenetic Monte S1 is made by Corenetic, a robotics company based in China.
How much does the Corenetic Monte S1 cost?
Corenetic has not publicly announced pricing for the Corenetic Monte S1. You can enquire through RobotAIGeek for current pricing.
What is the Corenetic Monte S1 used for?
The Corenetic Monte S1 is designed for pick-and-place, research, transport, and item delivery. It is used in research, healthcare, manufacturing, and retail settings.
What is the payload capacity of the Corenetic Monte S1?
The Corenetic Monte S1 has a payload capacity of 3 kg and a reach of 919 mm.
How much does the Corenetic Monte S1 weigh?
The Corenetic Monte S1 weighs 120 kg.
How fast is the Corenetic Monte S1?
The Corenetic Monte S1 can move at speeds of up to 5.4 km/h.
What is the battery life of the Corenetic Monte S1?
The Corenetic Monte S1 runs for 8 h typical on a charge.
COMPARE WITH SIMILAR ROBOTS
See how this robot stacks up against its closest alternatives
- Corenetic Monte S1 vs Slamtec Athena 2.0
- Corenetic Monte S1 vs Max
- Corenetic Monte S1 vs gitamini
- Corenetic Monte S1 vs RoboCT UFU Stand-Assisting Robot (Household)
- Corenetic Monte S1 vs Techi Linen Cart