DESCRIPTION
A-UT Machine is an Industrial-Robot from Mitsubishi Heavy Industries. It is built for Testing, Inspection, Remote. Key figures: 400 kg, 10 kg payload, 7 degrees of freedom.
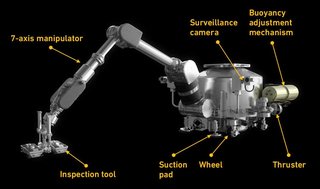
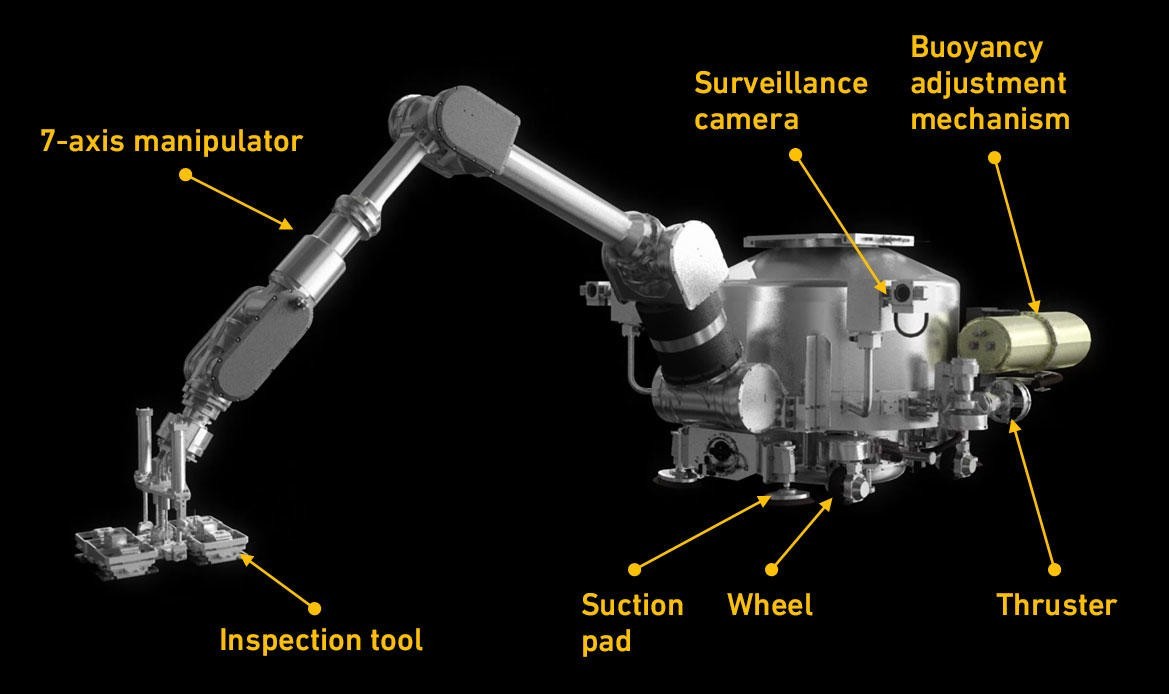
The A-UT Machine is Mitsubishi Heavy Industries' underwater navigation robot for non-destructive inspection of nuclear reactor vessels in high-radiation underwater environments. It navigates underwater with thrusters, travels on the vessel wall on wheels with a suction pad, and uses a 7-axis manipulator to inspect the vessel's weld lines. The manipulator carries 10 kg with a positioning precision of plus or minus 0.1 mm and has a tool changer at its tip so inspection tools can be swapped. A camera tracks a target mounted on the robot in real time and triangulates its position and orientation, and two units can work simultaneously to shorten inspections. It is controlled remotely from a desktop computer with a joystick, works to a maximum water depth of 20 m, measures 1,800 x 1,000 x 900 mm and weighs 400 kg (neutrally buoyant underwater). In operation at PWR plants in Japan since 1995 with 46 installations, it was certified as the first Maintenance Heritage by the Japan Society of Maintenology.
FEATURES
- Underwater navigation by thrusters
- wall travel on wheels
- 7-axis manipulator, 10 kg, +/-0.1 mm positioning
- Tool changer for switching inspection tools
- Camera target tracking with triangulation for position and orientation
- Two units can operate simultaneously
- Remote control by desktop PC and joystick
- Maximum water depth 20 m
- In service at Japanese PWR plants since 1995
TECHNICAL SPECIFICATIONS
Verified| Physical | |
| Weight | 400 kg |
|---|---|
| Dimensions | L 1.8 m × W 1 m × H 900 mm |
| Payload | 10 kg |
| Repeatability | ±0.1 mm |
| Mobility | |
| Movement Type | Wheeled, Aquatic |
| Degrees of Freedom | 7 |
| Environment | Underwater inside PWR nuclear reactor vessels, high radiation, depth up to 20 m |
| Sensing & Compute | |
| Sensors | Camera-based position tracking; interchangeable NDT inspection tools |
| Software / AI | Remote control from a desktop computer with joystick; camera-based target tracking and triangulation |
ROBOT FORUMS
Loading forums...
TECHNICAL SPECIFICATIONS
Verified| Physical | |
| Weight | 400 kg |
|---|---|
| Dimensions | L 1.8 m × W 1 m × H 900 mm |
| Payload | 10 kg |
| Repeatability | ±0.1 mm |
| Mobility | |
| Movement Type | Wheeled, Aquatic |
| Degrees of Freedom | 7 |
| Environment | Underwater inside PWR nuclear reactor vessels, high radiation, depth up to 20 m |
| Sensing & Compute | |
| Sensors | Camera-based position tracking; interchangeable NDT inspection tools |
| Software / AI | Remote control from a desktop computer with joystick; camera-based target tracking and triangulation |
Images
 martti
Image Contributions
Videos
ROBOT FORUMS
Loading forums...
RATINGS
FREQUENTLY ASKED QUESTIONS
What is the A-UT Machine?
The A-UT Machine is Mitsubishi Heavy Industries' underwater navigation robot for non-destructive inspection of nuclear reactor vessels in high-radiation underwater environments.
Who makes the A-UT Machine?
The A-UT Machine is made by Mitsubishi Heavy Industries, a robotics company based in Japan.
How much does the A-UT Machine cost?
Mitsubishi Heavy Industries has not publicly announced pricing for the A-UT Machine. You can enquire through RobotAIGeek for current pricing.
What is the A-UT Machine used for?
The A-UT Machine is designed for testing, inspection, and remote. It is used in energy settings.
What is the payload capacity of the A-UT Machine?
The A-UT Machine has a payload capacity of 10 kg.
How much does the A-UT Machine weigh?
The A-UT Machine weighs 400 kg.
How many degrees of freedom does the A-UT Machine have?
The A-UT Machine has 7 degrees of freedom.
COMPARE WITH SIMILAR ROBOTS
See how this robot stacks up against its closest alternatives
- A-UT Machine vs MAG Crawler
- A-UT Machine vs MagCrawler
- A-UT Machine vs ORCA Hull Inspection Crawler
- A-UT Machine vs iSAGEBOT iSAGE STAR Dual-arm Robot
- A-UT Machine vs TRI Wind Turbine Blade Exterior Inspection Robot