Eka Robotics Raises US$150 Million to Teach Robot Hands to Feel
Cambridge startup Eka Robotics raised a US$150M Series A led by a16z and F-Prime for its force-sensing "Vision-Force-Action" manipulation model, betting touch, not more vision data, is what's missing from robotic grasping.


CAMBRIDGE, Massachusetts, October 20, 2026. Eka Robotics, a robotics startup founded in 2025, said it raised a US$150 million Series A round led by Andreessen Horowitz and F-Prime. The round values the company, which builds a force-sensing robotic manipulation system called Vision-Force-Action, at a reported US$1.45 billion post-money.
Eka is a small team by robotics standards, but its backers are not. Returning seed investors Obvious Ventures and E14 Fund joined the new round alongside MFV Partners, Bison Ventures, Glasswing Ventures, Samsung Next, and a group of unnamed Fortune 500 strategic investors. The company's pitch to that syndicate is narrow and specific: most of the capital chasing humanoid and manipulation robotics since 2024 has gone toward vision-language-action (VLA) models that teach robots to act by imitating video of humans. Eka's foundation model instead fuses vision with force and torque sensing, betting that a robotic hand cannot reliably pick, insert, or assemble objects it cannot feel.
The Grasping Problem Nobody Priced Correctly
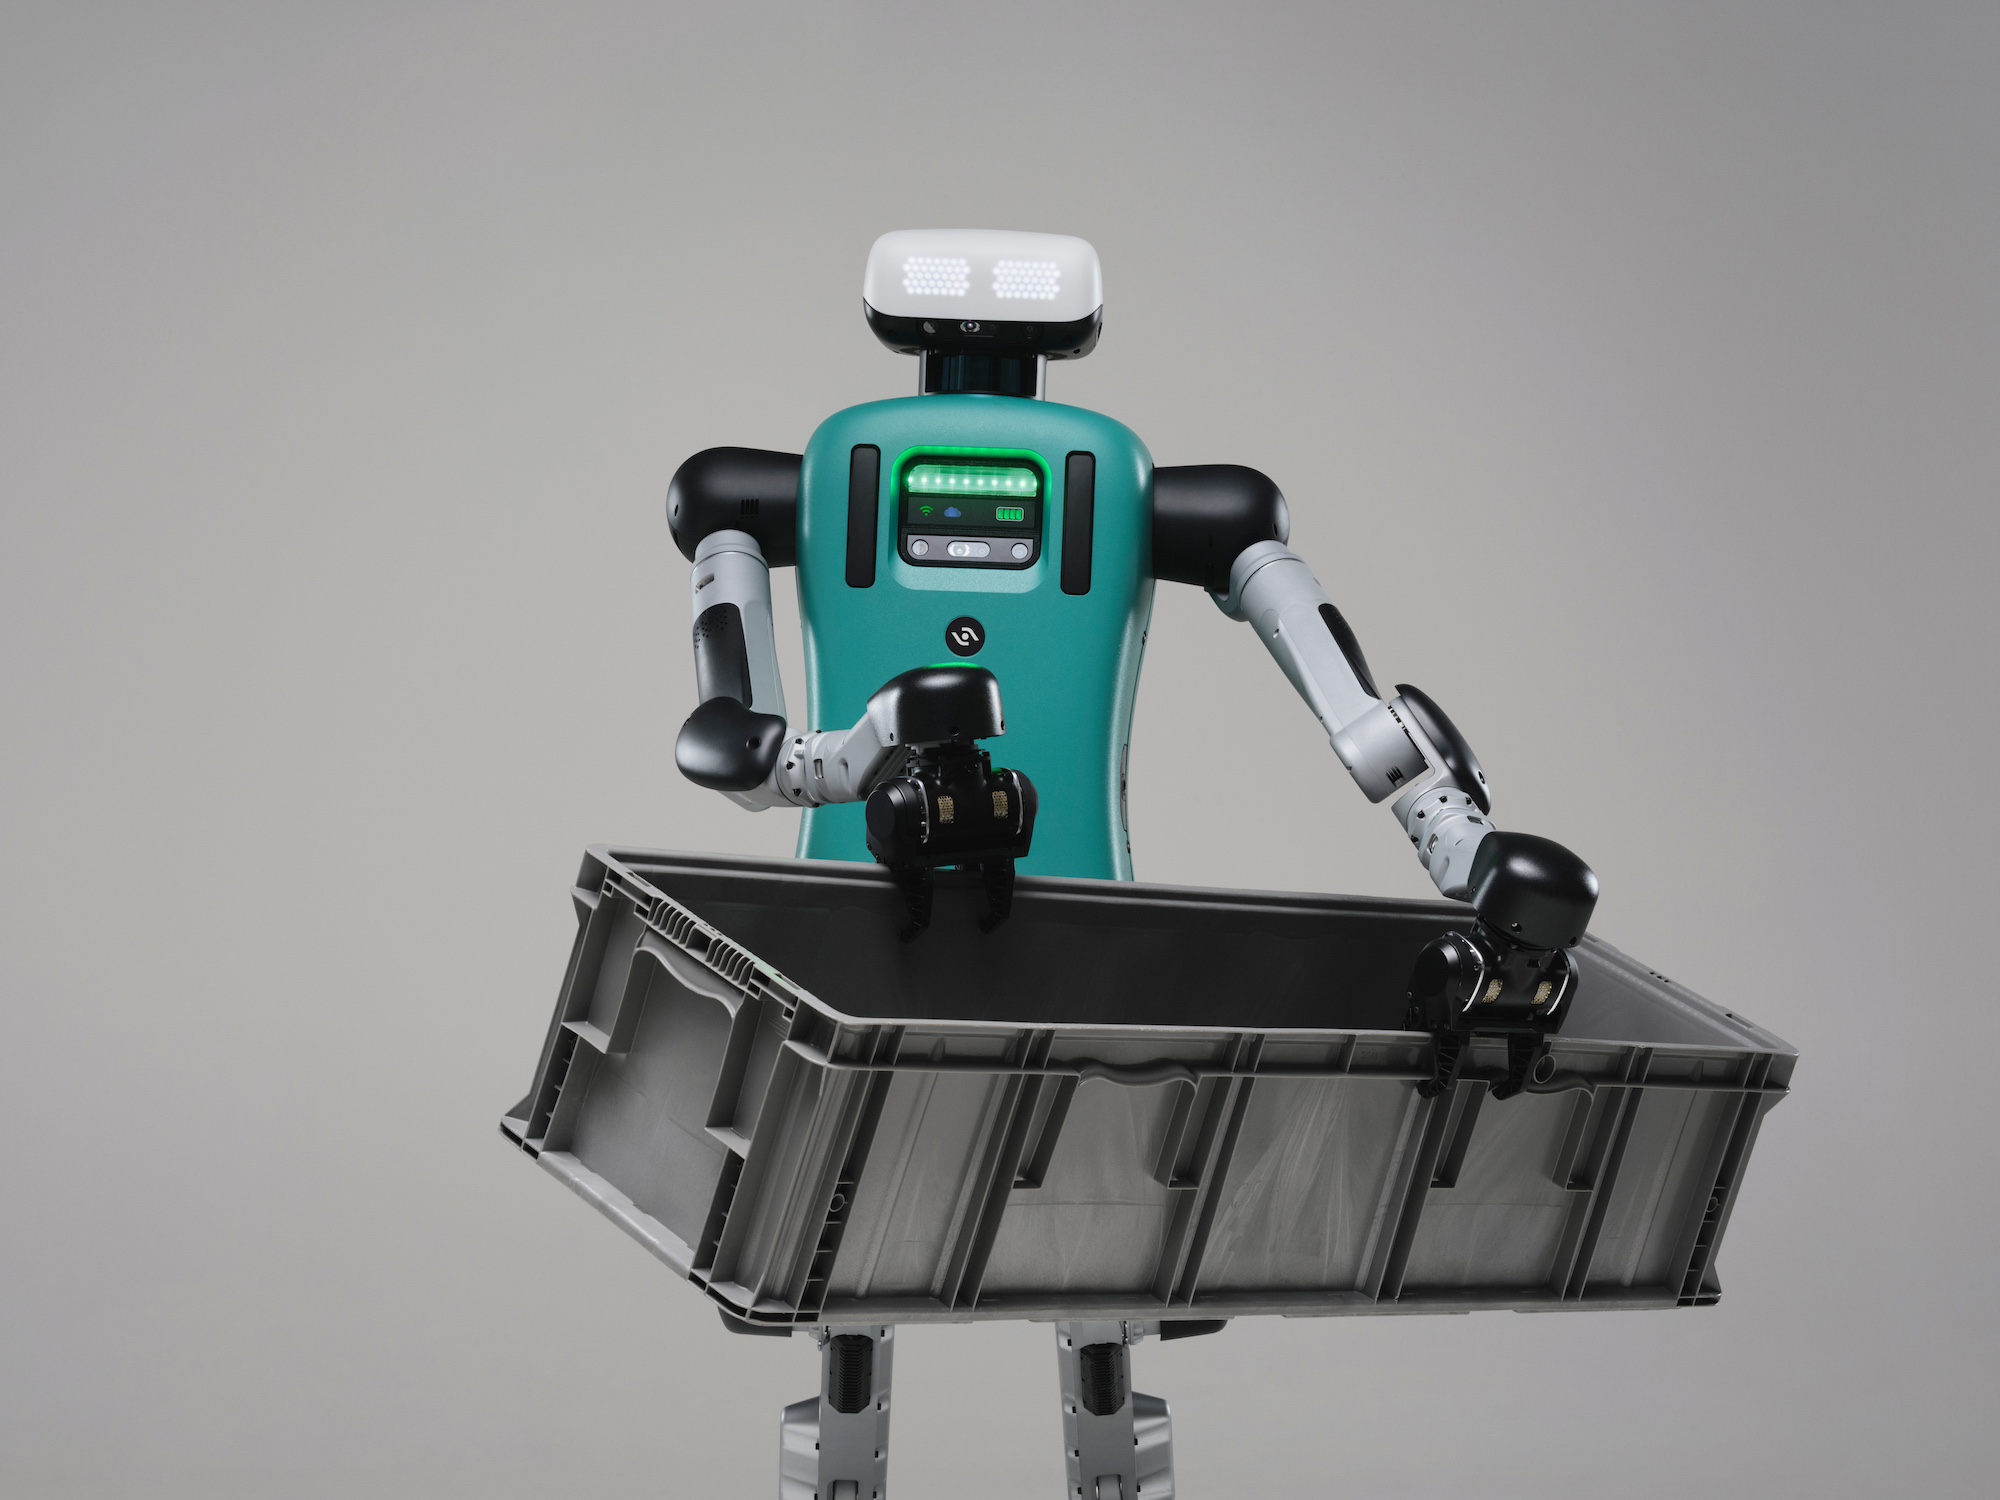
Grasping sounds like the easiest part of robotic manipulation and has turned out to be among the hardest to commercialize. A robot arm can be taught, in simulation, to recognize a thousand object shapes. What breaks in a real warehouse is the moment of contact: how hard to close a gripper around a crushable box, how to tell a cable is fully seated in a connector, how to recover when an object slips mid-lift. Eka's Vision-Force-Action (VFA) model is built specifically around that moment, pairing a force-sensitive gripper with a model trained to reason jointly about where an object is and how the physical interaction with it is unfolding, rather than relying purely on camera input and demonstration data.
The company trains the model largely in simulation, using reinforcement learning to generate large volumes of synthetic grasping experience across varied objects, environments, and physical conditions, then transfers that training to physical hardware. Eka says the gap between simulated and real-world performance, the sim-to-real gap that has stalled plenty of manipulation startups before it, is narrowing for its approach. That claim has not been independently audited, and procurement teams evaluating the technology should treat it as a vendor claim rather than a verified benchmark until third-party testing exists.
What 1,500 Picks an Hour Actually Means for a Warehouse Budget
Eka says its system picks a wide range of objects, including ones outside its training set, at roughly 1,500 operations per hour, a figure the company frames as about 2.5 times a human baseline of roughly 600 picks per hour. It also says the same hardware can perform higher-precision contact tasks, such as screwing in a light bulb or inserting a wire into a connector, without being re-engineered for each task. Again, these are the company's own disclosed figures rather than numbers verified by an independent lab or a customer deployment, and procurement teams should ask for site-specific pilot data before building a cost model around them.
If those throughput numbers hold up outside a demo environment, the commercial implication is straightforward: a single manipulation cell could begin to compete on cost with two to three human pickers in a warehouse or light-assembly line, not merely assist them. That is a different buying decision than the one most logistics operators have been offered so far, where robotic arms have been priced and positioned as a productivity multiplier for an existing workforce rather than a direct labor substitute. Eka's own language, which describes its mission as building "general-purpose robots that perform beyond human capabilities," makes clear which framing the company intends to sell.
A Funding Syndicate Betting Against the Humanoid Narrative
The investor list is notable less for its size than for what it signals about where sophisticated capital thinks the next bottleneck in physical AI sits. Raghu Raghuram, a general partner at Andreessen Horowitz who co-led the round, said in the funding announcement that "Eka's Vision-Force-Action model is the first approach I've seen that truly solves manipulation." Habib Haddad of E14 Fund, a seed investor returning for this round, summed up his firm's thesis in four words: "Three words: Team and Dream." Shyam Kamadolli of Fine Structure Ventures went further on the technical bet itself, saying "Eka's approach is the only one that will hold up in real-world deployments of complex tasks."
None of that is independent verification, and investors backing a thesis is not the same as a thesis being proven at scale. But the composition of the syndicate, which includes strategic capital from at least one major electronics manufacturer in addition to the venture firms, suggests Eka is being positioned as a component supplier to larger robotics and automation programs rather than purely as a standalone robot maker. That distinction matters for how quickly the technology could show up inside existing industrial automation lines rather than as a new category of robot altogether.
A Crowded Field Betting on Different Senses
Eka is not the only well-funded team chasing the manipulation problem, and its Series A arrives into a field where rivals have made different bets about which missing sense matters most. Some competitors have poured resources into larger vision-language-action models, scaling up demonstration data in the hope that enough video of human hands will eventually teach a robot the physics it needs. Others have focused on tactile sensor hardware itself, building specialized fingertip sensors before worrying about the model that interprets them. Eka's bet is narrower than either: that a single model trained jointly on vision and force signals, largely through simulated reinforcement learning rather than human demonstration video, can generalize across a wide enough range of objects to be useful before it has seen all of them.
That is a testable claim, not a proven one. Reinforcement learning in simulation has a long history of producing robots that perform well in a controlled demo and degrade sharply once object shapes, lighting, or surface friction change in the real world. Eka's own characterization that this sim-to-real gap is narrowing is the central unresolved question a buyer should probe before treating the company's throughput numbers as a budgeting input. A procurement team evaluating Eka's hardware against a conventional pick-and-place robotic arm, or against continued reliance on human pickers, should ask for a site-specific pilot under its own mix of stock-keeping units rather than accepting a lab benchmark at face value.
Why Touch Is Becoming the Scarce Resource in Physical AI
The broader pattern across 2026's physical AI funding has been a slow rotation away from flashy whole-body humanoid demonstrations and toward narrower, harder manipulation problems that determine whether any of those humanoids are actually useful once they reach a factory floor. Legs that walk convincingly on a stage are a solved marketing problem; hands that can reliably sort a mixed pallet of oddly shaped goods are not. In that sense, Eka's raise reads as part of a wider investor correction, one in which the distinction between a demo and a deployable system has become the central question every robotics term sheet now has to answer, rather than a footnote investors were once willing to overlook.
That correction is also visible in how capital is being allocated this year: fewer, larger checks going to companies that can show a specific mechanical bottleneck they have solved, rather than diffuse bets on general-purpose embodied AI. Whether this particular funding round signals durable momentum behind force-sensing manipulation, or marks a near-term peak in how much investors are willing to pay for an unproven throughput claim, will depend on what Eka's hardware does in a paying customer's facility over the next twelve months, not on what it does in a pitch deck.
The Verdict Investors Are Already Pricing In
Eka Robotics has not shipped at scale, has not disclosed a named commercial customer, and has not had its throughput or reliability claims tested outside its own facilities. What it has done is convince two major venture firms and a bench of returning seed investors that force-sensing manipulation, not another iteration of vision-language-action, is the technology most likely to turn robotic arms into something closer to a drop-in replacement for human pickers. At a reported US$1.45 billion valuation for a company founded barely a year ago, Eka Robotics is now one of the most richly priced bets in robotics on the proposition that touch, not sight, was the missing ingredient in making robots usable with their hands.
For procurement teams already running pilots with vision-only manipulation arms, the near-term takeaway is less about Eka specifically than about the benchmark it is forcing competitors to answer. Any vendor pitching a grasping or assembly robot into a 2027 budget cycle should now expect buyers to ask how the system behaves on contact, not only on approach: how it detects a partially inserted part, how it modulates grip force on a fragile item, and how it recovers from a missed pick without human intervention. Eka's raise does not settle that question in its own favor yet. It does settle, for the moment, which question the best-funded investors in the sector think is the one worth paying to answer.
This article synthesizes company statements, investor commentary, and public funding disclosures as of October 21, 2026. It is for general information purposes only and does not constitute investment, financial, or professional advice.