
LingYu TeleAvatar Standard

説明
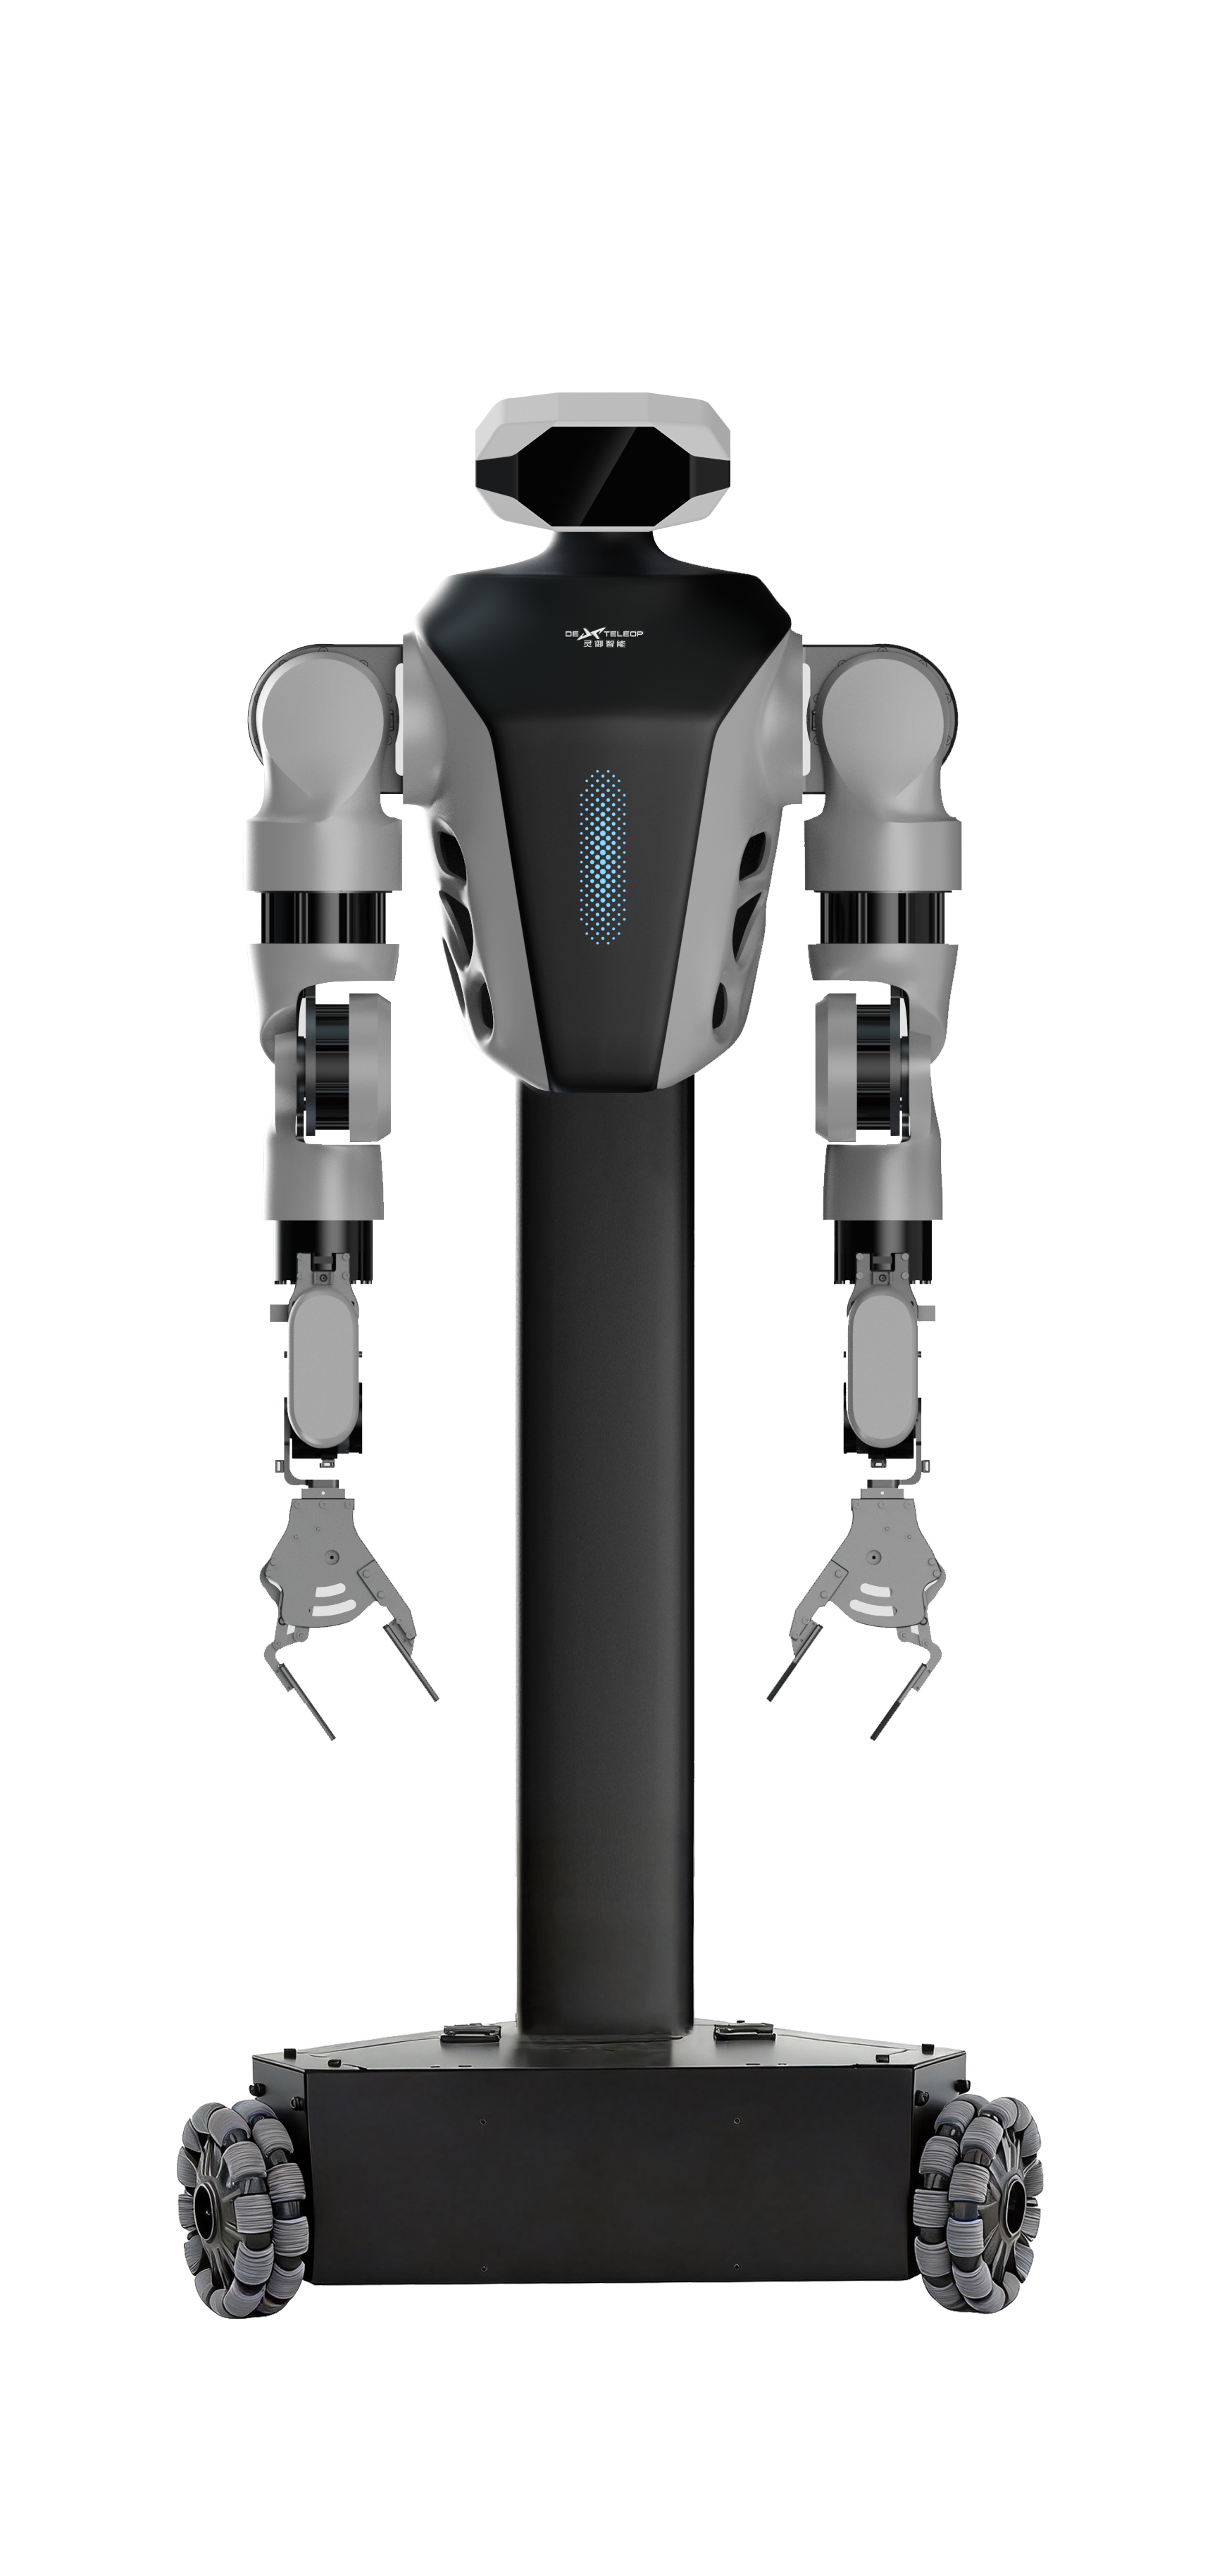
TeleAvatar Standard puts the TA torso on a tri-wheel omnidirectional chassis and is the variant LingYu recommends by default. Nineteen degrees of freedom in total, mobility to 2 m/s in any direction without turning, and the same dual seven-axis force-controlled arms carrying 3 kg to a tenth of a millimetre. LingYu positions it for general laboratory and inspection work — the case where the robot has to reach several places in a building rather than stand at one bench. The teleoperation stack is what makes that remote: under 100 ms end to end locally, and stable below 200 ms over public 4G, 5G or Starlink, so an operator can be in another region entirely. Sessions export as HDF5 training data.
特長
- Tri-wheel omnidirectional chassis
- 19 total degrees of freedom
- Omnidirectional mobility up to 2 m/s
- Dual 7-axis force-controlled arms
- Payload 3 kg
- Repeatability plus or minus 0.1 mm
- Flexible force-control range 0 to 10 N
- End-to-end teleoperation latency under 100 ms
- Binocular wide-angle stereo vision
- VR-based cross-regional remote control with immersive interaction
- Quick-change end effector with stepless high-precision force feedback
- HDF5 data export for AI training
- Sub-200 ms latency over public 4G, 5G or Starlink links
- Dual emergency shutdown with fail-safe posture locking
技術仕様
検証済み| 本体 | |
| 可搬重量 | 3 kg |
|---|---|
| 移動性能 | |
| 移動方式 | 車輪型 |
| 自由度 | 19 |
| 速度 | 7.2 km/h |
| マニピュレーション | 高 |
| 使用環境 | Laboratories, inspection routes and industrial workstations, operated locally or remotely |
| アクチュエーター | Dual 7-axis force-controlled arms on a tri-wheel omnidirectional chassis |
| センシング・演算 | |
| センサー | binocular wide-angle stereo camera, force sensors in arms |
| ソフトウェア / AI | Teleoperation stack with VR control and HDF5 data export; LingYu data-collection platform and Cloud Brain for training and capability iteration |
画像
 martti
投稿画像
動画
ロボットフォーラム
フォーラムを読み込み中...
評価
よくある質問
What is the LingYu TeleAvatar Standard?
TeleAvatar Standard puts the TA torso on a tri-wheel omnidirectional chassis and is the variant LingYu recommends by default. Nineteen degrees of freedom in total, mobility to 2 m/s in any direction without turning, and the same dual seven-axis force-controlled arms carrying 3 kg to a tenth of a millimetre.
Who makes the LingYu TeleAvatar Standard?
The LingYu TeleAvatar Standard is made by LingYu Robotics (DexTeleop Intelligence, 灵御智能), a robotics company based in China.
How much does the LingYu TeleAvatar Standard cost?
LingYu Robotics (DexTeleop Intelligence, 灵御智能) has not publicly announced pricing for the LingYu TeleAvatar Standard. You can enquire through RobotAIGeek for current pricing.
What is the LingYu TeleAvatar Standard used for?
The LingYu TeleAvatar Standard is designed for データ収集, マテリアルハンドリング, 研究, and リモート. It is used in 研究, 倉庫・物流, and 製造 settings.
What is the payload capacity of the LingYu TeleAvatar Standard?
The LingYu TeleAvatar Standard has a payload capacity of 3 kg.
How fast is the LingYu TeleAvatar Standard?
The LingYu TeleAvatar Standard can move at speeds of up to 7.2 km/h.
How many degrees of freedom does the LingYu TeleAvatar Standard have?
The LingYu TeleAvatar Standard has 19 degrees of freedom.
類似ロボットと比較
このロボットが最も近い代替候補とどう比べられるかをご覧ください
LingYu TeleAvatar Standard の代替候補 →