

描述
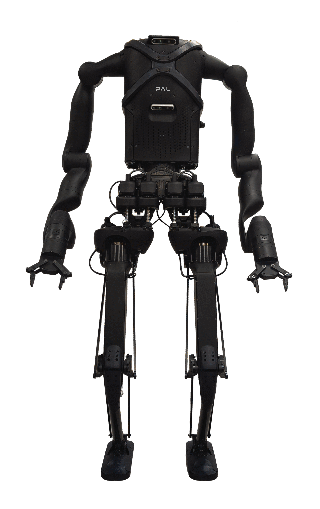
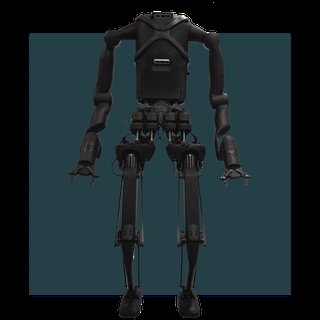
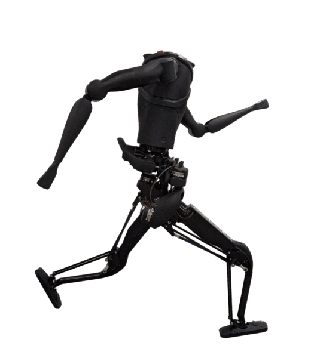
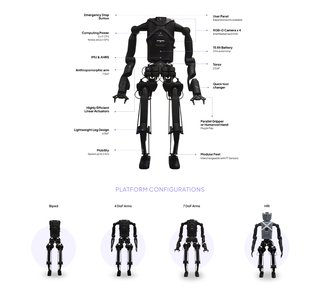
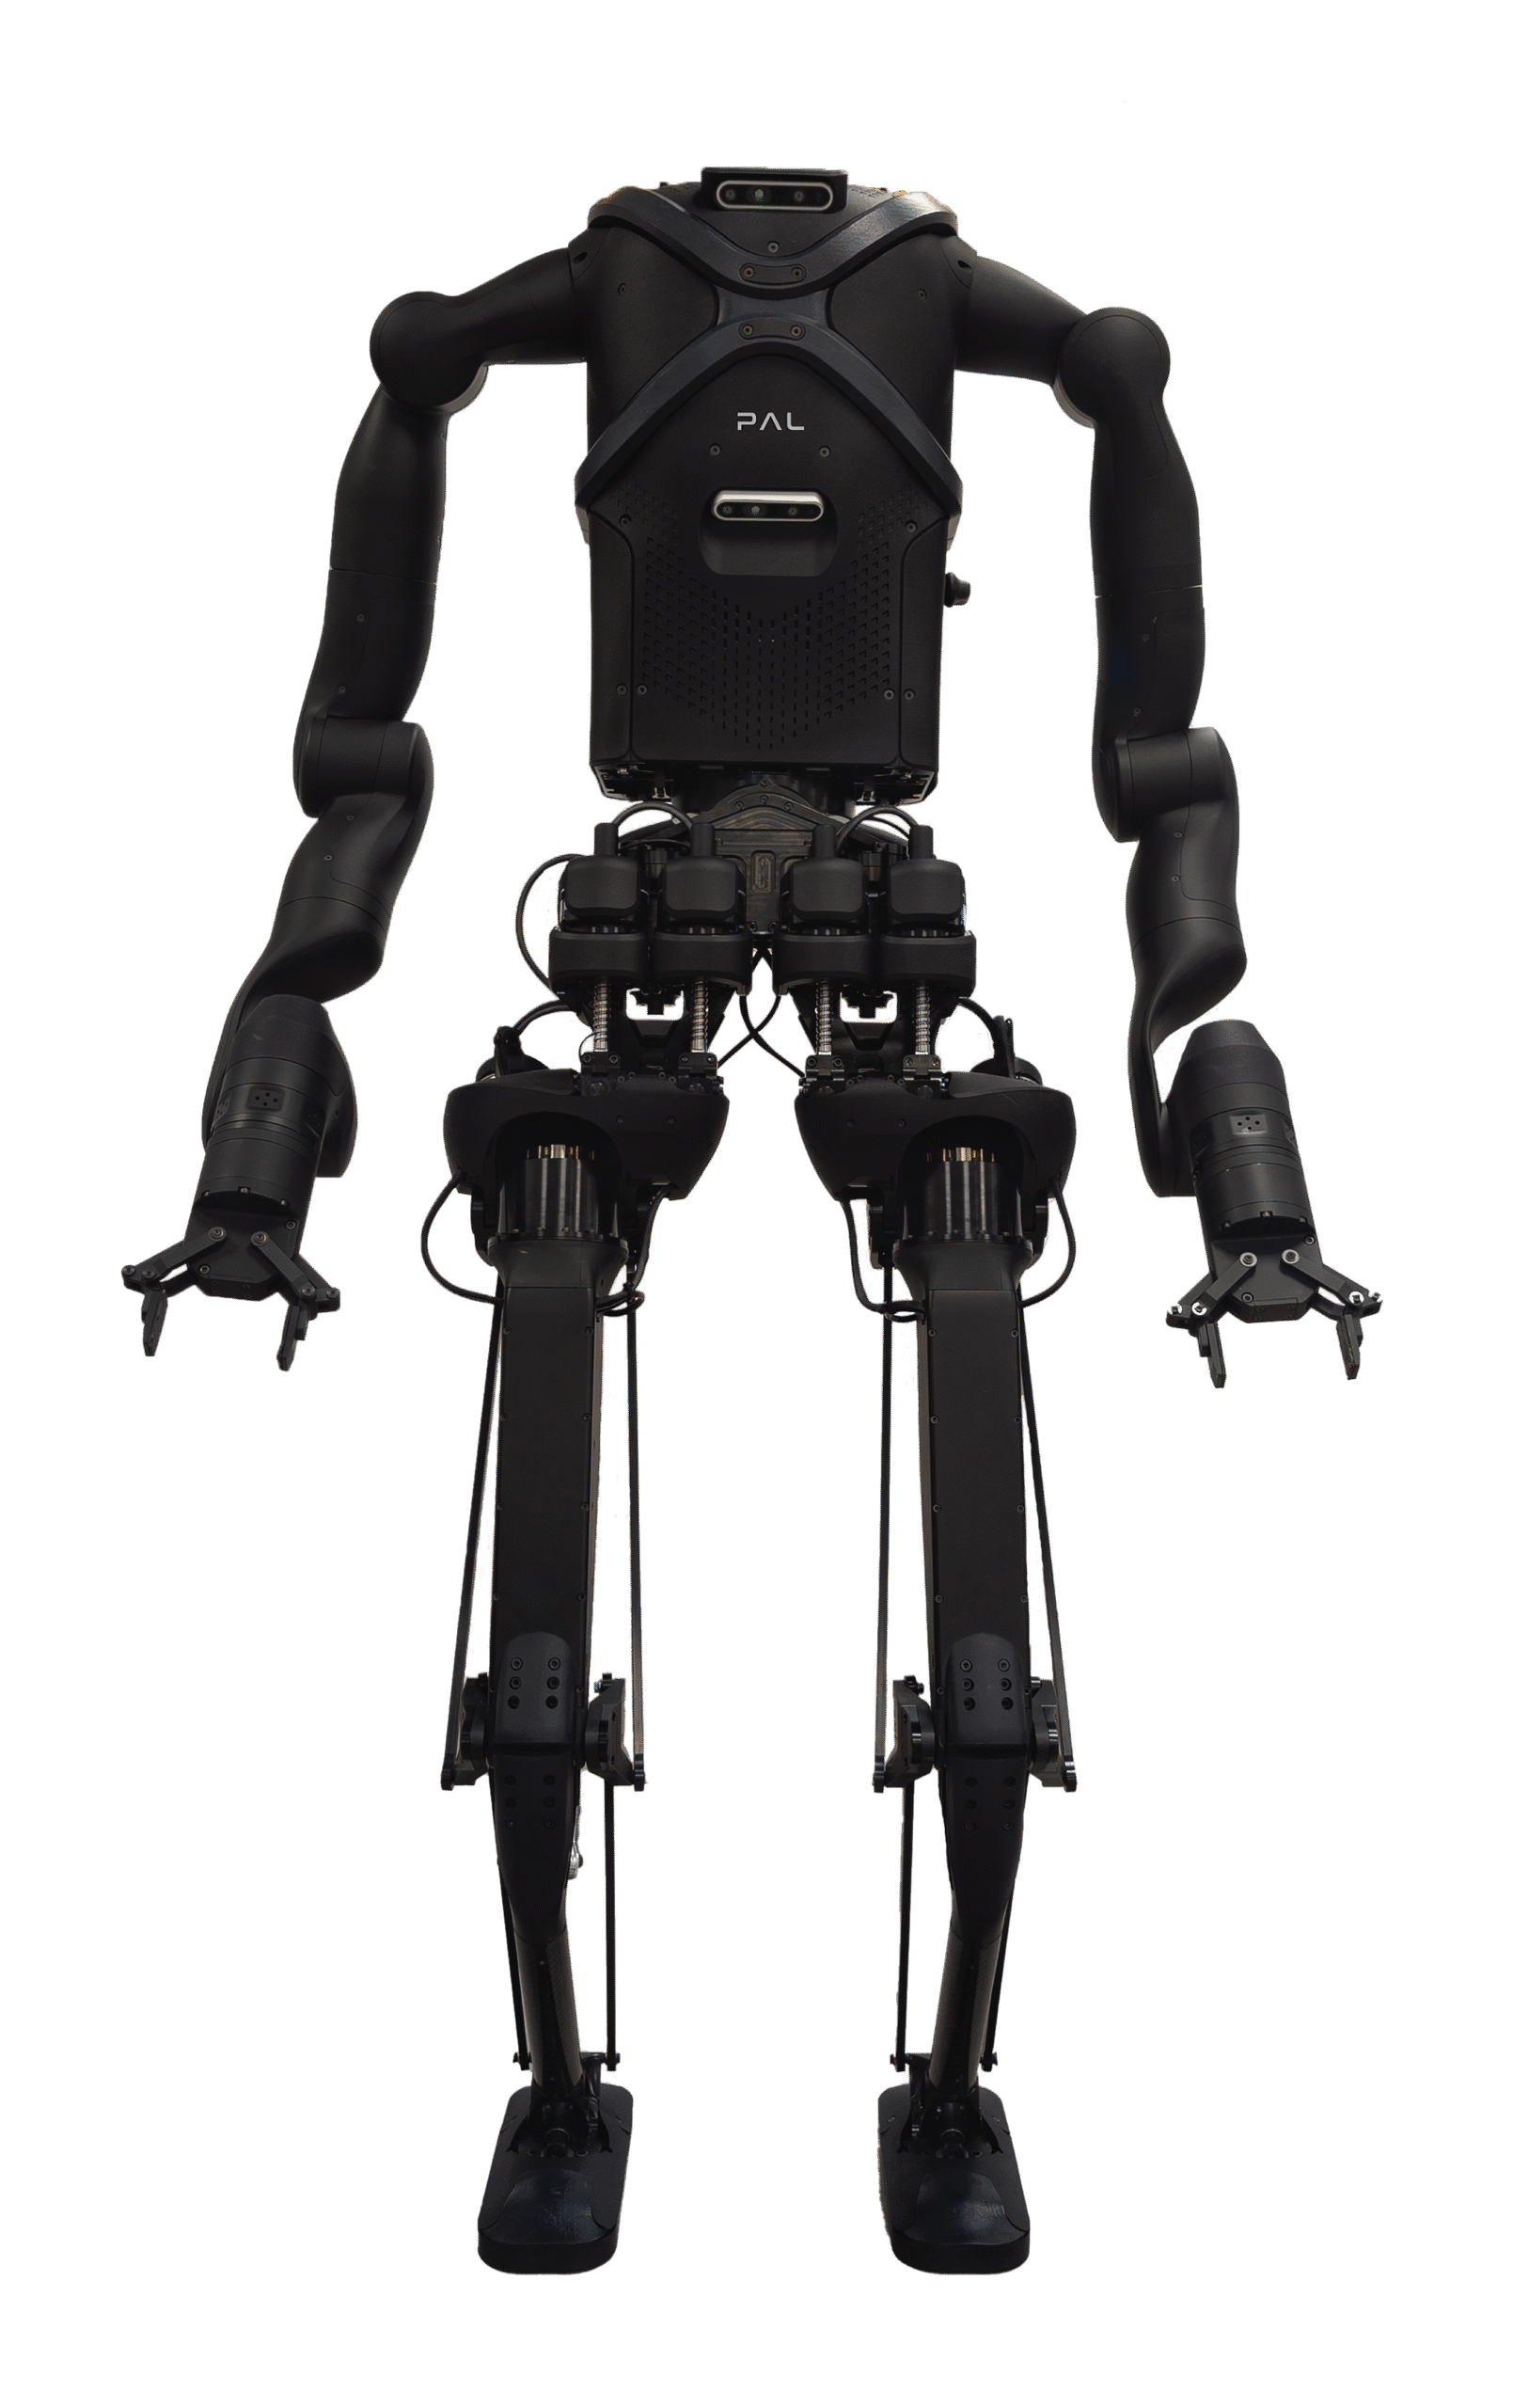
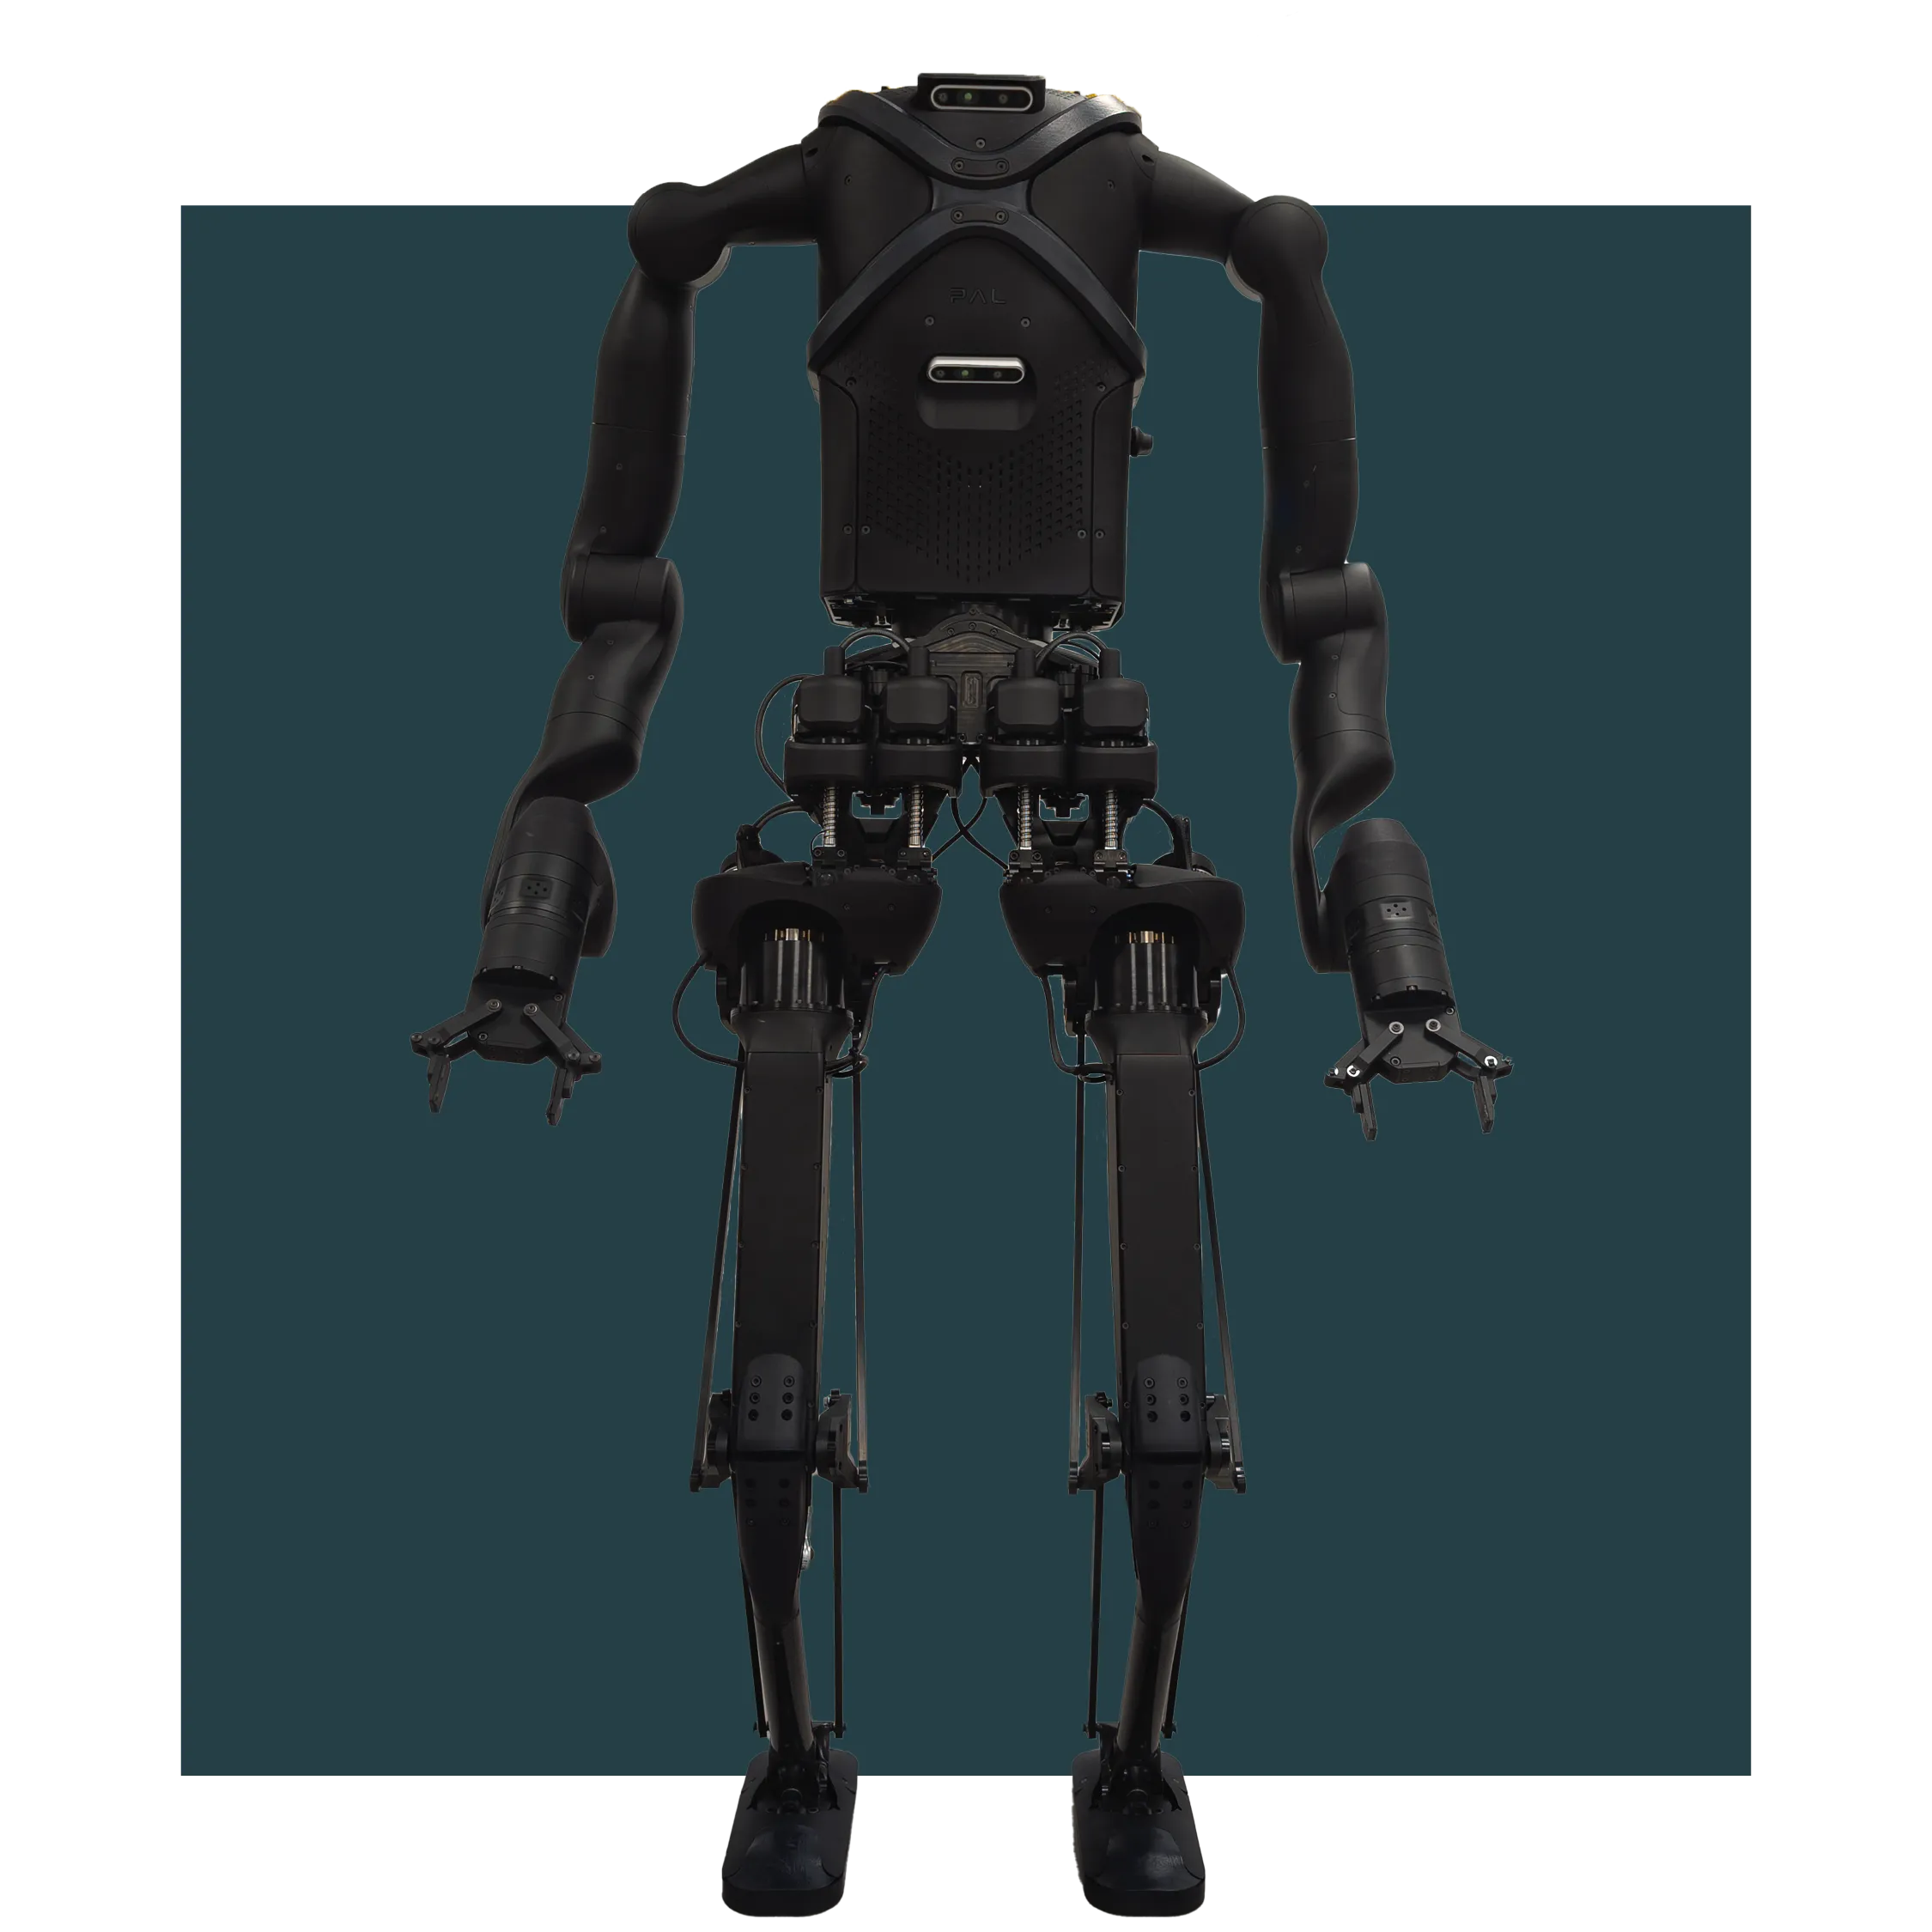
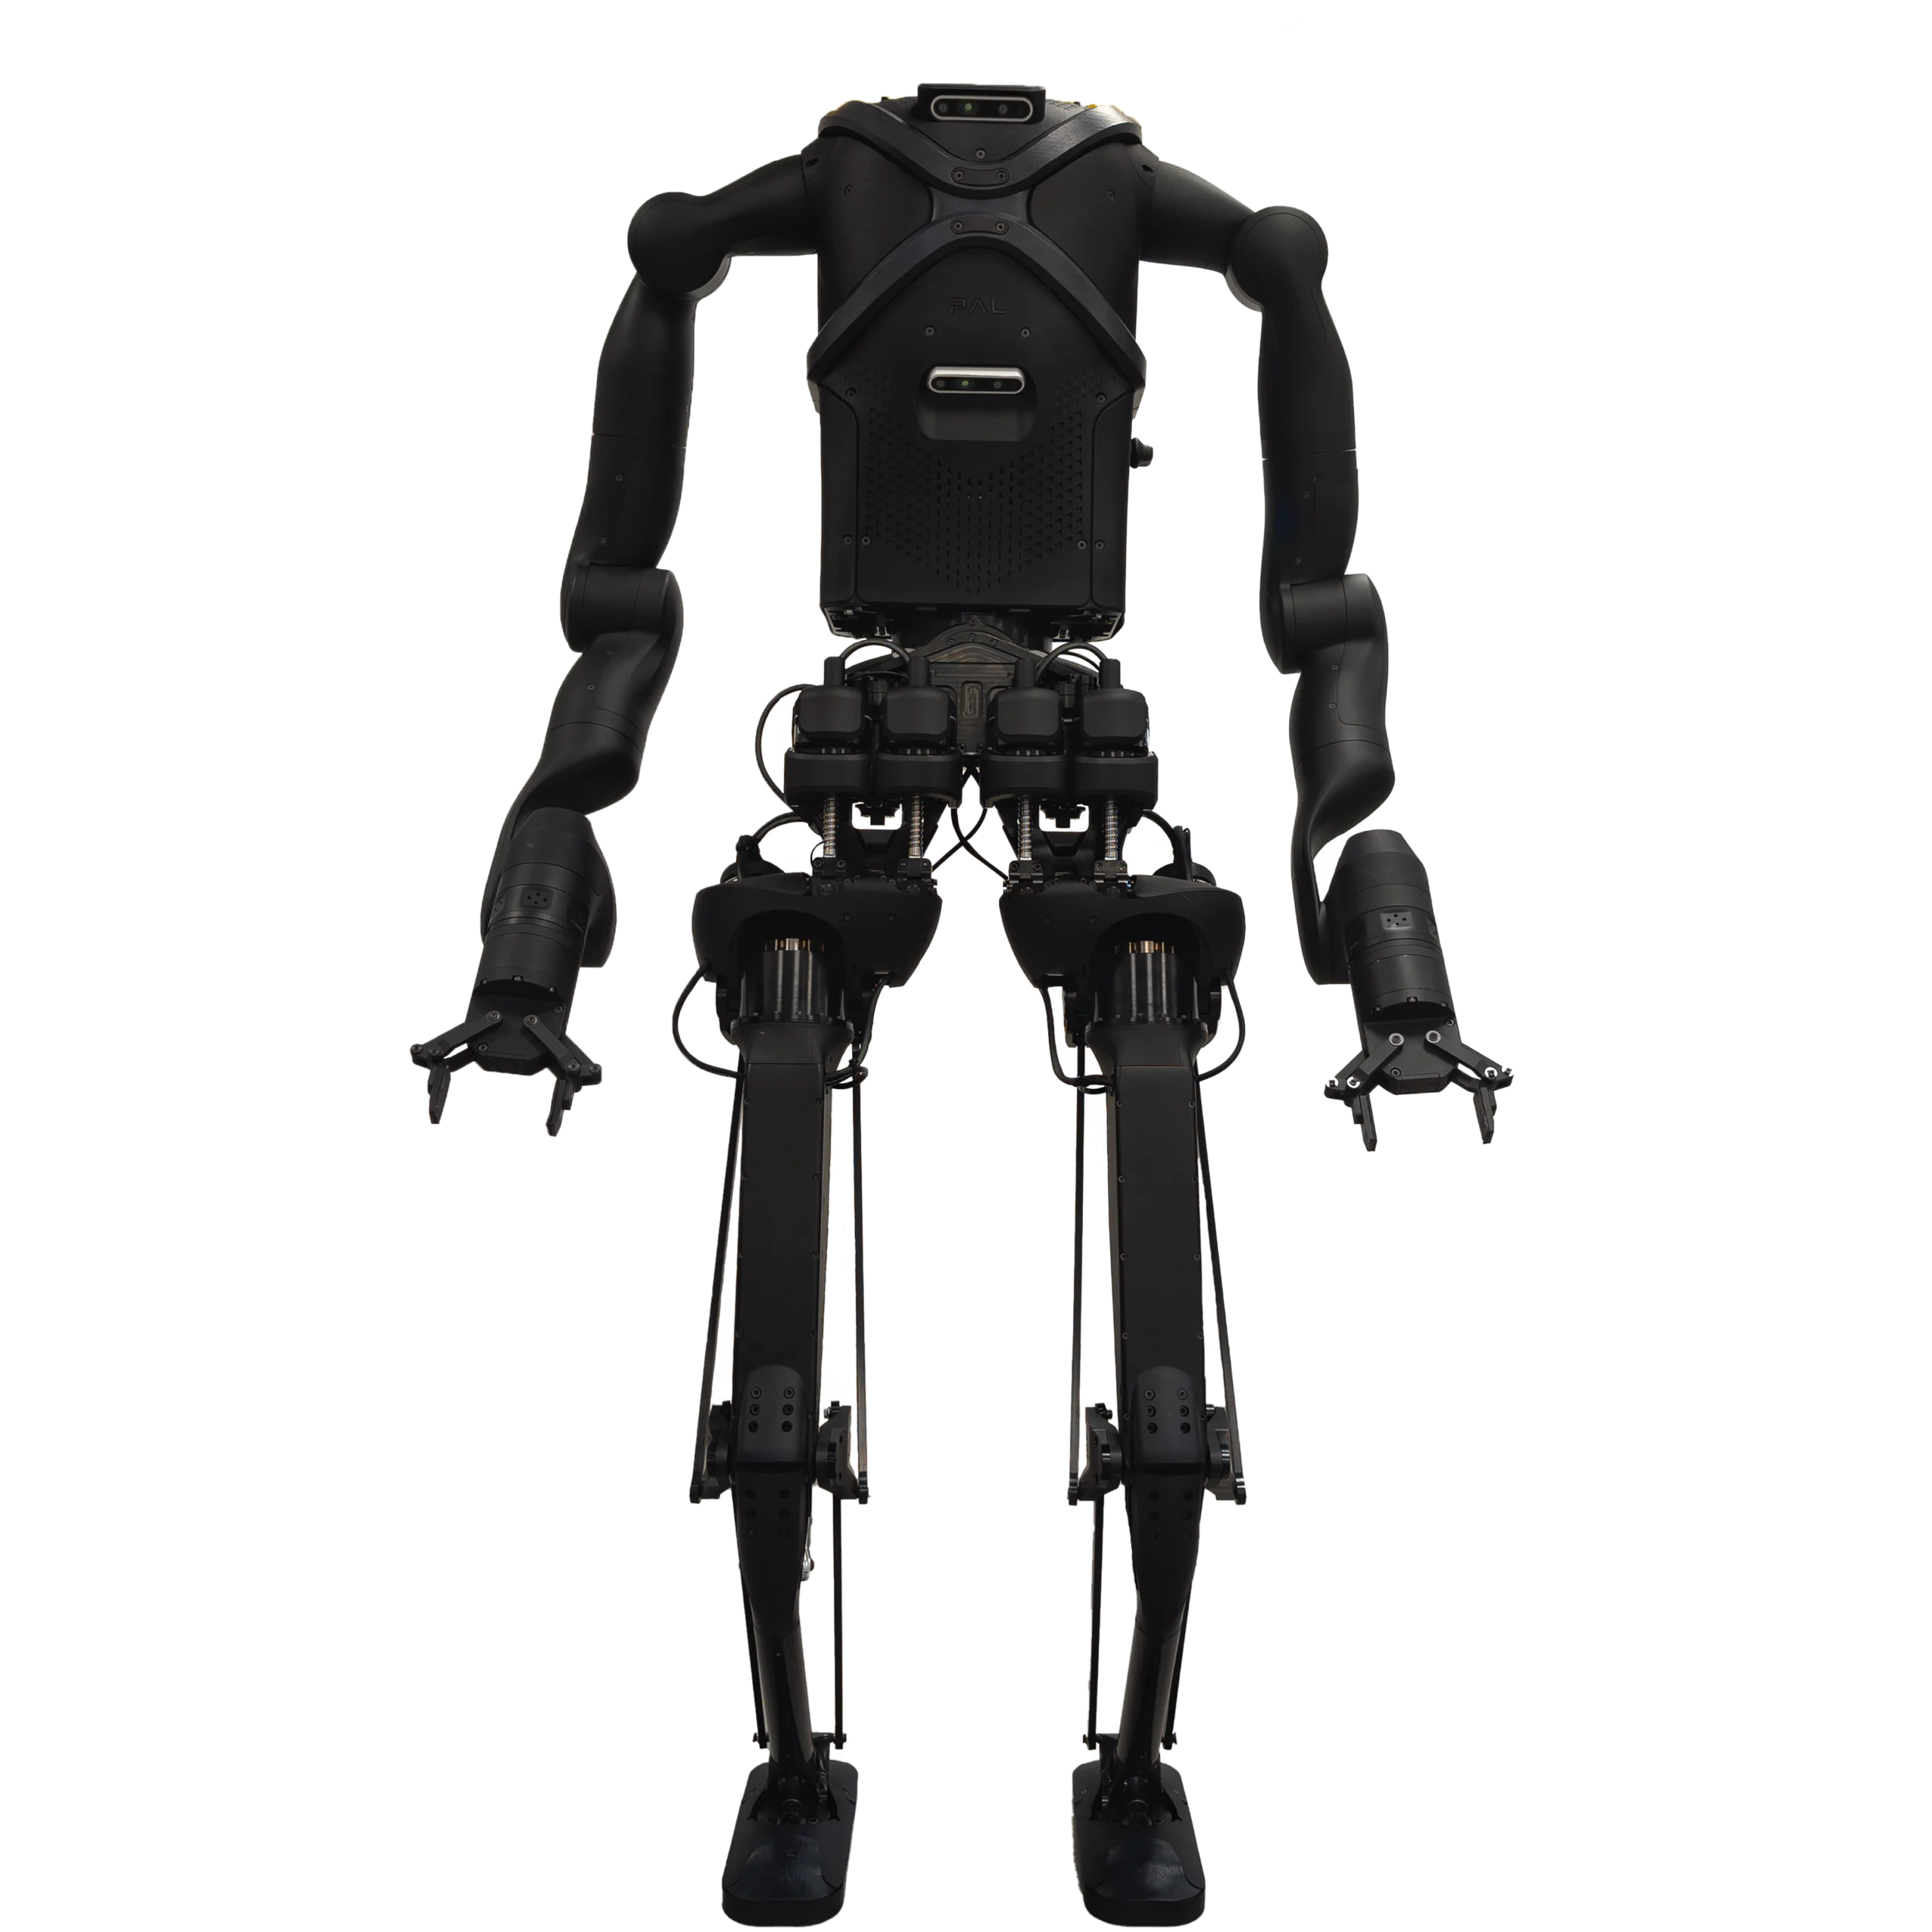
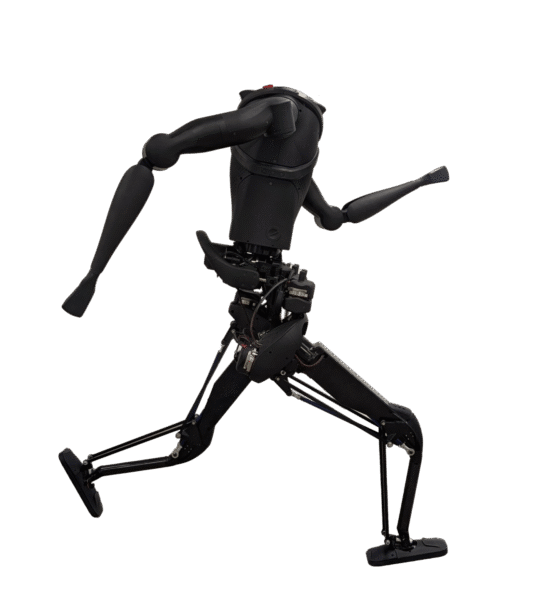
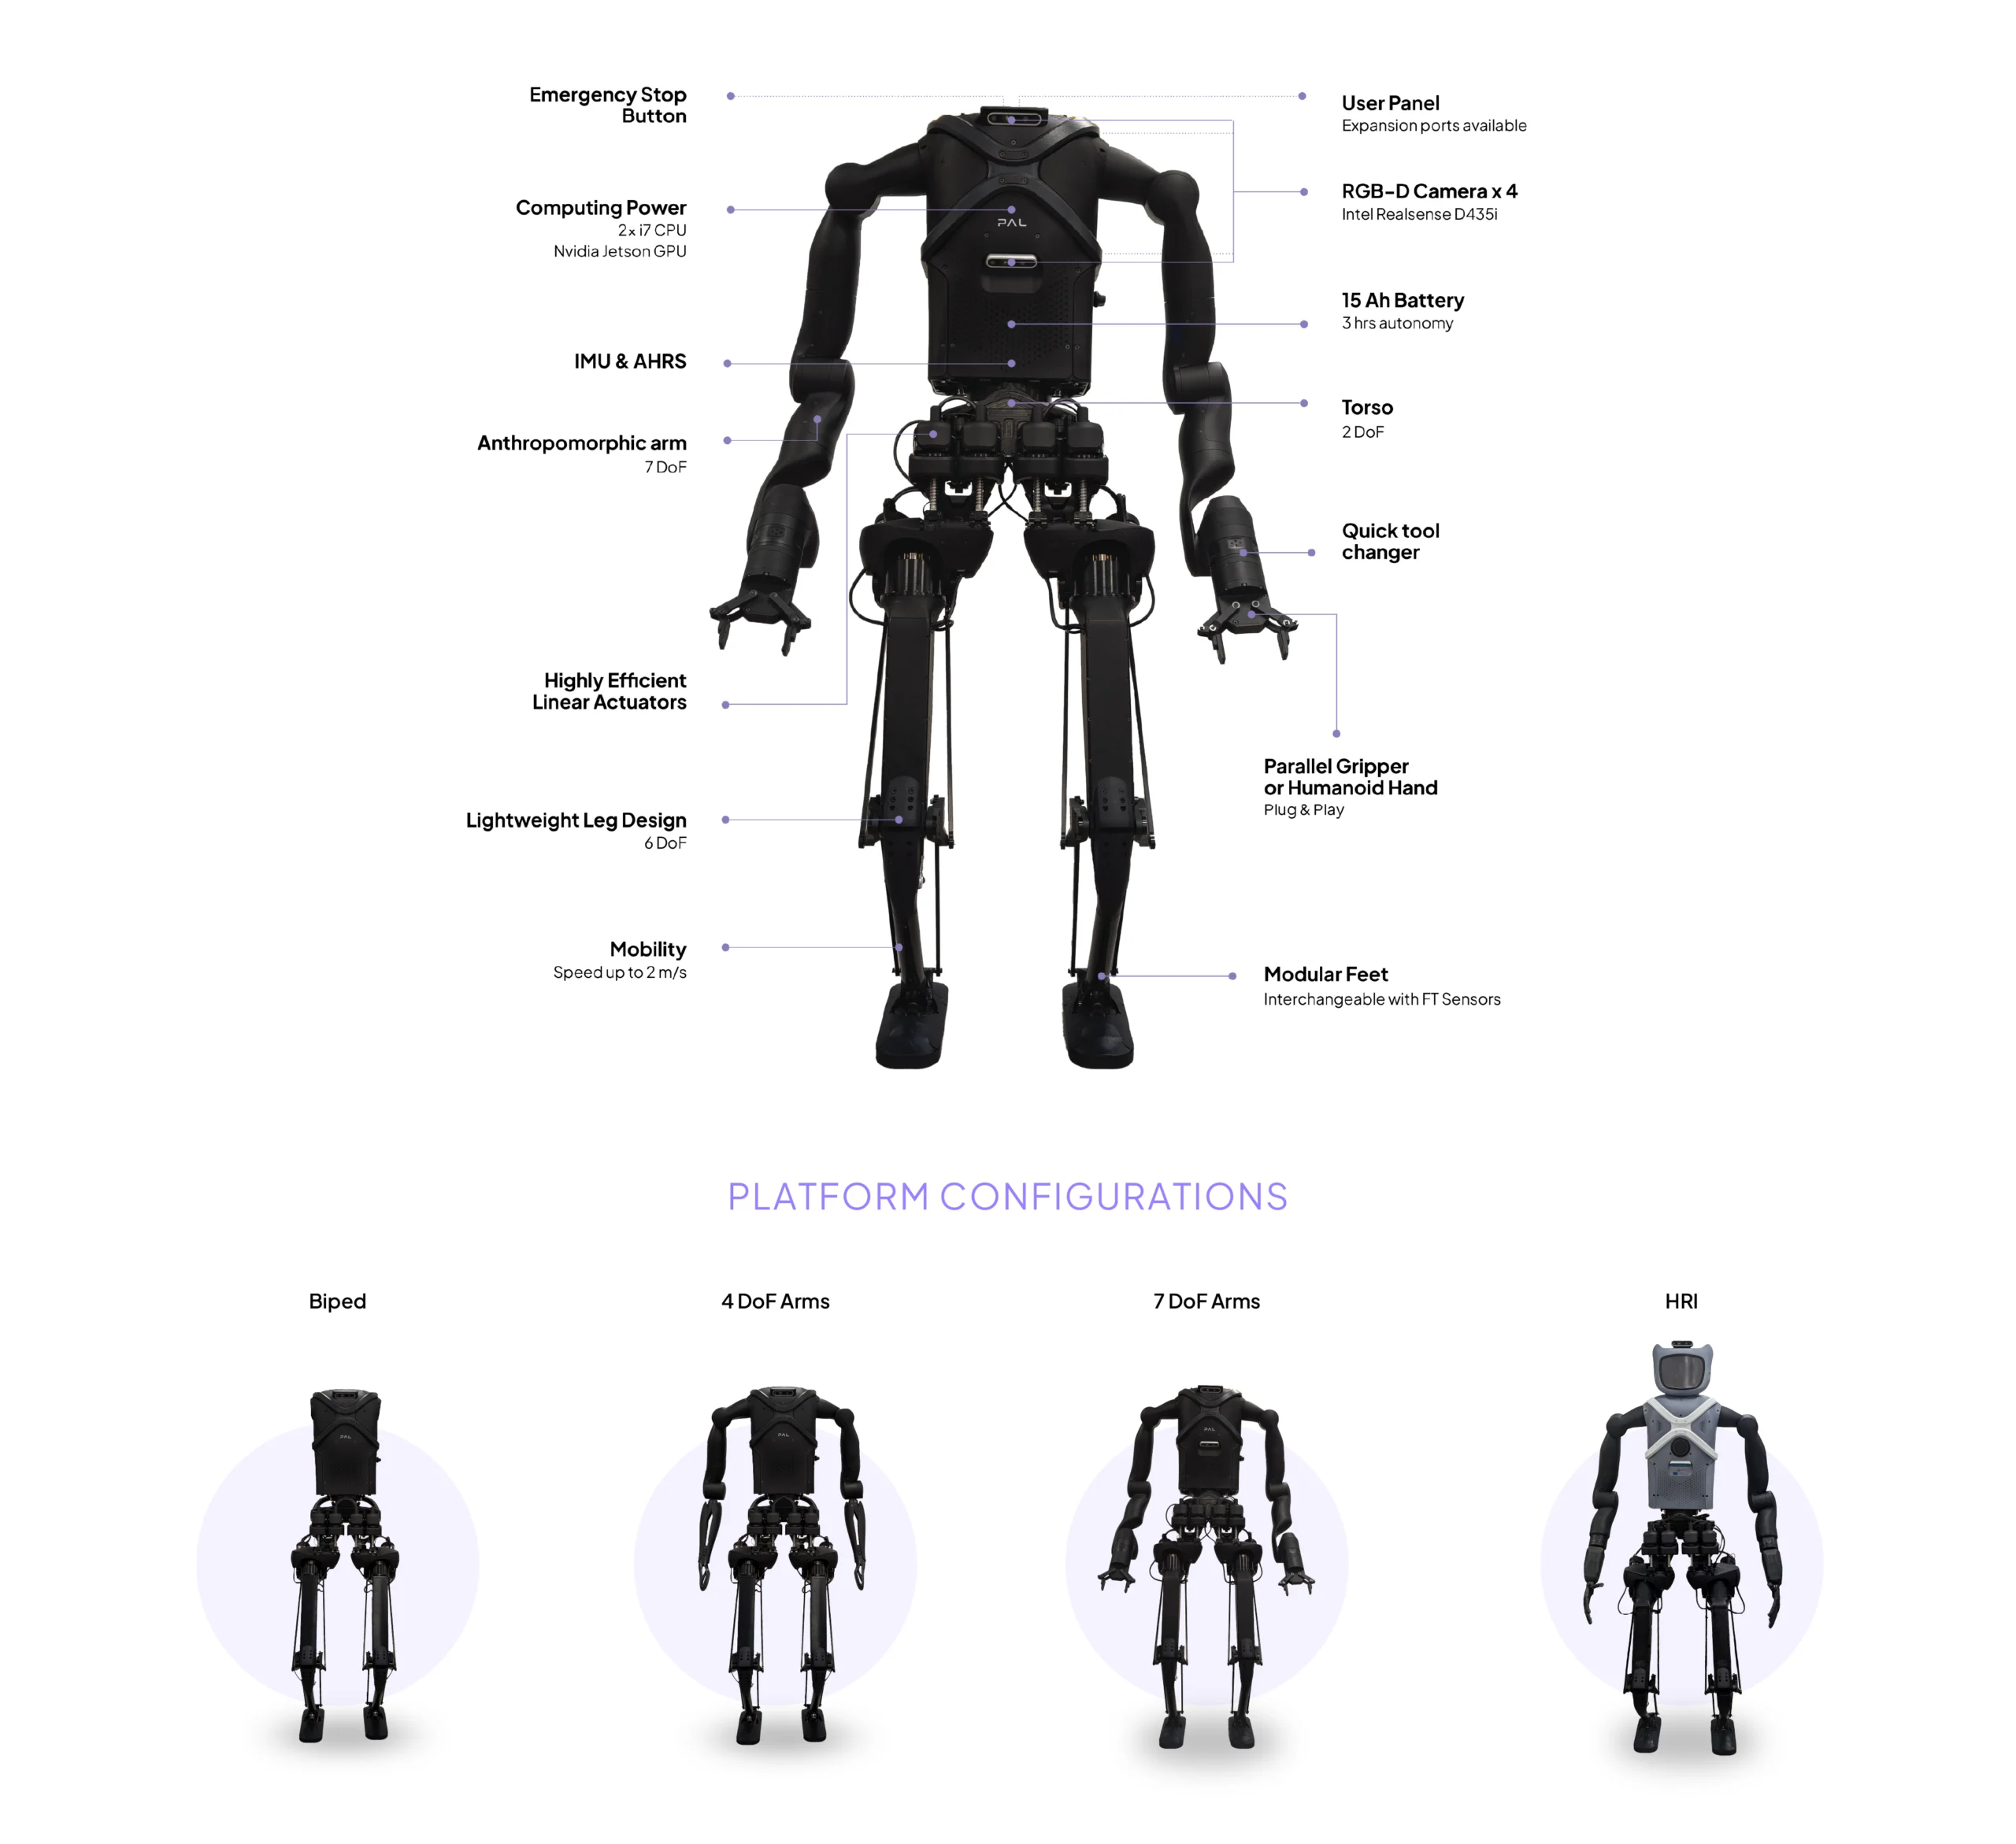
KANGAROO is PAL Robotics' bipedal research humanoid, built in Barcelona for work on dynamic locomotion, reinforcement learning and embodied AI. It is sold as a development platform: customisable, instrumented and open enough to experiment on rather than a finished product. The engineering choice that defines it is the drive. Custom linear actuators with integrated force sensors sit close to the body, giving a wide range of motion with high speed and torque at the joints while keeping the legs light; decoupling leg length from hip swing improves efficiency further. The result is low moving inertia in the legs, which means better impact resilience and lower energy consumption, and it is what makes highly dynamic motion possible. Closed-loop force and torque controllers at joint level let researchers try their own control algorithms rather than only the supplied ones. It stands 1.60 m and weighs 50-65 kg depending on configuration, with 14 to 40 degrees of freedom in total: 6 per leg, 2 in the torso for yaw and roll, and arms in 4, 5 or 7 degree-of-freedom versions carrying 7, 5 or 3 kg fully extended and up to 30, 28 or 25 kg bimanually. Control runs on an EtherCAT loop at 2 kHz with 0.25-degree static and 0.5-degree dynamic accuracy, rated PL d to EN ISO 13849-1. Two Intel i7 computers with 32 GB RAM and a 1 TB SSD each, plus an optional NVIDIA Jetson GPU, run Ubuntu LTS with ROS 2 LTS and PAL OS, with access to actuator PIDs, a whole-body inverse-dynamics controller, visualisation and diagnostics tools and a VR teleoperation demo. Sensing includes four RGB-D cameras, 6-axis force/torque sensors and fingertip tactile pressure sensors, on a 976 Wh battery.
功能特色
- Bipedal research humanoid: 1.60 m, 50-65 kg
- 14-40 total degrees of freedom depending on configuration
- 6 degrees of freedom per leg
- 2 in the torso (yaw and roll)
- Arms in 4, 5 or 7 degree-of-freedom versions
- Payload 7 kg (4 DoF), 5 kg (5 DoF) or 3 kg (7 DoF) fully extended
- Up to 30 kg bimanual payload
- Custom linear actuators with integrated force sensors
- Low moving inertia in the legs for impact resilience and efficiency
- Leg length decoupled from hip swing for efficiency
- Closed-loop force/torque control at joint level
- EtherCAT control loop at 2 kHz
- Accuracy 0.25 degrees static, 0.5 degrees dynamic
- Rated PL d to EN ISO 13849-1
- 2 x Intel i7 with 32 GB RAM and 1 TB SSD
- optional NVIDIA Jetson GPU
- Ubuntu LTS with ROS 2 LTS and PAL OS, with access to actuator PIDs
- Whole-body inverse-dynamics controller and VR teleoperation demo
- 4 x RGB-D cameras, 6-axis force/torque and fingertip tactile sensors
- 976 Wh battery (15 Ah, 63 V)
- ISO 9409-1 tool flange with quick tool changer
技術規格
已驗證| 物理參數 | |
| 重量 | 50-65 kg |
|---|---|
| 外形尺寸 | H 1.6 m |
| 負載 | 7 kg |
| 移動能力 | |
| 移動類型 | 兩足行走, 類人型機器人 |
| 操作能力 | 中 |
| 作業環境 | Laboratory and research settings. |
| 致動器 | Custom linear actuators with integrated force sensors |
| 電源與續航 | |
| 續航時間 | 15 Ah, 63 V, 976 Wh |
| 感知與計算 | |
| 感測器 | 4 x RGB-D cameras, 6-axis force/torque sensors, Fingertip tactile pressure sensors, Joint position encoders |
| 連線方式 | EtherCAT 2 kHz control loop |
| 軟體 / AI | Ubuntu LTS, ROS 2 LTS and PAL OS; whole-body inverse-dynamics controller; visualisation and diagnostics; VR teleoperation demo |
圖片
圖片貢獻
影片
機器人論壇
正在載入論壇...
評分
常見問題
What is the KANGAROO?
KANGAROO is PAL Robotics' bipedal research humanoid, built in Barcelona for work on dynamic locomotion, reinforcement learning and embodied AI. It is sold as a development platform: customisable, instrumented and open enough to experiment on rather than a finished product.
Who makes the KANGAROO?
The KANGAROO is made by PAL Robotics, a robotics company based in Spain.
How much does the KANGAROO cost?
PAL Robotics has not publicly announced pricing for the KANGAROO. You can enquire through RobotAIGeek for current pricing.
What is the KANGAROO used for?
The KANGAROO is designed for 發展, 操縱, and 研究. It is used in 研究 and 教育 settings.
What is the payload capacity of the KANGAROO?
The KANGAROO has a payload capacity of 7 kg.
How much does the KANGAROO weigh?
The KANGAROO weighs 65 kg.
與同類機器人對比
看看這款機器人與最接近的同類產品相比表現如何
- KANGAROO vs Tokyo Robotics Torobo
- KANGAROO vs Dexmate Vega
- KANGAROO vs Lanxin H6 Standard
- KANGAROO vs Elf3
- KANGAROO vs Noetix E1