
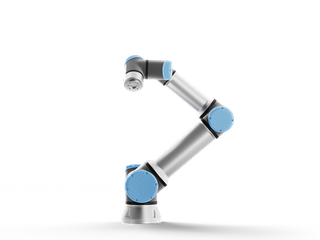
描述
Universal Robots UR16e is a six-axis collaborative robot from Universal Robots A/S (Denmark). OEM-cited payload 16 kg and reach 900 mm. Built for flexible industrial automation alongside human operators.
功能特点
- Universal Robots UR16e collaborative robot (6-axis cobot)
- Payload: 16 kg
- Reach: 900 mm
技术规格
| 物理参数 | |
| 重量 | 33.1 kg |
|---|---|
| 负载 | 16 kg |
| 臂展 | 900 mm |
| 移动能力 | |
| 运动类型 | 文具 |
| 自由度 | 6 |
| 速度 | 10.8 km/h |
| 操作能力 | 高 |
| 作业环境 | IP54, ?°C to 50°C |
技术规格
| 物理参数 | |
| 重量 | 33.1 kg |
|---|---|
| 负载 | 16 kg |
| 臂展 | 900 mm |
| 移动能力 | |
| 运动类型 | 文具 |
| 自由度 | 6 |
| 速度 | 10.8 km/h |
| 操作能力 | 高 |
| 作业环境 | IP54, ?°C to 50°C |
图片
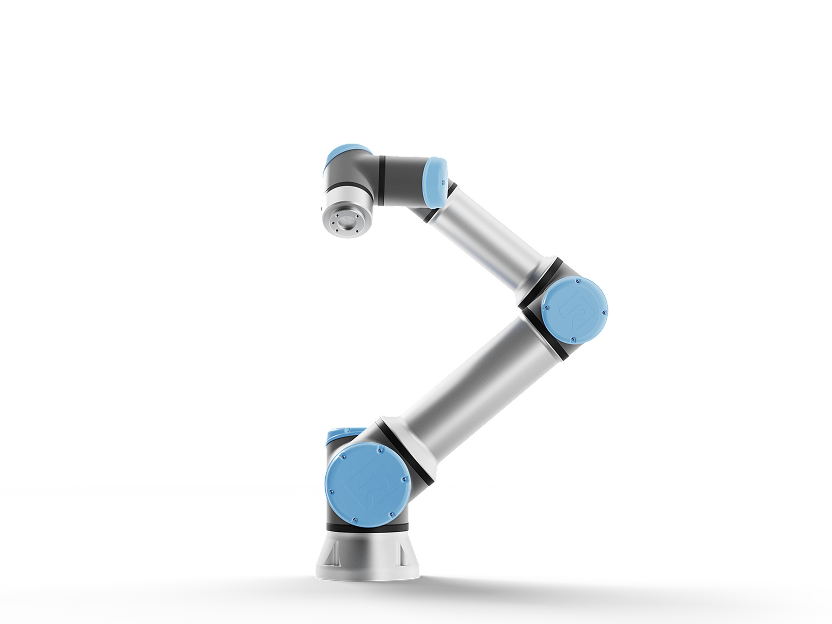
 martti
图片贡献
机器人论坛
正在加载论坛...
评分
常见问题
What is the Universal Robots UR16e?
Universal Robots UR16e is a six-axis collaborative robot from Universal Robots A/S (Denmark). OEM-cited payload 16 kg and reach 900 mm. Built for flexible industrial automation alongside human operators.
Who makes the Universal Robots UR16e?
The Universal Robots UR16e is made by Universal Robots, a robotics company based in Denmark.
How much does the Universal Robots UR16e cost?
Universal Robots has not publicly announced pricing for the Universal Robots UR16e. You can enquire through RobotAIGeek for current pricing.
What is the Universal Robots UR16e used for?
The Universal Robots UR16e is designed for 组装 and 拾放. It is used in 汽车 and 制造业 settings.
What is the payload capacity of the Universal Robots UR16e?
The Universal Robots UR16e has a payload capacity of 16 kg and a reach of 900 mm.
How much does the Universal Robots UR16e weigh?
The Universal Robots UR16e weighs 33.1 kg.
How fast is the Universal Robots UR16e?
The Universal Robots UR16e can move at speeds of up to 10.8 km/h.
How many degrees of freedom does the Universal Robots UR16e have?
The Universal Robots UR16e has 6 degrees of freedom.
与同类机器人对比
看看这款机器人与最接近的同类产品相比表现如何
- Universal Robots UR16e vs Perceptyne PR-DUO
- Universal Robots UR16e vs UR18g-950
- Universal Robots UR16e vs Elfin E10
- Universal Robots UR16e vs CS530H
- Universal Robots UR16e vs CS612