
描述
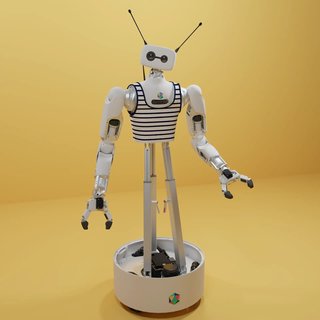
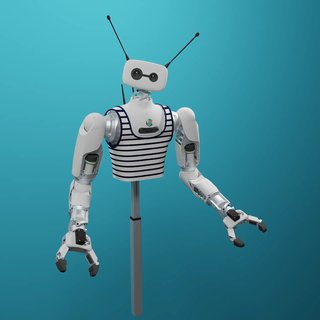
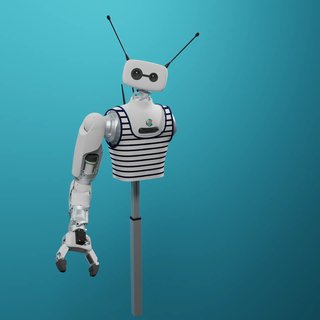
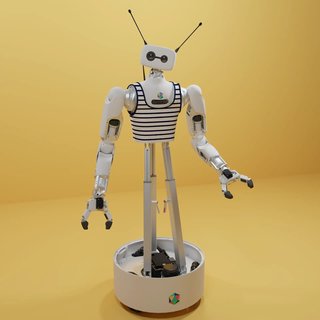
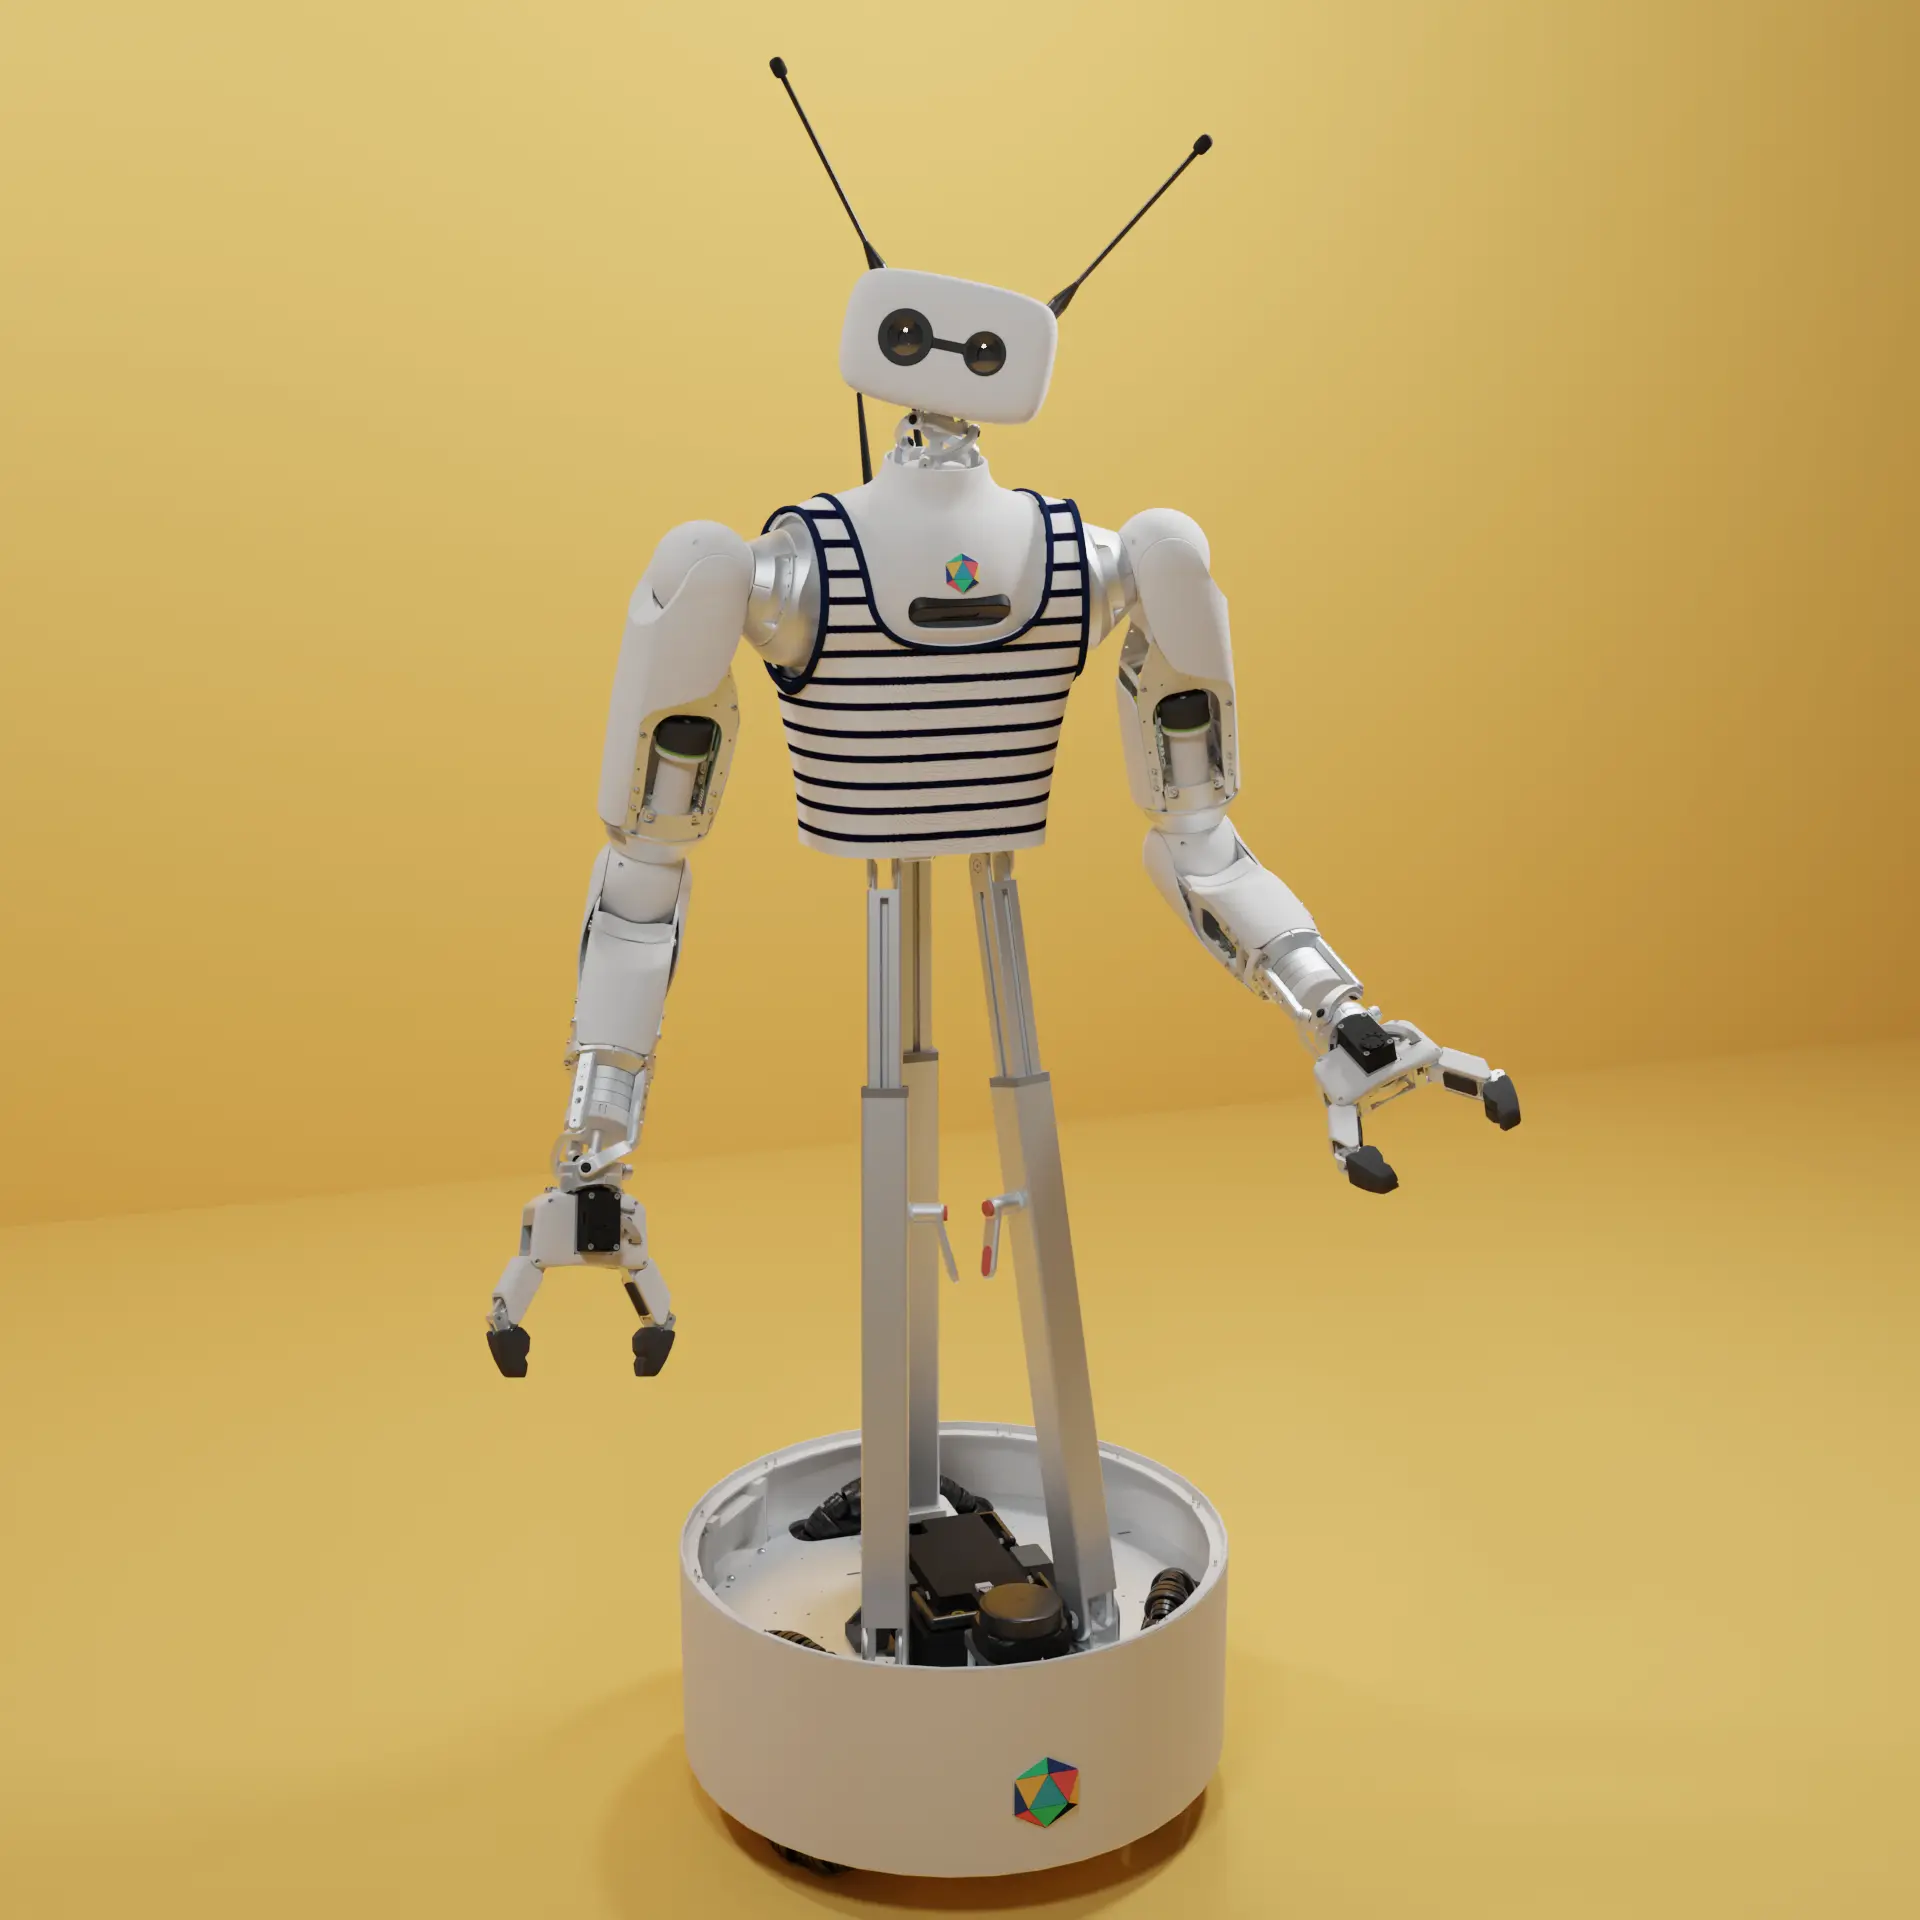
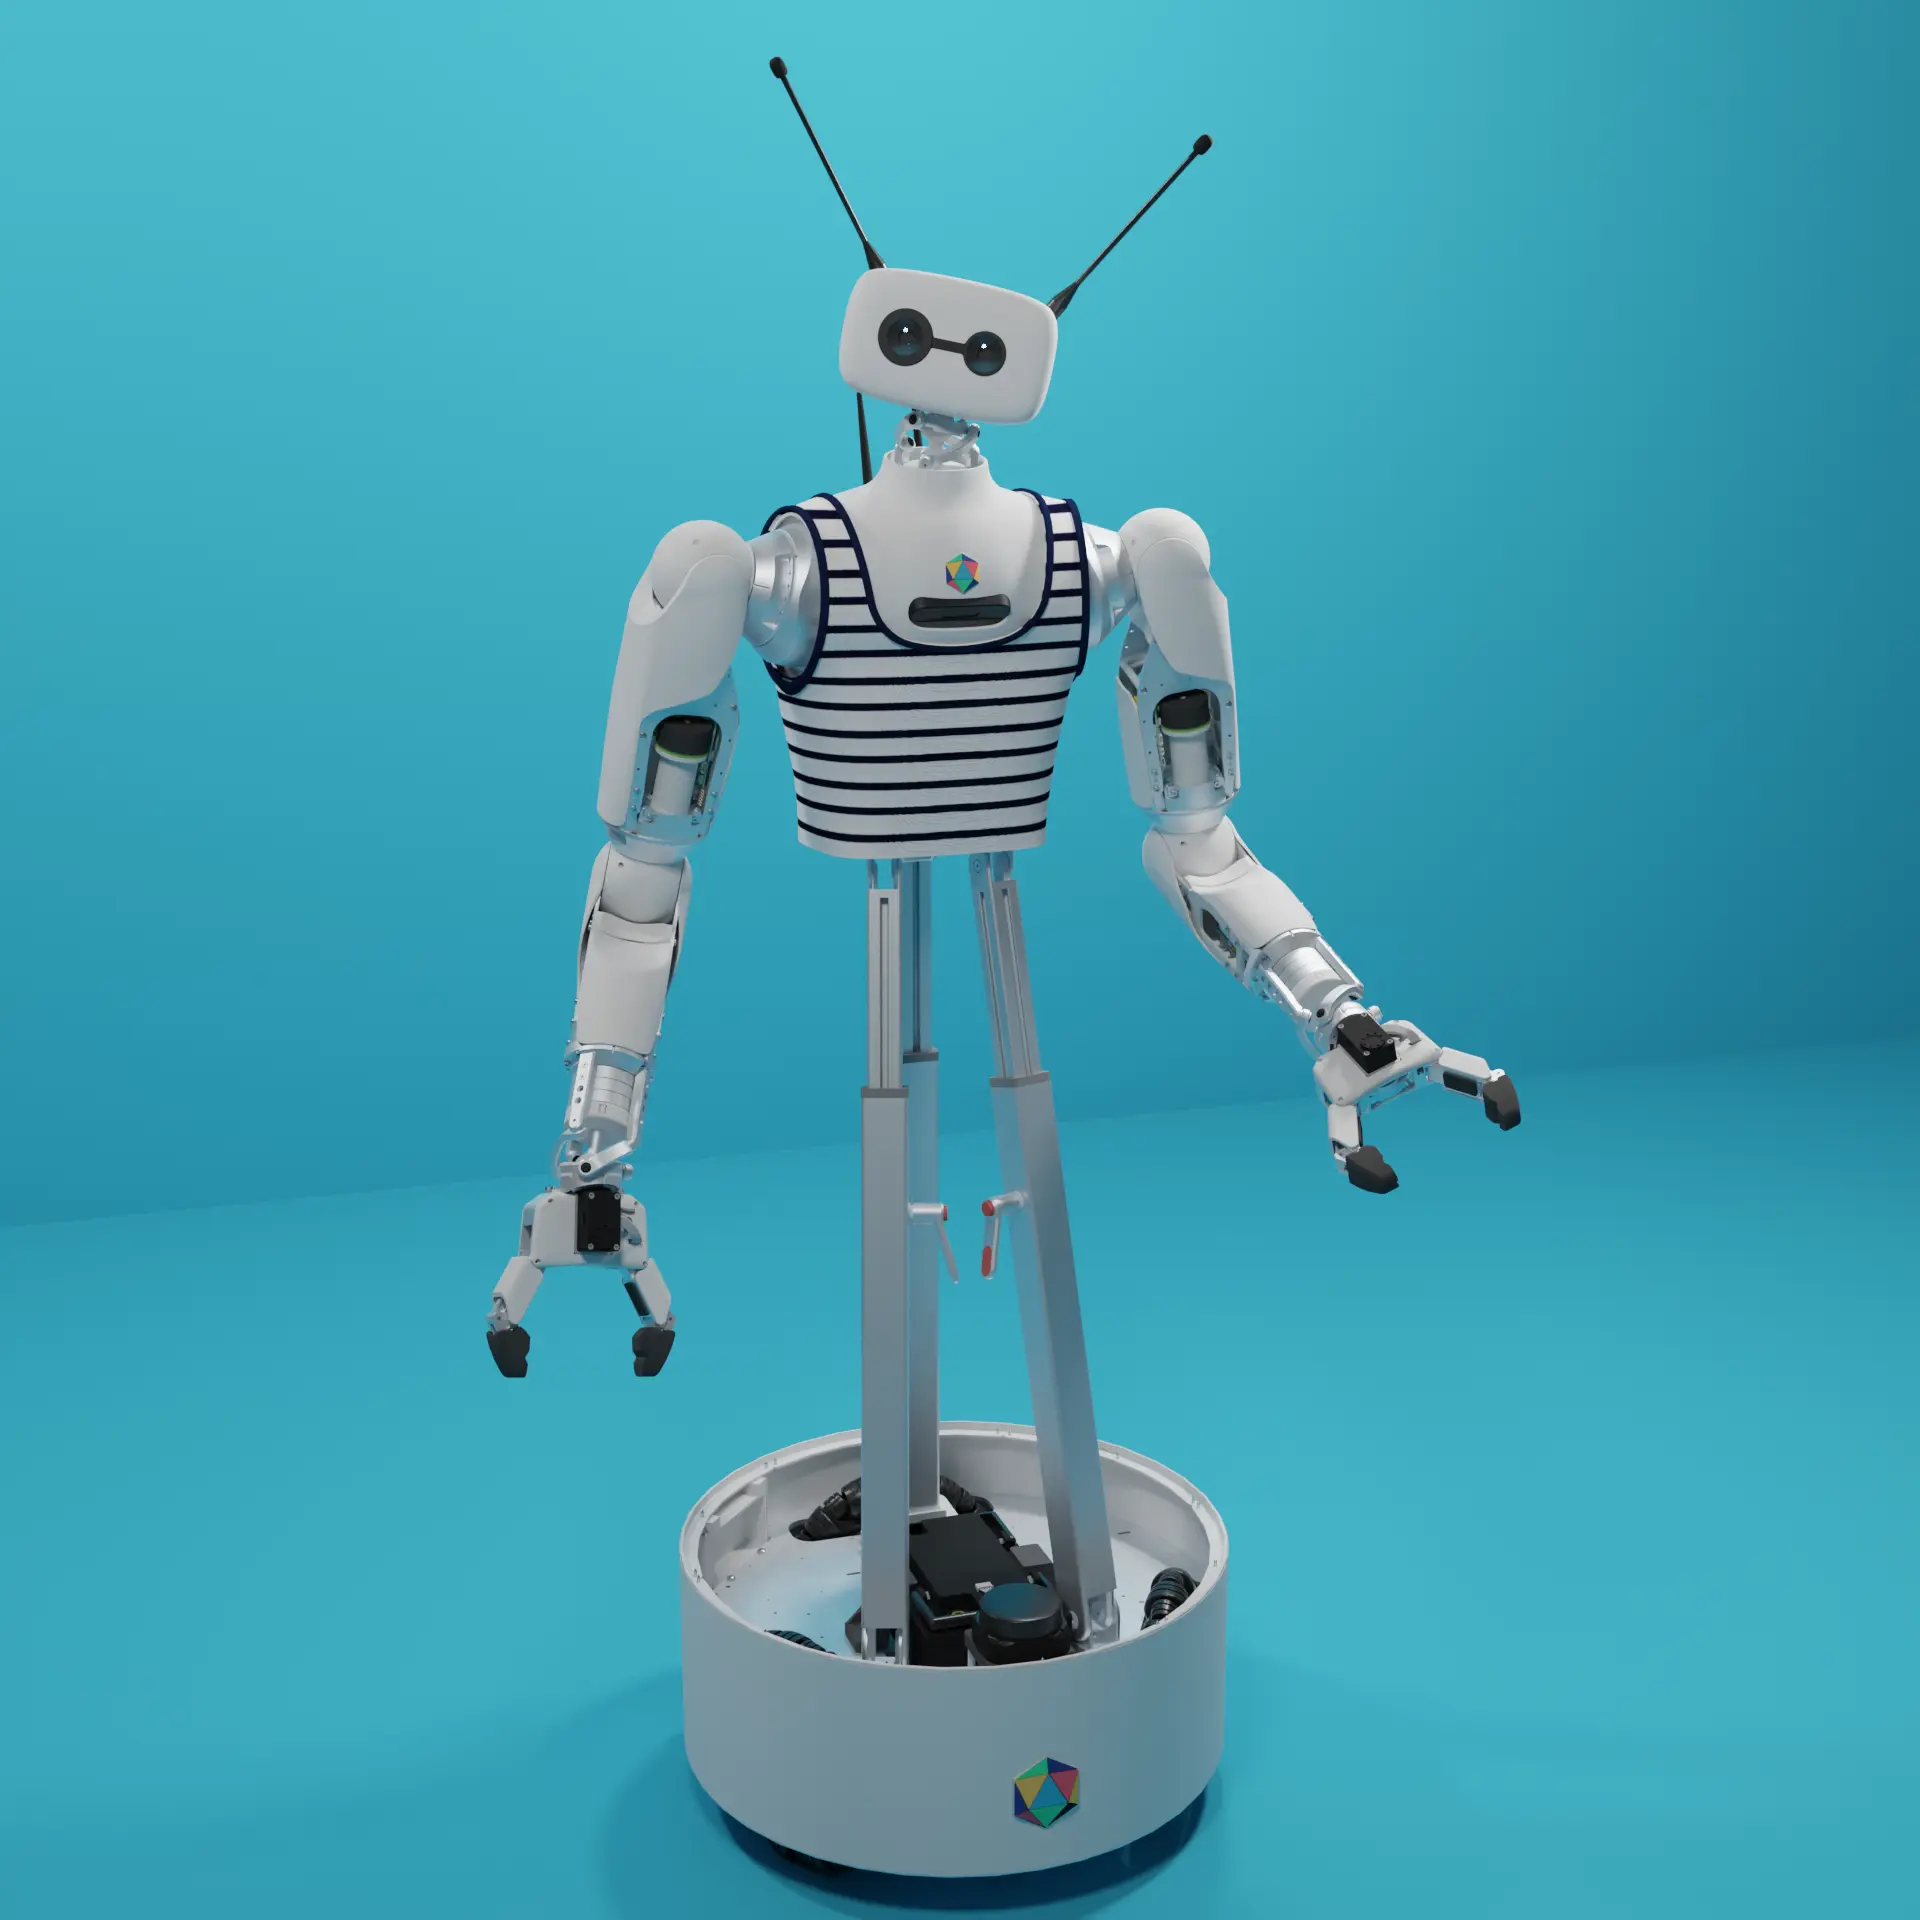
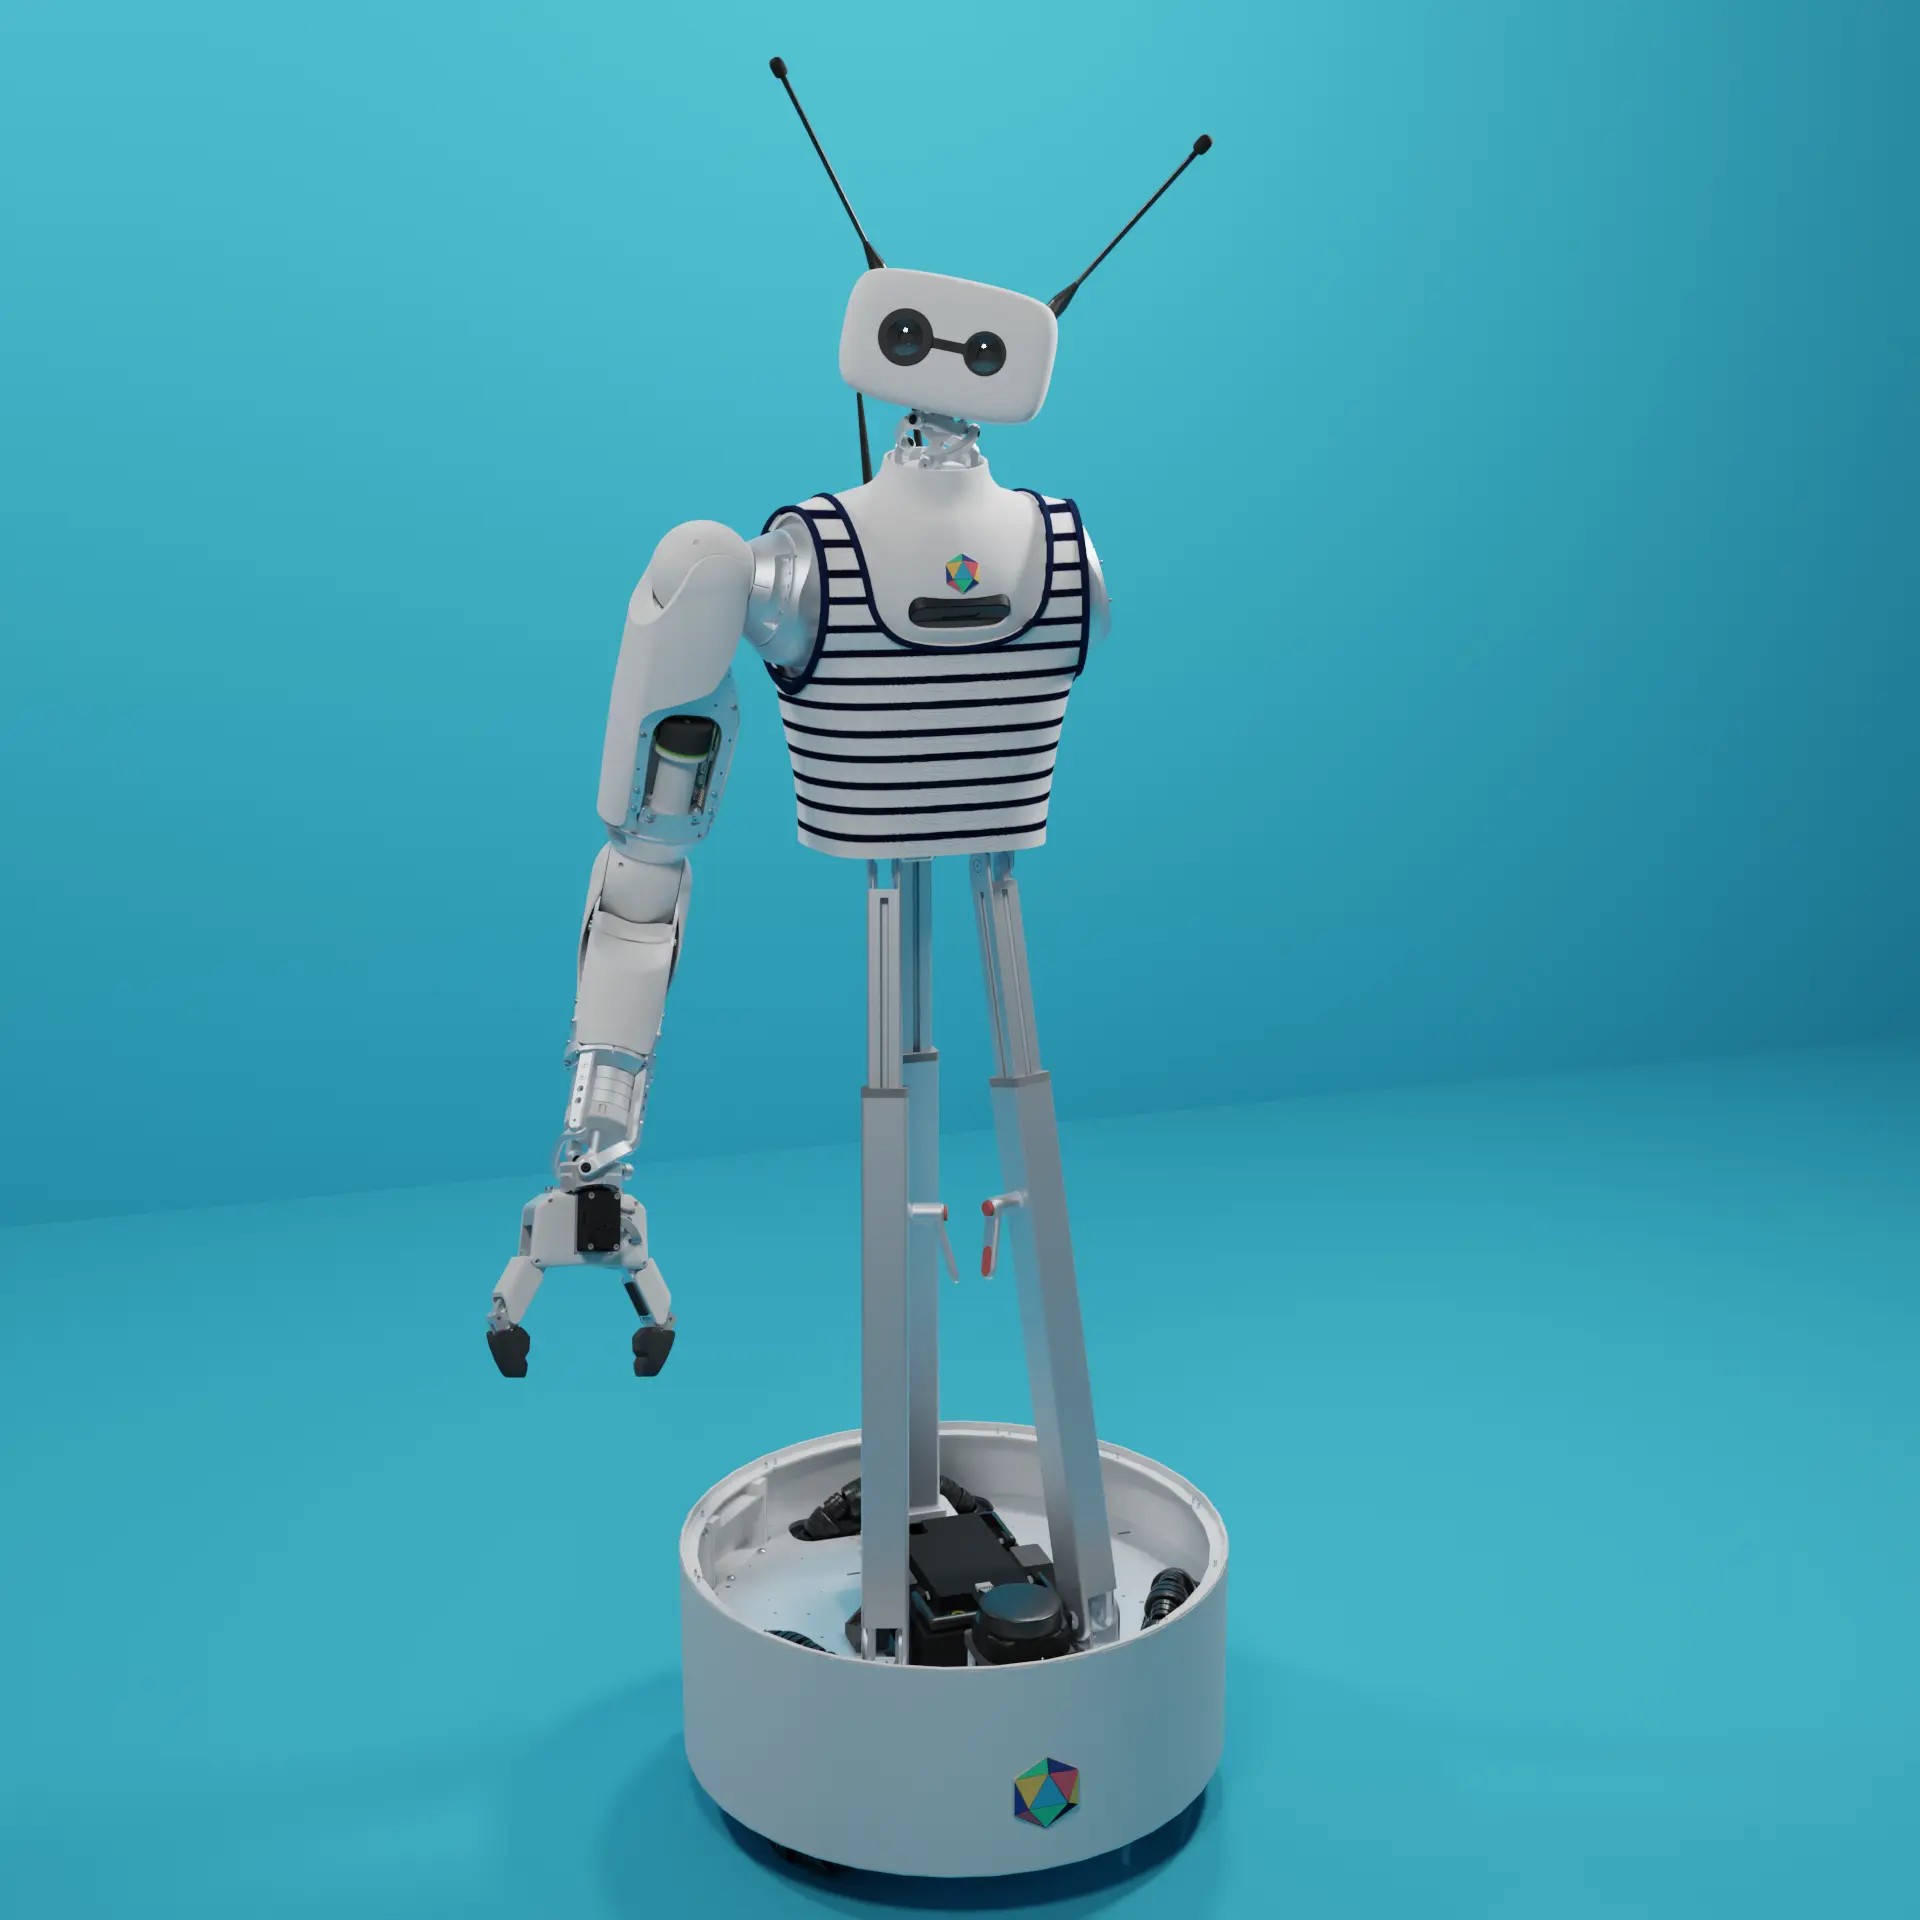
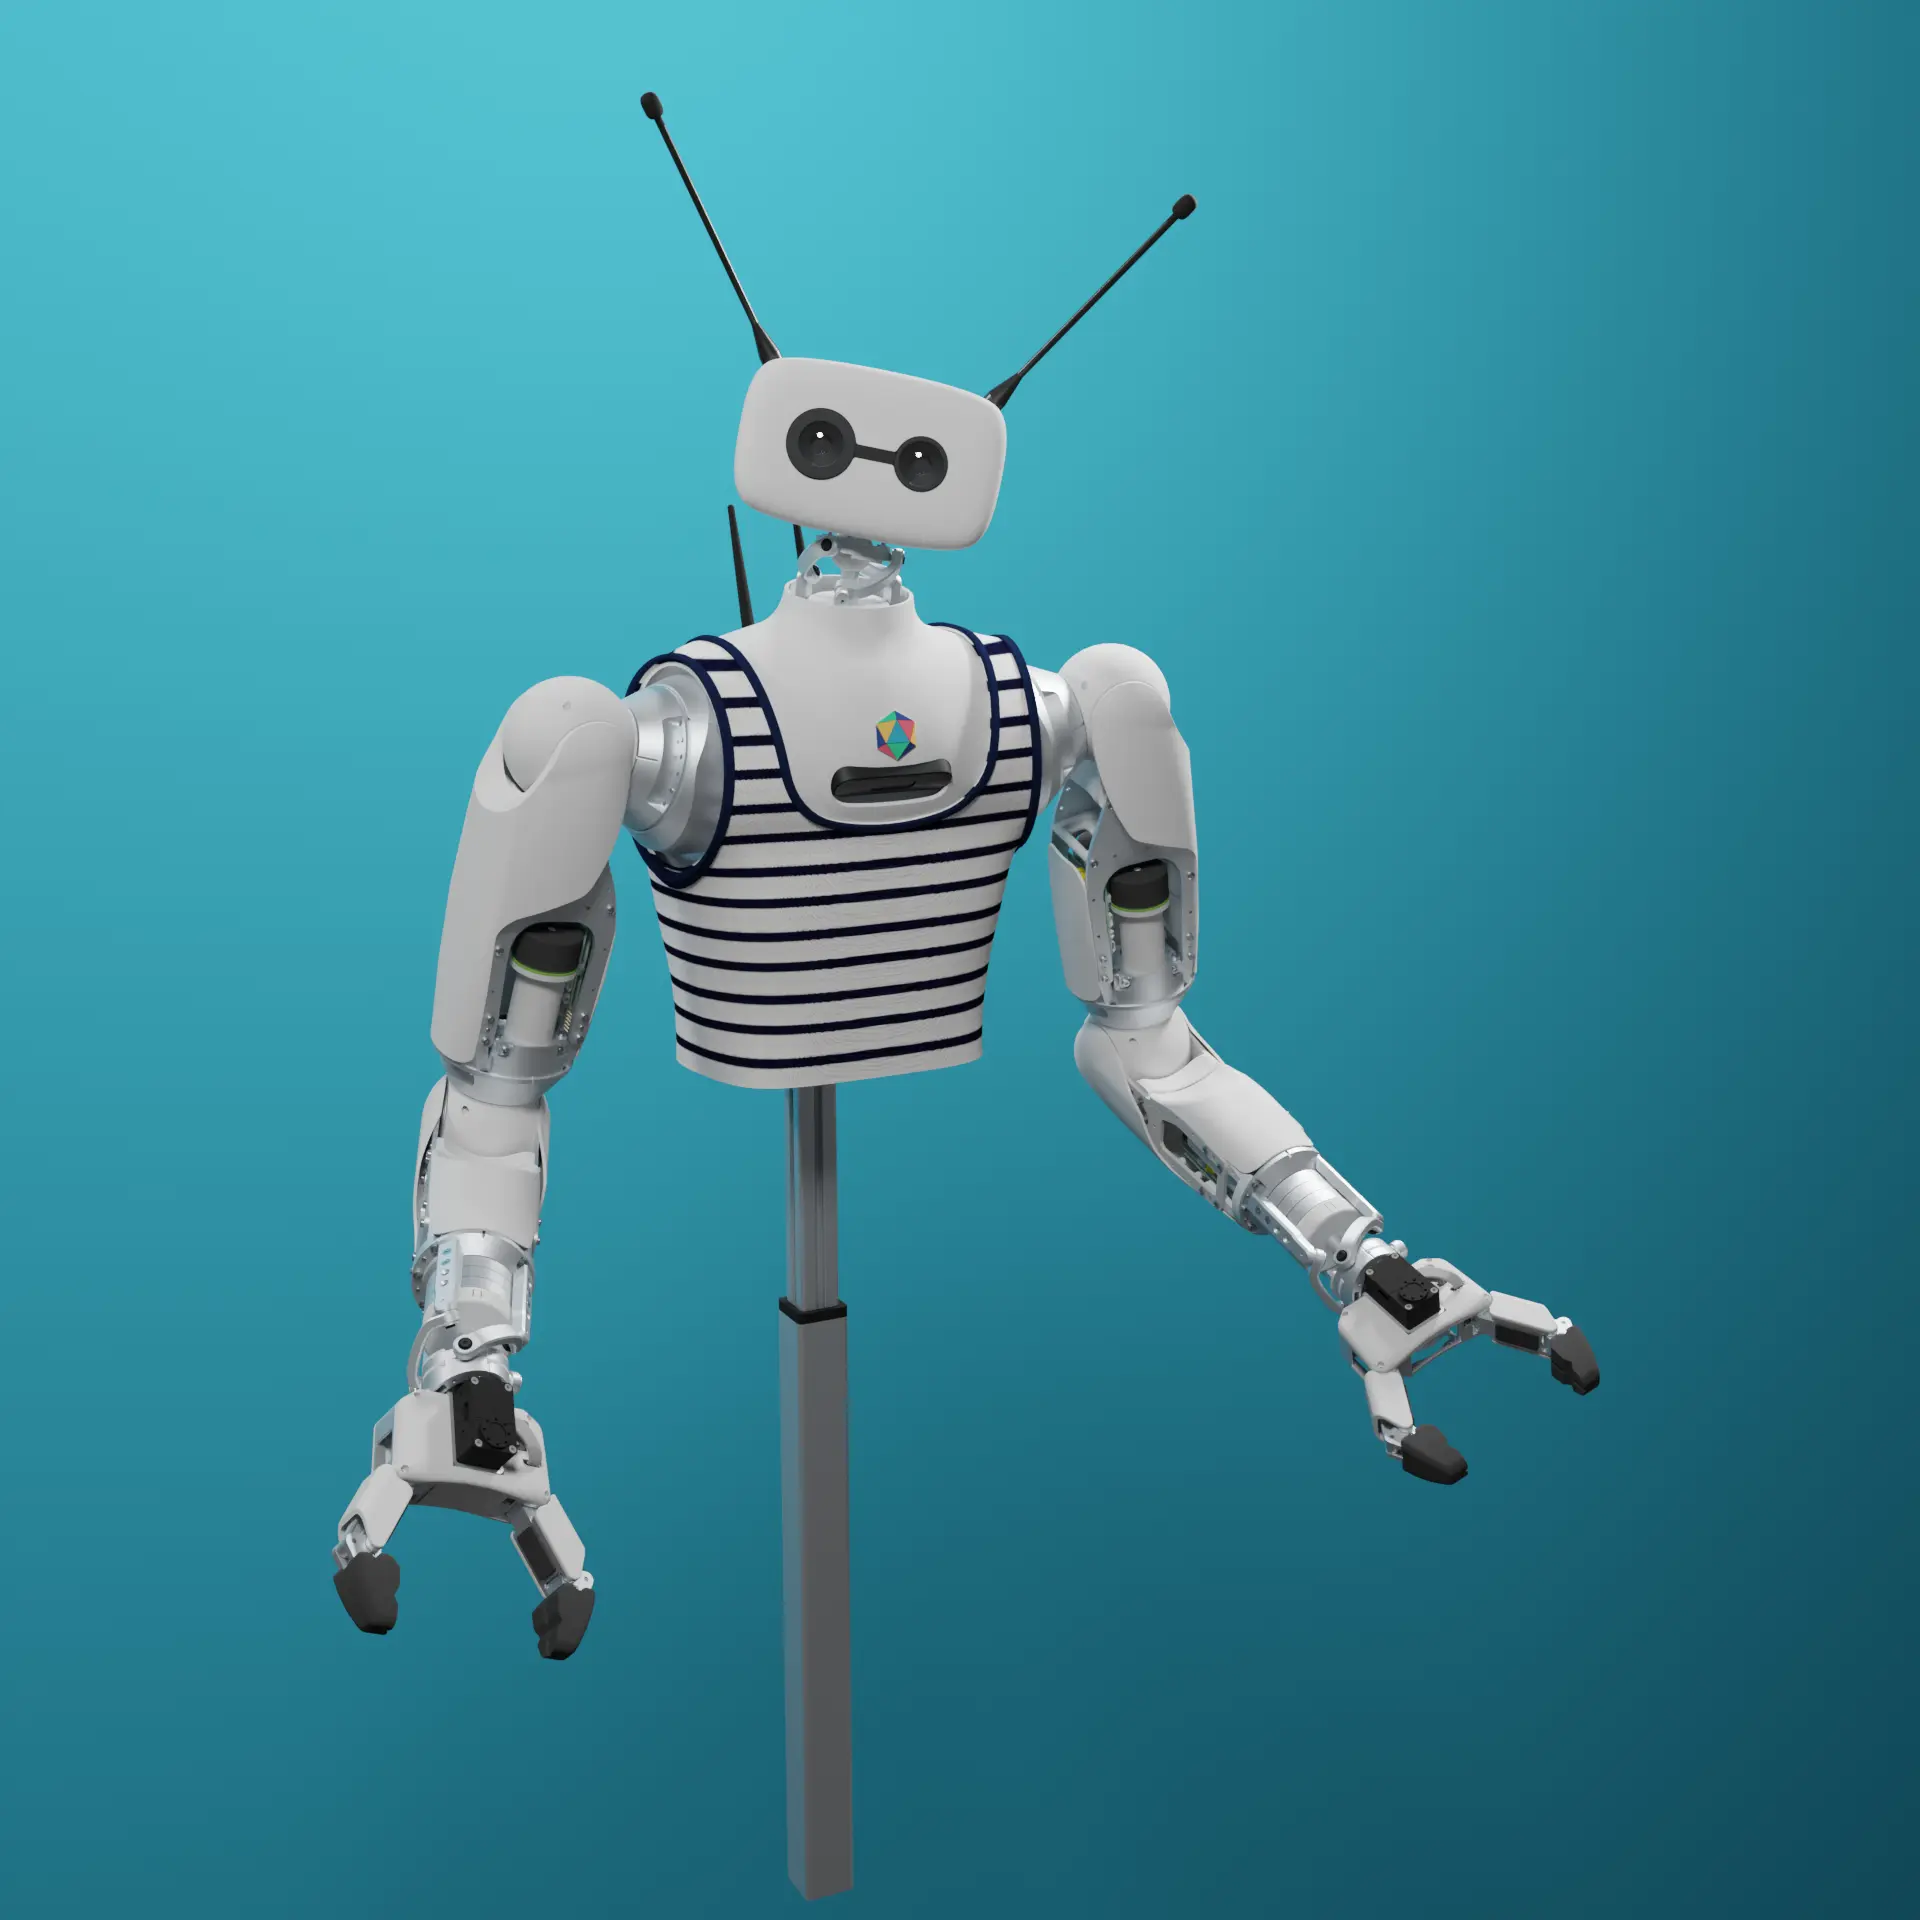
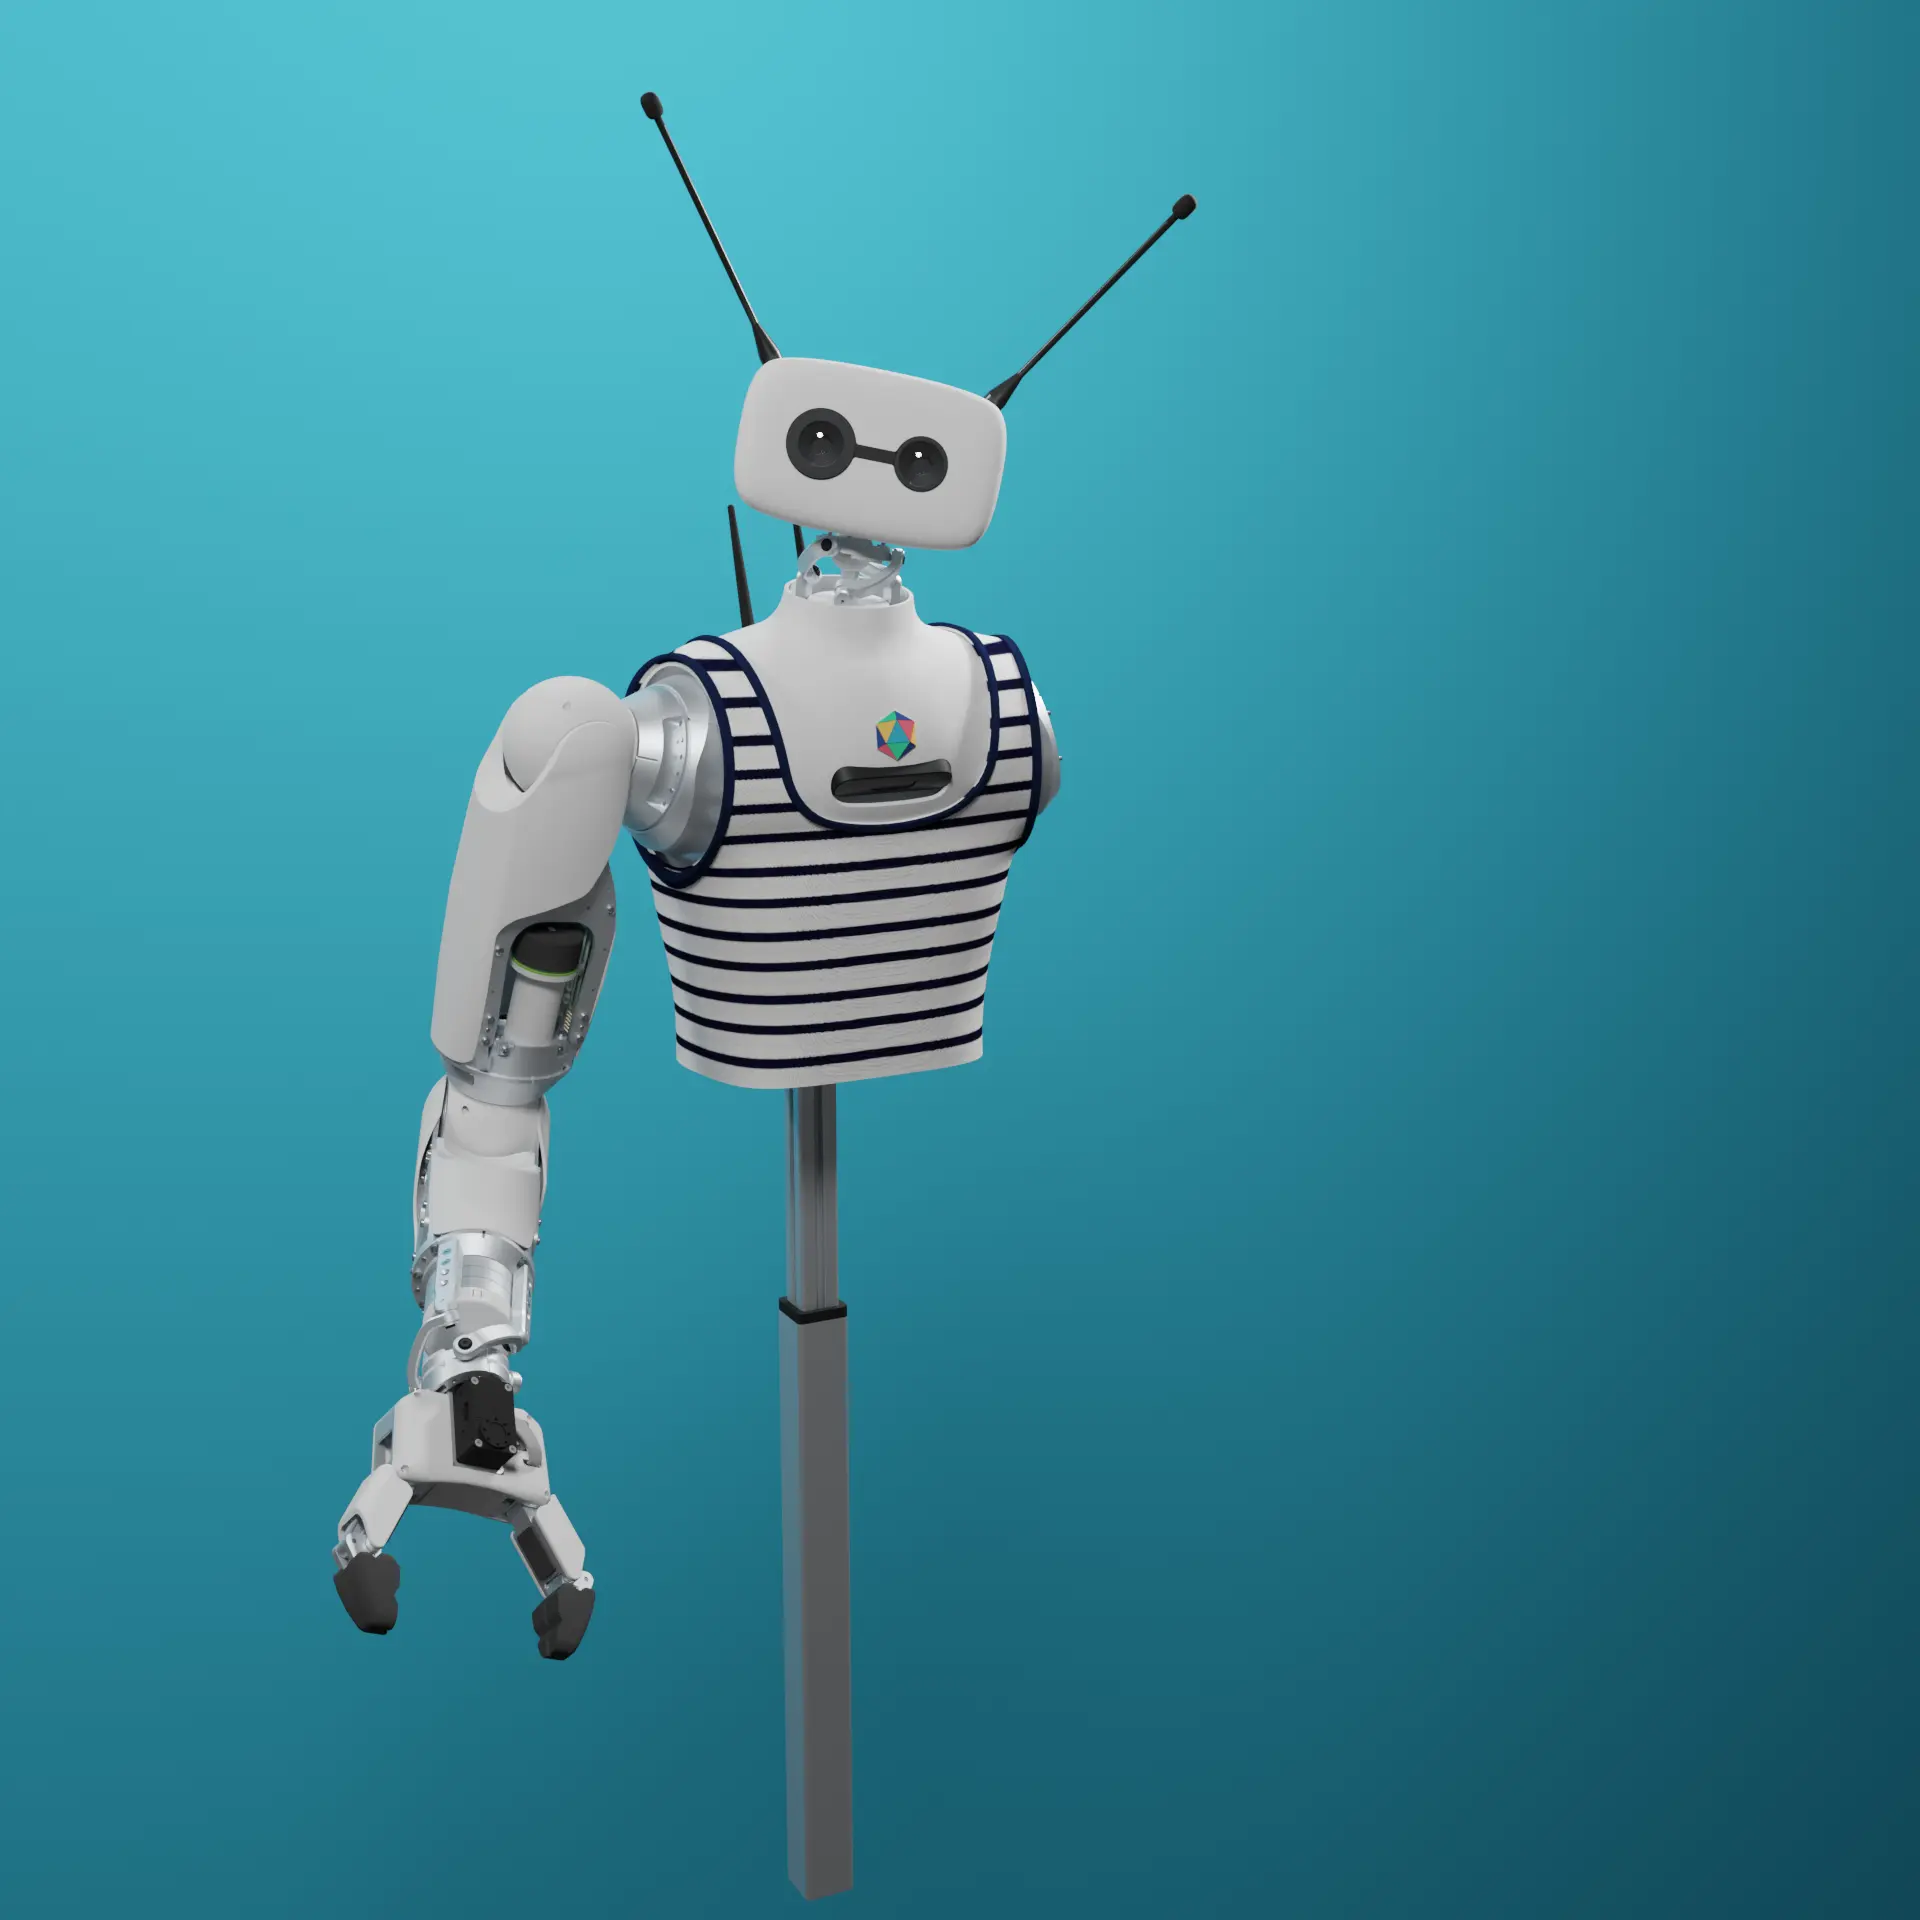
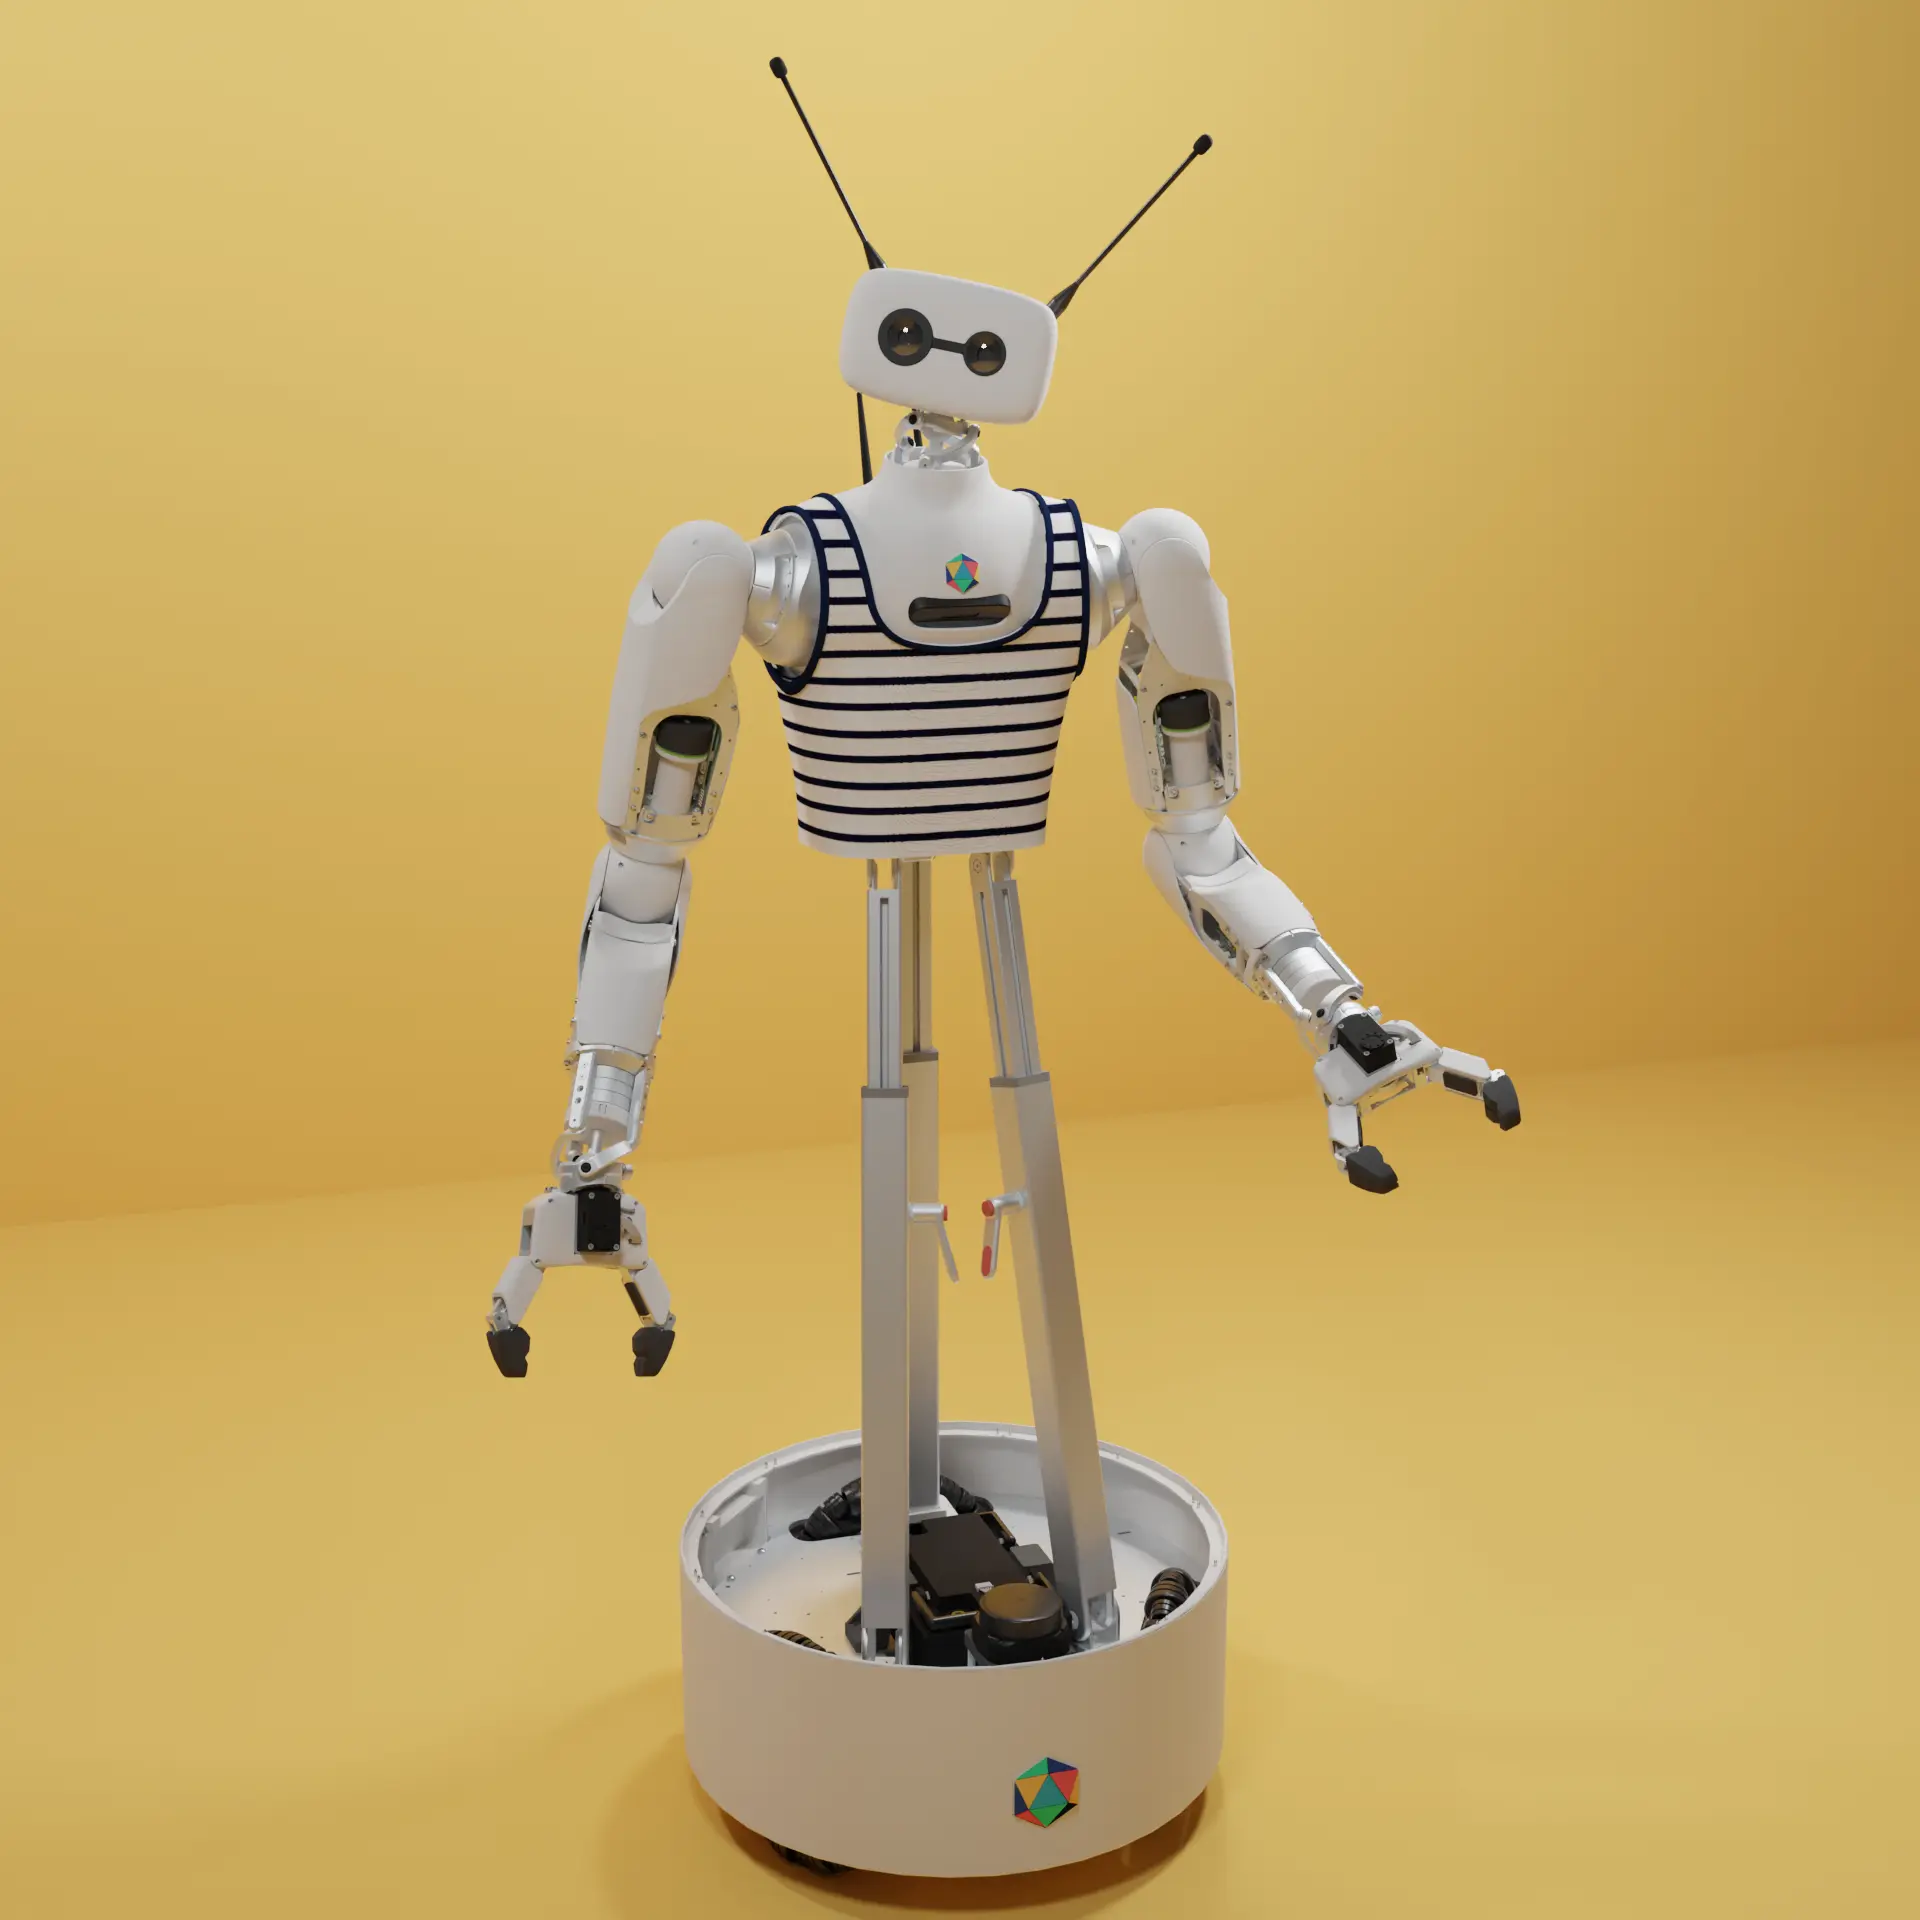
Reachy 2 is Pollen Robotics' open-source humanoid research platform: a bimanual mobile manipulator aimed at AI and robotics laboratories working on embodied AI and on the hard problem of grasping and using everyday objects in real environments such as offices, homes, hospitals and shops. Its two arms mirror the dimensions, proportions and movements of an adult human arm, with seven degrees of freedom each, and one arm can lift objects of up to about 3 kg and manipulate them with real dexterity. The joints use Pollen's Orbita 2D and 3D parallel actuators. The robot is available on an omnidirectional mobile base - three omniwheels, a cylindrical structure, a sensor suite and a LiDAR - for a wider working space, adjusts in height between 136 and 166 cm, and weighs up to 50 kg complete. Stereo and RGB-D cameras provide vision and depth. It runs ROS 2 Humble with a Python SDK, and its CPU-based system is built for compatibility with modern AI frameworks and learning models. It can also be teleoperated in VR through Pollen's application: the operator moves its arms, hands and head and sees through the robot's cameras, which makes it a way to collect real manipulation data as well as to work remotely. Hardware and software are fully open source, and it succeeds the original Reachy, launched at CES 2020.
功能特点
- Open-source bimanual mobile manipulator for embodied-AI research
- Two arms with 7 degrees of freedom each, matching adult human arm proportions
- About 3 kg payload per arm
- Orbita 2D and 3D parallel actuators
- Omnidirectional mobile base with three omniwheels and LiDAR
- Adjustable height 136-166 cm
- Up to 50 kg full robot weight
- Stereo and RGB-D vision and depth sensing
- Runs ROS 2 Humble with a Python SDK
- VR teleoperation: move its arms, hands and head and see through its cameras
- CPU-based compute compatible with modern AI frameworks
- Fully open hardware and software
技术规格
已验证| 物理参数 | |
| 重量 | Up to 50 kg (full robot) |
|---|---|
| 外形尺寸 | H 1.66 m |
| 负载 | 3 kg |
| 移动能力 | |
| 运动类型 | 带轮的, 类人机器人 |
| 执行器 | Orbita 2D and 3D parallel actuators |
| 感知与计算 | |
| 传感器 | Stereo cameras, RGB-D camera, LiDAR on the mobile base |
| 软件 / AI | ROS 2 Humble; open-source Python SDK; VR teleoperation application |
图片
 martti
 martti
 martti
 martti
 martti
 martti
图片贡献
机器人论坛
正在加载论坛...
评分
常见问题
What is the Reachy 2?
Reachy 2 is Pollen Robotics' open-source humanoid research platform: a bimanual mobile manipulator aimed at AI and robotics laboratories working on embodied AI and on the hard problem of grasping and using everyday objects in real environments such as offices, homes, hospitals and shops.
Who makes the Reachy 2?
The Reachy 2 is made by Pollen Robotics, a robotics company based in France.
How much does the Reachy 2 cost?
Pollen Robotics has not publicly announced pricing for the Reachy 2. You can enquire through RobotAIGeek for current pricing.
What is the Reachy 2 used for?
The Reachy 2 is designed for 娱乐, 研究, and 教育. It is used in 研究 and 教育 settings.
What is the payload capacity of the Reachy 2?
The Reachy 2 has a payload capacity of 3 kg.
How much does the Reachy 2 weigh?
The Reachy 2 weighs 50 kg.
与同类机器人对比
看看这款机器人与最接近的同类产品相比表现如何
- Reachy 2 vs PIPER 标准版
- Reachy 2 vs Lanxin H6 Standard
- Reachy 2 vs AGIBOT D1 Pro
- Reachy 2 vs Galaxea A1 X
- Reachy 2 vs ESD Eagle X