描述
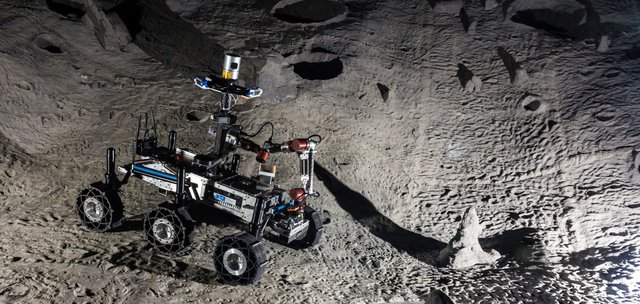
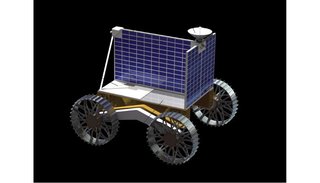
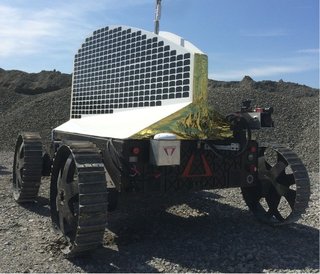
Polaris是Astrobotic Technology的Mobile-Robots。 面向探索、Lunar surface payload mobility (prospecting, excavation, drilling)设计。 关键数据:负载 90 kg。
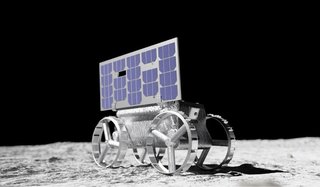
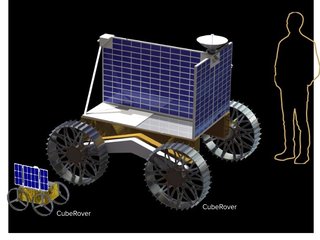
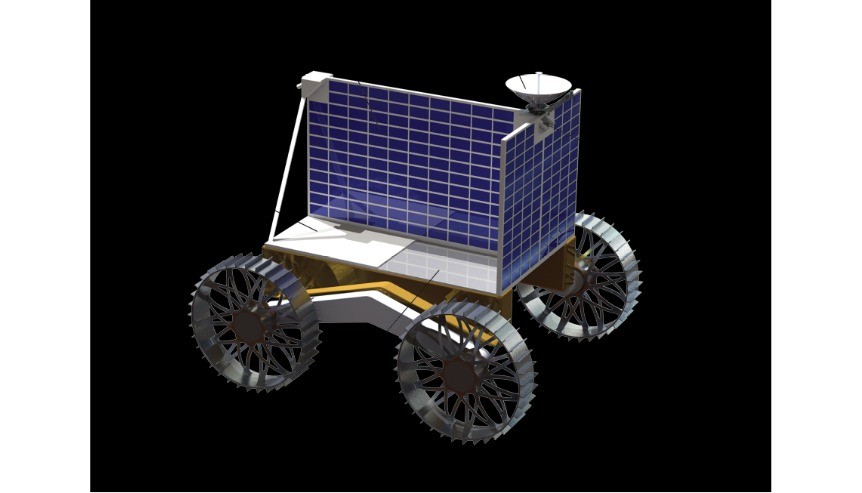
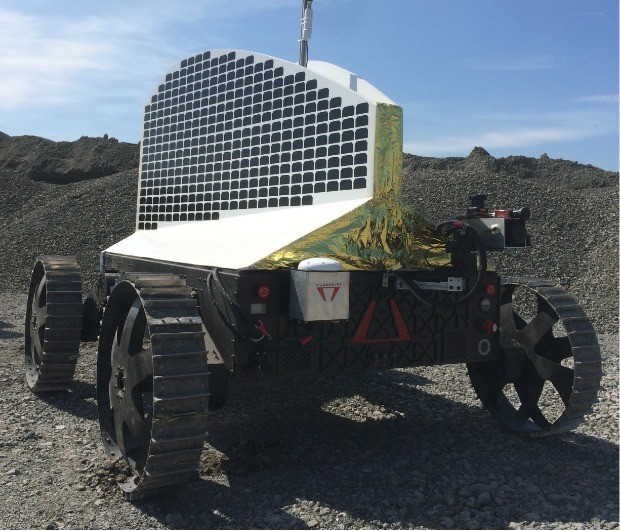
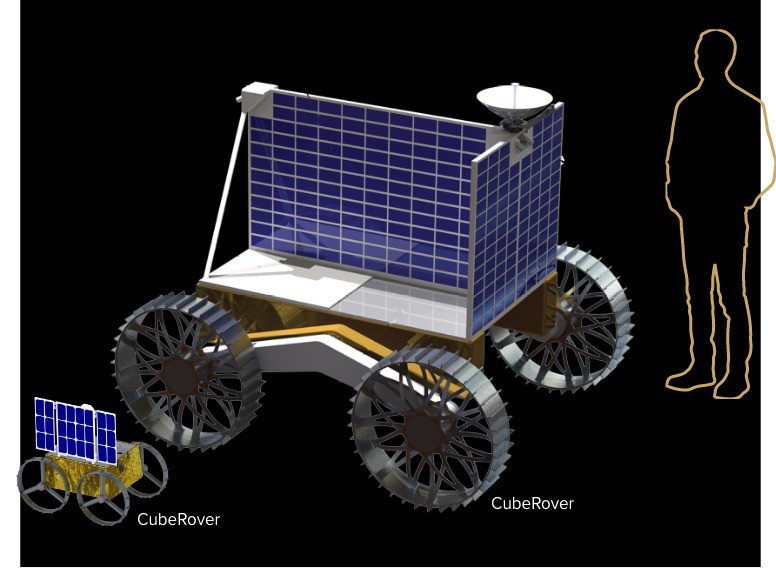
Polaris is Astrobotic's large lunar rover, designed for diverse payloads with distinct mission profiles such as regolith digging, drilling, excavation and water-ice harvesting. It carries up to 90 kg of payload above or below its main deck - including drills, excavators and robotic arms - and provides mobility, power, direct-to-Earth communications and protection from the lunar environment, surviving extended periods in permanently shadowed regions and making long traverses. Its four-wheel-drive skid-steer mobility system has independent actuators and rocker suspension, 55 cm of ground clearance, can climb obstacles up to 40 cm and reaches 37 cm/s, covering tens of kilometres in a lunar day; it has been tested in terrestrial rock yards and regolith simulants. It navigates autonomously or by teleoperation using stereo vision with inertial, wheel-rotation and Sun sensors to estimate its pose and model terrain, and it stows on and deploys from landers such as Astrobotic's Griffin. Astrobotic offers payload delivery on Polaris for USD 4.5 million per kilogram, including 0.5 W of continuous power and 10 kbps of bandwidth per kilogram.
功能特点
- Payload up to 90 kg, above or below deck (drills, excavators, robotic arms)
- Four-wheel-drive skid steer
- independent actuators
- rocker suspension
- Ground clearance 55 cm
- climbs obstacles up to 40 cm
- Top speed 37 cm/s
- tens of km per lunar day
- Autonomous or teleoperated
- stereo vision + inertial, wheel-rotation and Sun sensors
- Direct-to-Earth communications
- survives permanently shadowed regions
- Deploys from landers such as Griffin
- Delivery service: USD 4.5M/kg incl. 0.5 W and 10 kbps per kg
技术规格
| 物理参数 | |
| 负载 | 90 kg |
|---|---|
| 移动能力 | |
| 运动类型 | 带轮的 |
| 速度 | 1.33 km/h |
| 作业环境 | Lunar surface incl. permanently shadowed regions |
| 感知与计算 | |
| 传感器 | stereo cameras, inertial sensors, wheel encoders, Sun sensors |
| 连接方式 | Direct-to-Earth communications |
机器人论坛
正在加载论坛...
技术规格
| 物理参数 | |
| 负载 | 90 kg |
|---|---|
| 移动能力 | |
| 运动类型 | 带轮的 |
| 速度 | 1.33 km/h |
| 作业环境 | Lunar surface incl. permanently shadowed regions |
| 感知与计算 | |
| 传感器 | stereo cameras, inertial sensors, wheel encoders, Sun sensors |
| 连接方式 | Direct-to-Earth communications |
图片
 martti
 martti
 martti
 martti
图片贡献
视频
机器人论坛
正在加载论坛...
评分
常见问题
What is the Polaris?
Polaris is Astrobotic's large lunar rover, designed for diverse payloads with distinct mission profiles such as regolith digging, drilling, excavation and water-ice harvesting.
Who makes the Polaris?
The Polaris is made by Astrobotic Technology, a robotics company based in United States.
How much does the Polaris cost?
Astrobotic Technology has not publicly announced pricing for the Polaris. You can enquire through RobotAIGeek for current pricing.
What is the Polaris used for?
The Polaris is designed for 探索 and lunar surface payload mobility (prospecting, excavation, drilling). It is used in 空间 settings.
What is the payload capacity of the Polaris?
The Polaris has a payload capacity of 90 kg.
How fast is the Polaris?
The Polaris can move at speeds of up to 1.33 km/h.
与同类机器人对比
看看这款机器人与最接近的同类产品相比表现如何
- Polaris vs Slamtec Poseidon
- Polaris vs Mecabot Plus
- Polaris vs Mecabot X
- Polaris vs Pickerbot Pro
- Polaris vs Lunar Rover (Blue Ghost Mission 3)