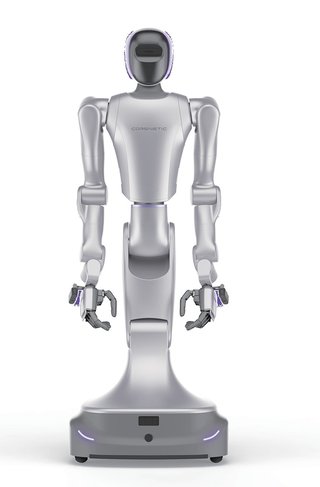
DESCRIPTION
Corenetic Monte 02 is a Humanoid from Corenetic. It is built for Pick-and-place, Research, Inspection. Key figures: 100 kg, 480 min runtime, 3 kg payload, 702 mm reach.
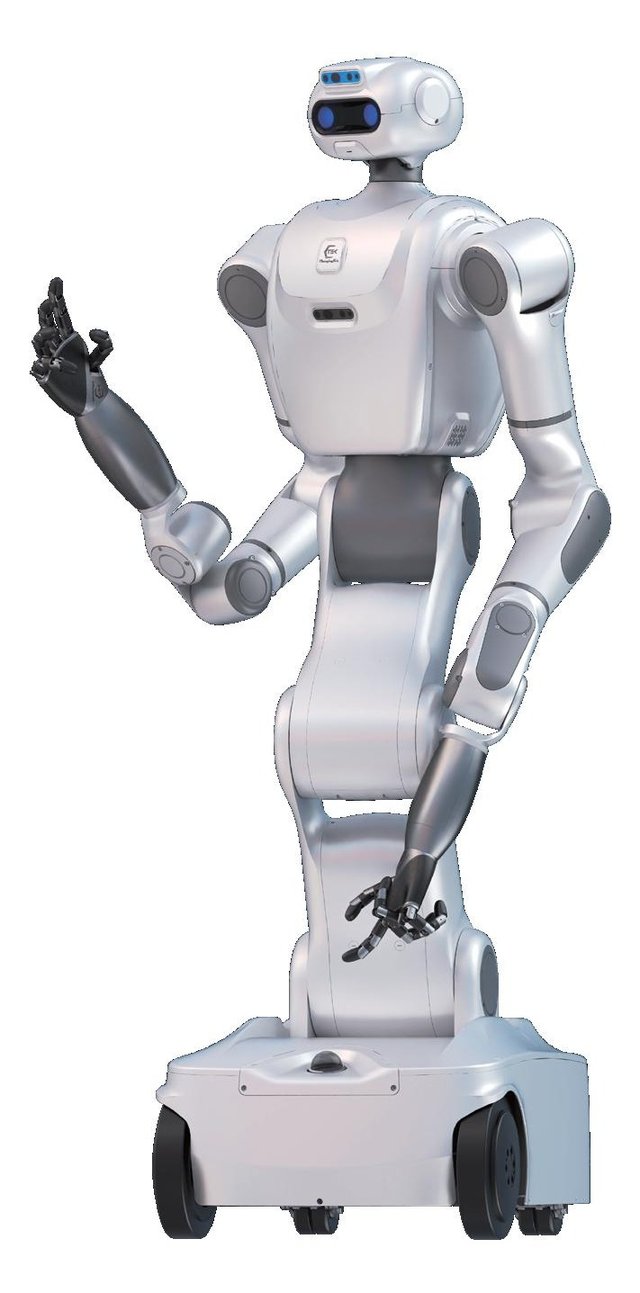
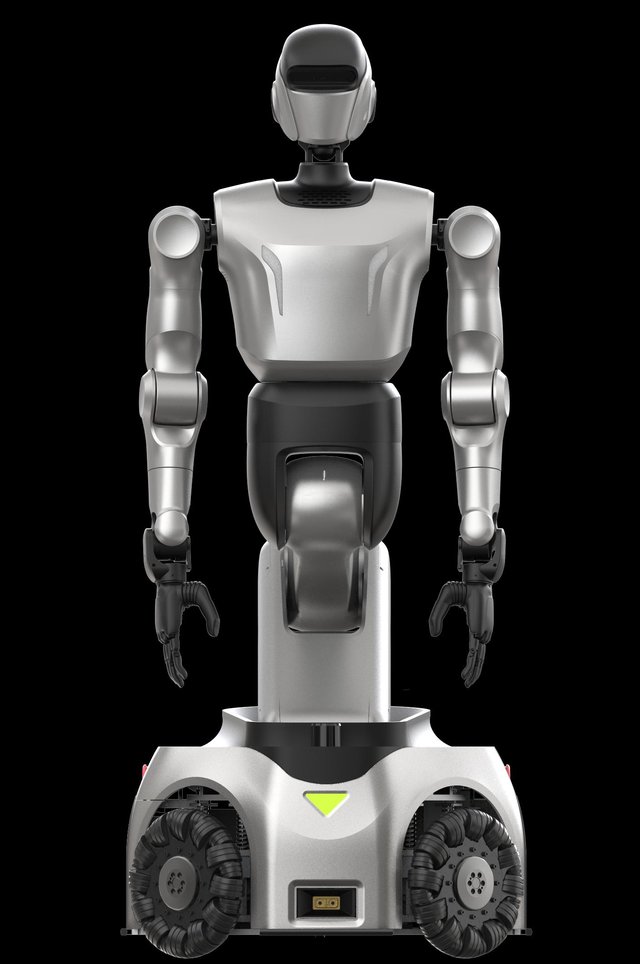
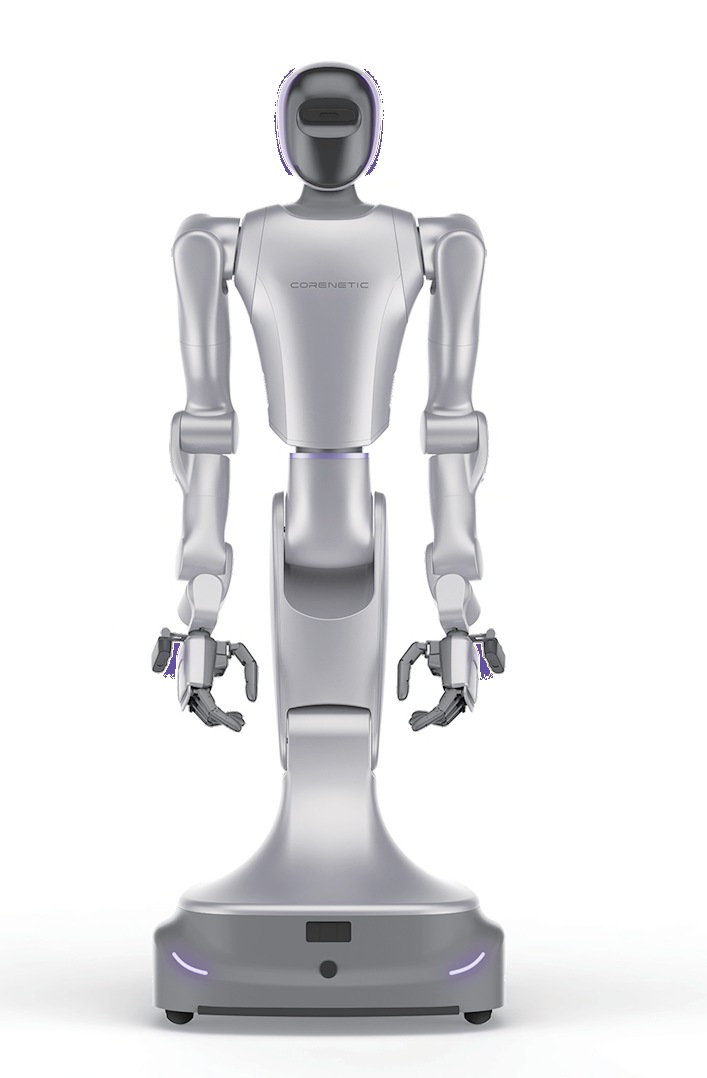
The Monte 02 is Corenetic's dual-arm embodied-intelligence robot, and its proportions tell you what it is for: a 1,623 mm humanoid upper body on a three-wheel omnidirectional base, built to work at laboratory benches and process equipment rather than to walk. Each arm uses a 7-degree-of-freedom SRS anthropomorphic configuration reaching 702 mm and lifting 3 kg — the SRS layout matters here because a redundant seven-axis arm can reach around an obstruction and still hold the tool at the required angle, which is what pipetting into a rack inside an instrument actually demands. End effectors change themselves: the robot swaps between an adaptive two-finger gripper and a multi-finger dexterous hand without a person, gripping to 110 N over a 100 mm stroke. It fuses vision and touch through Corenetic's own multimodal embodied-intelligence system to understand a scene and plan long, multi-step, cross-device tasks on its own. Compute is split between a 200+ TOPS embedded AI processor and an x86 industrial real-time control board, and a 51.2 V 30 Ah pack gives eight hours of typical operation with a two-hour fast charge. Corenetic aims it at life science, pharmaceuticals, chemicals and advanced manufacturing.
FEATURES
- 590 x 619 x 1623 mm and 100 kg
- Degrees of freedom published as a composition: chassis x2, waist x3, head x2, arms 7 x2, and grippers x2 or dexterous hands 9 x2
- High-strength aluminium alloy frame with an ABS engineering plastic shell
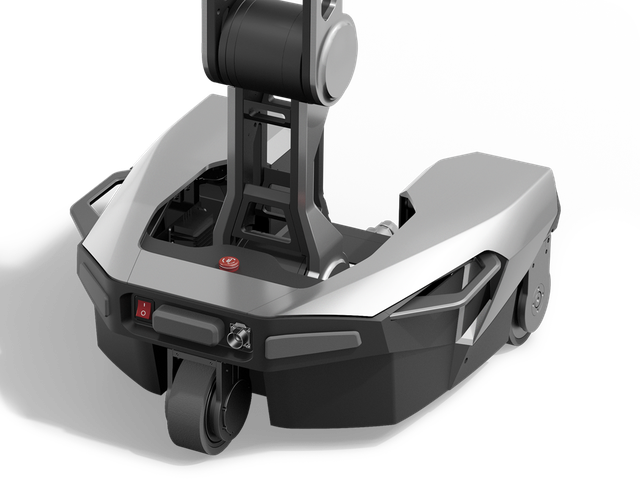
- Three-wheel omnidirectional chassis able to turn on the spot, maximum speed 1.0 m/s, gradeability up to 10 degrees
- Mapping, real-time localisation, obstacle-avoidance navigation and autonomous recharging
- Indoor floor surfaces including tile, wood flooring and rubber
- 7 degree-of-freedom SRS anthropomorphic arm configuration with a 702 mm working span per arm
- 3 kg maximum payload per arm
- Automatic scene-driven end-effector quick-change between an adaptive two-finger gripper and a multi-finger dexterous hand
- Maximum gripping force 110 N with a 100 mm gripper stroke
- Fused vision and touch perception through a self-developed multimodal embodied-intelligence system
- Autonomous understanding and decision-making for long, complex, cross-device multi-step tasks
- Lithium-ion battery pack, 51.2 V / 30 Ah, 8 hours typical operation, 2 hours fast charge
- Main control unit 1: embedded AI processor with 200+ TOPS
- main control unit 2: x86 industrial real-time control board
- Head vision: 1 RGBD camera
- end-of-arm vision: 1 RGBD camera per arm
- WiFi 6 at 2.4 GHz and 5 GHz, gigabit Ethernet and a full-function Type-C interface
- Manufacturer states the published figures come from laboratory testing and are for reference
TECHNICAL SPECIFICATIONS
| Physical | |
| Weight | 100 kg |
|---|---|
| Dimensions | L 590 mm × W 619 mm × H 1.62 m |
| Payload | 3 kg |
| Reach | 702 mm |
| Mobility | |
| Movement Type | Wheeled |
| Speed | 3.6 km/h |
| Manipulation | High |
| Environment | Indoor floors including tile, wood flooring and rubber; laboratories, cleanrooms, greenhouses and production areas |
| Actuators | Dual 7-degree-of-freedom SRS anthropomorphic arms with automatic end-effector quick-change, on a three-wheel omnidirectional chassis with a 3-degree-of-freedom waist and 2-degree-of-freedom head |
| Power | |
| Battery Life | 8 h typical |
| Sensing & Compute | |
| Sensors | RGBD camera (head), RGBD camera per arm, tactile sensing |
| Connectivity | WiFi 6 (2.4 GHz / 5 GHz), gigabit Ethernet, full-function Type-C |
| Software / AI | Self-developed multimodal embodied-intelligence system fusing vision and touch, providing scene understanding, autonomous decision-making and long-horizon multi-step cross-device task planning; mapping, localisation, obstacle avoidance and auto-recharge |
ROBOT FORUMS
Loading forums...
TECHNICAL SPECIFICATIONS
| Physical | |
| Weight | 100 kg |
|---|---|
| Dimensions | L 590 mm × W 619 mm × H 1.62 m |
| Payload | 3 kg |
| Reach | 702 mm |
| Mobility | |
| Movement Type | Wheeled |
| Speed | 3.6 km/h |
| Manipulation | High |
| Environment | Indoor floors including tile, wood flooring and rubber; laboratories, cleanrooms, greenhouses and production areas |
| Actuators | Dual 7-degree-of-freedom SRS anthropomorphic arms with automatic end-effector quick-change, on a three-wheel omnidirectional chassis with a 3-degree-of-freedom waist and 2-degree-of-freedom head |
| Power | |
| Battery Life | 8 h typical |
| Sensing & Compute | |
| Sensors | RGBD camera (head), RGBD camera per arm, tactile sensing |
| Connectivity | WiFi 6 (2.4 GHz / 5 GHz), gigabit Ethernet, full-function Type-C |
| Software / AI | Self-developed multimodal embodied-intelligence system fusing vision and touch, providing scene understanding, autonomous decision-making and long-horizon multi-step cross-device task planning; mapping, localisation, obstacle avoidance and auto-recharge |
Images
 martti
Image Contributions
Videos
ROBOT FORUMS
Loading forums...
RATINGS
FREQUENTLY ASKED QUESTIONS
What is the Corenetic Monte 02?
The Monte 02 is Corenetic's dual-arm embodied-intelligence robot, and its proportions tell you what it is for: a 1,623 mm humanoid upper body on a three-wheel omnidirectional base, built to work at laboratory benches and process equipment rather than to walk.
Who makes the Corenetic Monte 02?
The Corenetic Monte 02 is made by Corenetic, a robotics company based in China.
How much does the Corenetic Monte 02 cost?
Corenetic has not publicly announced pricing for the Corenetic Monte 02. You can enquire through RobotAIGeek for current pricing.
What is the Corenetic Monte 02 used for?
The Corenetic Monte 02 is designed for pick-and-place, research, inspection, and precision pipetting. It is used in research, agriculture, healthcare, and manufacturing settings.
What is the payload capacity of the Corenetic Monte 02?
The Corenetic Monte 02 has a payload capacity of 3 kg and a reach of 702 mm.
How much does the Corenetic Monte 02 weigh?
The Corenetic Monte 02 weighs 100 kg.
How fast is the Corenetic Monte 02?
The Corenetic Monte 02 can move at speeds of up to 3.6 km/h.
What is the battery life of the Corenetic Monte 02?
The Corenetic Monte 02 runs for 8 h typical on a charge.
COMPARE WITH SIMILAR ROBOTS
See how this robot stacks up against its closest alternatives
- Corenetic Monte 02 vs Embodied Tian Yi 2.0
- Corenetic Monte 02 vs CASBOT W1
- Corenetic Monte 02 vs Neuromeka ZEN
- Corenetic Monte 02 vs AlphaBot 2
- Corenetic Monte 02 vs Gento Luna