


説明
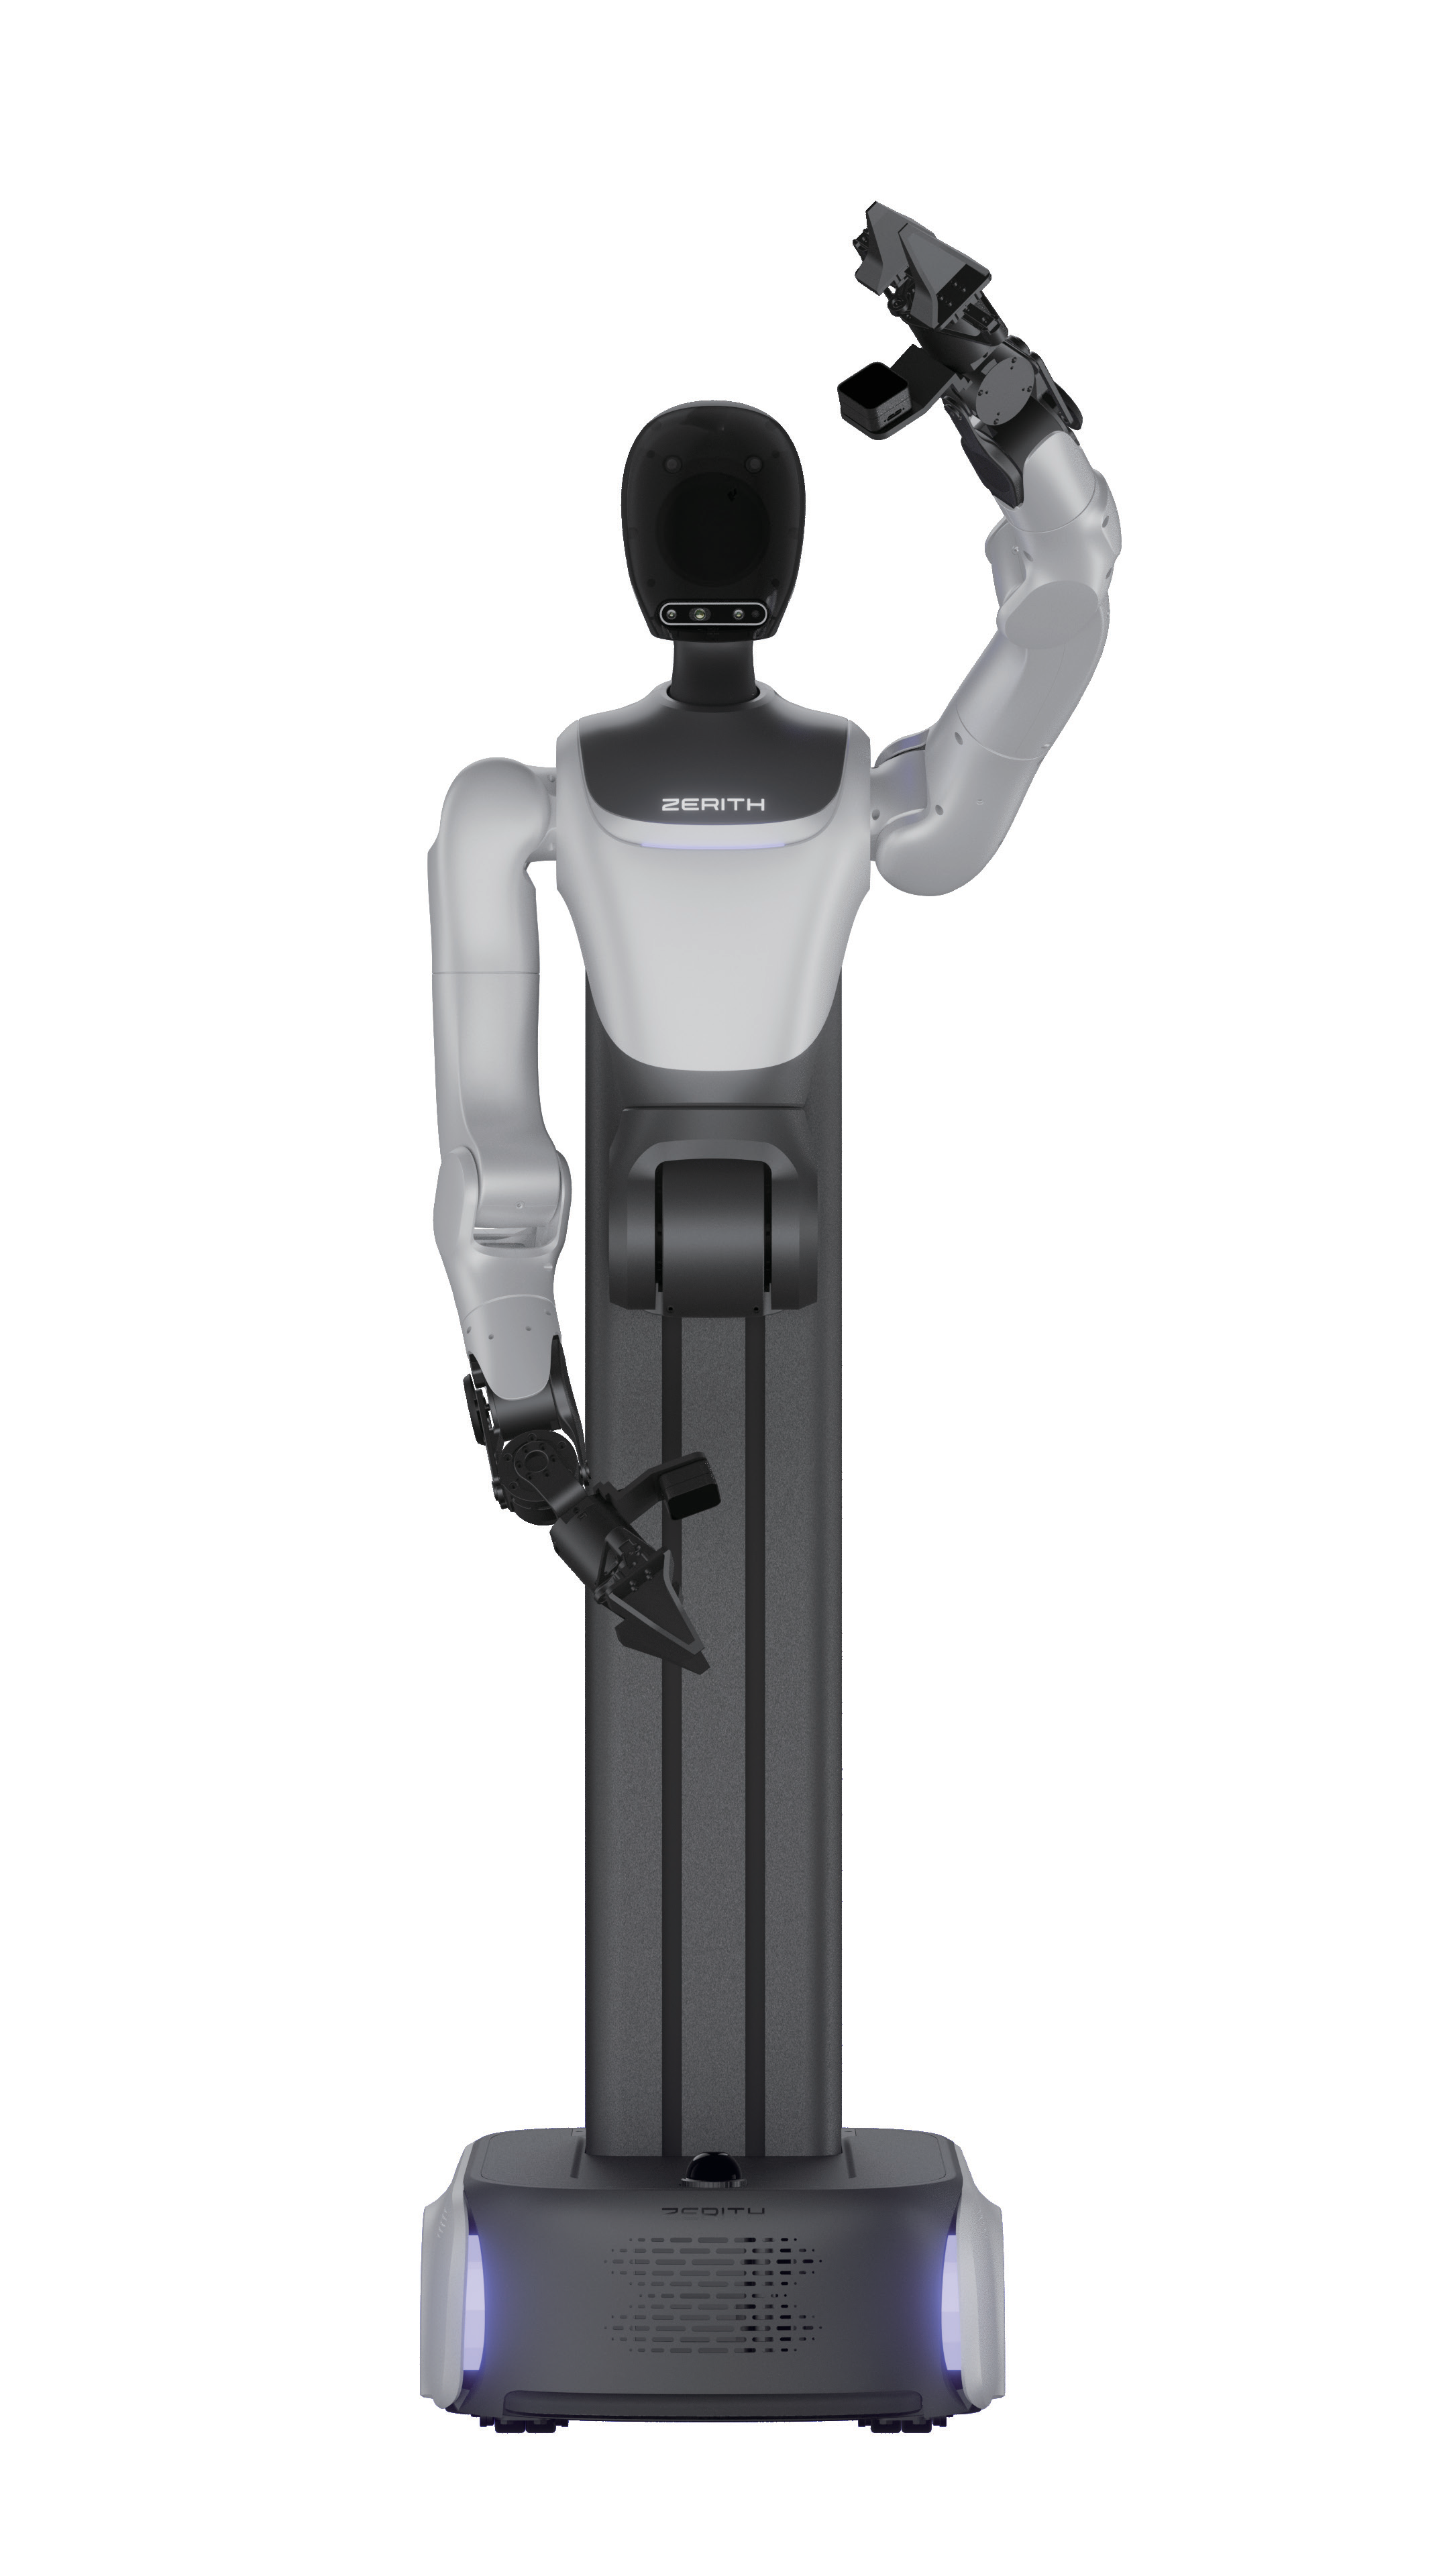
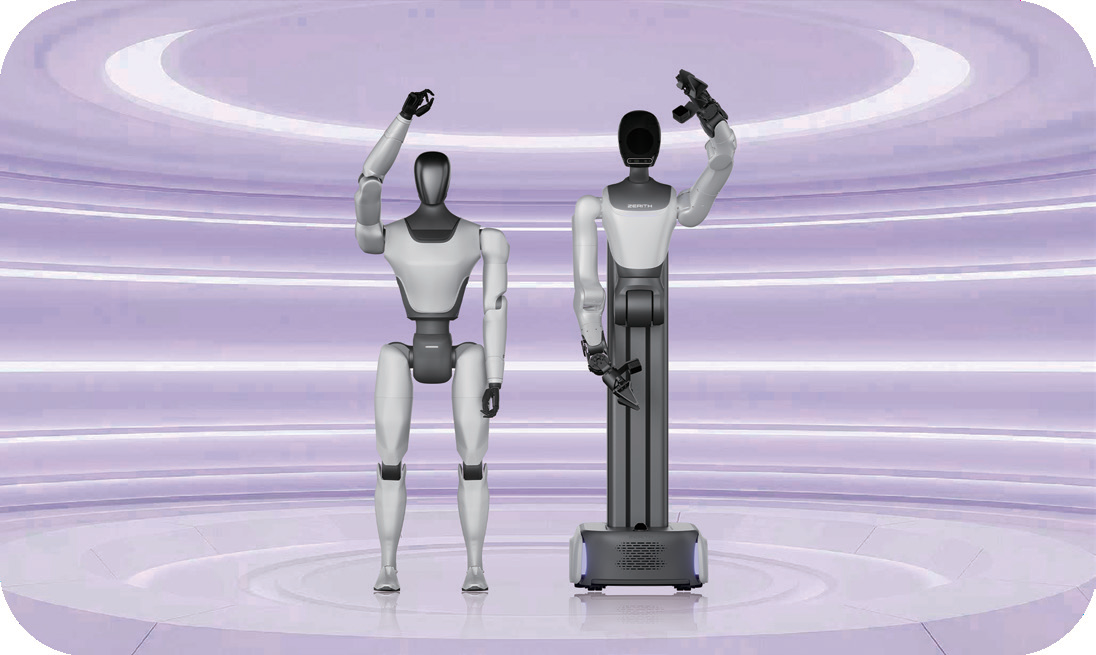
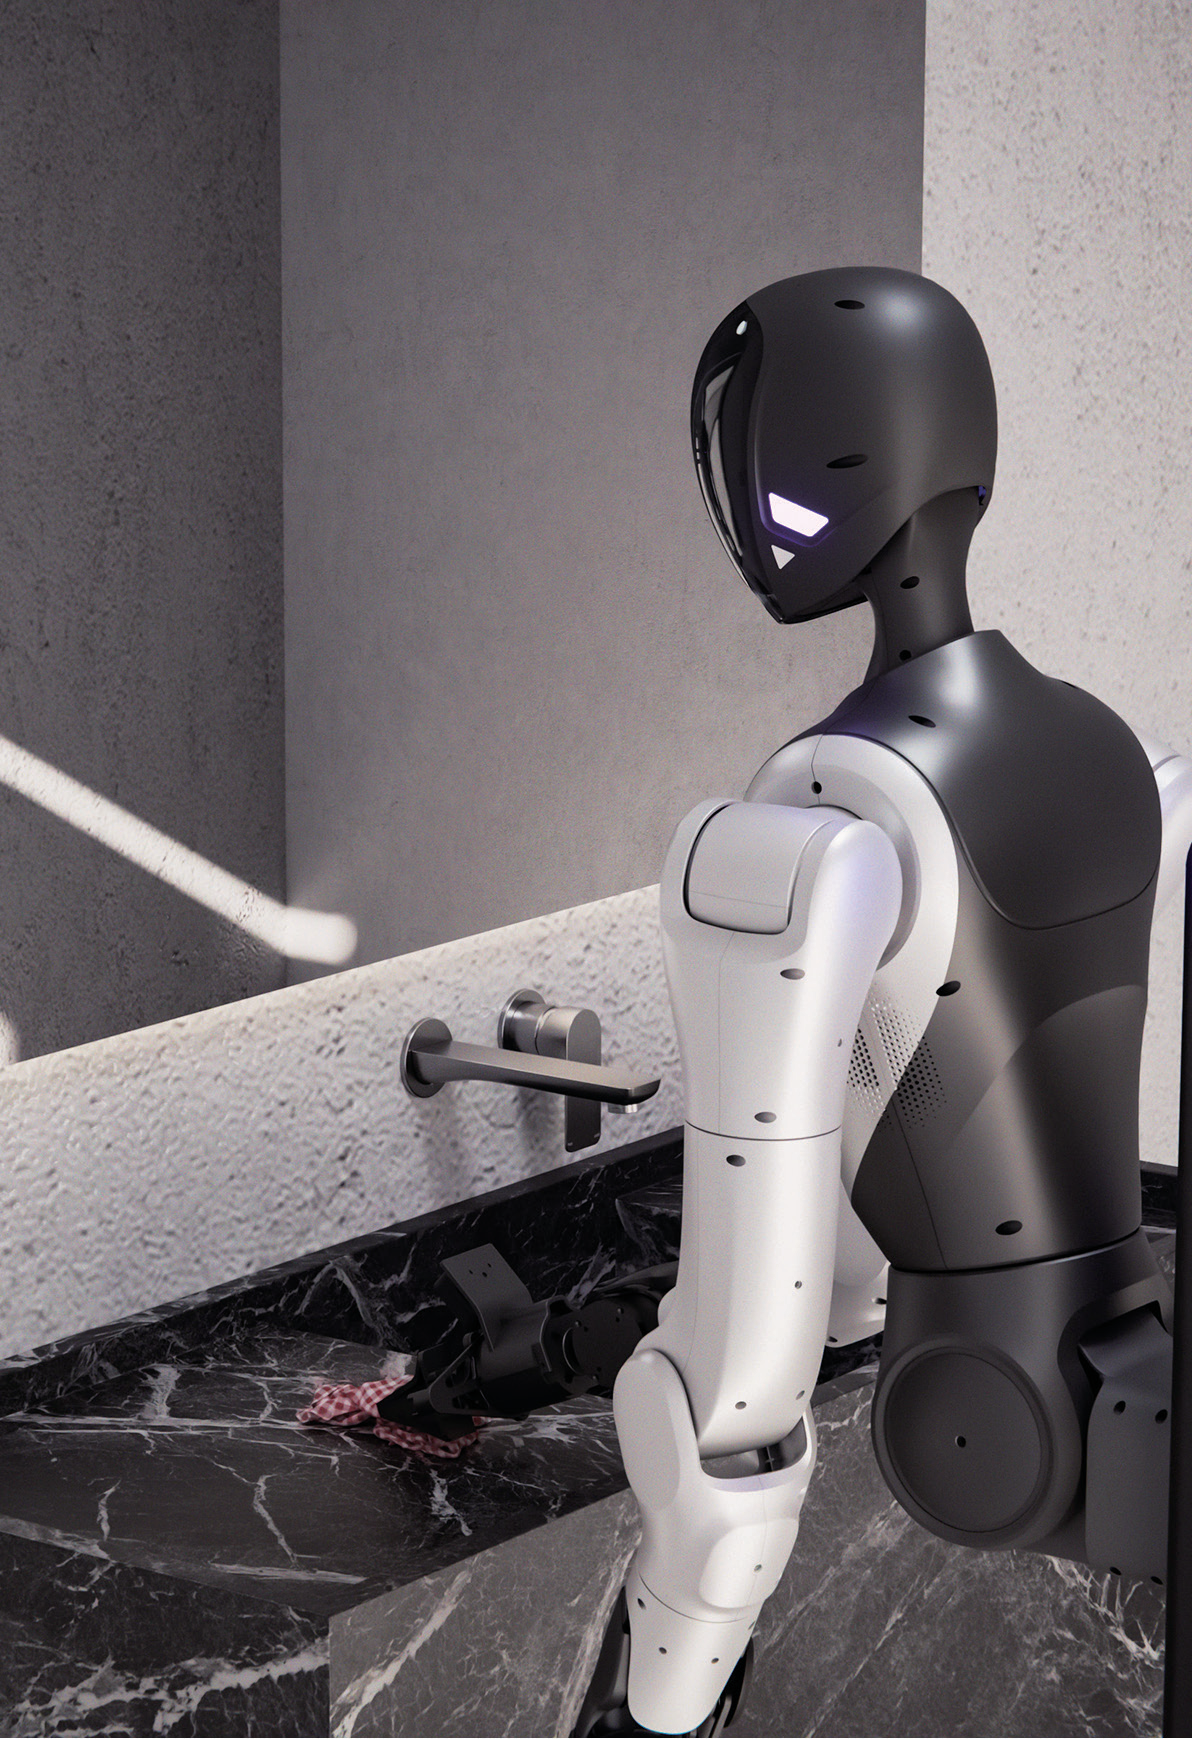
The Zerith H1 is a wheel-arm humanoid: a humanoid torso with two 7-axis arms riding a lifting column on an omnidirectional wheeled base, which is what lets it reach down to the floor and up beyond two metres from a single 1,788 mm arm reach. It runs 23 degrees of freedom on a 129 kg body, and the numbers make its intent clear — 1 kg rated and 1.5 kg maximum per arm is modest load, but ±0.15 mm end-point repeatability is precision work, derived from what Zerith describes as aerospace-heritage arm planning on a steady-state floating-base model. That combination suits shelf picking and order fulfilment, and Zerith reports it as the first in China to run continuous long-sequence tasks autonomously in a defined scenario, moving at up to 1.5 m/s. It is built to be developed against: fully open upper and lower-layer SDKs, a complete URDF, support for NVIDIA Isaac Sim, MuJoCo and Gazebo, and Ethernet, HDMI and USB expansion. Teleoperation is a first-class feature rather than a fallback — full-body VR remote control synchronised at millisecond level, paired with a data management platform, because collecting high-quality demonstration data is the point. Four to seven hours of runtime comes from swappable batteries or mains power, and an optional 6-DoF dexterous hand replaces the standard gripper for complex manipulation.
特長
- 23 total degrees of freedom on a 129 kg body
- twin 7-axis high-precision arms with 1,788 mm reach covering floor level to over 2 m
- ±0.15 mm end-point repeatability from a steady-state floating-base model with aerospace-derived arm planning
- 1 kg rated and 1.5 kg maximum load per arm
- optional 6-DoF dexterous hand with ±1 mm repeatability in place of the standard gripper
- omnidirectional wheeled base moving at up to 1.5 m/s
- omnidirectional environmental perception fusing tactile, visual and radar sensing
- EtherCAT real-time bus for millisecond-level response on a high-rigidity parallel mechanical design
- full-body VR teleoperation with millisecond motion synchronisation and a one-stop data acquisition management platform
- fully open upper and lower-layer SDK with complete URDF and support for NVIDIA Isaac Sim, MuJoCo and Gazebo
- 4-7 hours of runtime with battery swapping or mains power
- Ethernet x2, HDMI x1 and USB x1 external interfaces with Wi-Fi and Bluetooth.
技術仕様
| 本体 | |
| 重量 | 129 kg |
|---|---|
| 可搬重量 | 1 kg |
| リーチ | 1.79 m |
| 繰り返し精度 | ±0.15 mm |
| 移動性能 | |
| 移動方式 | 車輪型 |
| 自由度 | 23 |
| 速度 | 5.4 km/h |
| マニピュレーション | 高 |
| 使用環境 | Indoor retail, household, hotel and office spaces |
| アクチュエーター | 23 DoF total; two 7-axis high-precision arms with 1,788 mm reach on a lifting column over an omnidirectional wheeled base; high-rigidity parallel mechanical design; optional 6-DoF dexterous hand end effector |
| 電源 | |
| バッテリー駆動時間 | 4-7 h |
| 充電方式 | Battery replacement or mains power |
| センシング・演算 | |
| センサー | omnidirectional environmental perception system, multimodal tactile sensing, visual sensing, radar sensing, six-axis force sensing, IMU |
| 接続性 | Wi-Fi and Bluetooth; EtherCAT real-time bus; Ethernet x2, HDMI x1, USB x1 |
| ソフトウェア / AI | Reinforcement-learning gait with whole-body anthropomorphic control and dynamic balance; domestic-scenario foundation model with memory-enhanced learning and combined virtual and real-world data; Zerith-V0 embodied action large model; fully open upper and lower-layer SDK with complete URDF; NVIDIA Isaac Sim, MuJoCo and Gazebo support; VR teleoperation with millisecond full-body synchronisation and an integrated data management platform |
画像
 martti
 martti
 martti
 martti
 martti
投稿画像
動画
ロボットフォーラム
フォーラムを読み込み中...
評価
よくある質問
What is the Zerith H1?
The Zerith H1 is a wheel-arm humanoid: a humanoid torso with two 7-axis arms riding a lifting column on an omnidirectional wheeled base, which is what lets it reach down to the floor and up beyond two metres from a single 1,788 mm arm reach.
Who makes the Zerith H1?
The Zerith H1 is made by Zerith, a robotics company based in China.
How much does the Zerith H1 cost?
Zerith has not publicly announced pricing for the Zerith H1. You can enquire through RobotAIGeek for current pricing.
What is the Zerith H1 used for?
The Zerith H1 is designed for ピック&プレース, instant retail and supermarket order picking, unmanned robot shops, and household cleaning and home organisation. It is used in 教育, 家庭, 倉庫・物流, and 小売 settings.
What is the payload capacity of the Zerith H1?
The Zerith H1 has a payload capacity of 1 kg and a reach of 1.79 m.
How much does the Zerith H1 weigh?
The Zerith H1 weighs 129 kg.
How fast is the Zerith H1?
The Zerith H1 can move at speeds of up to 5.4 km/h.
What is the battery life of the Zerith H1?
The Zerith H1 runs for 4-7 h on a charge.
類似ロボットと比較
このロボットが最も近い代替候補とどう比べられるかをご覧ください
- Zerith H1 vs Reflex Robotics Reflex
- Zerith H1 vs Perceptyne PR-OMNI
- Zerith H1 vs HHS Juliet
- Zerith H1 vs Lanxin VB1-I
- Zerith H1 vs Noetix M1