
BESCHREIBUNG
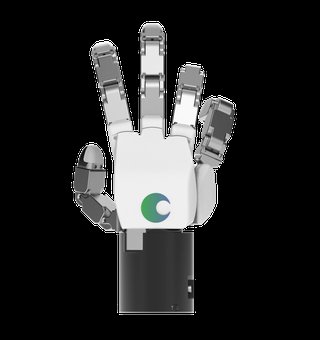
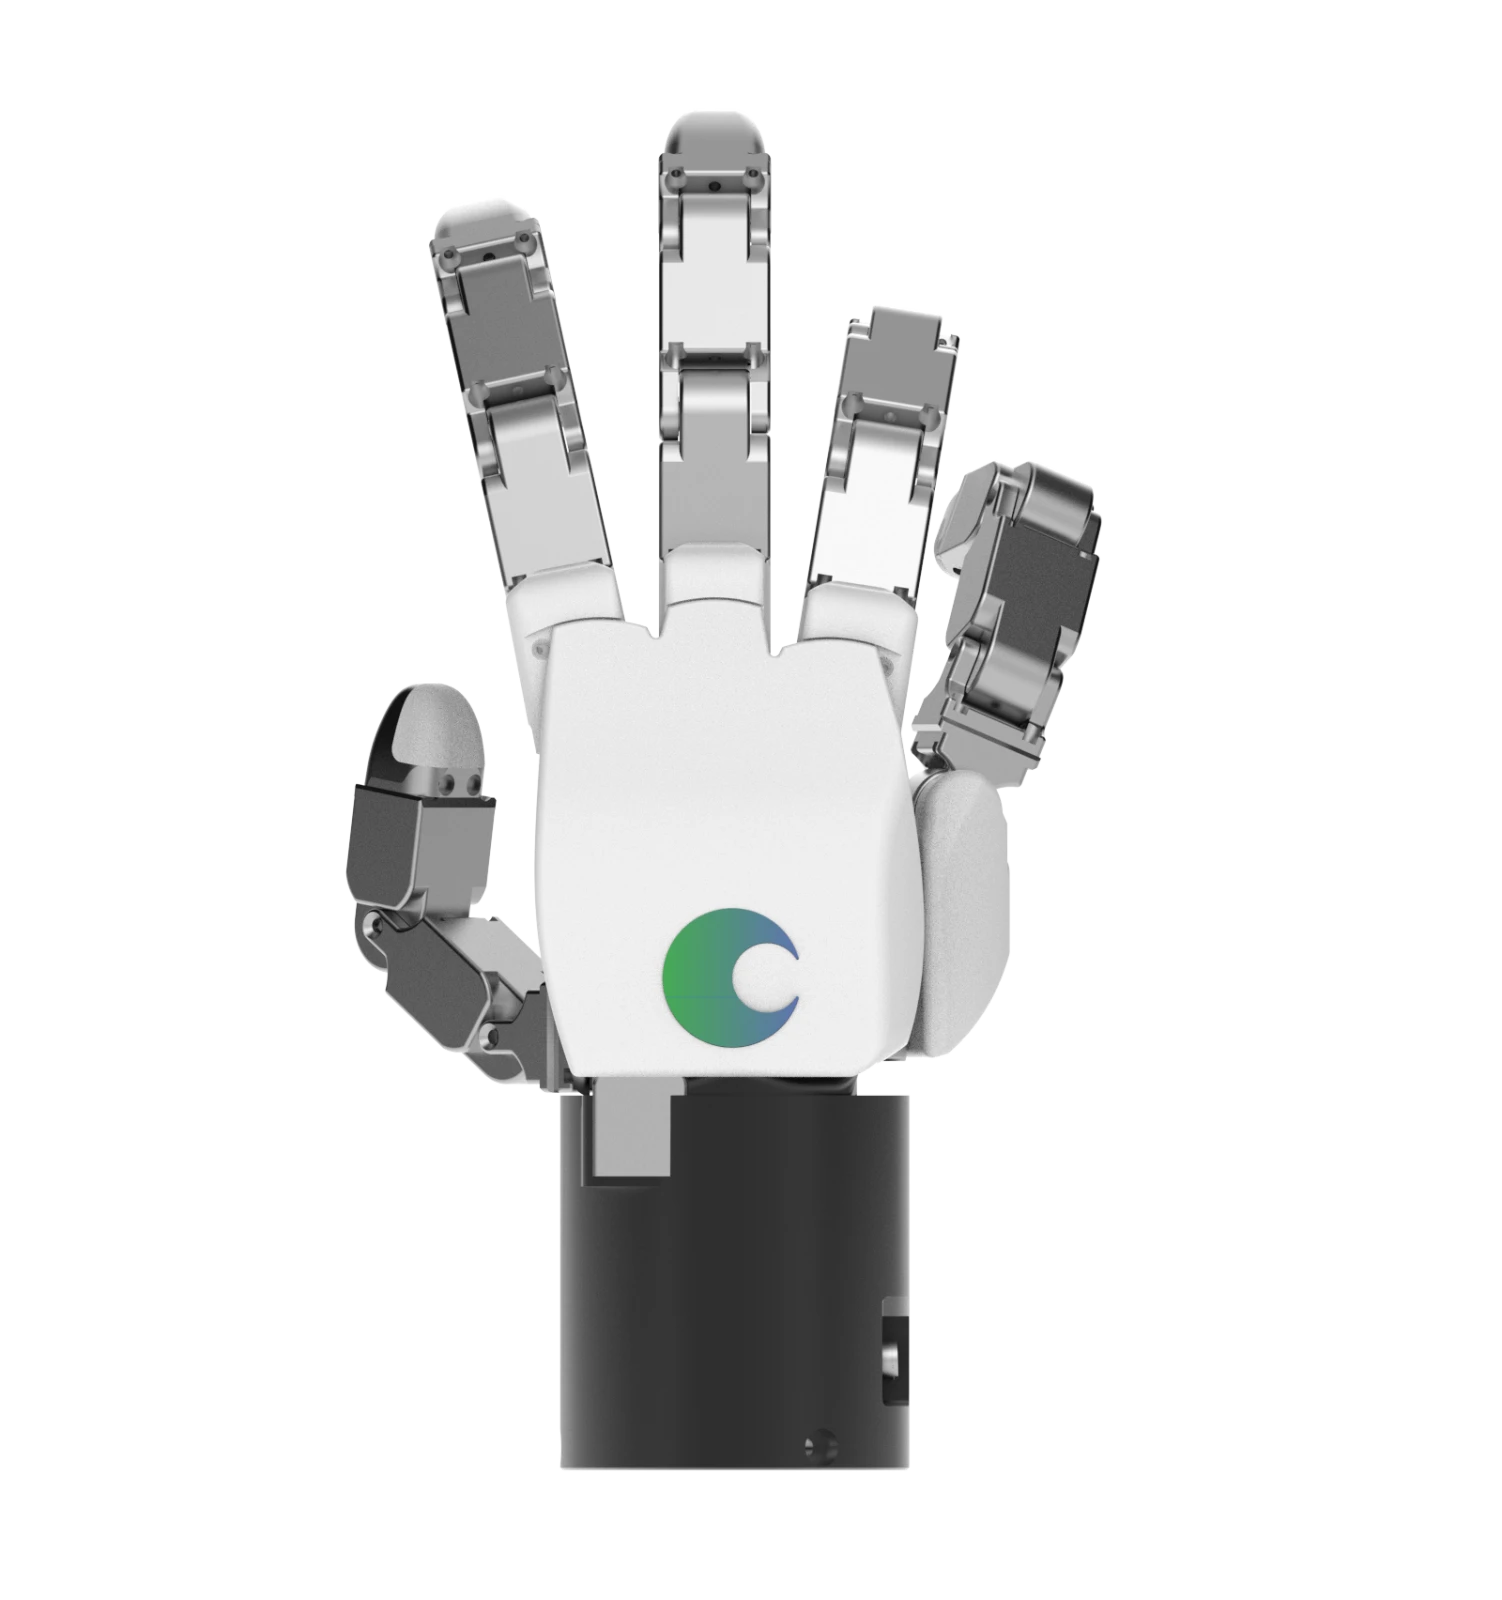
The DG-5F-M is Tesollo's fully actuated five-finger anthropomorphic hand, with 20 degrees of freedom — four per finger — and high-torque actuation for human-like manipulation. What separates it from most multi-finger grippers is that every one of those 20 joints has its own integrated actuator, so there is no mechanical coupling between joints. Each finger can be driven independently, which is what makes in-hand manipulation and tool use possible rather than just grasping. Coordinated multi-finger control handles objects of varying shape and size, and it will hold 10 kg rated in an enveloping grasp, or 2.5 kg rated in a pinch. It runs at 250 Hz over Modbus or Ethernet with absolute encoders on every joint. Optional fingertip sensing adds 6-axis force/torque, 3-axis force or tactile feedback, and suction-type fingertips and a short-wrist version are available. Tesollo positions it for humanoid research, in-hand manipulation and precision assembly.
FUNKTIONEN
- 20 DoF across five fingers, 4 DoF per finger
- Every joint driven by its own integrated actuator
- Fully independent joint control with no inter-joint mechanical coupling
- Enveloping payload 10 kg rated, 20 kg maximum
- Pinching payload 2.5 kg rated, 5 kg maximum
- 1,763 g weight
- 250 Hz control frequency
- Absolute encoders on all joints
- 24 V input, max 10 A
- Modbus (RTU, TCP) and Ethernet (TCP/IP)
- Optional 6-axis F/T, 3-axis force or tactile fingertip sensors
- Optional suction-type fingertip and short-wrist version
TECHNISCHE DATEN
Verifiziert| Physisch | |
| Gewicht | 1.763 kg |
|---|---|
| Traglast | 10 kg |
| Mobilität | |
| Bewegungsart | Stationär |
| Freiheitsgrade | 20 |
| Aktoren | Integrated actuator per joint, absolute encoders |
| Sensorik & Rechenleistung | |
| Konnektivität | Modbus (RTU, TCP), Ethernet (TCP/IP) |
| Software / KI | Delto Gripper Manager and SDK |
Bilder
 martti
 martti
 martti
Bildbeiträge
Videos
ROBOTER-FOREN
Foren werden geladen...
BEWERTUNGEN
HÄUFIG GESTELLTE FRAGEN
What is the Tesollo Delto DG-5F-M?
The DG-5F-M is Tesollo's fully actuated five-finger anthropomorphic hand, with 20 degrees of freedom — four per finger — and high-torque actuation for human-like manipulation.
Who makes the Tesollo Delto DG-5F-M?
The Tesollo Delto DG-5F-M is made by Tesollo, a robotics company based in South Korea.
How much does the Tesollo Delto DG-5F-M cost?
Tesollo has not publicly announced pricing for the Tesollo Delto DG-5F-M. You can enquire through RobotAIGeek for current pricing.
What is the Tesollo Delto DG-5F-M used for?
The Tesollo Delto DG-5F-M is designed for kommissionierung. It is used in fertigung and robotics research settings.
What is the payload capacity of the Tesollo Delto DG-5F-M?
The Tesollo Delto DG-5F-M has a payload capacity of 10 kg.
How much does the Tesollo Delto DG-5F-M weigh?
The Tesollo Delto DG-5F-M weighs 1.76 kg.
How many degrees of freedom does the Tesollo Delto DG-5F-M have?
The Tesollo Delto DG-5F-M has 20 degrees of freedom.
MIT ÄHNLICHEN ROBOTERN VERGLEICHEN
Sehen Sie, wie sich dieser Roboter gegenüber seinen nächsten Alternativen schlägt
- Tesollo Delto DG-5F-M vs Tesollo Delto DG-5F-S
- Tesollo Delto DG-5F-M vs Tesollo Delto DG-4F
- Tesollo Delto DG-5F-M vs Tesollo Delto DG-3F-M
- Tesollo Delto DG-5F-M vs Tesollo Delto DG-3F-B
- Tesollo Delto DG-5F-M vs Barrett BarrettHand BH8-282