BESCHREIBUNG
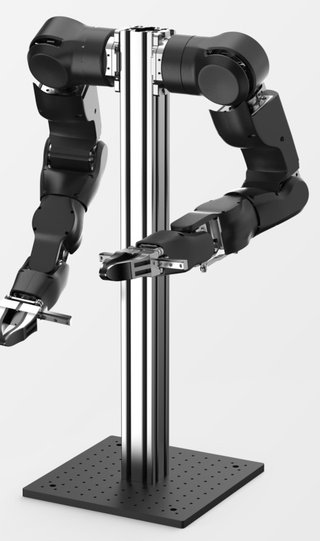
Open arm-HT ist ein Collaborative-Robot von High Torque Technology. Er ist für Pick-and-Place, Forschung, Dual-arm manipulation research ausgelegt. Eckdaten: 6 kg, 5 kg Traglast, 689 mm Reichweite, 7 Freiheitsgrade.
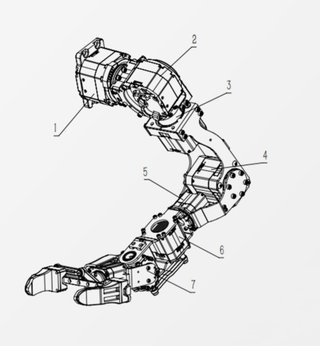
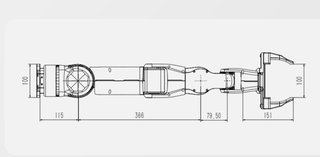
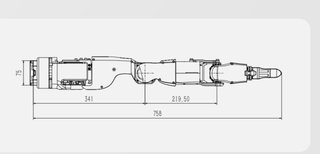
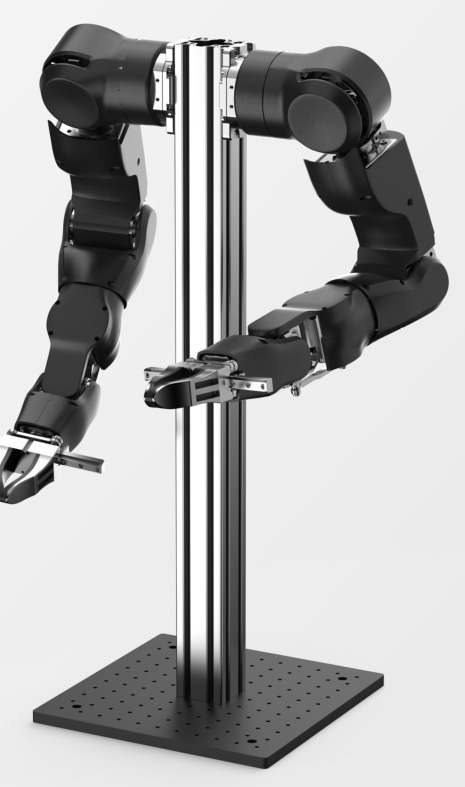
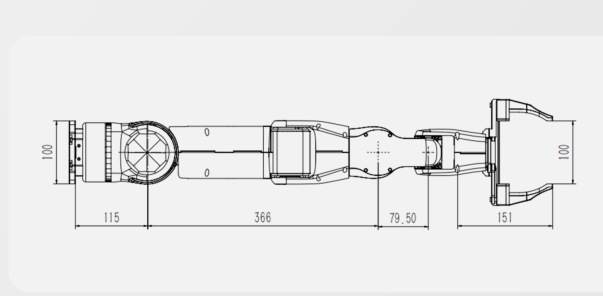
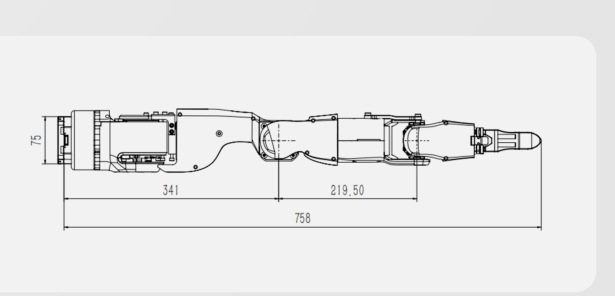
Open arm-HT is High Torque's seven-degree-of-freedom arm, sold as a pair on a shared column so that the two arms work as one dual-arm cell: 689 mm from the mount to the tip at zero position, 1,596 mm of wingspan across the pair. Each arm weighs 6 kg and lifts 5 kg, and the redundant seventh axis is what makes it worth the extra joint — a 7-DoF arm can reach the same point through many different elbow poses, which is how it works around obstacles that would stop a six-axis machine. Peak joint torque is 60 N·m and the end effector moves at up to 3.6 m/s, well above the six-axis Panthera-HT, so it suits dynamic manipulation and teleoperated data collection rather than slow positioning alone. All seven joints run on CAN FD using the same HTDW module family as the rest of the High Torque ecosystem.
FUNKTIONEN
- 7 DoF per arm plus a gripper motor, sold as a synchronised left/right pair on a shared column
- 689 mm sag size at zero position and 1,596 mm dual-arm wingspan
- 6 kg per arm carrying 5 kg maximum load
- 60 N·m peak joint torque
- 3.6 m/s maximum end-effector speed
- CAN FD communication
- redundant seventh axis for obstacle-avoiding elbow poses
- documented joint ranges (-180° to +90°, -15° to +195°, ±90°, -60° to +130°, ±90°, ±45°, ±90°)
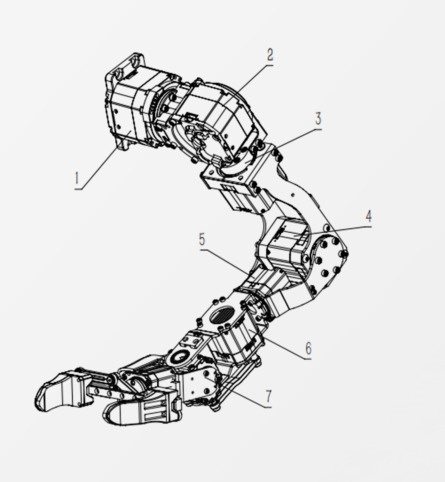
- built from HTDW-7535, 6036, 5036 and 4438 joint modules shared across the High Torque ecosystem
- official Python SDK with Pinocchio kinematics, full dynamics compensation, QP inverse kinematics, trajectory record and playback, and Meta Quest VR teleoperation.
TECHNISCHE DATEN
| Physisch | |
| Gewicht | 6 kg |
|---|---|
| Abmessungen | W 1.6 m |
| Traglast | 5 kg |
| Reichweite | 689 mm |
| Mobilität | |
| Bewegungsart | Stationär |
| Freiheitsgrade | 7 |
| Geschwindigkeit | 12.96 km/h |
| Manipulation | Hoch |
| Aktoren | 7 joints per arm using HTDW-7535-02-CNE, HTDW-6036-02-CNE, HTDW-6036-02-DNE, HTDW-5036-02-DNE, HTDW-4438-30-NE-JC and HTDW-4438-30-NE modules; 60 N·m peak torque; mounted in pairs on a shared column |
| Sensorik & Rechenleistung | |
| Sensoren | joint position sensing on all seven axes |
| Konnektivität | CAN FD |
| Software / KI | Official openarm_HT Python SDK: left-arm, right-arm and synchronised dual-arm control; position, velocity, torque, position-velocity and MIT five-parameter control modes; Pinocchio forward kinematics, inverse kinematics and Jacobians; gravity, friction, Coriolis, mass-matrix and full dynamics compensation; quintic and septic polynomial interpolation with Cartesian trajectories; QP inverse kinematics under joint position, velocity and acceleration constraints; single- and dual-arm trajectory recording, history selection and MIT playback; keyboard Cartesian control and Meta Quest VR DLS/QP teleoperation; YAML joint-limit and URDF configuration. |
ROBOTER-FOREN
Foren werden geladen...
TECHNISCHE DATEN
| Physisch | |
| Gewicht | 6 kg |
|---|---|
| Abmessungen | W 1.6 m |
| Traglast | 5 kg |
| Reichweite | 689 mm |
| Mobilität | |
| Bewegungsart | Stationär |
| Freiheitsgrade | 7 |
| Geschwindigkeit | 12.96 km/h |
| Manipulation | Hoch |
| Aktoren | 7 joints per arm using HTDW-7535-02-CNE, HTDW-6036-02-CNE, HTDW-6036-02-DNE, HTDW-5036-02-DNE, HTDW-4438-30-NE-JC and HTDW-4438-30-NE modules; 60 N·m peak torque; mounted in pairs on a shared column |
| Sensorik & Rechenleistung | |
| Sensoren | joint position sensing on all seven axes |
| Konnektivität | CAN FD |
| Software / KI | Official openarm_HT Python SDK: left-arm, right-arm and synchronised dual-arm control; position, velocity, torque, position-velocity and MIT five-parameter control modes; Pinocchio forward kinematics, inverse kinematics and Jacobians; gravity, friction, Coriolis, mass-matrix and full dynamics compensation; quintic and septic polynomial interpolation with Cartesian trajectories; QP inverse kinematics under joint position, velocity and acceleration constraints; single- and dual-arm trajectory recording, history selection and MIT playback; keyboard Cartesian control and Meta Quest VR DLS/QP teleoperation; YAML joint-limit and URDF configuration. |
Bilder
 martti
 martti
 martti
 martti
Bildbeiträge
Videos
ROBOTER-FOREN
Foren werden geladen...
BEWERTUNGEN
HÄUFIG GESTELLTE FRAGEN
What is the Open arm-HT?
Open arm-HT is High Torque's seven-degree-of-freedom arm, sold as a pair on a shared column so that the two arms work as one dual-arm cell: 689 mm from the mount to the tip at zero position, 1,596 mm of wingspan across the pair.
Who makes the Open arm-HT?
The Open arm-HT is made by High Torque Technology, a robotics company based in China.
How much does the Open arm-HT cost?
High Torque Technology has not publicly announced pricing for the Open arm-HT. You can enquire through RobotAIGeek for current pricing.
What is the Open arm-HT used for?
The Open arm-HT is designed for pick-and-place, forschung, dual-arm manipulation research, and teleoperated data collection. It is used in forschung, bildung, and fertigung settings.
What is the payload capacity of the Open arm-HT?
The Open arm-HT has a payload capacity of 5 kg and a reach of 689 mm.
How much does the Open arm-HT weigh?
The Open arm-HT weighs 6 kg.
How fast is the Open arm-HT?
The Open arm-HT can move at speeds of up to 12.96 km/h.
How many degrees of freedom does the Open arm-HT have?
The Open arm-HT has 7 degrees of freedom.
MIT ÄHNLICHEN ROBOTERN VERGLEICHEN
Sehen Sie, wie sich dieser Roboter gegenüber seinen nächsten Alternativen schlägt
- Open arm-HT vs ASYSTR 3C
- Open arm-HT vs Enlight L
- Open arm-HT vs Linker Arm P7
- Open arm-HT vs SZGH-I3
- Open arm-HT vs SZGH-I5