描述
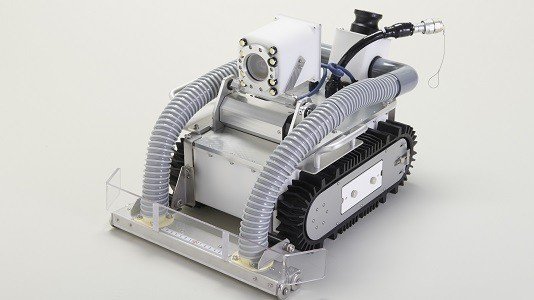
Cavity Decontamination ROV是Diakont的Cleaning-Robots。 面向清潔、檢查、Nuclear cavity decontamination設計。
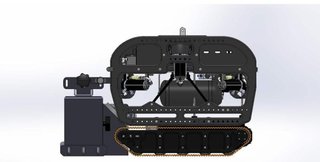
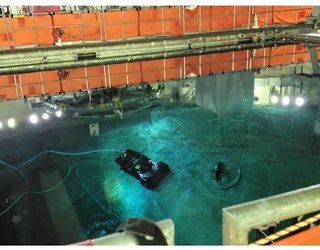
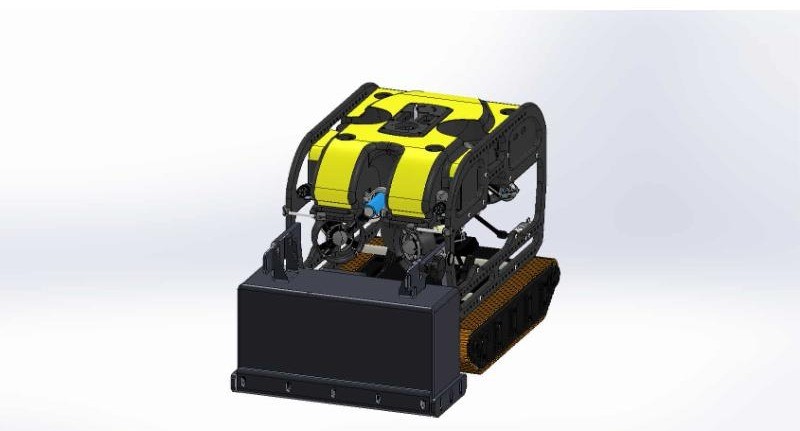
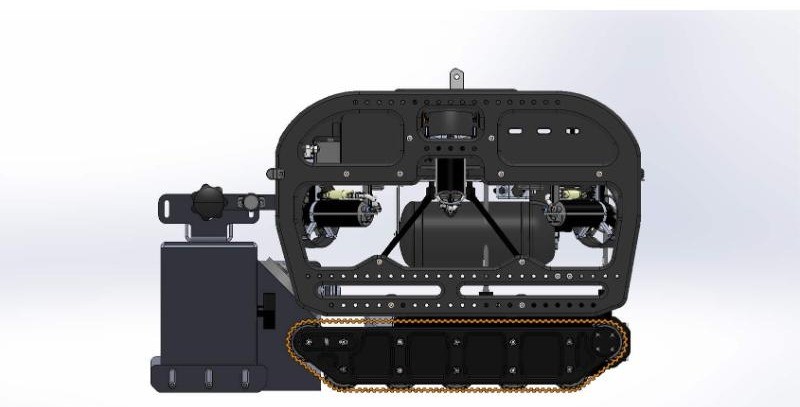
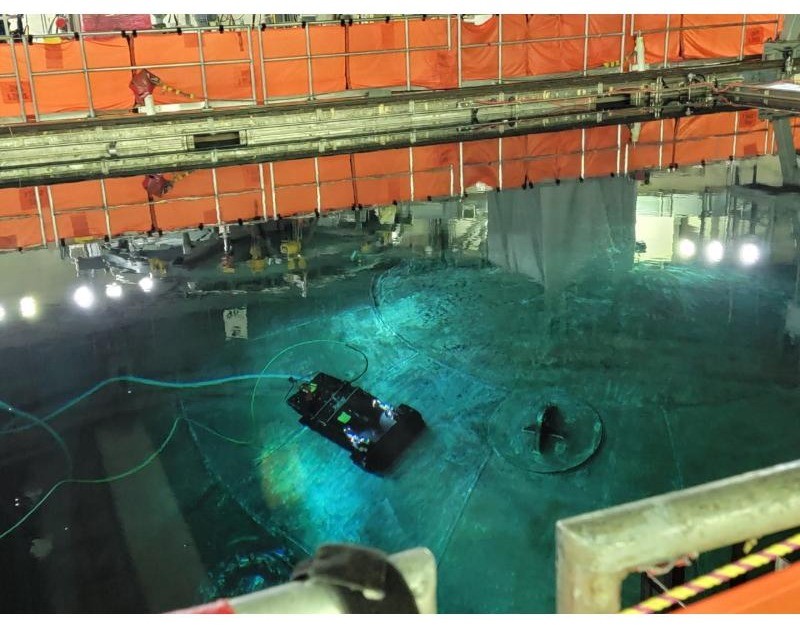
Diakont's cavity decontamination ROV is a hybrid crawler-ROV with an integrated cleaning system that cleans and decontaminates nuclear plant cavities while they are still flooded - refuelling and reactor cavities, drywell heads and other curved surfaces, equipment pools and pits, spent fuel pools, cask loading pools and fuel transfer canals. Because it works underwater in parallel with fuel moves and other outage tasks, it cuts personnel dose and critical-path time compared with brushing a drained cavity by hand. It switches between a swimming mode and a crawling mode without adjustment, and a high-force, no-flow vortex generator holds it on floors, walls and complex shapes, even with residual-heat-removal or shutdown cooling flow running. Rugged brushes loosen crud, which is vacuumed at high flow into a submerged filter. A small team runs it from a control station at the edge of the refuelling floor, with one technician belaying the umbilical; Diakont began the service in 2016 and reported its first applications at four US plants in 2019.
功能特色
- Hybrid crawler-ROV: swim and crawl modes, bridge-free operation
- High-force, no-flow vortex generator for adhesion on floors, walls and curved surfaces
- works with RHR/shutdown cooling flow
- Integrated cleaning: rugged brushes plus high-flow vacuum into a submerged filter
- Applications: reactor cavity, drywell heads, equipment pools and pits, spent fuel pools, cask loading pools, fuel transfer canals
- Runs in parallel with other outage work to cut dose and critical-path time
- Built from nuclear-proven, FME-compliant modules meeting EPRI FME guidelines
技術規格
已驗證| 移動能力 | |
| 移動類型 | 混合型 |
|---|---|
| 作業環境 | Underwater in flooded reactor, fuel-pool and cask-loading cavities |
| 致動器 | Thrusters (swim mode) and tracks with vortex adhesion (crawl mode); brushes and vacuum pump |
| 感知與計算 | |
| 感測器 | cameras |
| 連線方式 | Tethered umbilical |
機器人論壇
正在載入論壇...
技術規格
已驗證| 移動能力 | |
| 移動類型 | 混合型 |
|---|---|
| 作業環境 | Underwater in flooded reactor, fuel-pool and cask-loading cavities |
| 致動器 | Thrusters (swim mode) and tracks with vortex adhesion (crawl mode); brushes and vacuum pump |
| 感知與計算 | |
| 感測器 | cameras |
| 連線方式 | Tethered umbilical |
圖片
 martti
 martti
 martti
圖片貢獻
影片
機器人論壇
正在載入論壇...
評分
常見問題
What is the Cavity Decontamination ROV?
Diakont's cavity decontamination ROV is a hybrid crawler-ROV with an integrated cleaning system that cleans and decontaminates nuclear plant cavities while they are still flooded - refuelling and reactor cavities, drywell heads and other curved surfaces, equipment pools and pits, spent fuel pools, cask loading pools an…
Who makes the Cavity Decontamination ROV?
The Cavity Decontamination ROV is made by Diakont, a robotics company based in United States.
How much does the Cavity Decontamination ROV cost?
Diakont has not publicly announced pricing for the Cavity Decontamination ROV. You can enquire through RobotAIGeek for current pricing.
What is the Cavity Decontamination ROV used for?
The Cavity Decontamination ROV is designed for 清潔, 檢查, and nuclear cavity decontamination. It is used in 能源 settings.
與同類機器人對比
看看這款機器人與最接近的同類產品相比表現如何
- Cavity Decontamination ROV vs Sludge Cleaning Robot
- Cavity Decontamination ROV vs Remotely Operated Underwater Vehicle
- Cavity Decontamination ROV vs JalaDuta
- Cavity Decontamination ROV vs SAUSR Alpha
- Cavity Decontamination ROV vs Crude Oil Sludge Cleaning Robot