描述
X-Bot是Yue Quan Bionics的Humanoid。 面向物料搬运、研究设计。 关键数据:65 kg、51 自由度。
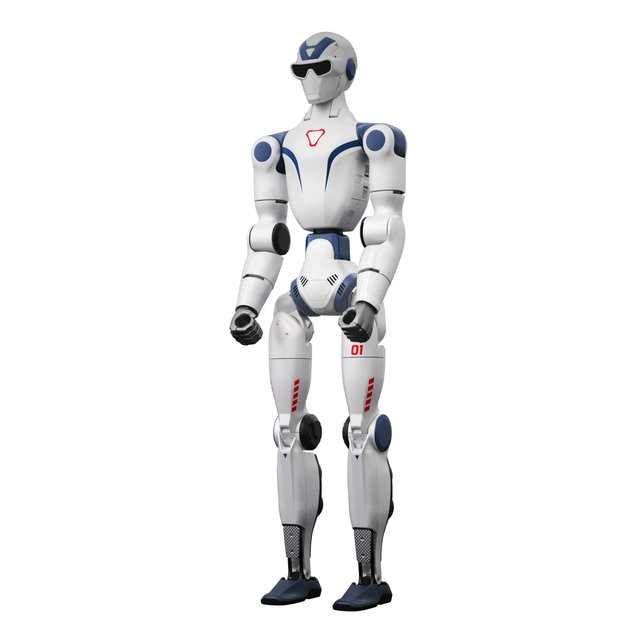
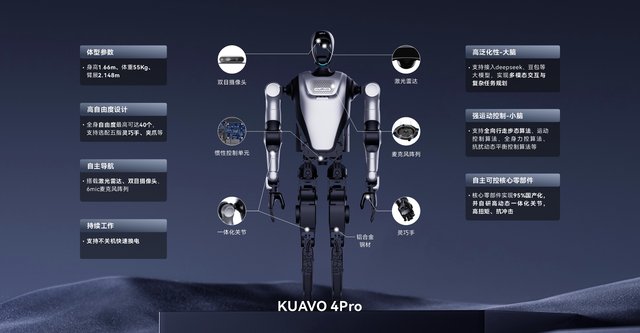
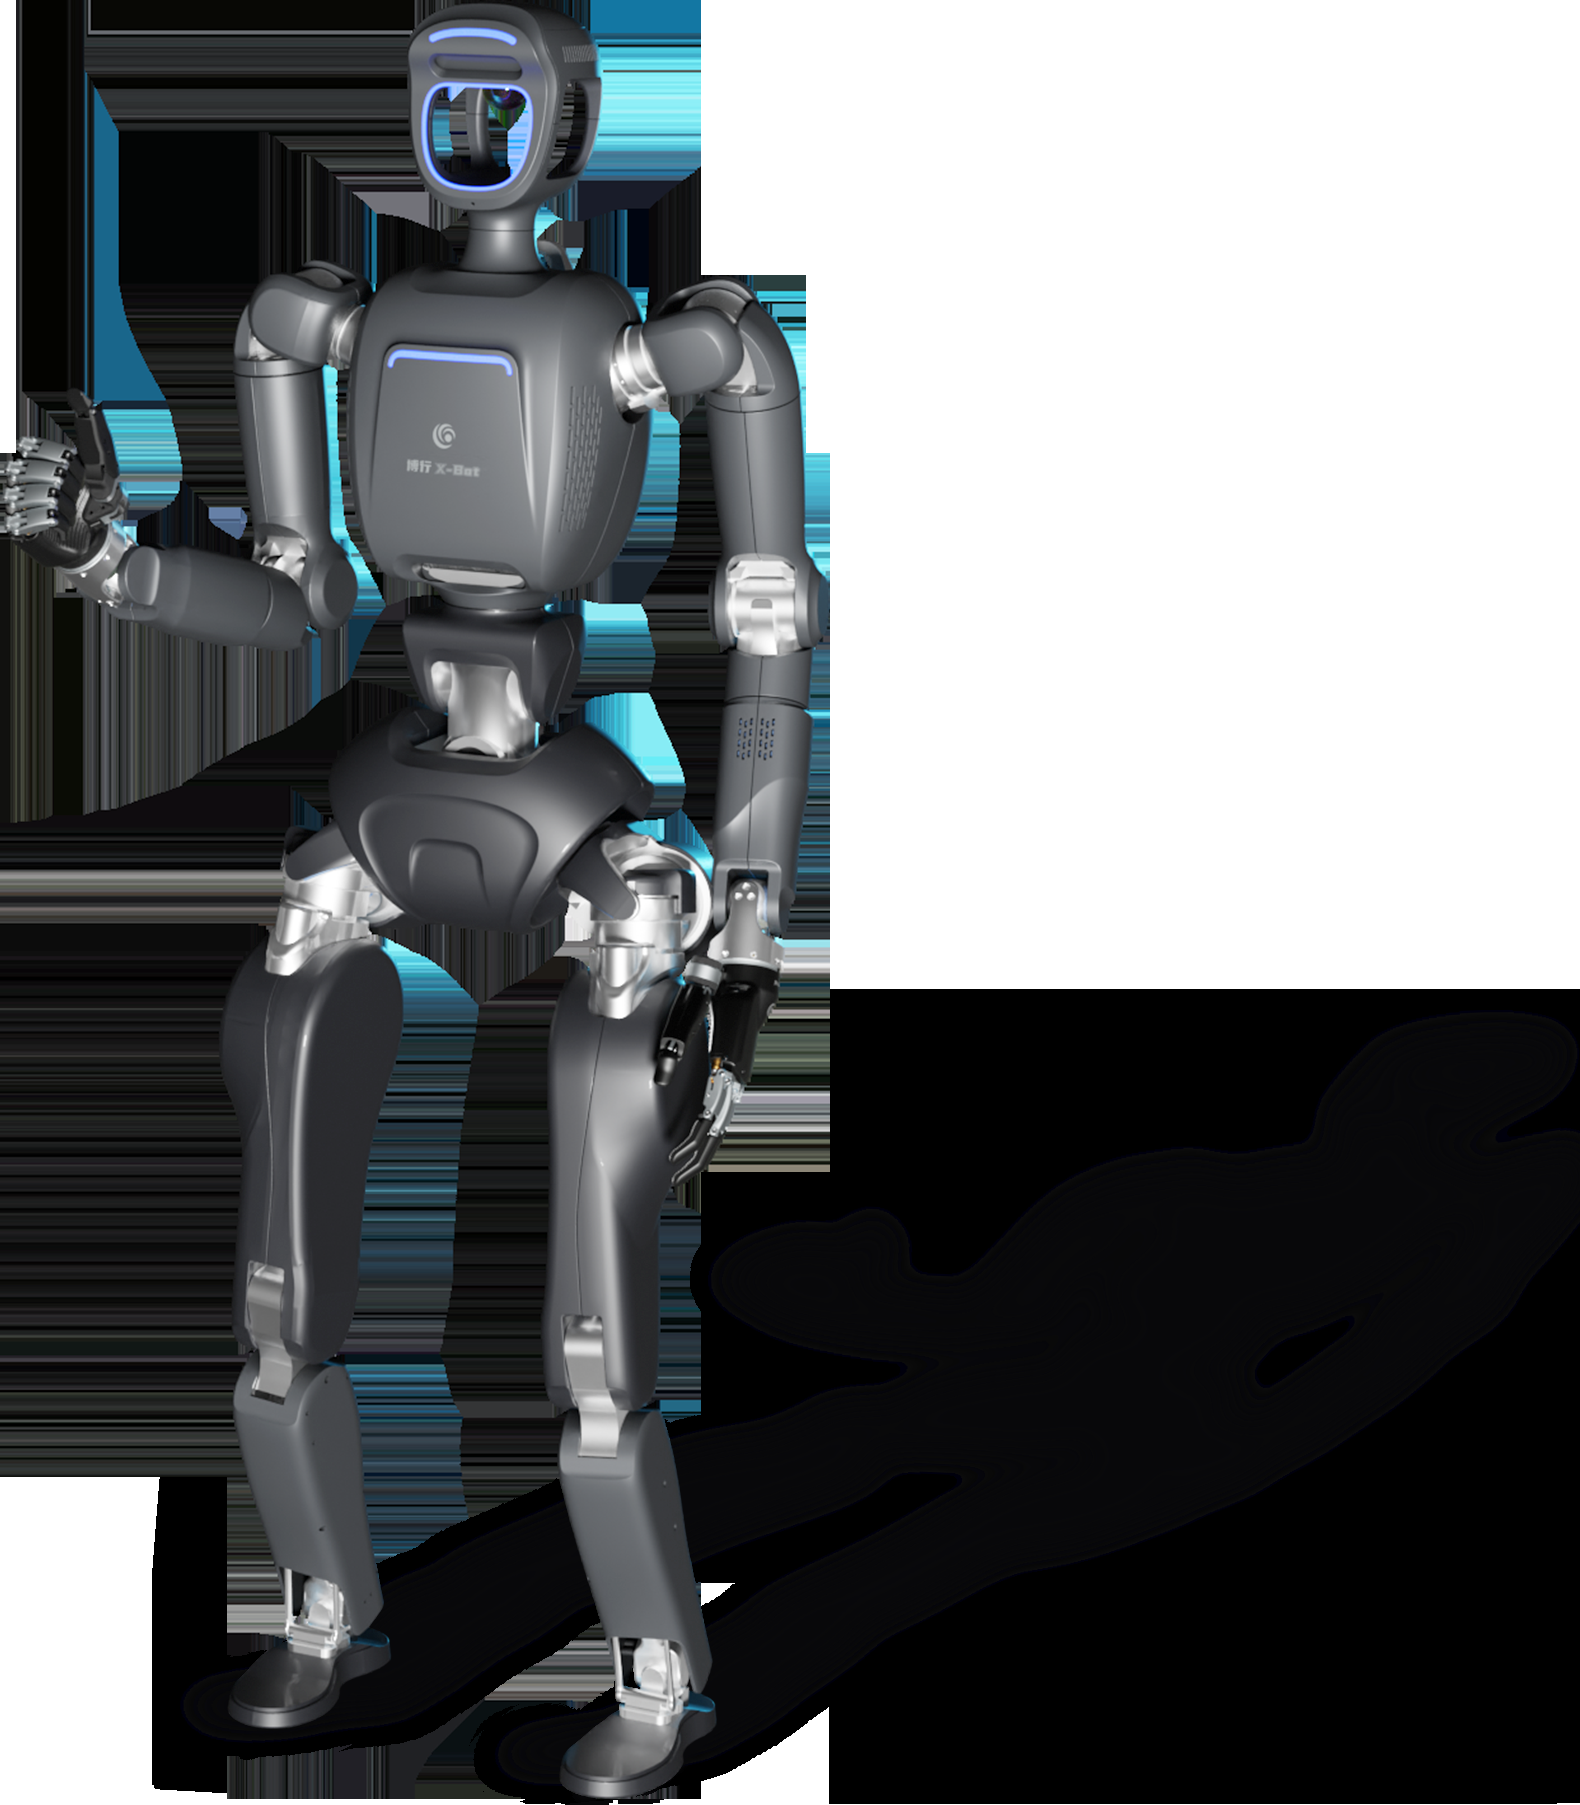
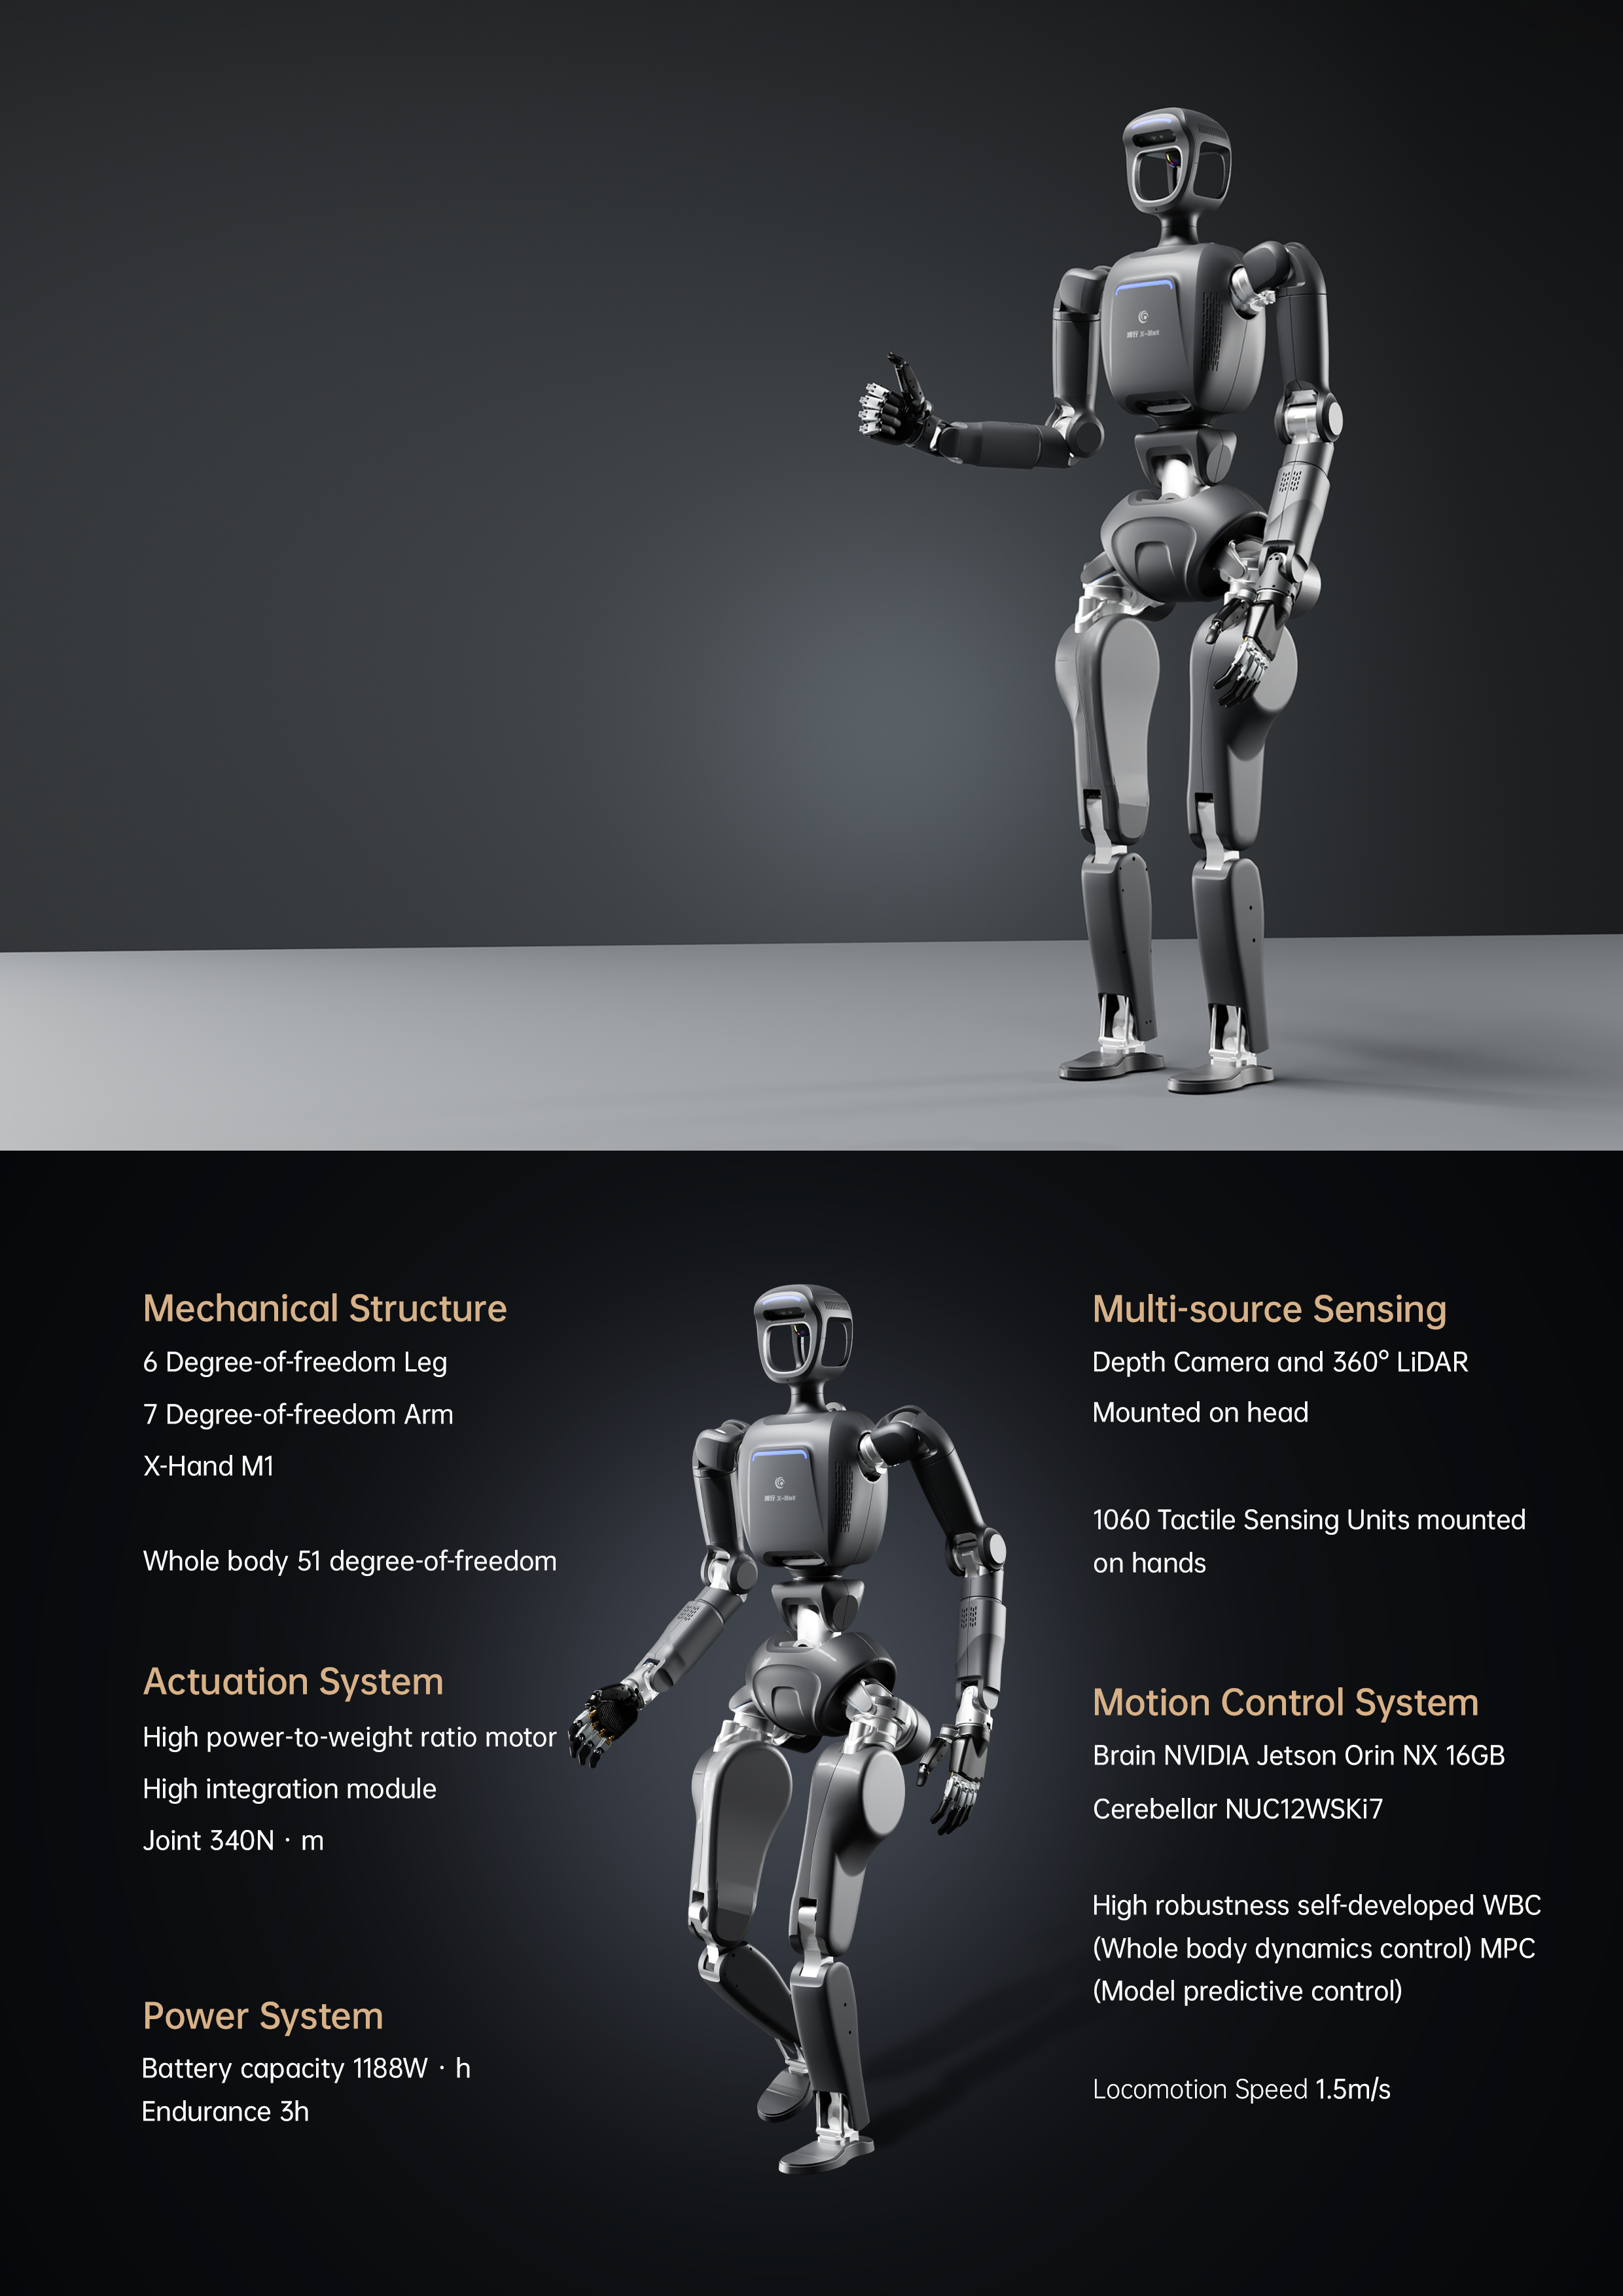
X-Bot is Yue Quan's full-size bipedal humanoid and the clearest expression of its bionic thesis: 1.67 m and 65 kg, driven by up to 51 quasi-direct-drive flexible force-controlled actuators. Quasi-direct drive matters here — with little gearing between motor and joint the robot can feel what it touches and yield to it, which is what makes force control credible rather than nominal. The legs carry four high-sensitivity quasi-direct-drive force-controlled joints on a 7:1 gear ratio, which the company claims as the highest torque density in the field. The numbers support it: 340 N·m at both knee and hip, against 46 N·m at the ankle and 60 N·m at the arm joints. It walks at up to 1.5 m/s. Fifty-one degrees of freedom are distributed as six per leg — three at the hip, one at the knee, two at the ankle — seven per arm, and three at the waist. Control is split between a NUC12WSKi7 running whole-body dynamics control and model-predictive control as the cerebellum, and an NVIDIA Jetson Orin NX 16 GB as the brain for vision and higher decisions. Perception is an Intel RealSense D435 depth camera and a Livox 360-degree LiDAR, and an 1,188 Wh battery feeds it at 48 V.
功能特点
- Height 1,670 mm
- weight 65 kg
- 51 whole-body degrees of freedom
- Up to 51 quasi-direct-drive flexible force-controlled actuators
- Leg DoF: hip 3 + knee 1 + ankle 2 = 6 per leg
- Arm DoF: shoulder 3 + elbow 1 + arm 1 + wrist 2 = 7 per arm
- waist 3 DoF
- Joint torque: knee 340 N·m, hip 340 N·m, ankle 46 N·m, arm 60 N·m
- Four high-sensitivity quasi-direct-drive force-controlled leg joints at 7:1 gear ratio
- Walking speed up to 1.5 m/s
- Battery 1,188 Wh at 48 V, maximum output current 25 A
- Cerebellum: NUC12WSKi7 for motion control with whole-body dynamics (WBC) and model predictive control (MPC)
- Brain: NVIDIA Jetson Orin NX 16 GB for AI, vision and high-level decisions
- Perception: Intel RealSense D435 depth camera and Livox 360-degree LiDAR
- Wi-Fi 6 and Bluetooth 5.0 for remote real-time control and debugging
技术规格
| 物理参数 | |
| 重量 | 65 kg |
|---|---|
| 外形尺寸 | H 1.67 m |
| 移动能力 | |
| 运动类型 | 两足行走, 类人机器人 |
| 自由度 | 51 |
| 速度 | 5.4 km/h |
| 操作能力 | 高 |
| 作业环境 | Indoor research and industrial settings |
| 执行器 | 51 quasi-direct-drive flexible force-controlled actuators; leg joints at 7:1 gear ratio delivering 340 N·m at knee and hip |
| 电源与续航 | |
| 续航时间 | 1.19 kWh |
| 感知与计算 | |
| 传感器 | Intel RealSense D435 depth camera, Livox 360-degree LiDAR |
| 软件 / AI | Whole-body dynamics control (WBC) with model predictive control (MPC) |
图片
 martti
 martti
 martti
图片贡献
视频
机器人论坛
正在加载论坛...
评分
常见问题
What is the X-Bot?
X-Bot is Yue Quan's full-size bipedal humanoid and the clearest expression of its bionic thesis: 1.67 m and 65 kg, driven by up to 51 quasi-direct-drive flexible force-controlled actuators.
Who makes the X-Bot?
The X-Bot is made by Yue Quan Bionics, a robotics company based in China.
How much does the X-Bot cost?
Yue Quan Bionics has not publicly announced pricing for the X-Bot. You can enquire through RobotAIGeek for current pricing.
What is the X-Bot used for?
The X-Bot is designed for 物料搬运 and 研究. It is used in 研究 and 制造业 settings.
How much does the X-Bot weigh?
The X-Bot weighs 65 kg.
How fast is the X-Bot?
The X-Bot can move at speeds of up to 5.4 km/h.
How many degrees of freedom does the X-Bot have?
The X-Bot has 51 degrees of freedom.
与同类机器人对比
看看这款机器人与最接近的同类产品相比表现如何
X-Bot 的替代选择 →