描述
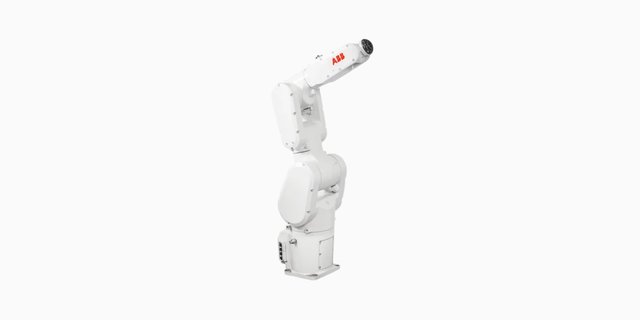
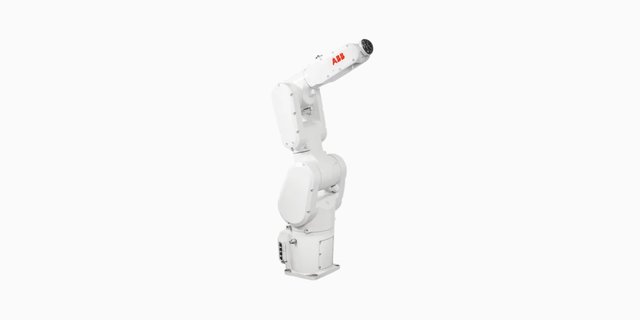
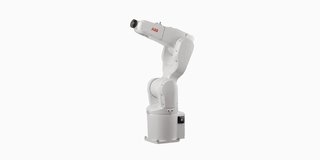
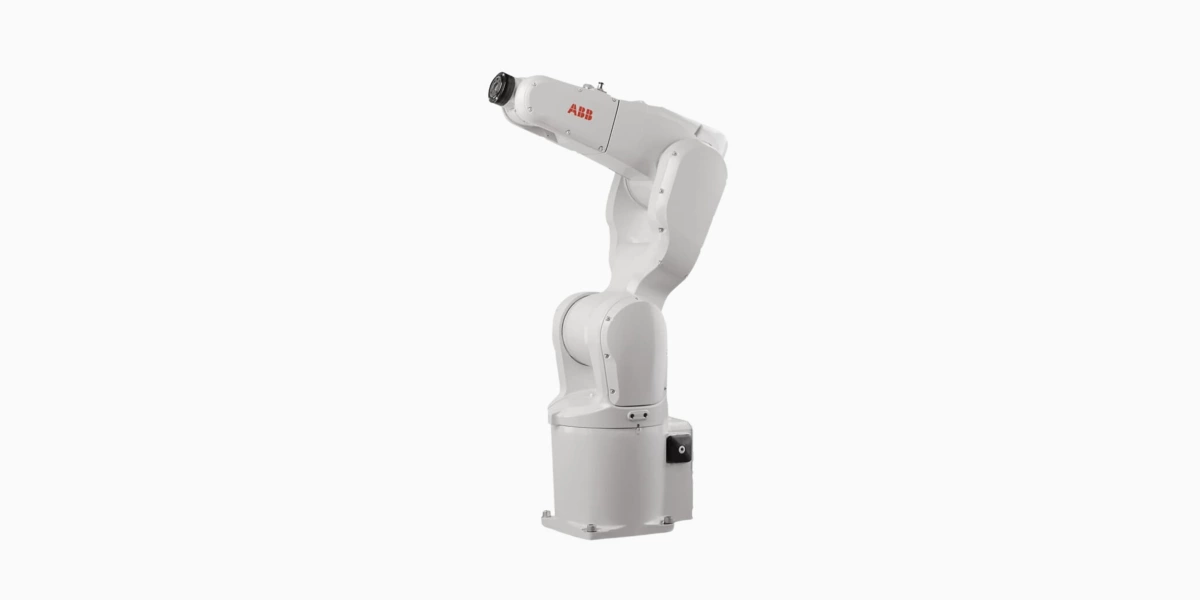
IRB 1200-7/0.7 Gen2是ABB Robotics的Industrial-Robot。 面向机床操作、物料搬运设计。 关键数据:52 kg、负载 7 kg、臂展 700 mm、6 自由度、2025 年发布。
The ABB IRB 1200-7/0.7 Gen2 is a high performance articulated robot with a 7 kg payload capacity and 700 mm reach, engineered for precision automation in demanding industrial environments.
功能特点
- Floor/wall/ceiling mounting, IP67 option, Clean Room ISO 4 option, improved speed and energy efficiency vs Gen 1, TrueMove & QuickMove
技术规格
| 物理参数 | |
| 重量 | 52 kg |
|---|---|
| 负载 | 7 kg |
| 臂展 | 700 mm |
| 移动能力 | |
| 运动类型 | 文具 |
| 自由度 | 6 |
| 操作能力 | 低 |
视频
机器人论坛
正在加载论坛...
技术规格
| 物理参数 | |
| 重量 | 52 kg |
|---|---|
| 负载 | 7 kg |
| 臂展 | 700 mm |
| 移动能力 | |
| 运动类型 | 文具 |
| 自由度 | 6 |
| 操作能力 | 低 |
图片
 martti
图片贡献
机器人论坛
正在加载论坛...
评分
常见问题
What is the IRB 1200-7/0.7 Gen2?
The ABB IRB 1200-7/0.7 Gen2 is a high performance articulated robot with a 7 kg payload capacity and 700 mm reach, engineered for precision automation in demanding industrial environments.
Who makes the IRB 1200-7/0.7 Gen2?
The IRB 1200-7/0.7 Gen2 is made by ABB Robotics, a robotics company based in China.
How much does the IRB 1200-7/0.7 Gen2 cost?
ABB Robotics has not publicly announced pricing for the IRB 1200-7/0.7 Gen2. You can enquire through RobotAIGeek for current pricing.
What is the IRB 1200-7/0.7 Gen2 used for?
The IRB 1200-7/0.7 Gen2 is designed for 机床操作 and 物料搬运. It is used in 制造业 settings.
What is the payload capacity of the IRB 1200-7/0.7 Gen2?
The IRB 1200-7/0.7 Gen2 has a payload capacity of 7 kg and a reach of 700 mm.
How much does the IRB 1200-7/0.7 Gen2 weigh?
The IRB 1200-7/0.7 Gen2 weighs 52 kg.
How many degrees of freedom does the IRB 1200-7/0.7 Gen2 have?
The IRB 1200-7/0.7 Gen2 has 6 degrees of freedom.
When was the IRB 1200-7/0.7 Gen2 released?
The IRB 1200-7/0.7 Gen2 was released in 2025.
与同类机器人对比
看看这款机器人与最接近的同类产品相比表现如何
- IRB 1200-7/0.7 Gen2 vs IRB 1200-9/0.7 Gen2
- IRB 1200-7/0.7 Gen2 vs IRB 1200-8/0.9 Gen2
- IRB 1200-7/0.7 Gen2 vs IRB 1200-5/0.9 Gen2
- IRB 1200-7/0.7 Gen2 vs IRB 1300-11/0.9
- IRB 1200-7/0.7 Gen2 vs IRB 1300-10/1.15