描述
Gravis RACK Autonomous Excavation System是Gravis Robotics的Industrial-Robot。 面向建筑、正在加载、物料搬运设计。
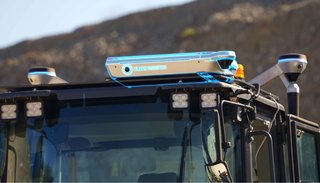
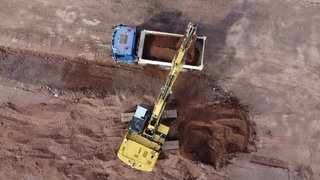
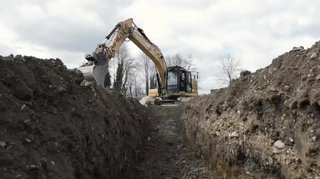
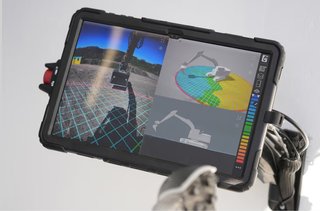
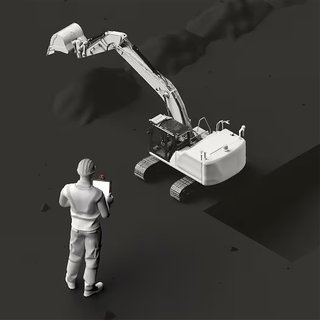
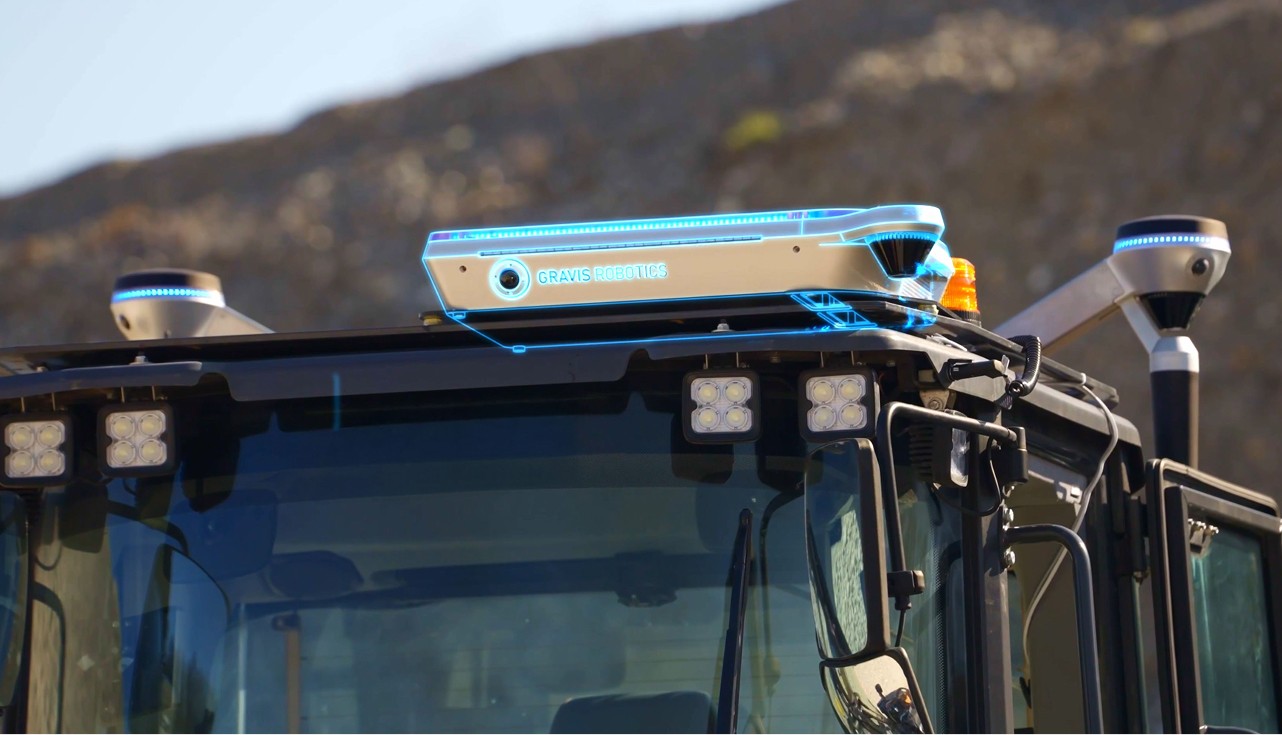
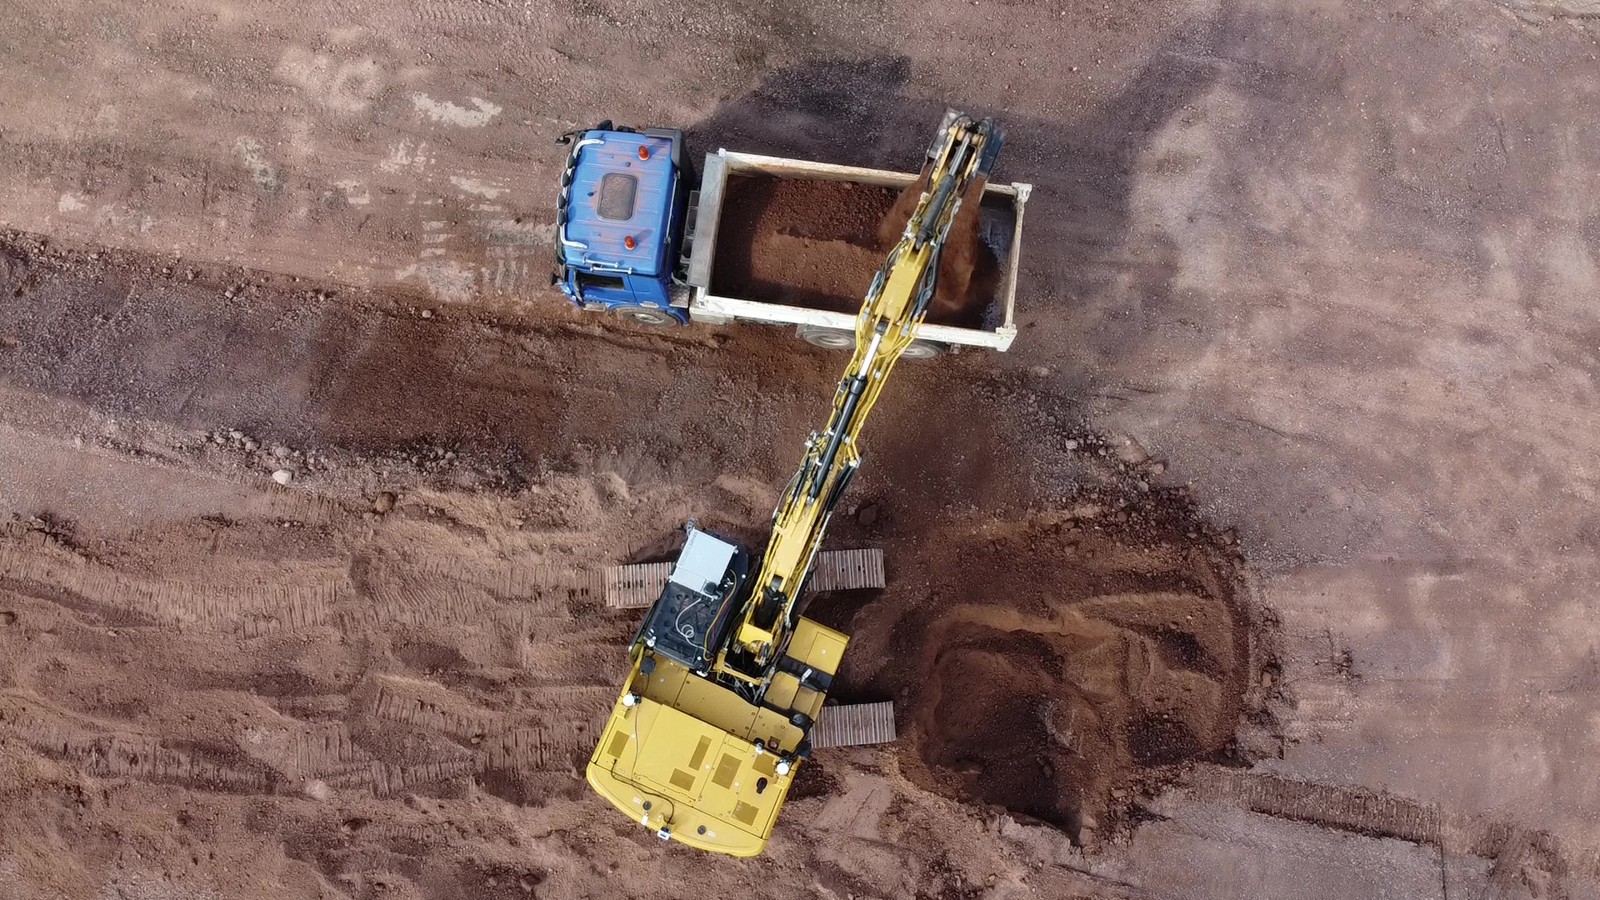
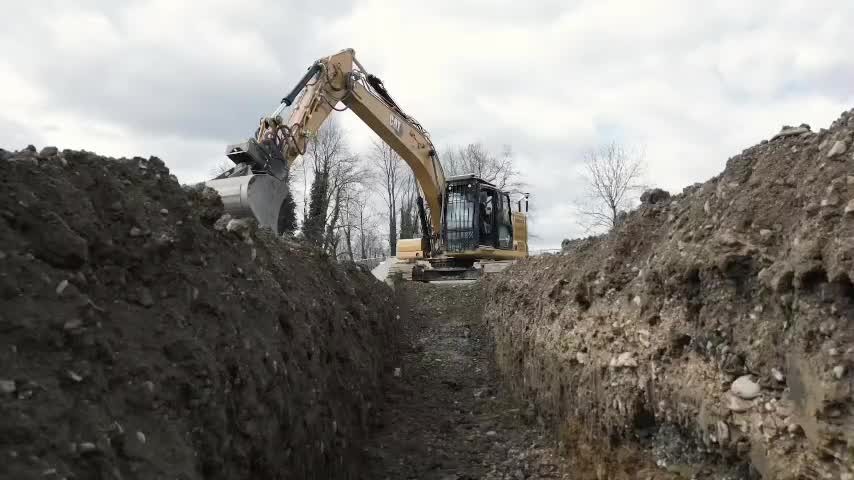
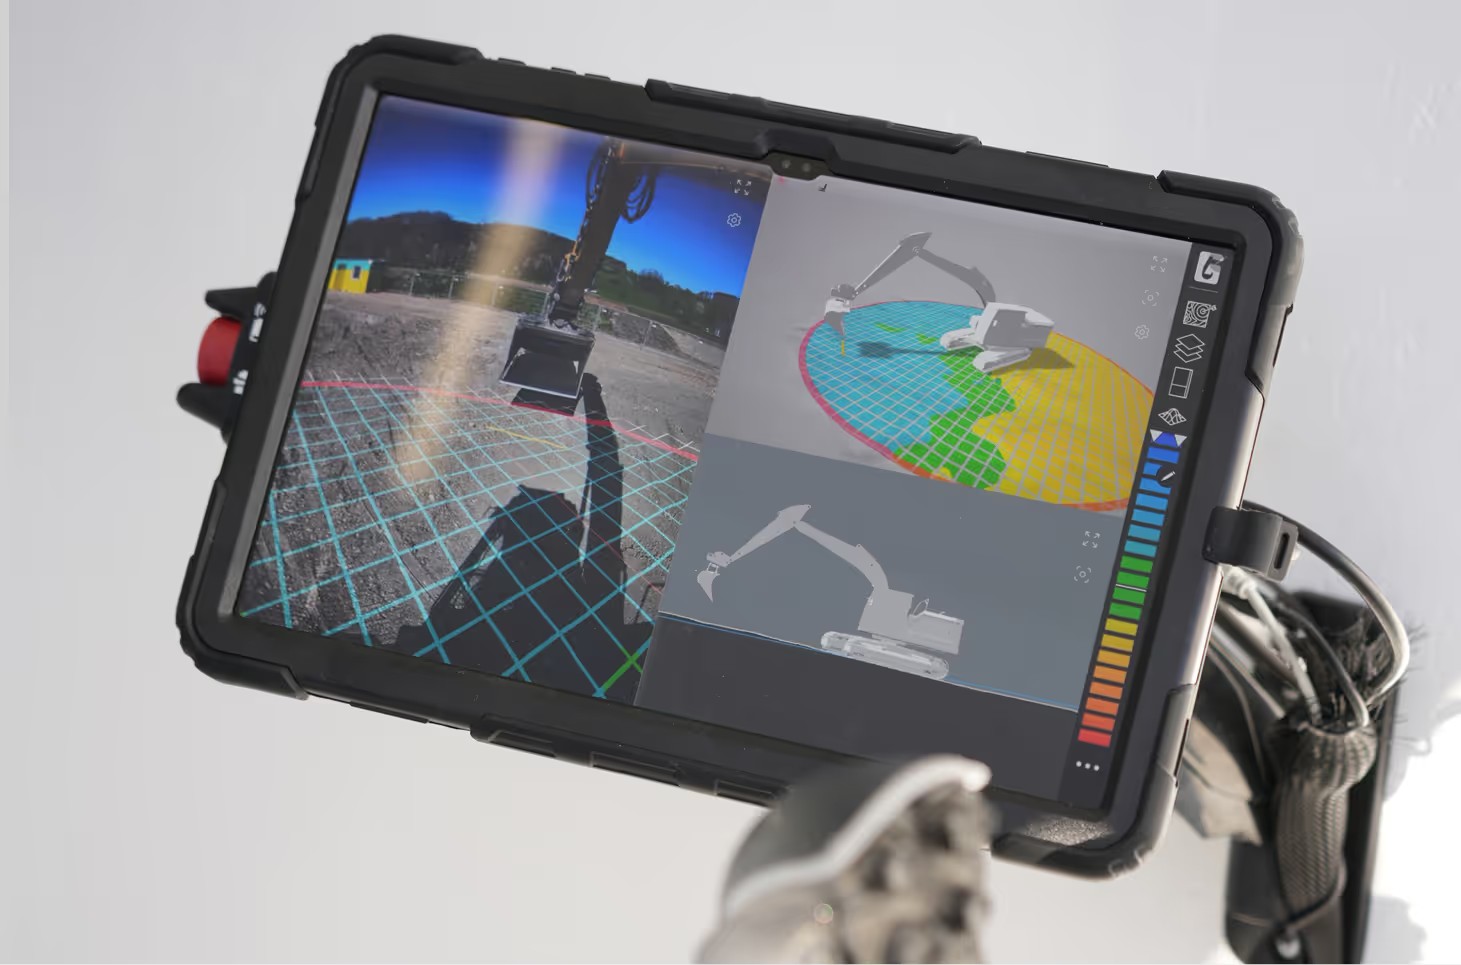
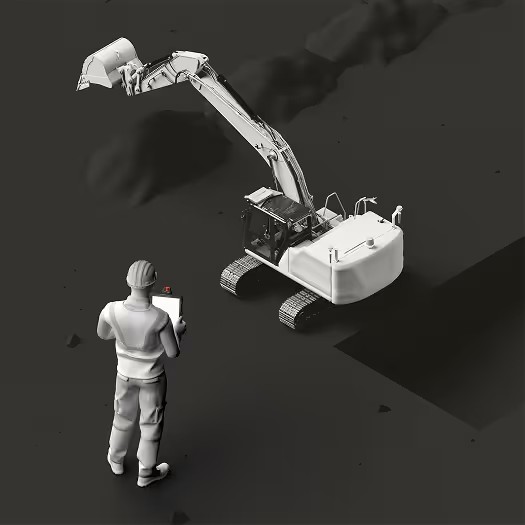
The Gravis RACK is a modular rooftop autonomy kit that turns an existing excavator or wheel loader into a robot. It bolts onto machines from about 10 to more than 100 tonnes across a dozen brands, connects to electro-hydraulic pilot valves (older mechanical machines get a retrofit EH valve), and lets Gravis' learning-based, soil-aware AI dig, load and dump on its own. A forward camera and lidar scan the terrain ahead, smart rear masts combine RTK GNSS with HDR cameras, 3D lidar, long-range Wi-Fi and status lights, and surround-view cameras give the operator a live picture; automotive-grade edge computing keeps it running offline. Operators drive it from Slate, a tablet with a wireless stop: they can use it as an in-cab copilot, define tap-to-dig jobs from CAD/BIM models or on-site points, step out for long autonomous tasks, or supervise several machines remotely. Perception finds dump trucks for precision truck loading or dumps to a spoil pile or hopper, and 360° lidar scanning shows live cut/fill and as-built data. Gravis says it raises throughput by up to 30%; machines are available as retrofits or as turnkey Gravis-equipped rentals and purchases through dealers.
功能特点
- Modular rooftop autonomy kit for excavators and wheel loaders, about 10 to 100+ tonnes
- Installed on a dozen machine brands
- electro-hydraulic pilot-valve interface
- Learning-based, soil-aware AI for autonomous excavation
- up to 30% more throughput
- Forward camera and lidar for terrain scanning
- automotive-grade edge computer works offline
- Smart masts: RTK GNSS, wide-angle HDR cameras, 3D lidar, long-range Wi-Fi, status lights
- Surround-view cameras and low-latency HDR video for supervision and remote control
- 360° lidar surveying with live cut/fill visualisation and as-builts
- Truck detection for precision truck loading
- dump to pile, hopper or truck
- Slate tablet: in-cab copilot, tap-to-dig jobs from CAD/BIM, remote multi-machine supervision, wireless stop
技术规格
已验证| 移动能力 | |
| 运动类型 | 其他 |
|---|---|
| 作业环境 | Outdoor construction sites, quarries and mines |
| 感知与计算 | |
| 传感器 | forward camera, lidar, 3D lidar, RTK GNSS, HDR surround-view cameras |
| 连接方式 | Long-range Wi-Fi; low-latency video streaming |
| 软件 / AI | Gravis AI copilot; Slate tablet interface (tap-to-dig, Grade-Vis, AR) |
机器人论坛
正在加载论坛...
技术规格
已验证| 移动能力 | |
| 运动类型 | 其他 |
|---|---|
| 作业环境 | Outdoor construction sites, quarries and mines |
| 感知与计算 | |
| 传感器 | forward camera, lidar, 3D lidar, RTK GNSS, HDR surround-view cameras |
| 连接方式 | Long-range Wi-Fi; low-latency video streaming |
| 软件 / AI | Gravis AI copilot; Slate tablet interface (tap-to-dig, Grade-Vis, AR) |
图片
 martti
 martti
 martti
 martti
 martti
图片贡献
视频
机器人论坛
正在加载论坛...
评分
常见问题
What is the Gravis RACK Autonomous Excavation System?
The Gravis RACK is a modular rooftop autonomy kit that turns an existing excavator or wheel loader into a robot. It bolts onto machines from about 10 to more than 100 tonnes across a dozen brands, connects to electro-hydraulic pilot valves (older mechanical machines get a retrofit EH valve), and lets Gravis' learning-b…
Who makes the Gravis RACK Autonomous Excavation System?
The Gravis RACK Autonomous Excavation System is made by Gravis Robotics, a robotics company based in Switzerland.
How much does the Gravis RACK Autonomous Excavation System cost?
Gravis Robotics has not publicly announced pricing for the Gravis RACK Autonomous Excavation System. You can enquire through RobotAIGeek for current pricing.
What is the Gravis RACK Autonomous Excavation System used for?
The Gravis RACK Autonomous Excavation System is designed for 建筑, 正在加载, 物料搬运, and 测量. It is used in 采矿 and 建筑 settings.
与同类机器人对比
看看这款机器人与最接近的同类产品相比表现如何
- Gravis RACK Autonomous Excavation System vs sensmore Loader Automation
- Gravis RACK Autonomous Excavation System vs Autonom Tract AT135
- Gravis RACK Autonomous Excavation System vs DIGGER SCRAPER
- Gravis RACK Autonomous Excavation System vs SwappBot
- Gravis RACK Autonomous Excavation System vs Laser Inspection Robot