
説明
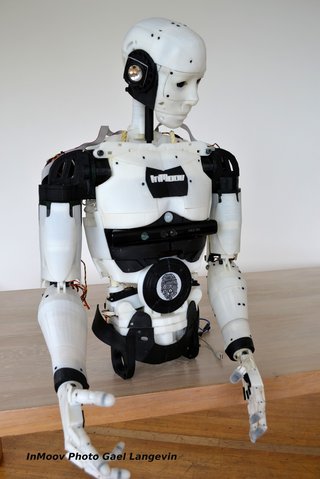
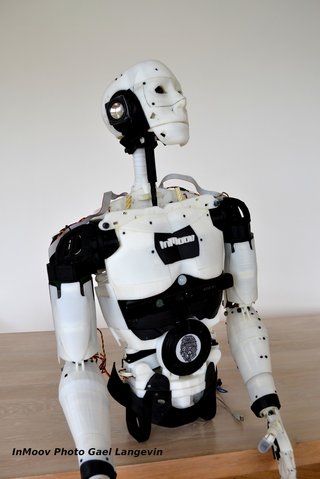
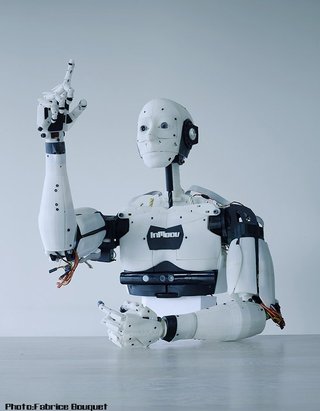
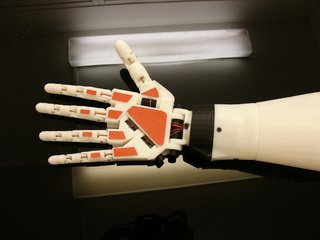
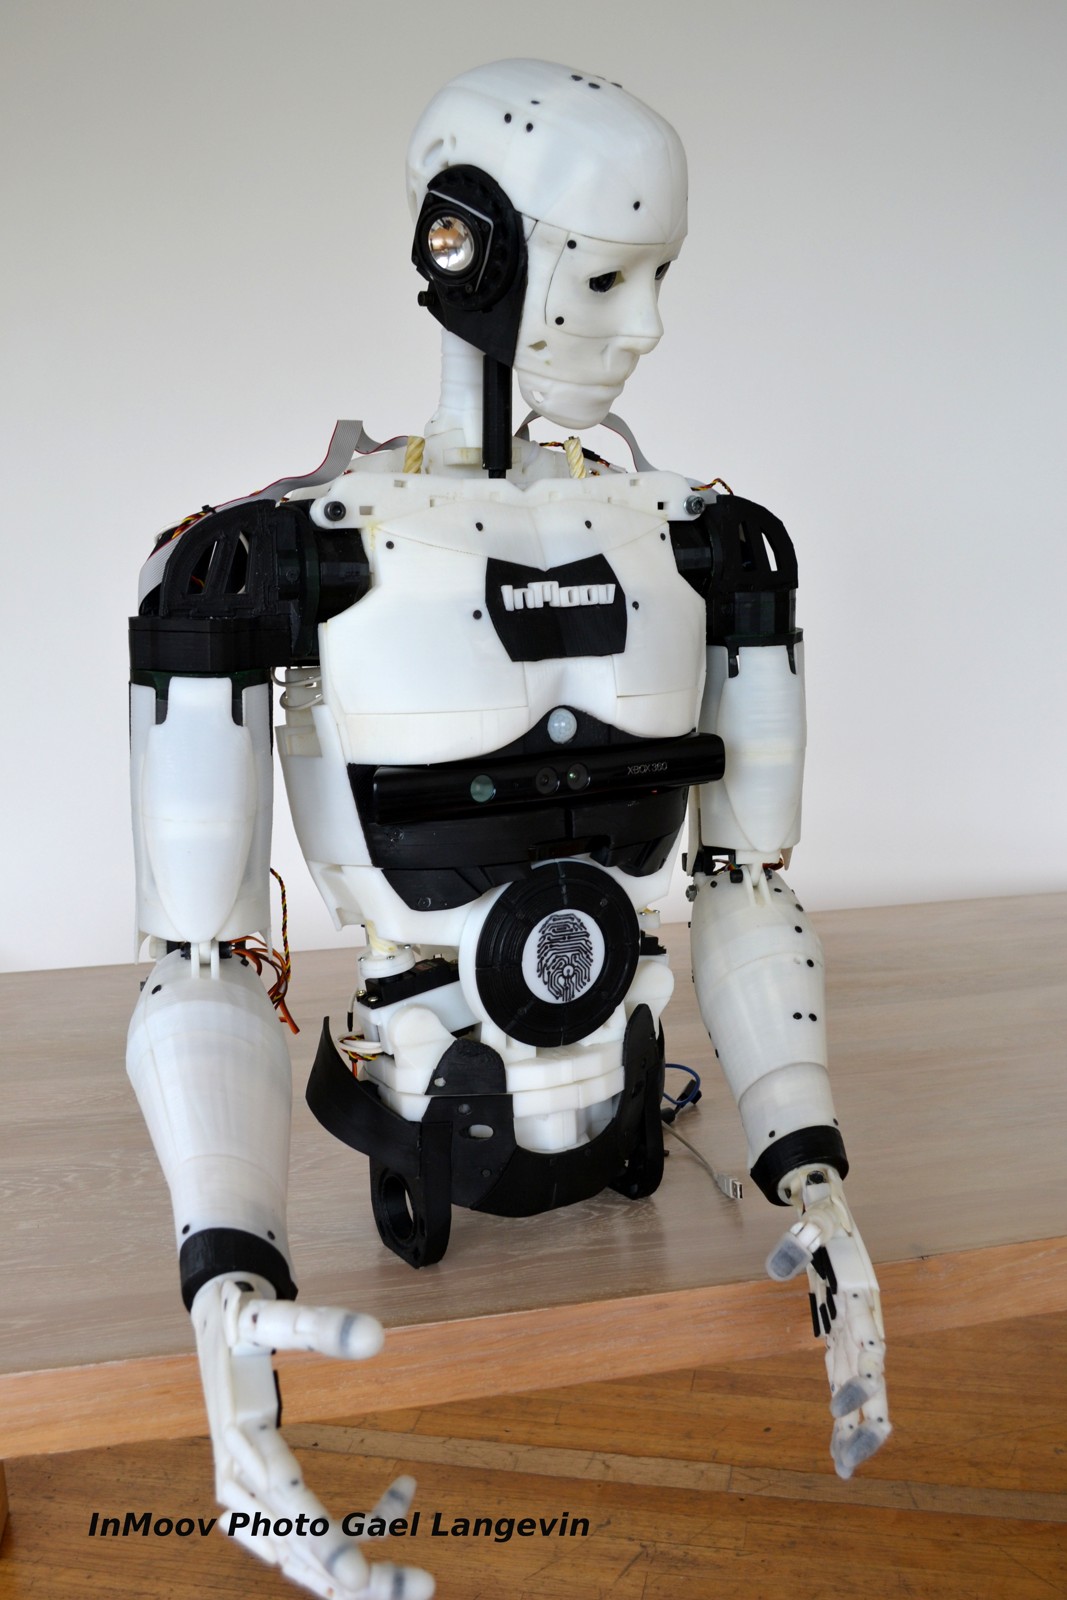
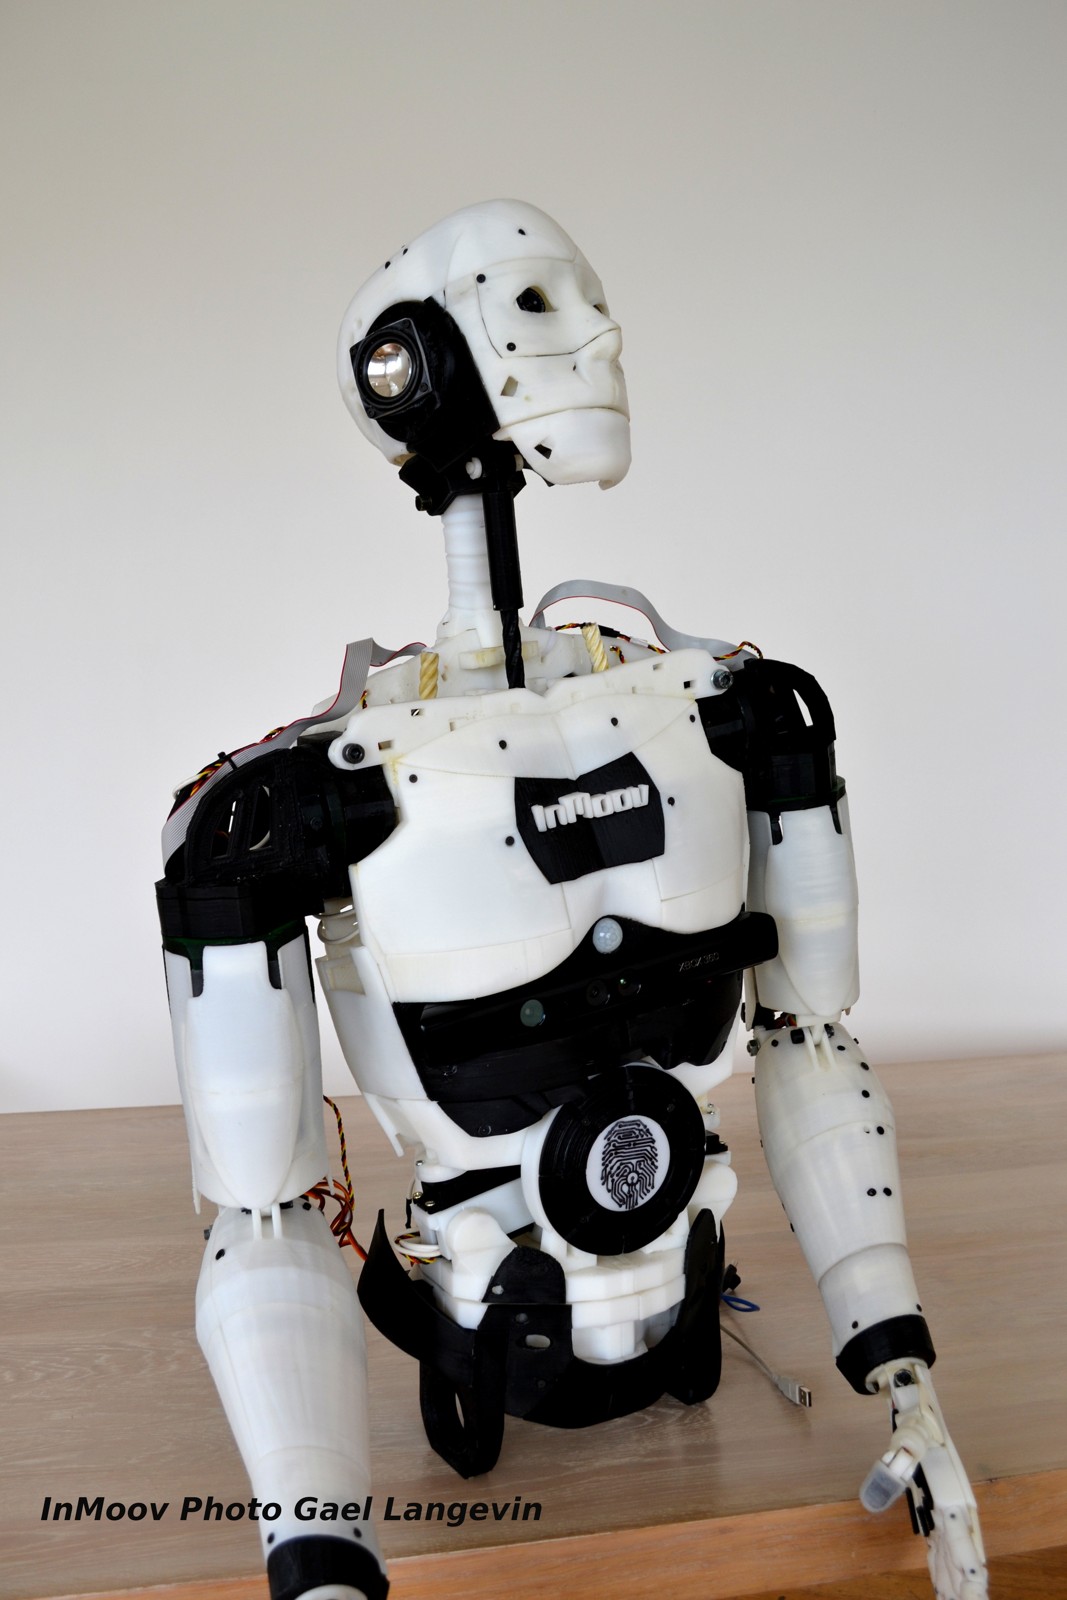
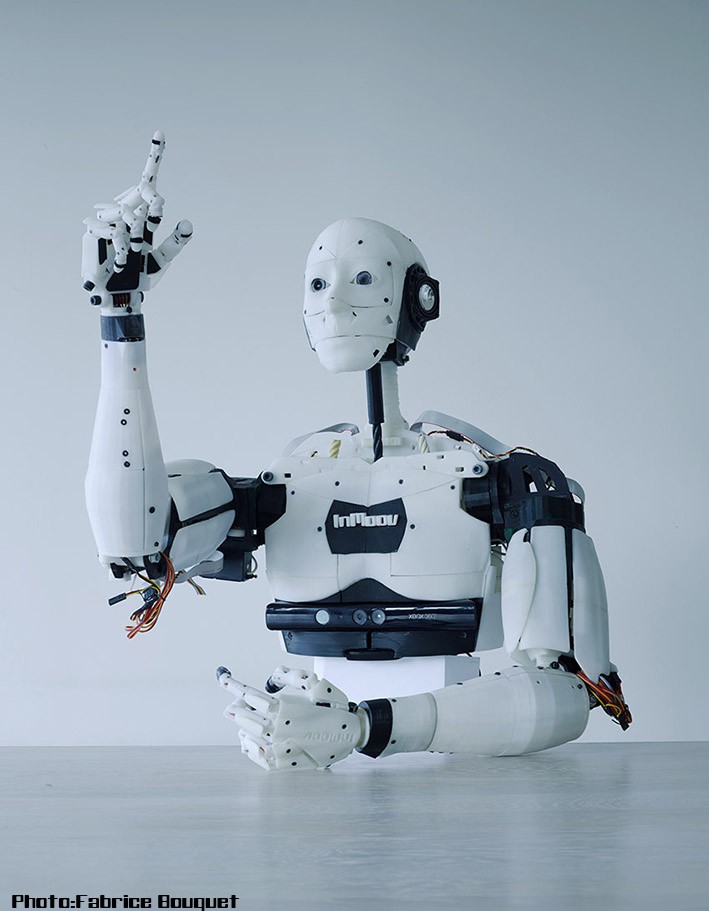
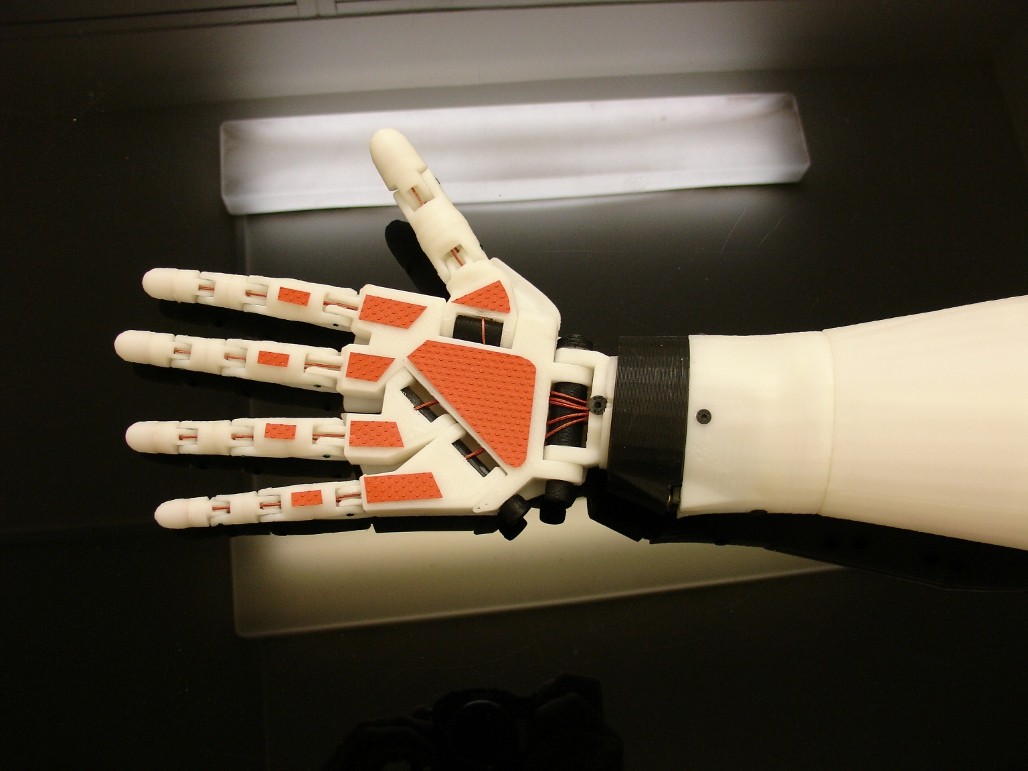
InMoov is the first open-source, life-size humanoid robot that anyone can print at home. Gaël Langevin published the files in 2012, and the constraint that shaped the whole design is a modest one: every part fits inside a 12 x 12 x 12 cm print area, so the robot can be reproduced on the cheapest desktop 3D printer rather than an industrial machine. It is built in sections — fingers, hand and forearm, bicep, shoulder and torso, back, head, neck and jaw, eye mechanism, and three stomach segments — and the usual way in is to print the finger starter, then a hand, and keep going. Servos move the joints, Arduino-based Nervo boards wire them together, and MyRobotLab handles speech, vision and gesture, with tutorials for PIR, ultrasonic and finger sensors, the Kinect and Leap Motion. What it is not is a walking robot. The legs in the official build are explicitly non-motorised: InMoov stands or sits as a life-size upper body that looks, speaks, gestures and grasps. That is the honest shape of the project, and it is enough for what it is mostly used for — universities, laboratories, hobbyists and makers who want a human-scale platform to experiment on. The project has been reproduced worldwide and has spawned variants, including the reduced MinMoov 64 and Very Mini InMoov, plus a ROS integration. Files are free under a Creative Commons Attribution-NonCommercial licence, so there is no price: the cost is filament, servos and time.
特長
- First open-source, 3D-printed, life-size humanoid robot
- Every part prints in a 12 x 12 x 12 cm build area, so any small desktop printer can make it
- Built in modules: fingers, hand and forearm, bicep, shoulder and torso, back, head, neck and jaw, eyes, three stomach sections
- Legs are NON-MOTORISED in the official build — it gestures and grasps, it does not walk
- Driven by the open-source MyRobotLab software
- designed in Blender
- Arduino-based Nervo boards for servo wiring and control
- Documented sensor options: PIR, ultrasonic, finger sensors, Kinect, Leap Motion, Neopixel
- ROS integration documented
- Files released under a Creative Commons Attribution-NonCommercial licence, free to download
- Active builder community with forums, Discord, shared STL library and events calendar
- Reduced variants documented: MinMoov 64 and Very Mini InMoov
技術仕様
検証済み| 移動性能 | |
| 移動方式 | 固定型 |
|---|---|
| 使用環境 | Indoor: workshops, classrooms and laboratories |
| センシング・演算 | |
| センサー | cameras for vision, optional PIR, ultrasonic and finger sensors, optional Kinect or Leap Motion |
| ソフトウェア / AI | MyRobotLab (open source) for speech, vision and gesture; designed in Blender |
画像
 martti
 martti
 martti
 martti
投稿画像
動画
ロボットフォーラム
フォーラムを読み込み中...
評価
よくある質問
What is the InMoov?
InMoov is the first open-source, life-size humanoid robot that anyone can print at home. Gaël Langevin published the files in 2012, and the constraint that shaped the whole design is a modest one: every part fits inside a 12 x 12 x 12 cm print area, so the robot can be reproduced on the cheapest desktop 3D printer rath…
Who makes the InMoov?
The InMoov is made by InMoov, a robotics company based in France.
How much does the InMoov cost?
InMoov has not publicly announced pricing for the InMoov. You can enquire through RobotAIGeek for current pricing.
What is the InMoov used for?
The InMoov is designed for 開発, 研究, and 教育. It is used in コンシューマー, 研究, and 教育 settings.
類似ロボットと比較
このロボットが最も近い代替候補とどう比べられるかをご覧ください
- InMoov vs Red Rabbit Robotics RX1
- InMoov vs Lanxin H6 Standard
- InMoov vs Microduck
- InMoov vs ESD Eagle X
- InMoov vs KHR-3HV Ver.3.1 (22-Axis Version)