
Quellen:
Branchen:
Anwendungen:
Preis:
Nicht angekündigt
BESCHREIBUNG
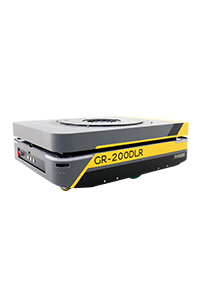
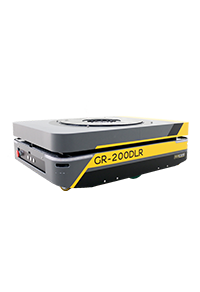
A Goods-to-Person system, the AMR system autonomously schedule material movement with bi-directional scalability to react to changing demand patterns
FUNKTIONEN
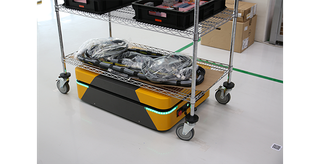
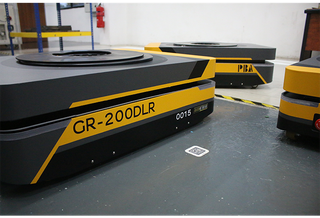
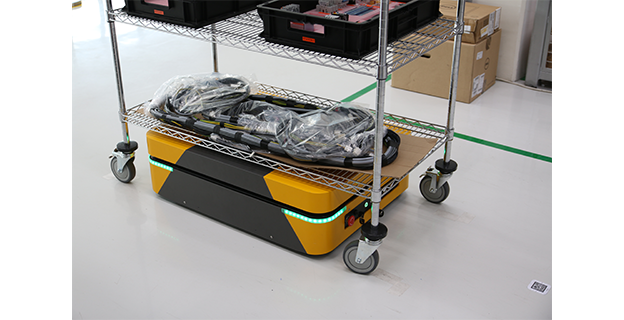
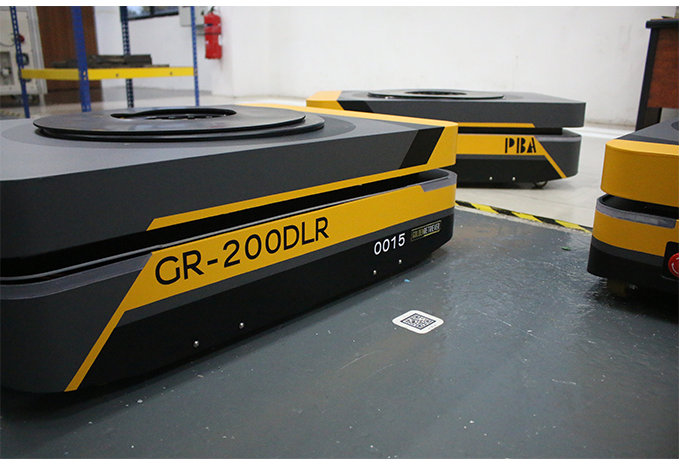
- Deck Lift AMRs are compact and manoeuvrable and are ideal for point-to-point transportation.
- The modular solution ensures bi-directional scalability to react to changing demand patterns and is adaptable for a wide range of applications.
- The AMR system can enable the autonomous scheduling of material movement according to production and storage demands.
- The AMR navigates via a grid to deliver mobile racks to workstations, carrying a shelf to the workers for picking instead, reducing the travel path for workers.
TECHNISCHE DATEN
| Mobilität | |
| Bewegungsart | Radbasiert |
|---|---|
HerstellerangabeDrittquelleOhne QuelleDer Quellenstatus basiert auf den angegebenen Quellen dieses Roboters.
TECHNISCHE DATEN
| Mobilität | |
| Bewegungsart | Radbasiert |
|---|---|
HerstellerangabeDrittquelleOhne QuelleDer Quellenstatus basiert auf den angegebenen Quellen dieses Roboters.
Bilder
 martti
Jul 31
 martti
Aug 5
 martti
Aug 5
Bildbeiträge
martti3 Bild(er)
Videos
Keine Videos verfügbar.
ROBOTER-FOREN
Foren werden geladen...
BEWERTUNGEN
Noch keine Bewertungen.
HÄUFIG GESTELLTE FRAGEN
What is the Deck Lifter?
A Goods-to-Person system, the AMR system autonomously schedule material movement with bi-directional scalability to react to changing demand patterns
Who makes the Deck Lifter?
The Deck Lifter is made by KAZE Robotics, a robotics company based in Malaysia.
How much does the Deck Lifter cost?
KAZE Robotics has not publicly announced pricing for the Deck Lifter. You can enquire through RobotAIGeek for current pricing.
What is the Deck Lifter used for?
The Deck Lifter is designed for kommissionierung and transport. It is used in lager & logistik and fertigung settings.
MIT ÄHNLICHEN ROBOTERN VERGLEICHEN
Sehen Sie, wie sich dieser Roboter gegenüber seinen nächsten Alternativen schlägt
Alternativen zu Deck Lifter →