MAXIMA-w1
描述
MAXIMA-w1是IRS (Intelligent & Integrated Robotics Solutions) / Integrated Robotics Solutions)的Humanoid。 面向機台操作、物料搬運、送貨設計。 關鍵數據:負載 10 kg。
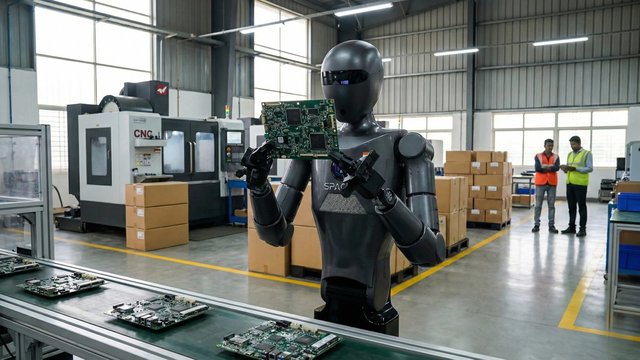
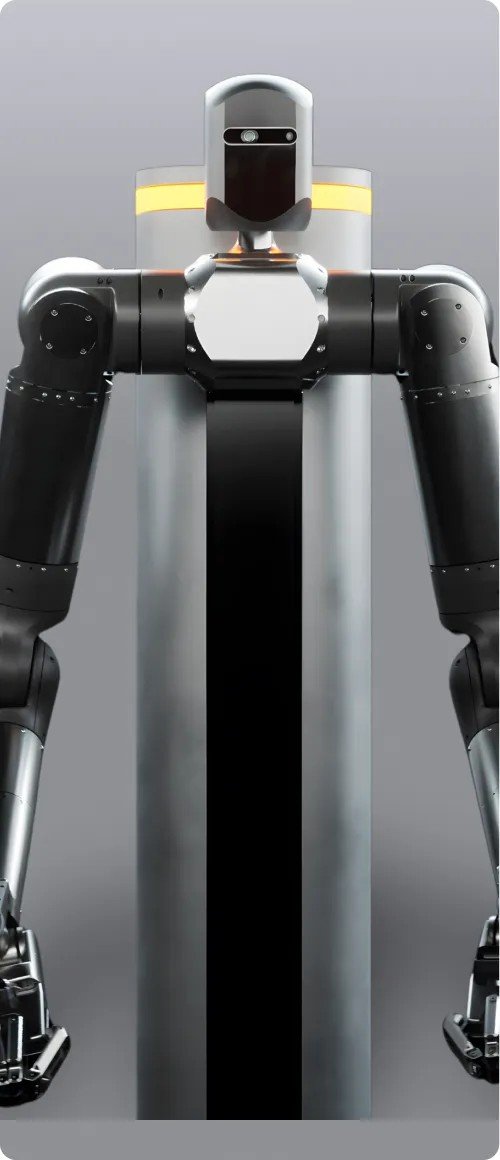
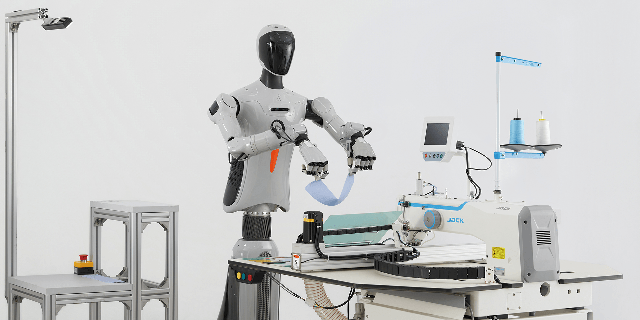
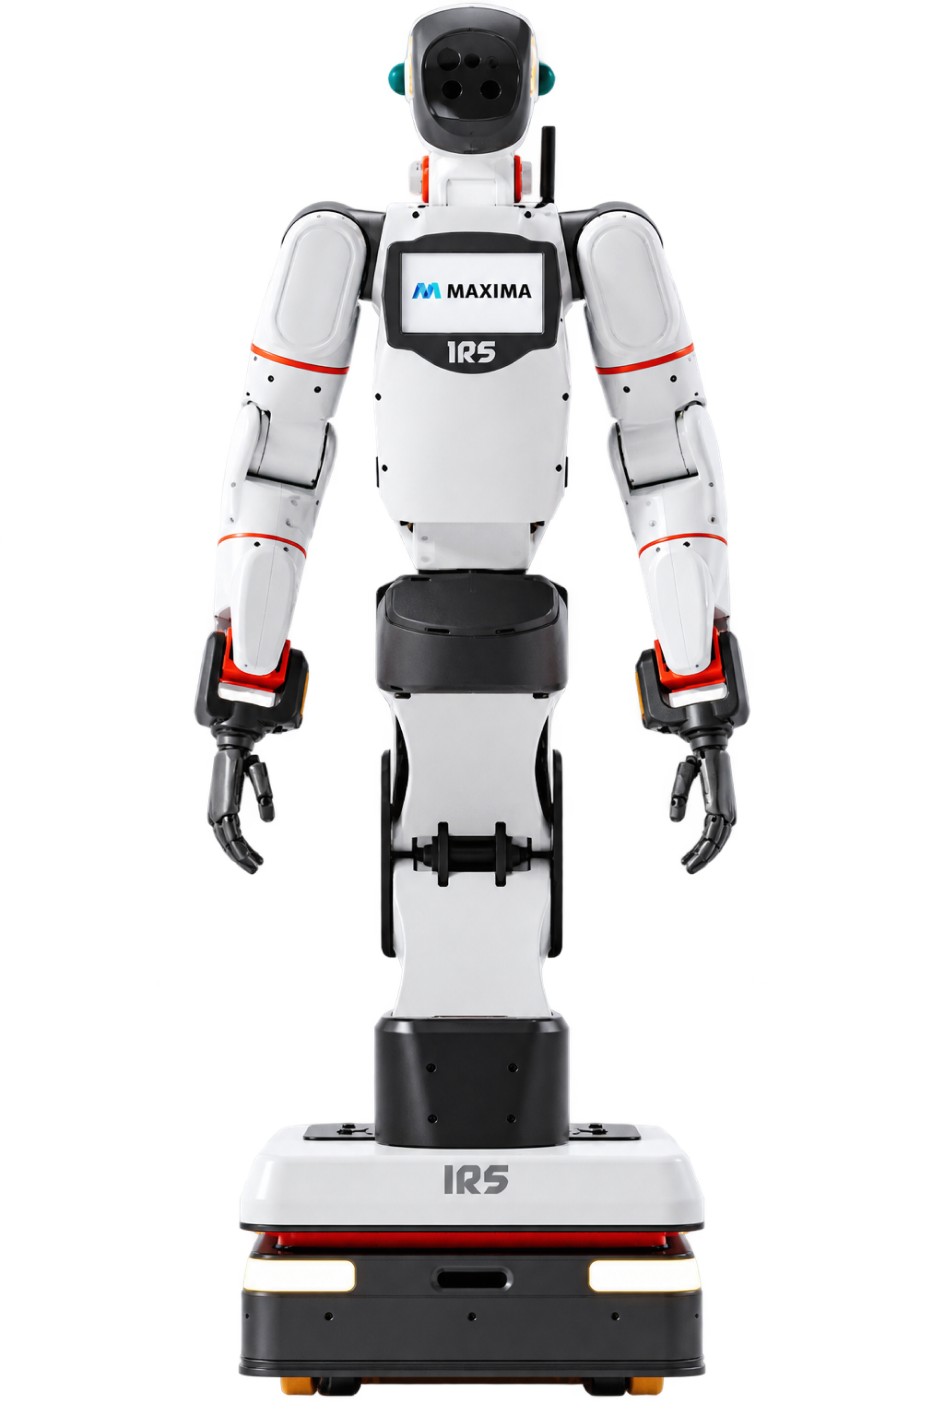
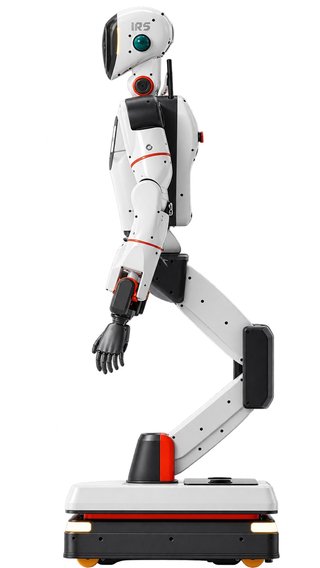
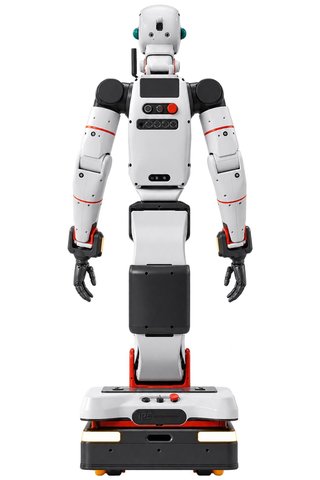
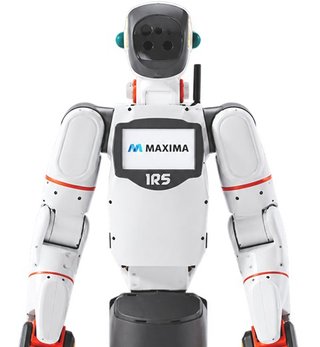
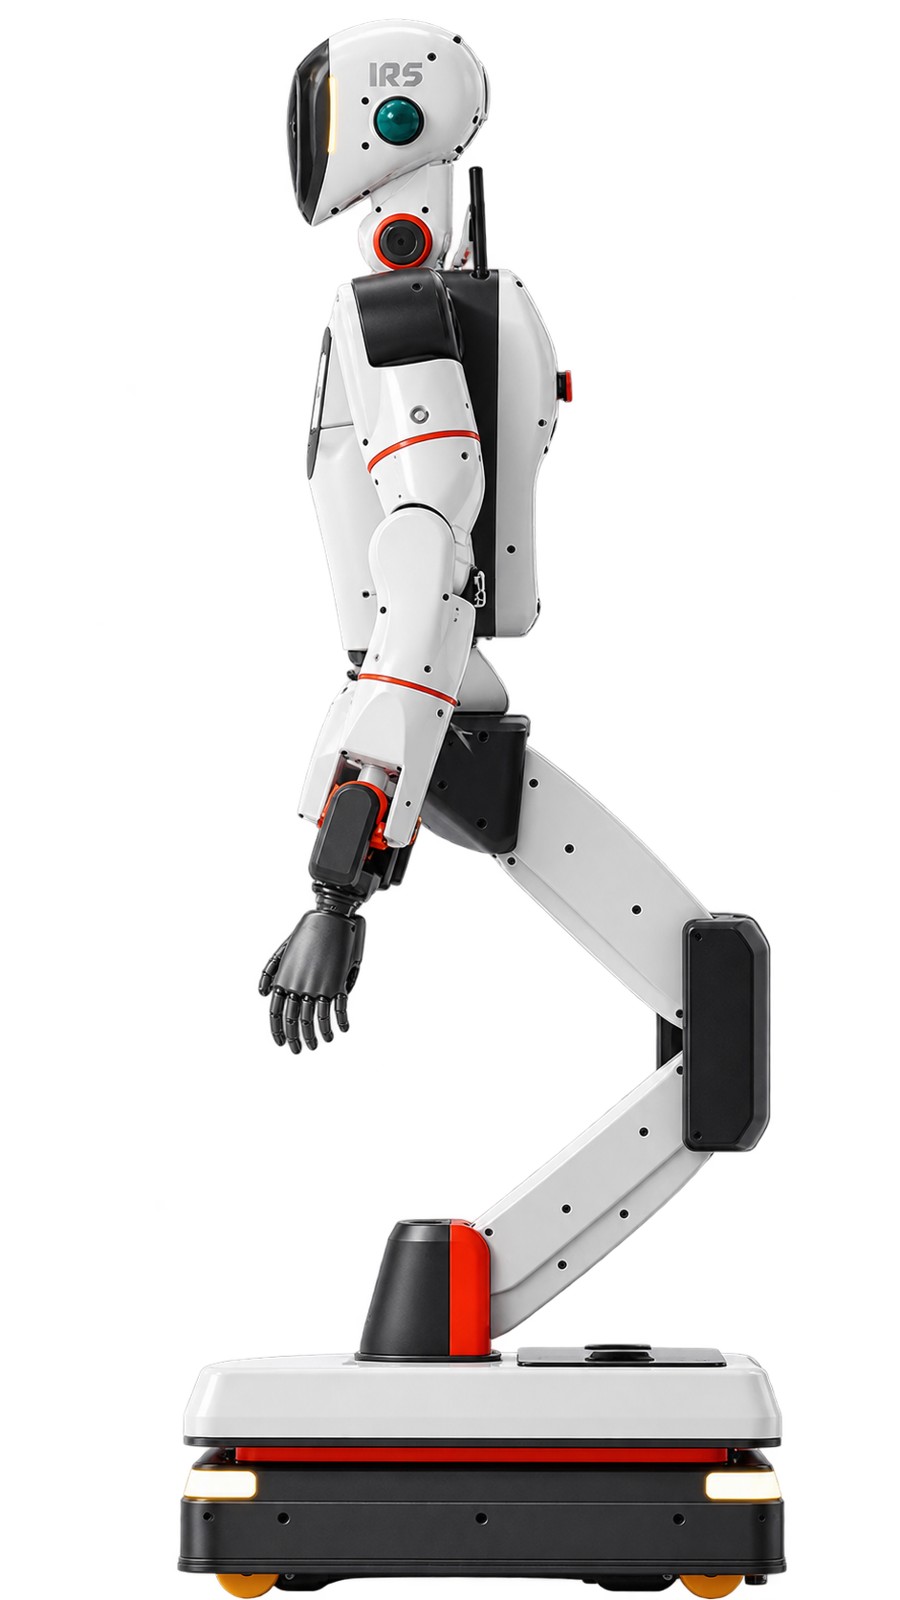
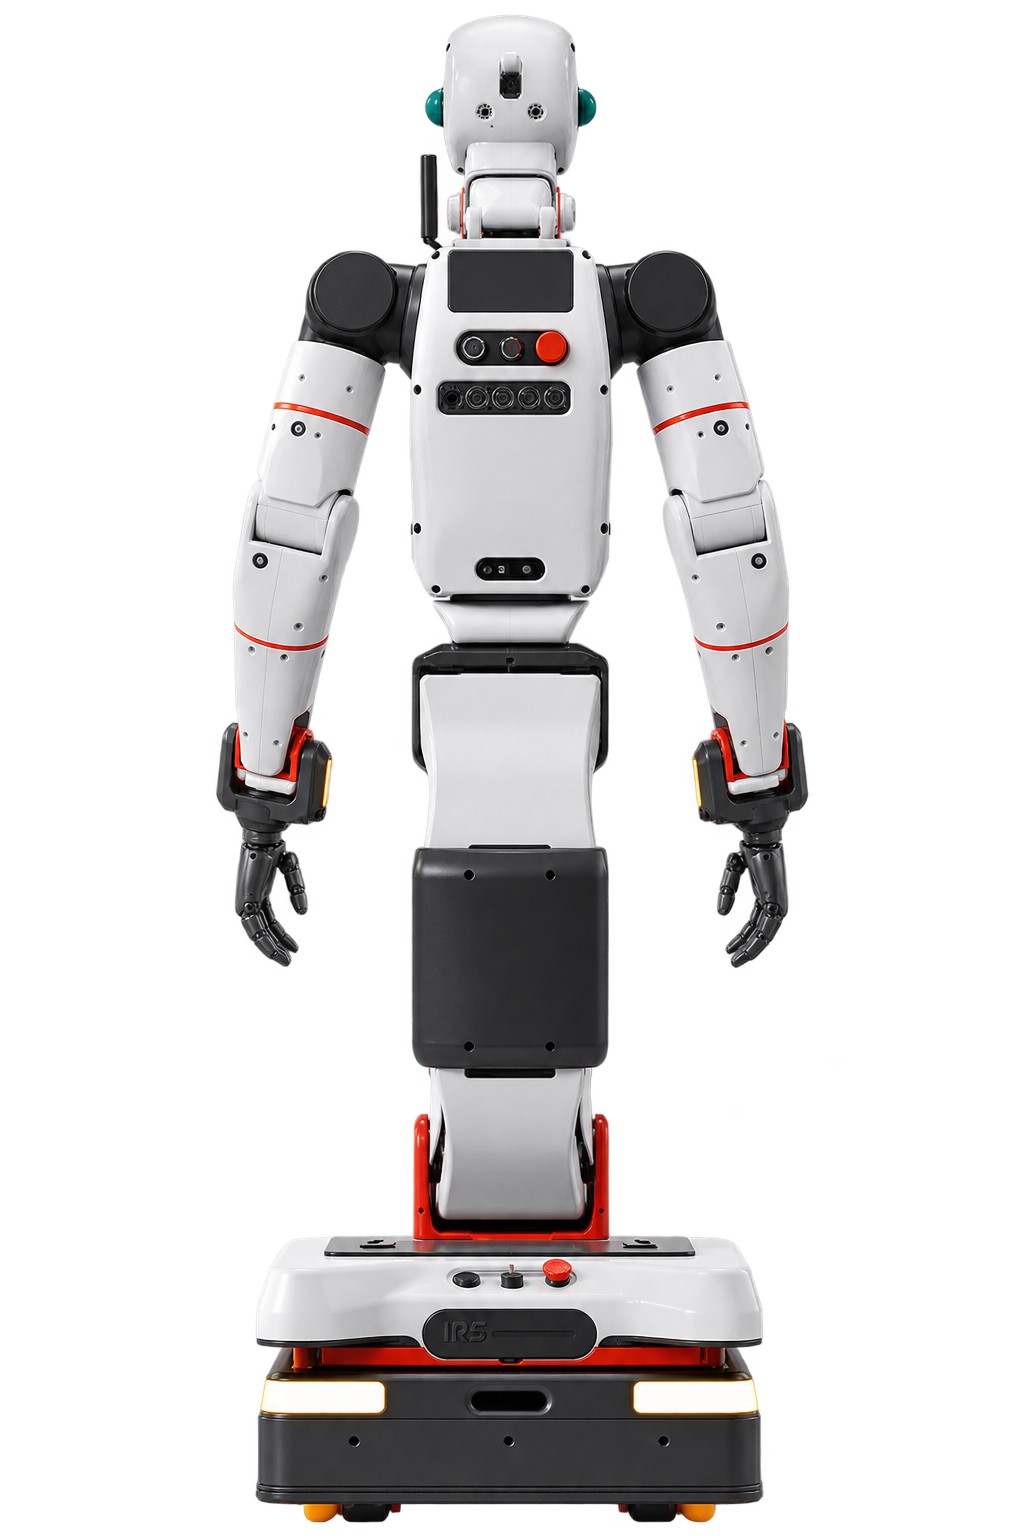
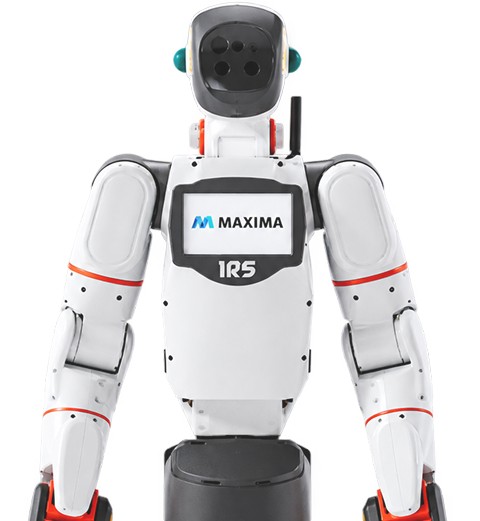
MAXIMA-w1 is IRS's general-purpose humanoid platform, a wheeled dual-arm robot built for 'brownfield' factories - existing plants laid out for people, with variable objects, dust, changing light and tight shared spaces. Rather than redesigning the site around automation, IRS's approach is to put a human-shaped machine into it. Each 7-DoF arm carries 10 kg and ends in a 6-DoF dexterous hand with a force/torque sensor, a wrist camera and tactile sensing. The head carries two 3D LiDARs, a ToF sensor, an RGBD camera, a microphone and a speaker on a 2-DoF neck, and a 3-DoF linkage-and-linear-actuator lower body tilts and rolls the torso above an omnidirectional base. The base holds two lithium-ion batteries, front and rear 2D LiDAR, an RGBD camera and collision detection, with an NVIDIA Jetson Orin; perception runs on a Jetson NX and training and inference on a Jetson Thor T5000. Wi-Fi, Bluetooth and LTE, a status LCD and dual emergency stops complete the package. Deployment comes in two phases. First the robot works under rule-based control on a ROS 2 stack - Nav2 for navigation, MoveIt2 for dual-arm motion planning, YOLOv11 and FoundationPose for 6D object pose - while logging its sensor and task data. Then operators use XR headsets or 7-DoF master arms to teleoperate it through failures and new tasks, and those demonstrations train a vision-language-action policy fine-tuned from NVIDIA's Isaac GR00T N1.7, gradually widening what it does on its own. IRS lists heavy handling of 10 kg or more per arm, industrial material handling, teleoperated tool use, vision-based operation of equipment and autonomous delivery among its tasks, with an industrial build that can wear heat-protective gear.
功能特色
- Wheeled dual-arm humanoid on an omnidirectional mobile base
- Head: multimodal sensors - 2 x 3D LiDAR, ToF, RGBD camera, microphone and speaker
- Neck: 2 DoF (tilt, roll)
- Arms: 7 DoF each (roll-pitch-roll-pitch-roll-pitch-yaw), 10 kg payload per arm
- Dexterous hands: 6 DoF with force/torque sensor, 2D wrist camera and tactile sensing
- Lower body: linkage mechanism with linear actuator, 3 DoF (tilt x 2, roll)
- Mobile base: omnidirectional drive, 2 lithium-ion batteries, NVIDIA Jetson Orin, front and rear 2D LiDAR, RGBD camera, collision-detection sensor
- Perception computing: NVIDIA Jetson NX
- Training and inference SoC: NVIDIA Jetson Thor T5000 (2,070 TFLOPS)
- Connectivity: Wi-Fi, Bluetooth, LTE
- status LCD
- dual emergency-stop switches
- ROS 2 stack: Nav2 navigation, MoveIt2 dual-arm motion planning, ros2_control, TF2
- Perception: YOLOv11 segmentation and FoundationPose 6D pose estimation
- Teleoperation: XR ego-view headset control and dual 7-DoF master devices with 6D force feedback
- VLA policy learning: NVIDIA Isaac GR00T N1.7 fine-tuned on 1,000+ demonstration episodes
- Human-in-the-loop recovery data collection for progressive autonomy
- Industrial configuration available, including heat-protective gear
- Tasks: 10 kg+ per-arm handling, industrial material handling, teleoperated tool handling, vision-based equipment operation, autonomous delivery
技術規格
已驗證| 物理參數 | |
| 負載 | 10 kg |
|---|---|
| 移動能力 | |
| 移動類型 | 帶輪的, 類人型機器人 |
| 作業環境 | Brownfield manufacturing sites: unstructured, dusty, variable lighting, confined shared spaces |
| 致動器 | 2-DoF neck, two 7-DoF arms, 6-DoF hands, 3-DoF linkage and linear-actuator lower body, omnidirectional wheeled base |
| 感知與計算 | |
| 感測器 | 3D LiDAR x2 (head), ToF sensor, RGBD camera (head), microphone, front and rear 2D LiDAR, RGBD camera (base), collision-detection sensor, force/torque sensors (hands), 2D wrist cameras, tactile sensors |
| 連線方式 | Wi-Fi, Bluetooth, LTE |
| 軟體 / AI | ROS 2 (Nav2, MoveIt2, ros2_control, TF2); YOLOv11 + FoundationPose 6D pose; XR and master-device teleoperation; NVIDIA Isaac GR00T N1.7 VLA policy fine-tuning |
圖片
 martti
 martti
 martti
 martti
圖片貢獻
影片
機器人論壇
正在載入論壇...
評分
常見問題
What is the MAXIMA-w1?
MAXIMA-w1 is IRS's general-purpose humanoid platform, a wheeled dual-arm robot built for 'brownfield' factories - existing plants laid out for people, with variable objects, dust, changing light and tight shared spaces.
Who makes the MAXIMA-w1?
The MAXIMA-w1 is made by IRS (Intelligent & Integrated Robotics Solutions) / Integrated Robotics Solutions), a robotics company based in South Korea.
How much does the MAXIMA-w1 cost?
IRS (Intelligent & Integrated Robotics Solutions) / Integrated Robotics Solutions) has not publicly announced pricing for the MAXIMA-w1. You can enquire through RobotAIGeek for current pricing.
What is the MAXIMA-w1 used for?
The MAXIMA-w1 is designed for 機台操作, 物料搬運, 送貨, and industrial material handling. It is used in 研究, 建築, and 製造業 settings.
What is the payload capacity of the MAXIMA-w1?
The MAXIMA-w1 has a payload capacity of 10 kg.
與同類機器人對比
看看這款機器人與最接近的同類產品相比表現如何
- MAXIMA-w1 vs KUAVO 5-W MAX
- MAXIMA-w1 vs iSAGEBOT SageMan Quad-arm Robot
- MAXIMA-w1 vs iSAGEBOT iSAGE STAR Dual-arm Robot
- MAXIMA-w1 vs AEON
- MAXIMA-w1 vs POLCERO Humanoid on Mobile Platform